
Robot grabbing positioning device as well as robot grabbing system and method
A technology of grasping, positioning and robotics, which is applied in the field of robotics and can solve the problems of large space occupation
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2017-08-04
Smart Images
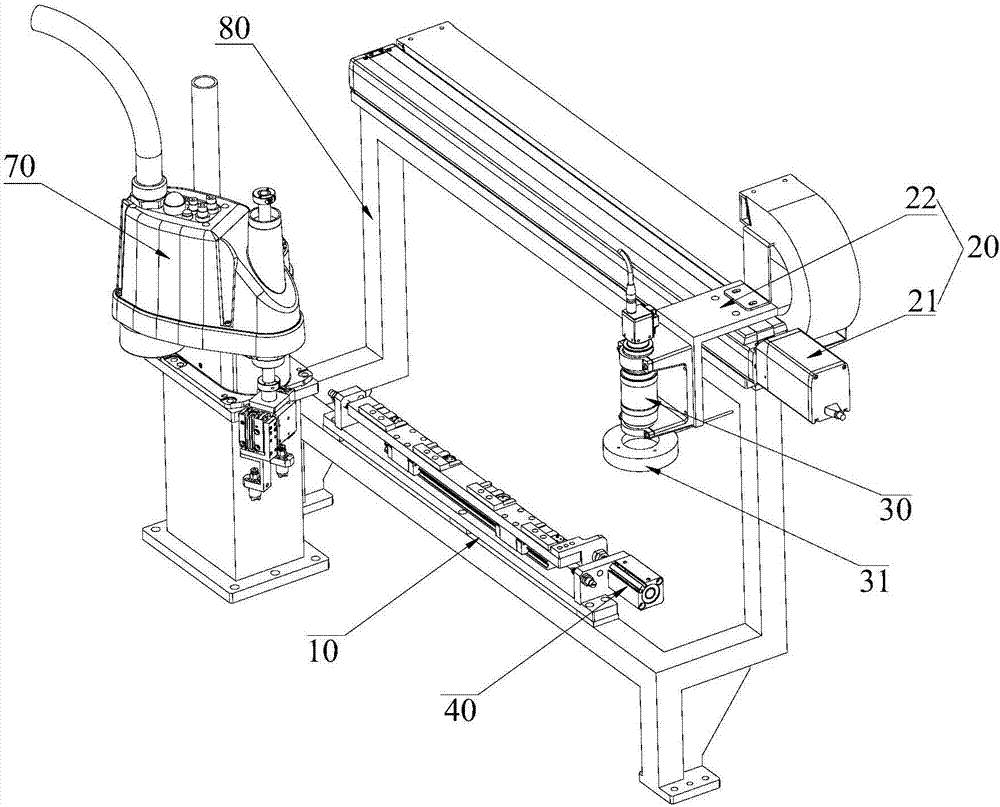
Figure 1 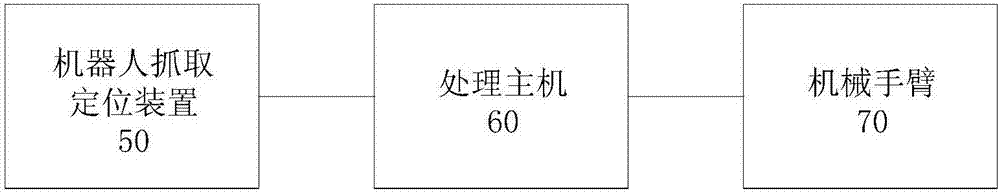
Figure 2 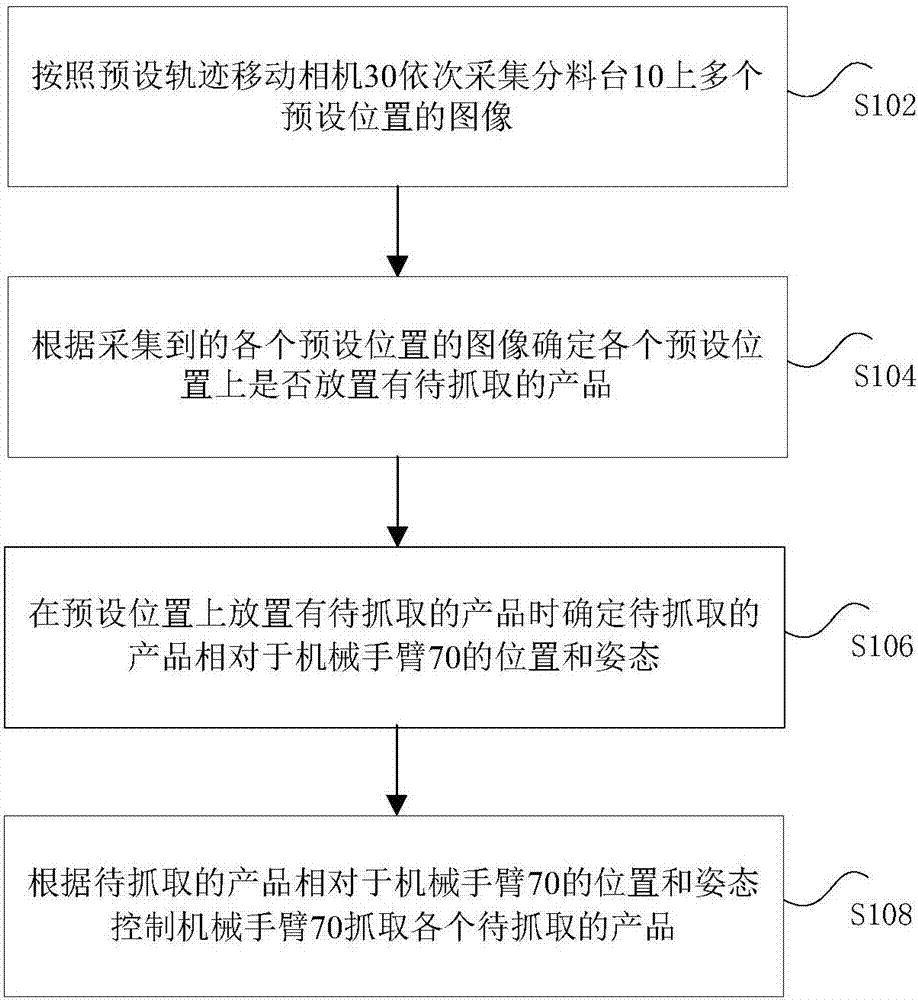
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of robots, in particular to a robot grasping and positioning device, a robot grasping system and a grasping method. Background technique
[0002] In the field of automation, robots play an important role. With the development of automation, the application of robots is becoming more and more extensive. The introduction of machine vision makes the robot stable, reliable, efficient and more intelligent at the same time.
[0003] As the "eye" of the robot, machine vision guides the robot to achieve intelligent grasping. The flexible production line uses visual positioning, and the robot automatically recognizes the product type for positioning and grasping, thereby improving production efficiency.
[0004] However, in practical applications, the robot needs to grab multiple products to complete the task. Due to the different materials of the products, the reflective effect will be very different and the products will b...
Examples
Embodiment Construction
[0032] It should be noted that, in the case of no conflict, the embodiments of the present invention and the features in the embodiments can be combined with each other. The present invention will be described in detail below with reference to the accompanying drawings and examples.
[0033] In order to enable those skilled in the art to better understand the solutions of the present invention, the following will clearly and completely describe the technical solutions in the embodiments of the present invention in conjunction with the drawings in the embodiments of the present invention. Obviously, the described embodiments are only It is an embodiment of a part of the present invention, but not all embodiments. Based on the embodiments of the present invention, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts shall fall within the protection scope of the present invention.
[0034] According to the robot grasping position...