
Robot servo motor wire
A technology of servo motors and motor wires, applied in the direction of electromechanical devices, circuits, electrical components, etc., can solve the problems of frequent robot movement, easy loose connection of wire ends, poor applicability and matching, etc., to improve convenience, increase applicability, and firm connection Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2019-09-20
Smart Images
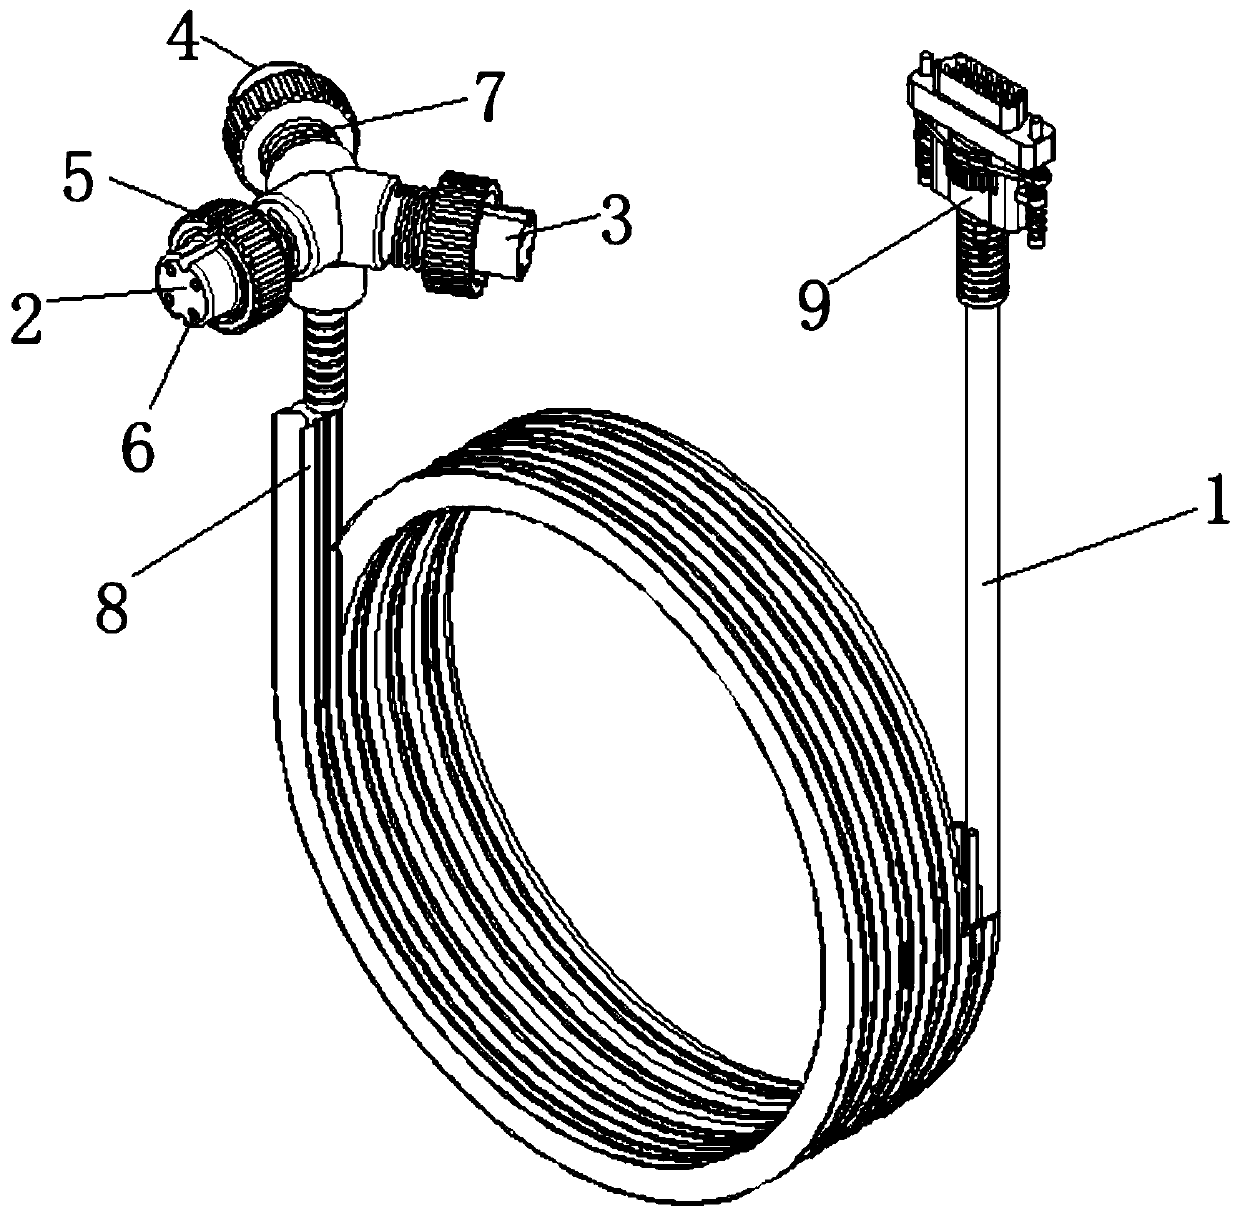
Figure 1 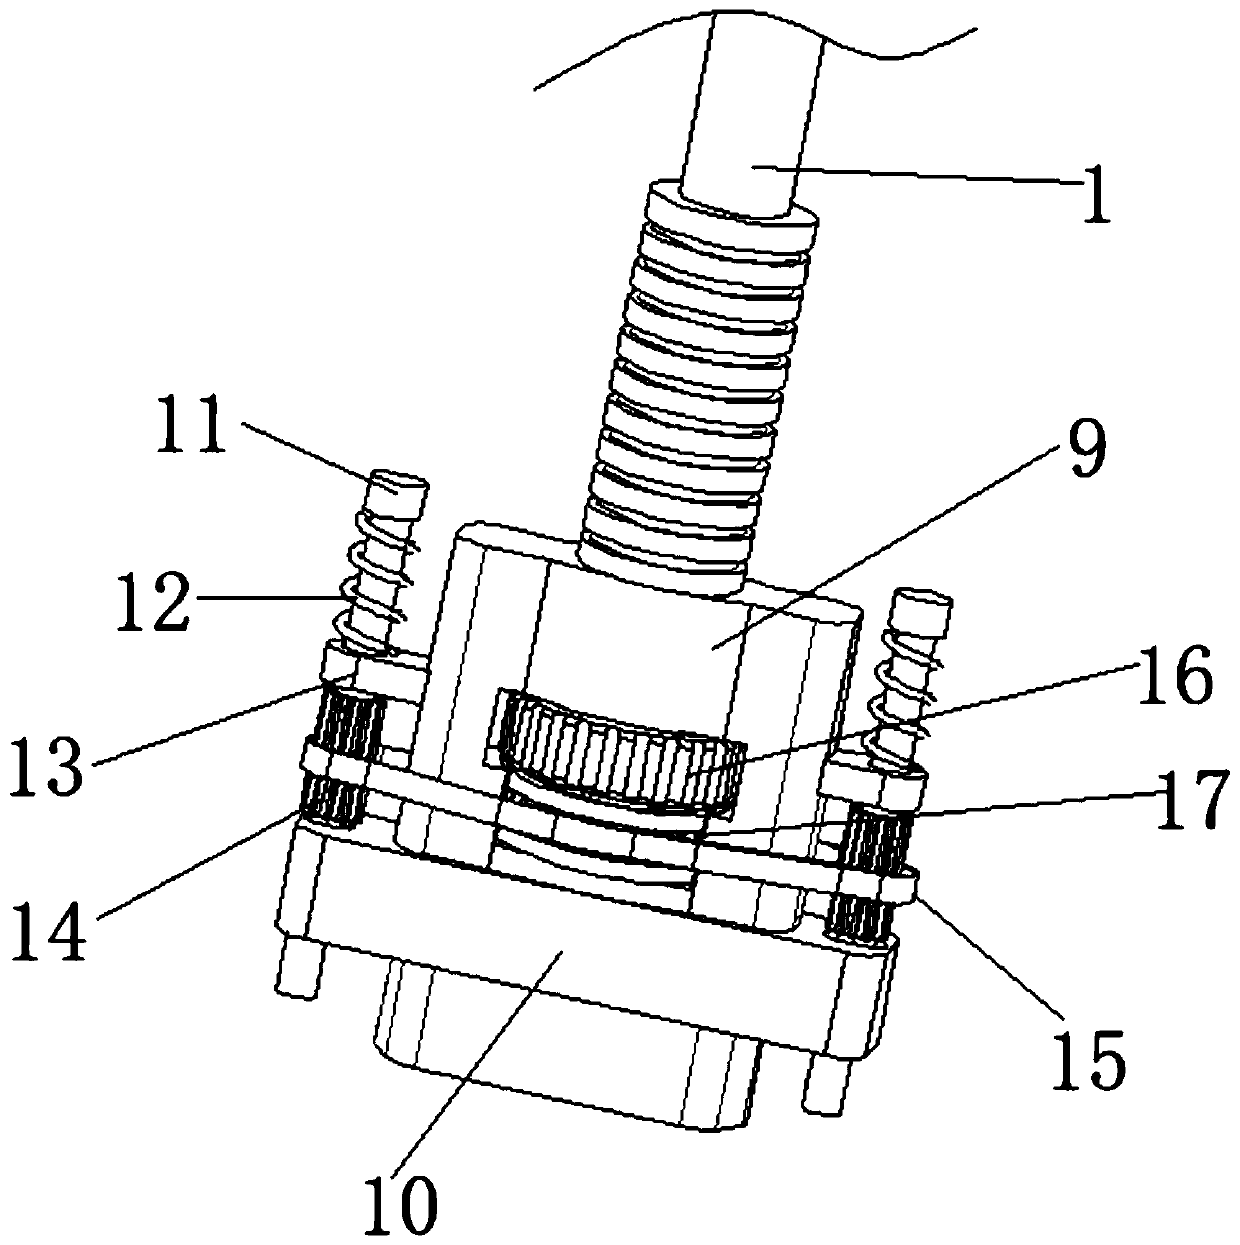
Figure 2 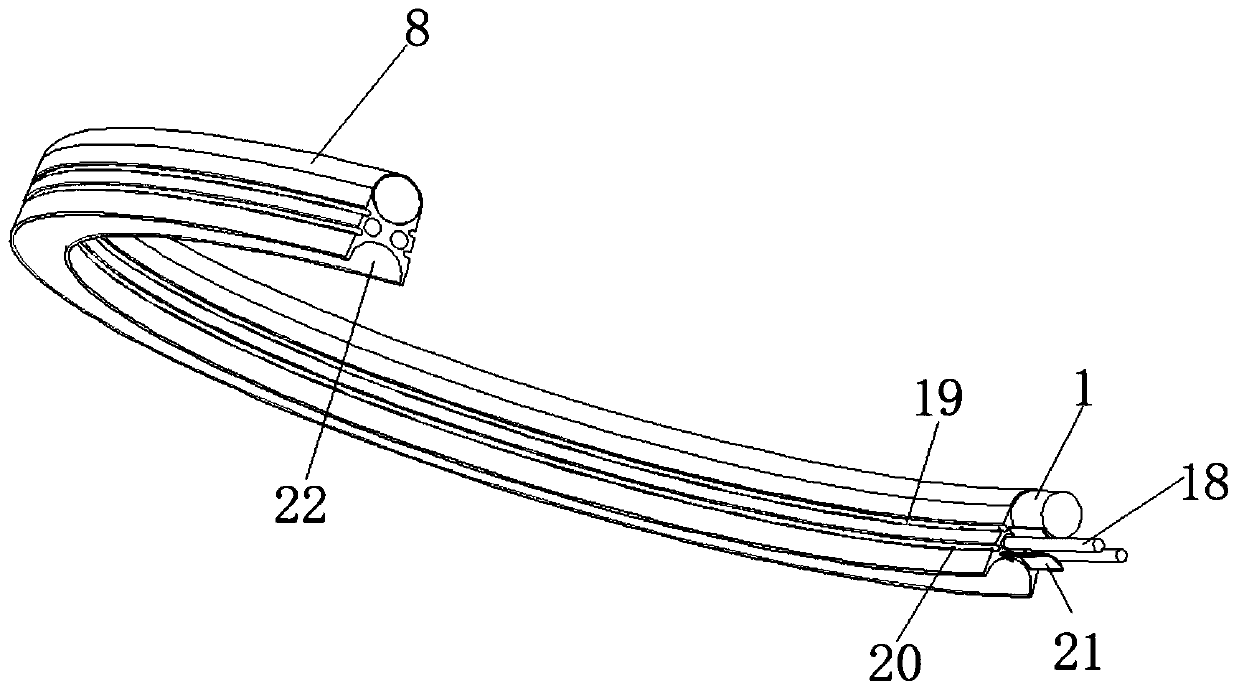
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of motor connecting wires, in particular to a robot servo motor wire. Background technique
[0002] The servo motor can control the speed and position accuracy very accurately, and can convert the voltage signal into torque and speed to drive the control object. The rotor speed of the servo motor is controlled by the input signal and can respond quickly. In the automatic control system, it is used as an actuator, and has the characteristics of small electromechanical time constant, high linearity, and starting voltage. It can convert the received electrical signal Converted to angular displacement or angular velocity output on the motor shaft. It is divided into two categories: DC and AC servo motors. Its main feature is that when the signal voltage is zero, there is no self-rotation phenomenon, and the speed decreases at a uniform speed with the increase of torque. Servo motors are necessary driving device...
Examples
Embodiment Construction
[0016] The following will clearly and completely describe the technical solutions in the embodiments of the present invention with reference to the accompanying drawings in the embodiments of the present invention. Obviously, the described embodiments are only some, not all, embodiments of the present invention.
[0017] refer to Figure 1-3 , a robot servo motor line, including a motor line 1, the motor line 1 is an encoder cable, one end of the motor line 1 is provided with a first body connector 2, a second body connector 3 and a third body connector 4 in parallel, The first body connecting head 2, the second body connecting head 3 and the third body connecting head 4 are arranged at equal angles, and the three body connecting heads are all rotated and connected with a locking threaded cap 5, and the locking threaded cap 5 is connected to the body A first spring 7 is fixedly arranged between one side of the connector, and the wiring holes 6 on the three body connectors have...