
Device and method for vibration detection and control of parallel platform based on laser displacement sensor
A laser displacement and vibration detection technology, applied in measurement devices, program-controlled manipulators, instruments, etc., can solve the problems of high noise measurement of accelerometers, application limitations, and changing system structural characteristics.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2016-07-06
Smart Images
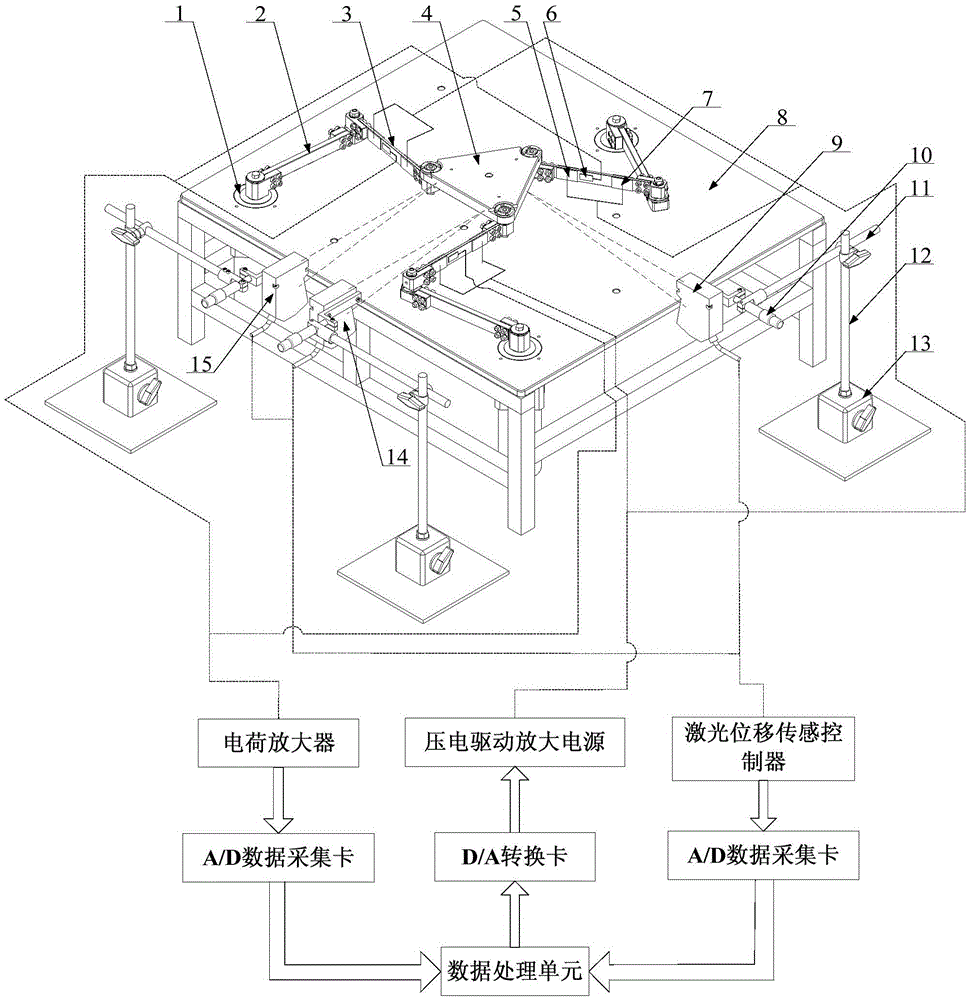
Figure 1 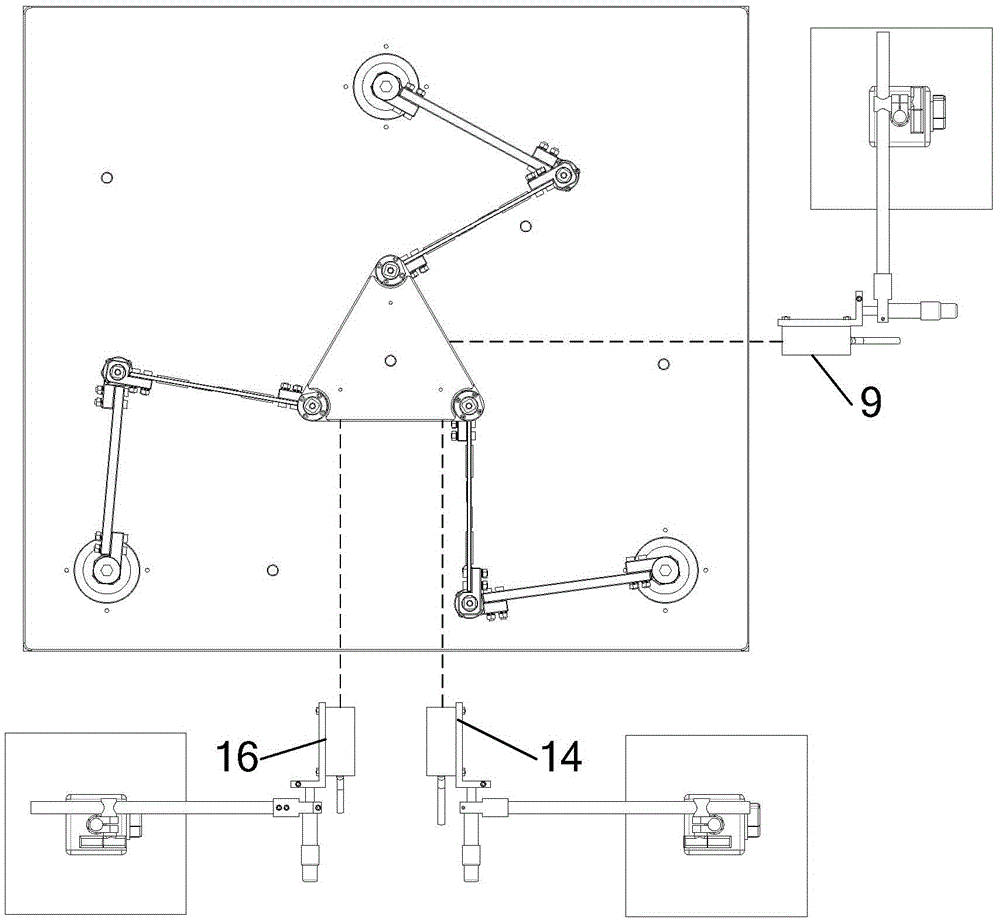
Figure 2 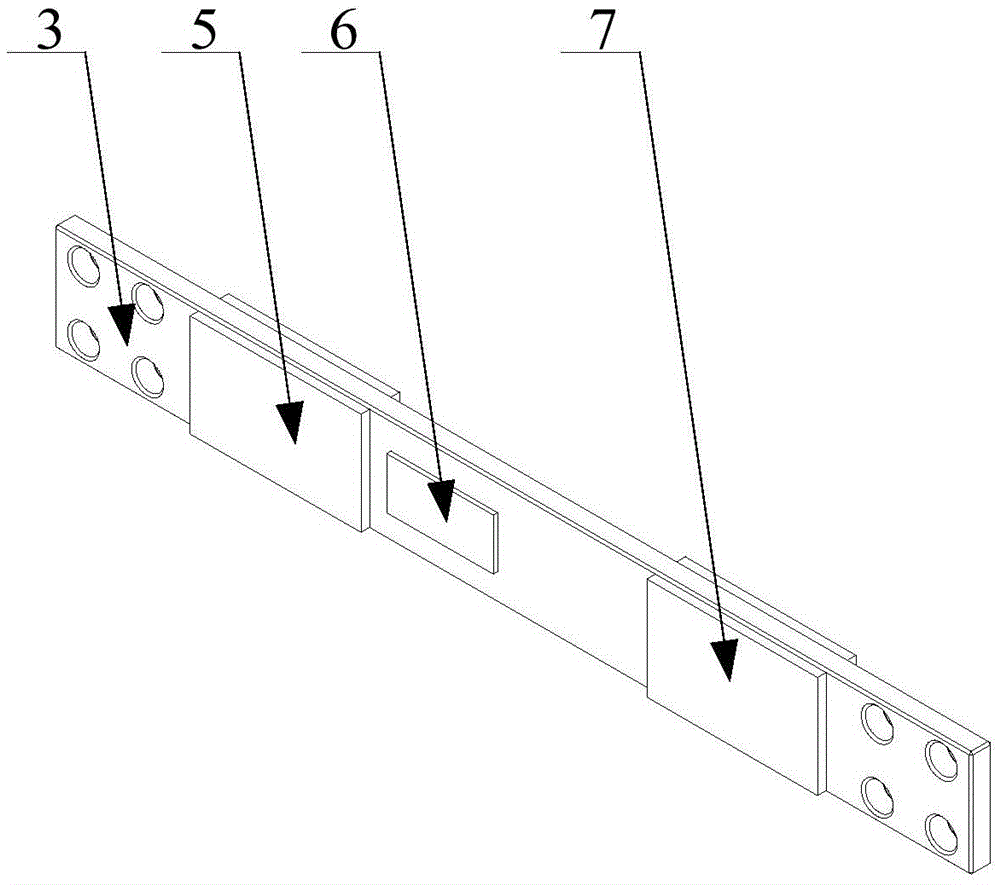
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the research field of positioning vibration detection and control of a flexible parallel platform, in particular to a vibration detection and control device and method for a parallel platform based on a laser displacement sensor. Background technique
[0002] A parallel robot is a robot that includes a parallel mechanism. The parallel mechanism is that the end effector with several degrees of freedom is connected to the fixed base through two or more independent motion branch chains. A parallel robot consists of two platforms, namely a dynamic platform and a static platform (also known as a fixed platform). The static platform is fixed on the base or connected to the end effector of another robot, and the dynamic platform moves relative to the static platform. The two platforms are connected by two or more branch chains. It has two or more degrees of freedom, and the drives are generally distributed on one end connected to the...
Examples
Embodiment 1
[0040] For the structure of the laser displacement sensor-based parallel platform vibration detection and control device described in this embodiment, see figure 1 , the device includes a parallel platform body unit, a vibration detection unit, and a vibration control unit. The above-mentioned units will be described in detail below with reference to the figures.
[0041] The parallel platform body unit includes a moving platform 4, a static platform 8 and three parallel branches, and the moving platform 4 is an equilateral triangle. Each parallel branch includes a motor 1, an active rod 2 and a driven flexible rod 3. The motor 1 in this embodiment is an Yaskawa servo motor, which is respectively installed on the edge of the static platform 8, and each motor shaft end is connected to an active rod 2. The other end of each active rod 2 is connected to a driven flexible rod 3 through a rotating shaft, and the other end of each driven flexible rod 3 is connected to a moving platf...