
A dynamic platform mechanism of ball screw series rack and pinion type
A technology of rack and pinion and ball screw, which is applied in the field of robotics, can solve the problems of limited application range and inflexible movement of the movable platform, and achieve the effect of small deflection angle and large deflection angle
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2019-03-22
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
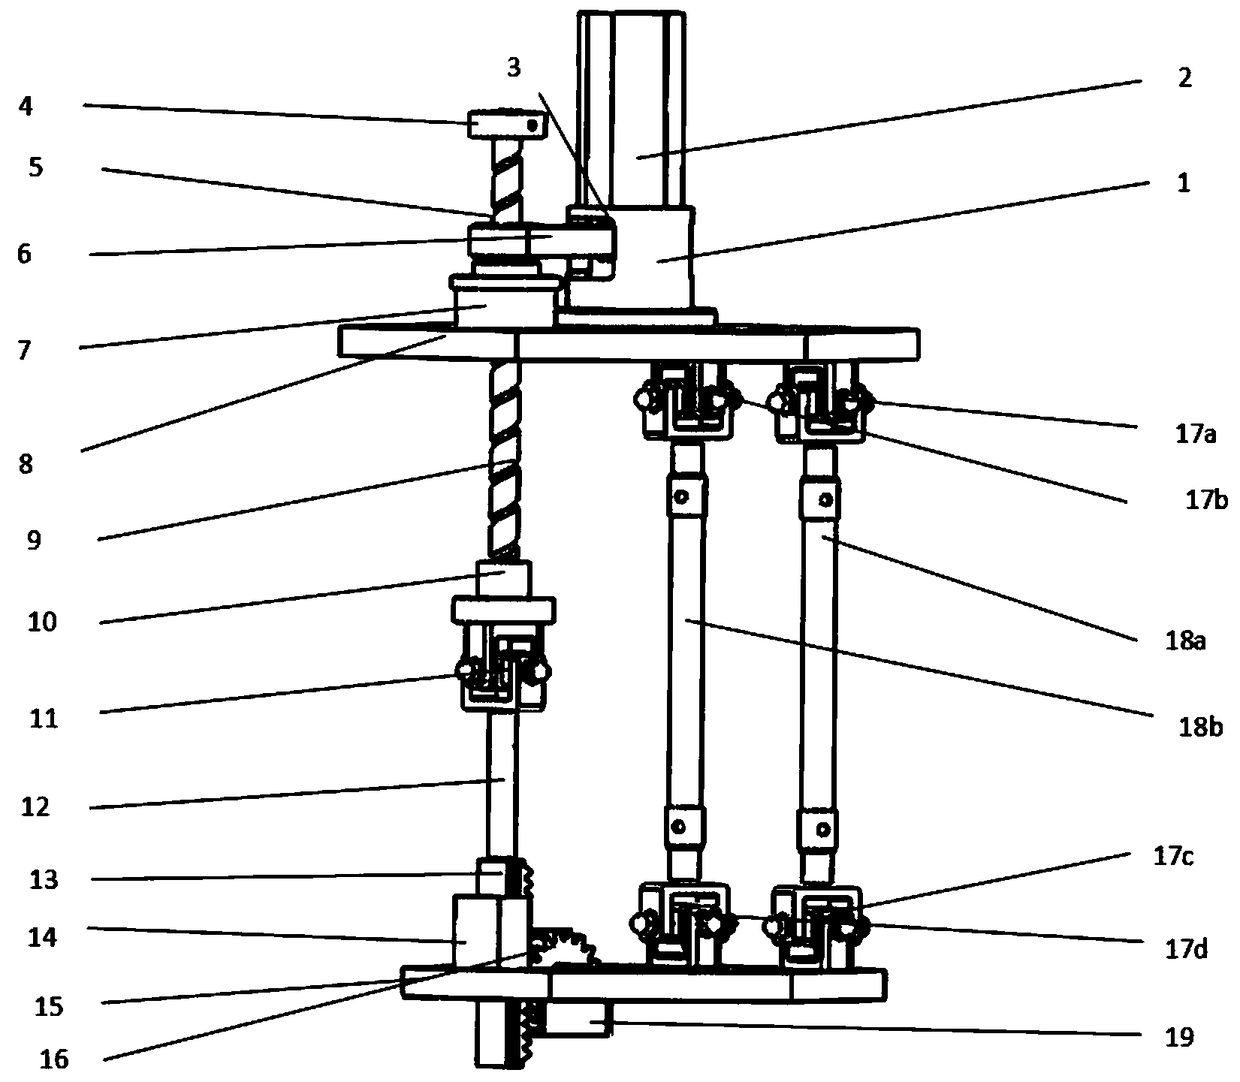
Figure 1 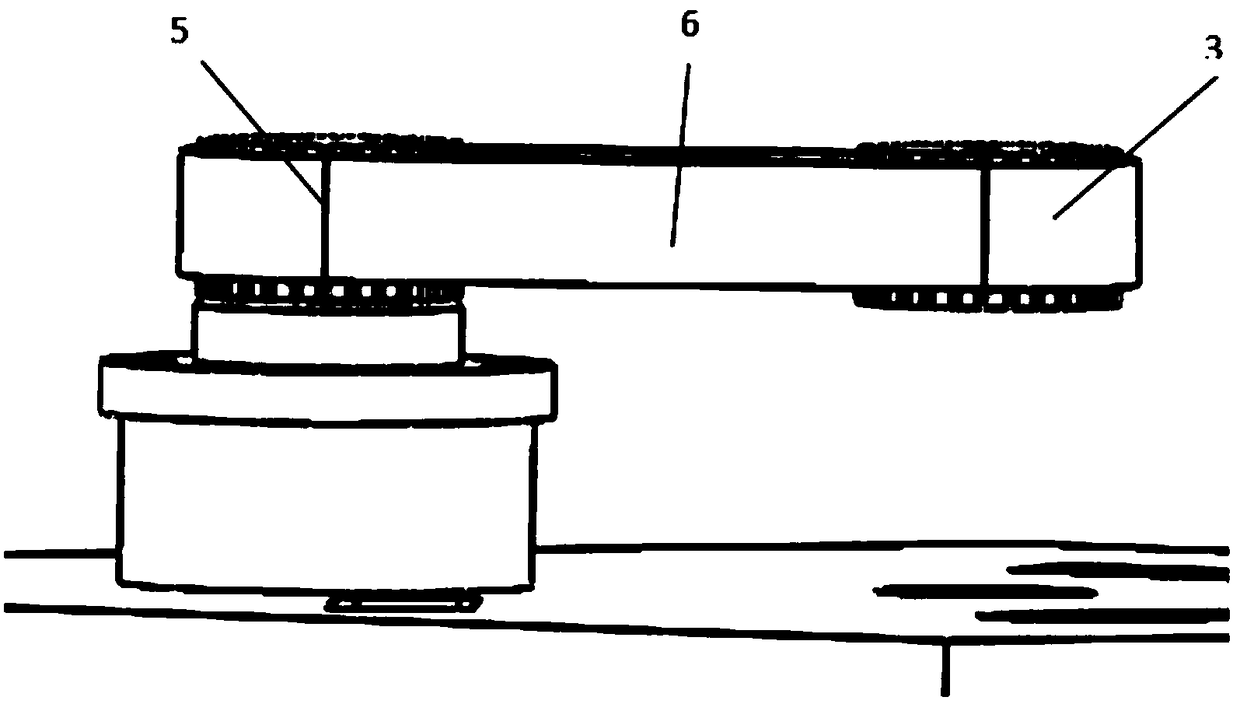
Figure 2 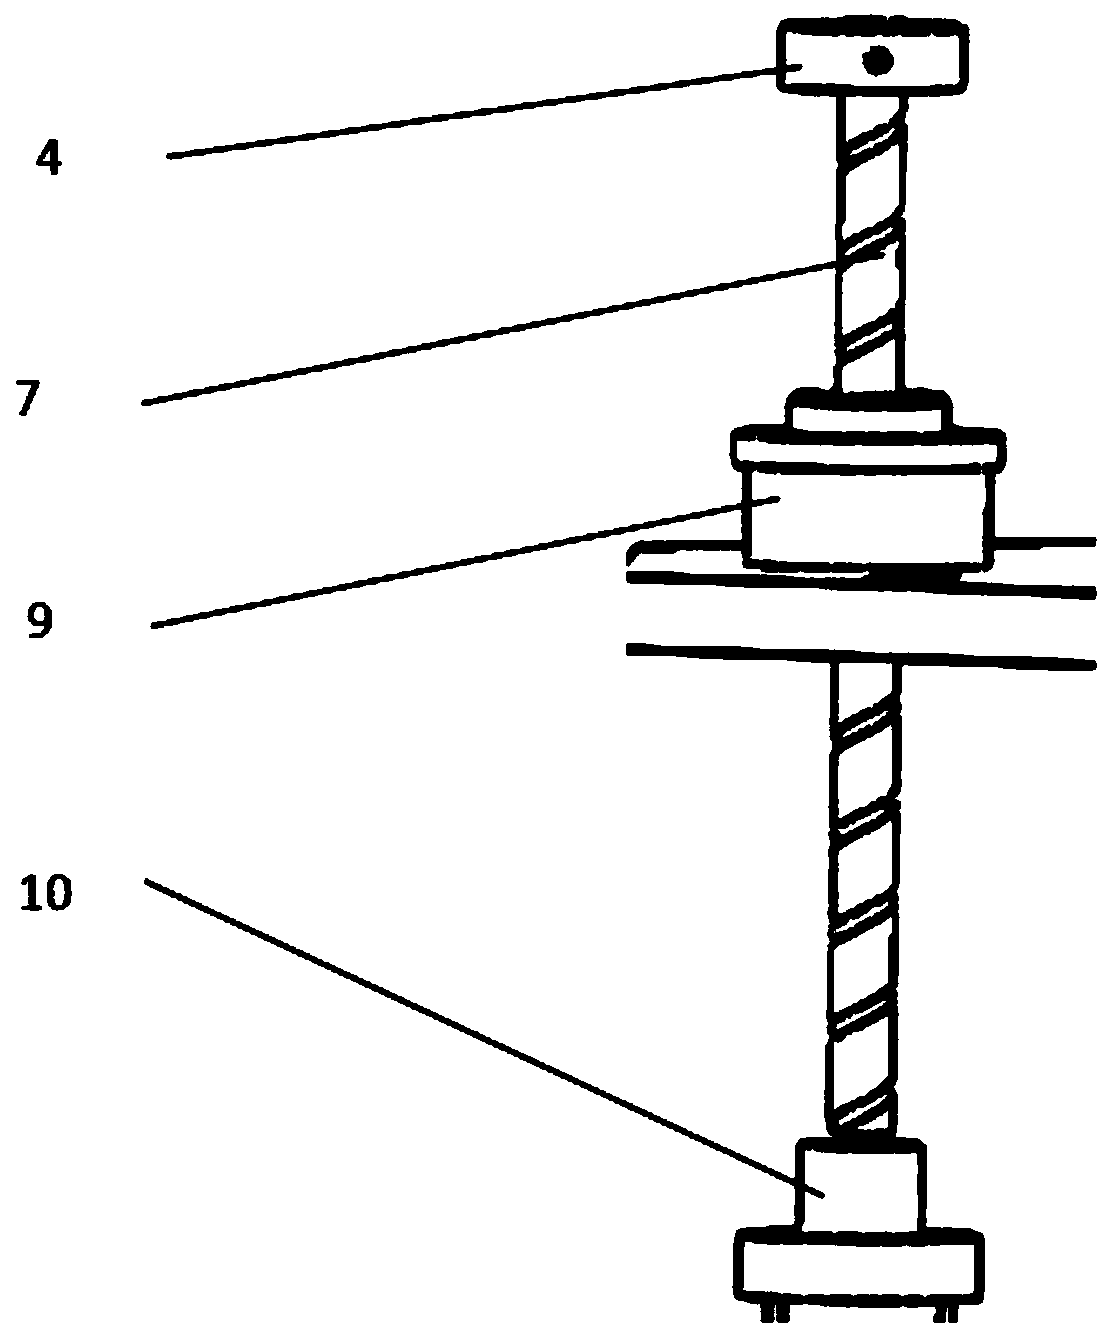
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of robots, and specifically designs a dynamic platform mechanism of a rack and pinion type in series with ball screws. Background technique
[0002] In the automated production lines of light industry, medicine, food and electronics industries, such as sorting, packaging and packaging, especially in repetitive, boring and dangerous tasks such as material handling and machine tool loading and unloading, in order to reduce human labor Strength, improve work efficiency, often need to place repetitive work robots in the space in the work process. However, the movement of the active platform of many mainstream parallel robots is not flexible enough, and the rotation range of the end piece is generally only about 40 degrees or less, and its application range is limited. Contents of the invention
[0003] The present invention aims at the deficiencies in the above-mentioned prior art, and provides a ball screw t...
Examples
Embodiment Construction
[0016] The present invention will be further described below in conjunction with accompanying drawing:
[0017] Such as figure 1 , figure 2 , image 3 , Figure 4 As shown, a ball screw type moving platform mechanism includes a synchronous belt mechanism, a ball screw mechanism, a rack and pinion mechanism, an upper moving platform, a lower moving platform, a moving platform connecting rod, etc., and the upper and lower moving platforms, the screw and the gear The bar connecting rod and the moving platform connecting rod form a closed-loop mechanism, and the lengths of the two moving platform connecting rods are the same.
[0018] Such as figure 1 , figure 2 , image 3 As shown, the synchronous belt pulley 5 is connected to the inner ring of the lead screw nut 7, the axes of the synchronous belt pulley 3 and the synchronous belt pulley 5 are parallel and the end faces are on the same plane parallel to the upper moving platform 8, and the synchronous belt mechanism is d...