
Multi-steering-wheel cooperative control method for omnidirectional mobile AGV
A collaborative control, omnidirectional movement technology, applied in electric controllers, non-electric variable control, control/regulation systems, etc., can solve problems such as force mismatch between gear trains, reduce asynchrony, improve motion accuracy and Operational efficiency, the effect of reducing internal force
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2020-06-19
Smart Images
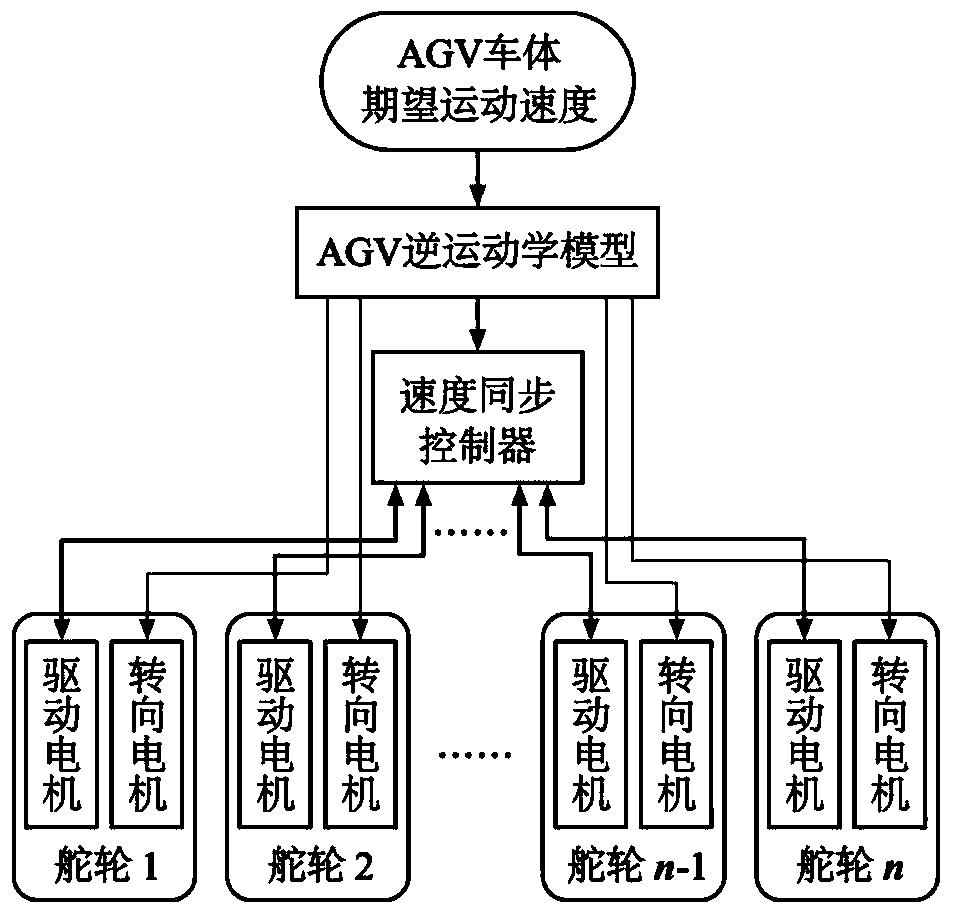
Figure 1 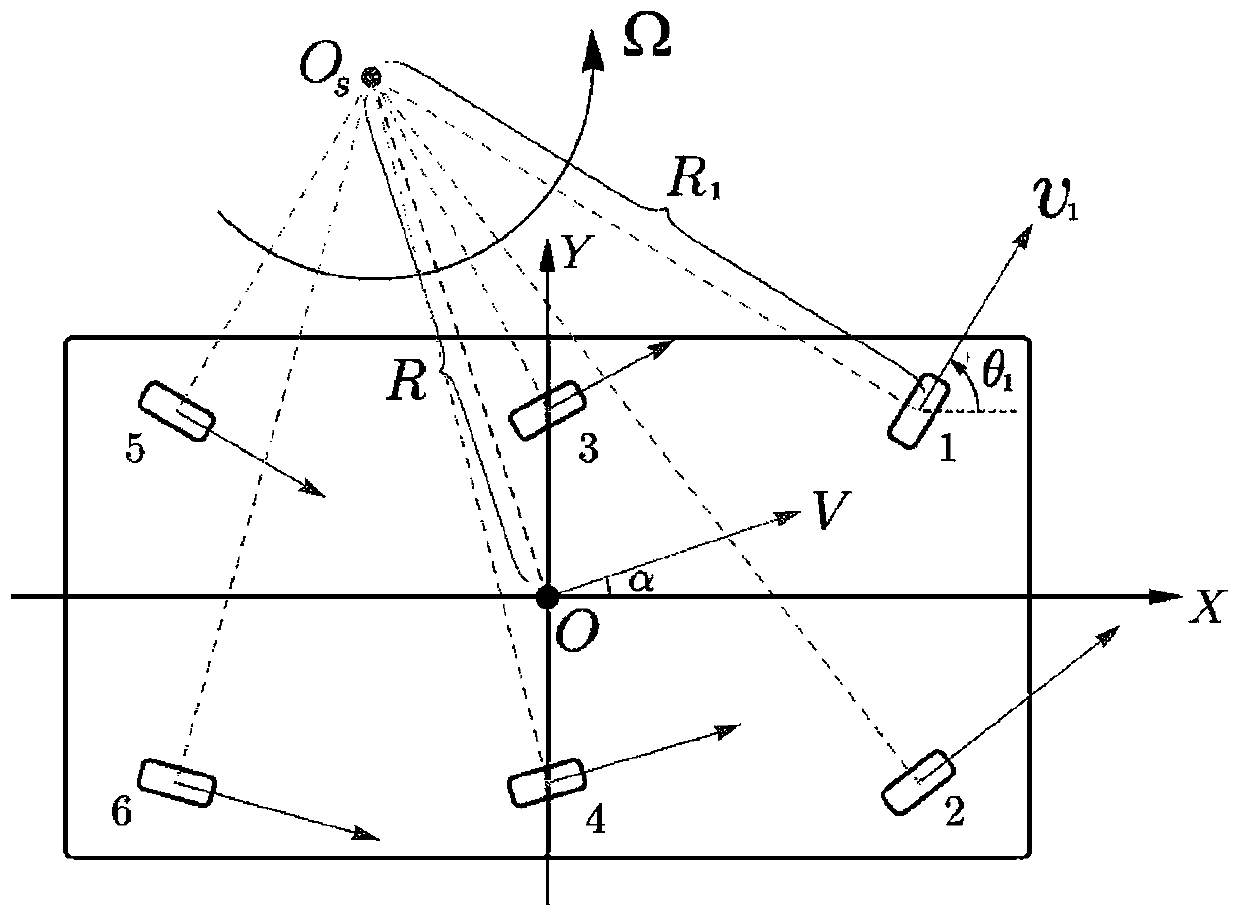
Figure 2 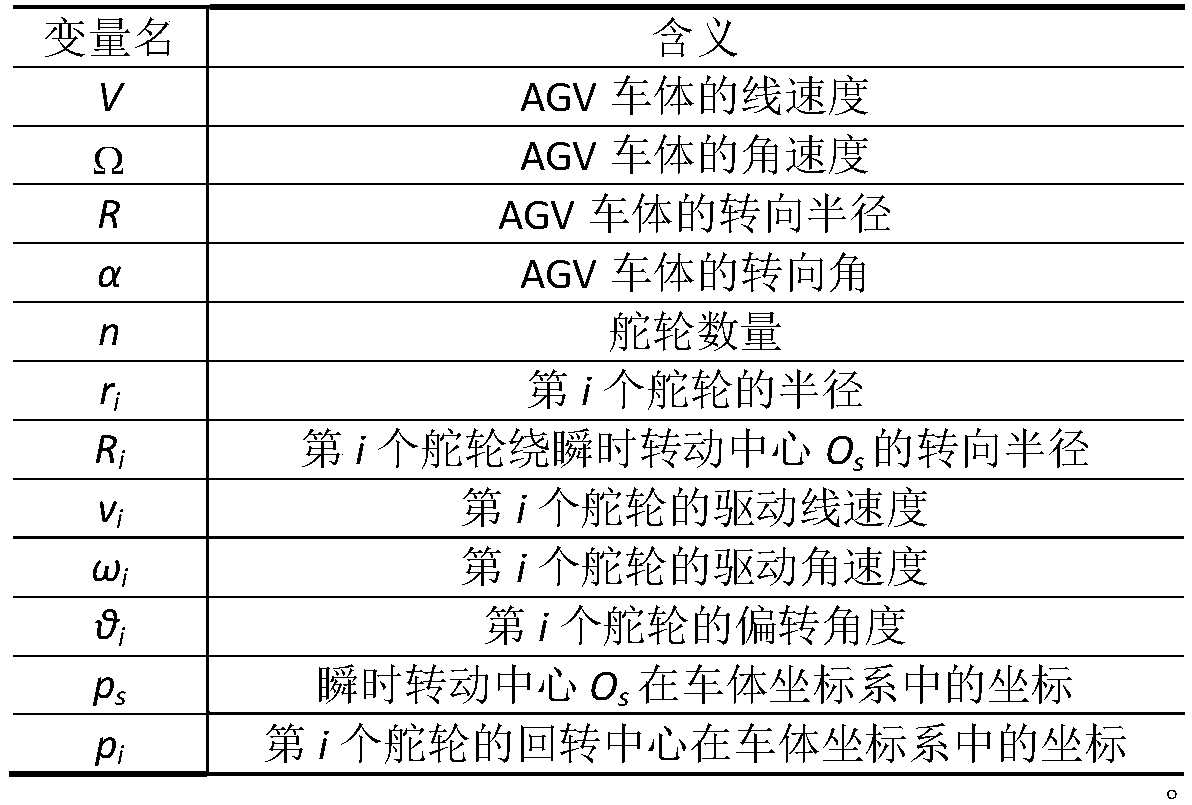
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of AGV (Automatic Guided Vehicle) motion control, and more specifically relates to a control method capable of realizing omnidirectional motion of a multi-rudder wheel driven AGV. Background technique
[0002] AGV (Automatic Guided Vehicle) is a wheeled mobile robot that can automatically drive along a prescribed path through a dispatch system or manual control, and it is widely used in the manufacturing and logistics industries. Many scenarios require the AGV to have omnidirectional mobility, that is, it can rotate around any point in the plane, or move in any direction without changing the posture of the car body. Existing omnidirectional mobile AGVs usually use mecanum wheel drive. The mecanum wheel has simple control and flexible movement, but its movement efficiency is low, and due to the limitation of structure and material, its single wheel bearing capacity is not large, and its price is relatively h...
Examples
Embodiment Construction
[0028] In order to make the purpose, technical solution and advantages of the present invention clearer, the technical solution of the present invention will be described in detail below taking an AGV with six steering wheels as an example. Apparently, the described embodiments are only some of the embodiments of the present invention, but not all of them. Based on the embodiments of the present invention, all other implementations obtained by persons of ordinary skill in the art without making creative efforts fall within the protection scope of the present invention.
[0029] A wheel group cooperative motion control method for a steering wheel-driven AGV, the cooperative motion method obtains the driving and steering control quantities of each steering wheel through an inverse kinematics model and speed compensation, and controls the speed of the steering wheel drive motor and the steering motor The angular position control of the system effectively solves the problem of for...