Calibration method for binocular vision navigation system of lunar rover

A navigation system and binocular vision technology, which is applied to measurement devices, instruments, etc., can solve the problems of unsuitable dual cameras, oscillation of fitting parameters, and many undetermined coefficients, so as to improve the accuracy of calibration and improve work efficiency. Simple to use effects

Active Publication Date: 2011-12-21
BEIJING INST OF CONTROL ENG
View PDF0 Cites 0 Cited by
  • Summary
  • Abstract
  • Description
  • Claims
  • Application Information

AI Technical Summary

Problems solved by technology

This calibration method is characterized by many undetermined coefficients and unclear meanings, and high-order quadratic equations are prone to produce fitting parameter oscillations. It is not suitable for close-range cameras (non-infinity target imaging) and dual cameras.

Method used

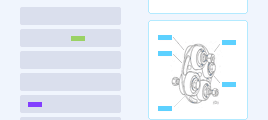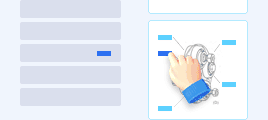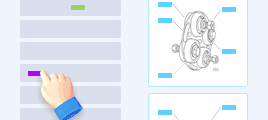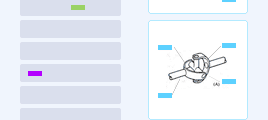
the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
View more

Image

Smart Image Click on the blue labels to locate them in the text.
Viewing Examples
Smart Image
  • Calibration method for binocular vision navigation system of lunar rover
  • Calibration method for binocular vision navigation system of lunar rover
  • Calibration method for binocular vision navigation system of lunar rover

Examples

Experimental program
Comparison scheme
Effect test

Embodiment

[0085] Steps to calibrate the internal parameters of the camera to be calibrated first:

[0086] (1) Establish a calibration device that includes a circular retroreflective measurement mark and a coding mark with a diameter of 10mm (or a diameter of 8mm) made of reflective materials produced by the US 3M company (models: 7610) and placed in the experiment. Indoors, the three-dimensional coordinates representing the relative position of the calibration device can be obtained. Use the industrial measurement system developed by Zhengzhou Chenwei Technology Co., Ltd. or the V-STARS digital photogrammetry system to measure the retroreflection measurement marks and coding marks in the calibration device. Carry out the measurement to obtain the three-dimensional coordinates of the backlight measurement reflection mark and the coding mark on the calibration device as the control point coordinates, and then convert the control point coordinates into the coordinate system of the calibrat...

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

PUM

No PUM Login to View More

Abstract

A method for calibrating a binocular vision navigation system of a lunar rover, using a measuring system to measure a calibrating device including a light reflection measurement mark and a coded mark to obtain control point coordinates, using two cameras to be calibrated to take pictures of the calibrating device, and then using The collinear equation can calibrate the internal parameters of the two cameras to be calibrated and the external parameters of the two cameras to be calibrated relative to the calibration device at various positions; use theodolite measurement system with the calibration device to calibrate the respective cube mirrors of the two cameras to be calibrated The coordinate system, using the respective cubic mirror coordinate system and the external parameters of the two cameras to be calibrated relative to the calibration device at each position, realizes the calibration of the respective external parameters of the two cameras to be calibrated. The invention fundamentally solves the problem that the camera coordinate system cannot be obtained by direct measurement, and makes the camera coordinate system visible; meanwhile, the invention has simple operation, high calibration precision and high work efficiency.

Description

technical field [0001] The invention relates to a calibration method for a binocular vision navigation system of a lunar rover, which is mainly used in the fields of digital photogrammetry, computer vision and the like. Background technique [0002] The binocular visual navigation system of the lunar rover is mainly composed of two digital cameras and two cubic mirrors, such as figure 1 As shown, two cubic mirrors are respectively fixed on two cameras. The binocular visual navigation of the lunar rover mainly relies on two digital cameras to obtain external information at the same time to determine its own position, including visual measurement, terrain matching, path planning, etc. In the binocular vision navigation system, system comprehensive calibration is the key technology, and accurate calibration is the basis to ensure correct navigation. Therefore, the calibration accuracy of the binocular vision navigation system of the lunar rover directly determines whether the...

Claims

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

Application Information

Patent Timeline
no application Login to View More
Patent Type & AuthorityPatents(China)
IPC IPC(8): G01C25/00
Inventor李春艳王立卢欣范生宏李晓周建涛刘淑娟
OwnerBEIJING INST OF CONTROL ENG