
Position sensor-free control technology for four-phase doubly salient motor
A sensor technology, double salient motor technology, applied in the field of position sensorless control and motor control, can solve the problems of inability to obtain the commutation point, RC filter potential phase offset, low sine degree, etc.
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2013-01-30
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
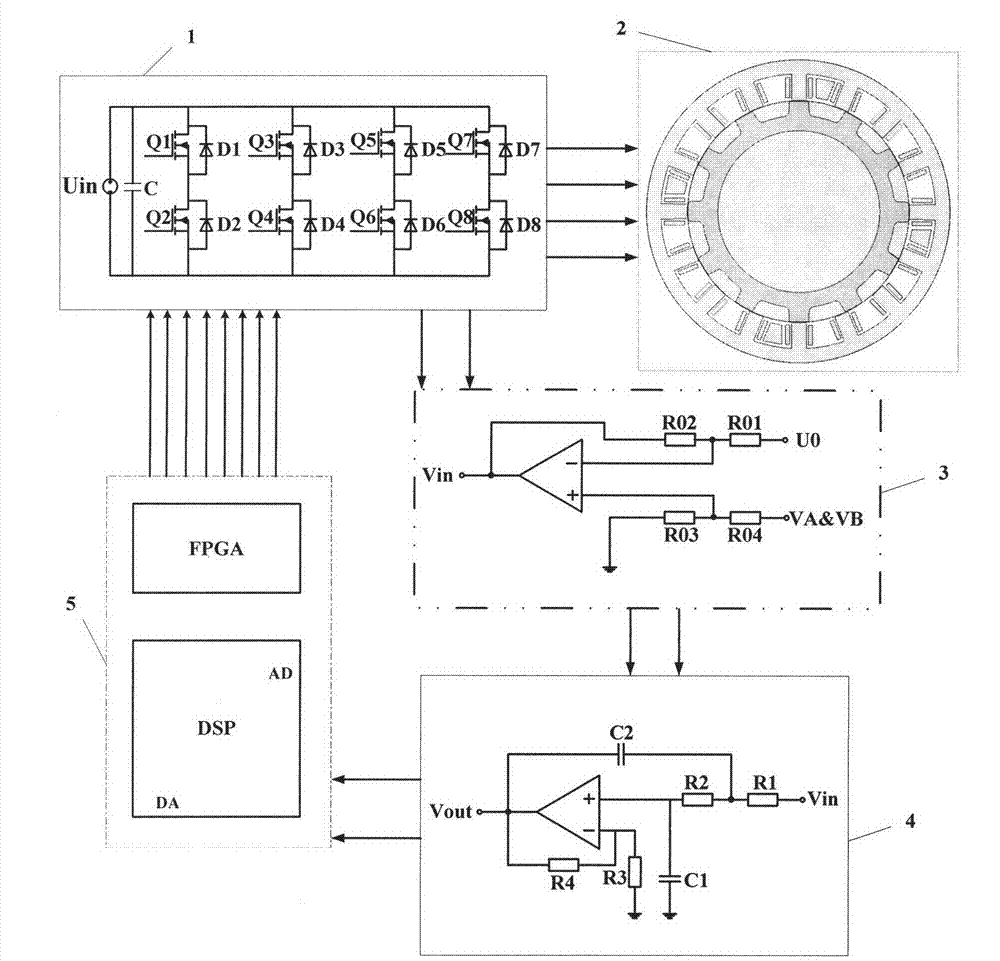
Figure 1 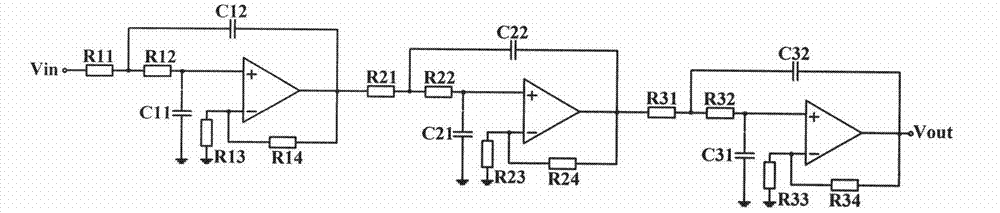
Figure 2 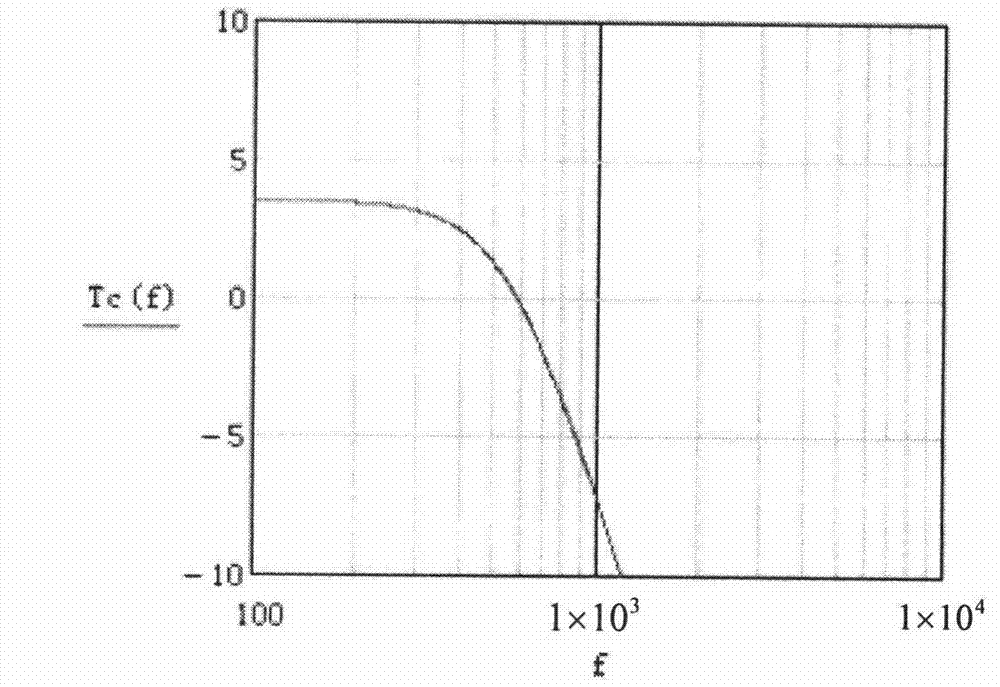
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a position sensorless control method for a four-phase double salient pole motor, which belongs to the motor control technology. Background technique
[0002] With the development of motor design and control technology, the precise detection of rotor position has become one of the research hotspots in the field of motors at home and abroad. At present, there are many kinds of control technologies. Conventional motor position detection technologies include: (1) direct position detection method; (2) conductive phase winding detection method; (3) non-conductive phase winding detection method; (4) additional electric current detection method Component detection method; (5) detection method based on intelligent technology, etc. Among these methods, except for the direct position detection method, which uses special detection elements such as Hall sensors to directly detect the rotor position, other methods are to find an obtainable ...
Examples
Embodiment Construction
[0053] The system structure block diagram of this patent is as follows figure 1 As shown, it mainly consists of five parts: (1) four-phase full-bridge power circuit module; (2) four-phase double salient pole motor; (3) subtractor module; (4) low-pass filter module; (5) The control module composed of DSP and FPGA.
[0054] Among them, the low-pass filter module includes N (N is a natural number greater than 2) low-pass filters with different cut-off frequencies, and every three filters with the same cut-off frequency are connected in series to form a three-stage filter, that is, a sixth-order filter pair The collected back EMF is filtered. The main functions of the control module composed of DSP and FPGA are: (1) calculate the speed at any time according to the zero-crossing voltage point of the phase A potential waveform; And select the angle that needs to be compensated according to the speed; (3) perform accurate angle compensation on the filtered back EMF; (4) perform log...