
Inversion anti-integral saturation method for precision motion control
A precision motion, anti-integration technology, applied in electric controllers, controllers with specific characteristics, etc., can solve the problems of prone to integral saturation, prolonged positioning motion and uniform scanning motion establishment time, etc., to reduce the establishment time, The effect of reducing the positioning movement and the establishment time of constant speed scanning and improving work efficiency
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2020-09-04
Smart Images
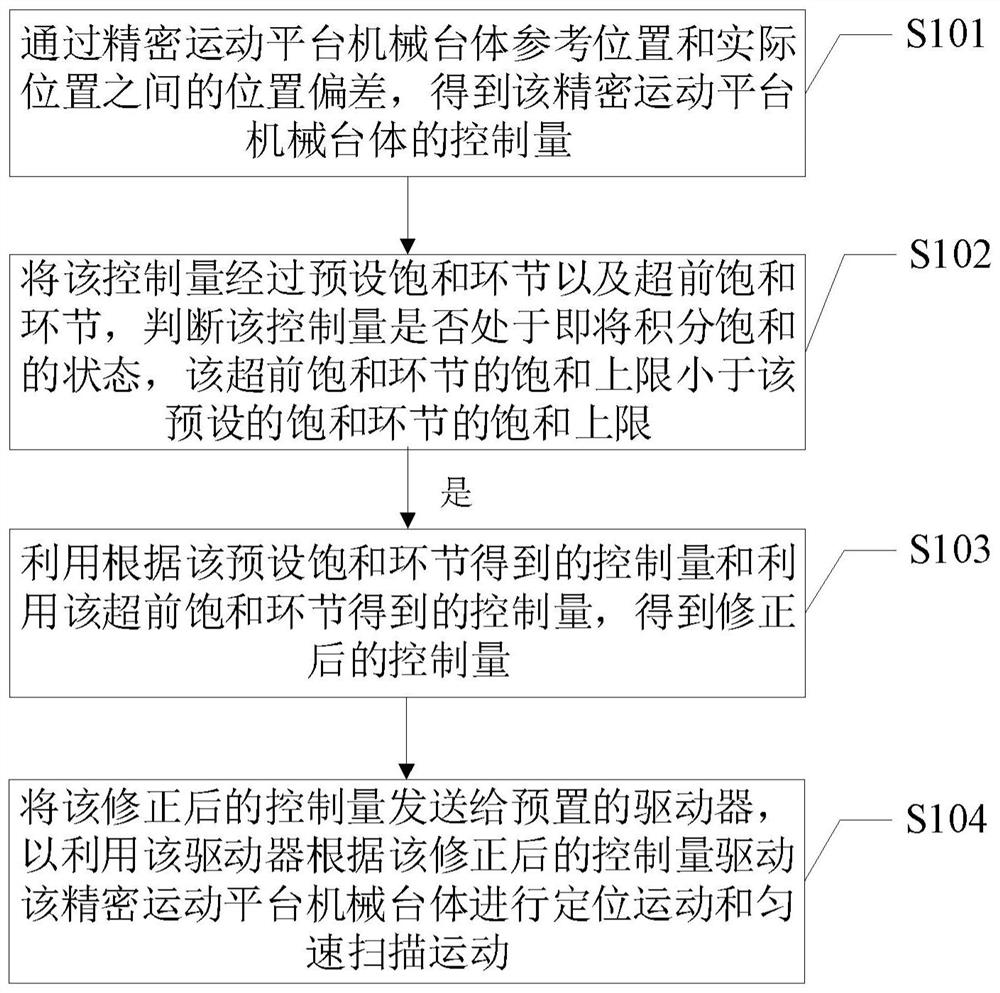
Figure 1 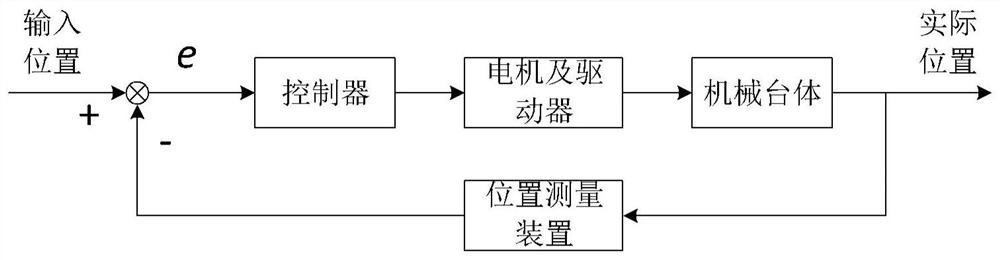
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The present application relates to the technical field of motion control, in particular to an inversion anti-integral windup method for precise motion control. Background technique
[0002] Precision motion stages are commonly used in industries such as machine tool machining and semiconductor manufacturing. The motion time of typical positioning motion and scanning motion is equal to the sum of acceleration time, settling time, scanning time and deceleration time. The acceleration time and deceleration time are related to the maximum acceleration and maximum jerk of the displacement platform, the scanning time is determined by the scanning speed, and the establishment time is directly included in the total movement time. The movement time often affects the production efficiency of these devices. From the perspective of improving economic output, the precision motion platform should minimize the movement time of positioning movement and scanning movem...
Examples
Embodiment Construction
[0047]In order to make the purpose, features, and advantages of the application more obvious and understandable, the technical solutions in the embodiments of the application will be clearly and completely described below in conjunction with the drawings in the embodiments of the application. Obviously, the described The embodiments are only some of the embodiments of the present application, but not all of them. Based on the embodiments in this application, all other embodiments obtained by those skilled in the art without making creative efforts belong to the scope of protection of this application.
[0048] see figure 1 , figure 1 It is a schematic flow chart of an inversion anti-integral windup motion control method for a precision motion platform provided by an embodiment of the present application. The method mainly includes the following steps:
[0049] S101. Obtain the control amount of the mechanical table body of the precision motion platform through the position d...