
Lower-hanging-type truss structure based on quadrilateral mechanism
A quadrilateral mechanism and truss structure technology, applied in the field of robotic arms, can solve the problems of reduced positioning accuracy and low positioning efficiency, and achieve the effects of reducing weight and manufacturing cost, improving stability, improving beat speed and positioning stability
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2018-02-23
Smart Images
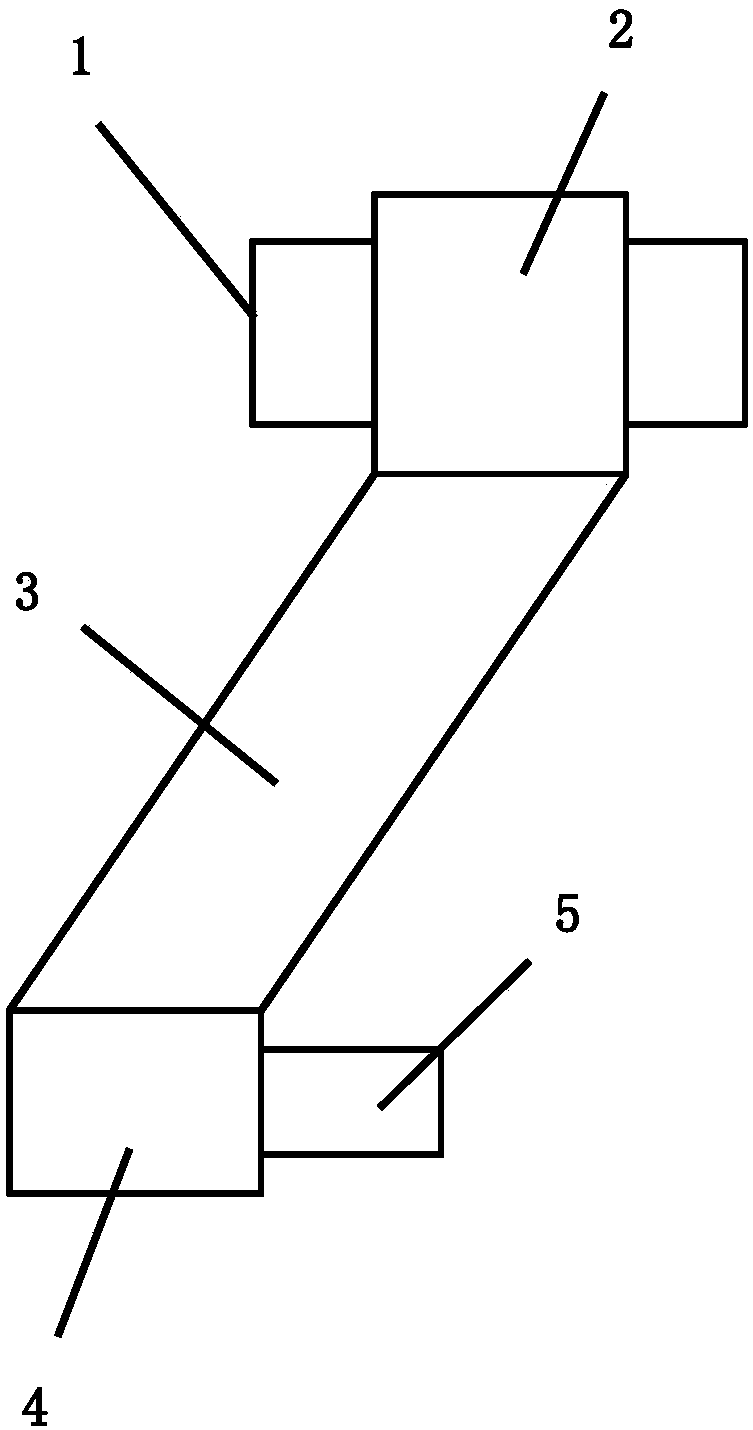
Figure 1 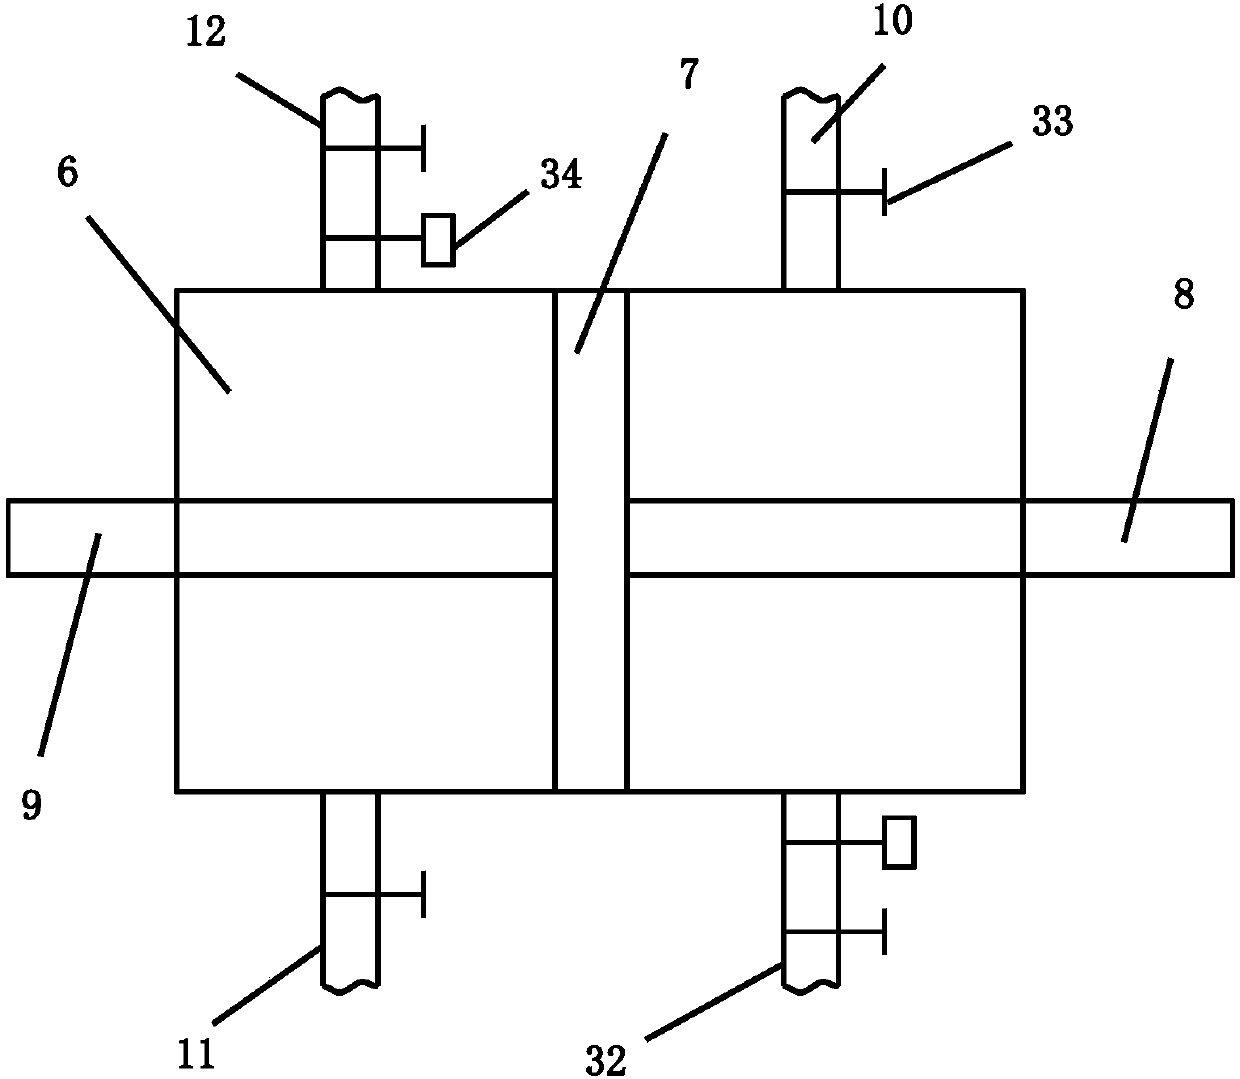
Figure 2 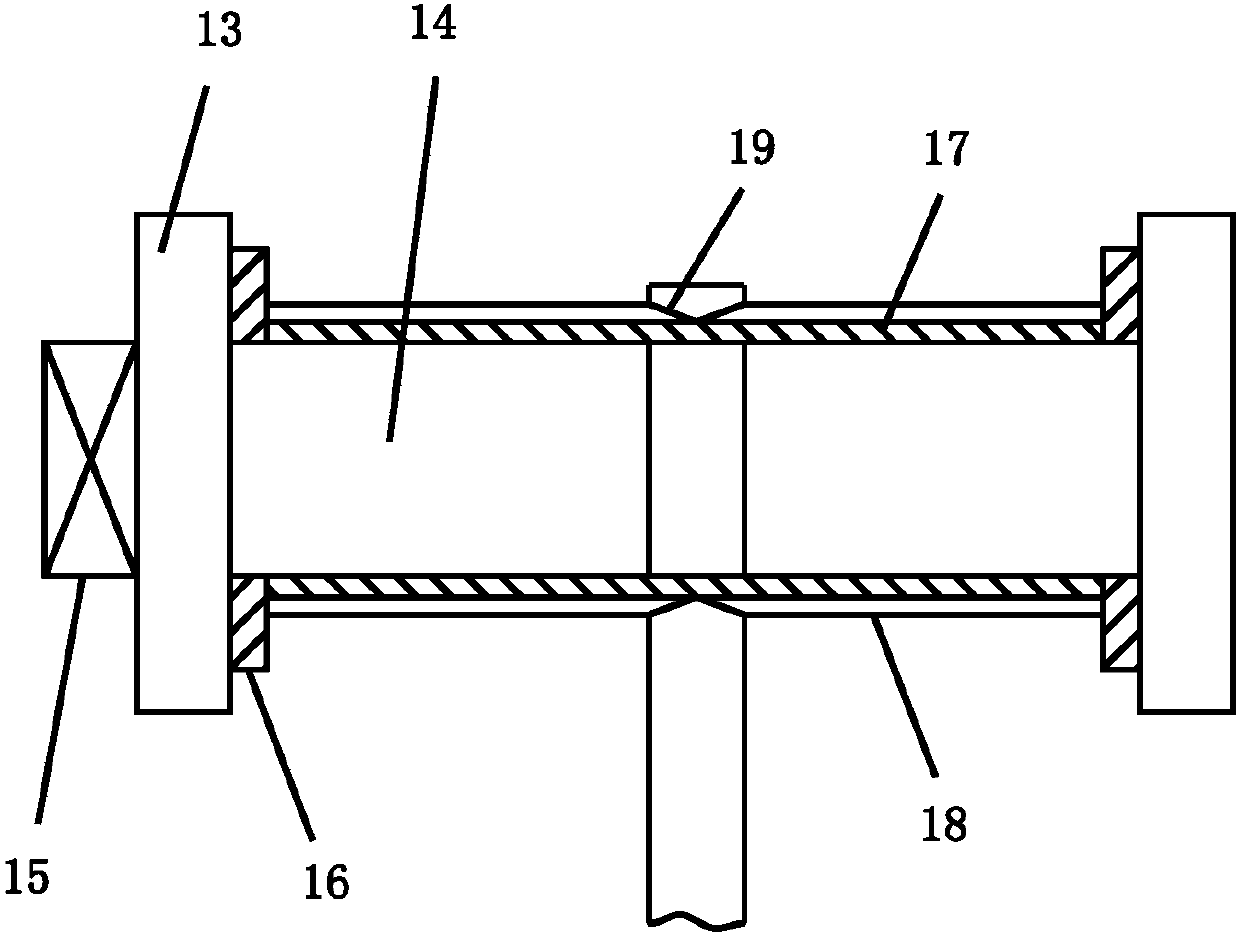
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a machine arm used for a horizontal machine tool machining center, in particular to a lower-hanging truss structure based on a quadrilateral mechanism. Background technique
[0002] In the existing horizontal machine tool machining center, the placement of fixtures and workpieces is completed by multi-degree-of-freedom joint robots. When the articulated robot moves rapidly or is impacted by processing, the positioning accuracy of its end will be reduced. Usually, it is necessary to reduce the moving speed and perform repeated positioning to ensure the positioning accuracy of the robot end, and the positioning efficiency is low. Contents of the invention
[0003] The technical problem to be solved by the present invention is to provide a bottom-hanging truss structure based on a quadrilateral mechanism, which can solve the deficiencies of the prior art and improve the positioning efficiency of a horizontal machine tool machini...
Examples
Embodiment Construction
[0018] The standard parts used in the present invention can be purchased from the market, and the special-shaped parts can be customized according to the instructions and the accompanying drawings. The specific connection methods of each part adopt mature bolts, rivets, welding in the prior art , pasting and other conventional means, no longer described in detail here.
[0019] refer to Figure 1-6 A specific embodiment of the present invention includes a transverse slide rail 1, a first driver 2 is slidably arranged on the transverse slide rail 1, a quadrilateral connecting frame 3 is connected to the first driver 2, and a second driver 4 is arranged on the bottom of the quadrangular connecting frame 3 A manipulator 5 is connected to the second driver 4, an oil cylinder 6 is arranged on the quadrilateral connecting frame 3, a piston 7 is arranged in the oil cylinder 6, and a first connecting rod 8 and a second connecting rod 9 are respectively arranged on both sides of the pi...