

Patents
Literature
3494 results about "Systems modeling" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Systems modeling or system modeling is the interdisciplinary study of the use of models to conceptualize and construct systems in business and IT development. A common type of systems modeling is function modeling, with specific techniques such as the Functional Flow Block Diagram and IDEF0. These models can be extended using functional decomposition, and can be linked to requirements models for further systems partition.
Systems and methods for automatically generating contextualized visualizations
PendingUS20250173170A1Database updatingExecution for user interfacesGraphical user interfaceObject based
Systems and methods for generating contextualized data visualizations. A first graphical user interface (GUI) object based on first data is provided, along with a second GUI object based on the second data. A user may select a scenario to be analyzed and, in response to the single selection of the scenario, the system models a first impact of the scenario on the first data to generate predicted first data and separately models a second impact of the scenario on the second data to generate predicted second data. The predicted data may be generated by an artificial intelligence system including a prediction processor. The first and second GUI objects are updated using the predicted first and second data, respectively.

Owner:THE TORONTO DOMINION BANK
Optical storage and charging cooperative control method and system based on multi-energy complementation
The invention provides an optical storage and charging cooperative control method and system based on multi-energy complementation. The method comprises the following sub-steps: respectively establishing a photovoltaic power generation model, an energy storage system model and a charging load model; acquiring historical illumination information, charging information and electricity price information, constructing a prediction model based on a neural network, and predicting and outputting illumination intensity, charging load demand power and electricity price in a future time period; constructing a target optimization function by taking the annual net cost and the power deviation rate as optimization targets; according to the method, the cooperative optimization control of the photovoltaic power generation, energy storage and charging system is realized, the annual net cost is reduced, the power deviation is reduced, the energy storage and charging cooperative control strategy is established, the target optimization function is solved by adopting the improved whale optimization algorithm, and the charging and discharging power sequence is generated according to the optimal solution obtained by solving and is input to the system for execution. And the operation efficiency and reliability of the whole system are improved.

Owner:HUBEI ELECTRIC POWER EQUIP
Permanent magnet motor energy storage and optimized operation method and system based on electricity price
ActiveCN119514816ARealize intelligent managementImprove stabilityForecastingArtificial lifeGlobal optimizationDynamic programming
The invention provides an electricity price-based permanent magnet motor energy storage and optimization operation method and system, and relates to the technical field of motor energy storage and optimization operation, and the method comprises the steps: predicting the power of a motor through a deep belief neural network, predicting the electricity price through a space-time diagram convolutional neural network, and quantifying a system error in combination with a Gaussian mixture model, based on a prediction result, performing global optimization by adopting a quantum genetic optimization algorithm to obtain an initial optimization strategy set, applying the initial optimization strategy set to a meta-heuristic hybrid optimization model, generating a time sequence association control strategy, performing system modeling through a hybrid Gaussian-hidden Markov model, and constructing a double-layer action evaluation control network to generate an operation control instruction; a distributed reinforcement learning framework is used for cooperative control, and an optimal control strategy is obtained based on adaptive dynamic programming and a meta-learning strategy migration mechanism.

Owner:江苏祝尔慷电机节能技术有限公司
Dynamic optimization and adaptive learning method of water conservancy system large model and storage medium
ActiveCN120218183AData processing applicationsKnowledge representationEnvironmental resource managementAdaptive learning
The invention provides a dynamic self-optimization and adaptive learning method for a large model of a water conservancy system, and the method comprises the steps: data collection and preprocessing, model construction and initialization, real-time monitoring and model evaluation, difference analysis and adaptive adjustment strategy generation, model updating and optimization, continuous learning and knowledge accumulation, etc. According to the method, through dynamic data driving, intelligent difference analysis and self-adaptive optimization, conversion of a water conservancy system model from static passive to dynamic active is realized. Compared with the prior art, the method has accuracy, real-time performance, economical efficiency and sustainability, provides a landing technical path for intelligent upgrading of a water conservancy system, and has wide application potential in the fields of flood control and disaster reduction, agricultural irrigation, clean energy production and the like.

Owner:WUHAN XINGHUAN HENGYU INFORMATION TECH CO LTD
Federal learning optimization system and method for intelligent network connection automobile scene
The invention belongs to the technical field of Internet of Vehicles, and particularly provides a federated learning optimization system and method for an intelligent network connection automobile scene, which improves an asynchronous federated learning framework, divides a plurality of vehicles into different clusters due to the isomerism of computing power, and adopts a cloud-edge-end three-layer federated learning framework, so as to realize the optimization of the federated learning of the vehicles. An edge server is deployed on a roadside unit RSU, received model parameters are subjected to pseudo-asynchronous aggregation in a self-adaptive dynamic time window, the received model parameters are subjected to real-time aggregation at a cloud end, the system model training efficiency and quality are improved, meanwhile, the data security is ensured, the user privacy is protected, and the user experience is improved. And the efficiency of the federated learning optimization system and the quality of the global model in the intelligent network connection automobile scene are ensured.

Owner:EDGE INTELLIGENCE RES INST NANJING CO LTD
Humanoid robot whole-body coordination control method based on mass center dynamic model
The invention discloses a humanoid robot whole-body coordination control method based on a mass center dynamical model. The method comprises the steps that system modeling is conducted on a humanoid robot according to the mass center dynamical model; establishing a relationship between arm momentum and centroid momentum based on whole-body kinematics and a momentum conservation principle; a whole nonlinear optimization control problem is constructed and solved in real time, and a controller predicts the motion trail of the robot in a future period of time; feedforward torque is obtained through inverse dynamics calculation, and joint torque is issued in combination with a joint PD controller. The invention designs a nonlinear model predictive control problem for whole-body coordination control of the humanoid robot, reasonably plans a system state, an arm tail end state, a foot end state and a reference trajectory of control input, and designs equality constraints and inequality constraints necessary for whole-body coordination movement of the robot; task trajectory constraint and momentum conservation constraint on the tail end of the arm are added, so that the ability of the arm to assist in motion balance is more prominent.

Owner:ZHEJIANG UNIV
Antenna polarization simulation method based on phase and amplitude calibration
ActiveCN119109527AImprove versatilityHigh precisionTransmitters monitoringReceivers monitoringAntenna polarizationOriginal data
The invention discloses an antenna polarization simulation method based on phase and amplitude calibration, and the method comprises the steps: collecting original data, carrying out the preprocessing, and obtaining the preprocessed original data; constructing an initial calibration model, and generating a calibrated lookup table; obtaining a target polarization parameter, and calculating a Stokes parameter; constructing a Mueller matrix, and determining an ideal polarization state; constructing a closed-loop control system to obtain a monitoring result; constructing a polarization parameter adjustment strategy, executing multi-objective optimization, and generating an optimized polarization parameter; acquiring position information of each antenna, and constructing a multi-antenna system model; a distributed optimization algorithm is used to obtain a coordination result, a space diversity strategy is realized, and polarization control parameters are generated; and generating a final polarization control parameter by using a beam forming technology. According to the invention, the universality of the system is improved, the precision and reliability of polarization simulation are improved, the adaptability and stability of the system are enhanced, the complexity of real-time calculation is reduced, and the response speed of the system is improved.

Owner:NANJING AEROSPACE IND TECH CO LTD
Satellite multi-hop task unloading optimization method and system based on edge calculation
The invention discloses a satellite multi-hop task offload optimization method and system based on edge computing, and the method comprises the steps: obtaining a task offload optimization problem through employing an on-demand routing protocol under a constraint condition based on environment exploration information with the minimum energy consumption of a system model as a target when the access satellite computing resources of a ground user are insufficient; and constructing a task unloading optimization problem into a Markov decision process, and solving by combining a deep reinforcement learning algorithm to obtain a task unloading and routing optimization strategy. In the invention, under the condition of insufficient computing resources of an access satellite, an on-demand routing protocol is combined to support efficient multi-hop task transmission unloading, so that energy consumption is comprehensively considered and selection of an intermediate satellite node on a routing path from a source satellite node to a target satellite node is optimized on the basis of the minimum hop count of the task; and the processing nodes are dynamically reached through multiple hops, and meanwhile, the control overhead of the whole network topology in the task unloading process is reduced to the greatest extent.

Owner:GUANGDONG UNIV OF TECH
CNN (Convolutional Neural Network)-oriented mobile edge computing dynamic unloading method and equipment medium
The invention discloses a CNN (Convolutional Neural Network)-oriented mobile edge computing dynamic unloading method and equipment medium, and the method comprises the steps: obtaining image task data, equipment state data and network state data in a communication, sensing and computing integrated system, and forming a data set; the method comprises the following steps of: constructing a general-inductance-calculation integrated system model, and converting the general-inductance-calculation integrated system model into a calculation task segmentation and resource allocation problem for a calculation task; a Markov decision model is constructed; a joint optimization strategy based on a multi-agent deep reinforcement learning algorithm is adopted, and a neural network parameter model meeting a termination condition is obtained through training image task data and network state data; deploying the trained neural network parameter model into the system; and generating a calculation task segmentation decision and a calculation resource allocation decision according to the real-time data, and transmitting decision result information to each node to realize unloading of the calculation task. According to the invention, smooth execution of the calculation task is realized under the condition of shortage of network environment and network resources.

Owner:JIMEI UNIV
Asymmetric fault transient stability analysis method and system based on network-forming inverter
PendingCN119134305AImprove transient stability analysis methodsImproved transient stability analysis methodsSingle network parallel feeding arrangementsPower oscillations reduction/preventionTransient stateMathematical model
The invention discloses an asymmetric fault transient stability analysis method and system based on a network-forming inverter. Relates to the technical field of power system transient stability analysis. According to the scheme, a mathematical model of hybrid synchronous control before and after a fault is derived according to a power grid system model of a hybrid synchronous control inverter connected to a power grid, and a transient instability mechanism based on the hybrid synchronous control inverter under an asymmetric fault is analyzed from the aspect of legal quantity by means of a power angle curve and a phase plane. The influence rule of the positive and negative sequence current on the stability is disclosed; based on mathematical modeling, a power angle curve and a phase diagram method, the influence of positive and negative sequence component coupling under an asymmetric fault is considered, and transient instability mechanism analysis of hybrid synchronous control is realized; the boundary of instability caused by positive and negative sequence current can be determined, a converter transient stability analysis method considering positive and negative sequence coupling caused by asymmetric faults under network construction type control is perfected, and a reference is provided for improving the transient synchronization stability of the converter under large disturbance; meanwhile, the researched current loss stability boundary can provide reference for a current limiting reference value.

Owner:STATE GRID SICHUAN ELECTRIC POWER CORP ELECTRIC POWER RES INST
Low voltage ride through control method of flywheel energy storage system
PendingCN120414627AFlicker reduction in ac networkContigency dealing ac circuit arrangementsControl setPrediction algorithms
The invention discloses a low-voltage ride-through control method of a flywheel energy storage system, which is based on a low-voltage ride-through control strategy of model predictive current control (MPCC) so as to improve the low-voltage ride-through capability of the flywheel energy storage system when a power grid fails. A future current value is predicted through system modeling and a prediction algorithm, so that effective control is realized. The MPCC-based machine side-power grid side coordination control strategy can quickly respond to the voltage sag of the power grid, provide reactive power support, stabilize the voltage of the direct current bus, and ensure the safe and reliable operation of the flywheel energy storage system during the voltage sag period of the power grid. A traditional pulse width modulation (PWM) technology is abandoned, the optimal switching state is directly selected through a limited control set, and hardware implementation of a power grid side converter is simplified. A differential control strategy aiming at a power grid symmetric fault (three-phase voltage sudden drop) and an asymmetric fault (single-phase grounding) is provided, the method is suitable for a complex power grid fault scene, and the system universality is improved.

Owner:HANGZHOU ELECTRIC EQUIP MFG +2
Conversion method and system based on SysML and Modelica model semantic mapping
ActiveCN120780317ADesign optimisation/simulationSpecial data processing applicationsAlgorithmTheoretical computer science
The invention discloses a conversion method and system based on SysML and Modelica model semantic mapping. The method comprises the following steps that S1, a Modelica standard model library is imported into a SysML modeling tool; s2, completing the definition of behavior elements, and forming an SysML model instance; s3, exporting a Modelica model which can be executed by the Modelica simulator; s4, establishing a mapping relation table between SysML model elements and Modelica model elements; s5, when a change event occurs in the SysML model, updating the content of the corresponding Modelica model; s6, the Modelica model is imported into the SysML model, and a corresponding SysML model instance is generated; s7, simulation result mapping and behavior modeling generation are executed, a state transition diagram structure is formed, and structure updating of internal block diagrams in the system model is completed. According to the method, bidirectional conversion and joint simulation optimization between models are realized, and the method is suitable for cross-platform modeling, collaborative design and functional verification scenes of a complex system.

Owner:HANGZHOU HUAWANG SYST TECH CO LTD
System control method for hybrid electric vehicles based on deep reinforcement learning
The present invention relates to the technical field of new energy vehicles, and provides a system control method for hybrid electric vehicles based on deep reinforcement learning. [Solution] For a plug-in hybrid logistics light truck, the method includes step S1 of acquiring multidimensional aisle situation information during the historical driving process, step S2 of creating a full-vehicle power system model, step S3 of performing initial optimization processing for two electric motors, step S4 of performing dynamic programming calculations to generate a state transfer dataset, step S5 of identifying state variables, operation variables and incentive functions, step S6 of initially training a network of critics and actors using the state transfer dataset, step S7 of constructing an ambient intelligence model and recovering and training an energy management policy using a deep reinforcement learning algorithm, and step S8 of applying the model.


Owner:YANSHAN UNIV +1
Enhanced structure design method and system for three-period minimal curved surface
The invention belongs to the technical field of material structure optimization, and discloses an enhanced structure design method and system for a three-period minimal curved surface, and the method comprises the steps: modeling a geometric model of the three-period minimal curved surface, and exporting the model; expanding a design domain of the geometric model to obtain a corresponding expanded design space of the three-period minimal curved surface; a design space file is converted into an analysis data structure, a general expression mode is constructed for the three-period minimum curved surface, an equal geometric element stiffness matrix is solved by using a Gaussian integral method and the elastic performance of each point in a design domain and assembled into a global stiffness matrix, and the structural response of the model is solved; constructing a local density distribution function in the Bayesian unit, and assembling all LDDFs to obtain a global density distribution function for presenting structural topology; and constructing a stiffness maximization topological optimization mathematical model for the TPMS, calculating an objective function and analyzing sensitivity, and carrying out iterative updating on design variables in the optimization model based on an optimal criterion method to obtain a reinforced structure configuration.

Owner:HUAZHONG UNIV OF SCI & TECH
Work ticket auxiliary decision-making method and system
The invention provides a work ticket auxiliary decision-making method and system, and relates to the technical field of electric power operation, and the method comprises the steps: collecting and fusing the multi-source data of an electric power operation system, and obtaining the multi-modal data of the electric power operation system; obtaining deep semantic features of the multi-modal data according to the multi-modal data through a large-scale language model, a data feature extraction model and an image feature extraction model; matching according to the deep semantic features through a preset knowledge graph to obtain knowledge graph nodes and relationships related to the multi-modal data; determining an initial auxiliary decision of the work ticket of the power operation by combining a preset deep reinforcement learning network; inputting the data into a power operation system model for simulation to obtain an execution effect; and optimizing the initial auxiliary decision according to the execution effect and the expected execution effect to obtain a final auxiliary decision of the work ticket. According to the invention, the accuracy and consistency of decision making are improved, and the intelligent degree of auxiliary decision making of the work ticket is improved.

Owner:CIXI SHUBIAN ELECTRICIAN CHENG CO LTD +1
Microgrid intelligent safety secondary voltage control method based on reinforcement learning
ActiveCN119496288Aincrease weightImprove adaptabilityBiological modelsAc network voltage adjustmentBacksteppingControl theory
The invention relates to a micro-grid intelligent safety secondary voltage control method based on reinforcement learning, and belongs to the technical field of power grids. The method comprises the following steps: firstly, establishing a micro-grid secondary control model under hybrid network attack; a DoS attack defense network based on deep learning is designed, a self-adaptive FDI attack compensation state observer is designed, compensation for unknown FDI attacks is established, a self-adaptive law of compensation signals is designed, and estimation of the system state under network attacks is achieved. An evaluation-execution structure is constructed based on reinforcement learning, a virtual optimal controller and an actual optimal controller are designed in combination with a backstepping method, unknown parts in a system model, an evaluation network and an execution network are approximated by using a neural network, and a weight adjustment law is given. And introducing a log type barrier function into the performance index function, and constraining the output in a fixed constant interval to meet the constraint condition. The method can cope with DoS attacks and FDI attacks, and ensures stable control and safe operation of the secondary voltage of the micro-grid.

Owner:CHONGQING UNIV
Cross-domain knowledge migration cold start recommendation method based on dynamic intention perception
The invention relates to a cross-domain knowledge migration cold start recommendation method based on dynamic intention perception. A system model of the method comprises a decoupling feature extractor based on graph convolution, an intention bridging network, a self-adaptive knowledge fusion mechanism and a recommendation generation unit. The method comprises the following steps: firstly, decomposing expressions of a user and an article into a plurality of intention subspaces through a decoupling feature extractor; then, establishing a soft mapping relation between intention subspaces of a source domain and a target domain by using an intention bridging network to realize intention alignment of fine granularity; the migration degree of source domain knowledge is dynamically adjusted through an adaptive knowledge fusion mechanism, and differentiated migration strategies are adopted for different users and articles; and finally, stable learning and smooth knowledge migration of the intention mapping relation are ensured by adopting a three-stage progressive training strategy of a recommendation generation unit. The problems of non-correspondence of intention semantics, negative migration and the like in traditional cross-domain recommendation are effectively solved, the recommendation effect is remarkably improved, and the method is particularly suitable for a cold start scene with sparse target domain data.

Owner:TIANJIN UNIV
Communication delay compensation method and system based on autonomous robot
ActiveUS20250044803A1TransmissionVehicle position/course/altitude controlControl engineeringControl theory
The disclosure provides a communication delay compensation method and a communication delay compensation system based on an autonomous robot, where the method includes the following steps: establishing a state equation based on a system model of an AUV positioning system; acquiring an included angle between a direction vector of AUV to an observation station and a velocity vector of AUV based on the system model; establishing an observation equation according to the state equation and the included angle; establishing an extended Kalman filter equation based on the system model, the included angle and the observation equation; and calculating a position information predicted value at the current time by using the extended Kalman filter equation to complete communication delay compensation.

Owner:HUNAN UNIV OF SCI & TECH
Multi-axis motion control method based on six-axis hydraulic mechanical arm
The invention relates to the technical field of mechanical arm control, and particularly discloses a multi-axis motion control method based on a six-axis hydraulic mechanical arm, and the method comprises the following steps: establishing a kinetic model and a hydraulic system model of the six-axis hydraulic mechanical arm, generating a motion track in a Cartesian space or a joint space based on a preset task demand, and generating a multi-axis motion model of the six-axis hydraulic mechanical arm; the track smoothness is optimized through an S-type acceleration and deceleration algorithm; a deviation coupling synchronous control strategy is adopted, and position, speed and pressure signals of all hydraulic cylinders are collected in real time. According to the multi-axis motion control method based on the six-axis hydraulic mechanical arm, through multi-layer modeling, multi-algorithm fusion and intelligent optimization, the core problems of synchronous errors, non-linear interference, high energy consumption and the like in multi-axis cooperative control of the hydraulic mechanical arm are solved, high-precision, high-robustness and low-energy-consumption industrial-grade motion control is achieved, and the multi-axis motion control method is suitable for industrial production. The method is suitable for heavy-load carrying, precision assembling and other complex scenes.

Owner:SUZHOU MINGTAI INTELLIGENT EQUIP CO LTD
Multi-unmanned ship cluster cooperative tracking control method based on data driving
ActiveCN119620762AReduce transmission delayImprove robustnessVehicle position/course/altitude controlPosition/direction controlComplete dataControl engineering
The invention discloses a multi-unmanned ship cluster cooperative tracking control method based on data driving, and belongs to the field of unmanned ship cluster intelligent control. The method comprises the following steps: firstly, constructing a communication topology for cluster distributed cooperative control of multiple unmanned ships; constructing a single unmanned ship speed and course system dynamic linearization data model with interference terms based on unknown external interference and nonlinear uncertainty; constructing a smooth anti-interference trajectory tracking algorithm of a single unmanned ship tracking dynamic target point; constructing a pseudo-Jacobian matrix estimation and distributed disturbance compensation controller for distributed model-free adaptive control of the multiple unmanned ships; constructing a reset algorithm and a controller of an actual unmanned ship; and finally, multi-unmanned ship cluster cooperative tracking control is realized. The method breaks through the limitation of a traditional control method, does not need to depend on complex system model information, only utilizes input and output data of the system, and achieves a complete data-driven intelligent control strategy.

Owner:ZHEJIANG UNIV
Flexible joint robot neural network adaptive iterative learning control method
PendingCN119238505Asafe and stable operationImprove industrial production efficiencyProgramme-controlled manipulatorLearning controllerEngineering
The invention discloses a neural network adaptive iterative learning control method for a flexible joint robot, and the method comprises the steps: S1, building a constrained flexible joint robot, and initializing a system state, sampling time and control parameters; s2, compensating input saturation constraint; s3, calculating a system tracking error, and constructing an expected error trajectory; and S4, defining an error variable, and designing a neural network adaptive iterative learning controller. According to the method, the uncertainty of the flexible joint robot is estimated and compensated through the neural network, the error convergence precision is improved, by constructing the quadratic fraction type symmetric constraint Lyapunov function, it is guaranteed that the system output is always within the constraint range, the transient performance of the system is improved, and the reliability of the system is improved. According to the method, the flexible joint robot can safely and stably run in an iterative change task, when the number of iterations is increased, the tracking error is consistently converged to zero, and the method has the advantages of less required priori knowledge, no need of an accurate system model, high control precision and the like.


Owner:DEQING COUNTY ZHEJIANG UNIV OF TECH MOGANSHAN RES INST
Active mismatch prediction control method of adaptive constraint model based on voltage and current ripple resistance of power converter in hybrid energy storage system
The invention provides a self-adaptive constraint model active mismatch prediction control method based on voltage and current ripple resistance of a power converter in a hybrid energy storage system, and the method comprises the steps: building an island DC micro-grid system model, collecting the voltage and current information of a system, and designing a model prediction control frame of a power loop and a cost function of the model prediction control frame; designing a model predictive control framework of the current loop and a cost function of the model predictive control framework; designing an active model mismatch mechanism to enhance the response capability to dynamic change; determining an optimization problem with a normal value, and designing an adaptive constraint optimization algorithm to dynamically adjust constraint parameters and optimize control performance; and designing a steady-state and dynamic-mode trigger for adapting to the running state of the system. According to the invention, the trajectory tracking precision of the system under dynamic and steady-state working conditions can be significantly improved, current ripples caused by control delay can be effectively eliminated, damage to electrical equipment due to overlarge ripples can be avoided, and the service life of the equipment can be prolonged.

Owner:HENAN UNIVERSITY +1
Hybrid load flow calculation method and device based on cross entropy algorithm
PendingCN120613731ASystems intergating technologiesAc networks with different sources same frequencyState spacePower grid
The invention discloses a hybrid power flow calculation method and device based on a cross entropy algorithm, and belongs to the technical field of optimization algorithm and machine learning crossing. The method comprises the steps that system modeling and parameter initialization are carried out, and a state space, an action space and a target function are defined according to a specific application scene; setting and initializing row parameters; entropy algorithm-guided sample generation and elite screening: iteratively optimizing power grid parameters through probability distribution, and quickly approaching a global optimal solution; the strategy optimization target of the strategy gradient algorithm is that a dynamic strategy network is constructed based on optimized power grid parameters, and the running state of the power grid is adjusted in real time to deal with uncertainty; performing sample multiplexing and distribution fusion of importance sampling: setting a double-buffer mechanism and performing sample fusion and multiplexing; and parameter updating and convergence judgment. According to the method, global search is carried out through the cross entropy algorithm, local optimization is carried out through the strategy gradient algorithm, the sample utilization rate is improved through the importance sampling method, and cooperative processing of global optimization and local optimization is achieved.

Owner:STATE GRID ANHUI ELECTRIC POWER CO LTD ELECTRIC POWER SCI RES INST +1
Air floating bearing quasi-zero stiffness active vibration reduction method based on model predictive control
The invention relates to the technical field of vibration isolation control, discloses an air floating support quasi-zero stiffness active vibration reduction method based on model predictive control, and aims to solve the problems of high vibration isolation requirements of precision equipment in a low-frequency vibration environment, response lag of a traditional vibration isolation technology and insufficient control precision under uncertainty. The method comprises the following steps: step 1, carrying out system modeling on the vibration damping device to obtain a state space model of the vibration damping device, and introducing a Kalman filter into the state space model to predict state information in real time; step 2, constructing an optimization problem and a constraint condition of the MPC controller; step 3, carrying out robustness and stability analysis on the MPC controller; and step 4, fusing sensor data through the MPC controller after robustness analysis, solving an optimization problem through an optimization algorithm, calculating an optimal control input # imgabs0 # in real time, driving a voice coil motor, and suppressing low-frequency vibration.

Owner:HARBIN INST OF TECH
A multi-user sharing-oriented multimedia network video recommendation method
PendingCN113468413AImprove computing speed and utilization of computing resourcesImprove utilizationDigital data information retrievalSpecial data processing applicationsPersonalizationEngineering
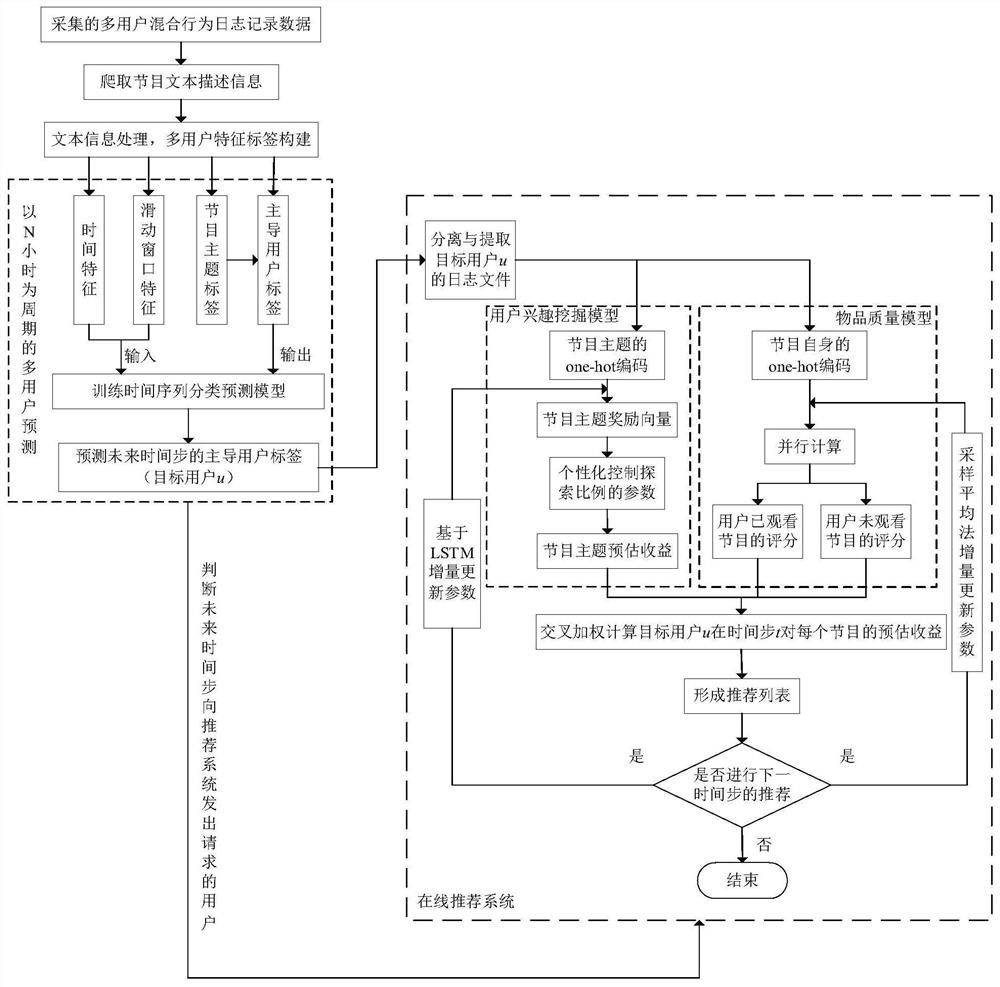
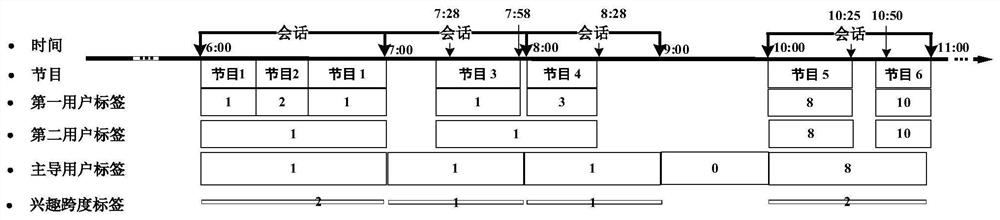
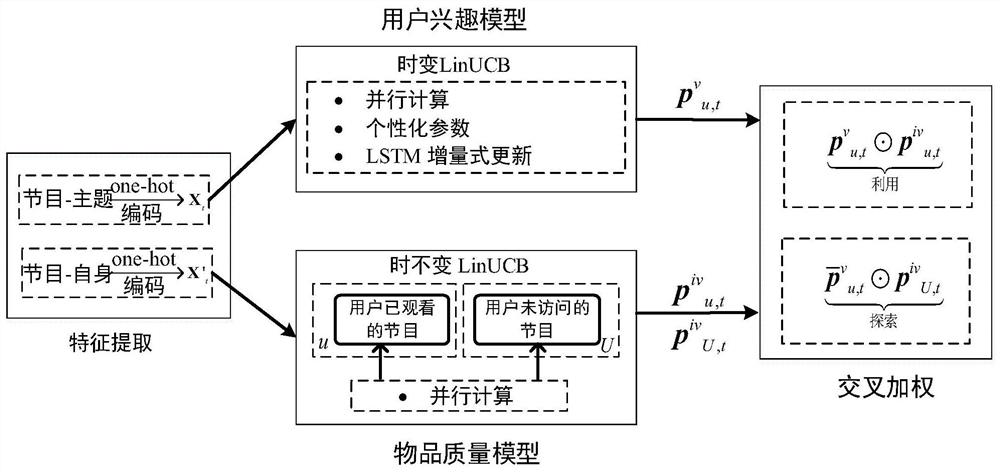
The invention discloses a multi-user sharing-oriented multimedia network video recommendation method, which comprises the following steps: firstly, constructing multi-user characteristics by utilizing collected program information in a multi-user sharing environment, and constructing a leading user label according to the similarity of the program characteristics and the continuity of user watching behaviors, so that separation of multi-user mixed logs is realized; performing periodic multi-user identification prediction of future sessions; secondly, building a user interest mining model based on a time-varying LinUCB algorithm to learn interest changes of a user for each program theme, and enhancing the personalized ability and efficiency of a recommendation system from three aspects of parallel calculation, adaptive control of an exploration coefficient and incremental updating based on LSTM; and finally, establishing an article quality model based on a non-time-varying LinUCB algorithm to further ensure the program quality, and integrating the two algorithms into a final recommendation system model by adopting a cross weighting strategy to form a final program recommendation list. The novelty and accuracy of the recommendation result are ensured.
Owner:NANJING UNIV OF POSTS & TELECOMM
Cloud control self-driving automobile control method considering automobile cloud communication time delay
The invention discloses a cloud control self-driving automobile control method considering automobile cloud communication time delay. By constructing a time delay prediction model based on historical communication delay data, the back-and-forth communication time delay at the current moment is accurately predicted, and forward compensation is carried out on the vehicle state by adopting an iterative prediction formula in combination with a vehicle transverse dynamic model. According to the method, a process disturbance correction item is introduced, system modeling errors caused by environment disturbance are effectively corrected, and the state prediction precision is improved. And deducing a future vehicle state through the predicted time delay step number in combination with a historical vehicle state and control input so as to realize dynamic compensation of the time delay influence. The method effectively solves the problems of control lag and state information lag caused by communication delay in vehicle-cloud cooperative control, improves the control real-time performance and precision of a cloud control automatic driving system, enhances the robustness and safety of the system in a complex environment, and is suitable for automatic driving scenes with high dynamic and high safety requirements.

Owner:TONGJI UNIV
Robust stability analysis method for network-following construction type series-parallel multi-infeed system
ActiveCN119864825ASingle network parallel feeding arrangementsPower oscillations reduction/preventionControl engineeringPower grid
The invention relates to a quantitative evaluation method for robust stability of a hybrid multi-infeed system constructed with a network. The quantitative evaluation method comprises the following steps: S1, constructing a hybrid multi-infeed system model; s2, enabling the series-parallel multi-infeed system to be equivalent to an equivalent network construction subsystem and an equivalent network following subsystem, and respectively calculating a generalized short-circuit ratio as a power grid strength quantitative index; s3, selecting a nominal system model, and determining a critical value of small interference stability of a nominal system through the dominant feature root locus; s4, drawing a frequency domain characteristic curve of the uncertainty perturbation singular value, and determining an uncertainty perturbation upper bound; and S5, drawing a complementary sensitivity peak curve when the decoupled nominal system is connected to alternating current networks with different power grid intensities, and quantifying a critical value and a margin of robust stability under a power grid intensity perspective by combining an uncertainty perturbation upper bound. Compared with the prior art, the robust small-interference stability quantitative evaluation method is creatively provided, and technical support can be provided for coordinated optimization configuration and safe and stable operation of the high-proportion new energy grid-connected system.


Owner:SHANGHAI UNIVERSITY OF ELECTRIC POWER
New energy consumption software model construction method based on simulation platform
The invention relates to the technical field of new energy power systems, and discloses a new energy consumption software model construction method based on a simulation platform, and the method comprises the steps: firstly dividing new energy consumption system units, determining the topological structure and operation parameters of the new energy consumption system units, and constructing a multi-physics field coupling simulation model; then, carrying out distributed parallel solution on the model, defining a global optimization target, constructing a joint optimization and network reconstruction model, respectively adopting a deep reinforcement learning algorithm and graph neural network optimization, and generating an optimization scheme through multi-agent collaboration; whether the optimization target converges is verified, if yes, control parameters are output, and if not, optimization variables are updated to continue optimization; and finally, the optimized parameters are imported into the digital twin platform calibration model integrated with the block chain technology, and hyper-parameters are adjusted. The method improves the accuracy of a new energy consumption system model, optimizes the system operation, enhances the cooperative stability, and promotes the efficient utilization of new energy and the sustainable development of a power system.

Owner:POWER ECONOMIC RESEARCH INSTITUTE OF JILIN ELECTRIC POWER CO LTD
Computing system for implementing system model using big data machine learning
Provided is a computing system for implementing a system model using big data machine learning, which is intended to build a hypothetical model, calculate verified parameter values by performing machine learning on big data acquired from an actual system, and apply the verified parameter values to the hypothetical model. A system modeling method of completing a simulation model for a target system by causing a hypothetical model defined by acquiring knowledge about the target system to perform machine learning on big data acquired by running and observing the target system includes defining a hypothetical model for a target system by finding acquirable information related to the target system.

Owner:KOREA DIGITAL TWIN LAB INC
Optimization design method for floating wind power-wave energy multi-energy complementary power generation platform
PendingCN121257176ABiological modelsDesign optimisation/simulationNumerical modelsComputational physics
The invention discloses an optimal design method for a floating wind power-wave energy multi-energy complementary power generation platform, which comprises the following steps of: constructing an integrated and parameterized system model which is a fully-coupled and parameterized numerical model comprising all key components of the floating wind power-wave energy multi-energy complementary power generation platform; all key design parameters influencing the system performance are set as parameterized variables; establishing a multidisciplinary coupling dynamic simulation model; defining a multi-objective optimization problem including decision variables, objective functions and constraint conditions; the decision variable selects a group of core variables from the parameterized variables as optimization input; and combining the multi-objective optimization problem with a multidisciplinary coupling dynamic simulation model, executing a multi-objective optimization cycle, and generating and deciding a Pareto optimal solution set to obtain typical design schemes with different characteristics. According to the method, the global optimization design of the floating wind power-wave energy multi-energy complementary power generation platform can be realized.

Owner:GUANGZHOU INST OF ENERGY CONVERSION CHINESE ACAD OF SCI