
A control method for rehabilitation training of a lower limb exoskeleton rehabilitation robot
A rehabilitation robot and control method technology, applied in the field of rehabilitation medicine, can solve problems such as low-level control methods that rarely involve active and passive training, and the influence of control is not considered.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2017-07-28
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
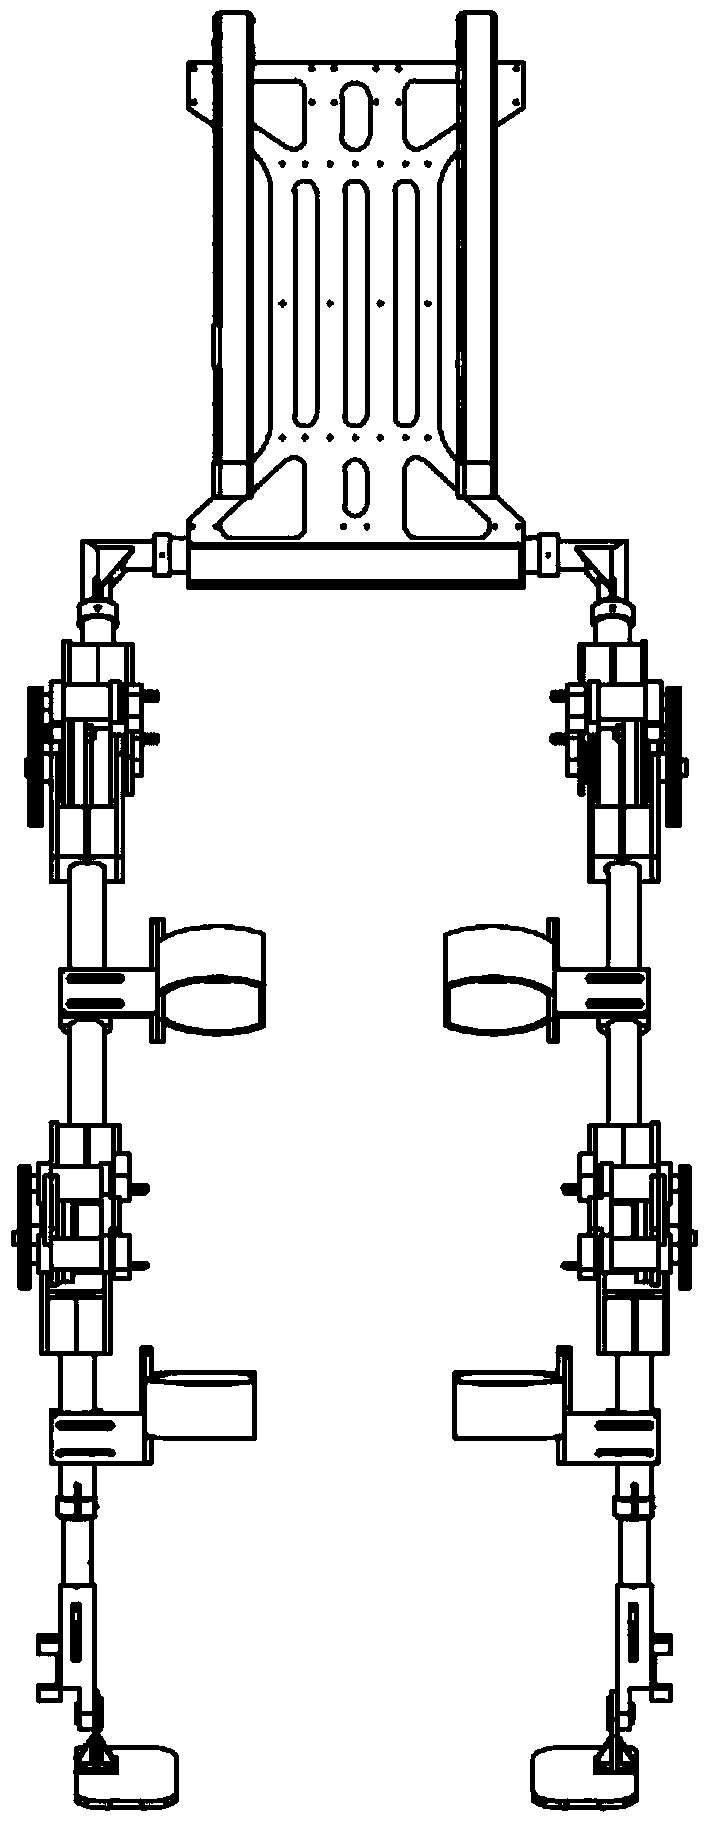
Figure 1 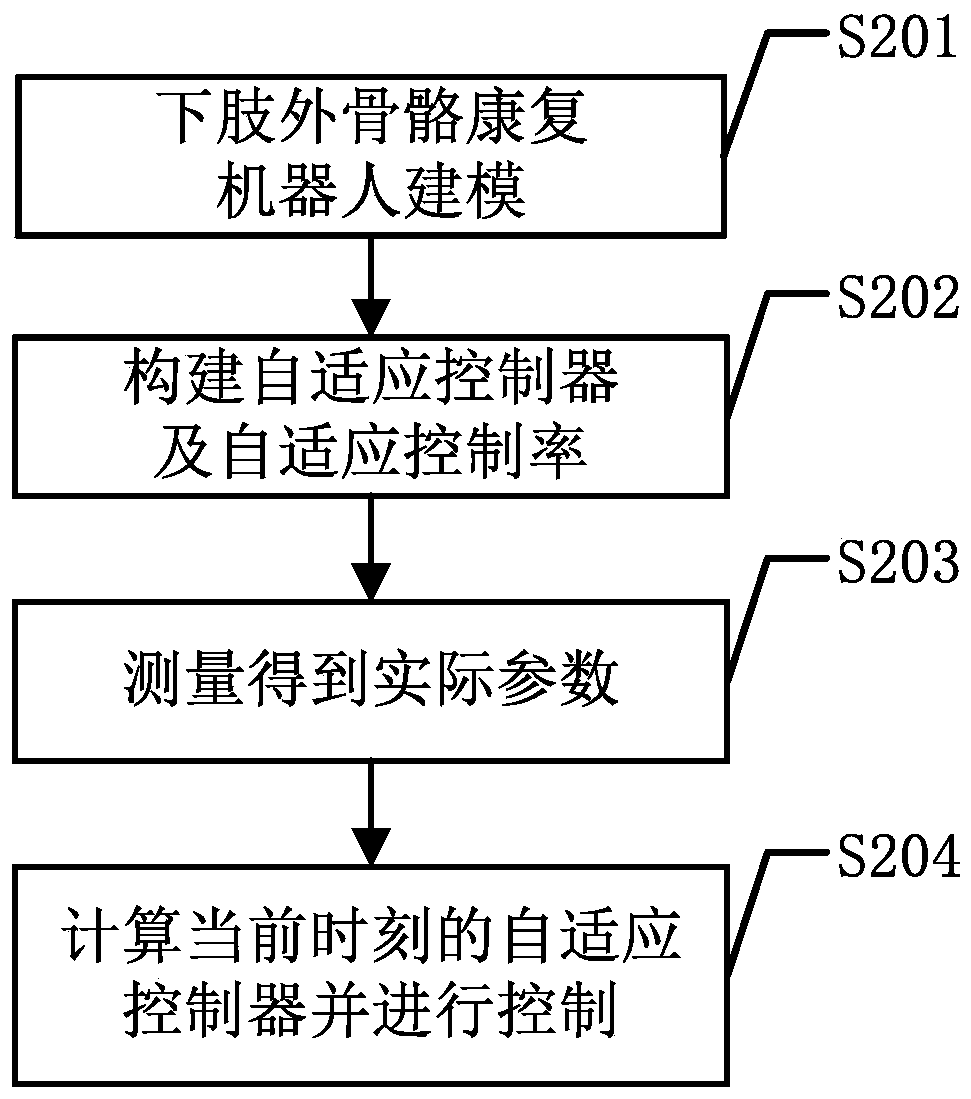
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of rehabilitation medicine, and more specifically relates to a control method for rehabilitation training of a lower limb exoskeleton rehabilitation robot. Background technique
[0002] With the intensification of aging in our country, the health care of the elderly population has attracted the attention of the society. Stroke hemiplegia is a common disease among the elderly, which can lead to inconvenient walking and gait deformation in mild cases, and can be bedridden and completely incapacitated in severe cases. Without effective rehabilitation treatment, their lower limb motor function may never recover, seriously affecting their normal life. Rehabilitation robot is a new application of the combination of robot and rehabilitation medicine. Rehabilitation robot combines different robot control methods to provide active and passive rehabilitation training for paraplegic patients. In the context of the ag...
Examples
Embodiment
[0038] figure 1 It is a schematic diagram of the mechanical structure of the lower extremity exoskeleton rehabilitation robot.
[0039] In this example, if figure 1 As shown, each leg of the lower extremity exoskeleton rehabilitation robot has two degrees of freedom, that is, the hip joint and the knee joint each have one degree of freedom. In the following adaptive controller design process, they are all designed based on the single-leg 2-degree-of-freedom model.
[0040] figure 2 It is a flow chart of the control method for the rehabilitation training of the lower limb exoskeleton rehabilitation robot of the present invention.
[0041] Such as figure 2 As shown, in this embodiment, a control method for rehabilitation training of a lower extremity exoskeleton rehabilitation robot includes the following steps:
[0042] S201. Model the lower limb exoskeleton rehabilitation robot, and obtain the model equation of the lower limb exoskeleton rehabilitation robot as:
[004...