
Twelve-point support based vertical launching platform attitude leveling control method
A vertical launch and control method technology, applied in the direction of control using feedback, etc., can solve problems such as poor stiffness and anti-overturning ability, complex control, strong electromagnetic interference, etc.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2016-11-09
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
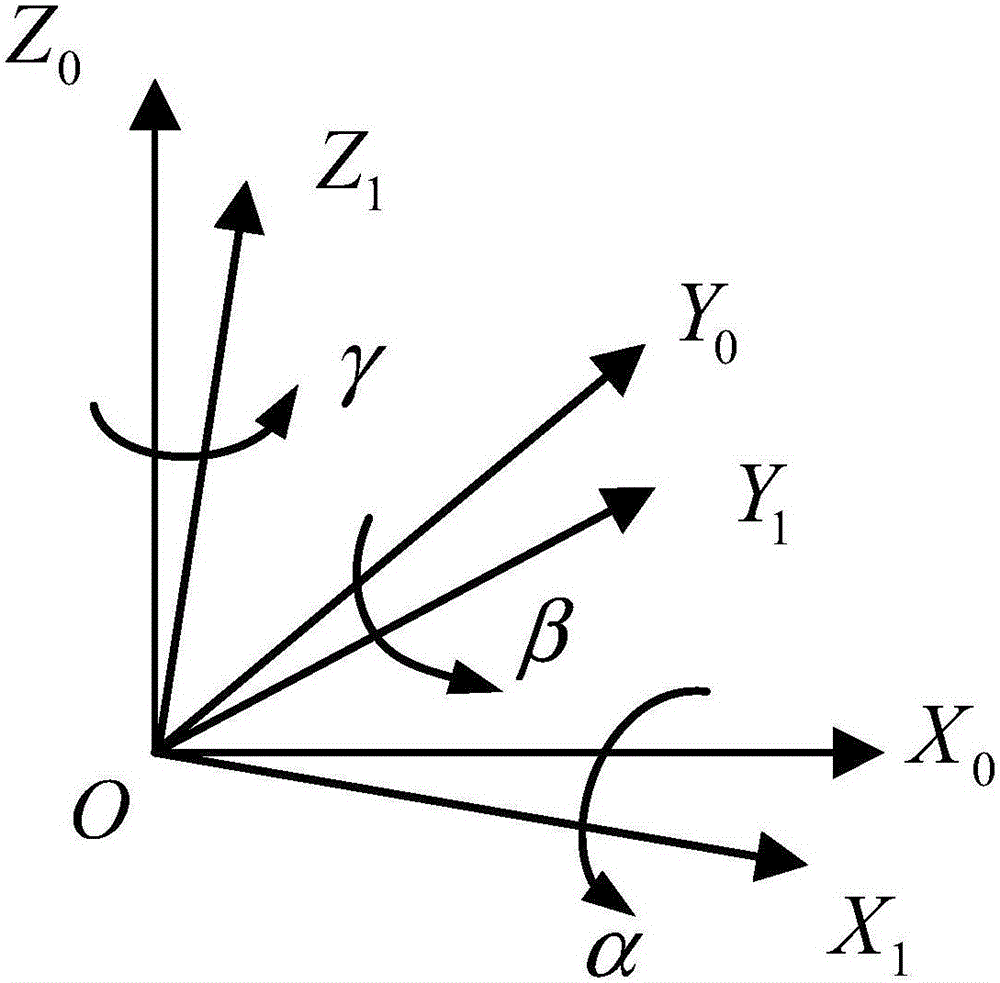
Figure 1 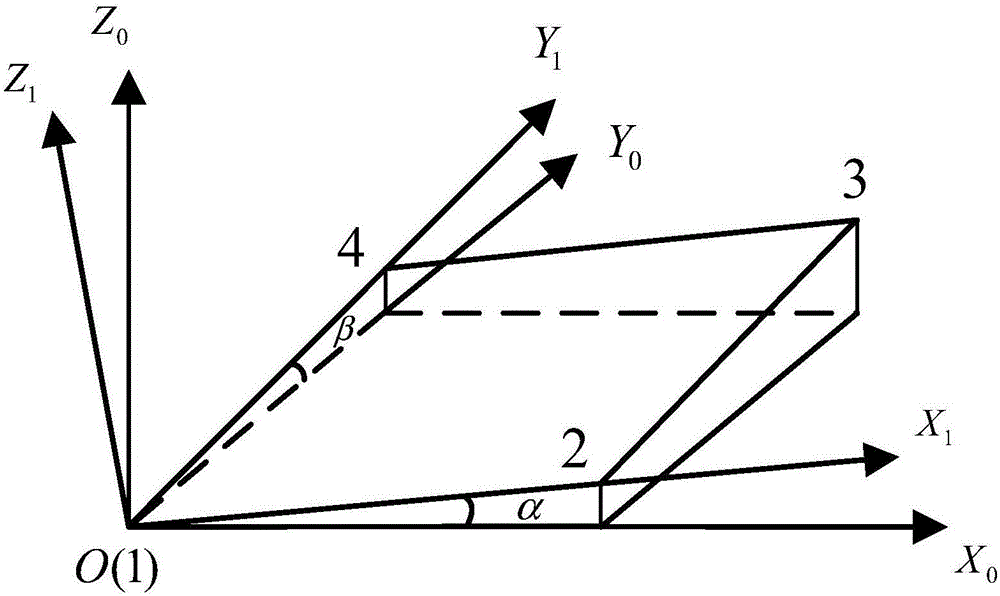
Figure 2 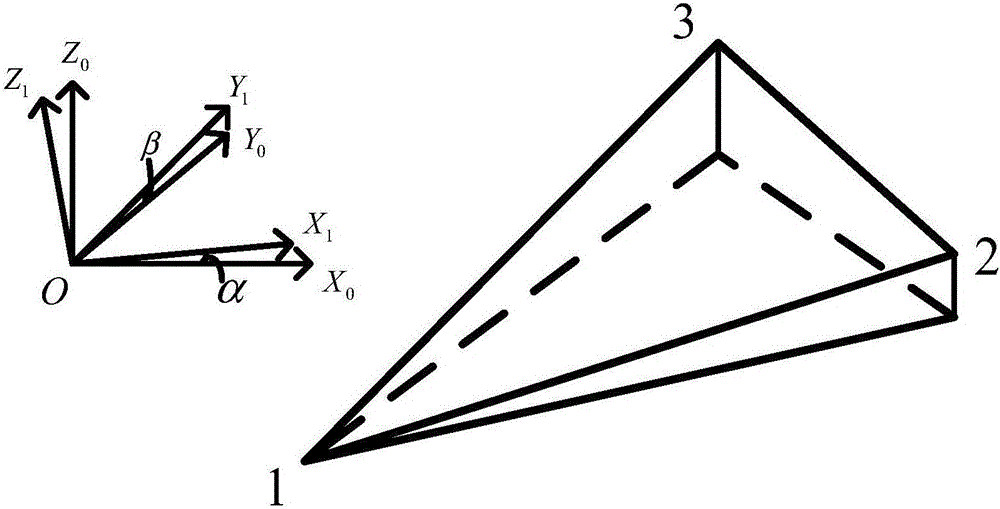
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of electro-hydraulic servo control, in particular to a control method for attitude leveling of a vertical launch platform based on twelve points of support. Background technique
[0002] Leveling devices play an important role in military weapons and equipment. For example, land-based mobile radars and missile launch vehicles are required to be erected after arriving at the predetermined combat position to obtain an accurate horizontal benchmark, and withdraw from the position after the combat mission is over.
[0003] At present, the systems that realize automatic leveling mostly use 3-point, 4-point, and 6-point support methods, and there are special multi-point types such as 8, 10, and 12 (four leveling legs + eight auxiliary legs) leg platforms. The advantage of the 3-point support is that the control method is simple and there is no over-constraint problem, but the stiffness and anti-overturning ability...
Examples
Embodiment Construction
[0055] The present invention will be described in further detail below in conjunction with the accompanying drawings.
[0056] combine Figure 1 to Figure 3 as well as Figure 24 and Figure 25 , a method for controlling attitude leveling of a vertical launch platform based on twelve points of support, comprising the following steps:
[0057] Step 1, establish the mathematical model of the attitude leveling system of the vertical launch platform supported by twelve points, as follows:
[0058] Set OX 0 Y 0 Z 0 is the horizontal coordinate system, keep still, OX 1 Y 1 Z 1 is a non-horizontal coordinate system, by the horizontal coordinate system OX 0 Y 0 Z 0 After a series of rotations, the schematic diagram of the rotation change is as follows figure 1 shown. It is stipulated here that the rotation angle direction satisfies the right-hand spiral rule, that is, the thumb points to the positive direction of the rotation axis, and the bending direction of the four fi...