
Cantilever manipulator structure
A technology of manipulator and cantilever, which is applied in the field of cantilever manipulator structure, can solve the problems that the three-coordinate positioning manipulator cannot meet modern production, cannot operate with manipulator, and cannot perform rotary operation, and achieves the effects of good versatility, guaranteed structural strength, and large working environment
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2014-11-12
Smart Images
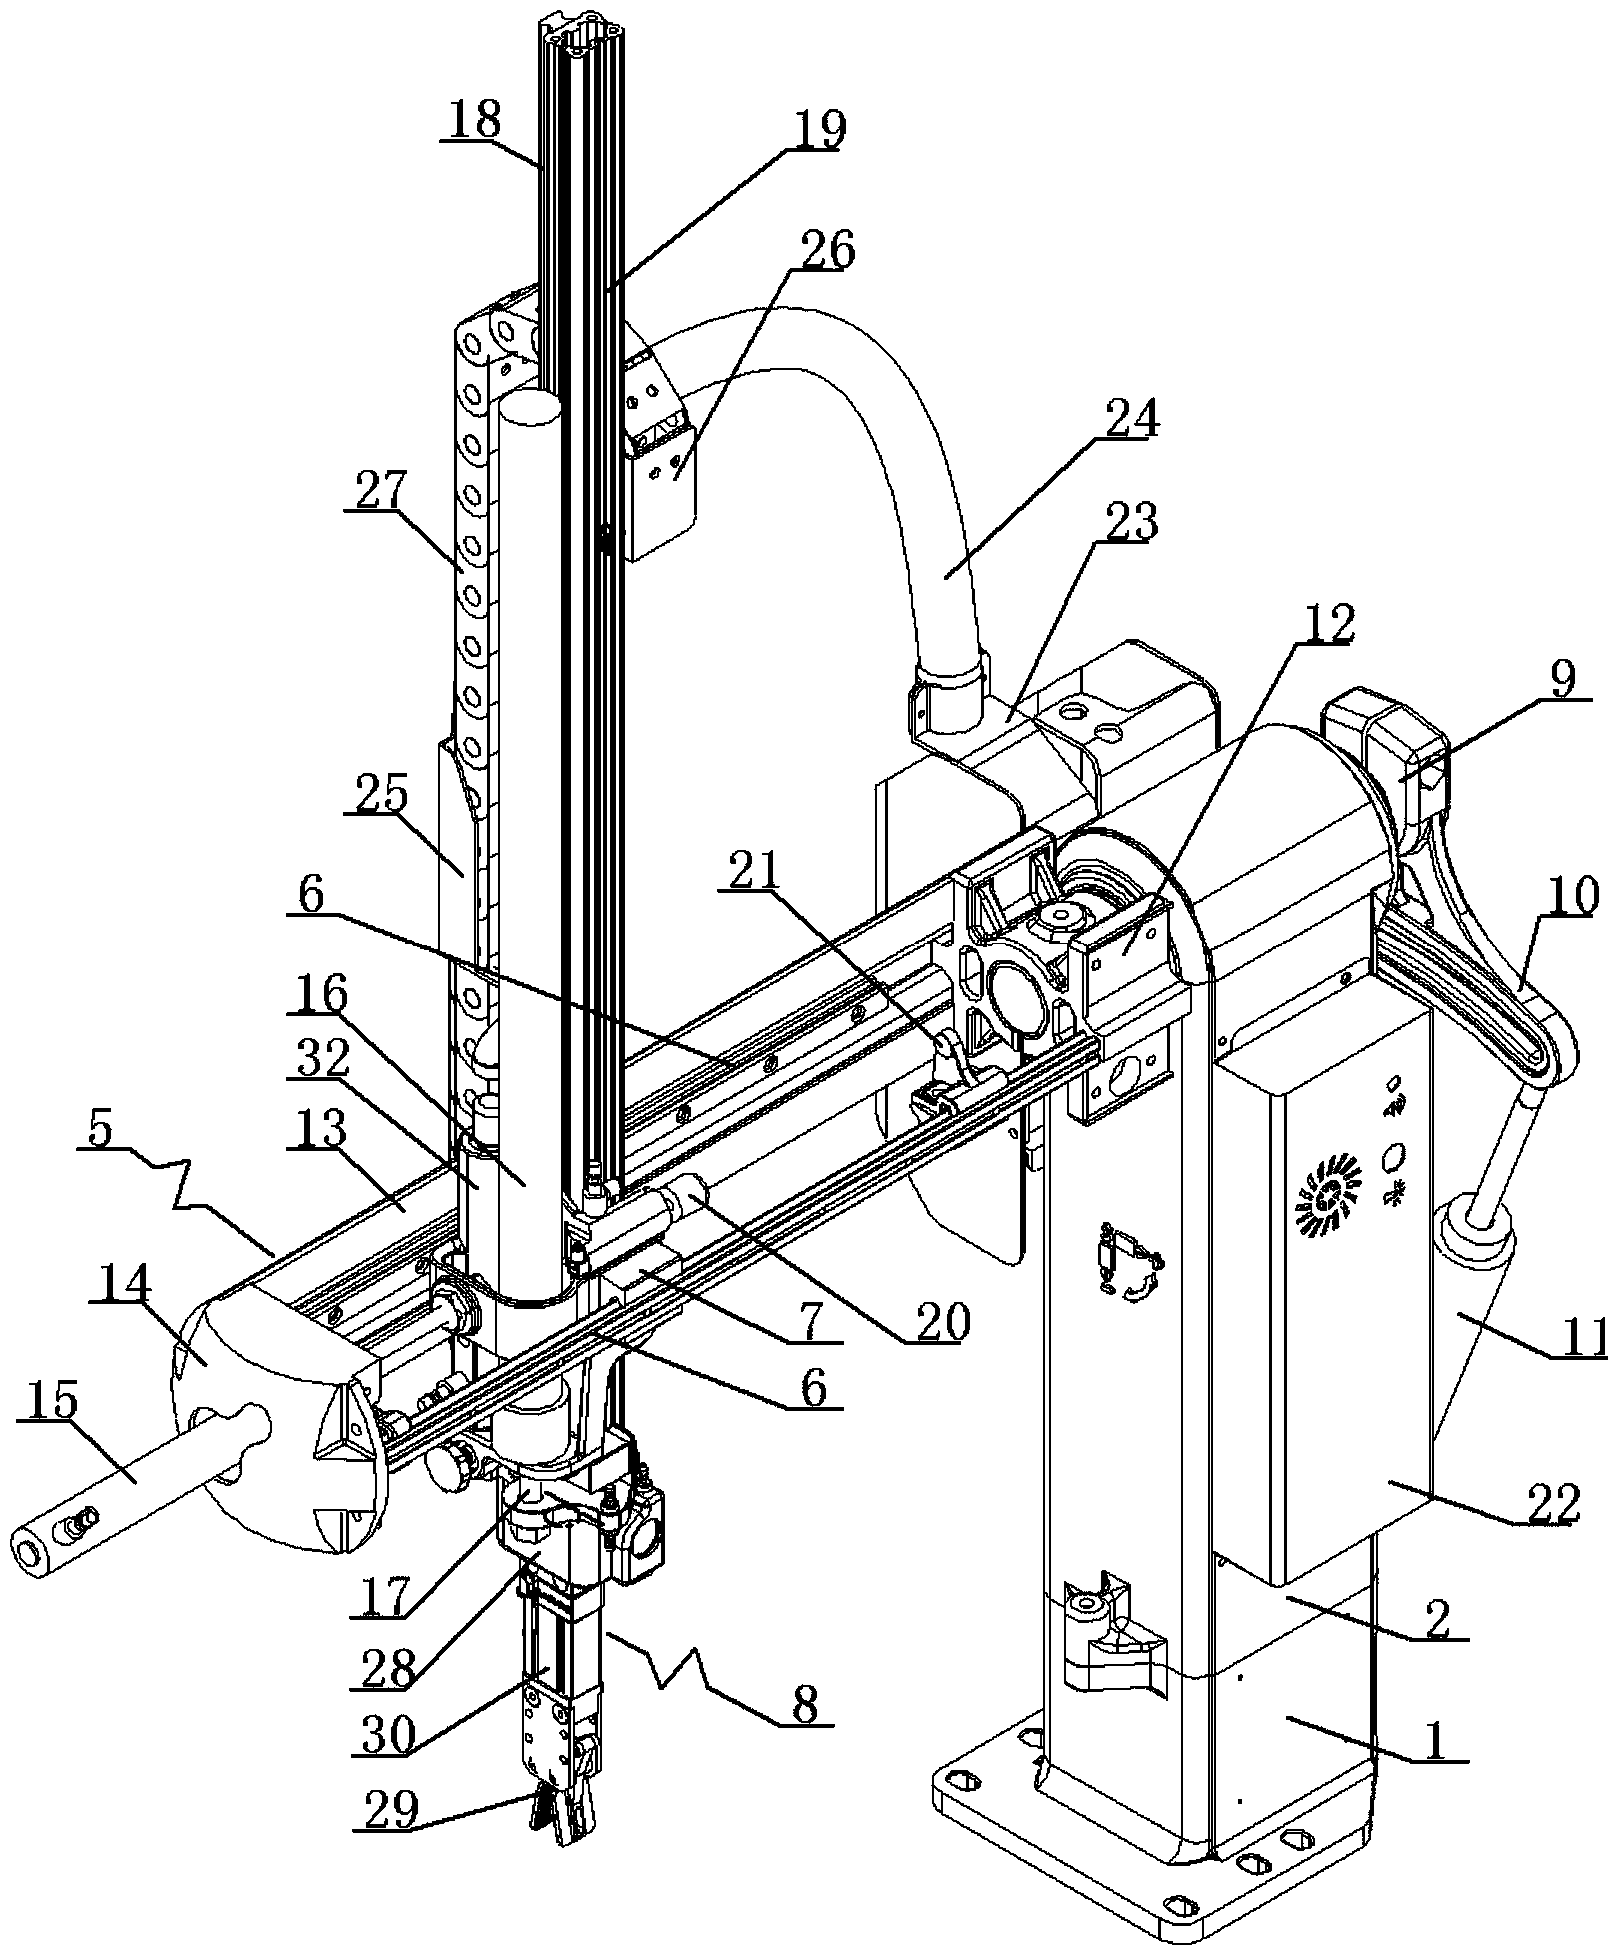
Figure 1 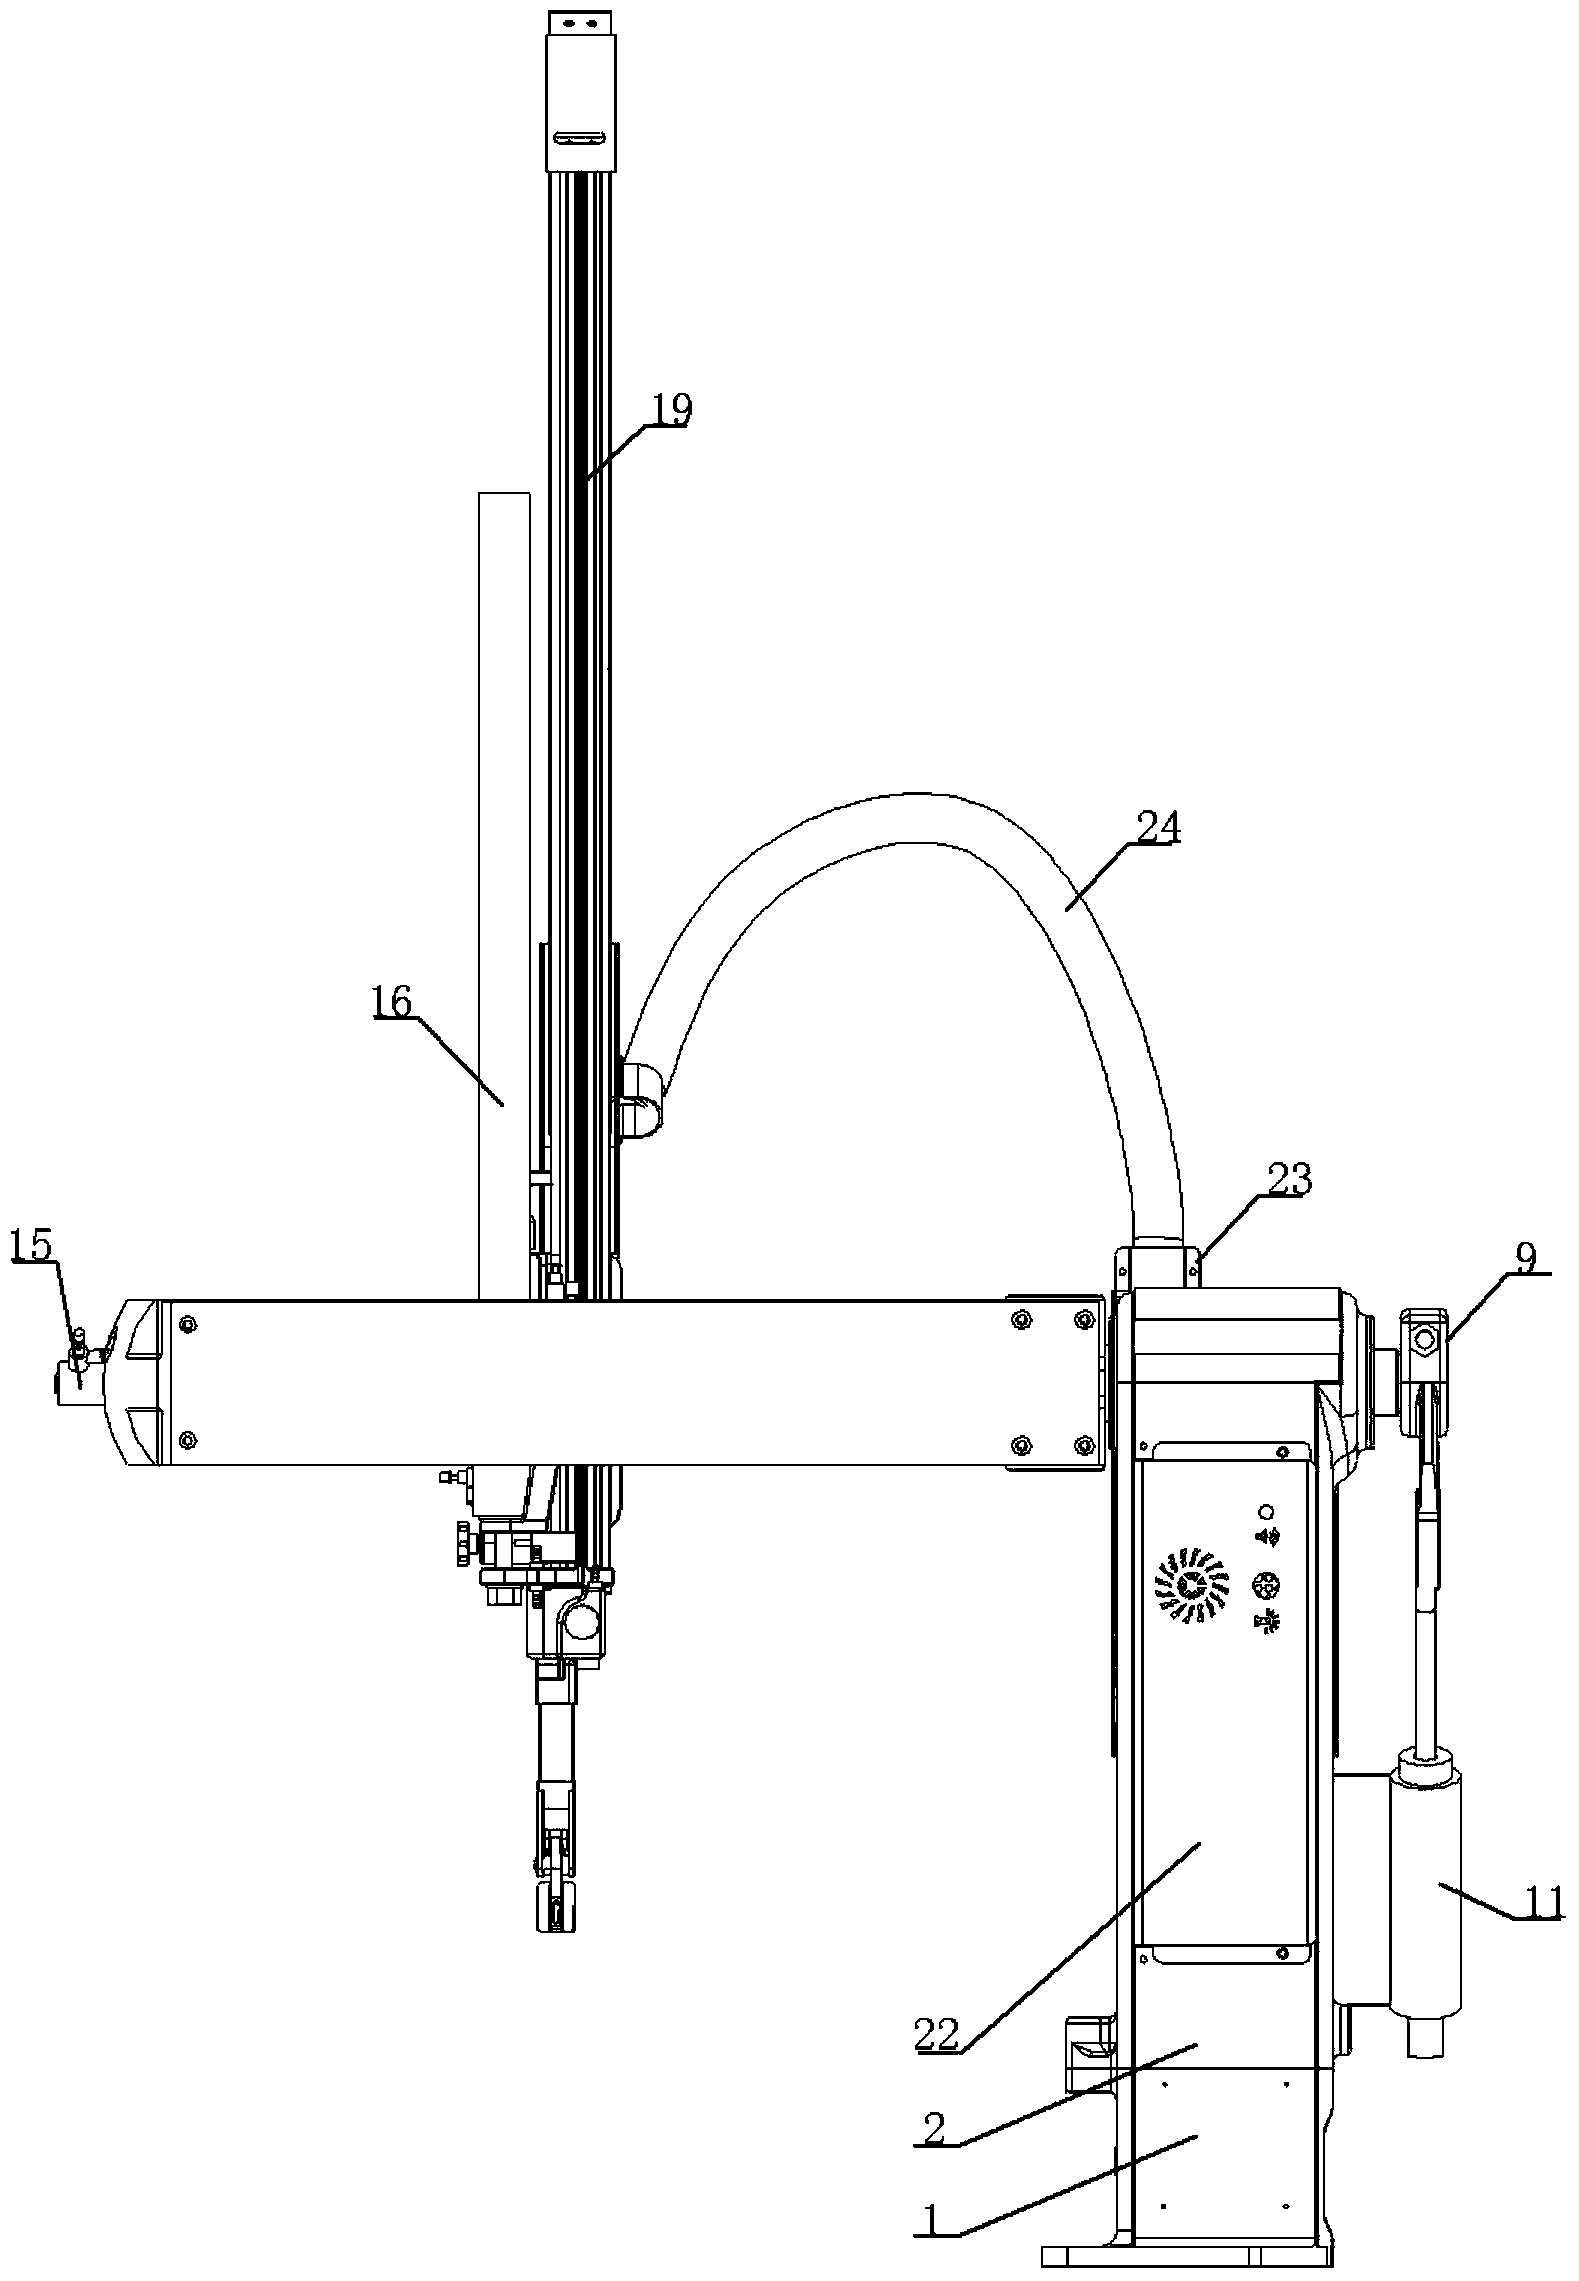
Figure 2 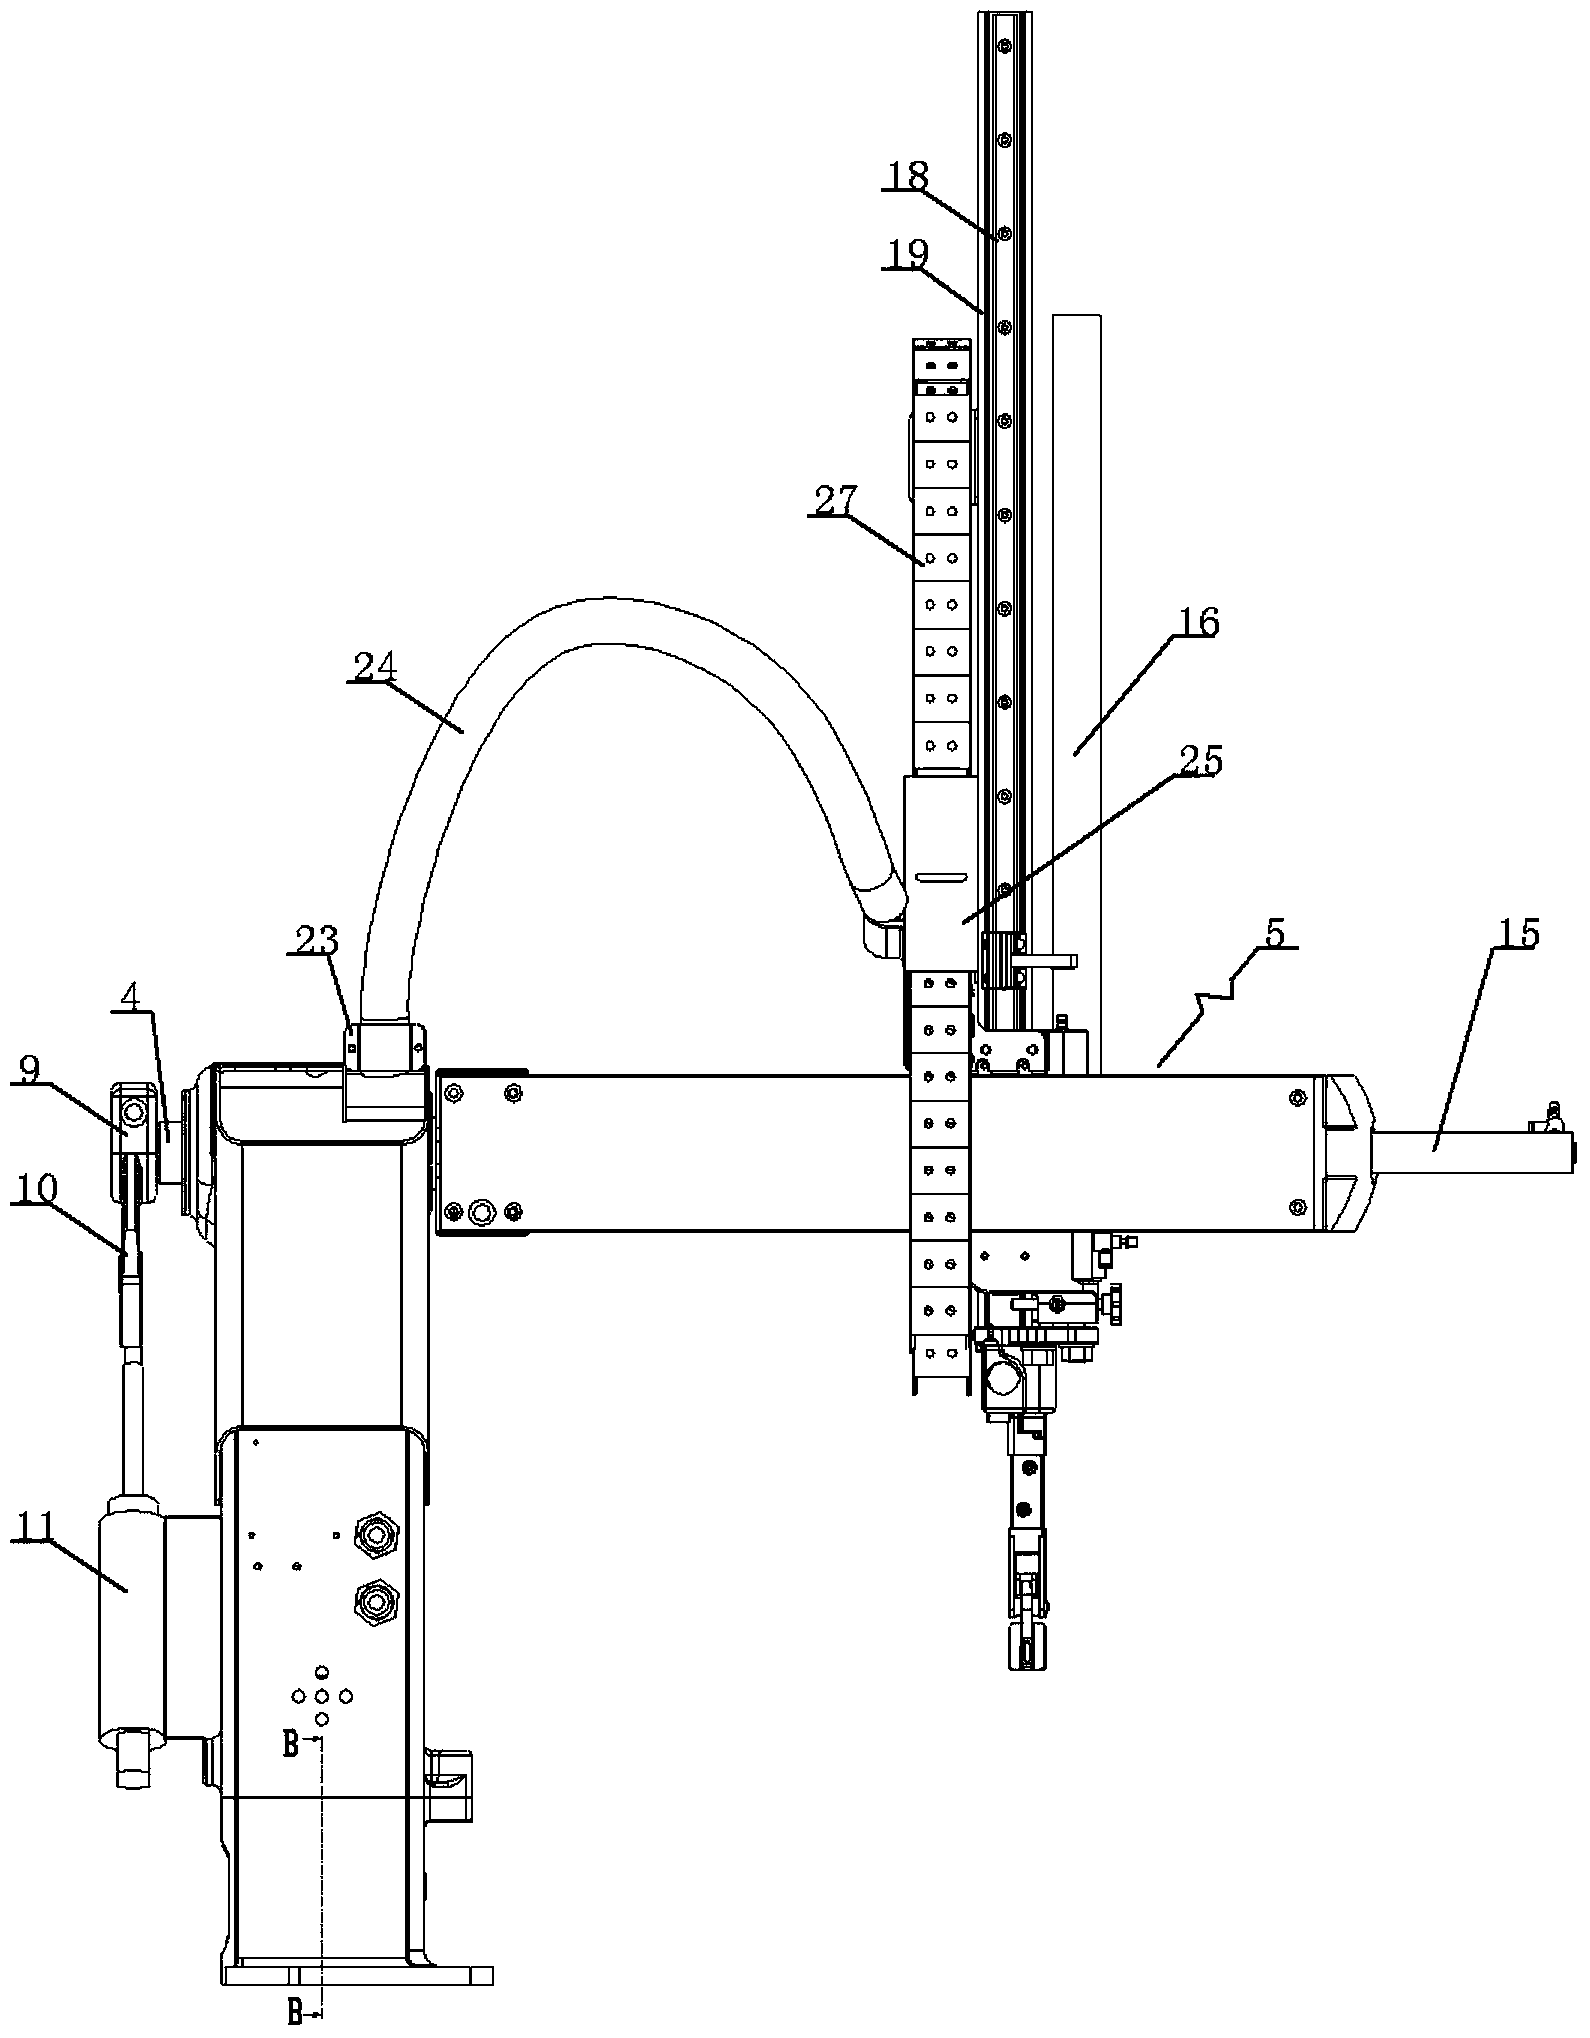
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of manipulator structures, in particular to a cantilever manipulator structure. Background technique
[0002] The existing manipulator includes a clamping part. After the clamping part is fastened to the corresponding base, the base is supported on a three-coordinate platform that can perform X, Y, and Z axes. According to the position of the workpiece, the position of the three-coordinate platform is adjusted so that The clamping part clamps the workpiece smoothly. With the continuous development of modernization, the three-coordinate positioning manipulator can no longer meet the needs of modern production. A four-axis manipulator for grabbing sheet metal parts", discloses the following technology "composed of one-axis parts, two-axis parts, three-axis parts, four-axis parts and electric control cabinets, one of which realizes the mechanical arm The lifting movement, the two-axis parts realize the rotary ...
Examples
Embodiment Construction
[0025] A cantilever manipulator structure, see Figure 1 to Figure 9 : It includes a base 1 and a support 2, the support 2 is supported on the base 1, a bottom rotating shaft 3 is arranged between the bottom center of the support 2 and the base, the support 2 can rotate relative to the base 1, The upper part of the support 2 is arranged with a horizontal rotating shaft 4 that runs through its front and rear ends. The horizontal rotating shaft 4 can rotate around. The structure 5 is provided with a drawing guide rail 6 parallel to the horizontal axis of rotation. The upper and lower seats 7 are clamped on the drawing guide rail 6. The upper and lower seats 7 can move linearly along the drawing guide rail 6. The upper and lower seats 7 are fastened with a linear drive. Components, the driving direction of the linear drive component is perpendicular to the upper plane of the drawing guide rail 6 , and the lower drive part of the linear drive component is fastened to the clamping ...