
A point cloud misregistration filtering method and system for three-dimensional measurement of complex special-shaped surface robot
A technology of 3D point cloud and robot, which is applied in the fields of instruments, 3D image processing, image analysis, etc.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2020-12-15
Smart Images
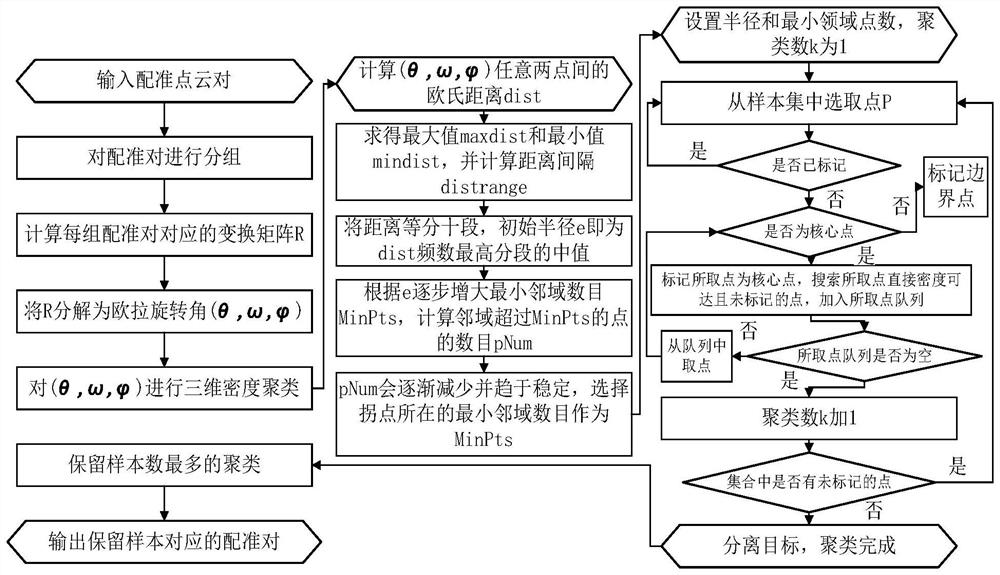
Figure 1 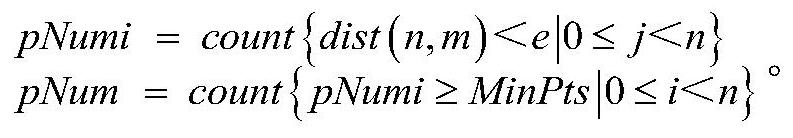
Figure 2 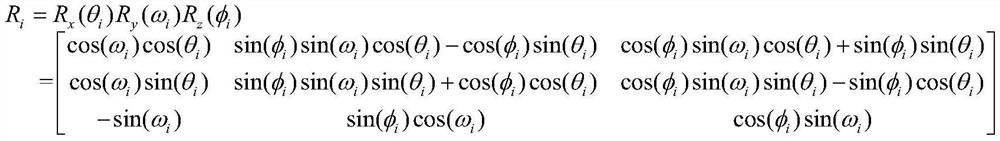
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of image registration, and in particular relates to a point cloud misregistration filtering method and system for three-dimensional measurement of complex special-shaped curved surface robots. Background technique
[0002] Intelligent manufacturing technology is to replace human beings to complete high-precision, high-intensity repetitive operations through the integration of intelligent perception, human-computer interaction, decision-making and execution technologies through industrial robots. It can complete complex workpiece identification, positioning and grasping, welding and grinding, drilling and riveting and other tasks.
[0003] Intelligent manufacturing is developing from 2D machine vision to 3D machine vision, but compared with 2D machine vision, the accuracy of point cloud registration in 3D visual space has always been lower. The main reason is that the three-dimensional space has high data complexity, ...
Examples
Embodiment Construction
[0033] The present invention will be further described below in conjunction with the accompanying drawings and embodiments.
[0034] Using the robot mobile platform equipped with a 3D scanning device at the end, it will scan the complex special-shaped surface target from multiple directions, collect 3D image information, calculate the registration points for feature matching through the computer, and use the point cloud error of the complex special-shaped surface robot 3D measurement The registration filtering method filters out incorrect registration results and obtains correct matching results.
[0035] The 3D target is a blade with a special-shaped curved surface. The special-shaped curved surface refers to a non-standardized complex surface structure. The similarity of the local depth image is high, and the surface model contains high-order nonlinear functions that are difficult to fit. The registration accuracy of multiple 3D point cloud depth images is difficult to guara...