
Air-ground amphibious mini unmanned aerial vehicle
An unmanned aerial vehicle (UAV) and miniature technology, applied in the field of UAV, can solve the problems of complex structure, difficult to maneuver, slow development of large-scale quadrotor UAV, etc. Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2017-08-18
Smart Images
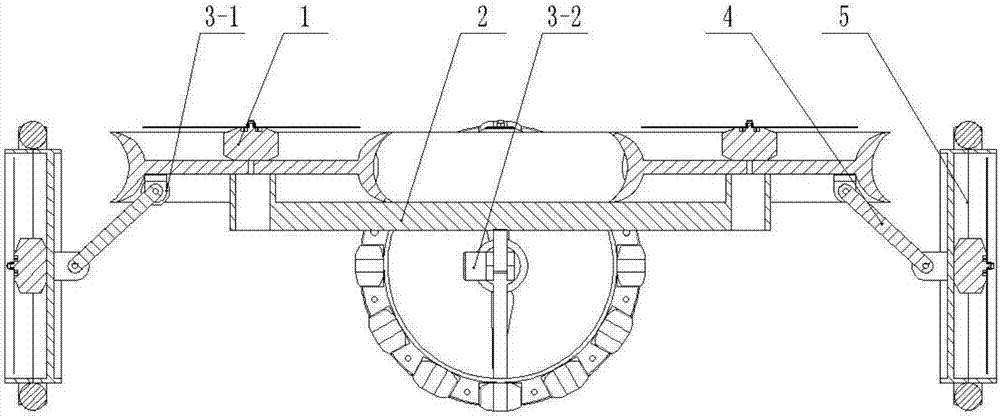
Figure 1 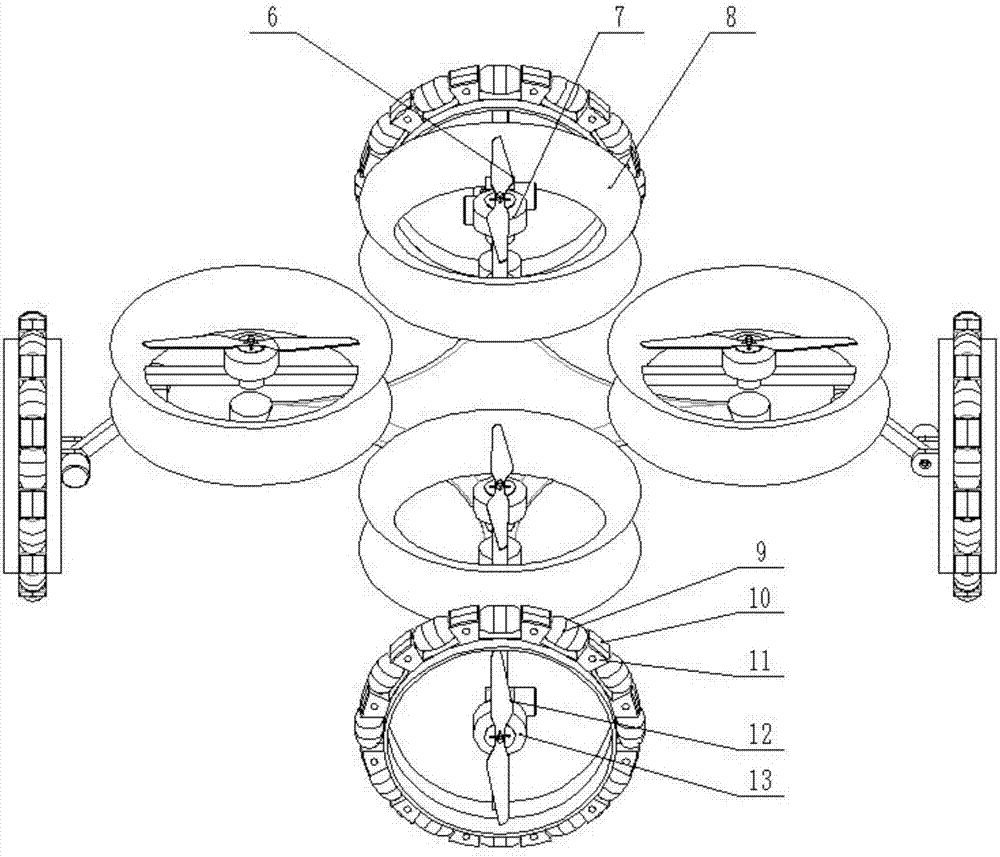
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention relates to an unmanned aerial vehicle technology, and Terne is a ground-air amphibious miniature unmanned aerial vehicle. Background technique
[0002] Traditional large-scale UAVs mainly use four-rotor, six-rotor or multi-rotor to perform tasks such as shooting, monitoring and reconnaissance in the near-ground environment. However, due to reasons such as complex structure and difficult manipulation, the development of large-scale quadrotor UAVs has been relatively slow. . In recent years, with the advancement of new materials, micro-electro-mechanical (MEMS), micro-inertial navigation (MIMU) and flight control technologies, micro-UAVs have developed rapidly and have gradually become the focus of attention.
[0003] Micro drones are especially suitable for monitoring, reconnaissance and other tasks in near-ground environments (such as indoors, urban areas and jungles, etc.), and have broad military and civilian prospects; at the same tim...
Examples
Embodiment Construction
[0016] combine figure 1 , a new type of land-air amphibious micro UAV, including upper rotor assembly 1, frame 2, motor 3-1 (with self-locking function), motor 3-2 (with self-locking function), connecting rod 4 and lower rotor Component 5. The upper rotor assembly 1 is fixedly connected to the frame 2 by bolts, the motor 3-1 is fixed to the upper rotor assembly 1 by bolts, the output shaft of the motor 3-1 is connected to the connecting rod 4 through a key, and the motor 3-2 is connected by The bolt is fixedly connected on the lower rotor assembly 4, and the output shaft of the motor 3-2 is rotatably connected with the connecting rod 4 through the key.
[0017] combine figure 2 , there are four upper rotor assemblies 1, and the distribution of the upper rotor assemblies 1 is carried out in the following manner: the lines connecting the centers of the two upper rotor assemblies are perpendicular to each other. Each upper rotor assembly 1 includes a blade 6 , a motor 7 and a...