
Grinding and polishing robot
A robot and polishing wheel technology, applied in the field of polishing, can solve problems such as high noise, lack of precision polishing, and difficulty in ensuring the consistency of processed workpieces
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2018-10-19
Smart Images
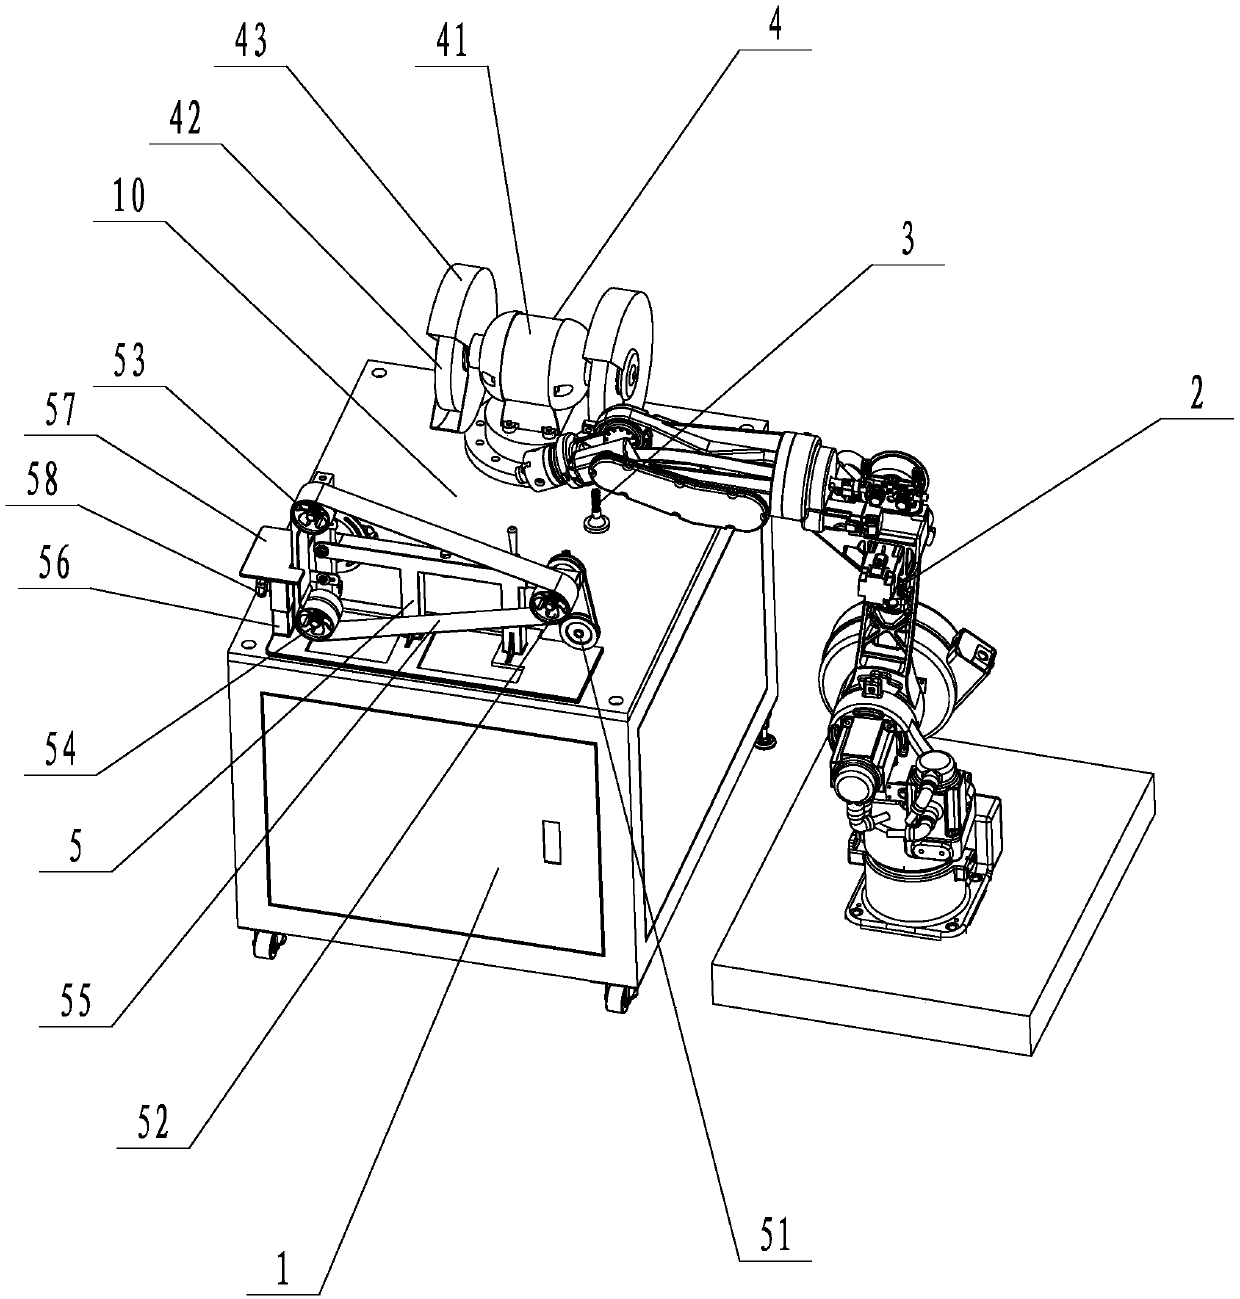
Figure 1
Abstract
Description
technical field
[0001] The invention relates to the technical field of polishing, in particular to a grinding and polishing robot. Background technique
[0002] The existing grinding and polishing manipulator is suitable for all aspects of the grinding and polishing process of various types of workpieces and materials. Compared with the high efficiency of robotic automatic grinding and polishing, the polishing of conventional complex-shaped workpieces (such as aviation blades, pipe fittings, faucets, and precision castings) etc.) need to be done manually, and the main disadvantages of manual operation are as follows: 1. Low processing efficiency, manual operation, fatigue problems will occur; 2. It is difficult to guarantee product consistency, manual operation, there will be proficiency and technical level 3. The working environment of the production personnel is harsh, and the operator is always in a noisy and dusty working environment, which will cause harm to the human b...
Examples
Embodiment Construction
[0013] The present invention will be further described in detail below in conjunction with the accompanying drawings and specific embodiments.
[0014] refer to figure 1 , a grinding and polishing robot of the present invention includes a polishing workbench 1 and a manipulator 2 that can move a workpiece. A working area 10 is arranged on the top, and a milling cutter 3 is arranged at the front end of the working area 10. A belt machine 5 and a polishing wheel mechanism 4 are respectively arranged on both sides of the milling cutter 3. The manipulator 2 is located on the polishing table 1 The front side of the milling cutter is close to 3 sides. When working, the conveying device transports the workpiece to the working area 10 of the polishing table 1, and then the manipulator 2 grabs and places the workpiece on the milling cutter 3 for surface milling, so that the size of the workpiece is more uniform before fine polishing, and then The manipulator 2 then grabs and moves th...