
Integrated positioning device and method based on AGV and laser tracker
A laser tracker and combined positioning technology, applied in the direction of using optical devices, measuring devices, instruments, etc., can solve the problems of complex control of the positioning system, low degree of automation, inability to practical application, etc., to ensure overall accuracy, avoid data export, The effect of improving the overall measurement efficiency
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2020-10-23
Smart Images
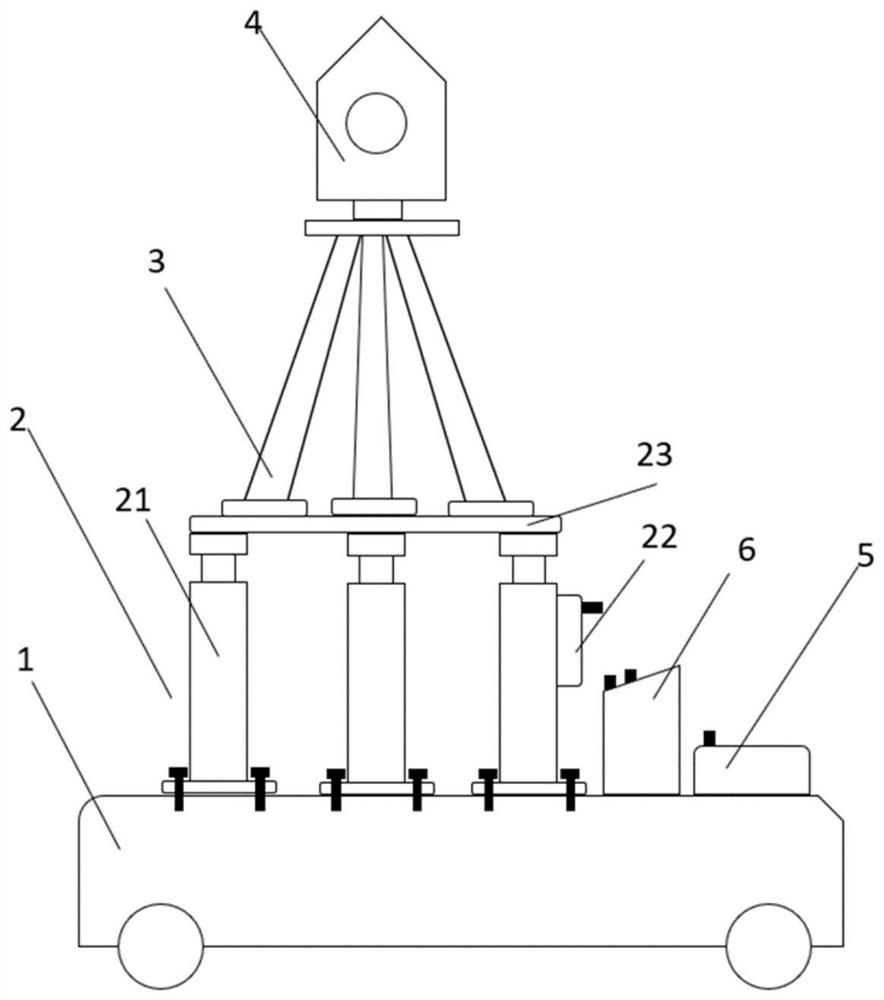
Figure 1 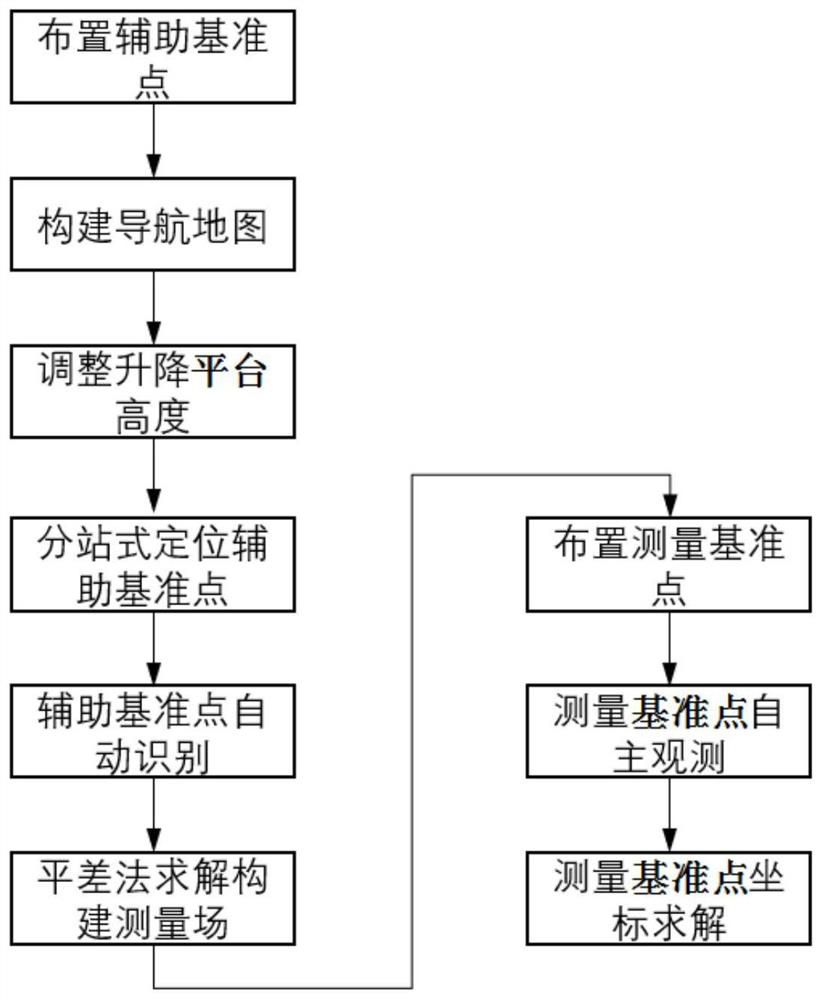
Figure 2
Abstract
Description
technical field
[0001] The invention belongs to the field of high-precision positioning, and in particular relates to a combined positioning device and method based on an AGV and a laser tracker. Background technique
[0002] In recent years, my country's aviation manufacturing industry has developed rapidly, and various new aircraft such as supersonic, super stealth, and super large have been successfully developed and put into mass production. However, many urgent problems have been exposed in the production process, such as the high-precision measurement of large aircraft parts and the overall shape of the aircraft.
[0003] At present, the measurement of large aircraft parts and the shape of the whole machine is usually to place dense targets or target balls on the object to be measured as a public reference point, and then use a handheld laser scanner to scan and obtain local measurement point clouds , and use the method of local point cloud data splicing to generate t...
Examples
Embodiment Construction
[0038] The combined positioning device and method based on the AGV and the laser tracker in the present invention will be further described in detail below in conjunction with the accompanying drawings and specific embodiments.
[0039] like figure 1As shown, a combined positioning device based on an AGV and a laser tracker includes a mobile platform 1 and a laser tracker 4. The upper end of the mobile platform 1 is fixedly equipped with a lifting platform 2, a system control module 5 and a system power supply module 6. The laser tracker 4 is fixedly arranged on the lifting platform 2. The mobile platform 1 is an AGV platform with a laser radar positioning system (indoor positioning accuracy is 100 mm), the system power supply module 6 supplies power for the combined positioning device, and the mobile platform 1, lifting platform 2 and laser tracker 4 communicate with the system control module 5 signals respectively. connect. The system control module 5 is used to control th...