
Intelligent detection and grabbing method based on ROS platform
An intelligent detection and platform technology, applied in the direction of program-controlled manipulators, manufacturing tools, chucks, etc., can solve the problems of long target detection time and low grasping accuracy, and achieve the effect of shortening the estimation time and improving the detection speed.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2020-08-04
Smart Images
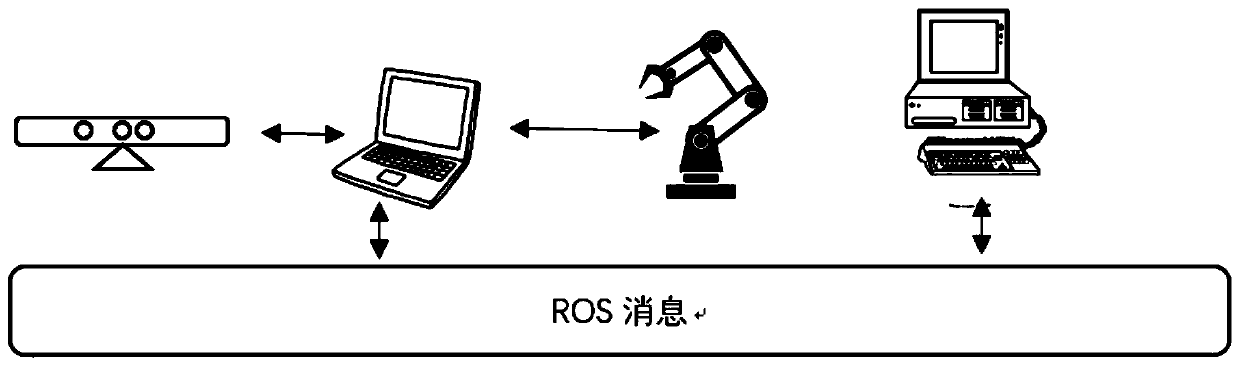
Figure 1 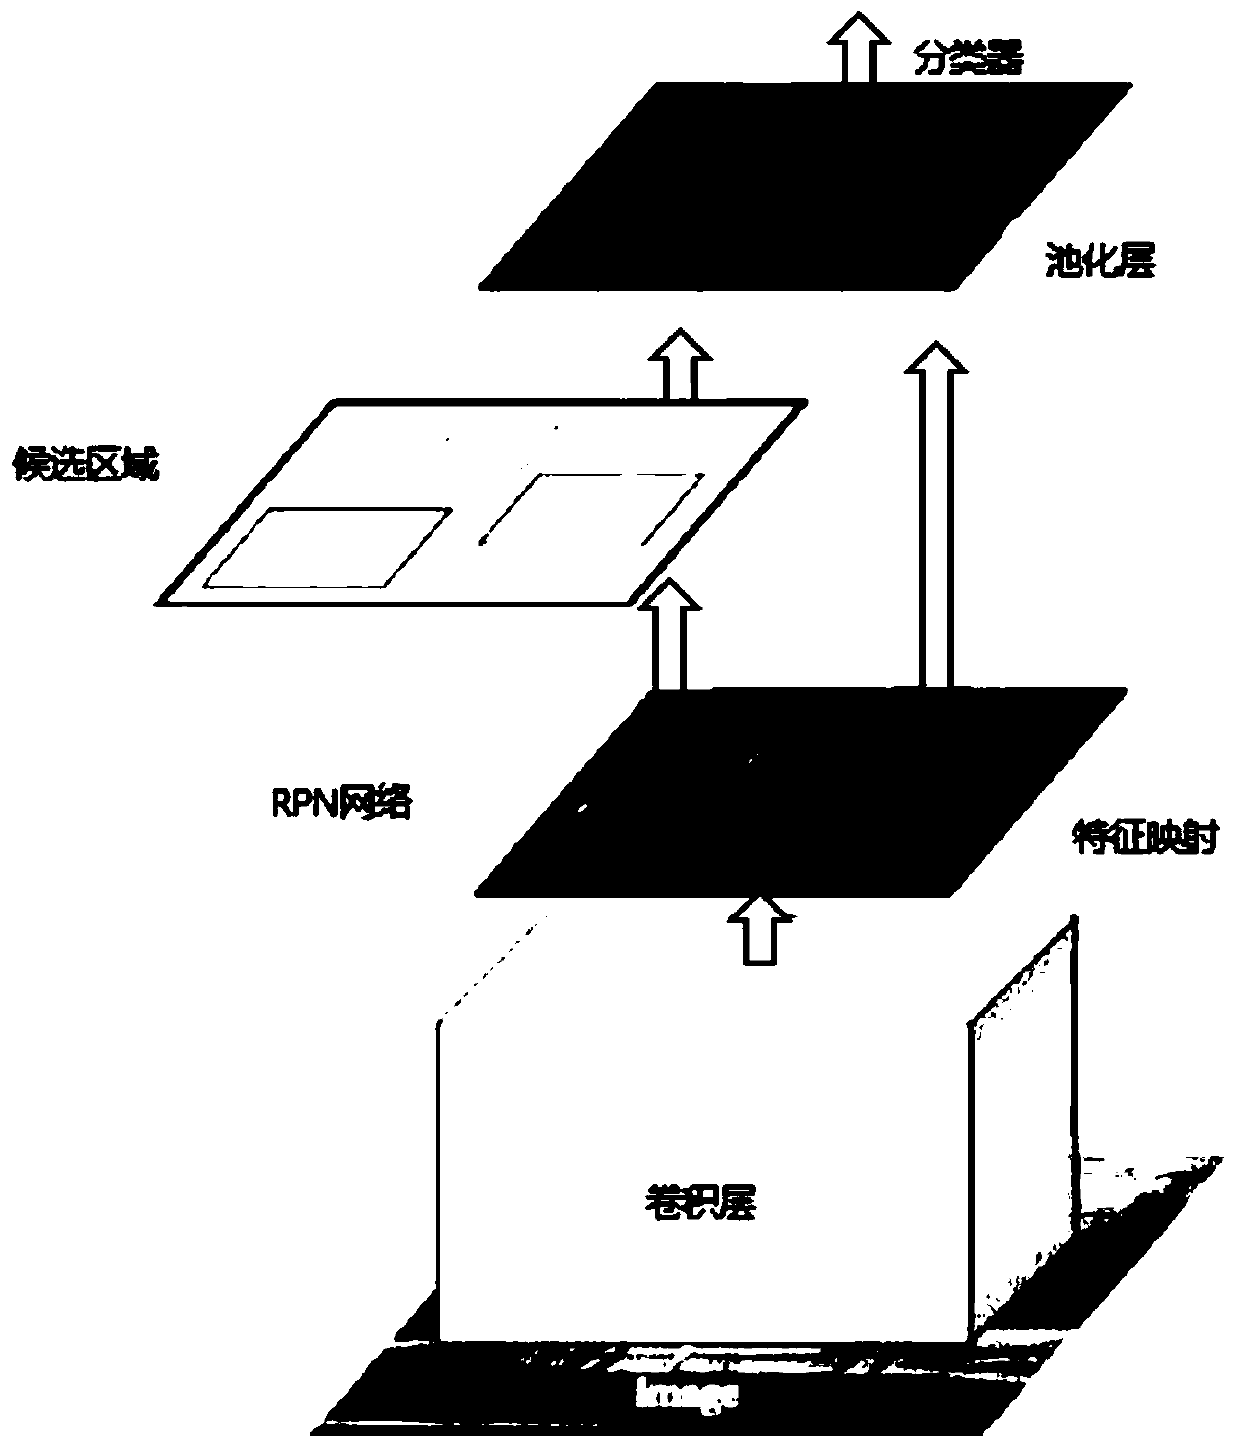
Figure 2 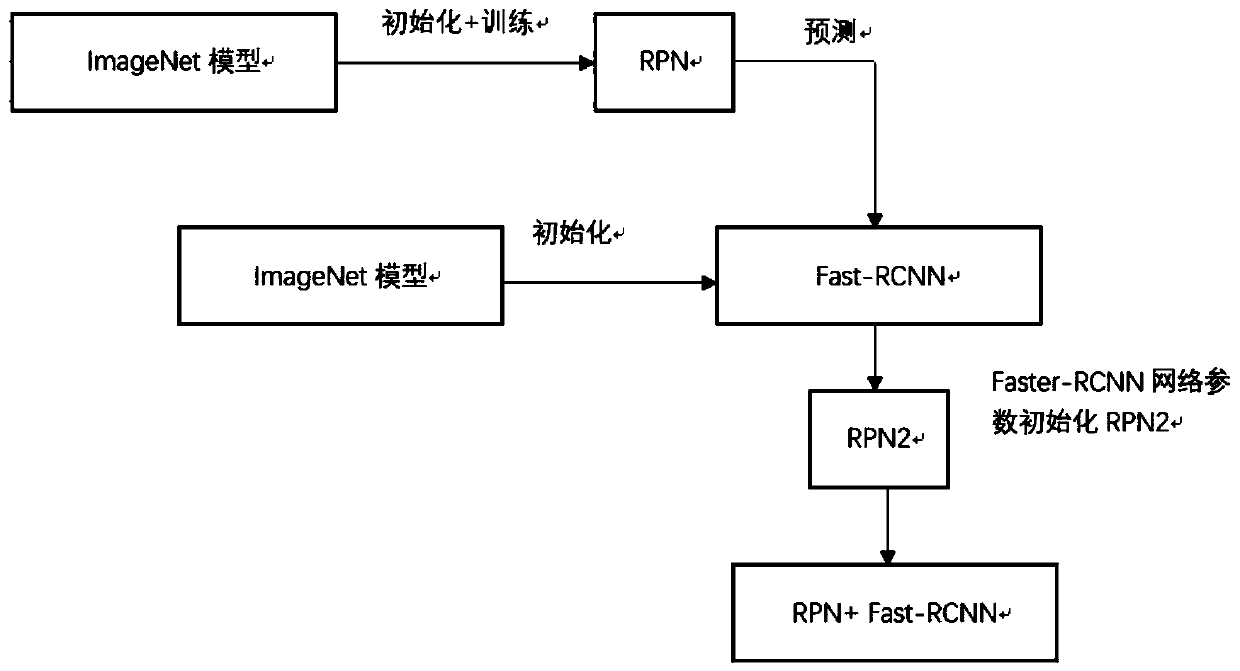
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of control and motion planning of a mechanical arm, and specifically relates to an intelligent detection and grasping method based on a ROS platform, and relates to a method for grasping an object by a mechanical arm, which can realize object recognition and find out the best grasping method. Grips for grabbing. Background technique
[0002] The control and grabbing of existing manipulators often use teaching methods, such as Chinese Patent Publication No. CN108655026A, titled "A System and Method for Rapid Teaching and Sorting of Robots". Although this teaching method saves some programming links, It has the following disadvantages: the accuracy is completely determined by the visual inspection of the teaching operator, and it is difficult to obtain satisfactory results for the messy path teaching online programming, and accidents are prone to occur during the teaching process, ranging from crashing the equipment to ...
Examples
Embodiment Construction
[0018] The present invention will be described in detail below with reference to the accompanying drawings and preferred embodiments.
[0019] The present invention provides a kind of intelligent detection and grasping method (abbreviation method) based on ROS platform, this method adopts following steps to realize:
[0020] Step 1: Install Kinect somatosensory peripherals through the peripheral fixing frame, place them on the top or side of the robotic arm, and make the robotic arm within the shooting field of view of its camera for easy shooting, and place the objects to be grasped on the platform Installed in front of the robot arm.
[0021] Step 2: Configure the scene realized by this method, connect Kinect somatosensory peripherals, a desktop computer, a mobile notebook computer and the robotic arm for communication. The specific method is to connect the notebook computer to the Internet using WIFI, and connect It is set as the ROS master server, assuming its IP address ...