Vertical movement device of truss manipulator

A truss robot and longitudinal movement technology, applied in the field of truss robots, can solve problems such as difficulties, uneven force, and high cost, and achieve the effects of overcoming uneven force, prolonging service life, and enhancing overall rigidity

Inactive Publication Date: 2014-07-09
TIANJIN EASY ROBOT SCI & TECH DEV
View PDF0 Cites 2 Cited by
  • Summary
  • Abstract
  • Description
  • Claims
  • Application Information

AI Technical Summary

Problems solved by technology

The traditional hanging arm structure often deforms after being used for a period of time due to uneven force, which brings great difficulties to high-precision walking positioning
In addition, it is often time-consuming and labor-intensive to maintain, and the cost is high.

Method used

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
View more

Image

Smart Image Click on the blue labels to locate them in the text.
Viewing Examples
Smart Image
  • Vertical movement device of truss manipulator
  • Vertical movement device of truss manipulator

Examples

Experimental program
Comparison scheme
Effect test

Embodiment Construction

[0015] The present invention will be further elaborated below in conjunction with the accompanying drawings.

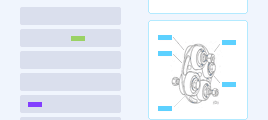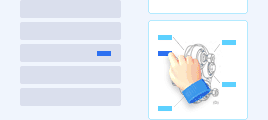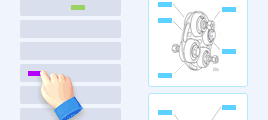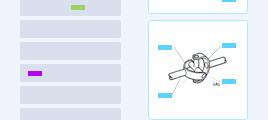
[0016] like figure 1 As shown, a longitudinal moving device of a truss robot in this embodiment includes a truss 1, a hanging arm 4, a running mechanism and a transmission mechanism, the truss 1 and the hanging arm 4 are connected together by a running mechanism, and the hanging arm 4 is a rectangular tubular structure ; The three adjacent sides of the truss 1 are working surfaces, the two parallel working surfaces are the first working surface and the second working surface, and the working surface perpendicular to the first working surface or the second working surface is the third working surface The traveling mechanism includes a linear guide rail 2, and the linear guide rail 2 has two groups, which are respectively fixed on the first working surface and the second working surface, and the sliders 6 matched with the linear guide rail 2 are respectively fixed on th...

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

PUM

No PUM Login to View More

Abstract

The invention provides a vertical movement device of a truss manipulator. The vertical movement device of the truss manipulator comprises a truss, a cantilever, a travelling mechanism and a transmission mechanism. The truss and the cantilever are connected through the travelling mechanism, the cantilever is of a rectangular tubular structure, the three neighboring side surfaces of the truss are working surfaces, the travelling mechanism comprises linear guide rails or ball screws, and the transmission mechanism comprises racks or lead screws. The vertical movement device of the truss manipulator changes single-surface stress into symmetrical double-surface stress, overcomes the existing defect of uneven stress, reduces damage due to inertia force during rapid movement, enhances integral rigidity and prolongs the service life.

Description

technical field [0001] The invention belongs to the field of truss robots, in particular to a longitudinal movement device of a truss robot. Background technique [0002] Truss robots are now widely used in the production of various products, especially for the welding of large equipment, which has incomparable advantages. Generally, the electric welding machines carried on truss robots are heavy in weight, and have extremely high requirements for walking positioning accuracy. The traditional hanging arm structure often deforms after being used for a period of time due to uneven force, which brings great difficulties to high-precision walking positioning. In addition, maintenance is often time-consuming and labor-intensive, and the cost is high. Contents of the invention [0003] The problem to be solved by the present invention is to provide a longitudinally moving device for a truss robot with uniform force and strong rigidity. [0004] In order to solve the above tec...

Claims

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

Application Information

Patent Timeline
no application Login to View More
Patent Type & AuthorityApplications(China)
IPC IPC(8): B25J9/00
Inventor吴涛张天江吴永英吴永军石明王悦
OwnerTIANJIN EASY ROBOT SCI & TECH DEV