Dental implant implanter with five degrees of freedom in space

A technology of tooth implantation and degree of freedom, applied in dentistry, dental implants, dental prosthetics, etc., can solve the problems of lack of safety, unable to truly replace manual operation, unable to complete automatic implantation, etc., to ensure safety and flexibility of movement high effect

Active Publication Date: 2021-12-31
BEIHANG UNIV +1
View PDF9 Cites 0 Cited by
  • Summary
  • Abstract
  • Description
  • Claims
  • Application Information

AI Technical Summary

Problems solved by technology

The above two groups of robots represent the existing outstanding achievements in the field of automatic tooth implantation. However, the automatic implantation robot developed by Beihang University and the Fourth Military Medical University lacks safety considerations. The YOMI robot facilitates the operation of doctors, but it cannot complete automatic implantation. Really replace manual operation

Method used

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
View more

Image

Smart Image Click on the blue labels to locate them in the text.
Viewing Examples
Smart Image
  • Dental implant implanter with five degrees of freedom in space
  • Dental implant implanter with five degrees of freedom in space
  • Dental implant implanter with five degrees of freedom in space

Examples

Experimental program
Comparison scheme
Effect test

Embodiment Construction

[0042] The present invention will be described in further detail below in conjunction with the accompanying drawings.

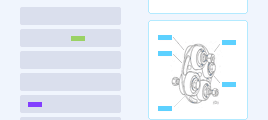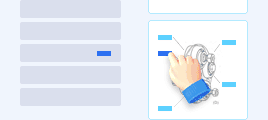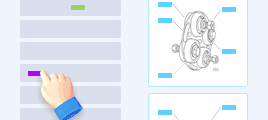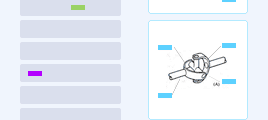
[0043] The space five-degree-of-freedom dental implant implanter of the present invention includes an XY-direction translation platform 1, a Z-direction movement drive mechanism 2, a two-degree-of-freedom attitude adjustment module 3, a force detection module 4, and an implant screw-in module 5, such as figure 1 shown.

[0044] The XY direction moving platform 1 has a Y direction moving platform 103 installed on the disk base 101 , and an X direction moving platform 102 is installed on the Y direction moving platform 102 .

[0045] The Z-direction driving motor module 2 is installed on the pedestal of the aforementioned X-direction moving platform 102 , and the Z-direction driving motor module 2 is controlled to move in translation along the X-axis and the Y-axis through the XY-direction moving platform 1 . The Z-direction drive motor module includes a guid...

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

PUM

No PUM Login to View More

Abstract

The invention discloses a spatial five-degree-of-freedom dental implant implanter which comprises an XY-direction translation platform, a Z-direction movement driving mechanism, a two-degree-of-freedom posture adjusting module, a force detection module and an implant screwing-in module. Wherein the X-direction and Y-direction translation platform and the Z-direction movement driving mechanism can realize position adjustment of an implant at the tail end of the implanter on three spatial axes. The two-degree-of-freedom posture adjusting module is installed at the output end of the Z-direction movement driving mechanism, and the implant can rotate around the Z axis and move along an arc with the implant as the circle center. The implant screwing-in module is used for being connected with an implant, and the implant can rotate around the axial direction of the implant. The force detection module is mounted between the two-degree-of-freedom posture adjusting module and the implant screwing-in module and is used for detecting the stress condition of the implant. According to the invention, five uncoupled degrees of freedom are designed, so that the movement of the implanter is highly flexible, and compared with the mode that a doctor only depends on manual implantation in a traditional implantation operation, the tooth implantation operation and the precision can be effectively ensured.

Description

technical field [0001] The invention belongs to the field of dentistry, in particular to a dental implant implanter with five degrees of freedom in space Background technique [0002] Dental implant surgery is a common operation in dental surgery. Traditional dental implant surgery is performed manually by doctors with the aid of dental surgical instruments. The main process is: gingival flap, cavity preparation, implant placement, and restoration of the surgical area. The current dental implant surgery is almost done manually by doctors, and dental implant surgery heavily depends on the doctor's operating experience and working status. In order to break the status quo of dental implant surgery and realize dental implant automation, many universities and companies have carried out vigorous exploration in this field and produced some results. Beihang University and the Fourth Military Medical University jointly researched an automatic planting robot system. Its main function...

Claims

the structure of the environmentally friendly knitted fabric provided by the present invention; figure 2 Flow chart of the yarn wrapping machine for environmentally friendly knitted fabrics and storage devices; image 3 Is the parameter map of the yarn covering machine
Login to View More

Application Information

Patent Timeline
no application Login to View More
Patent Type & AuthorityApplications(China)
IPC IPC(8): A61C8/00A61B34/30A61B90/00
CPCA61C8/0089A61B34/30A61B34/76A61B90/06A61B2090/065
Inventor王巍曾艺萌蔡月日李建原福松张敬涛
OwnerBEIHANG UNIV