
A robot path search method, system, device and storage medium
A path search and robot technology, applied in manipulators, program-controlled manipulators, manufacturing tools, etc., can solve the problems of cumbersome teaching steps and reduce the applicability of search methods, so as to simplify the steps of teaching and searching, improve flexibility and Practicality, the effect of improving work efficiency
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2021-06-01
Smart Images
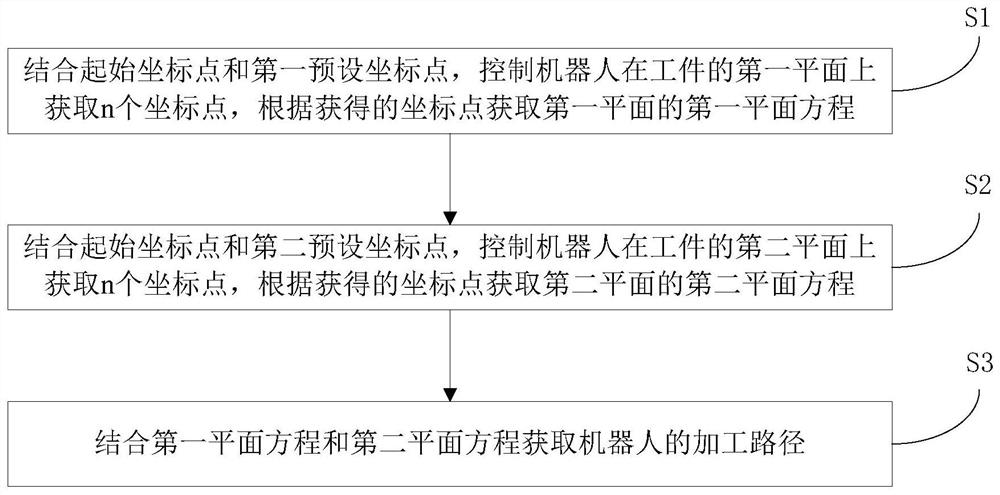
Figure 1 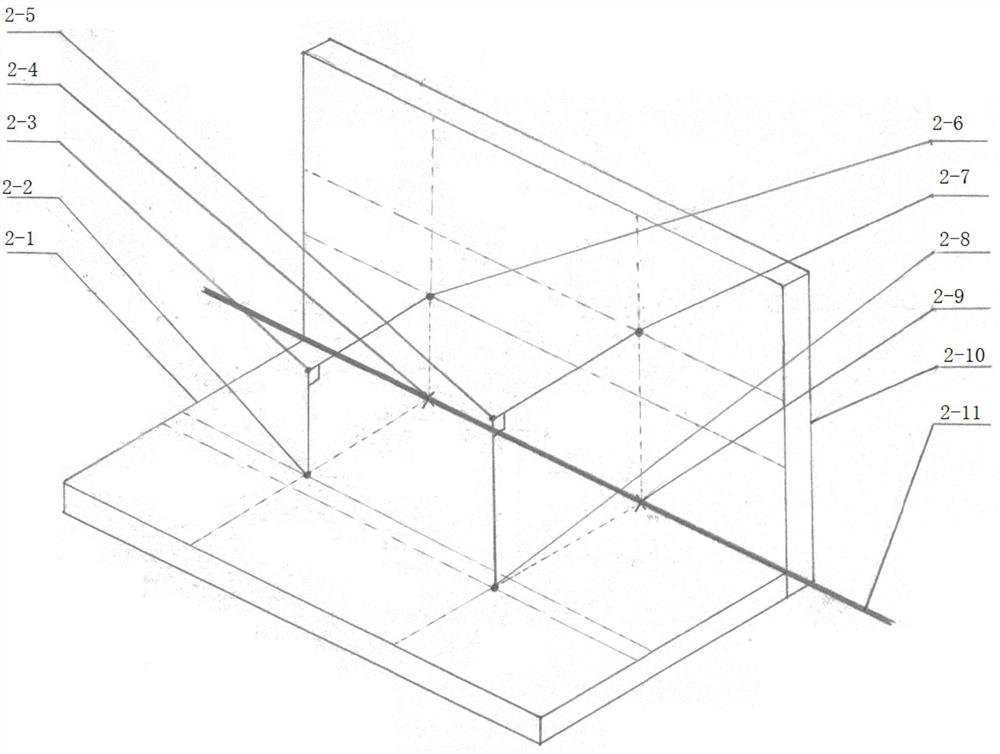
Figure 2 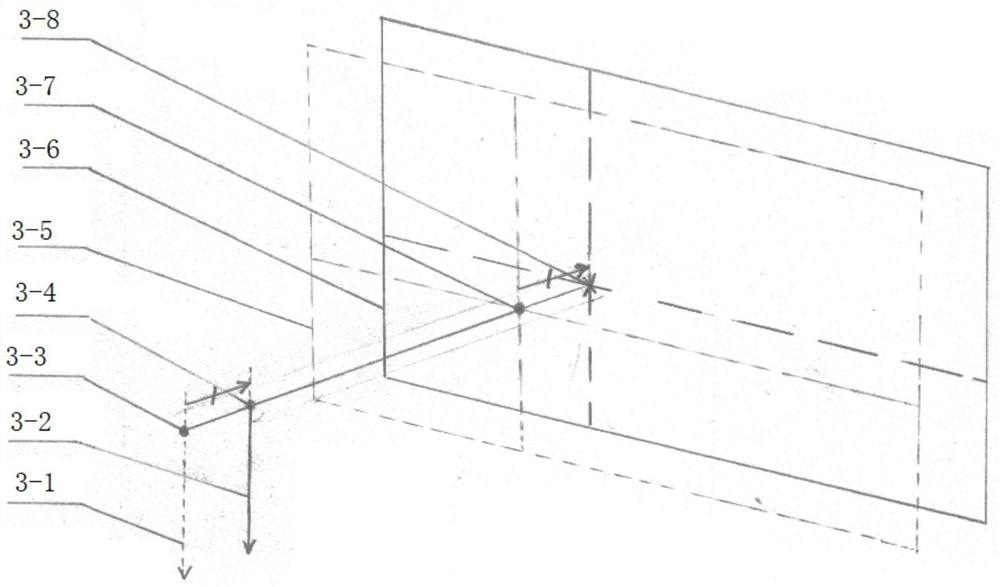
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of robot path planning, in particular to a robot path search method, system, device and storage medium. Background technique
[0002] In the production and processing application of industrial robots, before batch processing of workpieces, the robot will teach the workpiece; when batch processing of workpieces, there are position offsets and errors between the processed workpiece and the position of the workpiece during teaching. In order to solve the above problems, the existing technical method is to confirm the actual working path by comparing the initial teaching point, searching and calculating the parallel and rotational offset of the working object.
[0003] In the technology of searching the working path, the offset search is mainly used now. Although the offset search has a careful offset calculation method and a point-position superposition method, it also has great disadvantages. That is, the touch point n...
Examples
specific Embodiment
[0188] The following uses a welding robot as an example to explain the above-mentioned plane search method in detail:
[0189] This plane search method includes a teaching step, a search step and a calculation step; refer to Figure 5 , where the teaching part is operated by workers before the robot performs batch operations. The process of the teaching part is as follows:
[0190] Step 1: Control the teaching robot to move to the starting point where it can move in a straight line without being hindered and touch the two surfaces. Record this point as point 1 (x1, y1, z1);
[0191] Step 2: Move the teaching robot to the first plane and touch it, and record this touch point as point 2 (x2, y2, z2);
[0192] Step 3: Set the radius r of the circle centered at point 2 1 , the circle is perpendicular to the straight line connecting point 1 and point 2, so that moving from point 1 to any point on the circle can touch the first plane;
[0193] Step 4: Move the teaching robot to ...