
Unmanned surface vessel full state constraint trajectory tracking control method based on saturation compensation technology
A trajectory tracking and control method technology, applied in two-dimensional position/course control, non-electric variable control, control/regulation system, etc., can solve the problems of state constraint saturation and large control error
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2018-11-13
Smart Images
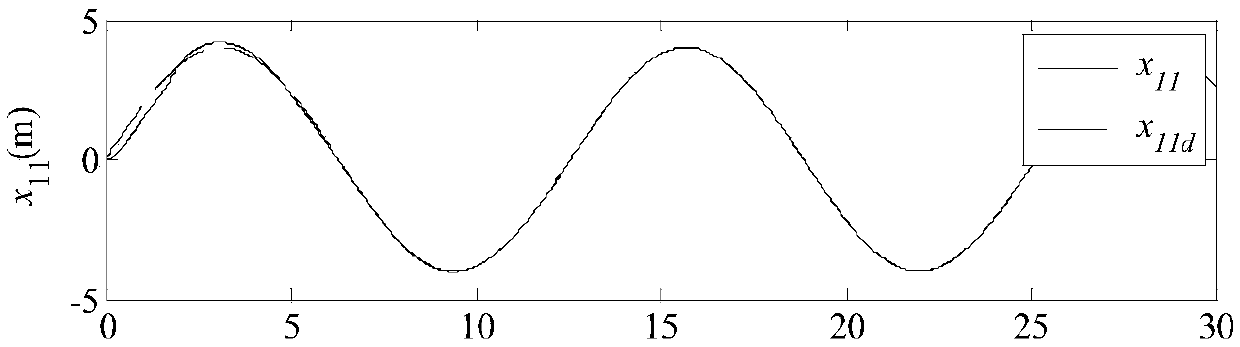
Figure 1 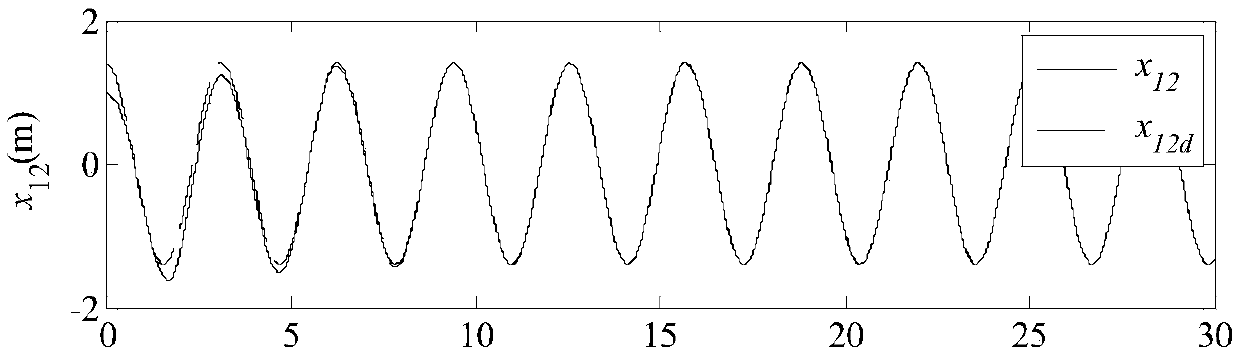
Figure 2 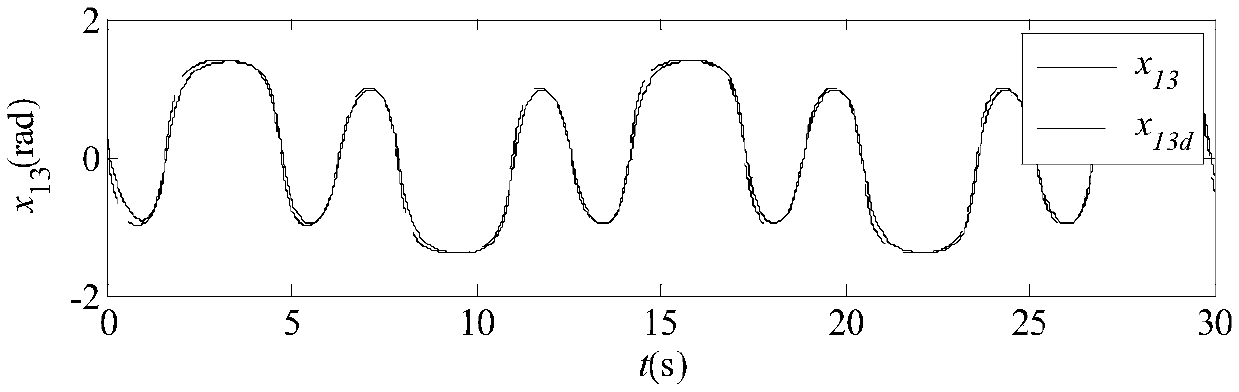
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of trajectory tracking control, in particular to a control method for an unmanned surface boat. Background technique
[0002] At present, people are paying more and more attention to ocean development, so marine survey and development tools such as surface unmanned ships, remote-controlled unmanned submersibles, and autonomous underwater submersibles are constantly being developed. Among them, as a multi-purpose, low-cost unmanned vehicle, the surface unmanned vehicle has broad application prospects in both military and civilian fields, so the research on the control of surface unmanned vehicles is of great significance.
[0003] Nowadays, with the increasing emphasis on surface unmanned boats, there are already a variety of motion control methods for them, such as trajectory tracking control, path following control, stabilization control, and formation control (Liao Yulei. Research on nonlinear motion control methods...
Examples
specific Embodiment approach 1
[0033] Specific implementation mode one: the full-state constraint trajectory tracking control method of the surface unmanned vehicle based on the saturation compensation technology includes the following steps:
[0034] Before describing this implementation, first define the relevant parameters:
[0035] n x , η y , η ψ ——The position component and heading of the target USV relative to the ground coordinate system;
[0036] v x ,ν y ,ν ψ ——the surge, sway and yaw speed of the target USV;
[0037] M——symmetric positive definite inertia matrix;
[0038] C(ν)——centripetal force and Coriolis force matrix;
[0039] D(ν)——damping matrix;
[0040] g(η)——restoring force caused by gravity, sea current and buoyancy;
[0041] H - unknown interference;
[0042] J(η)——the non-singular transformation matrix from the satellite coordinate system to the ground coordinate system;
[0043] τ——desired control input;
[0044] sat(τ)——actual control input;
[0045] Δτ—the difference ...
specific Embodiment approach 2
[0158] Specific embodiment two: the difference between this embodiment and specific embodiment one is: the specific process of establishing the dynamics model of surface unmanned boat in the described step one is:
[0159] The coordinate origin o of the satellite coordinate system o-xy is located at the center of gravity of the surface unmanned boat, the x-axis points from the stern to the bow along the longitudinal axis, and the y-axis points to the port side; the coordinate origin O of the ground coordinate system O-XY is located at the mooring line At the connection with the mooring terminal, the X, Y axes and the x, y axes of the satellite coordinate system are in the same plane;
[0160] The dynamic model of the 3-DOF, multi-input and multi-output surface unmanned vehicle is as follows:
[0161]
[0162] in hollow Represents the field of real numbers; (η x , η y ) represents the position in the ground coordinate system, η ψ Indicates the heading angle in the gro...
specific Embodiment approach 3
[0165] Specific embodiment three: the difference between this embodiment and specific embodiment one or two is that: the dynamics model of the surface unmanned boat established according to step one in the described step two, the specific process of designing the saturation compensation auxiliary system is:
[0166] The present invention uses an anti-saturation compensator to process the saturation function, and designs a saturation compensation auxiliary system:
[0167]
[0168] Where M is a symmetric positive definite inertia matrix, C 1 ,C 2 is a diagonal matrix whose diagonal elements are all constant numbers, ζ 1 ,ζ 2 is the output of the saturation compensation auxiliary system, J is the non-singular transformation matrix from the satellite coordinate system to the ground coordinate system, Δτ is the difference between the desired control input τ and the actual control input sat(τ);
[0169] The error variable z for the position 1 and the error variable z for the...