
Multi-robot cooperative task allocation method and device and medium
A multi-robot, distribution method technology, applied in the direction of instruments, data processing applications, resources, etc., can solve problems such as low efficiency, chaotic task allocation logic, and difficulty in obtaining ideal results, so as to achieve reasonable planning, ensure work efficiency, and improve data transmission. speed effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-12-10
Smart Images
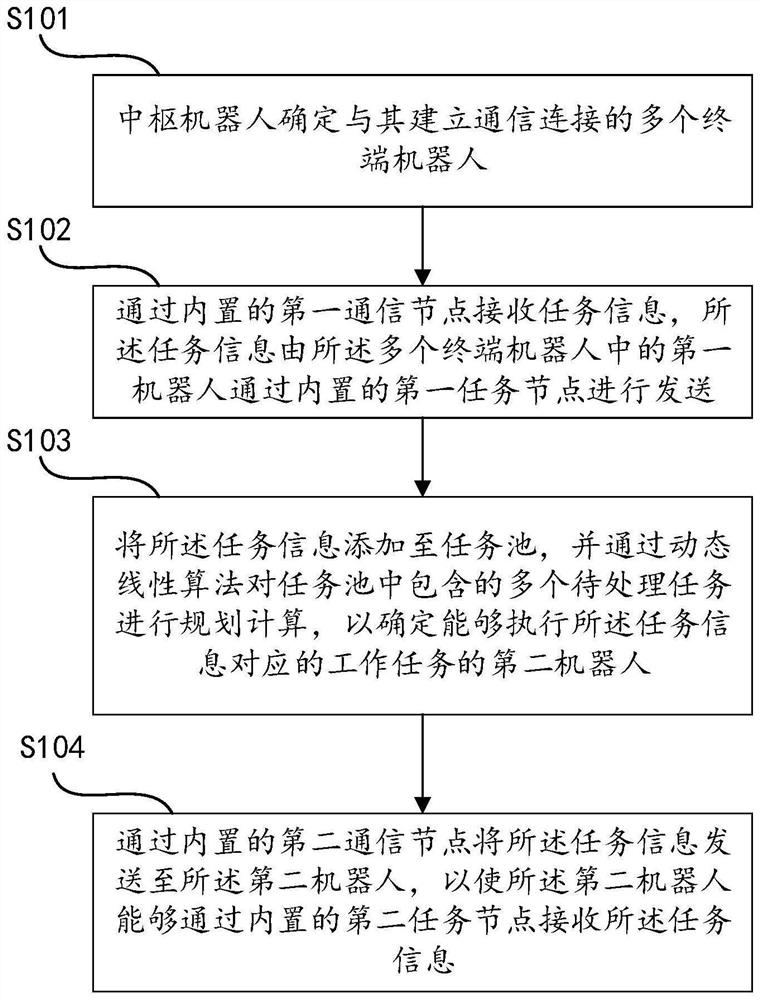
Figure 1 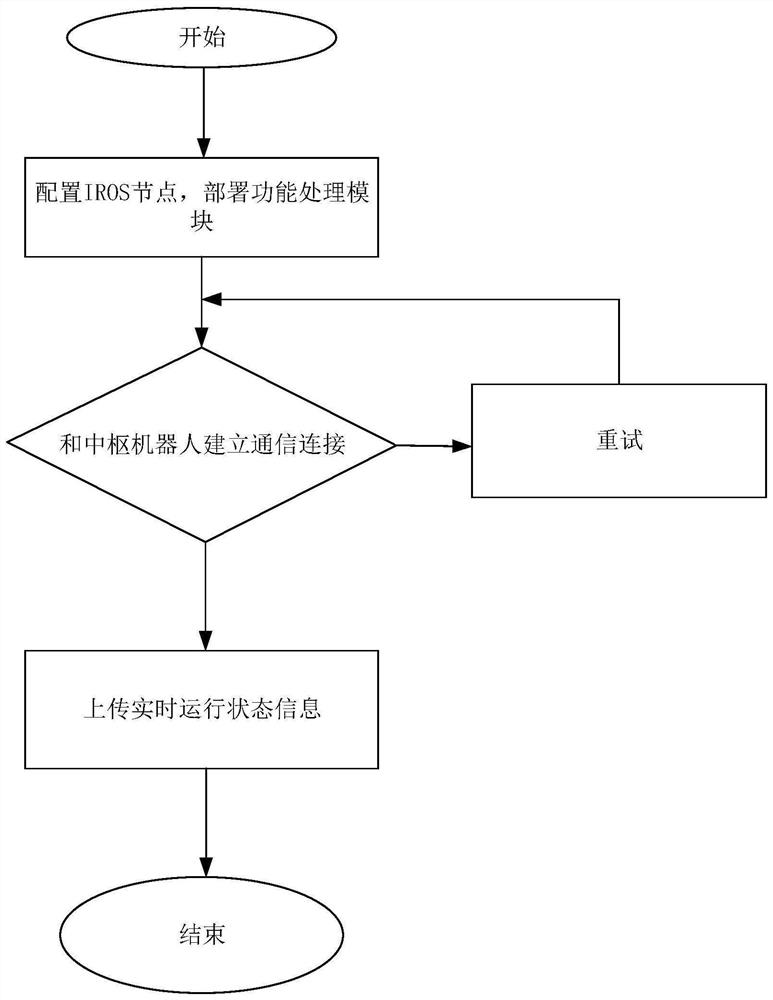
Figure 2 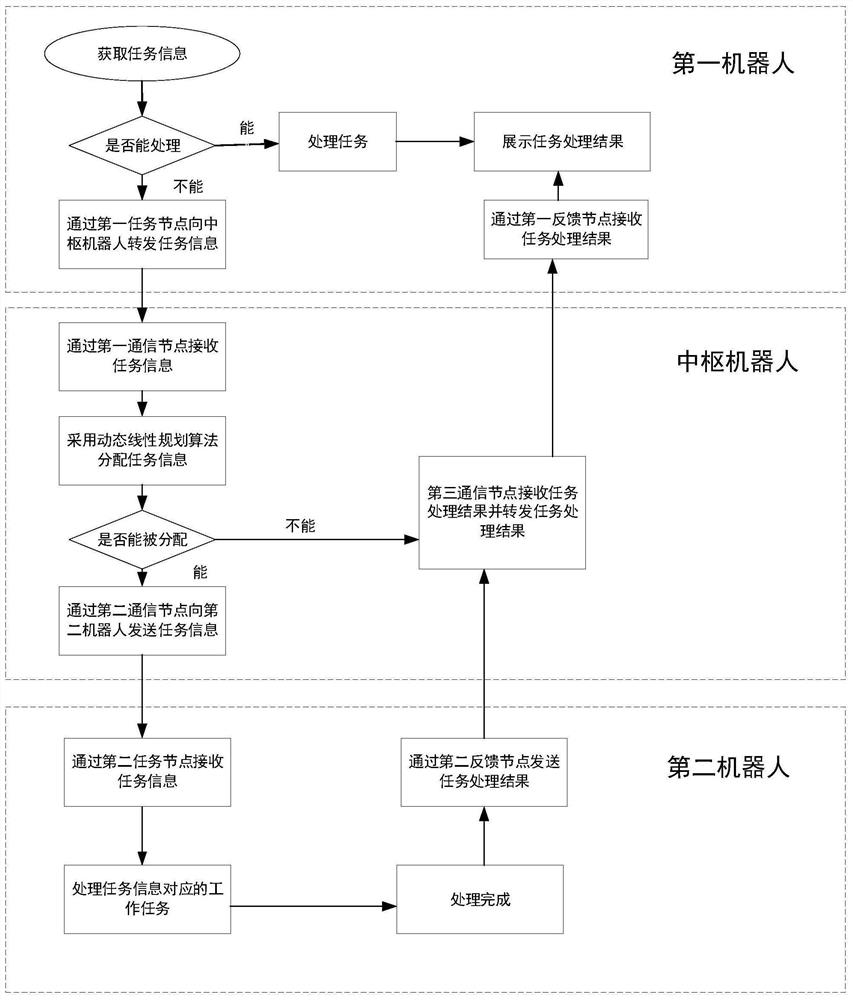
Figure 3
Abstract
Description
technical field
[0001] This application relates to the field of intelligent interconnection of robots, in particular to a method, equipment and media for multi-robot collaborative task assignment. Background technique
[0002] Robots are playing an increasingly important role in people's production and life. The functions of robots are becoming more and more powerful. At the same time, the working environment faced by robots is becoming more and more complex, and the types of tasks are becoming more complicated.
[0003] It is difficult for a single robot to obtain ideal results when dealing with tedious tasks in the form of individuals. In order to ensure the work efficiency of robots, research and discussion on collaborative work of robots has also been carried out, and has become a hot spot in the field of robotics in a short period of time. and key research areas.
[0004] In the existing robot collaborative work technology, there are big problems in the interconnection...
Examples
Embodiment Construction
[0022] In order to make the purpose, technical solution and advantages of the present application clearer, the technical solution of the present application will be clearly and completely described below in conjunction with specific embodiments of the present application and corresponding drawings. Apparently, the described embodiments are only some of the embodiments of the present application, rather than all the embodiments. Based on the embodiments in this application, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts belong to the scope of protection of this application.
[0023] First of all, it needs to be explained that a multi-robot collaborative task assignment method described in this application is stored in the central robot, and the central robot has at least built-in hardware devices such as processors, memory, and communication equipment, which can be the technology in this application. The solution provides ...