
Exoskeleton robot and controller system thereof
An exoskeleton robot and control system technology, applied in the direction of program control manipulator, manipulator, manufacturing tools, etc., can solve the problem that the battery can only be used for 40 minutes
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2020-01-17
Smart Images
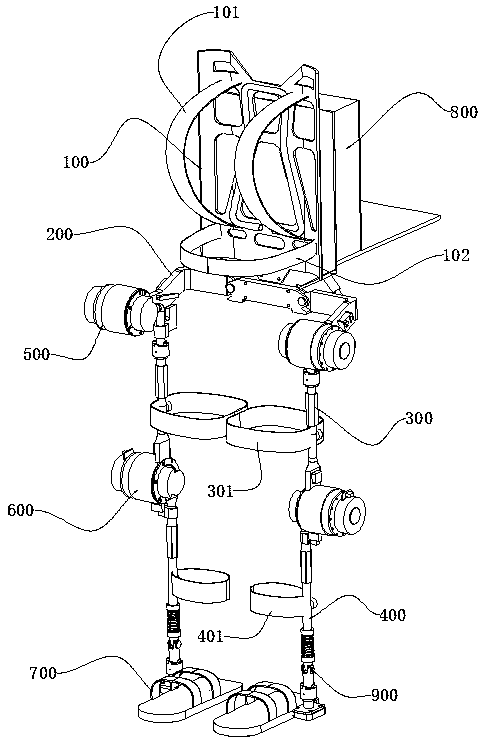
Figure 1 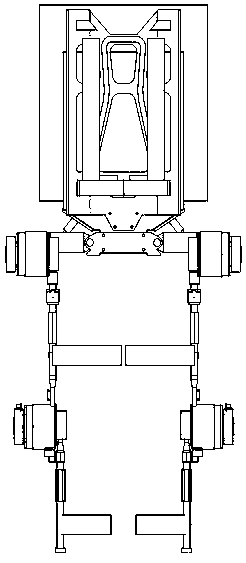
Figure 2 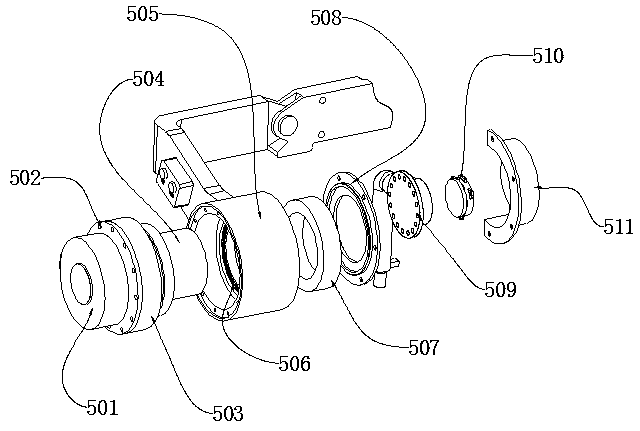
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of human auxiliary equipment, in particular to an exoskeleton robot and a control system thereof. Background technique
[0002] Exoskeleton robot technology is a comprehensive technology that integrates sensing, control, information, fusion, and mobile computing to provide operators with a wearable mechanical mechanism. This article briefly introduces the development status and trends of robotics in the world of exoskeletons in the military field. It refers to the robot that is set outside the human body, also known as "wearable robot".
[0003] The human exoskeleton power-assisted robot originated from the conception and development of the Hardman power-assisted robot in the United States in 1966. It is still in the research and development stage today. The energy supply device and the control system and force transmission device are highly in line with the requirements of human body agility and accuracy. All of th...
Examples
Embodiment Construction
[0254] The technical solution of the present invention will be further described in detail below in conjunction with specific examples, but the protection scope of the present invention is not limited to the following description.
[0255] Such as figure 1 , 2 Shown, a kind of exoskeleton robot, this robot comprises back frame 100, waist ring 200, left / right thigh assembly 300, left / right calf assembly 400, left / right shoe portion 700;
[0256] The back frame 100 is connected with the waist ring 200 and located above it;
[0257] The left / right thigh assembly 300 is connected to the left and right sides of the waist ring 200 through a hip joint assembly 500;
[0258] The left / right thigh assembly 300 and the left / right calf assembly 400 are respectively connected by a knee joint assembly 600;
[0259] The left / right shoe 700 is connected to the left / right calf assembly 400 through an ankle joint assembly 900;
[0260] The hip joint assembly 500 provides three degrees of fr...