
Grouping consistency unmanned aerial vehicle formation control method considering time-varying formation
A control method and technology for UAVs, applied in the field of UAVs, can solve problems such as inability to maintain control in formation
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-04-13
Smart Images
Figure 1 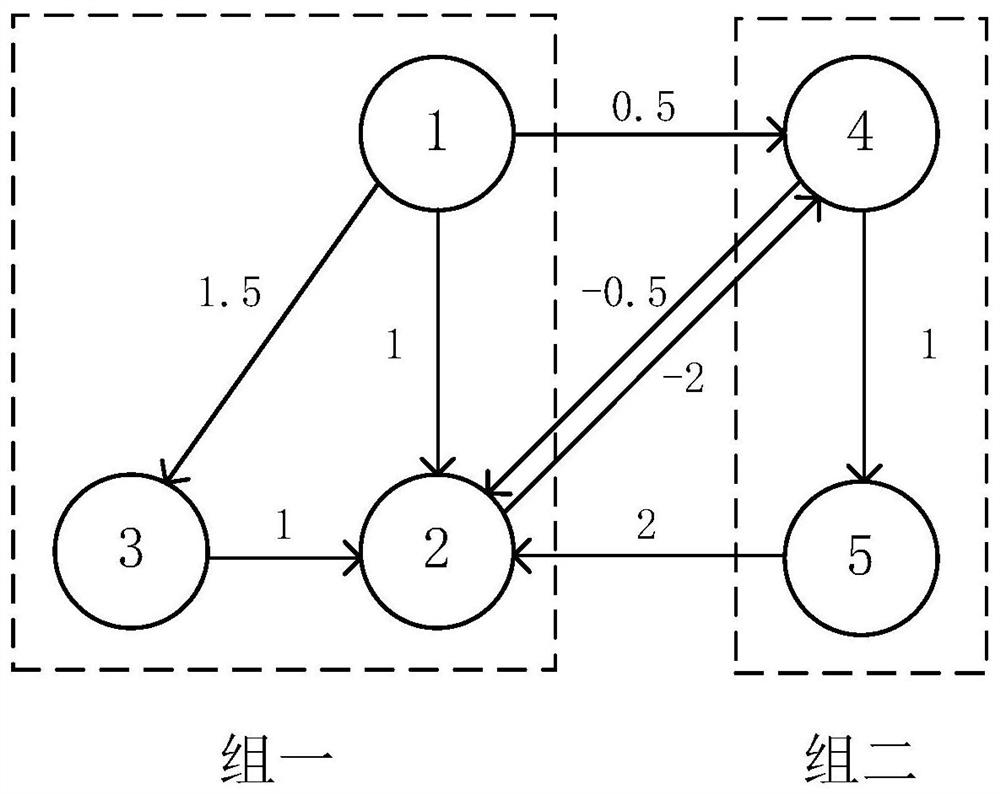
Figure 2 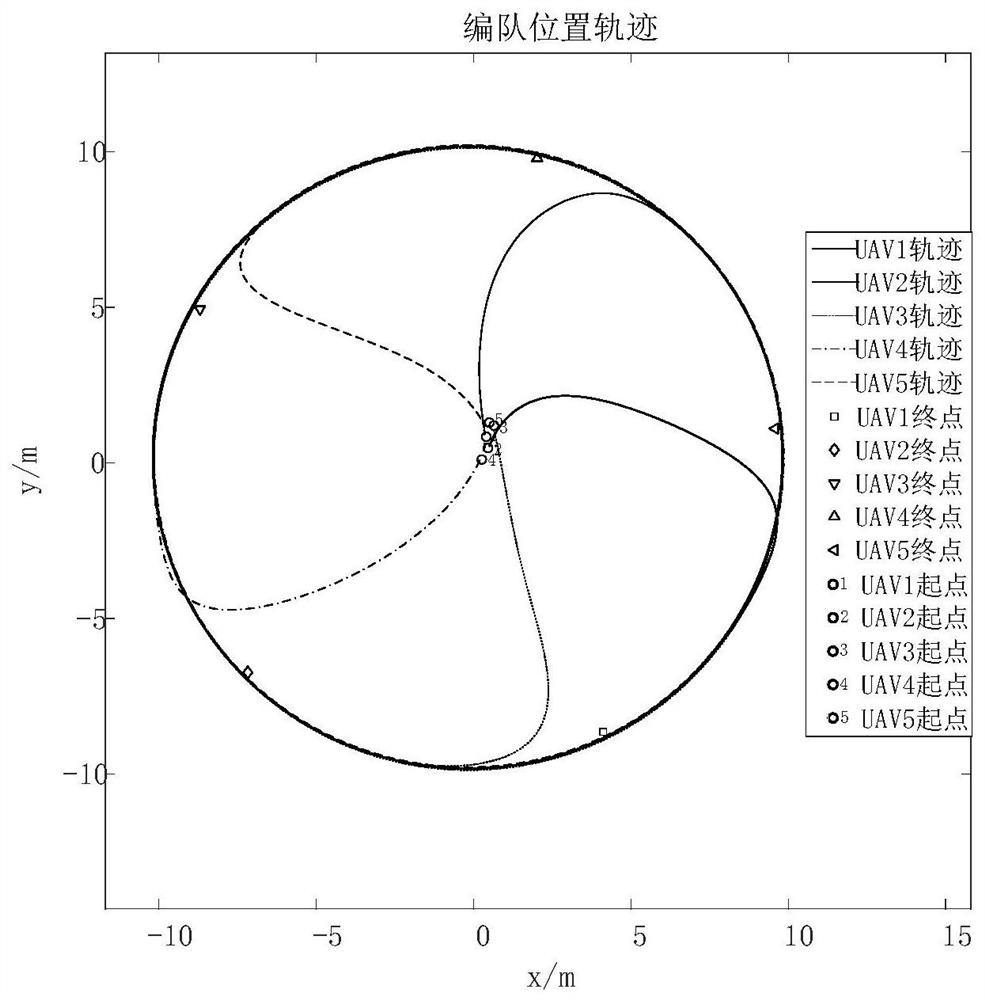
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of unmanned aerial vehicles, and in particular relates to a formation control method of unmanned aerial vehicles. Background technique
[0002] The formation control of multi-UAV systems has attracted the attention of many researchers because of its broad application prospects in military and civilian fields. The control effects of formation control based on multi-UAV system research at home and abroad mainly include: formation generation, formation maintenance, formation switching, formation obstacle avoidance, and adaptive control. To achieve the above control effects, traditional control methods mainly include: behavior-based control methods, leader-follower methods, and methods based on virtual structures. But with the development of consistency theory, formation control based on consistency theory has also achieved fruitful results. And from a theoretical point of view, the traditional formation contr...
Examples
specific Embodiment
[0131] Based on attached figure 2 The topological structure is simulated and verified. There are 5 drones participating in the simulation, which are divided into two groups: the first group is three, numbered 1, 2, 3; the second group is two, numbered 4, 5. The corresponding adjacency matrix is as follows:
[0132]
[0133] The Laplacian matrix is:
[0134]
[0135] The time-varying formation is attached Figure 5 And attached Figure 6 are the position and velocity trajectories of the time-varying formation function during formation flight simulation, respectively.
[0136] The controller parameter is K=[k 1 ,k 2 ] = [0.8156, 1.4127].
[0137] The initial state of the UAV formation is:
[0138]
[0139] combined with figure 2 The topology shown above and the initial state settings above, the simulation results are shown in the attached image 3 , attached Figure 4 And attached Figure 7 shown.
[0140] From attached image 3 And attached Figure...