
Polynomial Method of Unscented Kalman Filter Based on Higher Order Moment Matching
A technology of unscented Kalman and high-order moments, which is applied in impedance networks, digital technology networks, electrical components, etc., can solve problems such as black box packaging, large system errors, and limited precision.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2016-11-30
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
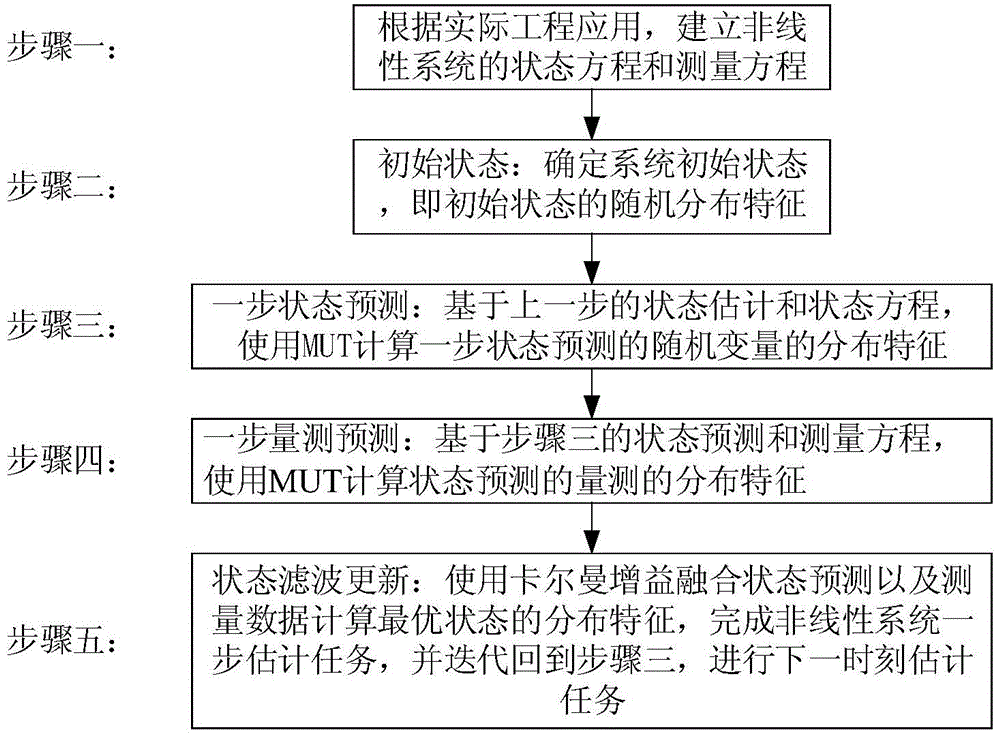
Figure 1 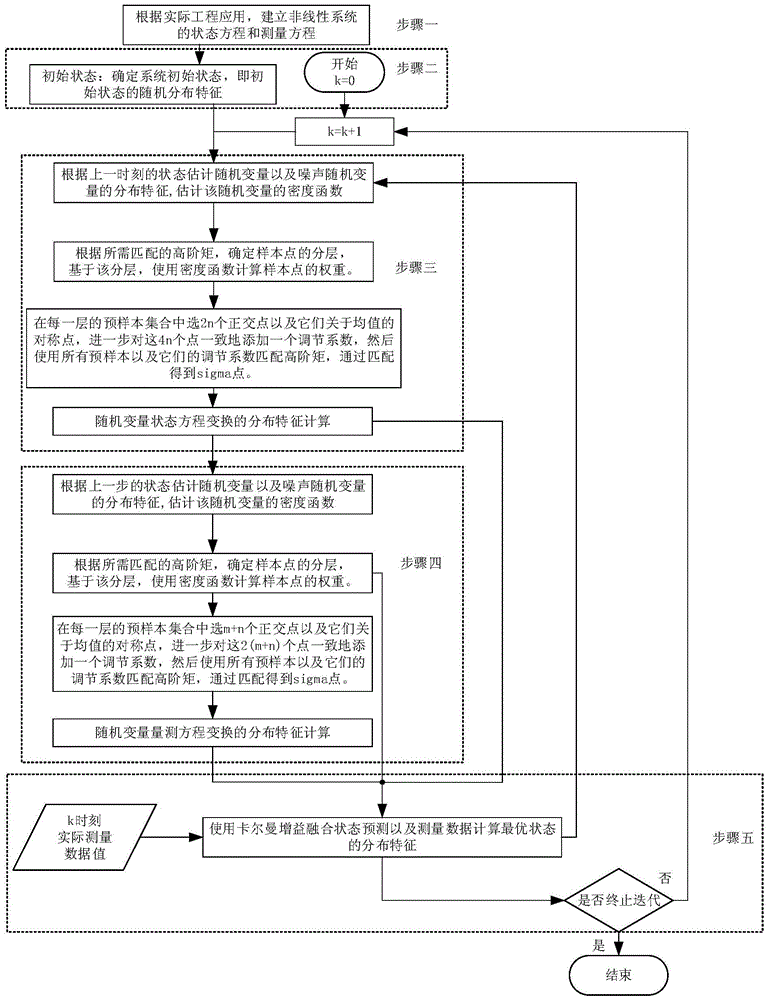
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical fields of information fusion such as nonlinear filtering, digital signal processing, and target positioning and tracking, and relates to a polynomial method of an unscented Kalman filter based on high-order moment matching. Background technique
[0002] At present, in the fields of aircraft navigation, target tracking and industrial control. Almost all real-world systems are nonlinear. For example: in the process of target positioning and tracking, when the radar is used to observe the air target, the radar can obtain the azimuth angle of the air target relative to itself, but this observation contains noise, and the azimuth observation of the radar in the observation equation is the target position parameter to be estimated Nonlinear functions cannot directly use the linear filtering method to obtain the motion state of the target. It is essentially a nonlinear filtering problem, which is a common problem in the...
Examples
Embodiment Construction
[0064] The preferred embodiments of the present invention will be described in detail below with reference to the accompanying drawings.
[0065] figure 1 It is a schematic flow chart of the method of the present invention, figure 2 It is a schematic diagram of the concrete steps of the method of the present invention, as shown in the figure, the concrete steps of the method are as follows:
[0066] Step 1: According to the problem of azimuth-only target tracking, the state equation and observation equation describing the target tracking system are established as follows:
[0067] x k 0.9 0 0 1 x k - 1 + w k - ...