
A Semantic Map Construction Method Based on Cloud Robot Hybrid Cloud Architecture
A semantic map and robot technology, applied in the field of cloud-based robot semantic map construction, can solve problems such as large recognition delay, inability to recognize unfamiliar objects, and long request response time
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2019-09-17
Smart Images
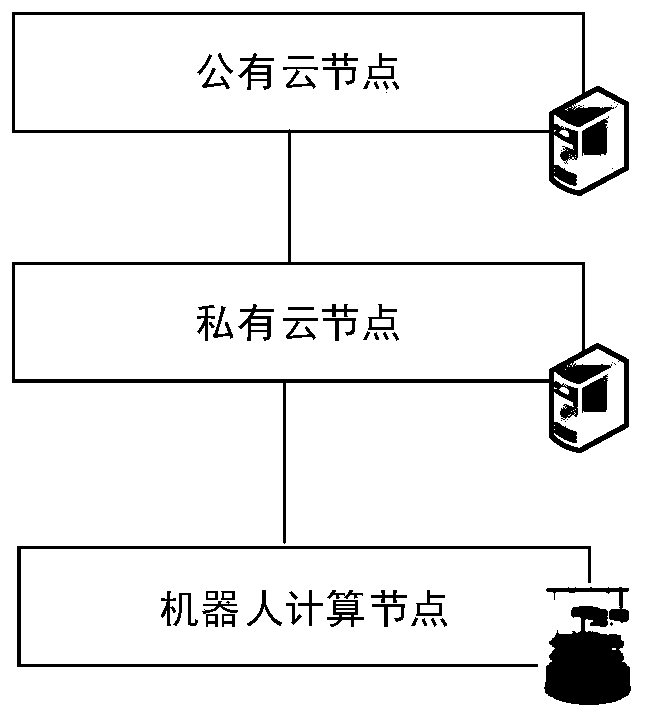
Figure 1 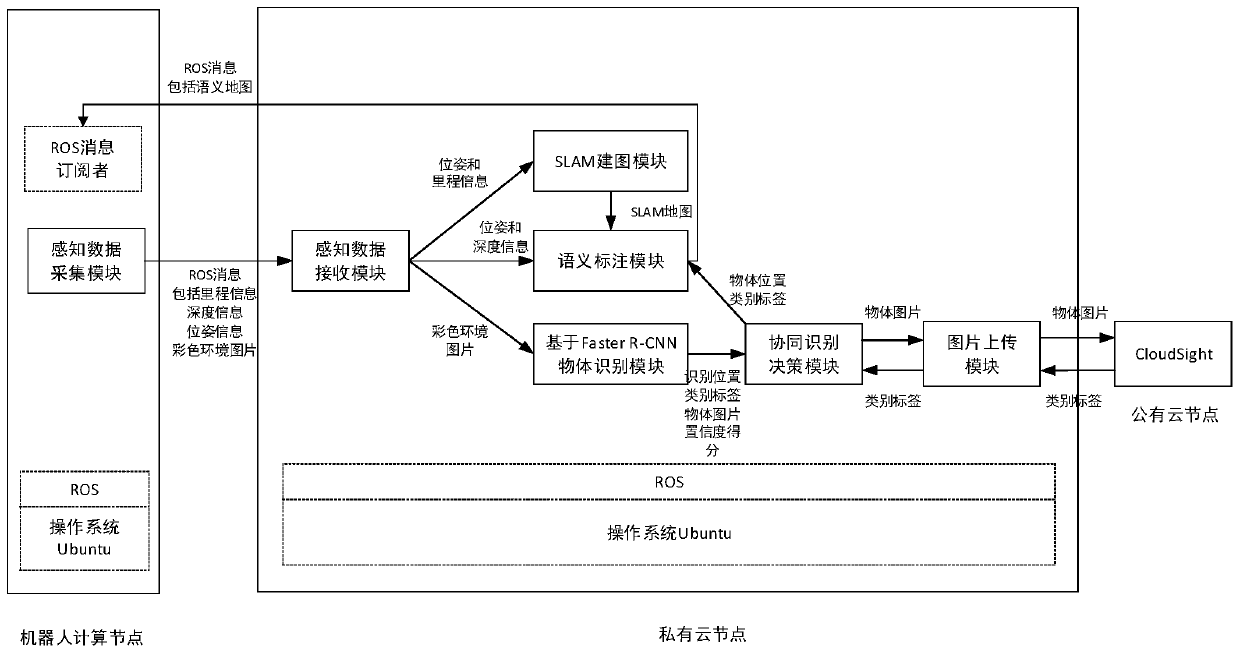
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of robot distributed computing, in particular to a method for building a cloud-based robot semantic map by using cloud computing as backup support and building a hybrid cloud architecture. Background technique
[0002] The perception data sources of robots may include multiple dimensions such as vision, force, touch, infrared, ultrasound, and lidar. Robot semantic map construction means that robots recognize and understand the environment based on these perception data, and the core focus is on how to perceive The data is extracted from the rough and the essence, the false and the true are removed, and then analyzed and synthesized to extract high-level semantic information (such as object names and locations) that can be used by the robot for autonomous decision-making. The specific performance is to add labels of objects in the environment on the geometric map. The acquisition of semantic information can b...
Examples
Embodiment Construction
[0090] figure 1 It is the robot hybrid cloud environment constructed in the first step of the present invention, which is composed of robot computing nodes, private cloud nodes and public cloud nodes. Robot computing nodes are robot hardware devices that can run software programs (such as drones, unmanned vehicles, humanoid robots, etc.), private cloud nodes are resource-controllable computing devices with good computing capabilities, and can run computing-intensive or knowledge-based Intensive robotic applications. Public cloud nodes are computing devices with abundant storage resources and the ability to provide external services. Robot computing nodes and private cloud nodes are interconnected through network devices, and private clouds access public clouds through the Internet.
[0091] figure 2 It is a software deployment diagram on the robot computing node and the private cloud node of the present invention. The robot computing node is a robot hardware device that ...