
A Less Conservative Trajectory Tracking Control Method for Permanent Magnet Spherical Motor
A spherical motor and trajectory tracking technology, which is applied in the direction of adaptive control, general control system, control/regulation system, etc., can solve the problems of bloated structure, larger controller size, limitations, etc., and achieve less conservatism and good robustness performance, good anti-disturbance ability
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2020-06-12
Smart Images
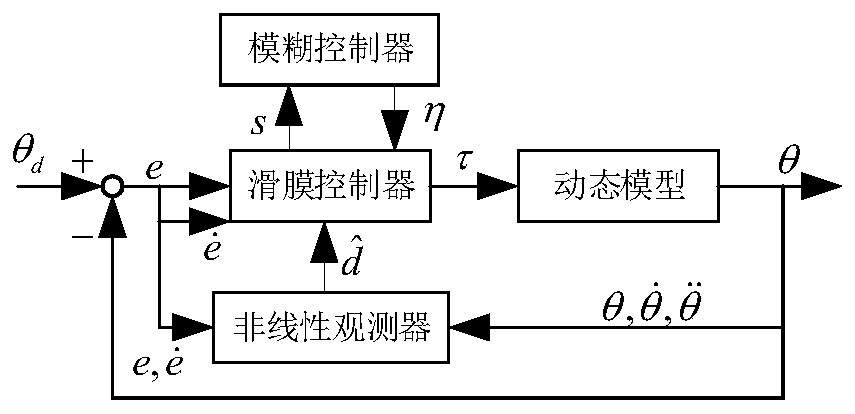
Figure 1 
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of trajectory tracking control of permanent magnet spherical motors, and relates to a less conservative trajectory tracking control method of permanent magnet spherical motors. Background technique
[0002] The permanent magnet spherical motor is a typical multivariable, strongly coupled, nonlinear system, and the problems involved in its control are very complicated, due to the inaccurate measurement and modeling, coupled with the influence of load, friction changes and external disturbances , it is actually impossible to obtain an accurate and complete dynamic model of the spherical motor. With the deepening of permanent magnet spherical motor technology research and the expansion of application fields, conventional permanent magnet spherical motor trajectory tracking control strategies and algorithms, such as PD control and calculated torque method control, can no longer meet the control requirements of these field...
Examples
Embodiment Construction
[0038] figure 1 Shown is the block diagram of the permanent magnet spherical motor fuzzy sliding mode control system based on nonlinear disturbance observer, including nonlinear observer, sliding mode controller, and three fuzzy controllers. The observed value of the nonlinear observer is used as the input of the sliding mode controller, and the output gains of the three fuzzy controllers are respectively used to replace the switching control gains of the three axes in the sliding mode control.
[0039] The dynamic model of permanent magnet spherical motor is:
[0040]
[0041] In the formula, θ=[αβγ]T represents the generalized displacement, M(θ) is the inertia matrix, is the matrix of centrifugal force and Coriolis force, d is the compound disturbance such as uncertainty, friction, external disturbance, load disturbance, etc., τ is the control torque matrix of the rotor in three axes.
[0042] M(θ), The expression is as follows:
[0043]
[0044]
[0045] Desi...