
Robot hand-eye system calibration method, device and equipment and storage medium
A system calibration, robot hand technology, applied in manipulators, program-controlled manipulators, manufacturing tools, etc., can solve problems such as large errors and complicated conversion processes
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2019-10-22
Smart Images
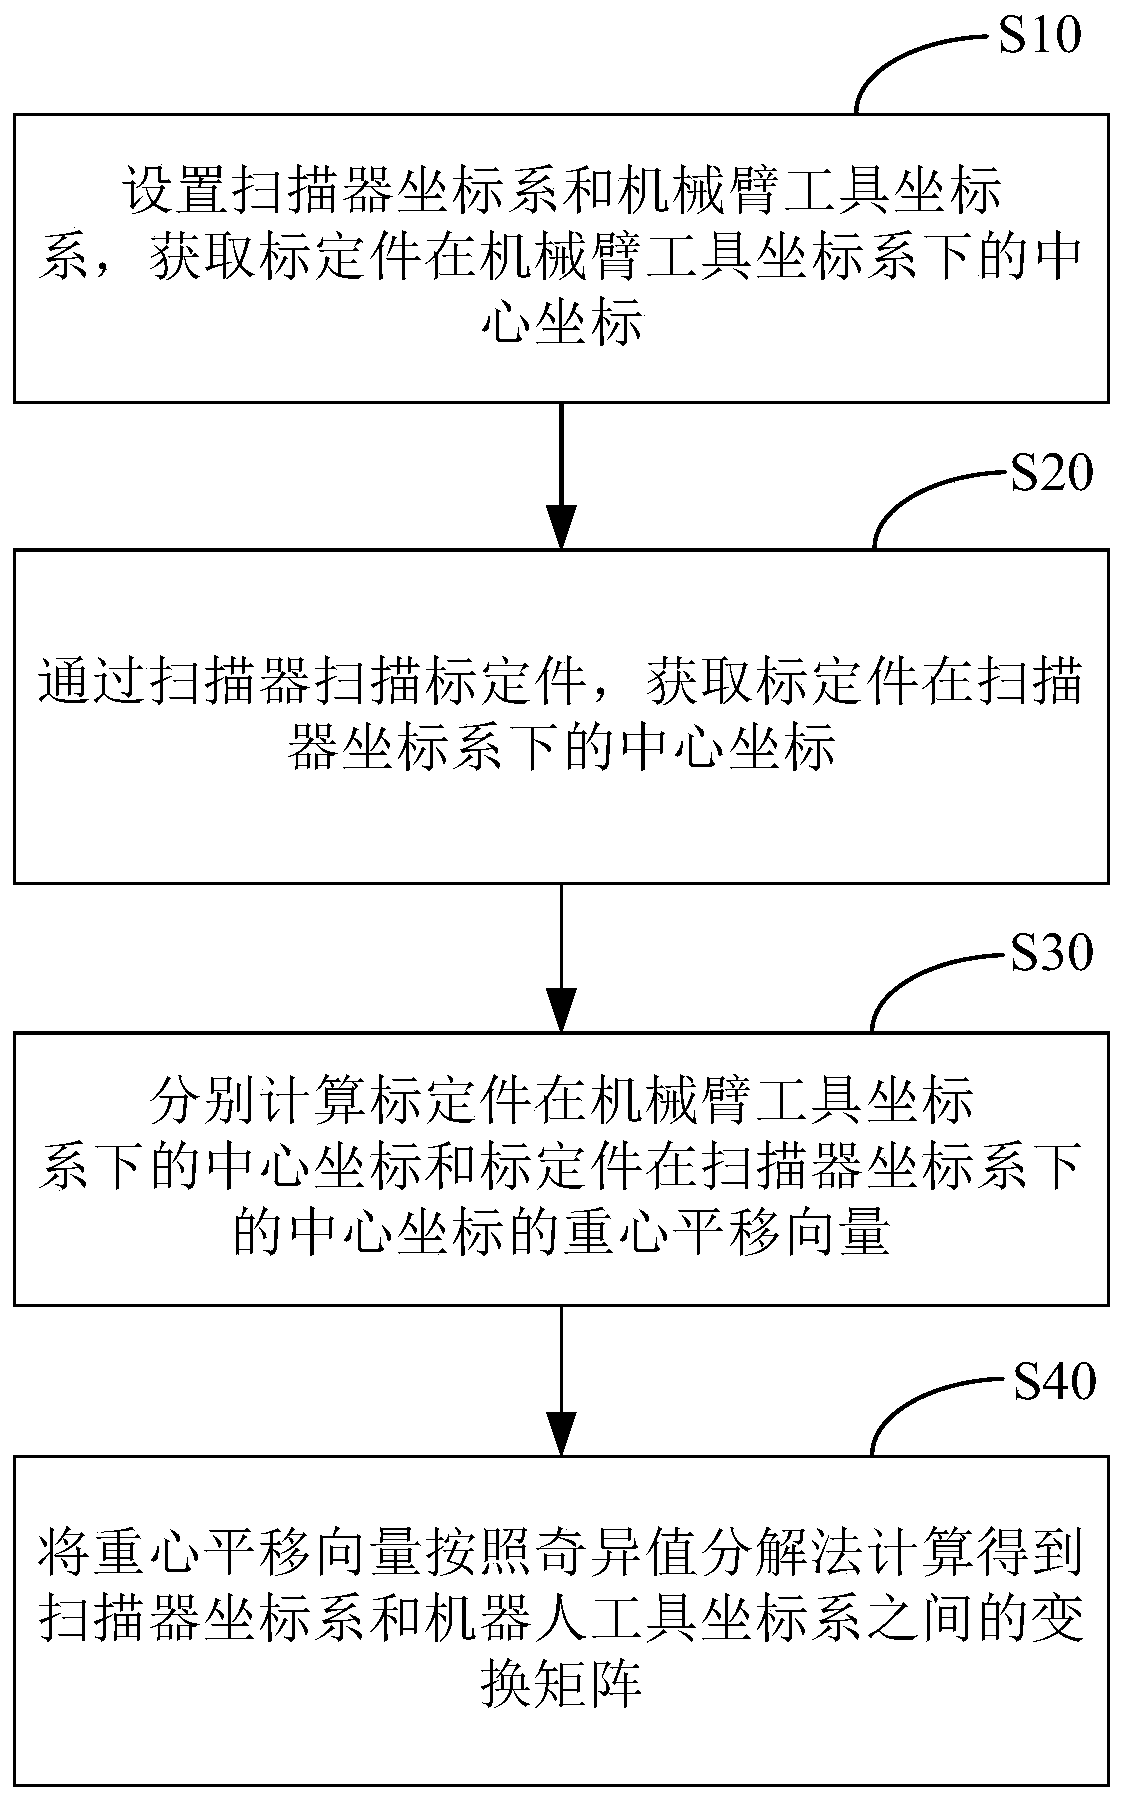
Figure 1 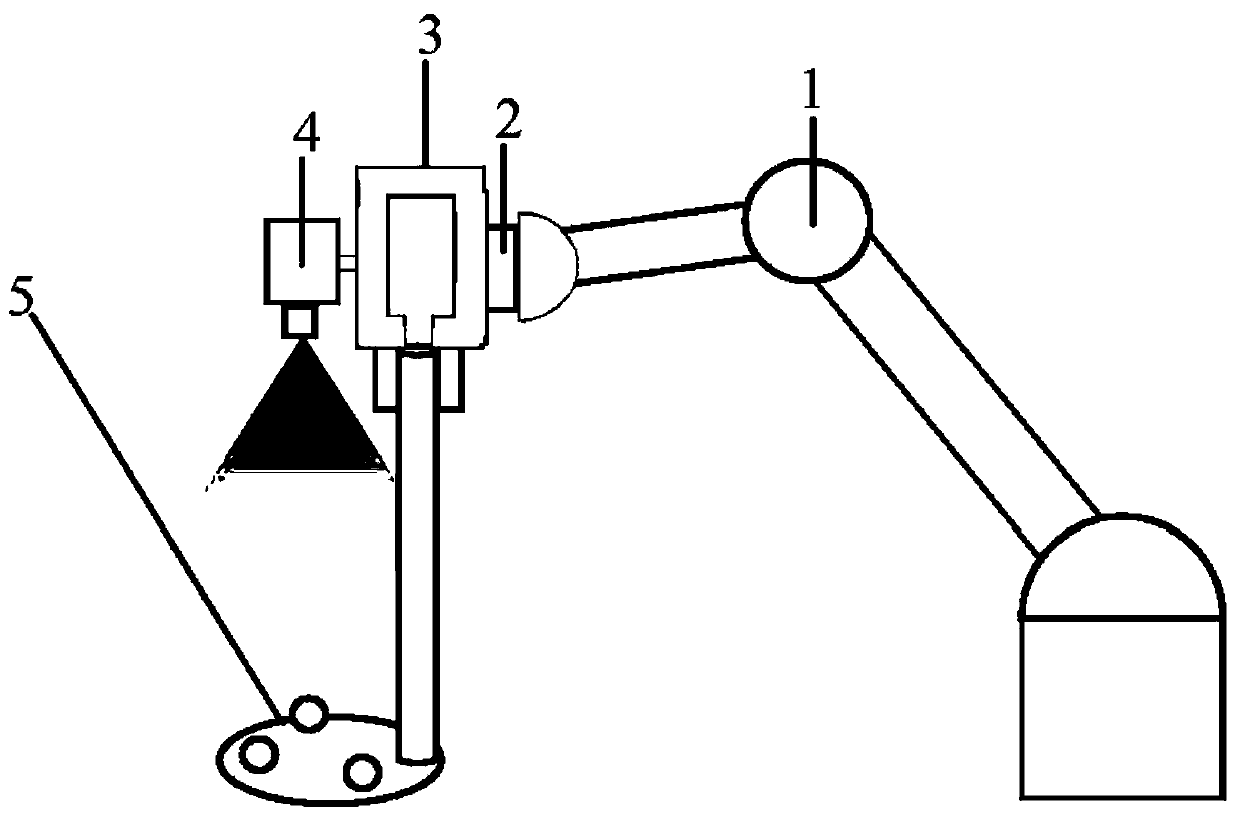
Figure 2 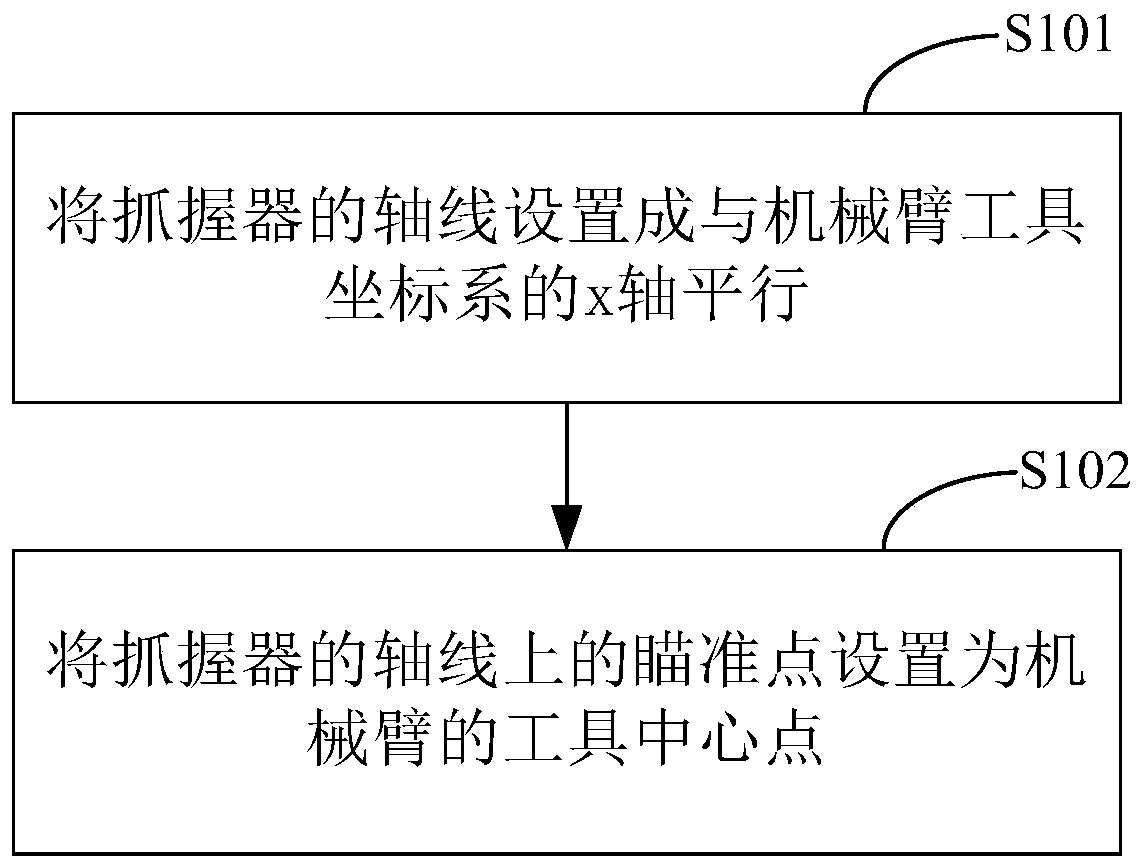
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of robot vision guidance, in particular to a robot hand-eye system calibration method, device, equipment and storage medium. Background technique
[0002] The robot hand-eye system mainly includes mechanical grippers and visual equipment. In the robot vision guidance system, there are two models that are often used: Eye-to-Hand and Eye-in-Hand. Among them, the vision device is installed on the robotic arm and directly connected to the robot body is called Eye-in-Hand (robot hand-eye system). The pose of the target object collected by the vision device is in the coordinate system of the vision device, and it needs to be converted to the tool coordinate system of the manipulator before it can be used for the motion control of the robot. The process of calculating the transformation matrix between the visual equipment coordinate system and the manipulator tool coordinate system is the calibration of the robot...
Examples
Embodiment approach
[0043] As an implementation manner, step S30 includes:
[0044] The coordinate vectors of the center of the three spheres in the tool coordinate system of the manipulator and the center coordinate vectors of the three spheres in the scanner coordinate system Calculate the arithmetic mean value separately to obtain the center-of-gravity coordinate vectors of the three spheres in the robot arm tool coordinate system and the center-of-gravity coordinate vectors of the three spheres in the scanner coordinate system
[0045] Calculate the coordinate vector of the center of the sphere according to the following formula The center of gravity translation vector of
[0046]
[0047] Calculate the coordinate vector of the center of the sphere according to the following formula The center of gravity translation vector of
[0048]
[0049] Step S40. Calculate the translation vector of the center of gravity according to the singular value decomposition method to obtai...