
Vision measuring method for spaced round geometrical parameters
A stereoscopic vision measurement and space technology, applied in the field of measurement, can solve the problems of not realizing circle radius measurement, etc., and achieve the effect of reducing measurement error, improving the degree of automation, and broadening the scope of application
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2005-01-19
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
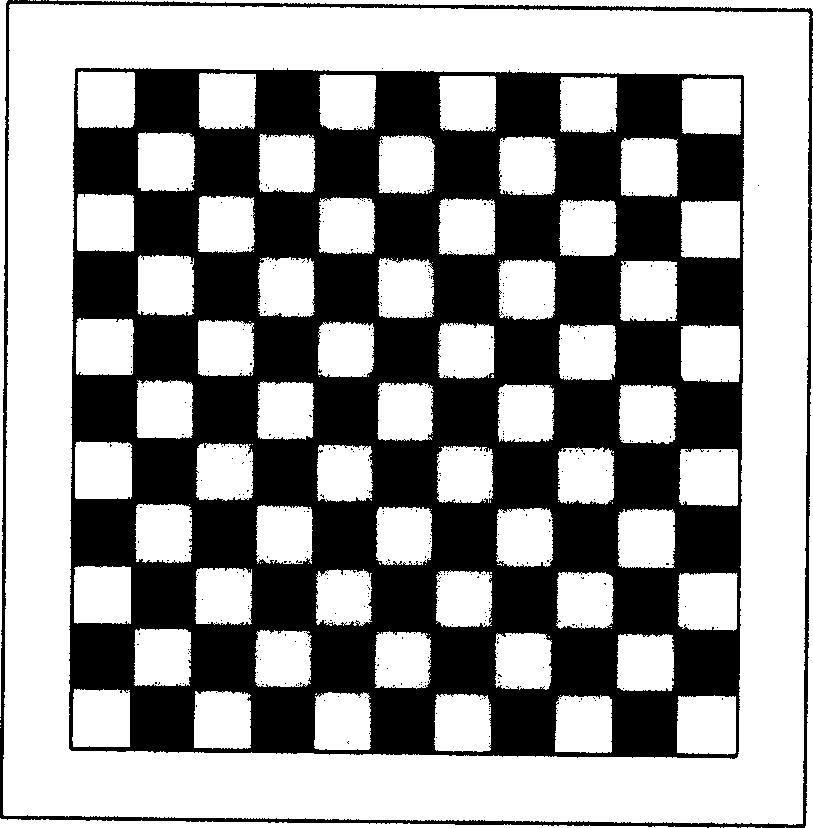
Figure 1 
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of measurement and relates to the improvement of a non-contact measurement method for geometric parameters of a space circle. Background technique
[0002] A circle is the basic geometric shape of an object, such as various workpieces, positioning holes on parts, etc. The three-dimensional space position of the geometric center of these round holes and the accuracy of the radius of the circle have a great influence on the successful installation of parts and the overall positioning of the object. Significance. The geometric parameters of the general round hole space can be measured by a three-coordinate measuring machine. The accuracy of the three-coordinate measuring machine can meet the accuracy requirements of the circle in most occasions. It cannot meet the needs of the installation site, especially the measurement of large round holes. Visual inspection technology is the most promising new technology ...
Examples
Embodiment
[0069] According to the steps described above, use two Mintong 368P CCD cameras and a 25mm Japan Seiko lens to form a binocular stereo vision sensor, and measure a circular hole with a diameter of D = 45.50mm. first use figure 1 The shown planar calibration target calibrates the CCD camera and the structured light vision sensor, and the distance between adjacent feature points in the planar target is 9±0.005mm. The obtained calibration parameters are:
[0070] Internal parameters of the left camera: A l = 4215.176 0 253.506 0 4203.932 383.968 0 0 1 ...