
Patents
Literature
1306results about "Steering controls" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Automotive user interface
PendingUS20250033476A1Input/output for user-computer interactionTactile signalling systemsTouch SensesDisplay device
A user interface for a vehicle includes a base display, a vibrotactile haptic actuator coupled to the base display, and a force sensor coupled to the base display. The user interface also includes an outer layer coupled to the base display. The outer layer is configured to generate surface friction haptic feedback.

Owner:STRATTEC SECURITY CORP
Methods and apparatus to control stowable steering wheels
PendingUS20250026396A1Registering/indicating working of vehiclesSteering controlsSteering wheelSteering column
Methods and apparatus to control stowable steering wheels are disclosed herein. An example apparatus disclosed herein includes a steering column assembly including a sensor, a first portion, and a second portion moveable relative to the first portion, machine readable instructions, and programmable circuitry to at least one of instantiate or execute the machine readable instructions to move the first portion relative to the second portion, determine based on an output of the sensor that the first portion has encountered an obstruction, and after determining the first portion has encountered the obstruction, stop a movement the first portion.

Owner:FORD GLOBAL TECH LLC
Manual lane biasing mode for adas
A method comprises: activating a full lane centering control mode in an advanced driver assistance system (ADAS) of a vehicle, wherein in the full lane centering control mode the ADAS keeps the vehicle centered on a trajectory of a lane regardless of surroundings of the vehicle and applies a first torque level against steering input that a driver applies using a steering wheel; detecting, in the full lane centering control mode, a driver input corresponding to a departure from the trajectory; and in response to the driver input, instead activating a manual lane biasing mode in which the ADAS applies a second torque level against the steering input, the second torque level lower than the first torque level, the manual lane biasing mode allowing the driver to steer away from the trajectory.

Owner:ATIEVA INC(US)
Assisted steering apparatus and associated systems and methods
The assisted steering unit includes a motor drive unit and a ring assembly constructed and arranged to couple to and rotate a steering wheel. The assisted steering unit may include a ring assembly where the ring assembly includes a housing, a ring gear disposed within the housing, an anti-rotation pin operatively engaged with the housing. The assisted steering unit may also include a motor drive unit (MDU) including a motor and a drive gear rotatably engaged with the motor. The ring assembly and motor drive unit are constructed and arranged to be releasably engaged to each other.

Owner:AG LEADER TECHNOLOGY INC
Systems and methods for handwheel actuator bind and / or steering column detection using torque detection
A method for handwheel actuator bind and / or steering column detection includes receiving, in response to a signal indicating a change in position of power steering column, a handwheel torque signal from a sensor associated with a handwheel of a vehicle. The method also includes determining whether a torque value associated with the handwheel torque signal is greater than a threshold. The method also includes, in response to a determination that the torque value associated with the handwheel torque signal is greater than the threshold, initiating at least one countermeasure.

Owner:STEERING SOLUTIONS IP HOLDING CORP
Collaborative steering in steer-by-wire systems for automated driving
A system for collaborative steering in steer-by-wire (SBW) vehicles includes sensors, a rack motor altering a position of the vehicle's steerable road wheels and an emulator altering a torque and position of a vehicle hand wheel. A collaborative steering system application (CSSA) obtains, static and dynamic information about the vehicle and the vehicle's environment, and generates a rack torque and / or angle command to the rack motor and an emulator torque and / or angle command to the emulator. The CSSA adjusts between ADAS and manual steering ratios and automatically transitions control between ADAS SBW control and manual control. The CSSA smooths transitions between ADAS SBW control and manual steering control and adjusts hand wheel stiffness by altering the emulator torque command, and causes the rack motor and emulator to operate according to a kinematic model while adapting road wheel response and vehicle operator steering feel based on scenarios and features currently enabled.

Owner:GM GLOBAL TECHNOLOGY OPERATIONS LLC
System and method for steering wheel actuator jake and / or steering column detection
A method for steering wheel actuator jamming and / or steering column detection includes receiving a steering wheel torque signal from a sensor associated with a steering wheel of a vehicle in response to a signal indicative of a change in position of a power steering column. The method also includes determining whether a torque value associated with the steering wheel torque signal is greater than a threshold. The method also includes initiating at least one countermeasure in response to determining that the torque value associated with the steering wheel torque signal is greater than the threshold.

Owner:STEERING SOLUTIONS IP HOLDING CORP
Device and system for retracting a control console of a vehicle in an emergency
A retractable console system for a vehicle, which may include: a control console; a linkage coupled to the control console; an actuator coupled to the linkage, the actuator may: lock the linkage and the control console coupled thereto in an operational position; and upon detection of an emergency, abruptly unlock and cause the linkage and the console coupled thereto to move from the operational position to a non-operational emergency position by releasing energy.

Owner:REE AUTOMOTIVE LTD
Automatic encoder calibration system for an agricultural vehicle
An agricultural vehicle includes a steering input device configured to steer the agricultural vehicle to perform a turn. The agricultural vehicle includes a steering control system configured to operate the steering input device. The steering control system includes processing circuitry. The processing circuitry is configured to receive a steering input indicating a curvature to be performed by the agricultural vehicle. The processing circuitry is configured to operate the steering input device using a primary curvature model of the agricultural vehicle and the steering input. The primary curvature model of the agricultural vehicle is configured to predict a steering condition of the steering input device to perform the steering input. The primary curvature model comprising a non-linear relationship between curvatures and steering conditions of the steering input device


Owner:BLUE LEAF I P INC
Real-time pinch detection and prevention for stow path power column
A method includes determining a current slew rate associated with a motor of the steering column, determining a speed slew rate associated with the motor, determining a current and speed slew rate threshold for the motor, and determining whether the current slew rate or the speed slew rate indicates a pinch event based on a comparison of the current slew rate, the speed slew rate, and the current and speed slew rate threshold. The method also includes, in response to a determination that at least one of the current slew rate and the speed slew rate indicates a pinch event, selectively instructing the motor to one of stop operation and reverse operation for a calibration period and, in response to the pinch event having a magnitude that is less than a pinch event threshold, selectively instructing the motor to continue operation.

Owner:STEERING SOLUTIONS IP HOLDING CORP
Multifunctional steer-by-wire hand feeling simulator
PendingCN119527417AImprove driving experienceImprove the sense of controlMechanical steeringSteering controlsAuto regulationSteering wheel
The invention relates to the technical field of vehicles, and discloses a multifunctional steer-by-wire hand feeling simulator which comprises a steering column and an upper steering mandrel assembly arranged in the steering column, and the upper steering mandrel assembly is connected with a steering wheel through a spline. A speed reducing mechanism, a telescopic adjusting mechanism, an angle adjusting mechanism and an angle limiting mechanism are arranged on the steering column, the speed reducing mechanism is used for providing damping for the steering wheel to guarantee the road feeling, the telescopic adjusting mechanism is used for automatically adjusting the telescopic steering wheel, and the angle adjusting mechanism is used for adjusting the angle of the steering wheel. The angle limiting mechanism is used for limiting the number of turns of the steering wheel. The invention has the following advantages and effects: the driving experience of a driver can be improved, the driving space is saved, and the comfort level is improved.

Owner:NAT SUN TECH CO LTD
Control device for vehicle and control method for vehicle
A control device for a vehicle configured to execute a first control for outputting a steering torque based on a predetermined first gain and a second control for outputting a steering torque based on a predetermined second gain different from the first gain, wherein during execution of the first control, a predicted start time, which is a predicted time until the start condition of the second control is satisfied, is calculated, and when the start predicted time satisfies the predetermined condition, a reduction control for bringing the output steering torque of the first control closer to 0 is executed before starting the second control.

Owner:TOYOTA JIDOSHA KK
Tilt structure for console and console
ActiveUS12312001B2Soil-shifting machines/dredgersSteering controlsClassical mechanicsMechanical engineering

Owner:STARTING IND CO LTD +1
Method for Assisting a User of a Vehicle During an Automated Transverse Guidance of the Vehicle on a Road Having a Branch Taking Into Account a Preceding Vehicle, Computing Device and Driver Assistance System
A method for assisting a user of a vehicle during an automated lateral guidance of the vehicle on a road having multiple lanes includes determining map-based position data that describes a present position of the vehicle in relation to the lanes on the basis of satellite-based position data and high-resolution map data, receiving sensor data from an environment sensor of the vehicle, detecting a preceding vehicle and a trajectory taken by the preceding vehicle based on the sensor data, determining probabilities of occupancy for the vehicle for at least some of the lanes based on the map-based position data and / or sensor data, recognizing a branch in the road based on the map-based position data and / or sensor data, and actuating an output device for outputting a takeover request before the branch is reached according to the probabilities of occupancy and the trajectory of the preceding vehicle.

Owner:BAYERISCHE MOTOREN WERKE AG
SYSTEMS AND METHOD FOR DETECTING A BLOCKAGE OF A HANDWHEEL ACTUATOR AND / OR A STEERING COLUMN BY MEANS OF TORQUE SENSORSHIP
A method for detecting a blockage of the handwheel actuator and / or steering column includes receiving a handwheel torque signal from a sensor linked to a vehicle handwheel in response to a signal indicating a change in the position of the power steering column. The method also includes determining whether a torque value associated with the handwheel torque signal exceeds a threshold value. Furthermore, the method includes initiating at least one countermeasure in response to a determination that the torque value associated with the handwheel torque signal exceeds the threshold value.

Owner:STEERING SOLUTIONS IP HOLDING CORP
Display control device, display device, and display control method
ActiveUS20250042254A1Passenger/driving compartment lightingsStatic indicating devicesSteering wheelDriver/operator
A control unit of a display control device, which controls an illumination unit capable of forming a display with light on a steering wheel in a vehicle comprising a driving assistance function, controls rendering by first display elements formed on a central portion of a steering wheel, a second display element formed on connecting portions and a third display element formed on an outer edge, when there is a change in a driving assistance level. The control unit causes a driver to have a first sense in which the driving responsibility of a vehicle is transitioning from the front part of the vehicle in front of the steering wheel to the steering wheel, and a second sense in which the driving responsibility of the vehicle is transitioning from the steering wheel to the front part of the vehicle, thereby presenting change information regarding the driving assistance level.

Owner:NIPPON SEIKI CO LTD
Vehicle control method, autonomous driving controller, steering controller, and vehicle
A vehicle control method includes the following steps. When a vehicle is in an autonomous driving mode, a first steering signal is received from a steering column of the vehicle. The first steering signal includes a first torque signal and / or a first steering angle signal. The holding information of a steering wheel of the vehicle is obtained, and the holding information indicates whether the steering wheel is held. Based on the first steering signal and the holding information, the vehicle is controlled to maintain or exit the autonomous driving mode.

Owner:BYD CO LTD
Vehicle intelligent adjusting method and device, vehicle, medium and program
ActiveCN119611245AIn line with the actual situationMeet actual driving needsSteering controlsElectric/fluid circuitDriver/operatorControl engineering
The invention relates to the technical field of vehicle control, in particular to a vehicle intelligent adjusting method and device, a vehicle, a medium and a program.The method comprises the steps that identity information of a driver is recognized; if it is determined that the driver drives the current vehicle for the first time according to the identity information, biological parameters and absolute driving height of the driver are collected, and the absolute driving height is the height from eyes of the driver to a vehicle body floor when the seat height is adjusted to the minimum; the target adjusting parameters of the multiple target mechanisms of the vehicle are determined according to the biological parameters and the absolute driving height, the multiple target mechanisms are adjusted according to the target adjusting parameters, and therefore the problems that the adjusting process of the vehicle is too tedious and poor in intelligence due to the fact that a driver needs to adjust the parameters of all the mechanisms one by one in the related technology are solved.

Owner:BEIJING AUTOMOBILE RES GENERAL INST
Method for carrying out a remote-controlled parking maneuver with a vehicle using a mobile terminal, and system
ActiveUS12379721B2Road vehicles traffic controlExternal condition input parametersDriver/operatorDisplay device
A method carries out a remote-controlled parking maneuver with a vehicle. A user with a mobile terminal is located outside the vehicle. The method plans a trajectory for the parking maneuver by way of a driver assistance system of the vehicle, maneuvers the vehicle along the planned trajectory by the driver assistance system, detects image data which describes the vehicle and the surroundings of the vehicle by a camera of the mobile terminal, and provides a display on a display device of the mobile terminal using the image data. The maneuvering process along the planned trajectory is carried out as long as an operating input which is carried out by the user on the mobile terminal and which describes a movement of the vehicle during the maneuvering process along the planned trajectory is detected by way of the mobile terminal, otherwise the maneuvering process is interrupted.

Owner:BAYERISCHE MOTOREN WERKE AG
Selector knob for a motor vehicle
PendingUS20250178435A1Controlling membersLimiting/preventing/returning movement of partsControl signalControl theory
A selector knob for a motor vehicle is disclosed. The selector knob comprises a support adapted to be attached to a component of the motor vehicle, a lever carried by the support in a rotatable manner about a straight axis among a plurality of distinct angular positions, transduction means configured to detect information about an actual angular position of the lever and to generate a control signal corresponding to the detected information, wherein the transduction means comprises a number of sensors equal to the number of said distinct angular positions, the sensors being angularly distributed about said axis and facing the lever according to respective radial directions with respect to said axis, wherein each of the sensors is configured to detect the presence of a device fixed to the lever when the lever reaches a said distinct angular position, thereby detecting the actual angular position of the lever.

Owner:FERRARI SPA
Method for setting a driver environment of a vehicle, computer-readable medium, system, and vehicle
The invention relates to a method for adjusting a driver environment of a vehicle, wherein the driver environment comprises components, the components being a driver's seat, a steering wheel, an exterior mirror, and / or a rearview mirror of the vehicle, the method comprising: detecting a driver in the driver's seat by the vehicle; acquiring an actual state of the driver environment and a current driver position with one or more cameras and / or one or more distance sensors of the vehicle; determining input parameters of a mathematical model depending on the detected driver in the driver's seat, wherein the input parameters include the acquired actual state of the driver environment, the acquired current driver position, and parameters for a best possible seating position of the driver as optimization variables of the mathematical model;Execution of the mathematical model with the determined input parameters by the vehicle to determine output parameters of the mathematical model, wherein the output parameters of the mathematical model include setting parameters for components of the driver environment with actuators and / or setting suggestions for components of the driver environment without actuators; If the output parameters of the mathematical model indicate that an improvement of the current state of the driver environment can be achieved: setting the actuators of the components of the driver environment depending on the setting parameters; and providing the setting suggestions to the driver of the vehicle for manual setting of the components of the driver environment without actuators.

Owner:BAYERISCHE MOTOREN WERKE AG
Rake bracket coupling assembly for steering column
A bushing for a steering column rake bracket assembly includes a flange portion. The bushing also includes a tubular segment having an inner wall defining a central hole and an outer wall. The outer wall of the tubular segment includes a first flat outer surface. The outer wall also includes a second flat outer surface. The outer wall further includes a first curved end surface connecting the first flat outer surface and the second flat outer surface. The outer wall yet further includes a second curved end surface connecting the first flat outer surface and the second flat outer surface.

Owner:STEERING SOLUTIONS IP HOLDING CORP
Control device, control method, and control program
A control device for a moving object that includes a plurality of opening and closing bodies includes: a control unit configured to perform movement control of the moving object based on a specific operation on an information terminal portable by a user of the moving object. In response to an opening and closing reservation of a specific opening and closing body other than an opening and closing body of a driver seat of the moving object among the plurality of opening and closing bodies being received during execution of the movement control, the control unit sets a target movement position of the movement control based on a positional relationship between the specific opening and closing body and the information terminal.

Owner:HONDA MOTOR CO LTD
Motor control device
A motor control device includes: a manual steering command value generation unit that generates a manual steering command value; an integrated angle command value calculation unit that calculates an integrated angle command value by adding the manual steering command value to an automatic steering command value provided in a driver assist mode; and a control unit that performs angle control on an electric motor for steering angle control based on the integrated angle command value. The manual steering command value generation unit generates the manual steering command value based on an equation of motion including road reaction force characteristic coefficients. The motor control device further includes a road reaction force characteristic changing unit that changes a value of at least one of the road reaction force characteristic coefficients included in the equation of motion, based on vehicle environment information that is information on an environment in which a vehicle travels.

Owner:JTEKT CORP
Road to Rail Hybrid Vehicles Using a Transition Span and Passive Junctions
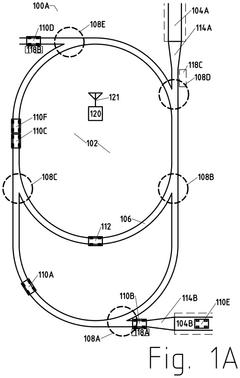
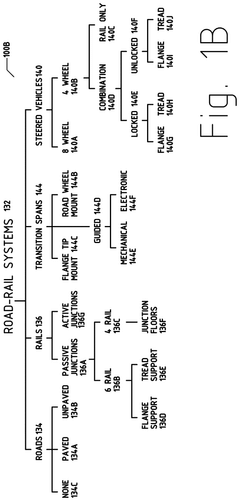
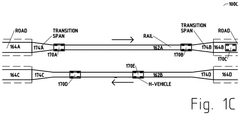
Described is a hybrid transportation system with hybrid vehicles (H-vehicles) that can travel on pavement (or off-road), then transition to railroad track travel, and then later transition back onto pavement without stopping or requiring an operator to exit the vehicle. At static rail junctions (with no moving switch parts) the H-vehicle selects its outgoing track. Turns at passive junctions are made by applying lateral force which may be applied using multiple methods including side roller diverters and steering. Separate road wheels and rail wheels may be employed on an H-vehicle, or a combination wheel can be used with concentric road and rail wheel components. Combination wheels may be locked together or unlocked with relative rotational angular velocities. Transition between road and rail travel is facilitated using transition spans which connect roads to rails. Improved rail-only vehicles (R-) vehicles and junctions are also described
Owner:WILLIAMS THOMAS HOLTZMAN
Autonomous driving control apparatus and method
Disclosed is an autonomous driving control apparatus which includes a steering device, a memory, and a controller. The autonomous driving control apparatus determines a user required torque received through the steering device, while controlling a host vehicle based on a required steering angle, determines a torque sensor value corresponding to the user required torque, using the steering device, adjusts an amount of control attenuation about a usage ratio between the required steering angle and the user required torque, based on the torque sensor value, and performs steering control of the host vehicle, based on at least one of the required steering angle, the user required torque, or the amount of control attenuation, or any combination thereof.

Owner:HYUNDAI MOTOR CO LTD +1
Working Machine
A working machine includes a steer column; and a seat that rotates a rotation path between a first position and a second position. The steer column is movable between a first position, where the steer column is operable from the seat when the seat is in the first seat position, and a second position, where there is clearance between the steer column and the seat rotation path. A seat latch arrangement retains the seat in said first seat position; and a latch control mechanism releases the seat latch arrangement. The latch control mechanism prevents release of the seat latch arrangement when the steer column is in the first position. The actuator assembly actuates the latch control mechanism, wherein the actuator assembly is operated by movement of the steer column between the first position and the second position.

Owner:J C BAMFORD EXCAVATORS LTD
Motor vehicle having reconfigurable cabin interior
A motor vehicle includes a passenger compartment, a steering wheel configured to be moveable between a use position and a stowed position, a floor, a seating rail system positioned on the floor and extending along a longitudinal direction of the motor vehicle, and a plurality of seating assemblies arranged in the passenger compartment in a first row, a second row, and a third row and configured to be actuated to a plurality of positions. Also included is a center console on a center console rail system extending longitudinally on the floor. A controller is configured to receive an input commanding a selected passenger compartment arrangement. The controller controls the actuators to position the seat assemblies, the center console and the steering wheel in the commanded passenger compartment arrangement.

Owner:FORD GLOBAL TECH LLC
Control device, control method, and control program
A control device for a moving object that includes an opening and closing body includes: a control unit configured to perform automated movement control for moving the moving object to a target movement position that is a parking position or a exit position. In response to an opening and closing reservation of the opening and closing body being performed, the control unit stops the moving object at an opening and closing position different from the target movement position after the automated movement control is started, performs opening and closing of the opening and closing body, and resumes movement of the moving object toward the target movement position after the opening and closing are completed.

Owner:HONDA MOTOR CO LTD
Method and detection unit for detecting the probability that a steering element of a vehicle is gripped by the driver's hands - Patents.com
A method (1000) is presented for detecting a probability K (140) that a steering element (120) of a vehicle (100) is being gripped by a hand (145) of a driver (150), the method (1000) comprising a step (1010) of reading a torque signal representative of a torque acting on a torque sensor coupled between the steering element (120) and a steering gear (125). The method (1000) further comprises a step (1010) of reading a torque signal representative of a torque acting on a torque sensor coupled between the steering element (120) and a steering gear (125). The method (1000) further comprises a step (1010) of reading a torque signal representative of a torque acting on a torque sensor coupled between the steering element (120) and a steering gear (125). The step (1010) ... reading a torque signal representative of a torque acting on a torque sensor coupled between the steering element (120) and a steering gear (125). The step (1010) comprises reading a torque signal representative of a torque acting on a torque sensor coupled between the steering element (120) and a steering gear (125). S The method includes identifying (1020) the probability K (140) that a steering element (120) of a vehicle (100) is being grasped by a hand (145) of a driver (150) if the probability K (155) exceeds the predetermined probability K (140).


Owner:KNORR BREMSE SYSTEME FUER NUTZFAHIZEUGE GMBH