

Patents
Literature
9037 results about "Control mode" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Multi-layer distributed micro-grid control system and method based on edge cloud collaborative lightweight reinforcement learning
PendingCN120073869AResource allocationSingle network parallel feeding arrangementsEdge nodeElectric network
The invention relates to the technical field of micro-grid control, in particular to a multi-layer distributed micro-grid control system and method based on edge cloud collaborative lightweight reinforcement learning. The method comprises the following steps: a cloud management unit trains a DQN model by using historical environment data, generates a lightweight DQN model through pruning and quantification, issues the lightweight DQN model to an edge node unit, and formulates day-level and weekly-level optimization scheduling strategies based on a function layering + layering cooperation strategy; the edge node unit monitors electrical quantity and environmental parameters in real time through a sensor, deploys a lightweight DQN model to monitor abnormal conditions and trigger local early warning and emergency strategies, and makes a fast decision by using the lightweight DQN model; the micro-grid subgroup units collect data of the edge node units. According to the invention, through close cooperation of the edge node layer, the micro-grid subgroup layer and the cloud management layer, a distributed cooperative control mode of edge node real-time decision, subgroup cooperative management and cloud global optimization is realized.

Owner:YANTAI DEV ZONE DELIAN SOFTWARE CO LTD
Temperature correction method and correction system for hot press
ActiveCN119590025AImprove reliabilityPrecise temperature controlLaminationLamination apparatusTemperature controlData pack
The invention discloses a temperature correction method and system for a hot press, and particularly relates to the technical field of hot press temperature control, and the method comprises the steps: obtaining and preprocessing multi-dimensional operation data, including a temperature time sequence, pressure setting and material attributes; constructing a coupling model based on the multilayer neural network, and predicting temperature distribution of different process stages; performing sensor drift compensation, analyzing temperature deviation characteristics, judging whether sensor drift or material thermal diffusion abnormity exists or not, and generating a local distortion mark; determining a compensation mode according to the distortion mark, and starting a local compensation mode or a global balance control mode if the distortion is recognized as over-limit distortion; and comparing with the output of the coupling model, verifying the temperature correction effect, and if the deviation is reduced and the distortion mark is converged, outputting a stable temperature correction result. The problems of temperature distortion and sensor drift are effectively solved, and the long-term precision and stability of the hot press under complex working conditions are improved.

Owner:WUXI HUASHENG HEAVY IND TECH CO LTD
Multi-robot collaborative scheduling method based on end-side collaboration
PendingCN119105503AEfficient collaborative workImprove collaboration efficiencyVehicle position/course/altitude controlPosition/direction controlDistributed intelligenceBottleneck
The invention discloses a multi-robot collaborative scheduling method based on end-side collaboration, and the method remarkably improves the collaborative efficiency and robustness of a system when the system processes complex tasks and deals with dynamic environment changes on the basis of a conventional industrial park multi-robot system through introducing an end-side cloud collaborative swarm intelligence algorithm. According to the invention, the bottleneck in a traditional centralized control mode is broken through, and the problems of reduced cooperation efficiency and out-of-control system caused by system scale enlargement and task complexity are avoided; efficient collaborative operation of the multi-robot system in a large-scale and multi-task scene is realized; besides, according to the method, through real-time task monitoring, dynamic scheduling optimization and global map updating, the flexibility and adaptability of the system in a complex dynamic environment are ensured, so that each robot can make a decision autonomously and quickly respond to task requirements, and finally optimal configuration of resources and accurate execution of tasks are achieved.

Owner:GUANGDONG MECHANICAL & ELECTRICAL COLLEGE
Inverter control method, device, computer equipment and storage medium
PendingUS20250158408A1Ac-dc conversionSingle network parallel feeding arrangementsVirtual synchronous generatorLoop control
The present invention provides an inverter control method, device, computer equipment and storage medium, belonging to the field of power electronics. The method comprises: determining a frequency control equation of the inverter under a grid-connected condition when the inverter is in a VSG control mode; determining a relationship between a virtual electromotive force of a virtual synchronous generator in a reactive state and an output voltage of the inverter; constructing a voltage-current double closed-loop control structure of the inverter under the VSG control mode, and determining a current reference value and a voltage reference value of the virtual synchronous generator under dq axes through the frequency control equation and the relationship; constructing a fuzzy control rule of a virtual damping coefficient and a virtual inertia according to the current reference value and the voltage reference value; and controlling the virtual damping coefficient and the virtual inertia through the fuzzy control rule, thereby improving the stability and performance of the inverter during the grid-connected process, reducing the harmonic disturbance of the power system, and helping to improve the adaptability and reliability of the entire photovoltaic power generation system.

Owner:INNER MONGOLIA UNIV OF TECH
Following structure network type control smooth switching method based on generalized operation short-circuit ratio index
PendingCN120185112ASingle network parallel feeding arrangementsPower oscillations reduction/preventionSystems analysisNew energy
The invention relates to a follow-up network type control smooth switching method based on a generalized operation short-circuit ratio index. The follow-up network type control smooth switching method comprises the following steps of 1, introducing a generalized operation short-circuit ratio (GOSCR) as a switching index, and proposing a GOSCR-based hysteresis control mode switching judgment index under different power grid strength and power output working conditions; step 2, establishing a unified new energy grid-connected control unit model: constructing a unified grid-connected control model in two modes of network following control and network construction control, systematically analyzing oscillation characteristics of a grid-connected unit in the two modes, and defining boundary conditions of mode switching; 3, proposing an LADRC-based undisturbed switching control strategy: observing and estimating system current disturbance parameters online by utilizing LESO, realizing real-time compensation of disturbance quantity, and reducing dynamic sudden change in the switching process; the method has the advantages that GOSCR switching indexes are introduced to comprehensively evaluate the strength, a unified grid-connected control model is established, and an undisturbed switching control strategy is provided.

Owner:XINYANG POWER SUPPLY OF HENAN ELECTRIC POWER CORP
Humanoid robot control system and method based on reinforcement learning
The invention relates to the field of robot control, and provides a humanoid robot control system and method based on reinforcement learning, and the humanoid robot control system comprises a first control subsystem and a second control subsystem. The first control subsystem comprises a strategy reasoning module, a state conversion module and a robot control module; the second control subsystem comprises a data acquisition module and a driving control module; the data acquisition module is used for finishing timestamp alignment and abnormal value filtering of sensor data and transmitting the data to the state conversion module; the state conversion module is used for fusing multi-source sensor data and constructing a time sequence state feature containing a real-time measurement value and historical time sequence information; the strategy reasoning module is used for generating a multi-joint angle target value of the robot according to the time sequence state characteristics provided by the state conversion module; and the robot control module is used for analyzing the multi-joint angle target value output by the strategy reasoning module, selecting a control mode and generating a control command comprising a parameter adjustment instruction.

Owner:GUANGDONG TIANTAI ROBOT CO LTD
Dynamic optimization control method and system for multi-component batching of paste making machine
The invention belongs to the technical field of industrial automation control, and particularly relates to a dynamic optimization control method and system for multi-component batching of a paste making machine, and the method comprises the steps: generating a characteristic waveform spectrum corresponding to a residue molecular structure; dynamically generating electric lubricating medium parameters containing the electroosmotic liquid concentration and the release rate; triggering a low-frequency vibration module of the material layer to generate vibration waves, and enabling the solution and the vibration waves to form a molecular-level synergistic stripping effect; calculating a nanoparticle dispersity index, and generating an inverse gradient mixing instruction when the index exceeds a threshold value; activating a hot vortex ring in a spiral flow guide convex pattern area and establishing a directional heat energy migration channel; and verifying the dynamic equilibrium state of the temperature of the paste core area and the viscoelasticity of the target formula, and triggering a phase lock control signal to terminate the parameter adjustment chain when the energy consumption rate reaches a stable interval. According to the invention, the problems that the transition period during formula switching is prolonged and the phase differences among the execution mechanisms are difficult to match in real time due to a traditional staged regulation and control mode are solved.

Owner:JIANGSU XINGZONGHENG BIOTECHNOLOGY CO LTD
Fine energy consumption analysis and optimization management method and system based on rail transit
ActiveCN119578834AData processing applicationsCharacter and pattern recognitionControl engineeringLocal environment
The invention relates to a refined energy consumption analysis and optimization management method and system based on rail transit, and solves the problems that a regulation and control mode based on overall energy consumption data cannot accurately adapt to actual energy consumption requirements of all regions, and energy waste or reduction of local environment comfort is easily caused. The method comprises the following steps: according to the optimal illumination brightness and air conditioner output combination of each micro-area obtained by a multi-target particle swarm optimization algorithm, sending a control instruction to related equipment of each micro-area; acquiring energy consumption data of each micro-area, and analyzing and determining whether the energy consumption of the micro-area is higher than an expected range or not according to a preset energy consumption reference value and an expected fluctuation range of each micro-area; if not, maintaining the original setting; and if yes, adjusting the weight of the energy consumption objective function in the multi-objective particle swarm optimization algorithm according to a preset weight adjustment strategy. The method has the advantages that the overall energy consumption of the rail transit is effectively reduced, and fine management is achieved.

Owner:NINGBO YIKATONG TECHNOLOGY CO LTD
Deep peak regulation control system for thermal power generating unit
The invention discloses a thermal power generating unit deep peak regulation control system, and relates to the technical field of thermal power generating unit deep peak regulation, the thermal power generating unit deep peak regulation control system comprises a deep peak regulation control center, and the deep peak regulation control center is in communication connection with a data acquisition module, a load prediction module, a working condition monitoring module, a distributed control module and a safety monitoring early warning module. By introducing a distributed control architecture and bat algorithm optimization, each subsystem of the thermal power generating unit is divided into a plurality of local control units, independent and cooperative control is realized, the flexibility and the response speed of the thermal power generating unit in the deep peak regulation process are remarkably improved, and the reliability of the thermal power generating unit is improved. Distributed control ensures that each subsystem can quickly adjust operation parameters according to actual load requirements, and the global optimization capability of the bat algorithm further improves the self-adaptability and decision-making efficiency of the system in a complex working condition, so that the problem of response lag in a traditional centralized control mode is effectively solved.

Owner:JIANGXI DATANG INT XINYU NO 2 POWER GENERATION CO LTD
Blood pump
The invention concerns a control device for controlling a blood flow of an intravascular blood pump for percutaneous insertion into a patient's blood vessel, the blood pump comprising a pump unit with a drive unit for driving the pump unit and configured to convey blood from a blood flow inlet towards a blood flow outlet, wherein the control device is configured to operate the blood pump in a selectable zero-flow control mode, wherein a blood flow command signal is selected, and the control device comprises a first controller and a second controller, wherein the first controller is configured to control the blood flow by adjusting a speed command signal for the drive unit, and the second controller is configured to control a drive speed of the drive unit.

Owner:ABIOMED EUROPE GMBH
Medical robotic system with coupled control modes
A system with coupled control modes includes a first manipulator, a second manipulator, an input device for commanding movement of the first manipulator or the second manipulator, and one or more controllers. The one or more controllers are configured to detect movement of the input device; when movement of the first manipulator is responsive to movement of the input device: determine a commanded movement for the first manipulator from the detected movement of the input device and command the second manipulator to move in response, at least in part, to the commanded movement of the first manipulator; and when movement of the second manipulator is responsive to the movement of the input device: determine a commanded movement for the second manipulator from the detected movement of the input device and command the first manipulator to move in response, at least in part, to the commanded movement of the second manipulator.

Owner:INTUITIVE SURGICAL OPERATIONS INC
Adaptive adjustment method and system for network following and network construction control modes of inverter
ActiveCN120320405AData processing applicationsSingle network parallel feeding arrangementsPower system stability controlControl engineering
The invention belongs to the technical field of power system stability control, and particularly discloses an inverter network following and constructing control mode adaptive adjustment method and system, and the method comprises the steps: obtaining a current power grid state parameter in real time; a multi-scale fusion depth evaluation model is constructed and trained; inputting the current power grid state parameters into the trained multi-scale fusion depth evaluation model, and outputting current power grid state evaluation indexes; according to the current power grid state evaluation index, adaptively selecting a control mode, wherein the control mode comprises a network following type inverter dominant mode, a network constructing type inverter dominant mode and a transition mode; and according to the selected control mode, verifying whether the power grid state satisfies a constraint condition, and if not, carrying out global optimization on the control parameters of the inverter. According to the invention, the dynamic stability and disturbance response capability of the power system can be improved through the adaptive adjustment of the network-following type and network-constructing type control modes of the inverter.

Owner:NORTH CHINA ELECTRIC POWER UNIV
Temperature energy-saving control method and system for communication machine room
The invention relates to the technical field of communication machine room energy conservation, in particular to a temperature energy-saving control method and system for a communication machine room, and the method comprises the steps: obtaining multi-region temperature and humidity and equipment load data in the machine room, inputting a pre-training model to obtain a cabinet heat dissipation risk level, judging an environment state through combination with an incidence matrix, entering an operation mode if a requirement is satisfied, and entering a control mode if a requirement is satisfied. If not, a local temperature control adjusting mechanism is triggered; the method comprises the following steps: calculating a refrigeration efficiency ratio according to the air volume of ventilation equipment, air conditioner power consumption, real-time electricity price and the like, generating a candidate scheme set by using a dynamic weight multi-target optimization algorithm in combination with factors such as equipment life, and selecting a target scheme through virtual verification; and according to air conditioner waste heat and cabinet heat dissipation and storage heat, a heat energy distribution strategy is dynamically generated by using a deep Q network reinforcement learning algorithm. Therefore, the problems that in the prior art, energy is wasted, cost is high, heat dissipation requirements of all areas are difficult to accurately adapt, the service life and stability of equipment are affected, and fault risks are increased are solved.

Owner:HEILONGJIANG LONGTING INFORMATION TECH CO LTD
Dual-mode dynamic active wake flow control method and system for wind power plant and medium
The invention discloses a wind power plant dual-mode dynamic active wake flow control method and system and a medium, and the method comprises the steps: taking the maximum power output, power balance and fatigue load stabilization as optimization targets for solving and obtaining an optimal control instruction if a current control mode is a power efficiency improvement mode; otherwise, taking the maximum power output as an optimization target to solve and obtain an optimal control instruction; issuing the optimal control instruction to the virtual wind power plant, and delaying to obtain a delayed control instruction; if the mode is a power efficiency increasing mode, directly issuing to a real wind power plant; and if the mode is a power tracking mode, solving a final optimal control instruction by taking power reference tracking, control reference tracking and fatigue load stabilization as optimization targets, and issuing the final optimal control instruction to the real wind power plant. The method aims at weakening the influence of the wake effect in the wind power plant through dynamic active wake control, improving the generating capacity, maintaining the fatigue load balance and bringing higher economic benefits to operators.

Owner:HUNAN UNIV
Intelligent pressure management system, method and terminal for geological storage of carbon dioxide
The invention provides an intelligent pressure management system, method and terminal for geological sequestration of carbon dioxide, and the system comprises the steps: collecting the pressure data of the interior and peripheral key positions of each geological reservoir in real time through a pressure monitoring subsystem, and then carrying out the data preprocessing and feature extraction through a data processing and analysis subsystem; and predicting the reservoir pressure change trend in a specific time period in the future. If the predicted reservoir pressure change trend pressure is too high, high-risk related information is transmitted to the intelligent regulation and control subsystem, and the intelligent regulation and control subsystem regulates and controls the reservoir pressure by regulating the flow of a carbon dioxide injection well and a production well or starting a pressure release device according to a preset strategy and dynamically regulates a regulation and control mode according to pressure data. Meanwhile, the communication and monitoring subsystem transmits system operation data to a remote monitoring terminal in real time, so that real-time monitoring is facilitated. Real-time, accurate and automatic regulation and control of the pressure of the geological reservoir are achieved, the stability and safety of the geological reservoir in the carbon dioxide injection process are guaranteed, the geological storage effect of the carbon dioxide is improved, and various negative effects caused by too high pressure are avoided.

Owner:SHANGHAI ADVANCED RES INST CHINESE ACADEMY OF SCI
Remote monitoring and control method based on intelligent engineering management system
The invention discloses a remote monitoring and control method based on an intelligent engineering management system, and relates to the technical field of the Internet of Things, and the method comprises the steps: carrying out the data collection of an engineering object, carrying out the weight adjustment of multi-modal data through a dynamic weight distribution algorithm, and carrying out the fusion, and obtaining an engineering state feature vector; constructing a prediction model by using historical data and the engineering state feature vector, and calculating and analyzing dynamic characteristics through phase-space reconstruction and a Lyapunov exponent to obtain a chaos prediction model; performing anomaly prediction on the engineering object, calculating a Lyapunov index and identifying an abnormal mode to obtain an anomaly prediction result; performing fault-tolerant analysis on the abnormal prediction result and the network state by using an AI model, predicting a fault risk, switching a control mode, and obtaining a fault-tolerant operation state; and analyzing the monitoring data by using an AI algorithm to generate a control instruction. According to the method, the data acquisition quality is adaptively optimized, so that the reliability under complex working conditions is improved.

Owner:正民建设集团有限公司
Slurry pump control method and related equipment
The invention discloses a slurry pump control method and related equipment, and relates to the technical field of seawater desalination, and the method comprises the following steps: obtaining sensor data of a slurry pump; data analysis is conducted on the sensor data, and the working condition abnormal index of the slurry pump is determined; determining a target control instruction corresponding to the working condition abnormal index based on the working condition abnormal index and a preset threshold interval; and based on the target control instruction, the slurry pump is controlled to execute corresponding target regulation and control operation. Real-time monitoring and intelligent judgment of the operation state of the slurry pump are achieved, early warning can be triggered at the initial stage of equipment abnormity, the operation parameters can be adjusted in a self-adaptive mode, the response delay problem of a traditional single control mode is effectively avoided, and the operation reliability and safety of the equipment are improved.

Owner:BEIJING SHOUGANG AUTOMATION INFORMATION TECH
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
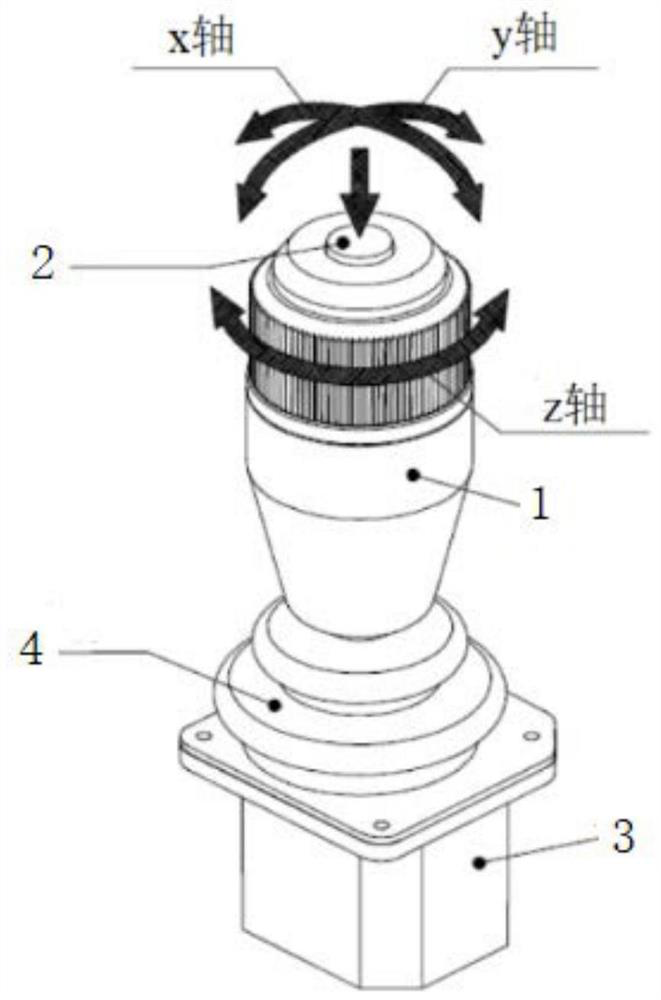
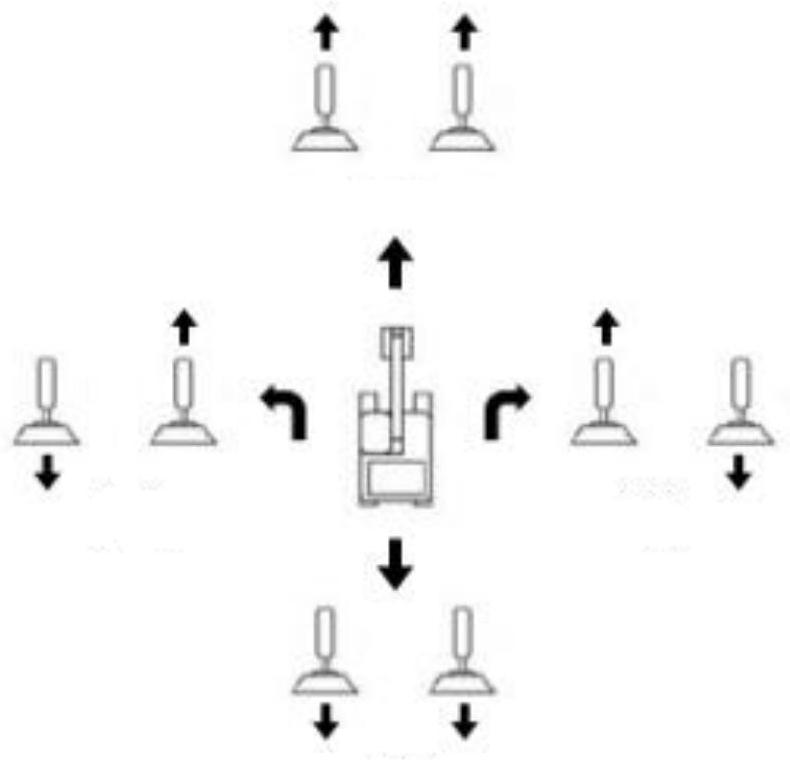
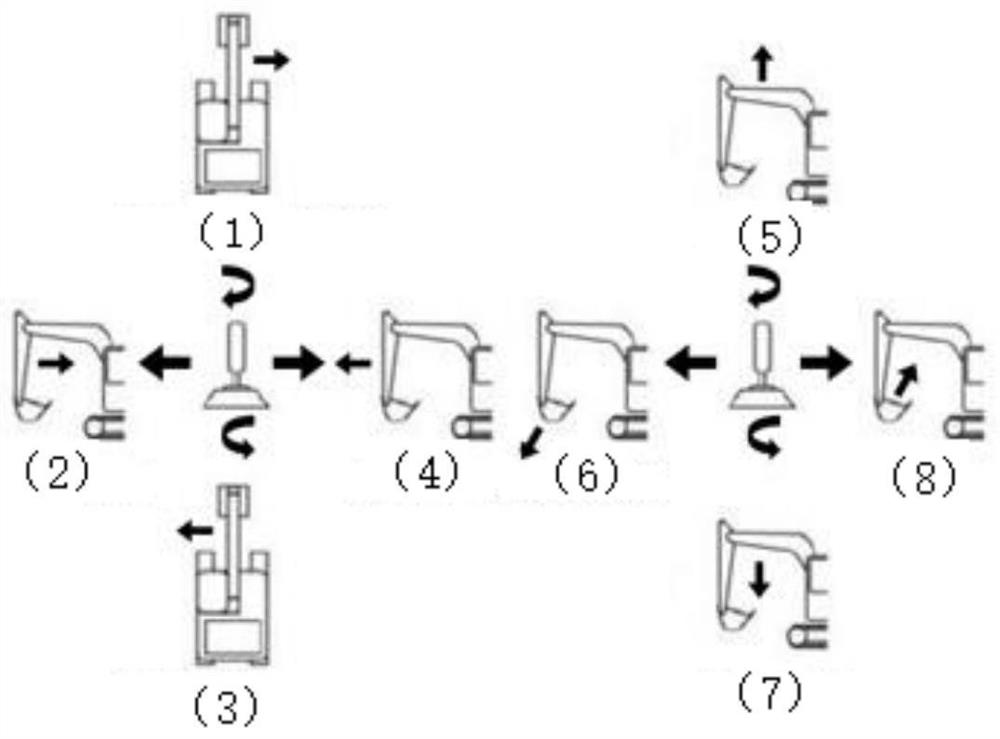
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Adaptive cycle engine control rule optimization method based on DLH-IHBA
The invention provides a DLH-IHBA-based adaptive cycle engine control law optimization method, and belongs to the technical field of aero-engine control, and the method comprises the steps: building an adaptive cycle engine model, and determining an optimization variable based on the adaptive cycle engine model; according to the control mode of each self-adaptive cycle engine, constraint conditions and an objective function based on optimization variables are determined, the control modes comprise a steady state control mode and a transition state control mode, and the steady state control mode comprises a minimum fuel consumption control mode, a maximum thrust control mode and a minimum turbine front temperature control mode; and based on the objective function and the constraint condition, optimizing the control rule of each control mode by adopting a multi-dimensional learning prey strategy fused with a badger optimization algorithm to obtain an optimal control variable, and adopting Tent mapping as initial particle swarm position mapping. According to the scheme, the convergence speed of engine control rule optimization is increased, and the optimization effect and the engine performance are improved.

Owner:TAIHANG LABORATORY
Grid-connected inverter control mode switching method, device, equipment, medium and product
PendingCN120675200AAc-dc conversionSingle network parallel feeding arrangementsIntegratorGrid connected inverter
The embodiment of the invention provides a grid-connected inverter control mode switching method and device, equipment, a medium and a product, and is applied to the technical field of electrical control. The method comprises the following steps: acquiring a control mode switching signal of the grid-connected inverter, and determining a switching direction of a control mode based on the switching signal; when the switching direction indicates that the current control mode is switched from the GFL mode to the GFM mode, setting an initial value of an integrator of a power synchronization loop of the GFM mode as a phase angle value of a phase-locked loop corresponding to the GFL mode; switching the control mode from the GFL mode to the GFM mode based on a first preset path and a step-by-step switching mode; when the switching direction indicates that the current control mode is switched from the GFM mode to the GFL mode, acquiring a power steady-state output value of the GFM mode, and setting a power reference value of the GFL mode as the power steady-state output value; and switching the control mode from the GFM mode to the GFL mode based on the second preset path and the step-by-step switching mode. The technical effect of improving the control mode switching fluency is achieved.

Owner:MEIZHOU POWER SUPPLY BUREAU OF GUANGDONG POWER GRID CORP
Vehicle network interaction cooperative regulation and control method
The invention relates to the technical field of electric vehicle and power grid interaction control, in particular to a vehicle network interaction cooperative regulation and control method, which realizes cloud platform strategy generation and issuing, edge terminal deployment and data acquisition, local control mode switching and power redistribution by building a hierarchical control framework. Constructing a space-time fusion prediction model to perform dynamic load prediction and strategy generation; designing a multi-modal data interaction mechanism, and standardizing data transmission; an abnormal state co-processing mechanism is established to quickly deal with faults; and user side interaction optimization is implemented, and the user is guided to charge reasonably. Experiments show that according to the scheme, the load rate of the transformer in the area can be reduced by 18%, the charging cost of a user is reduced by 23%, the fault response time is shortened to 1 / 5 of that of a traditional scheme, the power grid safety and the charging efficiency are effectively balanced, the charging experience of the user is improved, and coordinated development of the electric vehicle and the power grid is promoted.


Owner:KAIFENG POWER SUPPLY COMPANY STATE GRID HENAN ELECTRIC POWER
Intelligent drive-by-wire chassis comprehensive control platform
InactiveCN119142367AGeneralized intelligence capabilitiesMulti-intelligence capabilitiesControl devicesTime informationAutomatic control
The invention discloses an intelligent drive-by-wire chassis comprehensive control platform, and belongs to the technical field of automobile chassis control. An intelligent drive-by-wire chassis comprehensive control platform is divided into an information interaction processing layer, a state information estimation layer, a control mode management layer, a comprehensive motion control layer and a drive-by-wire execution layer, so that the drive-by-wire chassis can generalize more intelligent capabilities; comprising environment information cognitive ability, chassis fault pre-judgment ability, real-time information interaction ability, vehicle stability autonomous control ability, minimum risk state automatic control ability and failure state autonomous adjustment ability. The chassis health state assessment is used for acquiring the execution capability and the comprehensive health degree of chassis components in real time, carrying out fault definition and division based on the information, and ensuring the implementation or degradation control of an expected target through failure reconstruction control; the minimum risk control module serves as a minimum intelligent driving backup, and it is guaranteed that after an intelligent driving system fails or exceeds a design operation domain, the vehicle can achieve basic decision making, planning and control for guaranteeing safety of the vehicle.

Owner:XIAMEN KING LONG UNITED AUTOMOTIVE IND CO LTD
PFM-PWM dual-mode control method for high-voltage direct-current power supply with wide output voltage range
PendingCN120566917AEfficient power electronics conversionDc-dc conversionMode controlHigh-voltage direct current
The invention relates to a PFC-PWM (Pulse Width Modulation) dual-mode control method for a high-voltage direct-current power supply with a wide output voltage range. The output current of the high-voltage direct-current power supply is detected in real time, the critical threshold value of the load impedance is mapped into the hysteresis interval of the output current, the theoretical boundary of mode switching is obtained, and the control mode is dynamically adjusted. In order to further guarantee smooth switching of the two control modes, hysteresis control logic is designed, and undisturbed smooth switching of the PFM mode and the PWM mode is achieved. Based on an energy equivalence principle and a frequency consistency constraint of a critical load SWL working point, a current threshold criterion and a parameter pre-synchronization strategy are constructed, seamless connection of a mode switching process in a frequency domain and an energy domain is ensured, a transient oscillation risk is remarkably reduced, and a guarantee is provided for continuous and stable output of a full-range load working condition.

Owner:SHENYANG SCI INSTR RES CENT CHINESE ACAD OF SCI
Automatic equipment control method for water treatment equipment
InactiveCN119511872ARealize dynamic adjustmentImprove water safetyProgramme controlComputer controlControl mannerWater quality
The invention relates to the technical field of water quality monitoring, and discloses an automatic equipment control method for water treatment equipment, which is characterized in that a water treatment process is modeled into a Markov decision process, and dynamic and optimal control on the water treatment equipment is realized. The model comprehensively considers a plurality of dimensions such as raw water quality, treatment water quality, equipment operation state and treatment flow, and defines comprehensive state space and action space. By designing a reward function, multiple indexes such as the water quality standard-reaching rate, the equipment operation efficiency and the energy consumption are evaluated, and a deep reinforcement learning algorithm is adopted to continuously optimize a control strategy so as to maximize accumulated rewards. According to the method, the defects of response lag, strategy stiffness, lack of global optimization capability and the like of a traditional control mode based on a threshold value and manual intervention are overcome, the method can be adaptive to complex and changeable water quality conditions and equipment operation states, the treatment efficiency is improved, the water quality safety is ensured, and the operation cost is reduced.

Owner:QINGDAO JUKONG AUTOMATION CO LTD
Multi-modal information fusion control system and method
The invention relates to the technical field of information fusion, in particular to a multi-modal information fusion control system and method, and the system comprises a target difference evaluation module, a modal replacement judgment module, a modal lag recognition module, a modal weight reconstruction module and a control instruction output module. According to the method, dynamic adjustment and optimization of the control system are achieved by comprehensively evaluating the difference of the execution parameters in the control period, tiny changes in task execution can be reflected in detail by calculating the path coordinate difference value, the category variation frequency and the offset variation amplitude, and then the control strategy is accurately adjusted; the adaptive capacity and decision precision of the system to the environment change are improved, the control mode more suitable for the current task environment can be switched to in time by evaluating the output error and the matching score between the modes, and the resource allocation is optimized and the response speed and the processing efficiency are improved by identifying the abnormal response mode and reallocating the mode weight.

Owner:HARBIN ENGINEERING UNIVERSITY SANYA NANHAI INNOVATION & DEVELOPMENT BASE
Curved surface mapping track optimization and multi-modal force control method for complex wall surface polishing
PendingCN120287291AProgramme-controlled manipulatorGrinding machine componentsAttitude controlControl engineering
The invention discloses a curved surface mapping track optimization and multi-modal force control method for complex wall surface polishing. The method can efficiently meet the polishing requirement of a complex curved surface. A polishing track is determined by introducing a projection technology, a path optimization model is constructed, and multi-node force fusion attitude control is combined, so that interpolation point calculation and attitude change and position planning matching are realized, and a robot polishing path including a polishing position, an attitude and adjustment parameters is effectively generated. According to the multi-mode force control method, a force control mode is dynamically adjusted by combining radial height state switching of state classification of convex and concave path sections; multi-node fusion attitude control is further introduced, the surface contact force of a sand disc is accurately tracked, the tail end attitude of the robot is dynamically adjusted to follow the curved surface characteristics, the problems of irregular curved surfaces, unstable force control and the like in the traditional grinding technology are solved, and the method can be widely applied to automatic efficient grinding operation in the fields of buildings, ships and the like; and efficient and high-precision grinding of the complex curved surface is achieved.

Owner:SOUTHEAST UNIV
Auxiliary material adding control system for throat lozenge production
The invention discloses a throat lozenge production auxiliary material adding control system, and belongs to the technical field of data modeling and analysis, and the throat lozenge production auxiliary material adding control system comprises a threshold matrix establishment module which is used for constructing a dynamic threshold matrix; the data acquisition module is used for acquiring current production data; the data analysis module is used for generating a mode selection signal according to a comparison result of the current production data and the dynamic threshold matrix; the mode selection module is used for activating a corresponding control mode based on the mode selection signal, and the control mode comprises a conventional mode, an adjustment mode and an exception handling mode; and the control execution module is used for executing a control instruction corresponding to the control mode and sending the verified control instruction to the auxiliary material adding execution mechanism. According to the method, intelligent association and control strategy optimization of multi-source heterogeneous data are realized through data modeling and iterative optimization of an algorithm level.

Owner:GUANGDONG JIABAO GRP CO LTD
Wearable exoskeleton man-machine cooperation real-time control method based on artificial intelligence
The invention discloses a wearable exoskeleton man-machine cooperation real-time control method based on artificial intelligence, and relates to the technical field of exoskeleton robots, and the method comprises the steps: recognizing an exoskeleton scene in power grid maintenance, analyzing the demand degree, and constructing a maintenance demand sequence; determining a collaborative analysis scene based on the maintenance demand sequence; performing quantitative analysis on the man-machine confrontation event in the collaborative analysis scene to obtain a collaborative deviation value and generate a collaborative analysis signal; constructing a data set according to signal extraction features, and predicting man-machine cooperative control behaviors by using a genetic algorithm; finally, the exoskeleton is controlled in real time according to prediction, the man-machine cooperation degree is judged, and the control mode is switched when necessary. The exoskeleton man-machine cooperation performance is improved, the cooperation problem can be found in time, the control strategy is optimized, and it is guaranteed that electric power overhaul work is conducted efficiently and safely.

Owner:STATE GRID SHANXI ELECTRIC POWER COMPANY TAIYUAN POWER SUPPLY COMPANY +4
Accurate ammonia spraying control method and system suitable for coke oven flue gas denitration
ActiveCN119281108Aincrease profitAccurately adjust the amount of ammonia sprayedGas treatmentDispersed particle separationPrediction algorithmsReal-time data
The invention discloses a precise ammonia spraying control method and system suitable for coke oven flue gas denitration, and the method comprises the steps: collecting historical data and real-time data of coke oven flue gas flow and NOx concentration, carrying out the modeling of the collected historical data of the flue gas flow and NOx concentration through a time series prediction algorithm, and carrying out the calculation of the model; the flue gas flow and the NOx emission value in a period of time in the future are predicted, the corresponding ammonia spraying amount is calculated based on the flue gas flow and the NOx emission value predicted by the model, the system monitors the actual NOx emission value in real time and compares the actual NOx emission value with the predicted value, and if obvious deviation exists, the ammonia spraying amount is determined. If yes, the prediction model is corrected in the next period, the calculated ammonia spraying amount data is transmitted to a denitration master control system, the denitration master control system automatically adjusts an ammonia supply valve, if the denitration precise ammonia spraying control system breaks down, an alarm is triggered immediately, the mode is automatically switched to a manual control mode, and the manual control mode is switched to a manual control mode. Accurate control and stability of total ammonia regulation of the denitration system are realized.

Owner:JIANGSU PUWEI ENVIRONMENTAL TECH CO LTD
Coordination control method and device for off-grid new energy hydrogen production, electronic equipment and medium
ActiveCN119602359Asafe and stable operationImprove consumption rateCellsSingle network parallel feeding arrangementsNew energyIndustrial engineering
The invention provides a coordination control method and device for off-grid new energy hydrogen production, electronic equipment and a medium, and relates to the technical field of new energy hydrogen production. The coordination control method for off-grid new energy hydrogen production comprises the following steps: performing first coordination control on off-grid new energy hydrogen production based on a steady-state control mode under the condition that the actually measured current frequency of a system is within an adjustment dead zone range; under the condition that the current frequency of the system is not in the adjustment dead zone range, performing second coordination control based on the transient state control mode; after the second coordination control, under the condition that the current frequency of the system is not in the adjustment dead zone range, third coordination control is carried out on off-network new energy hydrogen production based on the emergency control mode; and after the third coordination control, under the condition that the current frequency of the system is not in the adjustment dead zone range, determining a to-be-cut power value of off-grid new energy hydrogen production according to an overcut principle. According to the method, the load adjusting characteristic of the hydrogen production electrolytic cell is considered, source-load interaction is achieved, and the absorption rate of new energy is increased.

Owner:NR ELECTRIC CO LTD +1