
Flexible laparoscope actuator based on serial elastic element and continuum configuration
A series of elastic and continuum technology, applied in the field of robotics, can solve problems such as the inability to prevent unexpected situations and the inability to cooperate with the stability of the robotic arm, and achieve the effect of eliminating unfavorable surgical factors, good elasticity, and high control accuracy.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-06-29
Smart Images
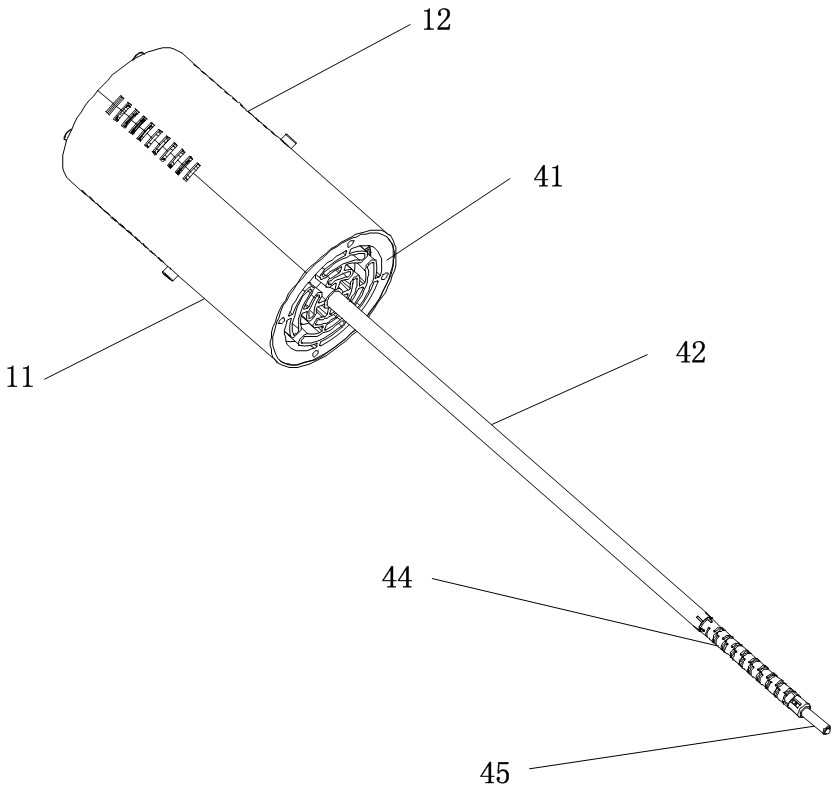
Figure 1 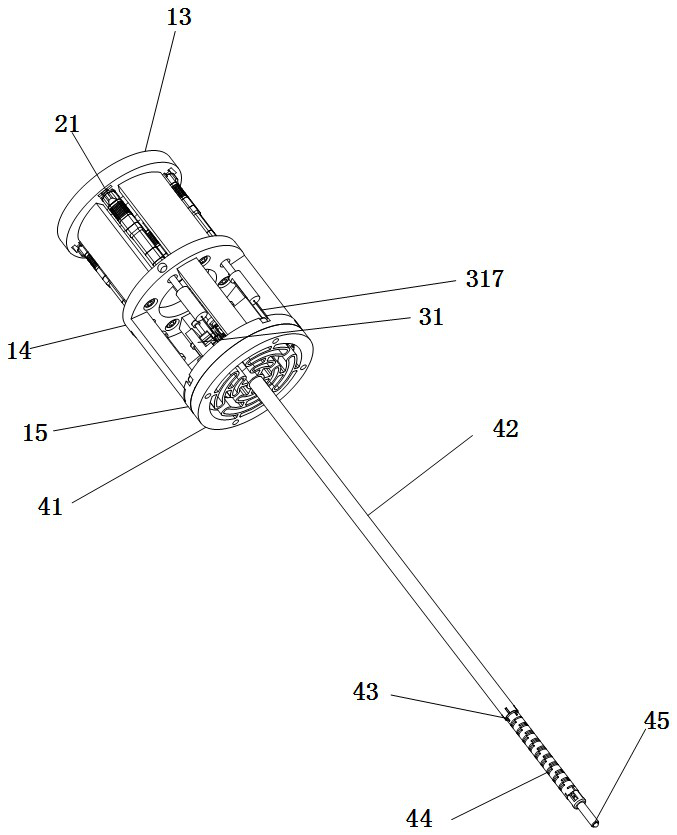
Figure 2 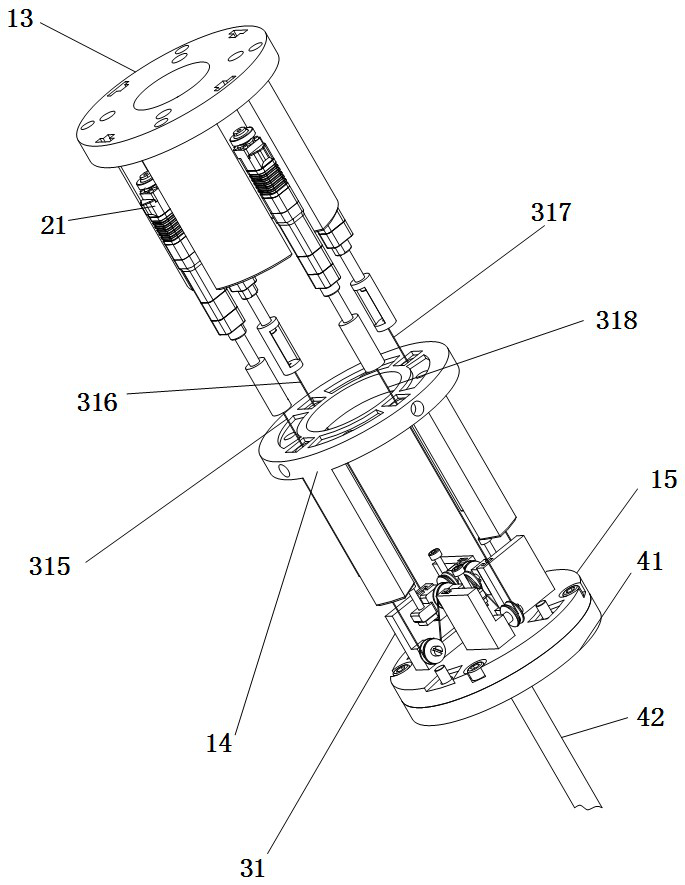
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of robots, in particular to a flexible laparoscopic actuator based on a serial elastic element and a continuum configuration. Background technique
[0002] Due to the small trauma of minimally invasive surgery, the recovery time of patients is fast and so on. Minimally invasive surgery has been vigorously promoted and developed at home and abroad. When performing minimally invasive surgery, one or several small holes need to be opened on the patient's body surface to support the work of surgical forceps and laparoscope. The main function of laparoscope is to obtain clear images during surgery. Cooperate with surgical forceps for various operations.
[0003] However, the traditional minimally invasive surgery requires the cooperation of several doctors and nurses. Among them, the laparoscope needs to be controlled by a doctor holding the mirror to obtain images. The operation process is complex and changeabl...
Examples
Embodiment Construction
[0035] The present invention will be further described through the embodiments below in conjunction with the accompanying drawings.
[0036] see figure 1 , a flexible laparoscopic actuator based on a series elastic element and a continuum configuration includes a driving mechanism, a cable guiding mechanism and a lens assembly 45 .
[0037] see figure 2 , image 3 , the driving mechanism includes four linear motors 21, four flexible cables, four pre-tensioning mechanisms, the first fixing part 13, the second fixing part 14 and the fixing plate 15. The linear motor 21 is a screw-type linear motor, and the four flexible cables are a first flexible cable 315 , a second flexible cable 316 , a third flexible cable 317 and a first flexible cable 318 . The first fixing part 13, the second fixing part 14 and the fixing plate 15 are sequentially connected to form a columnar body; the four linear motors are evenly distributed in the first fixing part 13, and one end of the four flex...