
Kalman filtering, digital phase-locked loop filtering and signal tracking methods and devices
A technology of Kalman filtering and digital phase-locked loop, which is applied in measuring devices, radio wave measurement systems, satellite radio beacon positioning systems, etc., can solve problems such as high computational complexity, inability to adapt to high-speed calculations, and inability to self-adapt adjustments
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2011-06-08
Smart Images
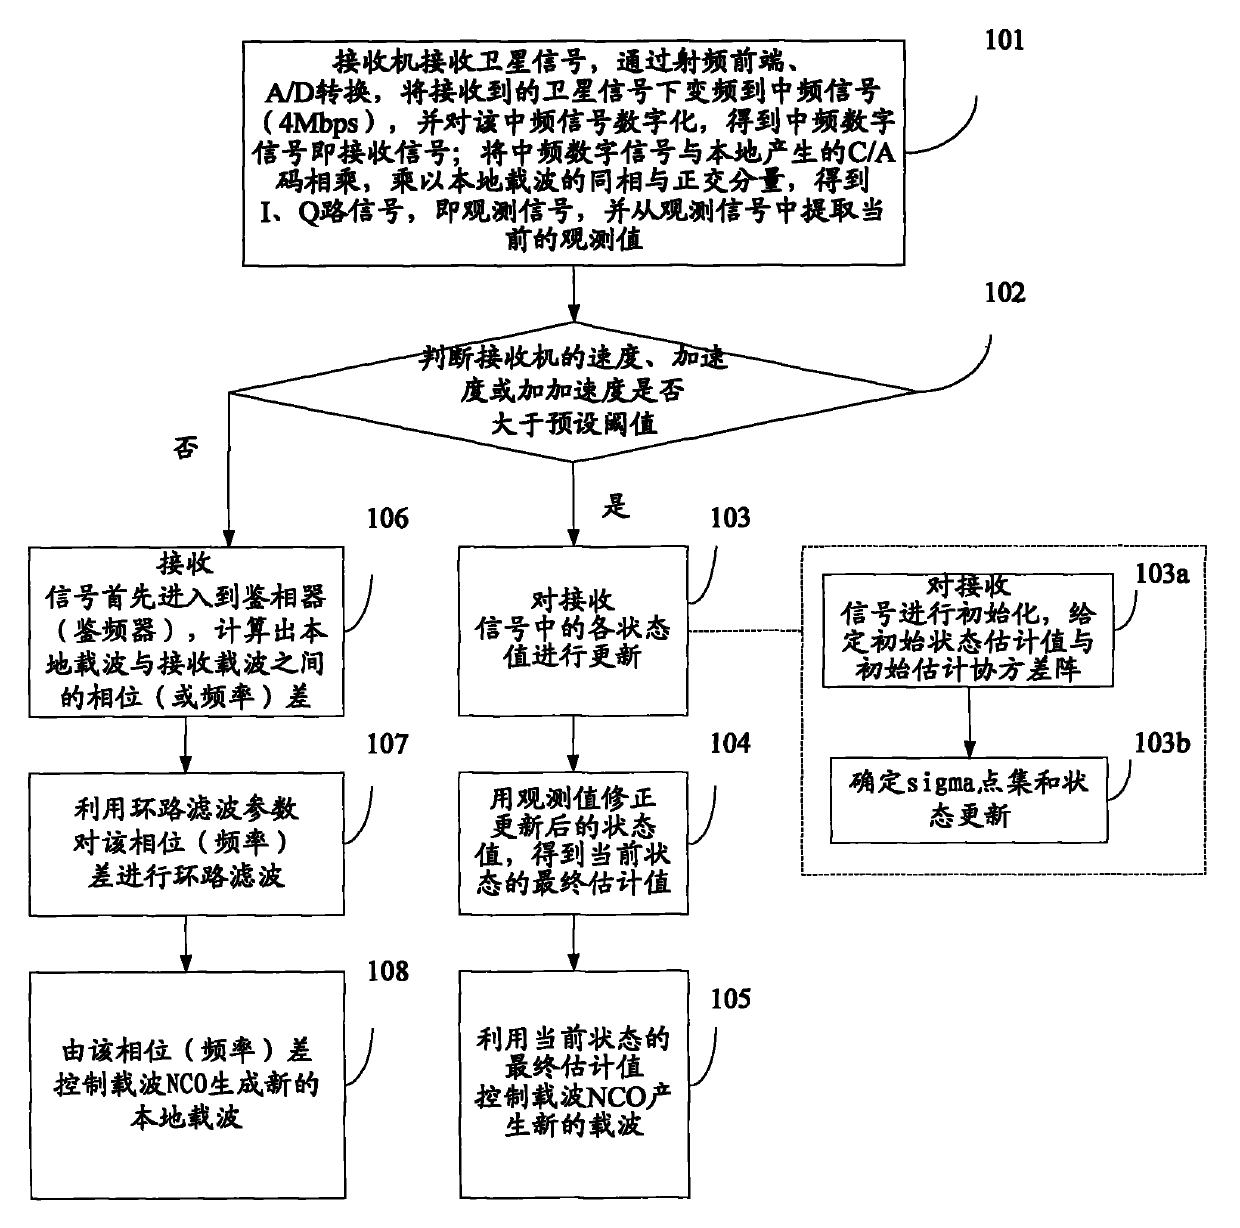
Figure 1 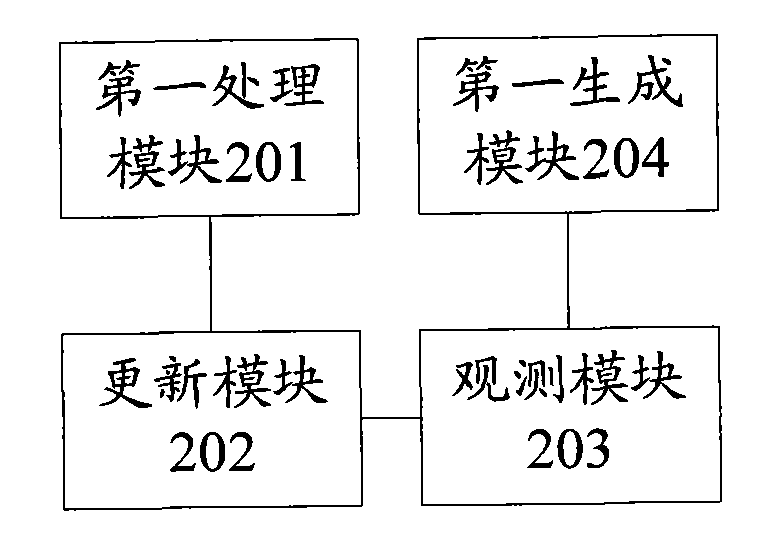
Figure 2 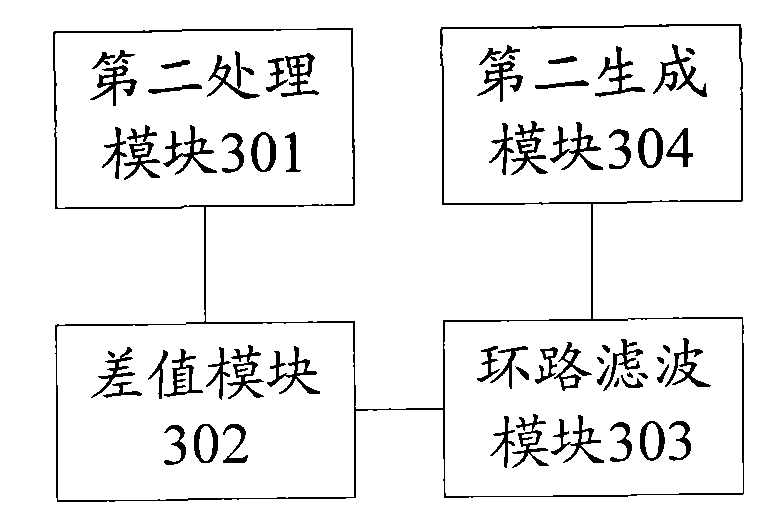
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of wireless communication, in particular to a method and device for Kalman filtering, digital phase-locked loop filtering and signal tracking. Background technique
[0002] The key part of the satellite navigation receiver baseband signal processing module is the carrier tracking and code tracking method. After receiving the GPS satellite signal, the carrier Doppler frequency shift value and the estimated value of the code phase in the input signal can be obtained. At this time, the receiver It can be transferred to the tracking state. The function of the tracking loop is to track the change of code phase and carrier Doppler, so as to realize the accurate synchronization of the local reproduced signal of the receiver with the input signal, extract accurate observation data and navigation message information, and receive Machine navigation solution.
[0003] There are mainly two types of carrier tracking and code trac...
Examples
Embodiment 1
[0107] In order to adapt to the complex dynamic environment, so that the tracking loop can switch the carrier tracking method according to the change of the dynamic environment, the loop bandwidth has a certain ability of self-adaptive adjustment, it has a wider bandwidth in the high dynamic environment, and in the non-high dynamic environment With a smaller bandwidth, and taking into account the capture performance of the loop and the steady-state tracking performance, the embodiment of the present invention provides a Kalman filtering method, including:
[0108] Process the received signal to obtain a received signal, and extract observation values from the received signal, the received signal includes a received carrier and a received code;
[0109] There are multiple methods for extracting observed values, which are not specifically limited in this embodiment of the present invention.
[0110] Update the state value of the received signal;
[0111] Use the observed valu...
Embodiment 2
[0210] In order to adapt to the complex dynamic environment, so that the tracking loop can switch the carrier tracking method according to the change of the dynamic environment, the loop bandwidth has a certain ability of self-adaptive adjustment, it has a wider bandwidth in the high dynamic environment, and in the non-high dynamic environment The embodiment of the present invention provides a Kalman filter device with a small bandwidth and taking into account both loop capture performance and steady-state tracking performance. see figure 2 , the device specifically includes:
[0211] The first processing module 201 is configured to process the received signal to obtain a received signal, and extract an observed value from the received signal, where the received signal includes a received carrier and a received code;
[0212] An update module 202, configured to update the state value of the received signal;
[0213] The observation module 203 is used to correct the updated st...
Embodiment 3
[0235] In order to adapt to the complex dynamic environment, so that the tracking loop can switch the carrier tracking method according to the change of the dynamic environment, the loop bandwidth has a certain ability of self-adaptive adjustment, it has a wider bandwidth in the high dynamic environment, and in the non-high dynamic environment The embodiment of the present invention provides a code tracking method with a small bandwidth and taking into account both loop capture performance and steady-state tracking performance. see Figure 5 , the method specifically includes:
[0236] 501: The receiver receives the satellite signal and processes the received signal to obtain the received signal, multiplies the received signal by the in-phase and quadrature components of the local carrier, and then multiplies it with the locally generated C / A code to obtain the observed signal , to extract the current observation value from the observation signal;
[0237] Wherein, the recei...