
A hydraulically driven flexible robot joint
A robot joint and flexible technology, applied in the field of bionic robots, can solve problems such as heavy weight, unfavorable robots, increased complexity and nonlinearity of motor dynamic modeling, etc., to reduce energy consumption, improve motion efficiency, and reduce overall weight Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2019-01-15
Smart Images
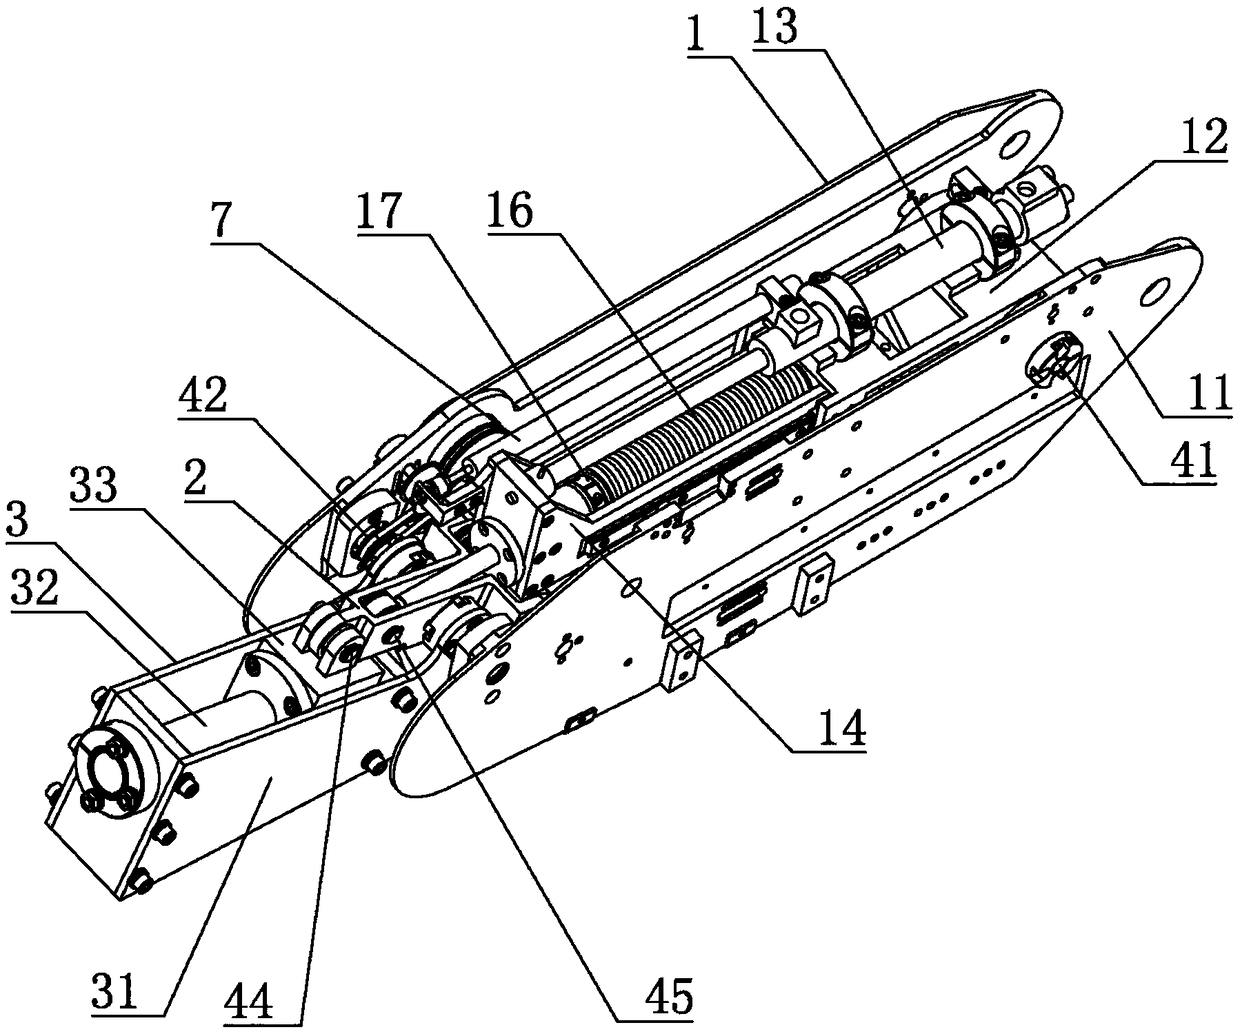
Figure 1 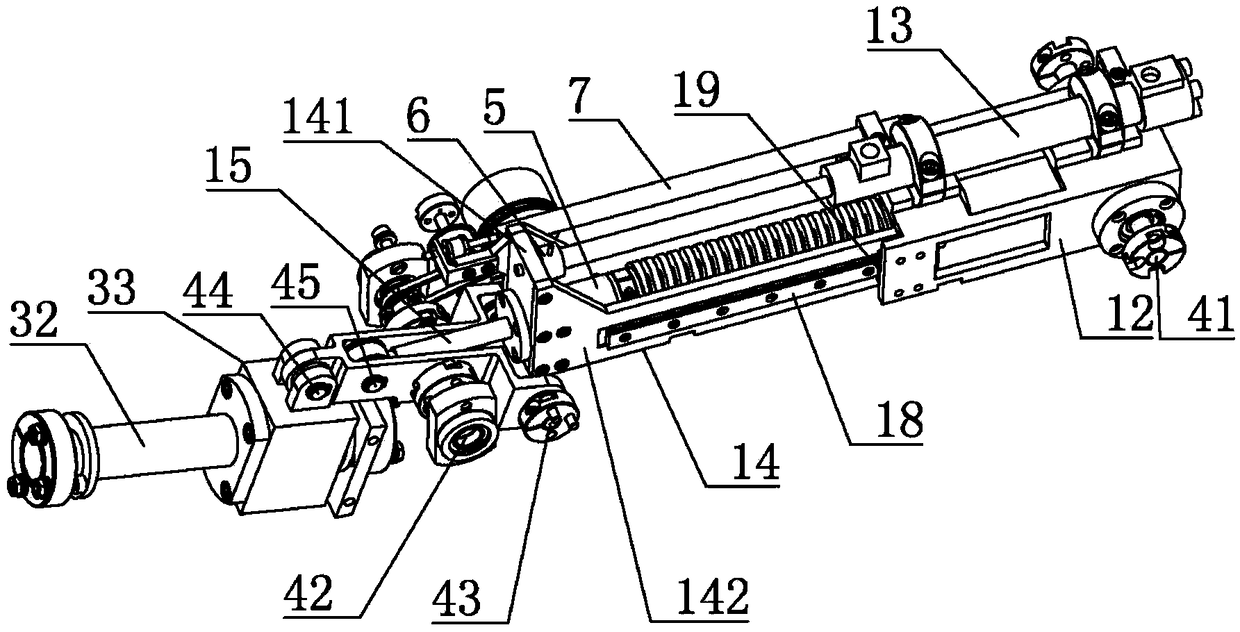
Figure 2 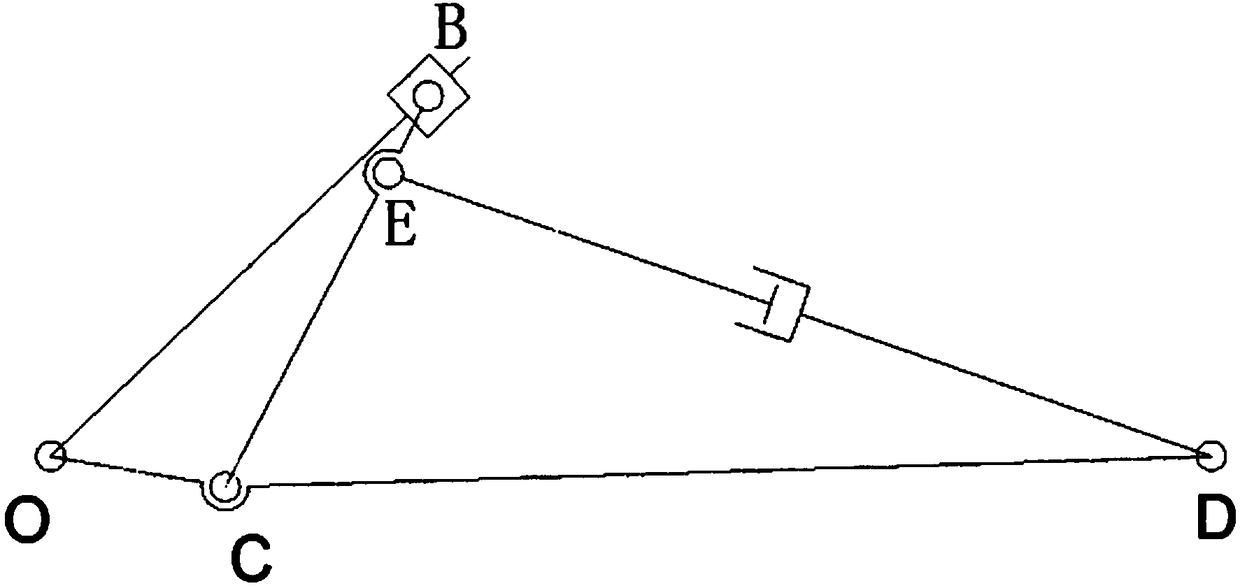
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of bionic robots, and more specifically relates to a hydraulically driven flexible robot joint. Background technique
[0002] With the development of robotics technology, there are more and more types of robots, and the scope of application is wider and wider. The current robots mainly have bipedal, quadrupedal, multi-legged and other forms, but no matter what kind of robot, one of its design cannot The problem to be avoided is the design and manufacture of the joint part. The design of the joint part is directly related to the dynamic performance and walking efficiency of the whole robot, so the joint bionic drive technology has become an important research direction in the field of robotics. In terms of joint servo drives, in the past, more robots used motors as power sources, but the reducer increased the output impedance of the motor while increasing the force and energy density of the motor drive, and at the sam...
Examples
Embodiment Construction
[0020] In order to make the object, technical solution and advantages of the present invention clearer, the present invention will be further described in detail below in conjunction with the accompanying drawings and embodiments. It should be understood that the specific embodiments described here are only used to explain the present invention, not to limit the present invention. In addition, the technical features involved in the various embodiments of the present invention described below can be combined with each other as long as they do not constitute a conflict with each other.
[0021] refer to Figure 1 ~ Figure 3 , a hydraulically driven flexible robot joint, including a thigh structure 1, a thigh structure 2 and a lower leg structure 3, wherein,
[0022] The thigh structure 1 includes a thigh main frame 11, a cylinder base 12, a hydraulic cylinder 13, a moving frame 14, a guide shaft 15 and a compression spring 16, and the cylinder base 12 is hinged to the thigh mai...