
Sliding-mode control method of permanent magnet synchronous motor based on reaching law and disturbance observation compensation
A permanent magnet synchronous motor, disturbance observation technology, applied in motor generator control, electronic commutation motor control, control system and other directions, can solve the problems of reducing sliding mode control and increasing the anti-interference of permanent magnet synchronous motor.
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2019-03-08
Smart Images
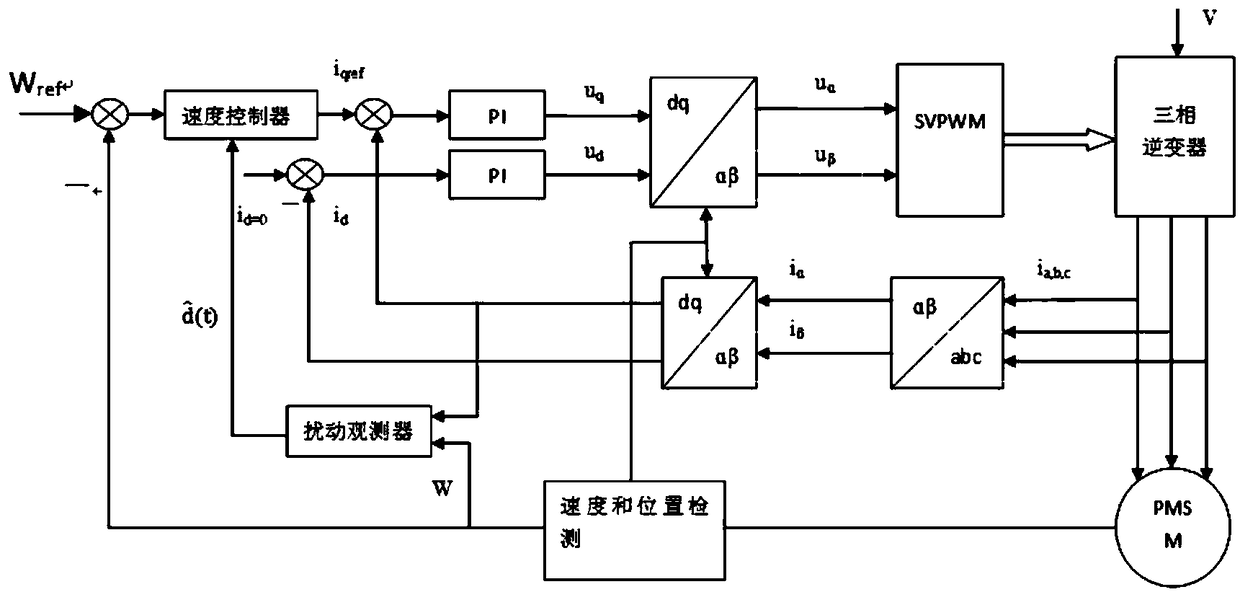
Figure 1 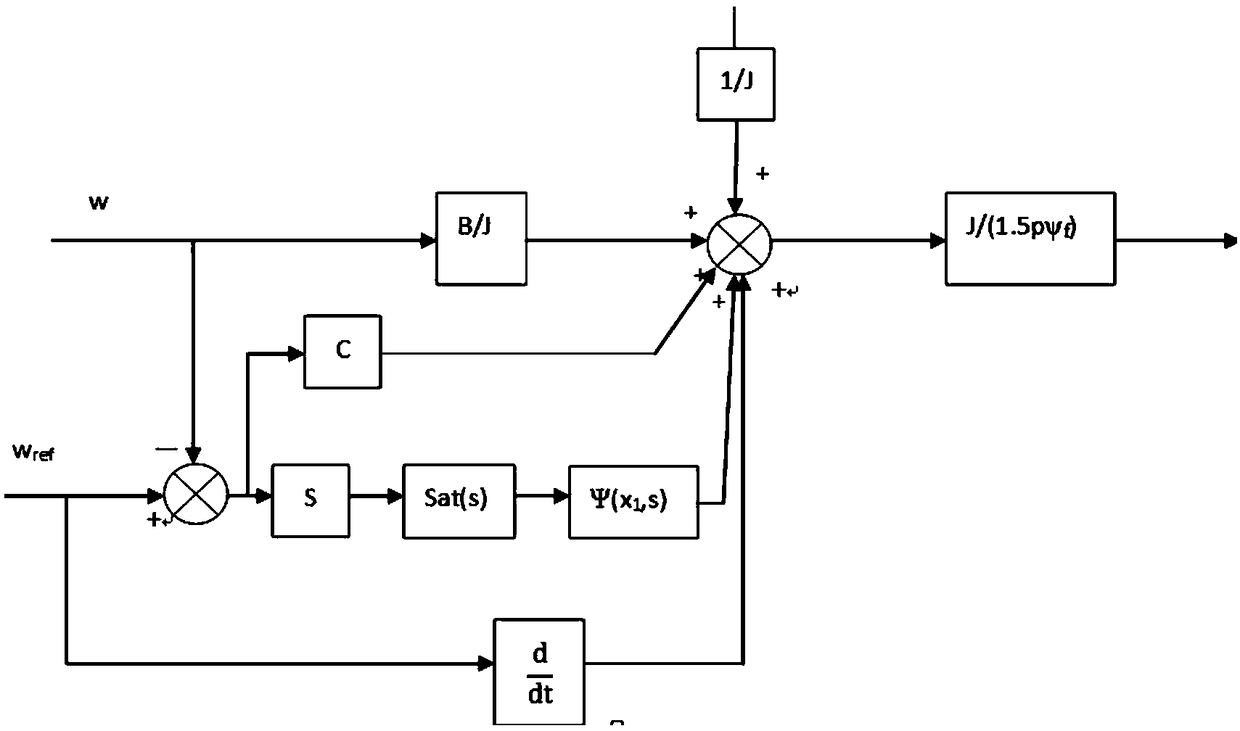
Figure 2 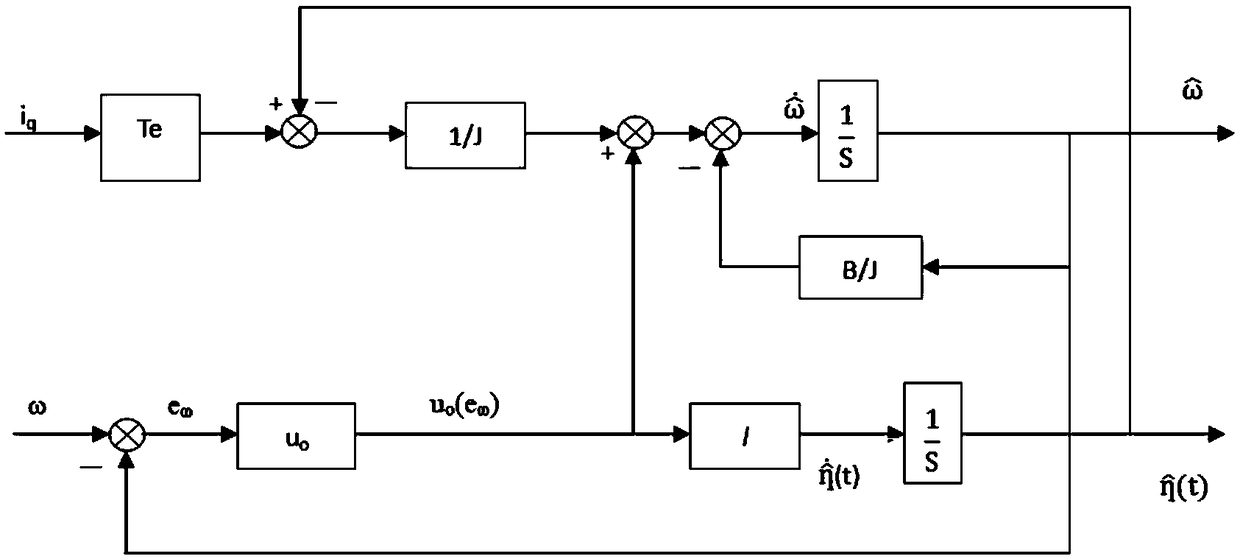
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of motor control, and specifically relates to a speed controller design in which a new reaching law algorithm is applied to a sliding mode variable structure, and at the same time, the value observed by a disturbance observer is compensated to a permanent speed controller in the speed controller. Sliding mode variable structure control method for magnetic synchronous motor. Background technique
[0002] The permanent magnet synchronous motor has many advantages such as simple structure, small size, high efficiency and reliable operation, but the characteristics of strong coupling, multi-variable and nonlinear make it difficult to meet the control requirements of high reliability and high performance in complex environments. Therefore, it is necessary to solve many problems caused by uncertain factors such as parameter perturbation and external disturbance. At present, in the industrial field, PI control str...
Examples
Embodiment Construction
[0075] Below in conjunction with specific embodiment, further illustrate the present invention.
[0076] combine Figure 9 , this embodiment provides a sliding mode control method for permanent magnet synchronous motors based on reaching law and disturbance observation compensation, the specific steps are as follows:
[0077] (1) Carry out coordinate transformation on the prototype motor equation.
[0078] The coordinate transformation is based on the principle of generating the same rotating magnetomotive force and the same total power, so as to establish the mutual conversion relationship between the three-phase AC winding, the two-phase AC winding and the two-phase rotating DC winding. The coordinate transformation formula used in the mathematical model is:
[0079] Clark transformation formula:
[0080] Inverse Clark transform formula:
[0081] Park transformation formula:
[0082] Inverse Park transformation formula:
[0083] In the above formula, i A , i ...