
Patents
Literature
29 results about "Stopped work" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Vehicle idling start and stop control system and method
InactiveCN108622068AReduce idle timeLow costExternal condition input parametersState of chargeFlywheel
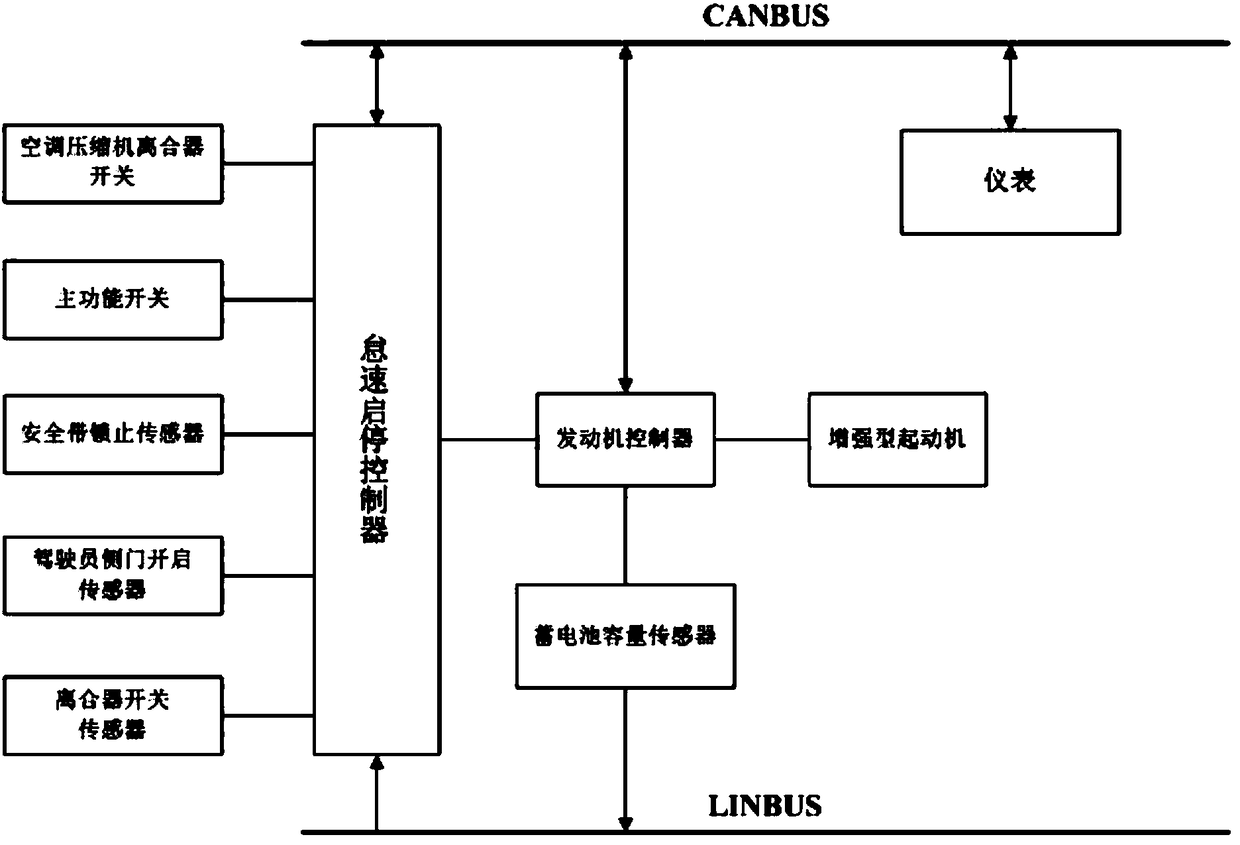
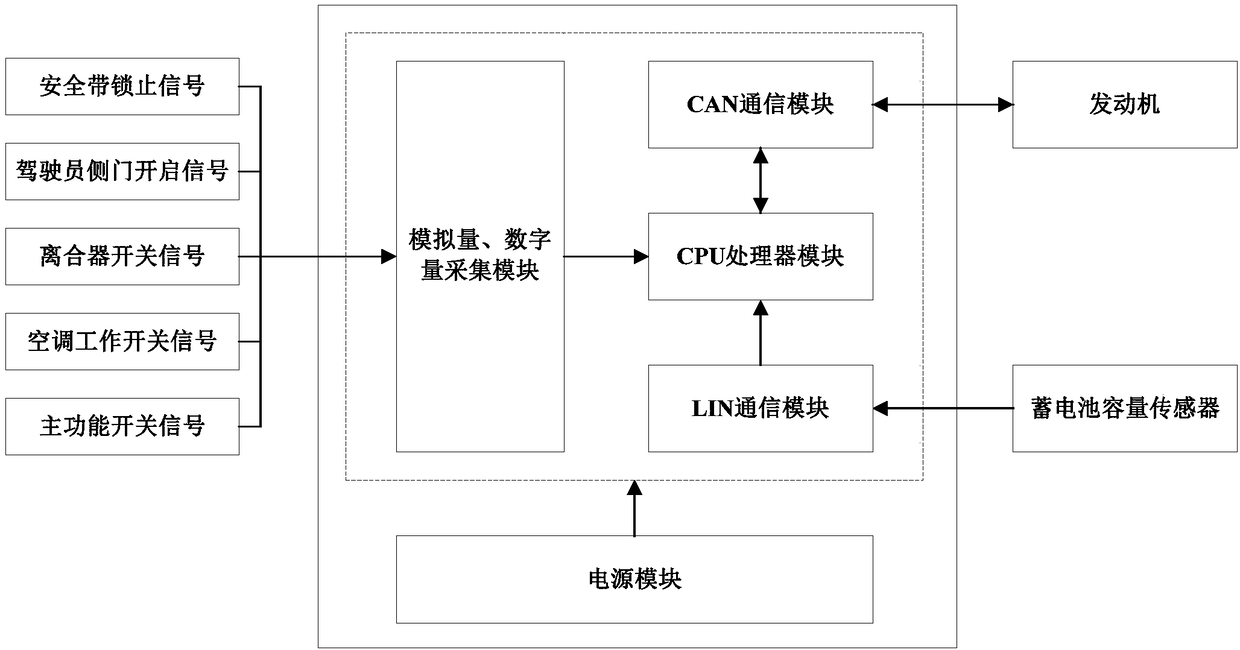
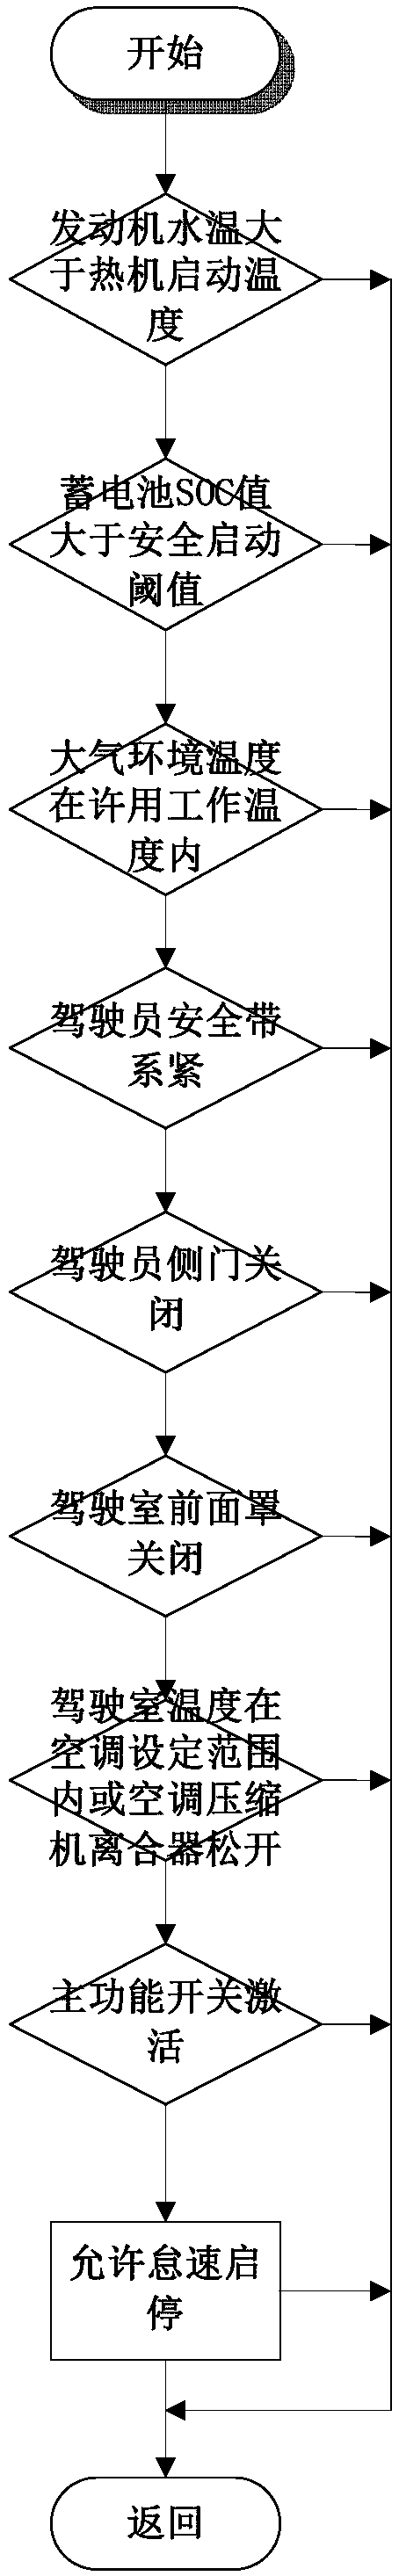
The invention discloses a vehicle idling start and stop control system and method. The control system judges whether a vehicle has idling start and stop conditions by monitoring the water temperatureof an engine, the capacity of a storage battery, a safety belt and other information, judges whether the vehicle has conditions of stopping the engine by monitoring the rotating speed of the engine, the speed of the vehicle, the brake air pressure and other conditions, and judges whether the vehicle has conditions of starting the engine by monitoring the gear of a gearbox, the speed of the vehicle, a hand brake and other information. When the relevant conditions are met, start and stop work signals are sent to the engine though a CAN bus. In order to guarantee the reliability of frequent startand stop of the engine, the system strengthens flywheel gear rings of a starter and the engine. In order to ensure that the battery does not lose power, a storage battery capacity sensor is added tothe system on the basis of increasing the capacity of the storage battery, and the idling start and stop are allowed when the state of charge (SOC) of the storage battery satisfies a safe starting threshold. The idling start and stop control system has advantages of low cost and high reliability, and is especially suitable for commercial vehicles.
Owner:SHAANXI AUTOMOBILE GROUP
A tool break detection device and method
The present application relates to the field of machine tool, and particularly relates to a tool broken tool detection device and method, which comprises: a swing rod is driven to rotate through a scanner, when the swing rod rotates and touches a to-be-detected tool, the scanner records the angle of the swing rod rotation, obtains the to-be-detected tool angle and sends it to a processor, the to-be-detected tool angle is compared with the standard tool angle collected in the processor in advance, to determine whether the to-be-detected tool has a broken tool condition, and in the case that the to-be-detected tool angle is less than the difference between the standard tool angle and the angle tolerance, the processor outputs a first signal that the to-be-detected tool has a broken tool. When the machine tool system receives the first signal, an alarm is sent and the machine tool is controlled to stop working, and a worker replaces the to-be-detected tool and checks whether the workpiece is damaged.

Owner:GENESIS IND EQUIP (GUANGDONG) CO LTD
High-altitude operation machine and anti-collision device thereof
ActiveCN224185822Uavoid collisionReduce risk of damageSafety devices for lifting equipmentsStopped workElectrical connection
The utility model belongs to the technical field of high-altitude operation mechanical equipment, and particularly relates to a high-altitude operation machine and an anti-collision device thereof. The anti-collision device comprises a telescopic sleeve assembly, a trigger piece, an elastic reset piece and a limiting switch, the telescopic sleeve assembly comprises a short sleeve and a movable rod which are matched in a telescopic mode in the vertical direction, and the top end of the movable rod stretches out of the short sleeve and stretches out to the position above the working platform; the trigger piece extends out of the movable rod; the limiting switch is installed on the short sleeve and used for being electrically connected with a lifting mechanism of the high-altitude operation machine, the limiting switch is located below the triggering piece, and a contact of the limiting switch can reach the switching position under pressing triggering of the triggering piece so as to send out a work stopping signal aiming at the lifting mechanism. In the process that the lifting mechanism drives the working platform to ascend, the movable rod replaces a contact of the limiting switch to make direct contact with an obstacle, so that the damage risk of the limiting switch is reduced, and the service life of the anti-collision device is prolonged.

Owner:ZOOMLION INTELLIGENT ACCESS MASCH CO LTD
Work device in hoistway

Owner:FUJITEC CO LTD
Workpiece thickness automatic detection device
The invention provides a workpiece thickness automatic detection device which comprises a rack, and a detection platform, a feeding conveying belt and a discharging conveying belt are arranged on the rack. A first detection element and a second detection element are arranged on the upper side and the lower side of the detection platform on the rack respectively, the second detection element slidably penetrates through the lower detection platform to abut against the lower end face of the workpiece, and the first detection element abuts against the upper end face of the workpiece; a material blocking plate capable of ascending and descending is arranged above one end of the discharging conveying belt, and a feeding sensor located above the outlet end of the feeding conveying belt and a discharging sensor located above the inlet end of the discharging conveying belt are further arranged on the machine frame. The system runs, when the discharging sensor does not detect the workpieces, the material blocking plate moves downwards to the material blocking station, and when the feeding sensor detects the workpieces and keeps the workpieces for a certain time, the material blocking plate moves upwards to the initial position. According to the workpiece thickness automatic detection device, the contour dimension of a product can be detected without transferring after the product is ground, the detection precision is high, and manual participation is not needed.


Owner:宁波邦一机械科技有限公司
Quick change structure of multi-degree-of-freedom robot end effector
The utility model relates to robot technical field especially, more degree of freedom robot end effector's quick change structure of quick change structure, including base, be provided with more degree of freedom robot main body on the base, more degree of freedom robot main body is fixedly arranged in the top of base through the rotary base of bottom, the end of more degree of freedom robot main body is provided with quick dismounting mechanism, and this quick dismounting mechanism is used for quick change of the execution tool to change the efficiency of execution tool, saves a lot of time and manpower cost, reduces the dependence on single tool or production line again, when facing different workpieces and complex process requirements, need not because tool adaptation problem and stop work adjustment, enhance the fault tolerance of production system, let the robot can flexible adaptation diversified production scene, guarantee the high efficiency and stability of production.

Owner:BEIJING HONGYUAN ONLINE TECHNOLOGY DEVELOPMENT CO LTD
Membrane center tapping machine
A diaphragm center tapping machine is characterized in that the diaphragm center tapping machine comprises a supporting frame, a workbench, a protection assembly, a placing base, a mounting base, a positioning mechanism, a driving motor and a tapping cutter, the workbench is fixedly mounted on the supporting frame, the protection assembly is mounted on the periphery of the workbench, the placing base is connected to the workbench, and the positioning mechanism is arranged on the placing base. A positioning plate is arranged on the workbench, a placing seat is arranged on the workbench, a mounting seat is fixed on the workbench and positioned beside the placing seat through bolts, the mounting seat is connected with a driving motor through a positioning mechanism, and an output end of the driving motor is connected with a trepanning cutter. The positioning plate is controlled to move downwards to press and position a workpiece to be machined through a telescopic cylinder, and the driving motor is controlled to move downwards to perform trepanning; the overall structure is simple, operation is convenient, machining efficiency is improved, and practicability is high; the infrared sensors are installed at the two ends of the opening of the protective cover installed on the workbench, when it is detected that an object stretches into the workbench, the infrared sensors transmit information signals, the controller is additionally arranged to control equipment to stop working, and installation accidents are avoided.

Owner:EMERSON PROCESS MANAGEMENT TIANJIN VALVES
Robot control system
The present invention provides a robot control system. In a robot control system that uses a robot to perform work on a continuously moving work object, a repeatedly moving, or a stopped work object, even if the robot cannot perform the work properly, the situation can be detected and the equipment damage and other problems can be avoided. The robot control system comprises: a robot (4) for performing work on the work object; a control unit for controlling the driving of the robot (4); a first area setting unit for setting a first area (R1) for performing work on the work object; and a second area setting unit for setting a second area (R2) outside the first area (R1) so as to make the robot (4) perform a retreat action as the robot (4) follows the moving work object and a work device (5) provided on the robot (4) leaves the first area (R1) and enters the second area (R2).

Owner:FANUC LTD
Working machine
A working machine includes a controller to: select one of pieces of operation characteristics information corresponding to respective work attachments stored in a memory that corresponds to a work attachment attached to an attachment mount portion and fluidly connected to a hydraulic fluid port; and control, based on the selected one of the pieces of operation characteristics information, the speed of switching of a work-attachment-drive control valve when starting the work attachment and / or when stopping the work attachment.


Owner:KUBOTA CORP
A tunneling machine cutting head protective cover
The utility model discloses a kind of tunneling machine cutting head protective cover, including metal net, steel pipe and nut, the metal net is divided into three parts, middle metal net and left and right metal net, middle metal net is connected two sides metal net by nut.The utility model folds up when tunneling machine cutting head works, protective cover can avoid affecting the normal work of tunneling machine.After cutting head stops working, promptly unfold protective cover and cover on cutting head, can effectively prevent personnel from accidentally touching cutting head and causing injury, ensure safety production.

Owner:SHAANXI ENERGY FENGJIATA MINING OPERATION CO LTD
Rivet leakage-proof mechanism
The utility model relates to the technical field of rivet installation, in particular to a rivet leakage-proof mechanism which comprises a template, a fixing seat fixedly connected to the upper surface of the template, a Harding fixedly connected to one side of the template, a support fixedly connected to the upper surface of the fixing seat, an inductor fixedly installed on the surface of the support, and a connecting wire fixedly connected to one end of the Harding. One end, far away from the Harding, of the wiring penetrates through the fixing seat and is electrically connected with the inductors, the surface of the support is in threaded connection with a nut, the support is fixedly connected with the fixing seat through the nut, the side face of the fixing seat is provided with a side face hole, the surface of the fixing seat is provided with a groove, and the inductors are arranged at the two ends of the groove in the surface of the fixing seat. The nut placing condition is monitored in real time, and once abnormity is found, a machine tool stops working immediately, so that accidental injury to staff caused by sudden damage of a die and splashed parts in the riveting process due to improper nut placing can be effectively reduced, the personal safety of the staff is greatly guaranteed, and a safer production environment is created.

Owner:WUXI MINGHAO AUTOMOTIVE PARTS
Monitoring system for work device
PCT designated stageWO2026058415A1Electrical componentsProgramme total factory controlStopped workControl cell
A monitoring system comprises a forward-movement-side sensor unit that is capable of detecting an object within a forward-movement-side warning area, a rearward-movement-side sensor unit that is capable of detecting an object within a rearward-movement-side warning area, and a control unit, the monitoring system monitoring a work device that moves in a reciprocating manner on a movement line. The control unit: receives input of signals from the forward-movement-side sensor unit and signals from the rearward-movement-side sensor unit, said signals being inputted independently of one another; confirms whether an obstacle is present on the forward-movement side of the work device on the basis of the input of a signal indicating that an object has been detected in the forward-movement-side warning area while the work device is moving; stops the work device when it is confirmed that an obstacle is present; confirms whether an obstacle is present on the rearward-movement side of the work device on the basis of the input of a signal indicating that an object has been detected in the rearward-movement-side warning area while the work device is moving; and stops the work device when it is confirmed that an obstacle is present.

Owner:FUJI CORP
Negative pressure drainage bag detection machine
The utility model belongs to the technical field of drainage bag detection, and particularly relates to a negative pressure drainage bag detection machine which comprises a working table and further comprises supports fixedly installed at the top of the working table, a top plate fixedly installed between the supports, a motor fixedly installed at the top of the top plate, a lead screw sleeve fixedly installed at the output end of the motor, and a pressure sensor fixedly installed at the top of the lead screw sleeve. A lead screw bearing is fixedly installed at the bottom of the lead screw sleeve, a lead screw body is fixedly installed at the bottom of the lead screw bearing, the lead screw sleeve can be driven by the motor to rotate, then the lead screw body can be fixed to the bottom of the lead screw sleeve through the lead screw sleeve, and rotation can be conducted through the lead screw bearing; the drainage bag bodies are placed in the containing frame, the pressing plate is driven by the lead screw nut to press downwards, when the pressing plate is pressed to a set position, the motor stops working, the PLC gives an instruction to the electromagnetic valve and supplies air to the four drainage bag bodies, air leakage of the drainage bag bodies can be detected, and accumulated liquid in the bodies can be led out.


Owner:CHANGZHOU WEIPU ELECTRONIC EQUIP CO LTD
WORK ROBOT
A work robot can comprise a work unit, which includes a work mechanism configured to operate and a work motor configured to drive the work mechanism; a rechargeable battery configured to supply power to the work motor; a sensing unit configured to detect the work unit's state; and a control unit. The control unit can be configured to perform an abnormality detection process, in which the control unit determines whether an abnormality is occurring in the work unit based on a detection result from the sensing unit; and an initial abnormality handling process, in which the control unit causes the work robot to return to a charging station with the work motor stopped to begin charging the battery.If the control unit determines in the abnormality detection process that an abnormality is occurring in the working unit, the control unit can execute the first abnormality treatment process.

Owner:MAKITA CORP
An intelligently controlled juicer
The present invention relates to an intelligently controlled juicer, comprising a hopper, a pre-cutting assembly, an extrusion assembly, an extrusion screw, and a motor. When the motor is detected to have decreased from satisfying the workload to not satisfying the workload, the motor is controlled to rotate in the reverse direction and then resumes forward rotation. When forward rotation resumes, it is detected that the motor still does not satisfy the workload, and it is determined that the material has been extruded and the machine stops working. When the pre-cutting assembly and the extrusion screw resume forward rotation, it is detected that the motor resumes satisfying the workload and it is determined that the motor has decreased from satisfying the workload to not satisfying the workload, the tip of the machine pierces the material and the material has been detached during the reversal of the pre-cutting assembly, and the pre-cutting assembly and the extrusion screw continue to rotate forward to process the material. The technical solution of the present invention distinguishes whether the motor is in an idle state after the juice extraction is normally completed when the workload is reduced from satisfying the workload to not satisfying the workload during forward rotation, or in an idle state where the material pierces the tip of the cutting edge, so as to ensure that the juice extraction work is completed normally.

Owner:JOYOUNG CO LTD
Work machine and method
PCT designated stageWO2025205084A1Fuel cell auxillariesSoil-shifting machines/dredgersStopped workFuel cells
In the present invention, a control device causes a power storage device to discharge power stored therein when a stop instruction for a work machine is received. The control device performs stop processing for a fuel cell module after the discharge of the power storage device, and causes the power storage device to be charged with generated power generated as a result of the stop processing.

Owner:KOMATSU LTD
Autonomous travel system, autonomous travel method, and autonomous travel program
ActiveUS12487600B2Guiding agricultural machinesVehicle position/course/altitude controlStopped workSimulation
A position acquisition processing unit acquires positional information of a work vehicle. A halt acquisition processing unit acquires a halt instruction for a work of the work vehicle. A halt processing unit halts the work and travel of the work vehicle when the halt acquisition processing unit acquires the halt instruction. A calculation processing unit calculates a resumption position in which the work is to be resumed, on the basis of a halt instruction position indicating a position in which the halt instruction has been acquired, and a vehicle stop position indicating a position in which the work vehicle has stopped. A resumption processing unit moves the work vehicle to the resumption position calculated by the calculation processing unit and resumes the work.

Owner:YANMAR HLDG CO LTD
Construction machine
A construction machine includes an angle measuring apparatus that sense acceleration and angular velocities of installation portions on a machine body and a work implement and that compute angles of the installation portions relative to a reference plane based on sensing results, and a controller that executes operation assistance of a work implement based on postural information on the machine body and the work implement computed on the basis of the angles from the angle measuring apparatus. The controller computes second required accuracy of angle computation by the angle measuring apparatus on the basis of first required accuracy set for the operation assistance, determines whether the state of the machine body has changed from an active state to a stopped state on the basis of the sensing results of the angle measuring apparatus, determines whether the computation accuracy of the angle measuring apparatus satisfies the second required accuracy, and stops the operation assistance of the work implement or gives a warning in a case where the state of the machine body has changed to a stopped state, and where the computation accuracy fails to satisfy the second required accuracy.

Owner:HITACHI CONSTRUCTION MACHINERY CO LTD
Stripping device with position alignment induction function
The utility model relates to a stripping device with a position alignment induction function, which belongs to the technical field of rubber product production and comprises a workbench, a sliding seat is arranged at the top end of the workbench, and a top plate is arranged at the top end of the sliding seat. The device has the beneficial effects that the linear distance between the detection head of the position sensor and the material sheet can be detected under the action of the position sensor, when the detection data of the two ends are the same, the placement position of the material sheet is accurate, and when the detection data of the position sensor at the two ends are different, the placement position of the material sheet is deviated, and at the moment, the material sheet can be accurately placed. The position sensor transmits information to the controller, and the controller controls the alarm to give an alarm and controls the hydraulic cylinder to stop working so as to remind a worker of position deviation and misalignment of the material sheet, so that the worker can make corresponding adjustment according to the detection condition, and the situation that the rubber particles are cut when the positioning rod is pressed downwards is avoided; therefore, the production quality of the rubber particles is improved.

Owner:DONGGUAN LIANHUAXIN PRECISION RUBBER CO LTD
Remote operation assistance server, remote operation assistance system, and remote operation assistance method
ActiveUS12509856B2Transmission systemsSoil-shifting machines/dredgersStopped workControl engineering
When a remote operation of a work machine 40 through one remote operation apparatus 20 as a first remote operation apparatus is stopped by one operator, operation of an engine 460 of the work machine 40 is continued without being stopped if another operator who may possibly continuously remotely operate the same work machine 40 through another remote operation apparatus 20 as a second remote operation apparatus exists. Therefore, the other operator can immediately remotely operate the work machine 40 through the second remote operation apparatus without causing the engine 460 of the work machine 40, which has been an operation target of the first remote operation apparatus so far, to restart and perform warm-up operation.

Owner:KOBELCO CONSTR MASCH CO LTD
Control system for work machine and control method for work machine
A control system for a work machine includes: a first detection data acquisition unit that acquires detection data of a first sensor that detects an object present in a traveling direction of the work machine; a determination unit that determines a type of a cliff present in the traveling direction on the basis of the detection data of the first sensor; a position setting unit that changes a stop position of the work machine on the basis of the type of the cliff; and a traveling control unit that stops travel of the work machine on the basis of the stop position.


Owner:KOMATSU LTD
Aerial work platform and work platform buffer control method and device thereof
PendingCN121292344ASafety devices for lifting equipmentsNon-rotating vibration suppressionStopped workControl engineering
The invention discloses an aerial work platform and a work platform buffering control method and device thereof, the work platform is connected with a buffering device, and the method comprises the steps that motion state information and load information of the work platform are obtained; determining the current working condition of the working platform according to the motion state information and the load information, wherein the working condition of the working platform comprises an impact working condition, a stable working condition, a starting working condition, a stopping working condition and a sudden stop working condition; determining target damping of the buffer device based on a preset composite damping calculation model according to the current working condition, the load information and the motion state information; determining a target travel proportion of the buffer device according to the current working condition and the load information; and the damping force and the stroke length of the buffer device are adjusted according to the target damping and the target stroke proportion. The damping and stroke of the working platform buffering device can be adjusted in a self-adaptive and cooperative mode, and therefore impact and shaking can be remarkably reduced under various dynamic working conditions.

Owner:ZOOMLION INTELLIGENT ACCESS MASCH CO LTD
Material dispensing control method, server, and storage medium
The application provides a material distribution control method, a server and a computer readable storage medium. The material distribution control method comprises the following steps: acquiring first distribution data of each work equipment in a material distribution control area, wherein the first distribution data comprises a distribution route congestion degree of each work equipment; obtaining a target material delivery time length of each work equipment based on prediction of the first distribution data; determining a material demand time point of each work equipment based on the target material delivery time length and a predicted completion time point of each work equipment; and executing a material distribution task of each work equipment based on the material demand time point of each work equipment. The application can ensure the timeliness of material reaching the work equipment, thereby reducing the probability of the work equipment being forced to stop working and improving work efficiency.

Owner:SHENZHEN YOUIBOT ROBOTICS CO LTD
Uninterruptible power operation tool management method and uninterruptible power operation tool management system
The invention provides an uninterruptible power operation tool management method and system, and belongs to the technical field of tool management, and the method specifically comprises the steps: carrying out the determination of a label verification processing method of an uninterruptible power operation tool according to the composition data of the label verification tool in different operation types, and carrying out the verification processing of the uninterruptible power operation tool; performing verification processing on the RFID tag of the non-power-cut operation tool by using a tag verification processing method, determining future ex-warehouse data of the non-power-cut operation tool in different operation types when secondary verification processing is required according to verification processing results of the non-power-cut operation tool in different operation types, and determining the future ex-warehouse data of the non-power-cut operation tool in the different operation types according to the future ex-warehouse data of the non-power-cut operation tool in the different operation types. And the secondary checking processing strategy is determined based on the future ex-warehouse data, so that the reliability degree of checking processing is improved.

Owner:XICHUAN COUNTY POWER BUREAU
Work machine
A controller of this work machine sets a constraint condition in model prediction control for preventing a work device from entering an entry prevention area, and performs model prediction control for calculating a target operation speed of a hydraulic actuator for a predetermined period of time from the present time so that the deviation between the coordinates of a work tool and the target coordinates of the work tool is reduced while satisfying the constraint condition. The controller calculates an operation speed of the hydraulic actuator on the basis of an attitude of the work device detected by an attitude detection device, controls the hydraulic actuator so that the operation speed of the hydraulic actuator matches the target operation speed, determines whether the position of a control point of the work device deviates from the constraint condition, and executes operation prohibition control for prohibiting or stopping the operation of the work device when it is determined that the position of the control point of the work device deviates from the constraint condition.

Owner:HITACHI CONSTRUCTION MACHINERY CO LTD
Intelligent control juicer
The invention relates to an intelligent control juicer which comprises a hopper, a pre-cutting assembly, an extrusion assembly, an extrusion screw and a motor, and when it is detected that the motor is reduced from meeting the working load to not meeting the working load, the motor is controlled to rotate in the reverse direction and then recover to rotate in the forward direction; the forward rotation is recovered, and when it is detected that the motor does not meet the working load, it is judged that the materials are completely extruded and work is stopped; the pre-cutting assembly and the extrusion screw rod are recovered to rotate in the forward direction, when it is detected that the motor recovers to meet the working load and it is judged that the motor is reduced from meeting the working load to not meeting the working load, the sharp end pricks the material, the material is separated in the reverse rotation process of the pre-cutting assembly, and the pre-cutting assembly and the extrusion screw rod are continuously driven to rotate in the forward direction to machine the material. According to the technical scheme, when the motor rotates forwards, the working load is reduced from meeting to not meeting, and whether the motor is in a no-load state after normal juicing is completed or in an idle state when materials are pricked into the tip end of the cutting edge is distinguished, so that normal completion of juicing work is guaranteed.

Owner:JOYOUNG CO LTD
Operation control device and operation control method
To provide an operation control device and the like which can appropriately control an operation of a work machine according to a body condition of an operator.SOLUTION: A device includes: an acquiring unit for acquiring data related to a vital data of an operator of a work machine; a determination unit for determining a body condition of the operator based on the data acquiring by the acquiring unit using a trained model; and a control unit for controlling operation of the work machine according to the determination result of the determination unit. When the determination result shows a poor body condition, the control unit stops the operation of the work machine. The trained model may be created per operator.SELECTED DRAWING: Figure 1

Owner:OHBAYASHI GUMI LTD
Portable handle electrically operated device
The application discloses a portable handle electric control operation device, which comprises a mounting device, a moving workbench and a limiting device, the moving workbench is fixedly arranged on the mounting device, a rail groove is arranged on the moving workbench, the limiting device is movably arranged on the rail groove, the moving workbench comprises a connecting device driven by a power device, the connecting device is used for connecting a handle of a device to be controlled, and the moving workbench stops working when the limiting device is in contact with the connecting device. The application can be connected to the device for automatic control when the handle of the device is controlled, and manual control can also be quickly taken over when an emergency or other situation occurs. The device is small in size, light in weight and convenient to carry, can be matched with different mounting panels according to different types of devices, and does not affect the existing structure and function of the device.

Owner:CHENGDU ZHONGDA HUARUI TECH CO LTD
Bending machine for front door machining
ActiveCN223684238UMetal-working feeding devicesPositioning devicesStopped workMechanical engineering
The utility model provides a bending machine for processing a front door, which relates to the technical field of bending machines and comprises a base, a placing table is fixedly mounted at the top of the base, a storage groove is formed in the outer wall of the placing table, and a fixing groove is formed in the inner wall of the storage groove. When the front door bending device is used, a worker places a front door on the placing table, the end, needing to be bent, of the front door is attached to the end, close to the placing table, of the baffle, at the moment, the worker starts the electric telescopic rod, the baffle moves, the baffle pushes the front door to move, and at the moment, the worker observes scales on the graduated scale on the side wall of the placing table; and when the required bending length is reached, the electric telescopic rod stops working, a worker starts an electromagnet, an iron baffle enters a limiting groove under attraction force, finally, the worker starts the electric telescopic rod and a movable plate to enter a storage groove, bending can be started at the moment, and therefore the working efficiency of the worker can be improved, and the working difficulty can be reduced.

Owner:YANCHENG JINJIA PRECISION SHEET METAL CO LTD