
Patents
Literature
1764 results about "Remote operation" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Remote operation is the control and operation of a system or equipment from a remote location. There are several particular types of systems that are often controlled remotely: Remotely operated vehicles are extensively used in hazardous environments. Entertainment systems are often controlled remotely via a remote control. Industrial machinery is often operated remotely, particularly in hazardous environments. One notable example is in the construction of the Object Shelter or sarcophagus at Chernobyl after the Chernobyl accident. Remote surgery
Photovoltaic power station intelligent remote operation and maintenance method and system based on relay protection
The invention discloses a photovoltaic power station intelligent remote operation and maintenance method and system based on relay protection, and the method comprises the steps: collecting the multi-mode characteristic quantity of a photovoltaic array region relay protection device in real time through a distributed optical fiber sensing network, so as to construct a dynamic protection characteristic matrix; performing feature decoupling on the dynamic protection feature matrix by adopting a space-time convolution adversarial encoder to generate a fault feature vector set; inputting the fault feature vector set into a physically constrained LSTM-GAN hybrid prediction model, and predicting a multi-dimensional failure probability tensor of the key relay protection node in a future preset duration; generating an optimal operation and maintenance strategy decision tree based on the multi-dimensional failure probability tensor; and analyzing the operation and maintenance strategy decision tree through a remote execution gateway driven by the digital twinborn, and synchronously updating the topological connection relationship of the digital twinborn bodies of the power station. According to the embodiment of the invention, the operation and maintenance efficiency and reliability of photovoltaic power station protection can be improved.

Owner:ZHEJIANG YULONG ELECTRIC POWER DESIGN CO LTD
Double-arm robot autonomous control system and method based on remote operation and visual features
The invention discloses a double-arm robot autonomous control system and method based on teleoperation and visual features. The system comprises a teleoperation acquisition module, a multi-view visual perception module, a data synchronization and demonstration acquisition module, a strategy model training module, an autonomous strategy execution module, a track deviation detection and takeover module and a hybrid control interface module. Human demonstration is completed through teleoperation, multi-modal information of images, tracks, clamping jaws and muscle activation is collected, perception features are fused by adopting multi-view space-time alignment and a cross-view attention mechanism, strategy learning is completed in combination with an end-to-end large model, and in the autonomous operation stage, the multi-view space-time alignment and the cross-view attention mechanism are combined with the end-to-end large model. The risk of current operation is predicted and evaluated through track deviation detection and collision probability, the autonomous control proportion is dynamically adjusted, manual intervention is allowed when necessary, the safety and stability of the whole system are improved, the robot control mode of seamless switching between man-machine cooperation and autonomous and teleoperation is achieved, and the method is suitable for object control tasks in complex and highly variable environments.

Owner:ZHEJIANG SHENCHEN KAIDONG TECHNOLOGY CO LTD
Multi-terminal mixed intelligent inspection and task scheduling method and system based on air-ground-person cooperation
PendingCN121254869AVehicle position/course/altitude controlPosition/direction controlPathPingEngineering
The invention discloses a multi-terminal mixed intelligent inspection and task scheduling method and system based on air-ground-person cooperation. The method comprises the following steps: constructing dynamic unknown environment active cognition; updating dynamic unknown environment active cognition; the candidate path segments are evaluated through a path cost evaluation function, path reachability judgment is performed based on a cost value, and an exploration guide item is introduced to actively guide an inspection carrier to enter an unknown area to realize synchronization of task execution and map expansion; in combination with semantic task description, real-time states of multiple inspection carriers and an updated global environment model, task dynamic allocation and path collaborative optimization are performed, and the emergency, execution efficiency and resource utilization rate of inspection tasks of multiple terminals are balanced; the operation state and environment cognitive quality of each inspection carrier are monitored in real time, and an MR teleoperation intervention mechanism is automatically triggered when it is detected that continuous planning fails, sensing confidence is lowered or a key unknown area is entered; projecting a global environment model, real-time sensing data and a planned path to an operator MR device in an immersive manner, guiding by an operator through gestures, gazing or voice, and finishing path correction or task redistribution by adopting a progressive sharing control strategy and fusing with a manual instruction and autonomous planning; a successful MR intervention process of an operator and a context environment thereof are recorded in a context memory library, and when a similar task or environment scene is encountered subsequently, a verified guide strategy or control parameter is actively recommended.

Owner:ZHEJIANG UNIV OF TECH
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
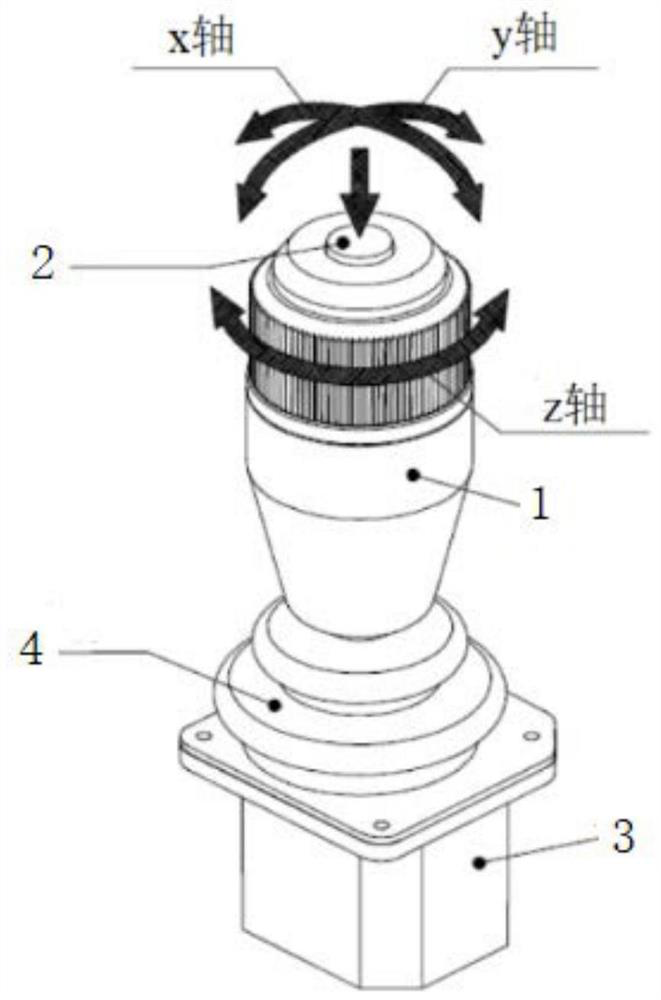
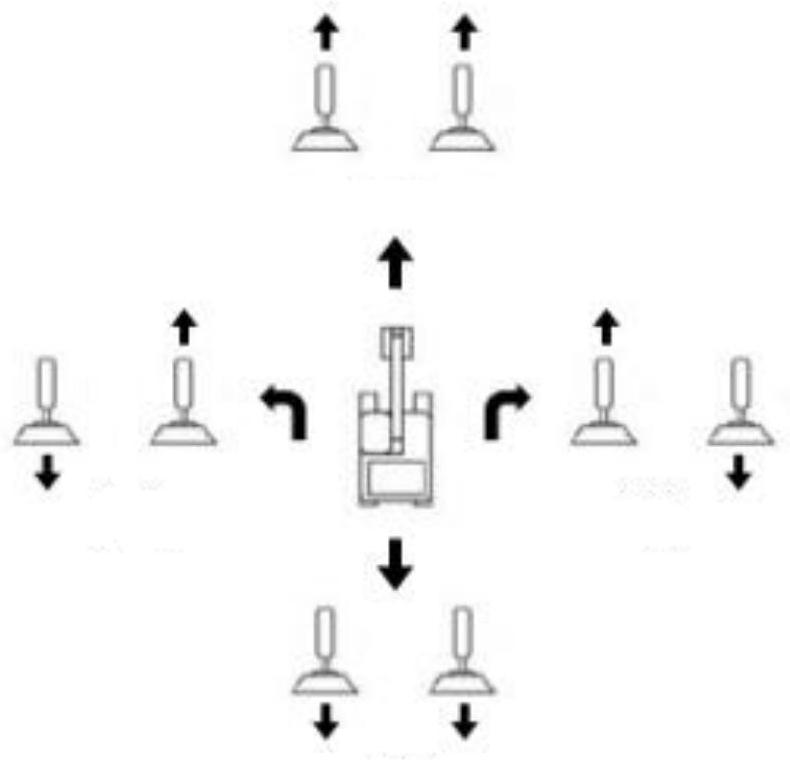
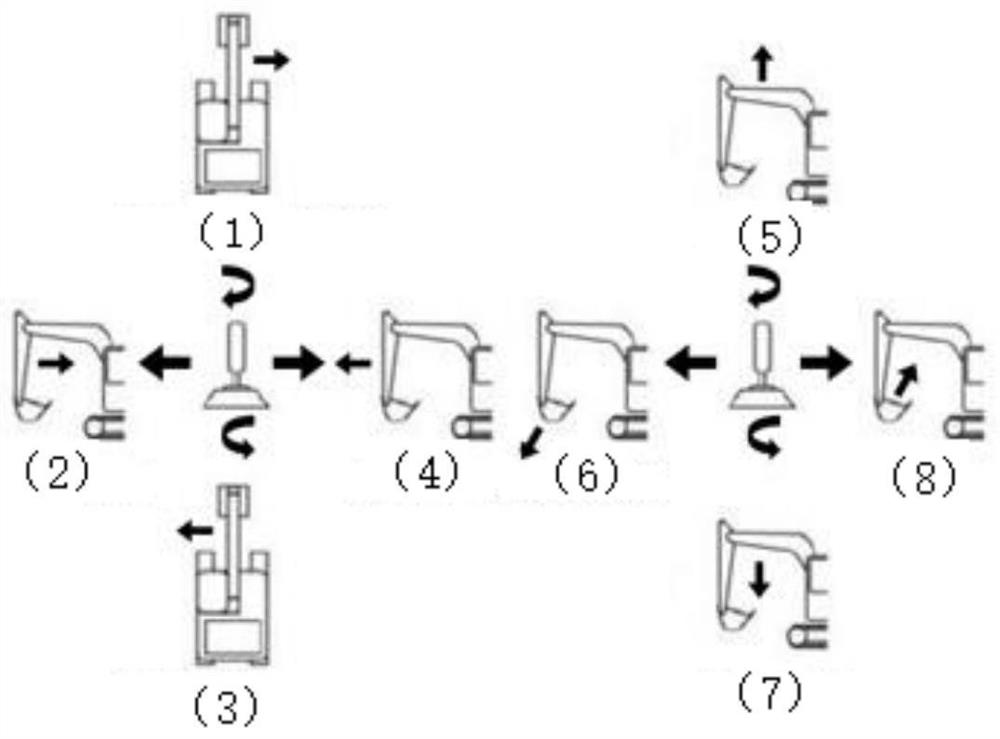
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Iron phosphate preparation energy-saving control system based on energy consumption scheduling model
PendingCN120806436AChemical processes analysis/designCheminformatics programming languagesControl systemOptimal scheduling
The invention belongs to the technical field of iron phosphate preparation, and discloses an energy-saving control system for iron phosphate preparation based on an energy consumption scheduling model. The system is composed of a data acquisition module, an energy consumption sensing module, a preparation process modeling module, an energy consumption prediction module, an energy-saving scheduling module, an intelligent execution module, a feedback correction module, a man-machine interaction module and a remote operation and maintenance module. The energy consumption sensing module intelligently senses an energy consumption state, the preparation process modeling and energy consumption prediction module accurately predicts energy consumption, the energy-saving scheduling module generates an optimal scheduling strategy, the intelligent execution module accurately executes an instruction, and the feedback correction module realizes closed-loop adaptive regulation and control; all the modules cooperatively operate, process parameters are adjusted in real time according to actual working conditions of iron phosphate preparation, energy consumption in the preparation process is remarkably reduced, the energy utilization rate is increased, and energy-saving optimization of iron phosphate preparation is achieved.

Owner:GUANGDONG JULISHENG INTELLIGENT TECH CO LTD
Charging pile remote operation and maintenance system based on Internet of Things
The invention discloses a charging pile remote operation and maintenance system based on the Internet of Things, and the system comprises a data collection and edge calculation module which is used for collecting multi-mode operation data of a charging pile, and generating standardized operation data; the health degree dynamic evaluation module is used for executing multi-modal feature coupling analysis on the standardized operation data; the fault root cause analysis module is used for starting a time-space coupled fault root cause analysis process to obtain a root cause confidence score and a high-risk component; the self-healing strategy execution module is used for generating a self-healing strategy of the charging pile; the resource dynamic scheduling module is used for realizing dynamic optimal distribution of operation and maintenance resources according to the health degree score and the geographic position; the intelligent operation and maintenance management module is used for updating the weight of the dynamic pruning random forest model and generating a hierarchical maintenance report; and the data full-process control module is used for completing automatic closed-loop management from data acquisition to operation and maintenance decision. According to the invention, remote intelligent diagnosis and self-healing operation and maintenance of the charging pile can be realized.

Owner:山东赢迅数字技术有限公司
Power cable comprehensive on-line monitoring system
The invention provides a power cable comprehensive online monitoring system, and relates to the technical field of data processing, and the system comprises the steps: extracting a partial discharge distribution point set in a multi-dimensional feature fusion data set, and calculating the weight factor of each distribution point; based on the weight factors, a weighted point set concave packet generation algorithm is adopted to construct a partial discharge source probability distribution boundary, and a boundary feature point set is obtained; inputting the boundary feature point set and the multi-dimensional feature fusion data set into a convolution-long and short-term memory hybrid neural network to generate a diagnosis result; and a third-level early warning signal is generated based on a diagnosis result, early warning information is pushed to a remote operation and maintenance terminal and a mobile APP through an MQTT protocol, a digital work order service is automatically triggered to generate a maintenance task, and positioning verification is executed. According to the invention, the accuracy of monitoring and fault diagnosis is improved.

Owner:XIAMEN ANRUIXIANG TECH CO LTD
Remote operation and maintenance system and method for power equipment based on digital twinborn technology
PendingCN120566686AMathematical modelsData processing applicationsElectric power systemData acquisition
The invention relates to the technical field of intelligent monitoring and operation and maintenance of power equipment, and discloses a remote operation and maintenance system and method for power equipment based on a digital twinborn technology, and the system comprises a data collection module, a digital twinborn modeling module, a state monitoring and diagnosis module, and an operation and maintenance decision module. The data acquisition module adopts a distributed grid architecture and optimizes sensor sampling by using a PPO algorithm; the digital twin modeling module fuses RLC voltage and a simplified heat dissipation equation, and model parameters are corrected through scaled Kalman filtering and aging factors; the state monitoring and diagnosis module realizes fault early warning based on multi-threshold detection and a Bayesian network; the operation and maintenance decision module adopts a genetic algorithm to generate an optimization operation and maintenance instruction; the method comprises the steps of adjusting parameters, updating a model, triggering calculation, sending a dimensional instruction and correcting model parameters. According to the invention, full-process intelligent management of power equipment is realized, the operation and maintenance cost is optimized, and stable operation of a power system is guaranteed.

Owner:LIGUNA TECH (GUANGZHOU) CO LTD
Automated storage and retrieval system and a method of transporting storage containers between an automated storage and retrieval grid and a second location
An automated storage and retrieval system includes an automated storage and retrieval grid and a delivery system. The automated storage and retrieval grid includes a container handling vehicle rail system and a delivery column. The container handling vehicle rail system is for guiding a plurality of container handling vehicles. The delivery column is adapted for transport of a storage container from a container handling vehicle to a delivery port situated at a lower end of the delivery column, and further adapted for transport of a storage container from the delivery port to the container handling vehicle. The storage container is configured to be stored in a stack of storage containers beneath the container handling vehicle rail system. The delivery system includes a remotely operated delivery vehicle, which includes a container carrier adapted to support the storage container. The delivery vehicle is further adapted to transport the storage container between a delivery port and a second location for handling of the storage container by at least one of a robotic operator and a human operator.

Owner:AUTOSTORE TECH AS
Robot teleoperation method and robot
The invention provides a robot teleoperation method and a robot. The robot teleoperation method comprises the steps that an acceleration command, an angular acceleration command and an expected attitude quaternion of an end effector are determined based on the current linear acceleration, the current angular acceleration and the current attitude quaternion of a control end; the current position and the current speed fed back by the end effector are obtained, a torque control signal for controlling the position of the end effector is determined based on the acceleration command, the current position and the current speed, and end acceleration feedforward is obtained; determining a torque control signal for controlling the attitude of the end effector based on the angular acceleration command and the expected attitude quaternion to obtain attitude feedforward; and a joint torque instruction of a mechanical arm joint corresponding to the end effector is determined based on the end acceleration feedforward and the posture feedforward, and the joint torque instruction is sent to a corresponding joint driver so that the end effector can synchronously act along with the control end. According to the invention, the problem of attitude lag of the end effector can be avoided, and the tracking error of the end effector is reduced.

Owner:JIANGSU CELL WALL INTELLIGENT TECH CO LTD
Remote operation and maintenance method, system and equipment for wide-area substation automation equipment
The invention relates to the technical field of power system automation, discloses a remote operation and maintenance method, system and equipment for wide-area substation automation equipment, and aims to solve the problems of data islanding, inaccurate diagnosis, strategy stiffness, low safety cooperation efficiency and the like in remote operation and maintenance of the wide-area substation automation equipment. According to the method and the system, a comprehensive platform is constructed, and multi-source heterogeneous data acquisition, intelligent fusion analysis, fault diagnosis and prediction, adaptive strategy generation, security remote control and block chain evidence storage and collaborative operation and maintenance are integrated. The method can solve the problem of data islands, improve the diagnosis and prediction precision and timeliness, optimize the operation and maintenance strategy, prolong the service life of equipment, and enhance the remote operation and maintenance safety and cooperation efficiency.

Owner:INNER MONGOLIA ELECTRIC POWER (GRP) CO LTD ORDOS POWER SUPPLY BRANCH
Power grid node health index assessment method suitable for remote operation and maintenance
PendingCN120632734AInstrumentsInformation technology support systemDiagnostic modalitiesHealth index
The invention relates to the technical field of intelligent power grid operation and maintenance, and discloses a power grid node health index assessment method suitable for remote operation and maintenance, and the method comprises the steps: S1, carrying out the fusion collection of multi-source data; s2, dynamic weight self-adaptive distribution is carried out; s3, dynamically correcting the life reference; step S4, layered health index calculation; s5, health state decision making and visualization are carried out; the data weight is automatically adjusted according to the timeliness difference of high and low frequency data through a dynamic weight adaptive distribution mechanism, so that the problem of health score long-term distortion possibly caused by low frequency data updating lag is solved, key parameters can be monitored in real time through a real-time anomaly detection and response mechanism, a parameter overrun early warning threshold value is set, and the early warning accuracy is improved. When the key parameters continuously exceed the limit, an online diagnosis mode is triggered, the data sampling frequency is increased, it is ensured that abnormal conditions can be quickly found and processed, the ability of the system to deal with sudden faults is improved, and the fault risk is reduced.

Owner:SHENZHEN FRIENDCOM TECH DEV +1
Intelligent door lock system
PendingUS20250301323A1Particular environment based servicesNon-mechanical controlsData setEngineering
A system provides for locking or unlocking a lock at a door of an intelligent door lock system at a dwelling by a designated dwelling user. An intelligent door lock system includes a remotely operable lock at a dwelling accessible by a user and a server in communication with the intelligent door lock system. A user mobile device is in communication with the server. The user mobile device includes an App that provides for locking and / or unlocking of the lock of the intelligent door lock system. The user communicates with the server using the user's mobile device, and the server is configured to process the user crossings one or more geo-locations relative to the dwelling and create a data set that is stored in a database.

Owner:MASTER LOCK CO INC
Derrick type coiled tubing integrated sidetrack drilling operation device and operation method thereof
The derrick type continuous oil pipe integrated sidetrack drilling operation device is provided with a base, a derrick, an injection head installation support, an injection head, a lifting oil cylinder, a hydraulic clamp and a remote operation room, one side of the derrick is fully opened, the derrick and the base are both of a lightweight rigid structure, and the injection head is installed at the top of the derrick for remote control. After the base is arranged at a wellhead and is unfolded and installed, one side of the base is connected with the lifting oil cylinder, the other side of the base is in butt joint with the ramp and the pipe rack, the derrick is rapidly erected through the lifting oil cylinder, and after the injection head is hoisted to the top of the derrick, the injection head is rapidly installed and subjected to alignment adjustment through the injection head installation support and the adjusting structure. Meanwhile, the tool rod and the elevator are arranged at the injection head, the tool rod is pulled and placed through the injection head, an oil pipe column and a sucker rod can be independently lifted or lowered, the oil pipe column and the sucker rod are pushed into a ramp from one side of an opening of a derrick, integrated sidetrack drilling operation of the coiled tubing is achieved, and sidetrack drilling efficiency and operation safety of the coiled tubing are remarkably improved.


Owner:CHINA PETROLEUM & CHEMICAL CORP +1
Remote power supply operation and maintenance virtual conference cooperation method and system and electronic equipment
The invention discloses a remote power supply operation and maintenance virtual conference cooperation method and system and electronic equipment, and particularly relates to the field of power operation and maintenance scheduling, and the method comprises the following steps: I, accessing various data of a power supply network, constructing a three-dimensional topology energy flow diagram in real time, and dynamically generating a security level matrix in combination with real-time equipment working conditions; iI, establishing a temporary operation authority tunnel, starting a virtual conference space, and automatically matching a most suitable interaction mode according to behaviors and intentions of participants; according to the method, the operation compliance and safety can be improved, key leakage and instruction tampering are effectively prevented, the encryption strength of remote operation is enhanced, permission abuse is prevented, the system toughness is improved, and safe closed-loop management from access to execution is realized; the comprehensiveness and timeliness of state monitoring of the power supply network are effectively improved, more accurate abnormal event identification can be realized, the problem positioning efficiency is improved, and a user is ensured to preferentially acquire the most reliable and most representative abnormal propagation chain.

Owner:DONGYING CITY DONGYING DISTRICT POWER SUPPLY CO STATE GRID SHANDONG ELECTRIC POWER CO
Bridge erecting machine structure health intelligent management system and intelligent management method thereof
The invention discloses a bridge girder erection machine structure health intelligent management system and an intelligent management method thereof. The system comprises a state data acquisition unit, a data preprocessing module, a structure state modeling module, a state prediction and residual life estimation module, an early warning and control module, a self-learning and optimization module and a system integration module. The method comprises sensor deployment, data preprocessing, structural state modeling, state prediction and residual life estimation, early warning and control, self-learning and optimization and system integration. Structural state monitoring data are collected in real time through a sensor, a structural state model is constructed after preprocessing, a future state is predicted in combination with time sequence prediction and a mechanism model, and the remaining safe life and risk points are estimated. And the system triggers multi-stage early warning according to a prediction result, executes an active maintenance control strategy, and continuously improves a prediction model through a self-learning and optimization module. According to the invention, real-time health management, remote operation and full-life-cycle risk control of the bridge girder erection machine structure can be realized.


Owner:GUANGXI NEW DEV TRANSPORT GRP CO LTD
Improved connection method, connection system and radio-controlled vehicle
PendingUS20250268117A1Agricultural machinesMechanical machines/dredgersRemotely operated vehicleElectrical and Electronics engineering
The present invention is related to a method for coupling an attachment to a radio-controlled vehicle by means of a connection system having a support, an attachment-holder unit and a coupling unit. The support is fixed to a radio-controlled vehicle and the attachment-holder unit is fixed to the attachment. The coupling unit is automatically operable, in particular it is remotely operable, without the direct intervention of an operator to selectively connect or disconnect the support and the attachment-holder unit to / from each other.

Owner:MDB SRL
Automatic driving hazard scene detection method and system, electronic equipment and vehicle
PendingCN121291485AParticular environment based servicesVehicle wireless communication serviceHazardEmbedded system
The invention provides an automatic driving hazard scene detection method and system, electronic equipment and a vehicle, and relates to the technical field of automatic driving. According to the method, a multi-dimensional hazard scene detection rule system is established, so that accurate identification and response to key security events are realized. In the automatic driving operation process, the system continuously collects and compares a vehicle state signal with a preset triggering condition in real time, once any hazard scene condition is met, vehicle burying point data in a preset time window are collected and uploaded to a cloud end, and the vehicle burying point data are stored in the cloud end. Accident scene restoration, system risk assessment and fault root cause analysis are carried out based on the collected data, then a targeted safety repair scheme is generated, vehicle software is remotely upgraded in an OTA mode, closed-loop processing of safety problems and continuous optimization of the system are achieved, the safety, traceability and remote operation and maintenance capacity of the automatic driving system are effectively improved, and the safety and reliability of the automatic driving system are improved. And the running safety of the vehicle is ensured.

Owner:CHINA FAW CO LTD
Binocular vision teleoperation robot system, robot and teleoperation method and device
The invention provides a binocular vision teleoperation robot system, a robot and a teleoperation method and device, and relates to the technical field of computers. The method comprises the following steps: receiving a binocular video stream obtained by carrying out image acquisition on an actual scene by a binocular vision robot, and rendering the binocular video stream to obtain a three-dimensional scene; displaying the three-dimensional scene to an operator of the binocular vision robot to capture motion data of the operator observing the three-dimensional scene; determining a target area from the actual scene according to the action data, and obtaining a visual control instruction based on the target area; the vision control instruction is transmitted to the binocular vision robot for teleoperation; wherein the visual control instruction is used for adjusting imaging parameters of the binocular vision robot for image acquisition of an actual scene, and the visual direction of the binocular vision robot can be rapidly and naturally kept consistent with the attention point of the operator.

Owner:BEIJING ACAD OF ARTIFICIAL INTELLLIGENCE
Fixed pollution source automatic monitoring method and system and digital intelligent construction method thereof
The invention relates to the technical field of pollution source monitoring, in particular to a stationary pollution source automatic monitoring method and system and a digital intelligent construction method thereof. S2, in a real-time monitoring stage, a multi-dimensional sensing array collects equipment health degree data and working condition parameters at high frequency, and a data collection device inputs real-time data into the ternary coupling reference model; s3, starting deviation traceability, and correcting equipment drift or working condition interference; s4, synchronously uploading the data to a remote operation and maintenance platform, pre-judging an equipment fault risk based on an equipment health degree change rate, and generating a maintenance work order 48 hours in advance; s5, for the predictive maintenance work order; and S6, automatically iterating the model monthly, incorporating the current-month effective monitoring data and maintenance records into the ternary coupling reference model, and optimizing the association weight. The method effectively guarantees the accuracy of the monitoring data of the stationary pollution source by constructing the ternary coupling reference model and combining the comparison and correction of the real-time monitoring data and the predicted value.

Owner:SHANDONG XIANGMING SHUZHI IOT TECH CO LTD
Photovoltaic module mismatch diagnosis system and method based on dual-mode thermal detection and AI dynamic optimization
PendingCN120567042APhotovoltaic monitoringData processing applicationsControl cellData analysis system
The invention discloses a photovoltaic module mismatch diagnosis system and method based on dual-mode thermal detection and AI dynamic optimization, and belongs to the technical field of fault detection of a photovoltaic power generation system.The photovoltaic module mismatch diagnosis system comprises a thermocouple sensor, an infrared thermal imaging module, a wireless data acquisition and transmission module, an AI intelligent data analysis system and a remote operation and maintenance management platform, and the inverter optimization control unit is respectively connected with the remote operation and maintenance management platform and the wireless data acquisition and transmission module. According to the invention, infrared thermal imaging large-range scanning and a surface ultra-thin flexible thermocouple sensor are combined, the temperature of key parts of the assembly is monitored in real time, and mismatch faults are accurately screened; adopting temperature gradient analysis, K-means clustering and a time sequence based on transfer learning to predict and recognize faults such as shadows, microcracks and poor welding, and performing remote early warning; mPPT parameters are dynamically adjusted based on a particle swarm algorithm, and power loss is reduced; the method improves the stability of a photovoltaic system, reduces the inspection cost, and is suitable for a large-scale power station and a distributed photovoltaic system.

Owner:YUNNAN NORMAL UNIV
Method and system for determining optimal parameters of X-ray excitation extra-high voltage composite apparatus
The invention discloses a method and a system for determining optimal parameters of an X-ray excited extra-high voltage composite apparatus, and relates to the technical field of extra-high voltage electrical equipment detection. The method comprises the following steps: remotely operating the X-ray machine and calculating partial discharge intensity; for the current irradiation position, the tube voltage and the tube current are gradually adjusted, parameters are dynamically optimized based on the quantitative relation between the partial discharge intensity and the radiation dose rate change rate, and the optimal parameters are recorded; and changing position repetition parameter optimization, and constructing a BP neural network model after data set training optimization so as to predict an optimal irradiation position. The optimized BP neural network adopts an improved sparrow search algorithm to optimize an initial weight and a threshold value, and combines Bayesian to optimize a learning rate and a hidden node number. Accurate optimization of excitation parameters and irradiation positions is achieved, detection accuracy and safety are both considered, the optimal irradiation position positioning efficiency is improved, and the method is suitable for ultra-high voltage GIS detection of different voltage grades.

Owner:NANCHANG POWER SUPPLY BRANCH OF STATE GRID JIANGXI ELECTRIC POWER CO LTD +4
Intelligent remote operation and maintenance method and system of security and protection monitoring system
The invention relates to the technical field of intelligent operation and maintenance, and discloses an intelligent remote operation and maintenance method and system for a security and protection monitoring system, and the method comprises the steps: carrying out the time sequence feature extraction of the equipment state data, alarm event data and instruction execution track data of security and protection monitoring equipment, and obtaining a time sequence dependence relation matrix; performing integrity check and priority classification to obtain a hierarchical annular cache queue; executing instruction state tracking and life cycle monitoring based on an operation and maintenance instruction of the security and protection monitoring equipment to obtain an instruction execution state tracking table, and performing adaptive retransmission based on a network connection quality parameter to obtain a dynamic scheduling parameter; according to the method, accurate delivery of the operation and maintenance instruction and reliable feedback of the execution result can be ensured, and the reliability and safety of remote operation and maintenance of the security and protection monitoring system are improved.

Owner:SHENZHEN BINGYITONG INFORMATION TECHNOLOGY CO LTD
Industrial equipment remote operation and maintenance management method and system based on digital twinning
The invention discloses an industrial equipment remote operation and maintenance management method based on digital twinning, and aims to solve the problems of deduplication, association and suppression of events and alarms and root cause fusion positioning under complex working conditions. According to the method, a multi-relation layered signed causal graph is constructed, a dynamic causal mask is generated according to a twinning state, causal structure learning is carried out under constraint, and graph anti-fact intervention and simulation of physical budget constraint and historical dual-channel consistency verification are combined; and the root cause priority and the evidence chain are generated by adopting topology perception contribution degree sorting, and the suppression strategy parameters are formed, so that the technical effects of reducing false alarms and repeated alarms, improving the root cause identification accuracy and processing efficiency and stably outputting the linkage work order are realized.

Owner:SHENZHEN ZHONGWEIER TECHNOLOGY CO LTD
Robot remote operation and maintenance task scheduling and optimizing method based on artificial intelligence
The invention discloses a robot remote operation and maintenance task scheduling and optimization method based on artificial intelligence, and the method comprises the following steps: collecting data, executing data cleaning, formatting and feature extraction, and forming a standardized feature vector set; constructing a state space, an action space and a reward function; the method comprises the following steps of: inputting an improved Distributional SAC (Software Consensus Consensus) task scheduling model; constructing a task demand matrix and a robot state matrix; generating a plurality of subtask sets, and establishing a high-level scheduling strategy according to task priority weights; in the low-layer execution network, a subtask strategy network is trained, and an action instruction set is generated to control the robot to execute tasks; updating strategy parameters based on environment feedback; establishing a self-adaptive hierarchy switching mechanism; and a hierarchical parameter updating mechanism is adopted to complete task scheduling and optimization. The improved reinforcement learning model is adopted, intelligent scheduling of robot operation and maintenance tasks is achieved, and the method has the advantages of being efficient, self-adaptive and high in stability.


Owner:GUANGDONG ENG POLYTECHNIC COLLEGE
High and low voltage power distribution cabinet remote operation and maintenance management and control system based on cloud computing
The invention provides a high and low voltage power distribution cabinet remote operation and maintenance management and control system based on cloud computing, relates to the field of remote operation and maintenance management, and improves the accuracy and operation and maintenance efficiency of power distribution cabinet fault early warning. The method comprises the following steps: firstly, acquiring sensing data through an edge intelligent sensing module, performing multi-dimensional correlation analysis based on a static safety threshold, identifying an abnormal trend with spatial-temporal correlation, and generating a preliminary early warning; then, a cloud platform prediction decision module drives the digital twin model to carry out dynamic simulation, and a predictive maintenance strategy and a dynamic safety threshold are generated in combination with a prediction algorithm of a historical performance decline curve; and finally, the adaptive control execution module optimizes subsequent analysis by using a dynamic threshold value, and triggers a differential control action from monitoring adjustment to emergency isolation according to a strategy type. According to the invention, by constructing the closed-loop intelligent operation and maintenance architecture of cloud-side cooperation, the operation and maintenance mode transformation from passive response to active prediction is realized, and the reliability and safety of the operation of the power distribution system are significantly improved.

Owner:QIN-HUANG ISLAND CITY-LONGDING ELECTRICAL LTD CO
Real-time interactive visualization system and method based on digital twinning
The invention relates to the technical field of digital twinning, in particular to a real-time interactive visualization system and method based on digital twinning, and the system comprises a data collection module which is used for configuring a multi-protocol adapter deployed on a physical equipment layer to collect the operation data of physical equipment, and transmitting the operation data of the physical equipment to an edge computing node. According to the method, the general data adapter is used for driving the three-dimensional rendering engine to execute real-time rendering based on physics, so that the virtual scene can dynamically reflect details such as illumination change and material aging of a physical entity, and high-fidelity visual feedback is provided. According to the method, a closed-loop control mechanism is established in combination with a multi-modal interaction framework, pure data monitoring is converted into operable bidirectional interaction, operation of a user on a visual interface can be converted into feedback instructions in real time to reversely adjust physical equipment, and the response efficiency of remote operation and maintenance is improved.

Owner:ZHEJIANG TIANNENG NEW ENERGY CO LTD
Display system
ActiveUS12401767B2Detection of traffic movementCharacter and pattern recognitionCamera imageComputer graphics (images)
A display system includes: one or more moving body cameras that capture one or more images in front of a moving body; one or more intersection cameras; a display device including one or more screens that display, as one or more images for remote operation of the moving body, one or more moving-body camera images; and one or more processors. The one or more processors are configured to: execute a determination process of determining whether or not a moving object is included in an intersection camera image by analyzing the intersection camera image; and execute a highlighting process of applying a highlighting to the one or more moving-body camera images when the moving object is included in the intersection camera image. The highlighting indicates whether the moving object is present in a left or right direction with respect to a traveling direction of the moving body.

Owner:TOYOTA JIDOSHA KK
Cross-domain maintenance decision-making method for coordinated optimization of maintenance service outlets, activities, and resources
The present invention relates to the technical field of avionics equipment, and disclosed is a cross-domain maintenance decision-making method for coordinated optimization of maintenance service outlets, activities, and resources. The method comprises the steps of: on the basis of a fault phenomenon, acquiring a set of a variety of maintenance activities; determining whether resources required for a faulty product are missing at a current service outlet, and if the resources are missing, separately computing a resource scheduling time and cost required for each maintenance activity for which resources are missing; computing a fault repair time, repair costs, and repair probability of a certain maintenance activity; and determining a goal of a maintenance decision, and outputting an optimal maintenance scheme. The present invention can assist technicians in making maintenance decisions during maintenance of electronic products, reduce the waste of time and resources caused by the inconsistencies and uncertainties of maintenance activities, guide maintenance activities of remote operation and maintenance, reduce maintenance time, and reduce operation and maintenance costs.

Owner:10TH RES INST OF CETC
Preparation method of flexible electromagnetic shielding type force sensor based on coaxial structure
PendingCN120992070AElectroconductive/antistatic filament manufactureMagnetic/electric field screeningFiberHuman–machine interface
The invention discloses a preparation method of a flexible electromagnetic shielding type force sensor based on a coaxial structure, and belongs to the field of flexible electronics and intelligent sensors. According to the method, a coaxial wet spinning process is adopted, a core-sheath structure conductive fiber is constructed, a core layer is made of a multi-walled carbon nanotube (CNT) and thermoplastic polyurethane (TPU) composite material, and a sheath layer is made of a nickel-coated carbon nanotube (Ni-CNT) and TPU composite material. By regulating and controlling the proportion of the core sheath, the construction of the gradient conductive network is realized, and the sensing sensitivity, the electromagnetic shielding performance and the mechanical flexibility are improved. The obtained Ni-CNT-coated CNT fiber is made into fabric and integrated in a sensing glove, and multi-finger bending detection and wireless man-machine interaction control are achieved. The sensor has the advantages of high sensitivity, wide strain detection range and excellent electromagnetic shielding effectiveness, is suitable for the fields of intelligent wearing, anti-interference man-machine interface and fire-fighting equipment, and can also be expanded to complex application scenes such as aerospace teleoperation.

Owner:邵一前