
Patents
Literature
367results about "Reference line/planes/sectors" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Error compensation method of birefringence self-calibration laser level meter
ActiveCN120890483APyrometry using electric radation detectorsReference line/planes/sectorsRefractive indexEngineering
The invention relates to an error compensation method of a birefringence self-calibration laser level meter, in particular to the field of laser level meters, and aims to improve the precision of the laser level meter by combining a birefringence effect, physical modeling and neural network optimization. Firstly, temperature data are collected in real time, Kalman filtering is used for noise reduction, and accurate data are provided for physical modeling; then, through physical constraints such as a heat conduction equation and a Jones matrix, a coupling relation between the temperature gradient and optical parameter changes is established; then, dynamically optimizing the refractive index correction by using a physical information neural network to avoid an overfitting problem; and finally, calculating optical path difference compensation by using a hardware accelerator, correcting a system error in real time, and feeding back and adjusting a network weight. According to the method, the precision and the stability of the laser level meter in an environment with relatively large temperature change are effectively improved.

Owner:NANTONG SIWOQI ELECTRONIC TECH CO LTD
Marking and/or leveling device
InactiveCN101836076AAdjustment manualReference line/planes/sectorsOptical elementsLight sourceEngineering
The invention relates to a marking and / or leveling device (1) comprising a light source (4) disposed on a pendulum (3) that can pivot relative to a housing (2). According to the invention, means are provided for accelerating (9) the pendulum (3) and / or a pendulum bearing (8) in a pulsing manner.
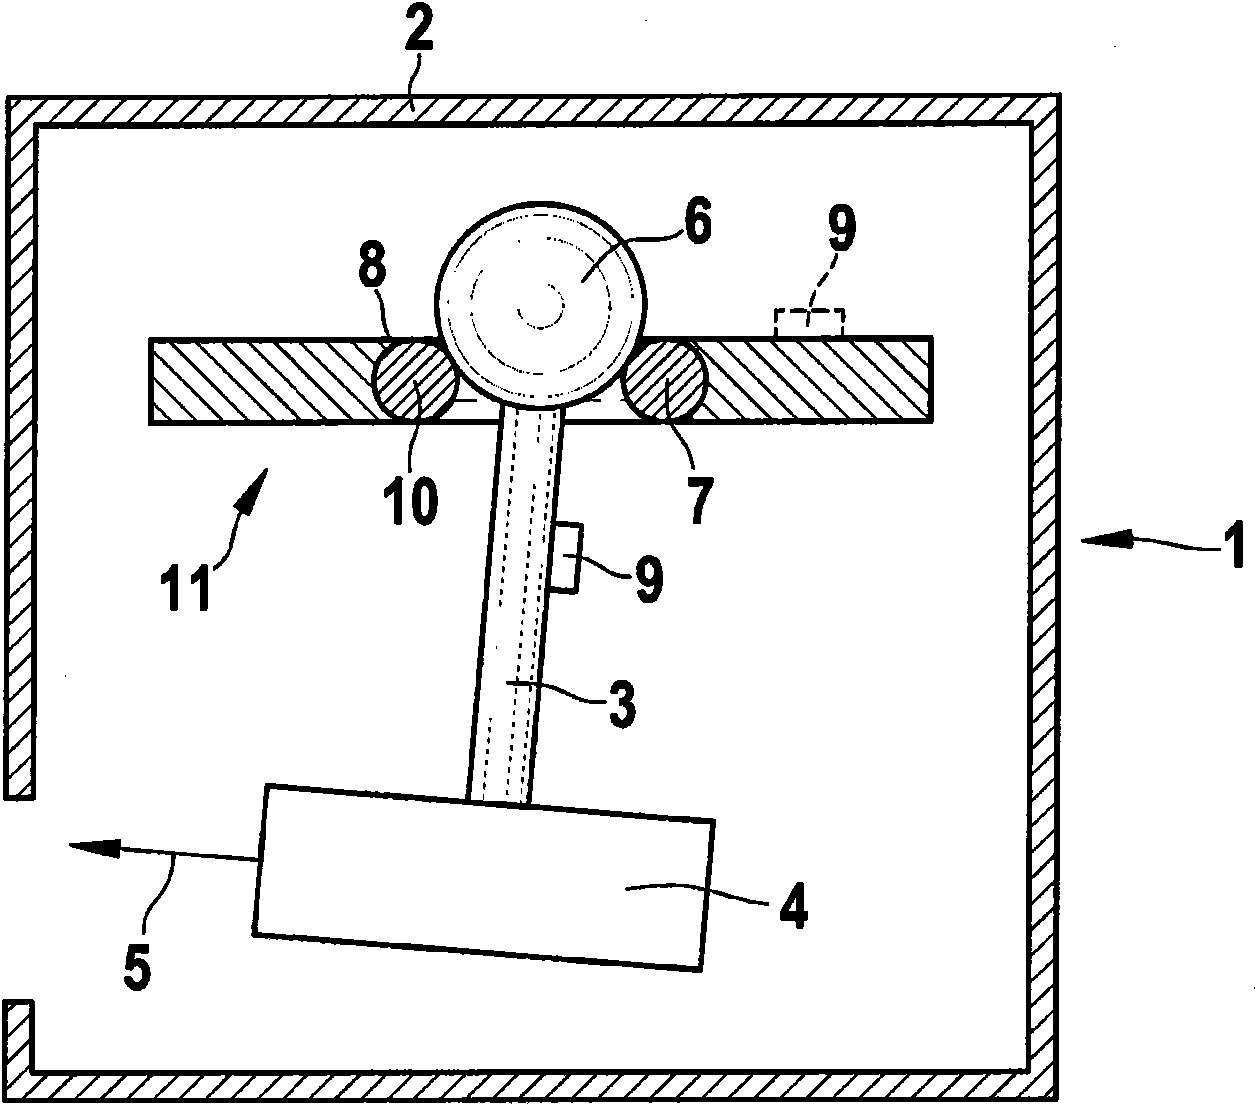
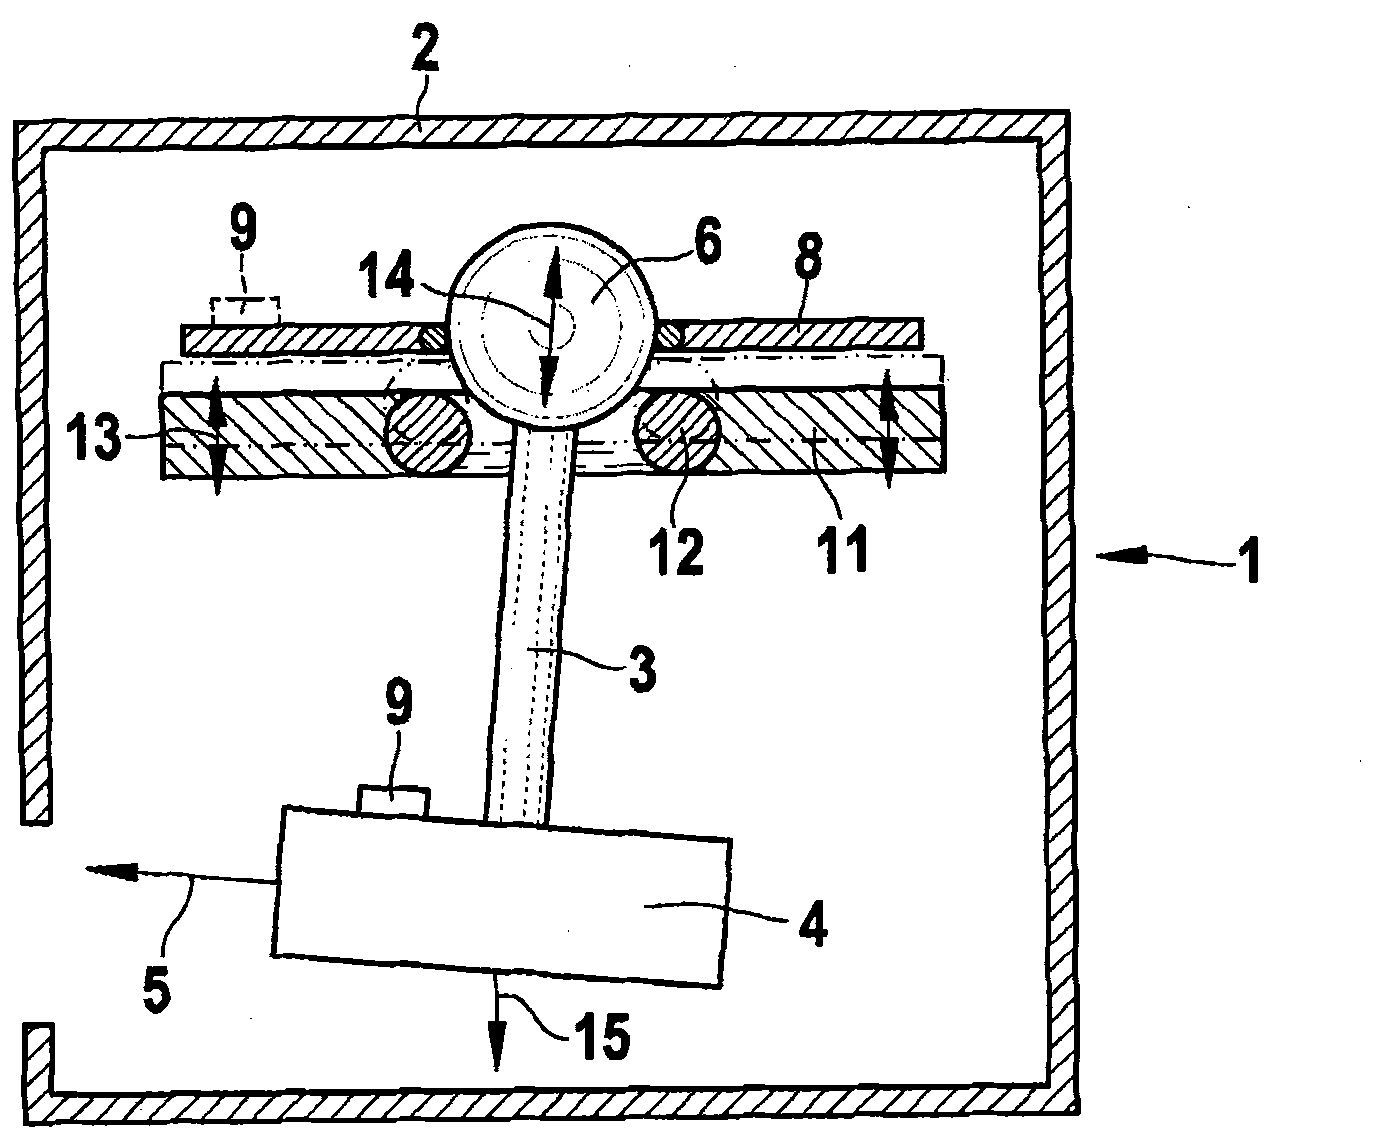
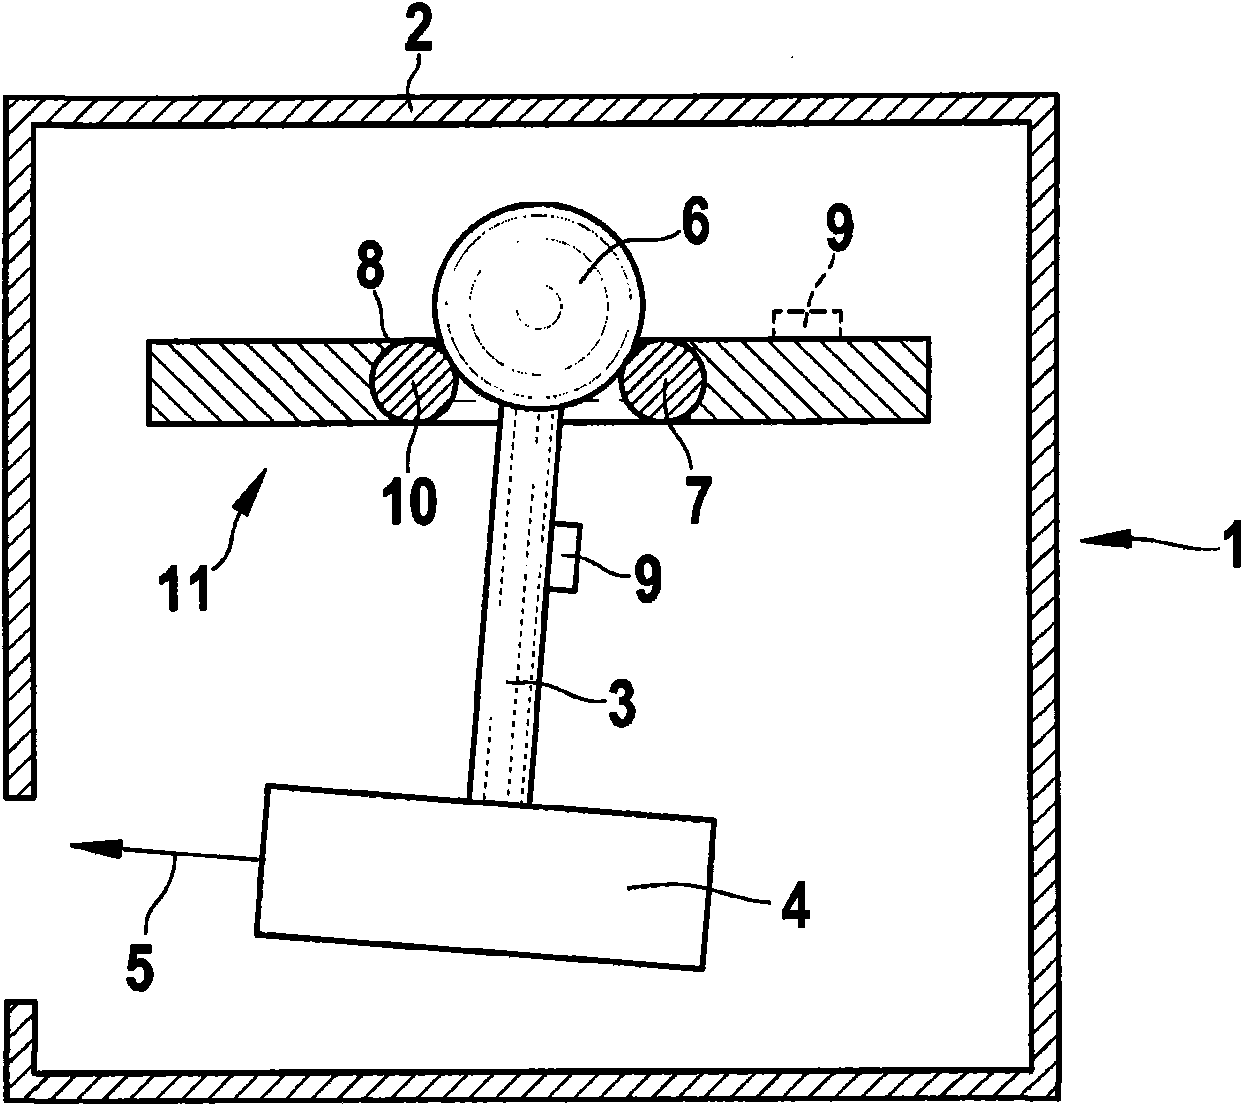
Owner:ROBERT BOSCH GMBH
Aligning scans of an environment using a reference object
An example method includes receiving a first plurality of coordinate measurement points capturing a portion of an environment and a reference object within the environment, the first plurality of coordinate measurement points defining at least a portion of a first point cloud. The method further includes receiving a second plurality of coordinate measurement points from a position other than the at least one aerial position, the second plurality of coordinate measurement points capturing at least some of the portion of the environment and the reference object within the environment, the second plurality of coordinate measurement points defining at least a portion of a second point cloud. The method further includes aligning the first point cloud and the second point cloud based at least in part on the reference object captured in the first point cloud and the reference object captured the second point cloud to generate a combined point cloud.

Owner:FARO TECHNOLOGIES INC
Vacuum adsorber
A vacuum adsorber includes a housing having an accommodating cavity and an opening communicating with the accommodating cavity; an integrated vacuum pump arranged inside the accommodating cavity; a control panel arranged inside the accommodating cavity and controllably connected with the integrated vacuum pump; wherein the control panel is controllably connected with a photoelectric switch; a power-up assembly having a guide piece and a shading movement portion; and an activating piece covering inside the opening of the housing. By means of setting the activating piece to push the shading movement portion to move in the movement cavity, when the shading movement portion moves to block beams, it causes the state of beams to change, and then voltage inside the photoelectric switch changes; when the control panel detects a change in voltage, it controls the pump to start operating; thereby improving the stability and reliability during starting the pump.

Owner:YANG GUIXIANG
Laser level meter supporting structure
InactiveCN120969671ASpringsSprings/dampers design characteristicsStructural engineeringLaser Powder Bed Fusion
The invention discloses a laser level meter supporting structure, and belongs to the technical field of laser level meters, the laser level meter supporting structure comprises a supporting seat, the top of the supporting seat is provided with a plurality of fixing clamps, the outer side of the supporting seat is hinged with a plurality of supporting frames, and the outer edge of the top of the supporting seat is fixedly provided with an annular folding air bag; an inflation inlet is formed in the bottom of the annular folding air bag; the sealing plate is connected into the supporting seat in a sliding and sealing mode, a plurality of compression springs are fixedly connected to the bottom of the sealing plate, and the bottom ends of the compression springs are fixedly connected to the inner wall of the bottom of the supporting seat; and the triggering mechanism comprises a shot, a rotating disc, four push plates and four clamping bases, and an iron block is fixedly installed at the top of the shot. Through the arranged triggering mechanism, the supporting frame can be controlled to be opened outwards to improve the supporting stability when the laser gradienter vibrates or inclines greatly, the air bag is inflated, the laser gradienter is protected, and the use safety is improved.

Owner:NANTONG KAIRUI LASER TECH CO LTD
System and method for enabling mixed reality on mobile devices in a construction site
PendingUS20250224231A1Measuring points markingPicture reproducers using projection devicesMixed realityComputer graphics (images)
A system for registering position and orientation (P&O) of mobile devices relative to a construction site may include: a light projector; at least one sensor configured to record at least one set of XYZ coordinates of at least one specific surface, and a set of XYZ coordinates of the light projector within the construction site; and a computer processor, wherein the light projector is configured to project the XYZ coordinates of the at least one set of position markers onto the at least one specific surface; and wherein the projection of the XYZ coordinates of the at least one set of position markers is detectable by at least one sensor located at a mobile device, allowing registration of XYZ coordinates of a virtual reality interface of the mobile device relative to the projection of the position markers onto the at least one specific surface.

Owner:LIGHTYX SYST LTD
Pole tower foundation automatic pit dividing device and method based on laser point cloud
The invention discloses an automatic tower foundation pit dividing device and method based on laser point cloud, relates to the technical field of tower foundation pit dividing of power transmission line mechanical construction, and solves the problems that existing power transmission line tower foundation pit dividing is low in automation degree, low in operation efficiency, low in manual operation precision and prone to generating pit dividing errors. Comprising a tripod and an equipment holder installed at the top of the tripod, a box body is arranged above the equipment holder, the box body is in butt joint with the equipment holder through a holder connecting piece, a laser radar is arranged on the inner side of the box body, and a top cover is installed at the top of the box body; the device further comprises a pit separating mechanism used for enabling the laser radar to automatically and efficiently separate pits, and the pit separating mechanism is installed on the inner side of the box body. Through the pit separation mechanism, automatic pit separation, design guidance, foundation acceptance and foundation bolt verification of the transmission tower foundation can be achieved, and therefore the effect of automatic and efficient pit separation is achieved.

Owner:YICHANG ELECTRIC POWER SURVEY & DESIGN INST
Power transmission line tower body assembly positioning and hoisting attitude control method in desert environment
The invention provides a power transmission line tower body assembly positioning and hoisting attitude control method in a desert environment, and relates to the technical field of power transmission engineering construction, and the method comprises the steps: obtaining power transmission line tower body structure parameters and desert environment parameters, the desert environment parameters comprise geological conditions, wind speed and wind direction; establishing a laser positioning reference system, wherein the laser positioning reference system comprises three laser emitting devices with angle and distance sensors; the tower body sections are assembled and positioned, space coordinates are established through laser marking projection, and the positions are corrected through a self-adaptive algorithm; installing an inertial measurement unit; establishing a hoisting attitude control system which comprises a main arm crane, an auxiliary crane and a tensioning device; in the hoisting process, the center-of-gravity offset is calculated based on the attitude data, and each device is controlled to realize attitude stabilization; and finally, curing materials are injected into the tower body foundation to complete installation.

Owner:CHINA ENERGY CO LTD
Laser level mounting device
Various laser mount designs are shown. The laser mount includes a body, a movable laser platform and a connection mechanism to clamp onto a surface and / or object. The connection mechanism includes a retention plate, a threaded rod, guide rods, a pair of connection jaws or clamps and a clamp adjustment screw knob configured to move both connection jaws. The connection jaws are designed to clamp onto a variety of surface shapes and material sizes.

Owner:MILWAUKEE ELECTRIC TOOL CORP
Combination tool
The present invention discloses a combination tool including a housing defining an internal cavity, in which a laser module and a level assembly are provided. The laser module is configured to produce spot-shaped laser light and / or linear laser light. The level assembly is configured to indicate a degree of levelness. The combination tool may further include a rangefinding module and a detection module, which provide the functions of rangefinding, detecting a wood / metal component, or the like.

Owner:HANGZHOU GREAT STAR IND CO LTD
Laser level target posts
ActiveUS12399003B2Height/levelling measurementReference line/planes/sectorsLight beamMechanical engineering
In one example, a laser level target post for leveling a server cabinet is disclosed. The laser level target post includes an elongated body section and a reflective surface at a top end of the elongated body section. The top end reflective surface is to reflect a received light beam for leveling a top surface of the server cabinet. The laser level target post also includes a magnetic base at a bottom end of the elongated body section. The magnetic base may attach the laser level target post to a corner of the top surface of the server cabinet.

Owner:JPMORGAN CHASE BANK NA
Laser and laser receiver
A laser level system includes a laser level configured to project a laser beam and a laser detector configured to detect the laser beam projected by the laser level. The laser detector includes at least one array of photo detector configured to detect the laser beam. The laser level and laser detector are configured to wirelessly communicate. The laser level and the laser detector are configured to selectively operate in a beam find mode. The laser level is configured to perform sweeps in the beam find mode to locate the laser beam on the at least one array of photo detectors.

Owner:STANLEY BLACK & DECKER INC
Combination tool
PCT designated stageWO2025208654A1Using mechanical meansIncline measurementSpirit levelMaterials science
Disclosed in the present invention is a combination tool, comprising a shell, wherein a cavity is formed in the shell, a laser module and a spirit level assembly are arranged in the cavity, the laser module is configured to generate point laser and / or line laser, and the spirit level assembly is configured to indicate whether a surface is level. The combination tool can further comprise a ranging module and a detection module to achieve functions such as range finding and wooden- / metal-part detection.

Owner:HANGZHOU GREAT STAR IND CO LTD
Laser level with internal adjustable platform
A laser level emits one or more planar lasers that can be self-leveled via one or more internal leveling systems. The motors bias a platform to rotate the laser emitters to a targeted orientation, such as via the motors collectively rotating the laser emitters in response to instructions to rotate with respect to one or more axes.

Owner:MILWAUKEE ELECTRIC TOOL CORP
Line laser
Line laser, comprising a self-levelling platform with laser beam sources arranged thereon, lenses for converting the laser beams, a power supply and control unit and a fastening unit for a tripod, characterized in that the laser beam sources, which serve to project reference axes, are combined in a radiation module which is provided with a housing and in which a power supply and control unit is additionally accommodated, wherein the self-levelling platform, the power supply and control unit and the fastening unit for a tripod are integrated in a fastening module with a housing, wherein the housing of the radiation module and the housing of the fastening module are designed to be connectable.

Owner:CONDTROL GMBH
Laser pocket level multi-axis micro adjust
ActiveUS12613094B2Incline measurementReference line/planes/sectorsLaser transmitterMechanical engineering
A laser level includes a housing having a laser emitter to emit a laser along a plane. The laser level includes a mounting base connected to the housing. The housing is pivotable relative to the mounting base about three axes by a user grasping the housing and moving the housing. The housing includes a first micro-adjustment knob to adjust the housing, relative to the mounting base, about a fourth axis. The housing includes a second micro-adjustment knob to adjust the housing, relative to the mounting base, about a fifth axis perpendicular to the fourth axis.

Owner:KLEIN TOOLS INC
Building wall perpendicularity measuring device
PendingCN120760691AIncline measurementReference line/planes/sectorsLaser transmitterMeasurement device
The invention relates to the technical field of wall perpendicularity measurement, and provides a building wall perpendicularity measuring device, which comprises a mounting seat fixed at the top of a to-be-measured wall through a detachable connecting structure; the leveling platform is mounted on the mounting seat, the leveling platform comprises a guide pipe and a base, the guide pipe is mounted at the bottom of the leveling platform, and the base is mounted at the bottom end of the guide pipe; and the laser transmitter is coaxially arranged in the guide tube. When the device is used, the second power source drives the second winding wheel to wind and unwind the traction rope and drives the movable sleeve to vertically move along the guide pipe, so that the distance measuring assembly can automatically cover the full-height detection range from the top to the bottom of the wall, manual climbing or segmented measurement is not needed, the manual operation intensity is reduced, and the device is particularly suitable for high-rise high-wall scenes, and meanwhile, the detection efficiency is improved. Detection points at different heights can be accurately positioned through automatic lifting control, and the measurement efficiency is improved.

Owner:HONGYI CONSTR ENG CO LTD
Surveying target and method with distance power optimization
A target (100) for use in surveying applications is provided. The target comprises a plurality of light sources (106) arranged around a longitudinal axis (A) of a base element (108) of the target. The plurality of light sources is configured to emit light radially. The target further comprises a control unit (214). The control unit is configured to control an intensity of the light (440a, 440b) emitted by the plurality of light sources based on a distance (d1, d2) between the target and a surveying instrument (120) aimed towards the target.

Owner:TRIMBLE AB
Device for calibrating laser level
The present disclosure relates to a device for calibrating a laser level, including a base platform configured to support the laser level that is to be mounted at a first position of the base platform, a laser detector arranged at a second position of the base platform and configured to receive a laser, and an optical path extension device arranged at a third position between the laser level and the laser detector and configured to receive the laser emitted by the laser level and project the laser to the laser detector after the laser is adjusted by the optical path extension device. With the optical path extension device, a physical distance between the laser level and the laser detector can be optically extended.

Owner:NORTHWEST INSTRUMENTATION INC
Motorized Mounting Devices
Various motorized device designs with backlash detection systems are shown. In a specific embodiment, a motorized laser level mount includes a rotatable laser platform, a housing cover, a housing, a gear train and a backlash detection system. The backlash detection system coupled to the motor and the laser platform and configured to determine when backlash has been removed from the gear train.

Owner:MILWAUKEE ELECTRIC TOOL CORP
Method for automatically correcting and optimizing field path of watermelon and melon transplanting machine based on laser navigation
ActiveCN120871895ANavigation instrumentsVehicle position/course/altitude controlElectric machineryEngineering
The invention relates to the technical field of correction optimization, in particular to a watermelon and melon transplanting machine field path automatic correction optimization method based on laser navigation, which comprises the following steps: capturing a reference laser signal projected by a laser plane transmitter in real time through a laser receiver array; calculating a real-time pitch angle and a roll angle of the transplanting machine according to the irradiation position distribution of the reference laser signal in the receiver array; generating a calibration laser plane equation based on the real-time pitch angle and the roll angle; synchronously outputting transverse position deviation and course angle deviation; according to the coupling relation between the transverse position deviation and the course angle deviation, steering motor control quantity and advancing speed compensation quantity are generated in sections; the steering motor control quantity and the advancing speed compensation quantity are synchronously output to a steering servo system and a walking hydraulic system of the transplanting machine tool, and continuous deviation correction between ridges is achieved. According to the invention, by constructing the laser receiver array and the attitude calculation model, the pitch angle and the roll angle of the transplanting machine in the field operation process can be sensed in real time.

Owner:NANJING AGRI MECHANIZATION INST MIN OF AGRI +1
Positioning measurement device for pipe jacking construction
The invention relates to the field of angle measurement, in particular to a positioning measurement device for pipe jacking construction, which comprises a working well and a pipe body mounted on the lower part of the side surface of the working well in a penetrating manner, a turnover piece is mounted on the inner side surface of the working well, and the end part of the turnover piece is connected with a center frame; the axis of the center frame is aligned with the center point of one end of the pipe body, a centering frame is coaxially arranged at the other end of the interior of the pipe body, a plurality of inclined fixing frames are obliquely arranged on the outer side of the center frame in an annular array mode, the inclined fixing frames are attached to the inner edge of one end of the pipe body, and a plurality of wheel frames are arranged on the outer side of the centering frame in an annular array mode. And centering wheels are installed at the two ends of the wheel frame and attached to the inner wall of the pipe body, and a detection piece is installed at the end of the center frame. According to the invention, the detection convenience is improved, the device can adapt to pipe bodies with different diameters, the detection requirement is met, and meanwhile, the normal operation of pipe jacking construction operation is ensured.

Owner:JIANGXI CONSTR ENG (GRP) CO LTD +2
Laser system for generating a linear laser marking on a projection surface
A laser system (10) for generating a linear laser marking (38) on a projection surface (37), including: a laser beam source (11), which generates a laser beam (28) and emits it along a propagation direction (29), an offset device (16) having a first interface (21), at which a first deflection of the laser beam is effected, and a conical mirror (14), which is embodied as a right cone having a cone axis (15) and a reflective lateral surface (26), wherein the conical mirror (14) is arranged in the beam path of the laser beam downstream of the offset device (16). The offset device (16) is embodied as rotatable about an axis of rotation (17), wherein the axis of rotation is arranged coaxially with respect to the cone axis (15).

Owner:HILTI AG
Surveying system and method with a surveying device and a moveable target
A surveying system and methods with a surveying device, e.g., a total station, and a target, whereby the target can be tracked and surveyed by the surveying device. The target comprises at least one sensor for sensing a target motion and / or position. An uncertainty of a target position derived from the sensor data is determined and used for adaption of a target surveying and / or searching.

Owner:LEICA GEOSYSTEMS AG
Motorized mounting devices
Various motorized device designs with backlash detection systems are shown. In a specific embodiment, a motorized laser level mount includes a rotatable laser platform, a housing cover, a housing, a gear train and a backlash detection system. The backlash detection system coupled to the motor and the laser platform and configured to determine when backlash has been removed from the gear train.

Owner:MILWAUKEE ELECTRIC TOOL CORP
Mount for a Measuring Device
A mount for a measuring device, for example a laser level, includes a first mounting member having a first mounting surface that defines a first plane and includes at least one first magnet, a second mounting member having a second mounting surface that includes at least one second magnet, and a measuring device support configured to support the measuring device. The second mounting member has a first position at which the second mounting member extends on an opposite side of the first plane from the measuring device support and the first and second mounting surfaces are substantially perpendicular to one another.

Owner:ROBERT BOSCH GMBH
Surveying system and method with a surveying device and a moveable target
The invention relates to a surveying system and methods with a surveying device, e.g., a total station, and a target, whereby the target can be tracked and surveyed by the surveying device. The target comprises at least one sensor for sensing a target motion and / or position. An uncertainty of a target position derived from the sensor data is determined and used for adaption of a target surveying and / or searching.

Owner:LEICA GEOSYSTEMS AG
Device for calibrating laser level
ActiveUS12566063B2Using optical meansReference line/planes/sectorsTesting MethodsLaser Powder Bed Fusion
A device for calibrating a laser level includes a base platform, a target, and an image recognition device. The base platform is configured to support the laser level that is to be mounted on the base platform at a first position. The target is arranged at a second position of the base platform and configured to receive a laser. The image recognition device is configured to obtain images of lasers projected on the target before and after the laser level rotates a first angle, determine, based on an image recognition result of the images, positions of the lasers emitted by the laser level to determine a deviation distance, and determine whether the laser level needs to be calibrated based on the deviation distance. The deviation distance is determined by position data of the first position and the second position, and the first angle.

Owner:NORTHWEST INSTRUMENTATION INC
Geographic information collection and mapping device and mapping method
ActiveCN120521564BHeight/levelling measurementReference line/planes/sectorsLaser lightTesting Methods
The present invention discloses a geographic information collection and mapping device and a mapping method, which relate to the technical field of mapping device technology. The device comprises a level and a telescopic ruler, wherein a top fixed ruler is provided at the upper end of the telescopic ruler, and an auxiliary mechanism is provided on the upper surface of the top fixed ruler. The auxiliary mechanism comprises a drone assembly and a marking assembly. The drone assembly comprises a fuselage component, and the fuselage component comprises: a bottom hanging plate, a fixed notch is provided at the center of the bottom hanging plate, an auxiliary fixed slot matched with the fixed notch is provided at the upper end of the top fixed ruler, and the marking assembly comprises: an auxiliary laser light, the auxiliary laser light is located on one side of the bottom surface of the bottom hanging plate, and a small camera matched with the auxiliary laser light is provided on the upper surface of a support plate body located on the front of the drone. In this solution, by providing the auxiliary mechanism, the equipment can break through geographical restrictions, expand the mapping scope, and comprehensively improve the efficiency, accuracy and adaptability of geographic information collection and mapping.

Owner:JINAN SURVEYING & MAPPING RES INST
Combination tool
The invention discloses a combination tool which comprises a shell, a cavity is formed in the shell, the cavity is provided with a laser module and a horizontal assembly, the laser module is configured to generate spot laser light and / or linear laser light, and the horizontal assembly is configured to indicate the horizontal condition. The combined tool can further comprise a distance measuring module and a detecting module, and the functions of distance measuring, wood / metal part detecting and the like are achieved.

Owner:HANGZHOU GREAT STAR IND CO LTD