

Patents
Literature
215 results about "Shortest distance" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Radar device
InactiveUS20060238404A1Accurately measure distanceAccurate distance measurementRadiating element housingsRadio wave reradiation/reflectionReflected wavesRadar
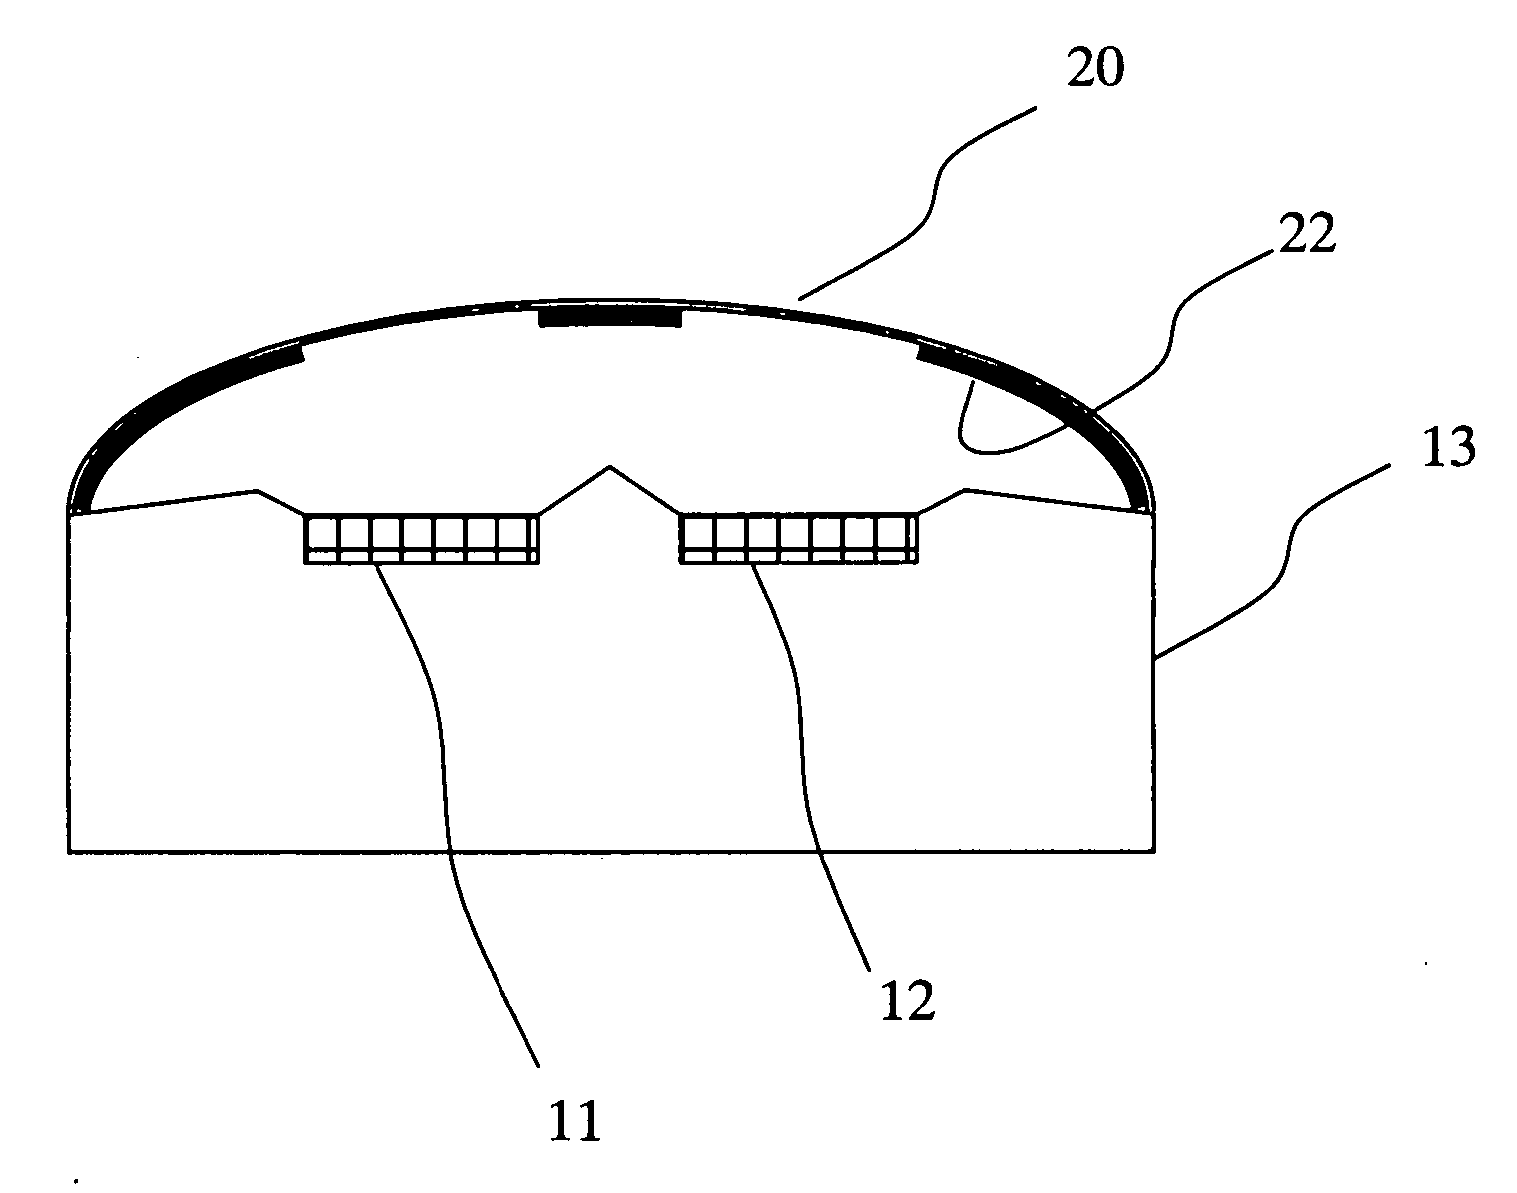
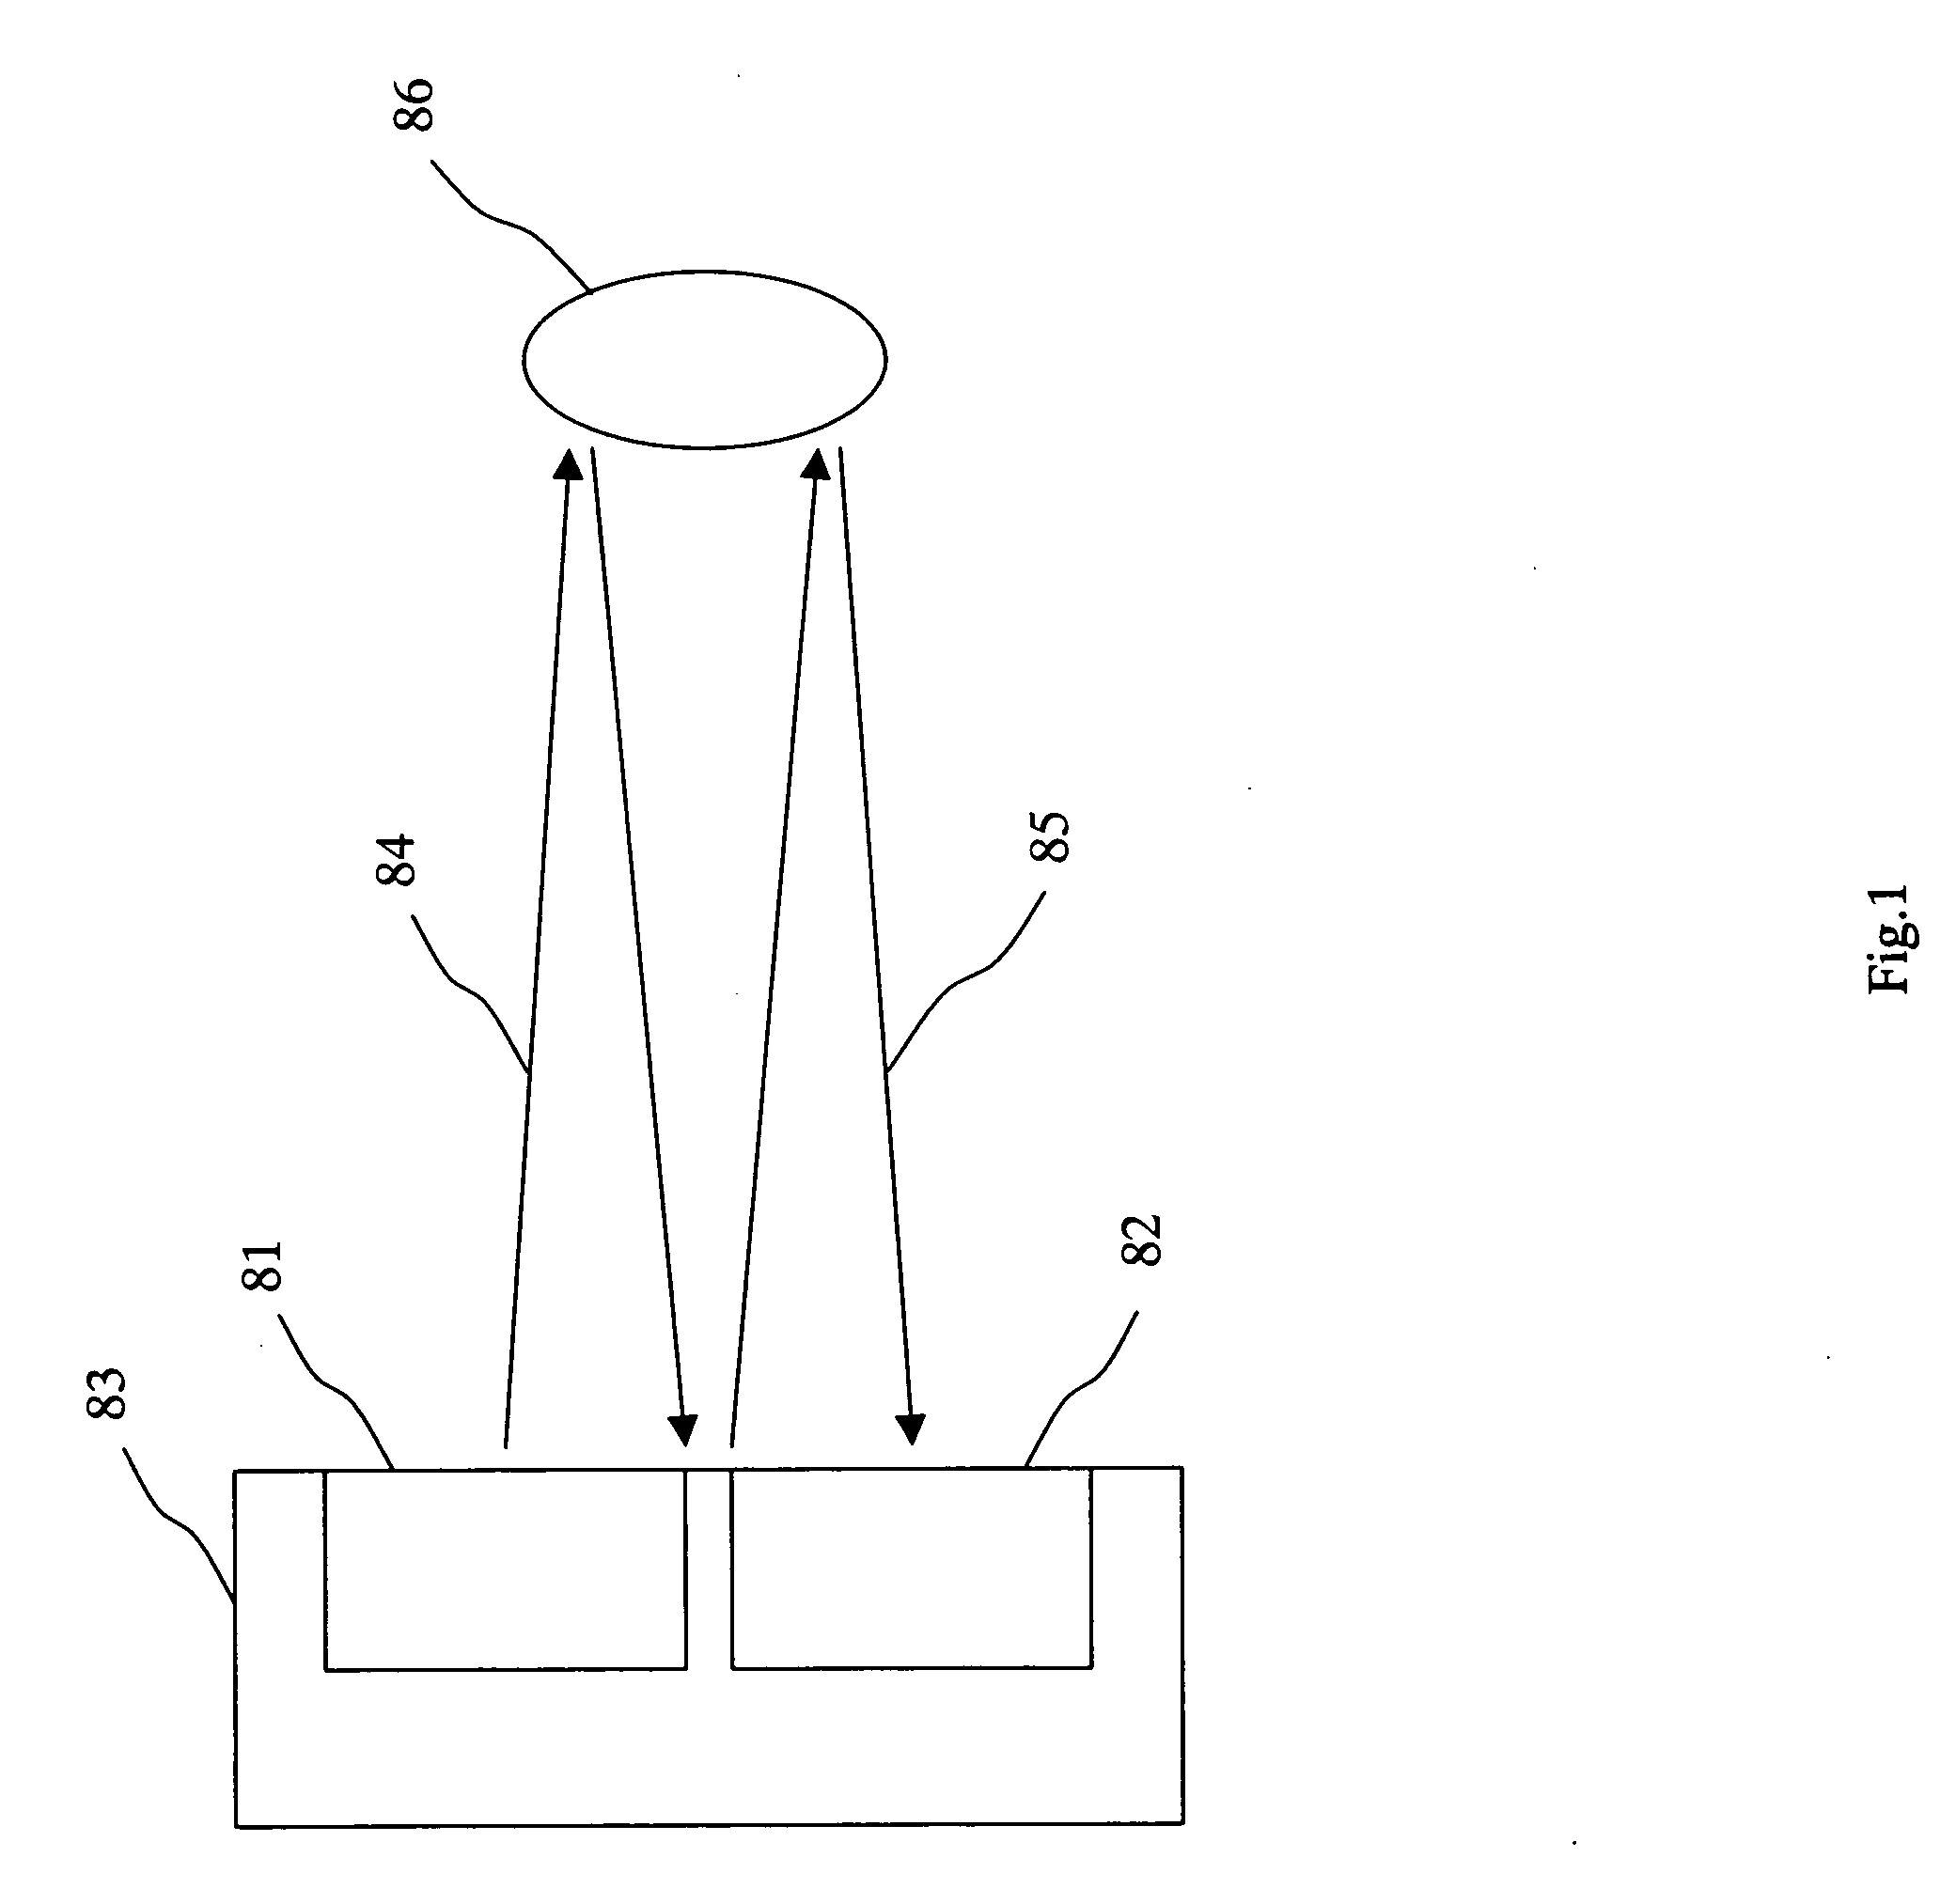
A radar device which is installed in a vehicle or the like needs to detect a target at a short distance from several tens of centimeters to several tens of meters and, therefore, has a problem that a reflected wave from the target may be reflected by a front case of the radar device and then reflected by the target again to be received as a secondary echo by itself. To solve this problem, it is an object of the present invention to provide a radar device again that can prevent multi-reflection to accurately measure a distance to a target in a short range. In a radar device according to the present invention, a surface of a frame body provided around a transmitting antenna and a receiving antenna is shaped so that a reflected wave from a target may not be returned in a direction in which a transmitting wave is transmitted from the transmitting antenna.
Owner:TDK CORPARATION
Dual-arm cooperative potential field-based force-guided teleoperation system and control method
PCT designated stageWO2025179629A1Programme-controlled manipulatorProgramme controlRobotic armShortest distance
A dual-arm cooperative potential field-based force-guided teleoperation system and control method. By means of real-time poses of tool center points of two robotic arms, whether the shortest distances dp-s,i between a target object and workspace boundaries of the two arms are lower than a threshold Ds is iteratively determined; if the shortest distances are both greater than the threshold, a dual-arm symmetric cooperation strategy is adopted, and if the shortest distances are lower than the threshold, a single-arm prioritized cooperation strategy is adopted, and the arm is used as a priority arm; cooperation factors δi of the two arms are respectively determined on the basis of the cooperation strategies; a dual-arm cooperative potential field is constructed on the basis of the cooperation factors, the distances between the target object and the tool center points of the two arms, and the position of an obstacle; and corresponding dynamic virtual constraint forces are generated on the basis of the dual-arm cooperative potential field, and two force feedback hand controllers are used to guide and assist an operator in controlling the two robotic arms to complete a dual-arm cooperative task.

Owner:SOUTHEAST UNIV
Force guidance telerobotic system and control method based on dual-arm collaborative potential field
Disclosed are a force guidance telerobotic system and control method based on a dual-arm collaborative potential field. A real-time pose of a tool center point of each of the two robotic arms is obtained using a robotic arm kinematic model, and checking is performed to determine whether a shortest distance dp-s,i between a target object and a workspace boundary of each of the two robotic arms is lower than a threshold Ds; a dual-arm symmetric collaboration strategy will be adopted when higher than the threshold; a single-arm primary collaboration strategy will be adopted when lower than the threshold; and a coordination factor δi of each of the robotic arms is determined according to the collaboration strategy; the dual-arm collaborative potential field is constructed according to the collaboration factor, a distance between the target object and the tool center point and a position of obstacle.

Owner:SOUTHEAST UNIV
Method and apparatus to symmetrize a mesh cross-reference to related application
A method performed by encoder comprises partitioning a mesh into a first side and a second side; determining, for a first vertex located on the first side, whether a first perpendicular line extending from the first vertex intersects with two or more surfaces of the mesh on the second side, each intersection of the first perpendicular line corresponding to an intersected vertex on the second side; based on the determination the first perpendicular line intersects with two or more surfaces of the mesh on the second side, selecting one of the intersected vertices on the second side as a second vertex corresponding to the first vertex based on a shortest distance between each intersected vertex and a predicted vertex on the second side that is symmetric to the first vertex; and generating a new connection in the mesh.

Owner:TENCENT AMERICA LLC
Path planning method of positioning robot based on SG heat transfer tube detection
PendingCN120178855AVehicle position/course/altitude controlPosition/direction controlShortest distanceSimulation
The invention belongs to the technical field of path planning in navigation, and particularly relates to a path planning method of a positioning robot based on SG heat transfer tube detection. Inputting a heat transfer tube panel environment matrix A, a robot starting center point S and a detection point E; performing position transformation on the detection point E of the specific area which cannot be reached; determining coordinates of a central point and four feet at the detection point El under different postures; according to the pre-path and the posture of the robot at the E0, the starting point and the posture of each section are reversely deduced, and the feasibility of walking in the pre-path by using the postures is judged; if so, storing the path and state data; otherwise, searching ferry points with as few turning points as possible and as short distance as possible, and giving paths and postures of all sections before and after the ferry points; and performing repeated point elimination on the key point data and attitude of each path, and storing the simplified key point data and attitude. According to the invention, the planned path has few turning points, the state change frequency of the positioning robot is few, and the positioning robot can realize rapid displacement from the initial position to the detection point.

Owner:CHINA NUCLEAR POWER OPERATION TECH CORP +1
Path determination method and apparatus, device and computer storage medium
PCT designated stage expiredWO2025118778A1Vehicle position/course/altitude controlPosition/direction controlPathPingPath length
A path determination method and apparatus, a device and a computer storage medium. The path determination method comprises: acquiring trajectory information and the sprinkling path length of a sprinkler, the trajectory information comprising information of paths that have been sprinkled and the sprinkling frequency of the paths that have been sprinkled (S110); selecting, from preset paths, a preset number of paths having a small sprinkling frequency, so as to obtain first paths (S120); selecting second paths having the shortest distance from the position of the sprinkler to starting points of the first paths, and using the first paths and the second paths as third paths (S130); selecting the third paths of which the path length is not greater than the sprinkling path length, so as to obtain fourth paths (S140); using a first path length weight, a first sprinkling frequency weight, the path length of the fourth paths, and the sprinkling frequency of the first paths to calculate a first weighted average of the fourth paths (S150); and determining a fourth path having a minimum first weighted average as a target path (S160). In this way, the situation that there is a path not sprinkled is avoided, all paths in an area are comprehensively covered, and water resources are saved.

Owner:CHINA MOBILE M2M +1
Osteotomy plane boundary control method, electronic equipment and storage medium
The invention discloses an osteotomy plane boundary control method, electronic equipment and a storage medium, and the method comprises the steps: calculating the distance from the center point of an osteotomy pendulum saw to a boundary connecting line of an osteotomy plane, selecting the inward vectors of two edges with the shortest distance, carrying out the weighted summation, taking the weighted summation as a search direction, and carrying out the step-by-step search; the method comprises the following steps of: quickly searching a safe position which is closest to the boundary of a plane position (conforming to the expected movement direction and posture) and is positioned in the boundary of the plane position, and subsequently issuing the safe position to a mechanical arm to drive a surgical tool to move so as to accurately and safely help a doctor to realize osteotomy operation on a thighbone and a tibia. The technical problems that in the prior art, due to the fact that the motion range of an osteotomy swing saw is too large, soft tissue and ligament injuries are caused, and operation precision is reduced are solved.

Owner:BEIJING TINAVI MEDICAL TECH
Ejection type clamping jaw mechanism
The utility model belongs to the technical field of clamping jaw equipment, and particularly relates to an ejection type clamping jaw mechanism which solves the problems that the ejection type clamping jaw mechanism cannot stretch out and draw back, and objects cannot be grabbed at a short distance and a long distance. The ejection type clamping jaw mechanism comprises an ejection frame and a clamping jaw seat, a grabbing assembly is arranged on the clamping jaw seat, the clamping jaw seat is slidably connected to the ejection frame through a sliding structure and has an extending position and a retracting position, and an ejection structure enabling the clamping jaw seat to tend to move towards the extending position is arranged between the clamping jaw seat and the ejection frame. And the limiting release structure is used for limiting or allowing the clamping jaw seat on the retraction position to move. According to the mechanism, the grabbing assembly and a corresponding structure used for stretching and retracting are combined, the effect that objects are grabbed in a short distance and a long distance through stretching and retracting is achieved, the structure is simple, and operation is convenient.

Owner:ZHEJIANG SCI-TECH UNIV
Low-computing-power dynamic obstacle avoidance method based on single 2D laser radar data
PendingCN121209491AVehicle position/course/altitude controlPosition/direction controlPathPingPath length
The invention discloses a low-computing-power dynamic obstacle avoidance method based on single 2D laser radar data. The method comprises the following steps: 1, collecting and preprocessing laser radar data; 2, modeling an obstacle in the environment, converting the laser point cloud data into the position and shape of the obstacle, performing local path planning with the minimum path width through an incremental local path planning algorithm, dynamically adjusting the local path according to the real-time laser point cloud data, and obtaining the position and shape of the obstacle; only calculating a path through which the equipment can pass through the obstacle and reach the end point at the current moment each time; and 3, defining a cost function considering the path length, the distance from the path point to the obstacle, the turning angle and the equipment size, obtaining the obstacle information according to the real-time laser point cloud data, calculating the shortest distance between the current path and the obstacle, and if the shortest distance is smaller than a safety threshold, adjusting the weight coefficient of the cost function, and locally optimizing the path. According to the method, the path planning performance under a low-computing-power platform is improved, and equipment can efficiently and dynamically avoid obstacles in real time.

Owner:NORTHWESTERN POLYTECHNICAL UNIV MING DE COLLEGE +1
Simulation device, simulation method, and simulation program
To provide a simulation device that can highly accurately perform an analysis of a flowing field including areas mutually separated by a wall, using a particle method.SOLUTION: A simulation condition is input to an input unit. A processing unit is configured to: represent a fluid body by a plurality of calculation particles on the basis of the simulation condition; numerically solve a dominant equation about each of the plurality of calculation particles; and subject a position and physical quantity of the plurality of calculation particles to a time evolution. Upon solving the dominant equation, other calculation particle arranged apart from a wall surface is excluded with respect to the calculation particle of interest. Information indicative of the shortest distance vector is calculated, which is defined by a length and direction of the shortest route to respective positions of the plurality of calculation particles from the wall surface. Using respective position vectors of two calculation particles, and the shortest distance vector with respect to each of the two calculation particles, a determination is made as to whether the two calculation particles are arranged mutually apart from the wall surface.SELECTED DRAWING: Figure 4

Owner:SUMITOMO HEAVY IND LTD
Memory and manufacturing method therefor, and electronic device
The present disclosure relates to the technical field of semiconductors, and particularly relates to a memory and a manufacturing method therefor, and an electronic device, which are used for reducing the parasitic capacitance of a memory. The memory comprises a substrate (1), a word line (WL) and a transistor (2). The word line (WL) extends in a direction perpendicular to the substrate (1). The transistor (2) comprises a semiconductor layer (21) at least partially surrounding the word line (WL) and a gate insulating layer (22) disposed between the word line (WL) and the semiconductor layer (21). The semiconductor layer (21) comprises a channel region (Q3) located on at least one side of the word line (WL) in a first direction, and two contact regions located on two sides of the word line (WL) in a second direction. The first direction and the second direction are both parallel to the substrate (1), and the first direction and the second direction intersect. The shortest distance from the channel region (Q3) to the word line (WL) is less than the shortest distance from at least one contact region to the word line (WL). The two contact regions comprise a first source / drain contact region (Q1) and a second source / drain contact region (Q2).

Owner:BEIJING SUPERSTRING ACAD OF MEMORY TECH
Navigation path planning method based on BOX algorithm
ActiveCN120831117AInstruments for road network navigationNavigational calculation instrumentsAlgorithmShortest distance
The invention relates to the technical field of algorithms, in particular to a BOX algorithm-based navigation path planning method, which comprises the following steps of: S1, generating a linear reference path from a starting point to an end point through a Bresenham algorithm, and ensuring the shortest distance potential of an initial path; s3, the shortest path is selected during obstacle avoidance, and obstacle avoidance redundancy is reduced; s4, dynamically adjusting a sliding mode by combining sliding optimization with path complexity, and furthest shortening the length of a free section on the premise of safety; s3, differential obstacle avoidance paths are generated according to the obstacle motion characteristics, for example, predictive oblique line bypassing is adopted for regularly moving obstacles to accurately avoid the obstacles, buffer space is reserved for irregularly moving obstacles, and the collision risk is reduced from the source; in the step S5, the constraint condition of the free section further ensures that the path conforms to the physical limitation of the mobile device, and mechanical failure or collision caused by unreasonable path design is avoided.


Owner:TIANJIN BONUO ZHICHUANG ROBOT TECH CO LTD +2
Device for detecting analyte in liquid sample
PendingCN120721711AAnalysis using chemical indicatorsMaterial analysis by observing effect on chemical indicatorShortest distanceTest region
The invention discloses a testing device which comprises a cavity used for receiving a liquid sample, a cover body, the cover body is used for sealing the cavity, the cover body further comprises a carrier with a groove, the carrier is used for receiving and holding a test strip, the cover body further comprises a hole, the hole is communicated with the groove, and the hole is communicated with the groove. The cover body is provided with a mark, the connecting line between the mark and the hole is the shortest distance, and when a test is carried out, the mark is set to indicate an inclined direction, so that a liquid sample is in contact with a test area of the test strip in the groove, and by adopting the device, the test can be rapidly carried out, the operation is simple and convenient, and the test efficiency is improved. And the test result is more accurate.

Owner:ZHEJIANG ORIENT GENE BIOTECH CO LTD
Game machine
To provide a game machine having features in presentation devices.SOLUTION: A first movable body and a second movable body are at least partially connected by a member. A shortest distance between a first part of the first movable body at a first position and a second part of the second movable body at a third position is equal to a shortest distance between the first part of the first movable body at a second position and a second part of the second movable body at a fourth position. The first movable body at the first position and the second movable body at the third position overlap display means with a first size, and the first movable body at the second position and the second movable body at the fourth position overlap the display means with a second size. The first size and the second size are the same size. When the first movable body is at the first position and when the first movable body is at the second position, the positional relations of the member with respect to the display means are the same. When the second movable body is at the third position and when the second movable body is at the fourth position, the positional relations of the member with respect to the display means are the same.SELECTED DRAWING: Figure 101

Owner:DAITO GIKEN CO LTD
Danger early warning method based on rapid calculation of distance between point and area on plane, medium and equipment
The invention provides a danger early warning method based on rapid calculation of the distance between a point and an area on a plane, a medium and equipment, and belongs to the technical field of cloud computing. The method comprises the following steps: firstly, outwards expanding a space with a specified threshold size for all areas; secondly, the minimum circumcircle is calculated for each expanded area, and the position of the circle center and the radius length are obtained; then, when the shortest distance between the target point and the multiple areas is calculated to be smaller than a threshold value or not, the distance between the target point and the circle center of all the minimum circumcircle can be compared firstly, and if the distance is larger than the radius of the minimum circumcircle, whether the target point is in the expanded area or not does not need to be calculated; and then, calculating whether the target point is in the expanded region or not to judge whether the distance between the target point and the region before expansion is smaller than a threshold value or not. According to the method, the complex calculation overhead is saved, and the calculation overhead can be further reduced by combining the information of the administrative region where the minimum circumcircle is located.

Owner:CHINA TELECOM DIGITAL INTELLIGENCE TECH CO LTD
Holding-up hammer grinding method
The invention relates to a holding-up hammer grinding method. A holding-up hammer grinding machining method comprises the following steps that S1, a sectional view of a holding-up hammer blank is drawn, and a sectional view of a holding-up hammer product is drawn; s2, placing the holding-up hammer product section drawing in the holding-up hammer blank section drawing, so that the distance between the top surface of the holding-up hammer product section drawing and the top surface of the holding-up hammer blank section drawing is greater than or equal to a first set distance, and the outer edge line of the holding-up hammer product section drawing does not coincide with the outer edge line of the holding-up hammer blank section; s3, measuring the distance between the corresponding line of each surface of the holding-up hammer product sectional view and the corresponding line of each surface of the holding-up hammer blank sectional view; s4, extending a line corresponding to the outer circular surface of the section drawing of the anvil product, drawing an auxiliary line perpendicular to a line corresponding to the bottom surface of the section drawing of the anvil product, and measuring the shortest distance between an intersection point and the auxiliary line; and S5, the anvil blank is machined according to the grinding machining amount obtained in the step S3 and the step S4. The method has the advantages that the production cost can be reduced, and the machining allowance is convenient to calculate.

Owner:ZHEJIANG HENGCHENG CEMENTED CARBIDE CO LTD
Encoding and decoding with merge mode and block partition index
An encoder determines, based on a width and a height of a block, whether or not to disable a prediction mode in which the block is split along a partitioning line defined by a distance and an angle and then prediction is performed; and encodes the block with the prediction mode disabled or not disabled according to a result of the determination on whether or not to disable the prediction mode. Here, the distance is the shortest distance between the center of the block and the partitioning line, and the angle is an angle representing a direction from the center of the block toward the partitioning line in the shortest distance. The encoder determines to disable the prediction mode when (i) a width-to-height ratio is at least 8 or (ii) a height-to-width ratio is at least 8.

Owner:PANASONIC INTELLECTUAL PROPERTY CORP OF AMERICA
Laser point cloud plane detection and distance measurement method, device, equipment and medium
The invention relates to the technical field of distance measurement, in particular to a laser point cloud plane detection and distance measurement method, device and equipment and a medium. And the automatic measurement of the underground tunnel wall distance is realized by using the laser radar. The measurement distance is the distance from the laser radar to the wall surface of the tunnel wall. The distance is equal to the plane distance from the viewpoint of the laser radar to the tunnel wall point set fitting, and is the shortest distance from the point to the plane. According to the strategy of the invention, the laser radar scans the tunnel wall area as much as possible, so that the area occupied by the tunnel wall area in the visual field of the laser radar is maximum. Then the vertical face with the largest area in the scene is obtained through the algorithm, and the distance between the vertical face and the laser radar is measured. And then, the least square method is adopted for plane fitting, so that the precision of plane extraction is improved, and the method is not influenced by outlier noise and is also not influenced by the unevenness and unevenness properties of the tunnel wall surface.

Owner:SHENZHEN UNIV
A method and apparatus for wire sawing
The application discloses a wire cutting machining method and device. The wire cutting machining method comprises the following steps: acquiring a current machining position of a workpiece to be machined, determining a geometric feature of the workpiece to be machined corresponding to the current machining position, wherein the geometric feature comprises a straight line feature and a circular arc feature; determining a target discharge gap corresponding to a cutting metal wire according to the geometric feature, wherein the target discharge gap is used to represent the shortest distance between the surface of the workpiece to be machined and the outer surface of the cutting metal wire; obtaining a current cutting offset of the cutting metal wire according to the target discharge gap and the cross-sectional radius of the cutting metal wire, wherein the current cutting offset is equal to the sum of the target discharge gap and the cross-sectional radius; and controlling the cutting metal wire to perform cutting machining according to the current cutting offset. The wire cutting machining method can significantly improve the machining precision and machining efficiency of small structural parts.


Owner:HUIZHOU ZHONGRUI INTELLIGENT EQUIP CO LTD
Improved steering of an antenna beam
The present disclosure relates to an antenna arrangement (200) comprising an antenna port (201) and a dielectric lens device (203). The antenna arrangement (200) comprises a first electrically conducting layer (204) that comprises a first aperture (205) and is separated from the dielectric lens device (203) by a shortest distance (dm) along a vertical extension (v) such that a cavity (206) is formed between the first electrically conducting layer (204) and the dielectric lens device (203), such that a leaky-wave feed is provided. The antenna port (201) is electrically connected to the first aperture (205), wherein the first electrically conducting layer (204) mainly lies in a plane (P) that is perpendicular to the vertical extension (v) and is movable in that plane (P).

Owner:TELEFONAKTIEBOLAGET LM ERICSSON (PUBL)
Automatic control method for excavator, excavator controller, excavator, and medium
The application provides an automatic control method of an excavator, an excavator controller, an excavator and a medium, and relates to the technical field of excavator control. The method comprises the following steps: acquiring a current work track corresponding to a first work cycle of the excavator; determining a relative position and a relative height between a starting point and an ending point of the current work track; determining a target work track with the shortest distance between the starting point and the ending point according to the relative position and the relative height of the current work track; determining a target speed proportion relationship between a swing speed of a swing arm and a lifting speed of the swing arm according to the target work track; determining an actual handle opening degree of an operation handle according to the target speed proportion relationship, and automatically controlling the excavator according to the actual handle opening degree. According to the method, the handle opening degree can be automatically adjusted according to an actual working condition, so that different working conditions can be automatically adapted, the operation difficulty of the excavator is reduced, and the working efficiency is improved.

Owner:SANY HEAVY MACHINERY
Transducer
PCT designated stage expiredWO2025022837A1Piezoelectric/electrostrictive resonant transducersVibrating membraneShortest distance
A transducer (1) comprises: a piezoelectric element (10) provided with a pair of electrodes (11, 12) and a piezoelectric film (13) sandwiched between the pair of electrodes (11, 12); a film support part (17); and a vibration film (16) supported by the film support part (17) so as to be able to vibrate in the thickness direction of the piezoelectric element (10). A plurality of openings (15) that continuously penetrate the vibration film (16) from the piezoelectric element (10) are provided, and the shortest distance between two points facing each other across the center of the opening (15) in each of the plurality of openings (15) is 20 μm or less.

Owner:ROHM CO LTD
Numerical controller and numerical control program
The irradiation position of the laser beam on the processing surface can be corrected together with the correction of the gap amount. A numerical controller controls a machine tool. The machine tool performs relative movement between the machining nozzle (72) and the workpiece (82), and performs laser machining on a machining surface (S) of the workpiece (82) by irradiating laser light from the machining nozzle (72) toward the machining surface (S). The numerical controller acquires a gap amount (G) that is the shortest distance from the machining nozzle (72) to the machining surface (S). The numerical controller calculates a normal direction (sZ) of the machining surface (S), and calculates a normal direction movement amount (V) for moving the machining nozzle (72) and the workpiece (82) relative to each other in the normal direction (sZ) so that the clearance amount (G) becomes a desired clearance amount (Go). The numerical controller corrects the clearance amount (G) to a desired clearance amount (Go) by relatively moving the machining nozzle (72) and the workpiece (82) in the normal direction (sZ) on the basis of the calculated normal direction movement amount (V).

Owner:FANUC LTD
Crucible for crystal growth and crystal growth equipment
The embodiment of the utility model provides a crucible for crystal growth and crystal growth equipment. On any section perpendicular to the axis of the crucible, the wall thickness of the crucible comprises a first wall thickness value and a second wall thickness value, the first wall thickness value is the maximum value of the wall thickness of the crucible, the second wall thickness value is the minimum value of the wall thickness of the crucible, and the first wall thickness value is different from the second wall thickness value. The crystal growth equipment comprises a seed crystal support crucible, the shortest distance between a seed crystal support and the inner wall of the crucible is between a first distance and a second distance, the first distance is the maximum value of the shortest distance, and the second distance is the minimum value of the shortest distance; the first distance is different from the second distance.

Owner:MEISHAN BOYA ADVANCED MATERIALS CO LTD
Work Machine Distance Predication and Action Control
A system and a method are disclosed for determining a range of potential distances between a work machine and an object. The system receives an image captured by a camera on the work machine and identifies an object in the image. The system determines an angle between the camera and the object, a height associated with the object, and an uncertainty associated with the height. Based on the angle, the height, and the uncertainty, the system determines a range of potential distances between the work machine and the object. The shortest distance in the range is compared to a threshold distance for safe operation of the work machine. When the shortest distance in the range is less than the threshold distance, the system causes the work machine to perform a safety action.

Owner:DEERE & CO
Grinding device, detection method, and grinding wheel
PendingJP2025081830ASemiconductor/solid-state device manufacturingGrinding feed controlShortest distanceElectric machinery
To provide a grinding device capable of detecting the wear of a grinding wheel with higher accuracy.SOLUTION: A grinding device includes: a grinding mechanism comprising a spindle to which a grinding wheel is mounted at its end, and a motor which rotates the spindle; a notification module; and a controller. On a first surface side of a wheel base of the grinding wheel, a member that has a shorter distance from the first surface to a tip of the member than that of a grinding stone is arranged. The controller performs processing of monitoring magnitude of a load applied to rotation of the spindle during grinding of a workpiece, and processing of causing the notification module to notify of such information when the magnitude of the load deviates from a reference range.SELECTED DRAWING: Figure 2

Owner:DISCO CORP
Drive device and method
Drive device (V), in particular a transport device of a container treatment plant (M), with at least one endless drive element (1) that can be driven to a movement and is subject to elongation during operation, wherein section markings (9, 9') and a start marking (10) are provided distributed along the drive element (1), wherein a encoder (C) generating displacement increments (16) synchronously with the movement of the drive element (1) and at least one stationary marker reader (AB) generating transmission signals (11, 12) are provided and are connected to a computer unit (CU) for signal transmission, which is designed to calculate the elongation either in sections (x, a - e, e') between the section markings (9) and / or in the drive element (1) by means of computational processing of the displacement increments (16) and the transmission signals (11, 12), characterized in thatthat the start mark (10) is formed by one of two section marks (9, 9') provided at a short distance from each other in the direction of movement (24) of the drive element (1), and that a common mark reader (AB) is provided for the section marks (9, 9') and the start mark (10).

Owner:KRONES AG
Container
The utility model discloses a container which comprises a container body, a first container door and a second container door, and a door slot is formed in the opposite end faces of the first container door and the second container door. A first box door lock rod is mounted on the first box door, and the number of the first box door lock rod is one; one or more second box door lock rods are mounted on the second box door; the distance between the first box door lock rod and the door slot is a first distance, the distance between the second box door lock rod with the shortest distance from the door slot and the door slot is a second distance, and the first distance is larger than the second distance. Only one first box door lock rod is installed on the first box door, the number of the lock rods is reduced, on one hand, the first box door lock rod is far away from a door slot and close to a door hinge, and therefore the opening degree of the box door is enlarged. On the other hand, the sealing performance of the box door is guaranteed through the second box door lock rod. According to the utility model, the number of the lock rods is reduced, and the box door is easier to open and close while the sealing performance of the box door is ensured.

Owner:FLEX CONTAINERS LTD
Game machine
To provide a game machine which can smoothly progress a game.SOLUTION: A first guard part has at least a base part to which a first long side of a reel tape is attached, and a protrusion bonded to the base part and protruding from the base part toward the center of a circle of the first guard part. The base part further has an outer end part farthest from a second guard part in a shaft center direction of a rotation shaft, and an inner end part nearest to the second guard part in the shaft center direction of the rotation shaft. A shortest distance between the outer end part and the protrusion is larger than a maximum thickness of the rotation shaft in the protrusion in the shaft center direction. A shortest distance between the outer end part and the protrusion is larger than a shortest distance between the inner end part and the protrusion.SELECTED DRAWING: Figure 203

Owner:SAMMY CORPORATION
Glass and optical member
The present invention addresses the problem of appropriately transmitting light. In a glass (10), when: the outer peripheral edge of the largest circle, centered on a center (P0) of the glass (10) and being contained within the range of an outer peripheral edge (10C) of the glass (10), is defined as a reference circumference (A0); a circumference, 5 mm away from the reference circumference (A0) inward in the radial direction, is defined as a first circumference (A1); the circumference of a circle, centered on the center (P0) of the glass (10) and having a radius that is half the distance between the reference circumference (A0) and the center (P0) of the glass (10), is defined as a second circumference (A2); a point on the first circumference (A1) is defined as a first point (P1); and a point having the shortest distance from the first point (P1) among the points on the second circumference (A2) is defined as a second point (P2), the maximum value of retardation is 20 nm or less in a straight line section (S) connecting from the first point (P1) to the second point (P2) in a straight line, the retardation does not monotonically decrease or monotonically increase from the first point (P1) toward the second point (P2), and there is a position where the retardation has an extreme value between the first point (P1) and the second point (P2).

Owner:AGC INC