

Patents
Literature
7962 results about "Excavator" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Excavators (hydraulic) are heavy construction equipment consisting of a boom, dipper (or stick), bucket and cab on a rotating platform known as the "house". The house sits atop an undercarriage with tracks or wheels. They are a natural progression from the steam shovels and often mistakenly called power shovels. All movement and functions of a hydraulic excavator are accomplished through the use of hydraulic fluid, with hydraulic cylinders and hydraulic motors. Due to the linear actuation of hydraulic cylinders, their mode of operation is fundamentally different from cable-operated excavators which use winches and steel ropes to accomplish the movements.
Unmanned intelligent excavator system
PendingCN119292124AConsistent working conditionsImprove work efficiencyProgramme controlComputer controlBulk cargoLoop control
The invention relates to an unmanned intelligent excavator system which is composed of a plurality of functional modules and is characterized in that various sensors and actuators are integrated through a hardware design module to provide basic support for subsequent operation; the environment sensing and positioning module collects three-dimensional point cloud data of an operation area in real time by using a multi-sensor fusion technology, realizes accurate positioning and environment sensing, and transmits the information to the planning module; the planning module formulates a driving route of the excavator and an operation track of the mechanical arm according to the received data, and sends the driving route and the operation track to an upper computer or a mobile terminal through the central control communication module to allow remote monitoring and control; and the lower computer communication module is responsible for transmitting a planned path instruction to an execution mechanism and driving a machine to execute a predetermined task. According to the system, a closed-loop control mode is adopted, high efficiency and safety of the excavator in bulk cargo cabin cleaning and coal stacking operation are guaranteed, and the wide potential of the excavator in future power plants and bulk cargo wharfs is shown.

Owner:HANGZHOU DENGYUAN TECH CO LTD
Pipeline laying assembly line in plain area and construction method
PendingCN119196400Alow efficiencyshorten the timePipe laying and repairCorrosion preventionLine tubingArchitectural engineering
The invention belongs to the technical field of pipeline construction, and particularly relates to a pipeline lowering assembly line in a plain area and a construction method.The assembly line is arranged at the front end of the starting end of pipe ditch excavation, and the assembly line is sequentially connected with a pipeline frame, a welding platform, a flaw detection platform, a joint coating platform, a pipe ditch support and a tractor in series through a conveying device; a pipeline is stored through the pipeline rack and conveyed to the welding platform for welding connection, welding quality detection is carried out on the flaw detection platform, anti-corrosion treatment is carried out on the joint coating platform, finally, the pipeline enters a pipe ditch through the pipe ditch support and then is connected to the bottom of the excavator through the tractor, and the excavator drags and distributes the pipeline. The problems that the road width is too large and the construction period is too long in traditional pipeline lowering are solved, the construction site can be saved, the construction efficiency is improved, and the construction cost is reduced.

Owner:HAIKOU JINGYUE INTELLIGENT TECHNOLOGY CO LTD
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
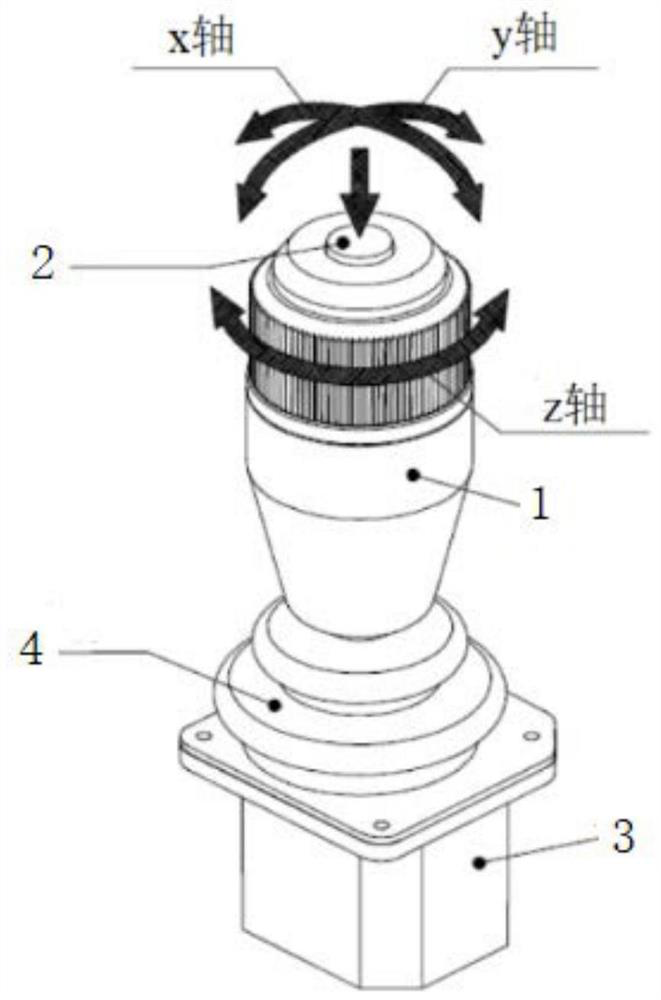
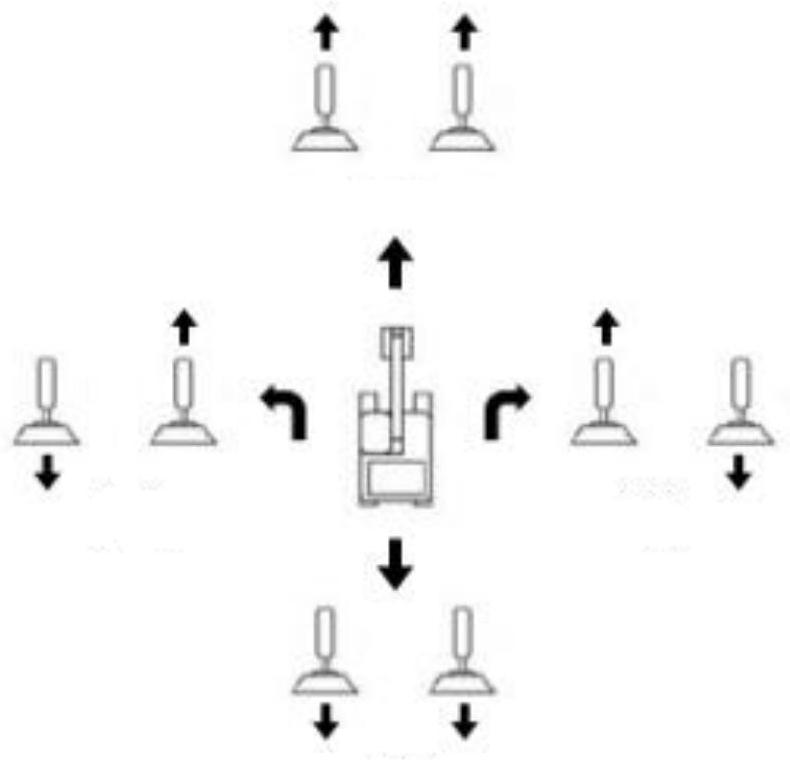
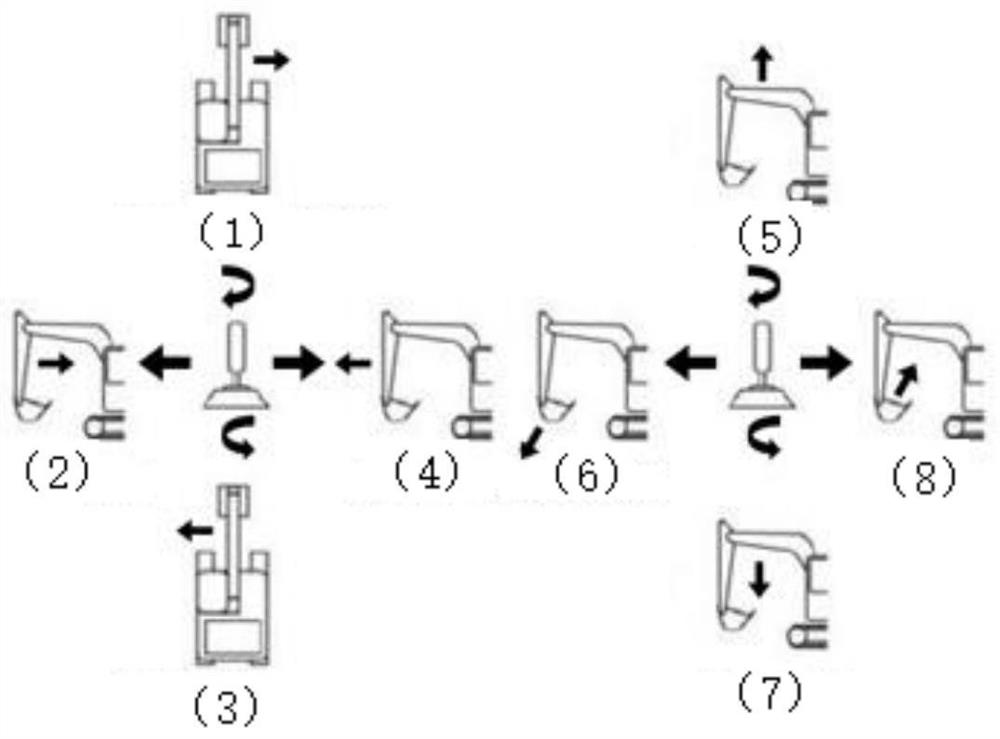
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Hydraulic loading system for semi-physical simulation platform of excavator
ActiveCN119412409AImprove general performanceeasy to operateFluid-pressure actuator testingServomotor componentsExcavatorOil intake
The invention discloses a hydraulic loading system for a semi-physical simulation platform of an excavator. The hydraulic loading system comprises a loading pump set, a confluence switching valve set, a movable arm linkage loading valve set, a bucket rod linkage loading valve set, a bucket linkage loading valve set, a rotation linkage loading valve set, a flow detection assembly, a pressure detection assembly, a multi-way valve and an excavator power unit. Oil inlet ports of all the multi-way valves provide oil inlet through an excavator power unit, flow of oil return ports of a movable arm link, a bucket rod link and a bucket link provides an oil source through a loading pump set, loading valve sets simulate loading load pressure, and the oil return amount and the oil return back pressure are controlled through speed regulating valves of all the loading valve sets. And the rotary unit controls the oil return quantity and simulates the rotary load through a rotary loading valve group. Multi-pump-set loading is adopted, the loading flow range is large, universality is high, an execution oil cylinder and an execution motor do not need to be installed and replaced, and operability is high; the oil inlet and return flow and pressure of the movable arm unit, the bucket rod unit and the bucket unit are independently loaded and are not limited by the area ratio of two cavities of an oil cylinder.

Owner:ZHEJIANG UNIV
Pipe ditch backfilling and tamping system based on excavator modification
The invention relates to the technical field of earthwork compaction, and discloses a pipe ditch backfilling and tamping system based on excavator modification. The system comprises an earthwork condition dynamic sensing module which captures a bucket tooth track, a hydraulic oil cylinder pressure pulse and a soil mass vibration spectrum in real time and combines a historical database to construct a model to output a theoretical compaction degree curve; a multi-source compaction difference analysis module performs three-dimensional deviation detection on the theoretical curve and the actual settlement volume data to generate a construction grid-level compaction difference tensor; the defect area association mapping module inputs the tensor into a geological topology analysis network, generates a loose defect propagation path probability cloud chart by combining soil parameters and identifies weak sections; and the tamping strategy self-adaptive configuration module automatically sets operation parameters according to the cloud picture, activates high-precision monitoring on a high-probability defect section, and applies a dynamic excitation force test on adjacent grids, so that intelligent management and control of the backfilling and compacting process are realized.

Owner:CHINA CONSTR FOURTH ENG DIV INSTALLATION ENG
Welding robot for excavator assembly
The invention relates to the technical field of excavator cab door frame welding, in particular to an excavator assembly welding robot which comprises a support table, an outer frame fixedly connected to the upper portion of the support table and a welding mechanical arm installed on the side portion of the support table. A first self-clamping assembly used for automatically centering, adjusting, clamping and limiting an excavator door frame vertical beam is arranged in the middle of the upper end face of the support, and a second self-clamping assembly used for automatically centering, adjusting and clamping an excavator door frame cross beam is arranged on the rear portion of the support. A linkage assembly used for sequentially triggering the moving assembly, the second self-clamping assembly and the first self-clamping assembly to operate so that a vertical supporting column, a cross beam, a vertical beam and an L-shaped supporting column section in an excavator door frame can be spliced together is jointly arranged between the support and the pushing assembly. Rapid and accurate splicing and undisturbed turn-over welding of the door frame component of the excavator are achieved through a linkage clamping and overall turn-over structure, the splicing size consistency and welding precision are remarkably improved, and meanwhile the welding efficiency and the process continuity are improved.

Owner:LINYI SANYOU HEAVYINDUSTRY CO LTD
Front eccentric block excitation cutting disc rock breaking device
The invention belongs to the technical field of hard rock cutting and tunneling, and particularly relates to a front eccentric block excitation cutting disc rock breaking device which comprises a cutting assembly, an eccentric excitation device, a driving assembly and a supporting assembly, and the rear portion of the supporting assembly is fixedly connected with a cutting arm of a tunneling machine; the driving assembly comprises a motor, a main shaft and various connecting devices; an eccentric excitation device and a cutting assembly are mounted at the front end of the main shaft; the cutting assembly is mounted at the front end of the main shaft; the driving device ensures stable rotation of the cutterhead and enables vibration generated by the eccentric excitation device to be transmitted to the cutterhead. Vibration generated by rotation of the eccentric block is utilized to enable the cutter head to impact the rock, so that the rock is collapsed, and the rock is efficiently cut; as the cutter head cuts the rock mainly by means of vibration impact generated by the eccentric device, compared with a self-rotating mode and a traditional milling rock breaking mode and a TBM rolling mode, the efficiency of cutting the rock is improved, and the service life of the cutter is prolonged.

Owner:TAIYUAN UNIVERSITY OF SCIENCE AND TECHNOLOGY
Power-operated construction machine
An upper revolving structure (4) of an electric hydraulic excavator (1) includes a revolving frame (7), an operator's seat (10), an electric motor (15), a hydraulic pump (17) driven by the electric motor (15), an oil tank (18), and an exterior cover (20) disposed in the revolving frame (7) to cover electrical equipment including the electric motor (15) and hydraulic equipment including the hydraulic pump (17) and the oil tank (18). A partitioning member (25) that is disposed in the revolving frame (7) to partition an inside of the exterior cover (20) into an electrical equipment room (28) and a hydraulic equipment room (29). An electrical equipment cooling device (31) including an electrical equipment cooling fan (34) is disposed in the electrical equipment room (28), and a hydraulic equipment cooling device (35) including a hydraulic equipment cooling fan (37) is disposed in the hydraulic equipment room (29).

Owner:HITACHI CONSTRUCTION MACHINERY TIERRA CO LTD
Harbor basin dredging construction method
PCT designated stage expiredWO2024260129A1Climate change adaptationStream regulationTerrainSoil science
Disclosed in the present invention is a harbor basin dredging construction method. The method comprises: construction preparation, wherein an antifouling curtain is arranged on the periphery of a construction water area, and a total station is used to survey the construction area; harbor basin dredging, wherein a grab dredger is used for layered excavation, and a hopper barge is used to convey mud to a mud unloading site for discharging; foundation trench and ocean-side inter-pile soil excavation, wherein a pipe head of a suction dredger extends to the ocean-side part of an inter-pile area, and pumps mud and sand to form an ocean-side dredging section; inter-pile soil excavation, wherein a long reach excavator barge is used for inter-pile soil excavation and dredging; shore-side inter-pile soil excavation, wherein a long reach excavator is used for excavation to form a shore-side dredging section; and harbor basin spot dredging, wherein an all-terrain survey is carried out to determine shallow spots and a spot dredging route, and spot dredging is carried out in the harbor basin according to the shallow spots and the spot dredging route so as to ensure dredging depth. The construction method provided in the present invention solves the problem of loss or reduction of dredging results that can be caused by the continuous movement and sedimentation of silt in excavation trenches as well as consequent siltation, thus ensuring dredging effectiveness and saving dredging construction time.

Owner:CHINA HARBOUR ENGINEERING
Self-adaptive inclined excavator bucket system and control method thereof
PendingCN119221544AImprove efficiencyHigh precisionMechanical machines/dredgersLaser rangingSoil characteristics
The invention discloses a self-adaptive inclined excavator bucket system and a control method thereof. The self-adaptive inclined excavator bucket system comprises a bucket, an inclination sensor, a laser distance measuring sensor, a soil characteristic sensor, a main controller and an executing mechanism. The inclination sensor is installed on the rear side of the bucket and used for monitoring the inclination angle of the bucket in real time. The laser distance measuring sensor is installed on the front edge of the bucket and used for measuring the distance between the bucket and the ground. The soil characteristic sensor is installed on bucket teeth of a bucket and used for obtaining physical characteristic information of soil in real time. The main controller is electrically connected with all the sensors and the executing mechanism and is used for receiving and processing data of the sensors in real time and sending a control command to the executing mechanism; the executing mechanism comprises a hydraulic system and a servo motor and is used for receiving a control command of the main controller in real time and automatically adjusting the inclination angle and the digging force of the bucket. The inclination angle and the digging depth of the bucket can be automatically adjusted according to different conditions, and the working efficiency, precision and safety are improved.

Owner:ZHEJIANG UNIV HIGH-END EQUIP RES INST +1
Multi-machine collaborative operation cabin cleaning method
According to the innovative port cabin cleaning scheme, multi-machine cooperative operation of the unmanned excavator and the ship unloader is utilized, and the operation safety and efficiency are remarkably improved. The system integrates multi-sensor mapping, path planning, intelligent collision avoidance and real-time position tracking technologies, and elevation grid map modeling and vehicle positioning in a cabin are realized through a mapping sensing module. The task scheduling module intelligently selects an operation point and plans a path according to the coal pile layout, and the cooperative control module monitors cooperative work of the unmanned excavator and the ship unloader in real time to prevent the collision risk. The work control module is responsible for dynamically adjusting the equipment state and ensuring safe and efficient operation. The scheme flexibly adapts to various ship types and cargo hold layouts, not only improves the port operation efficiency, but also reduces the risk of manual operation errors, and is an important step for modern port automation and intelligent development.


Owner:HANGZHOU DENGYUAN TECH CO LTD
Bucket rod composite damping device and excavator
The invention relates to the technical field of excavator bucket rods, and provides a bucket rod composite damping device and an excavator. The device comprises a shell composed of a base, an outer shell and a stress shell; the magneto-rheological buffer device is installed in the shell and composed of a lattice structure made of magneto-rheological elastomer materials and magneto-rheological fluid filled in gaps corresponding to the lattice structure, and a plurality of sound absorption holes are formed in each cell element wall in the lattice structure; the electromagnetic device is located in a containing cavity formed in the lattice structure and is composed of a magnetic core and an electromagnetic coil; the anti-vibration pad and the stress plate are embedded in the top of the shell and are in contact with the stress plate; the damping springs are arranged on the periphery of the shell and fixedly connected between the stress plate and the base; the vibration monitoring module is used for collecting vibration data of the bucket rod in real time and transmitting the vibration data to the intelligent control module, and the intelligent control module is used for adjusting the output magnetic field intensity of the electromagnetic coil according to the vibration data so as to adjust the viscosity of the magnetorheological fluid in real time.

Owner:CHINA UNIV OF PETROLEUM (EAST CHINA)
Quadrant switching smooth control method, device and equipment for electro-hydrostatic system
The invention provides a quadrant switching smooth control method, device and equipment for an electro-hydrostatic system, and relates to the technical field of electro-hydraulic compound drive control. According to the method, sensor state information is acquired, a discretization state-space equation is established, a cost function is designed, improved sequential quadratic programming is called to solve the optimal control quantity, instructions are smoothly processed through a linear tracking differentiator, a reference value is calculated through a current distribution strategy and pressure feed-forward compensation, and cooperative impact resistance control is achieved through a PI controller and SVPWM. The response speed and stability of the electro-hydraulic compound system in the quadrant switching process can be remarkably improved, the problems of impact and torque overshoot are effectively restrained, the service life of equipment is prolonged, and the electro-hydraulic compound system is suitable for high-performance requirement scenes under complex working conditions such as electric loaders, excavators and winches.

Owner:HUAQIAO UNIVERSITY
Excavator loading counting method and device based on machine vision, terminal and medium
The invention relates to the technical field of machine vision, and discloses an excavator loading counting method and device based on machine vision, a terminal and a medium, and the method comprises the steps: obtaining a current frame image collected according to a preset frame rate; inputting the current frame image into a pre-trained target detection model to obtain a detection result output by the pre-trained target detection model; when the detection result comprises a target image, extracting a loading vehicle image from the target image; inputting the loading vehicle image into a pre-trained optical character recognition model to obtain a loading vehicle number recognition result output by the pre-trained optical character recognition model; and counting the loading quantity of the excavator according to the number identification result of the loading vehicle. The automatic identification of the loading vehicle and the automatic statistics of the loading quantity of the excavator are realized, the complexity and error-prone property of manual counting are avoided, the working efficiency of a mine field is improved, and the workload of operators is reduced.

Owner:SHENNAN CIRCUITS
Working machine
A counterweight (7) is provided on the rear end side of an upper revolving structure (3). An electric motor (10) is a power source for a hydraulic excavator (1). An emergency stop switch (21) stops the electric motor (10). The counterweight (7) is provided with a recessed part (7D) recessed from a rear surface (7A) that is a surface of the counterweight (7). The emergency stop switch (21) is provided within the recessed part (7D) of the counterweight (7).

Owner:HITACHI CONSTRUCTION MACHINERY TIERRA CO LTD
Method and system for automatically calculating number of loading buckets and loading quantity
PendingCN119478910AImprove effectivenessimprove accuracyCharacter and pattern recognitionSoil-shifting machines/dredgersControl engineeringProcess engineering
The invention provides a method and system for automatically calculating the number of loading buckets and the loading quantity, and relates to the technical field of equipment monitoring, and the method comprises the steps of 1, obtaining bucket excavation pilot pressure and bucket rod excavation pilot pressure, 2, obtaining movable arm rising pilot pressure, and triggering a camera to recognize the state of materials in a bucket when the pilot pressure accords with a threshold value; 3, the state recognition result of the materials in the bucket is obtained, if the recognition result is that the materials exist, the unloading pilot pressure of the bucket continues to be obtained, and when the threshold value is met, a camera is triggered to recognize the ore card and the state of the materials in the ore card; step 4, acquiring a mine card identification result, and when the identification result is that the mine card exists, counting the number of effective loading buckets; and step 5, obtaining a state identification result of the materials in the mine card, if the identification result is that no load is changed into full load, adding one to the effective loading quantity, and reading the remaining oil quantity after loading. According to the invention, automatic statistics of the loading bucket number and the loading quantity of the large mining excavator can be realized, and the accuracy is improved.

Owner:QINGDAO LOVOL EXCAVATOR +1
Excavator heat dissipation control method and system based on environment temperature and working conditions
The invention discloses an excavator heat dissipation control method and system based on environment temperature and operation working conditions. The excavator heat dissipation control method comprises the steps that S1, the operation working conditions of an excavator are divided into five working conditions including the super-heavy load working condition, the heavy load working condition, the medium load working condition, the light load working condition and the super-light load working condition; s2, the external environment temperature is divided into 10 gears; s3, according to the environment temperature and the operation working condition, the heat dissipation requirement is divided into 10 gears; s4, the rotating speed of the cooling fan is adjusted according to the cooling requirement gear, so that the cooling requirement is accurately matched with the rotating speed of the cooling fan; and S5, whether the temperature of the working medium in the excavator is larger than a high-temperature threshold value or not is judged, if yes, heat dissipation is conducted according to the corresponding heat dissipation fan rotating speed obtained through the heat balance test, and if not, heat dissipation is conducted according to the actual heat dissipation requirement gear standard. The problem of heat dissipation redundancy caused by single parameter control is solved, and dynamic matching of the rotating speed of the fan and the composite heat dissipation requirement is achieved. And the energy consumption under the low-load working condition and the cold environment is reduced, and the risk of insufficient heat dissipation under the high-temperature heavy-load working condition is avoided.

Owner:XUZHOU XCMG MINING MACHINERY CO LTD
Bucket for testing excavating resistance of wheel bucket excavator
ActiveCN119352596ASimple structureImprove reliabilityMechanical machines/dredgersStructural/machines measurementControl theoryExcavator
The invention provides a bucket for testing the digging resistance of a wheel bucket excavator, and solves the problems that the conventional wheel bucket excavator is difficult to directly and accurately measure the resistance in the tangential direction, the lateral direction and the normal direction of the bucket and the distribution condition of the lateral digging resistance in a lug plate of the bucket cannot be tested. According to the technical scheme, a bucket is connected with a bucket wheel body through three or four sets of hinge parts, each set of hinge part is composed of two bucket lug plates and one bucket wheel body lug plate in a matched mode, and the bucket lug plates and the bucket wheel body lug plates are connected through bidirectional force measuring pin shaft sensors penetrating through lug plate shaft holes; pressure ring sensors are arranged between the two sides of the bucket wheel body lug plate and the two opposite bucket lug plates respectively, pin shaft sensors penetrate through shaft holes of the pressure ring sensors, and the pressure ring sensors are fixed to the opposite faces of the two bucket lug plates through annular baffles. And the pressure ring sensor is embedded in the annular baffle plate. By arranging the bucket for testing, the resistance distribution of the hinged part in the bucket is accurately measured, and the reliability and the testing efficiency are high.

Owner:CCTEG SHENYANG ENG CO
Multi-station welding device for movable arm of excavator
ActiveCN119077226Aachieve weldingImprove welding efficiencyEdge grinding machinesGrinding drivesExcavatorThreaded rod
The invention relates to the technical field of excavator production, and discloses an excavator movable arm multi-station welding device which comprises a mounting frame, a two-way threaded rod is rotationally connected into the mounting frame, and a plurality of sliding blocks are arranged on the outer surface of the two-way threaded rod in a threaded fit mode. A movable arm is placed below a mounting frame, then the movable arm is automatically fed to a welding treatment position through cooperation of a movable arm feeding and fixing mechanism, then a second transmission mechanism drives a two-way threaded rod to rotate, and a first mounting ring and a second mounting ring on the two sides are driven to move towards the middle; then, the multi-station welding mechanism and the surface treatment mechanism in the first mounting ring and the second mounting ring are used for carrying out all-directional welding and treatment on the surface of the movable arm, and meanwhile, the movable arm feeding mechanism is matched for carrying out welding treatment on the middle position of the movable arm, so that comprehensive welding of the movable arm is realized; and the welding efficiency and the welding effect of the movable arm are greatly improved.

Owner:XUZHOU YUANCHENG MASCH MFG CO LTD
Mining area vehicle excavation operation statistical method, system and device and storage medium
The invention relates to the technical field of mining area vehicle excavation operation statistics, in particular to a mining area vehicle excavation operation statistics method, system and device and a storage medium. The statistical method comprises the steps that the relative position between the excavator and the mine car is determined through beacon signals, and the distance between the excavator and the mine car is calculated according to position data of the relative position; a high-density vibration sensor is used for detecting periodic vibration signals generated during operation of the excavator, and SD periodic burr signals are extracted through a signal processing algorithm and used for judging whether the excavator is loading or not; when it is judged that the excavator is loading, a loading event is recorded, and a loading record is generated. According to the invention, by fusing various sensor signals, the accuracy of mining area vehicle excavation operation statistics is improved. Specifically, the beacon signal enables the relative position between the excavator and the mine car to be accurately determined, so that misstatistics caused by wrong position judgment is avoided.

Owner:NANJING ZEAHO ELECTRONICS TECH CO LTD
Soil sampling device
PendingCN119507395Aimprove accuracyprecise position adjustmentFouling preventionWithdrawing sample devicesSoil scienceHydraulic engineering
The invention relates to the technical field of hydraulic engineering construction equipment, in particular to a soil sampling device which comprises an excavator, a rock soil sampling device is arranged on the excavator, and the rock soil sampling device comprises a sampling rod used for sampling rock soil and a driving mechanism used for driving the sampling rod to move. The sampling rod is a hollow rod, a storage cavity for storing samples is formed in the inner wall of the sampling rod, and a plugging device is arranged between the storage cavity and the hollow cavity of the sampling rod; the plugging device comprises a plugging plate and an adjusting mechanism; the plugging plate is used for plugging and communicating the storage cavity and the hollow cavity; the adjusting mechanism is used for driving the plugging plate to adjust; and the plugging plate is rotationally matched on the sampling rod. The soil sampling device has the effects of reducing impurities entering a sample during re-sampling and improving the sampling accuracy.


Owner:SINOHYDRO ENG BUREAU 4
Excavator environment virtual view angle display method and device
PendingCN119251415AImprove efficiencyimprove securityImage enhancementImage analysisPoint cloudComputer graphics (images)
The invention discloses an environment virtual view angle display method and device for an excavator, and the method comprises the steps: reading sensor data collected by various sensors disposed on the excavator in advance in an operation process of the excavator; calculating a target pose of the excavator and constructing a real-time rgb point cloud map of a surrounding scene of the excavator by combining a mapping positioning algorithm SLAM based on the sensor data and pre-calibrated internal and external parameters of the sensor, performing surface reconstruction on the real-time rgb point cloud map, and converting the real-time rgb point cloud map into a real-time three-dimensional scene of the surrounding scene of the excavator; projecting the original image to a corresponding position of a real-time three-dimensional scene to obtain a full three-dimensional scene of the excavator; and according to the full three-dimensional scene of the excavator, rendering an excavator operation scene under a preset visual angle in real time. By the adoption of the system, all-around display of the surrounding environment of the excavator can be achieved, meanwhile, visual angle and depth information which can be adjusted at will are provided, and therefore the efficiency and safety of remote operation of the excavator are improved.

Owner:BEIJING BUILDER INTELLIGENT TECHNOLOGY CO LTD
Excavator control method and system oriented to non-structural working conditions
ActiveCN119266333Aimprove abilitiesreduce dependenceSoil-shifting machines/dredgersKnowledge representationControl systemControl engineering
The invention provides an excavator control method and system oriented to non-structural working conditions. According to the excavator control method and system oriented to the non-structural working condition, on one hand, according to the dynamic remodeling characteristic of earthwork in the excavation process, the excavation action track is planned through the earthwork state obtaining model and the excavation action planning model, the excavator control method and system can adapt to the non-structural working condition, and it is ensured that the operation effect is stable; on the second aspect, through real-time sensing and data feedback, the excavation action track can be adjusted in real time in the operation process, optimization is conducted according to the earthwork state, and the operation flexibility and effect can be improved; thirdly, by autonomously planning an excavation action track, the dependence on a manual operator can be reduced, the requirement of manual intervention is reduced, and the autonomous operation capability is improved; and fourthly, the mining action track is optimized through the mining action planning model, so that the energy consumption in the mining process can be reduced, the operation efficiency can be improved, and the operation cost can be reduced.

Owner:ZHEJIANG UNIV
Foundation pit supporting structure for foundation pit excavation
InactiveCN119221554AImprove project qualityreduce riskSoil-shifting machines/dredgersExcavationsArchitectural engineeringElectric machinery
The invention belongs to the technical field of foundation pit supporting, and discloses a foundation pit supporting structure for foundation pit excavation, which comprises an excavator body, a movable soil collecting mechanism is arranged between an excavator bucket of the excavator body and a crawler belt, and the soil collecting mechanism comprises a soil collecting frame, a soil breaking roller and a driving motor. Through the synergistic effect of the soil collecting mechanism, the soil moving mechanism, the mixing mechanism and the supporting mechanism, synchronous excavation and supporting of the foundation pit are achieved, the side wall of the foundation pit is refilled with excavated soil to form a supporting wall, cement slurry is injected through the mixing mechanism to reinforce a soil body, and therefore the problems existing in a traditional method are solved; therefore, the method has the advantages of improving the engineering quality, reducing the risk, saving the cost and conforming to environment-friendly sustainable development.

Owner:JIANGSU NANJING GEOLOGY ENG KANCHAYUAN +1
Excavator structure topological optimization method and system based on real-time stress field reconstruction
The invention relates to the technical field of engineering mechanical structure optimization, in particular to an excavator structure topological optimization method and system based on real-time stress field reconstruction. The method comprises the following steps of: designing finite element analysis software, modeling and simulating in the finite element analysis software to obtain virtual data, designing a Kalman filter to carry out error correction on the virtual data and actual test data, training the Kalman filter by utilizing the corrected data to obtain prediction of real-time stress field distribution, and further, establishing a topological optimization model of an excavator structure, according to the method, material attributes are coded into a weight matrix in a neural network, and a stress constraint partial differential equation is used as a constraint condition, so that high-precision reconstruction of the stress field of the movable arm of the excavator under an actual working condition is realized, and an accurate boundary condition is provided for topological optimization.

Owner:XUZHOU NORMAL UNIVERSITY
Yoke assembly for excavator thumb
A thumb for a machine implement has first and second side plates having a pivot end for pivotally connecting to a linkage of the machine and an engagement end for engaging with a load. A belly plate extends across a width of the thumb between the first and second side plates and along a length of the thumb from the pivot end toward the engagement end. A yoke assembly mounted to a surface of the belly plate is configured to connect the thumb to a thumb actuator that pivots the thumb about the pivot end. A first yoke plate has a first opening and a second yoke plate opposing the first yoke plate has a second opening aligned with the first opening. First and second inner collar spacers are respectively mounted to inner surfaces of the first and second yoke plates aligned with the first and second openings.

Owner:CATERPILLAR INC
Ultra-narrow multifunctional reversed loader suitable for coal mine tunnel
The invention relates to the field of coal mining, in particular to an ultra-narrow multifunctional reversed loader suitable for a coal mine tunnel, and aims to solve the problem that an excavator in the prior art is inconvenient to convey a coal mine in a narrow pipeline. The crawler walking assembly is mounted at the bottom of the saddle, the mounting frame is fixed to the top of the saddle, and a conveying space is formed between the mounting frame and the top of the saddle; the excavating mechanism comprises a rotary table rotationally connected to the top of the mounting frame, an excavating arm assembly mounted on the rotary table and a driving part mounted on the top surface of the mounting frame and used for driving the rotary table to rotate; and the material conveying mechanism comprises a fixing frame mounted at the top of the saddle, a conveying belt mounted on the fixing frame and a material receiving table mounted at the head of the fixing frame. According to the excavator, excavated coal in the bucket can be conveniently conveyed to the rear portion of the excavator through the conveying belt, and coal cinder adhering to the material guide plate can be conveniently cleaned.

Owner:HUAINAN UNITED UNIVERSITY
Power control method and system for hybrid power excavator and excavator
The power control method comprises the steps that a whole machine controller of the excavator receives a detection signal of an excavator load and judges the working condition of the excavator, the required torque is calculated according to the working condition of the excavator, and the required torque is output to a motor controller; the motor controller receives the target rotating speed and the required torque of the complete machine controller and the output rotating speed and the output torque of the engine controller, decides charging and discharging of the system and calculates an ISG motor control signal; and a feed-forward feedback control method is adopted to control the ISG motor to assist in driving the excavator load, the feed-forward control value of the ISG motor is the required torque, and the feedback control value of the ISG motor is the rotating speed error calculation value. According to the power control method of the hybrid power excavator, the time of charging and discharging in the excavation period is distributed, and the torque and the charging and discharging parameters can be set according to the characteristics of the battery and the motor, so that the whole system reaches a balance value.

Owner:XUZHOU XCMG MINING MACHINERY CO LTD
Bulldozing pilot valve assembly, bulldozing hydraulic system with bulldozing blade capable of floating and lifting and excavator
The bulldozing pilot valve assembly comprises a valve body, a handle assembly, a first valve part, a second valve part, a third valve part, a first opening, a second opening, a third opening and a fourth opening, wherein the third opening and the fourth opening are used for being connected with the hydraulic control end of a reversing valve. The dozer blade oil cylinder can enter different working states by pressing down the end of the connecting piece of the handle assembly, and the dozer blade ascends or descends or ascends or descends in a floating mode. And when one end of the connecting piece is pressed downwards, the other end of the connecting piece tilts. After the bulldozing blade enters a floating lifting working state, the third valve part can output oil liquid to carry out hydraulic control feedback on the first valve part, so that the first valve part is kept at a first valve position of the first valve part, the second valve part is kept at a second valve position of the second valve part, and the third valve part is kept at a third valve position of the third valve part; therefore, the dozer blade can be effectively maintained in a long-time floating lifting working state.

Owner:XCMG EXCAVATOR MACHINERY CO LTD
Excavator electric rotation system and control method
PendingCN119122046AImprove acceleration smoothnessAvoid the problem of insufficient regenerative braking forceMechanical power/torque controlSoil-shifting machines/dredgersRegenerative brakeLow speed
The invention belongs to the technical field of excavator rotation systems, and particularly relates to an excavator electric rotation system and a control method, the excavator electric rotation system comprises a handle, a tilt angle sensor, a rotation angle sensor, a weighing system, a whole machine controller, a power supply system, a brake resistor, a rotation motor and a brake; wherein the handle and the sensor are connected with an input port of the whole machine controller; the output port of the complete machine controller is connected with the control port of the brake, and the communication port of the complete machine controller is connected with the communication ports of the motor controller and the weighing system; the motor controller is connected with the power supply system, the rotary motor and the brake resistor, and the rotary motor is mechanically connected with the brake and the speed reducer. The acceleration stability in the rotation process is improved, the acceleration stability in the rotation process is improved, the stability in the rotation stopping process is improved, the problem that the regenerative braking force is insufficient when the motor is at a low speed is solved, the application working condition is wider, and the system is more reliable.

Owner:XUZHOU XCMG MINING MACHINERY CO LTD