

Patents
Literature
41results about How to "Reduce messaging" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Server-assisted device-to-device discovery and connection
ActiveUS20140357269A1Efficiently setReduce power consumptionConnection managementWireless commuication servicesIp addressService discovery
A method includes receiving, at a network node, a device-to-device D2D discovery request from a first device and sending a D2D discovery response from the network node to the first device. The D2D discovery response includes information associated with a second device that is available to establish a D2D connection with the first device. The network node may perform inquiries regarding D2D connection permission from both devices. If D2D connection is permitted by both devices, the network node may facilitate the D2D scanning by sending each device's scanning information to the other device via a non-D2D link. In parallel to D2D scanning, the network node may speed up D2D link setup by distributing, via non-D2D links, link setup information to each device, where the link setup information may include device credential(s), IP address allocation(s), and / or group owner assignment.


Owner:QUALCOMM INC
Social messaging system having multiple number, dual mode phone support
ActiveUS20120226759A1Low costEnables independenceAccounting/billing servicesTelephonic communicationInternet networkDual mode
A social messaging hub provides communication services for a data enabled device having Internet network access capabilities. The social messaging hub communicates with the data enabled device over the Internet or cellular data networks, and interfaces with a message infrastructure including mobile carriers, message aggregators, message exchanges and various specialized social messaging services to enable bi-directional messaging communication. The user is given a registered phone number and unique IP addressable identification which serve as a source and destination identifier of the associated data enabled device. Messages may originate in or be delivered to other users' mobile telephones or in similarly equipped and provisioned IP data enabled devices. An application operating on the IP enabled device determines in conjunction with the social messaging hub a mode of transmission as a function of parameters including device location and destination of a message.


Owner:HEYWIRE
Methods, systems and apparatus for public key encryption using error correcting codes
InactiveUS20150163060A1Improve securityEasy to broadcastKey distribution for secure communicationPublic key for secure communicationComputer hardwareTrade offs
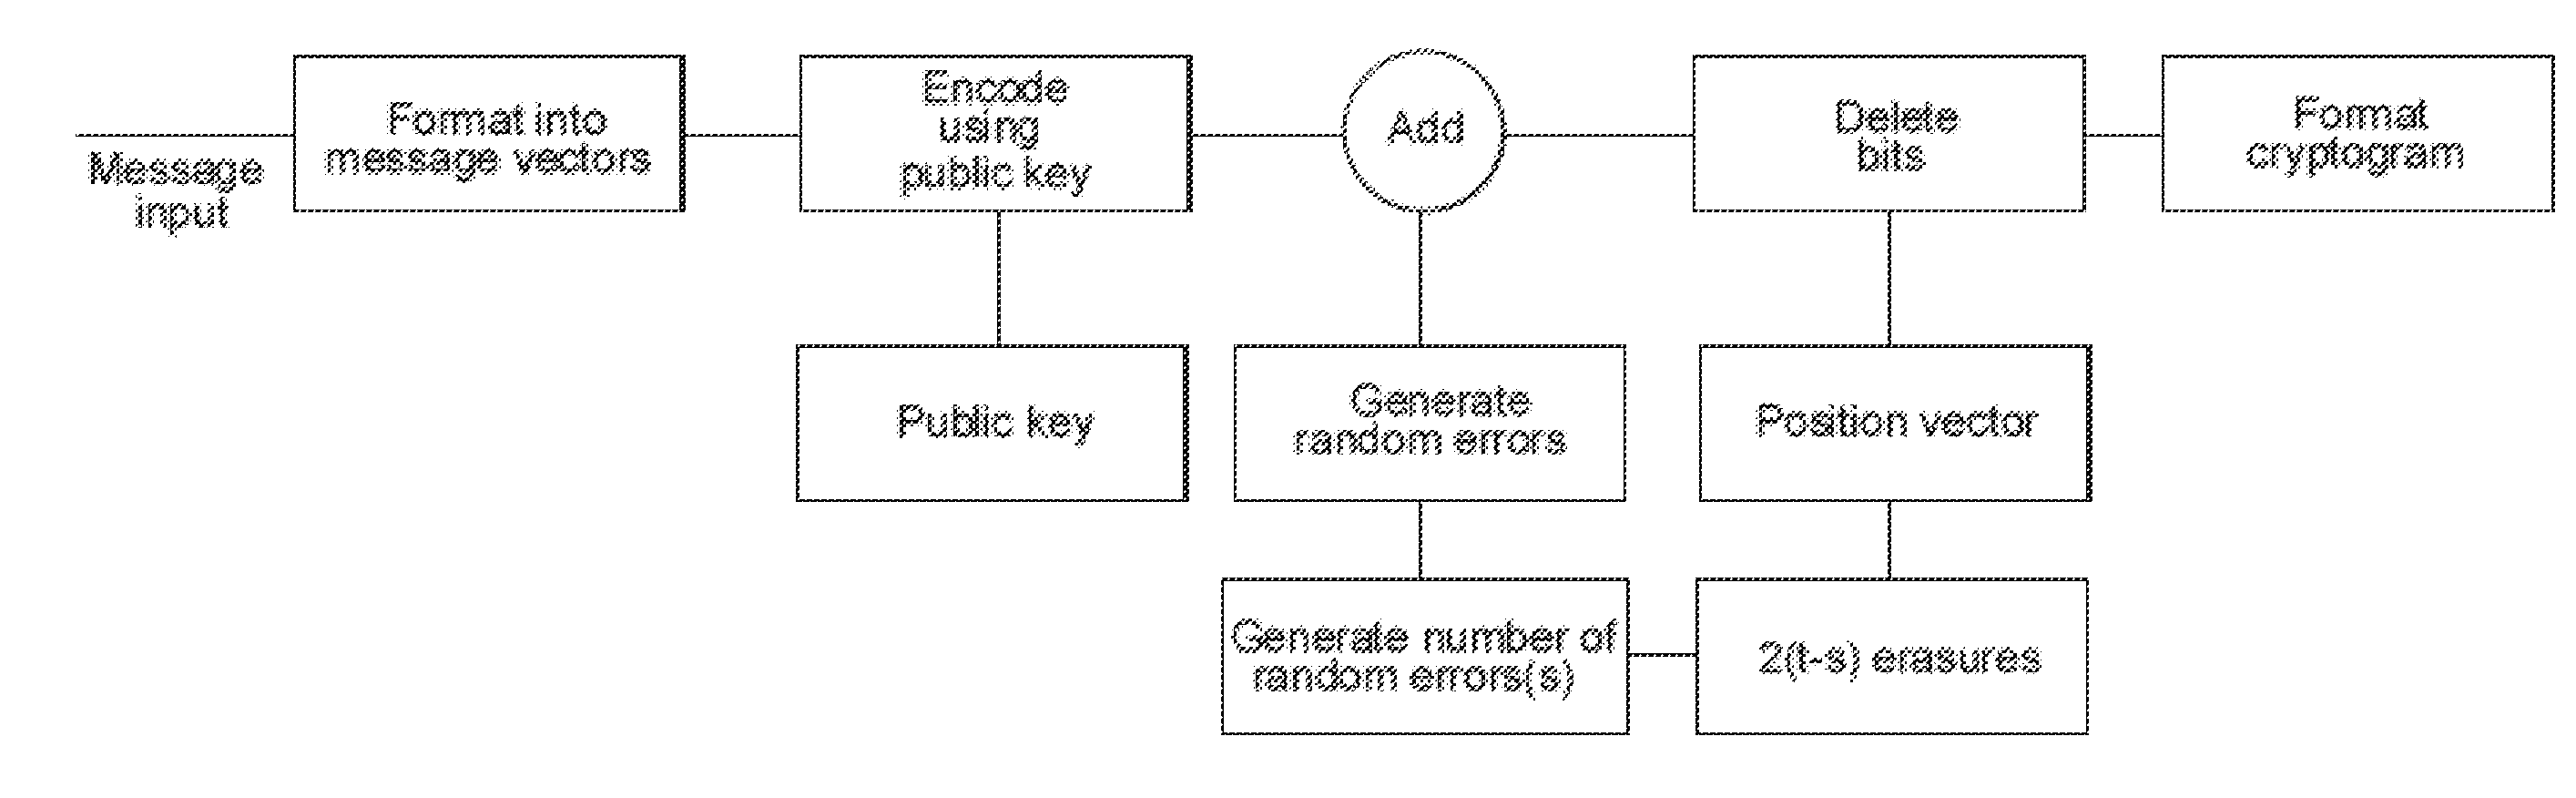
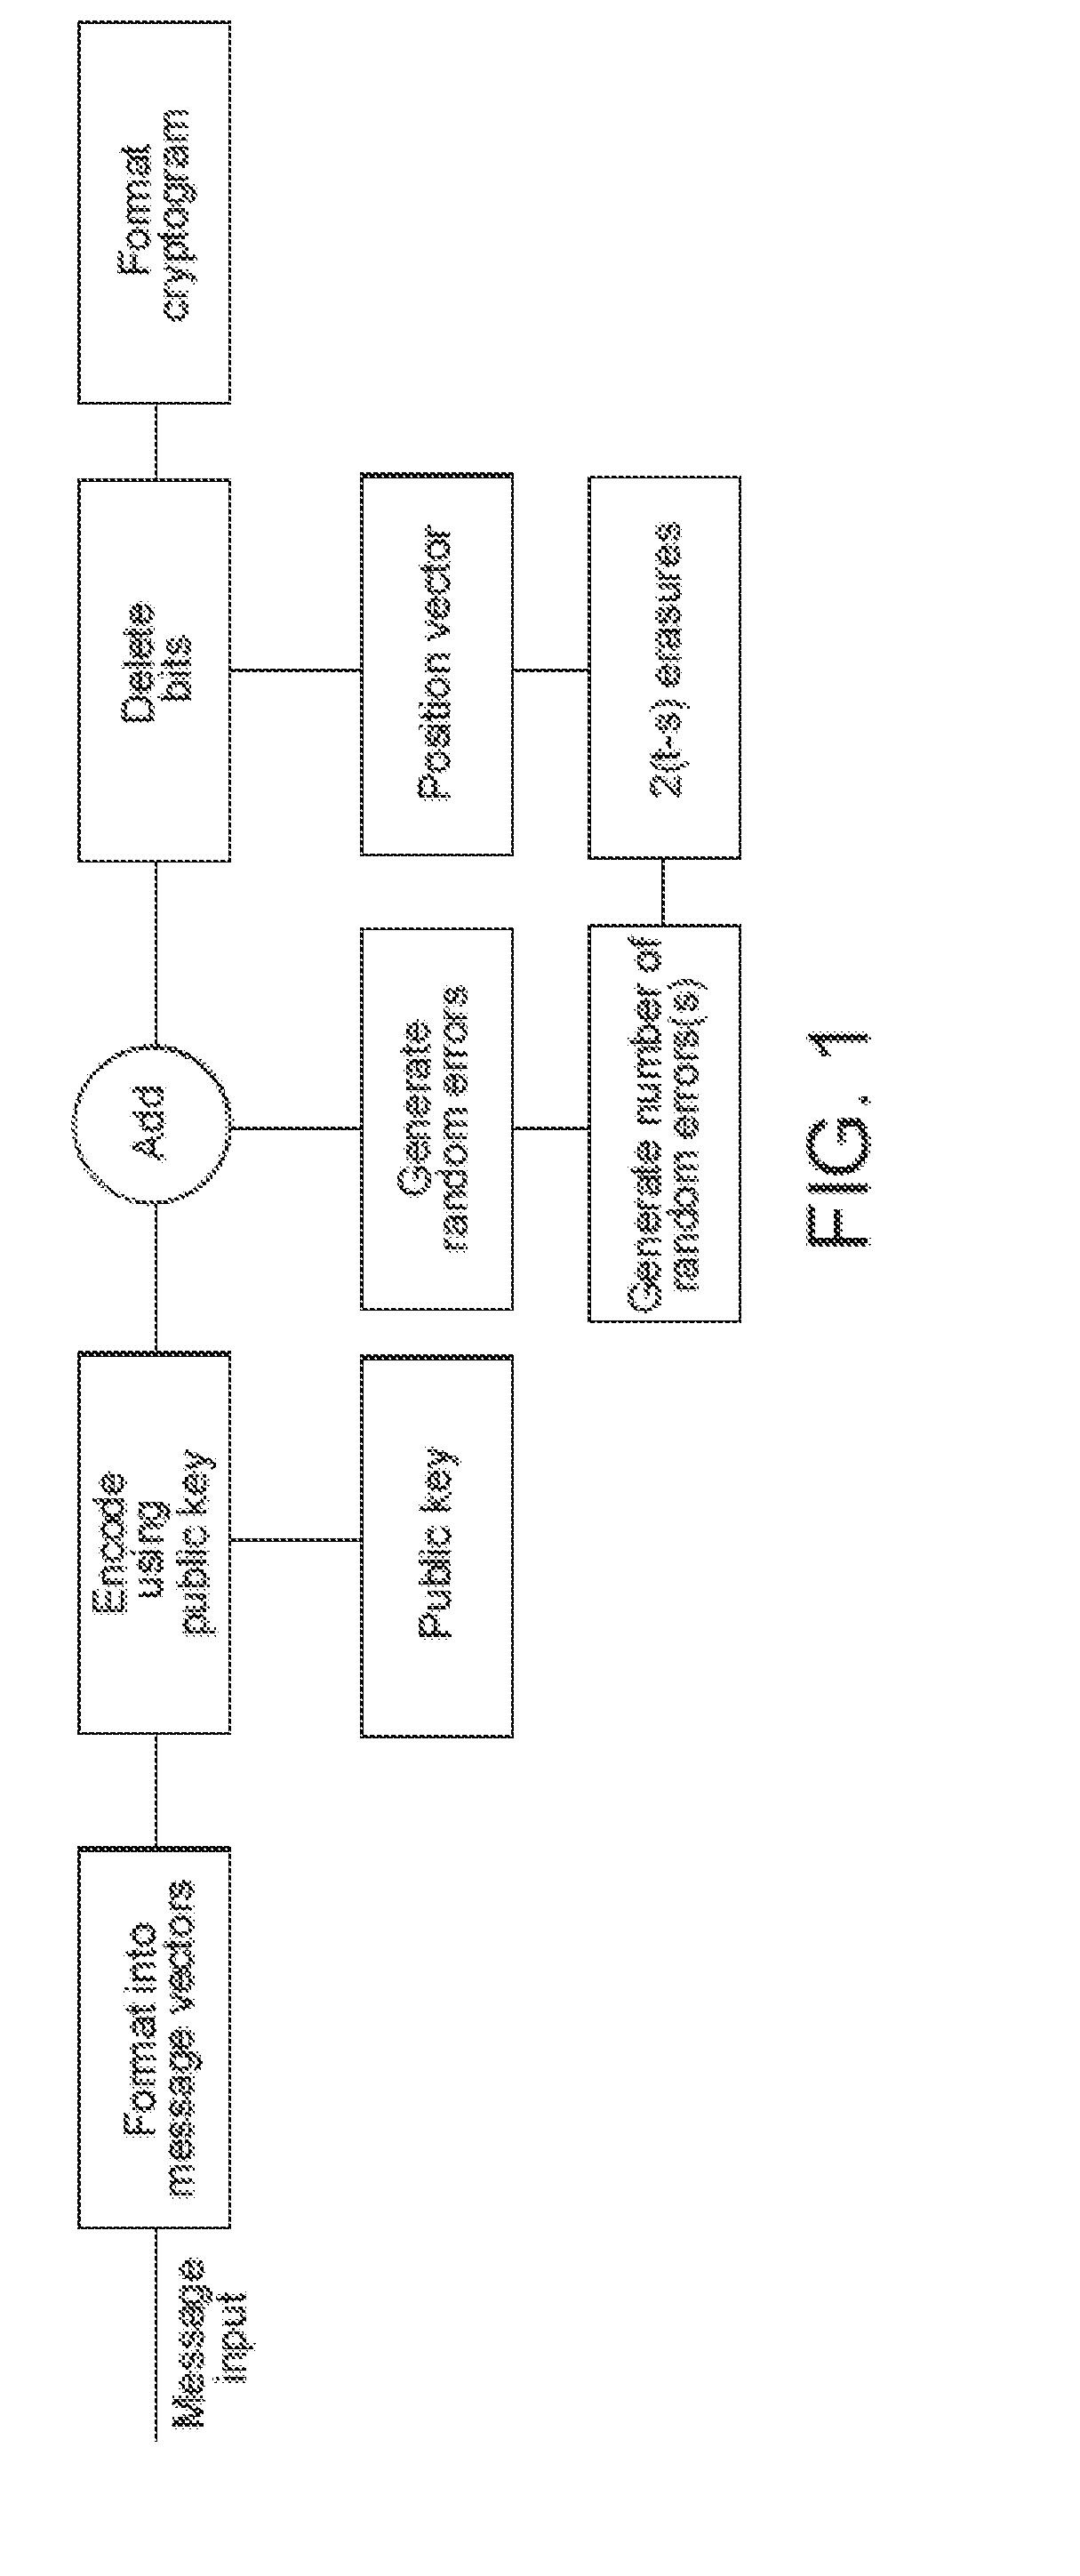
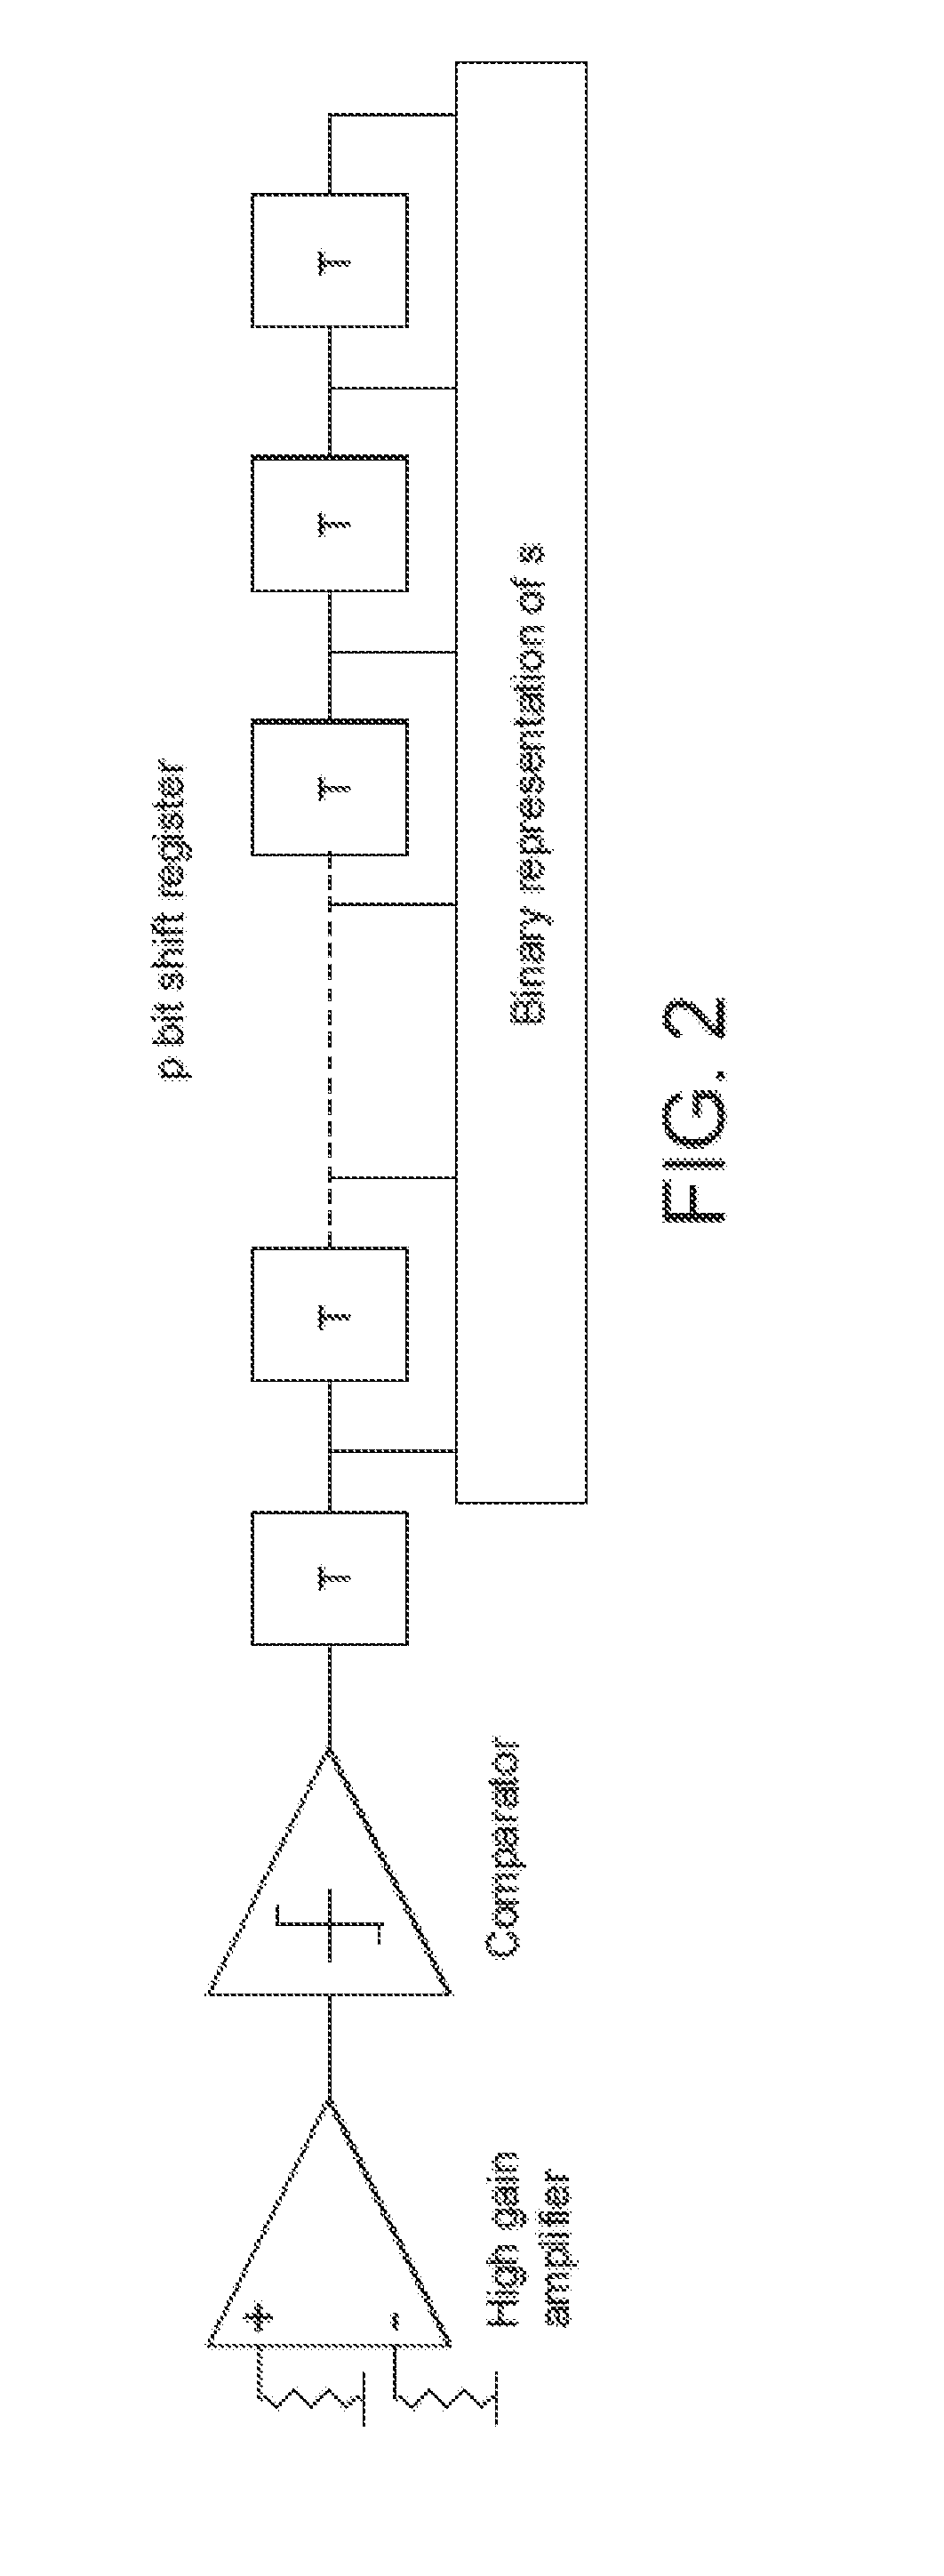
This invention provides improved security of the McEliece Public Key encryption system adding features which make full use of random number generation for given message and cryptogram parameters. Different embodiments of the invention are described which enable the level of security to be traded-off against cryptogram size and complexity. Message vectors are encoded with a scrambled generator matrix, using matrix multiplication to form codeword vectors. Shortened corrupted codewords are generated by corrupting each codeword vector and omitting a predefined number of bits, whereby a cryptogram is formed from the shortened corrupted codewords. Measures are included to defeat attacks based on information set decoding. A number of different applications are given.
Owner:PQ SOLUTIONS LTD
Device, method and program for securely reducing an amount of records in a database
ActiveUS20180129700A1Reducing size of databaseSmall sizeDigital data information retrievalEncryption apparatus with shift registers/memoriesFinancial transactionComputer science
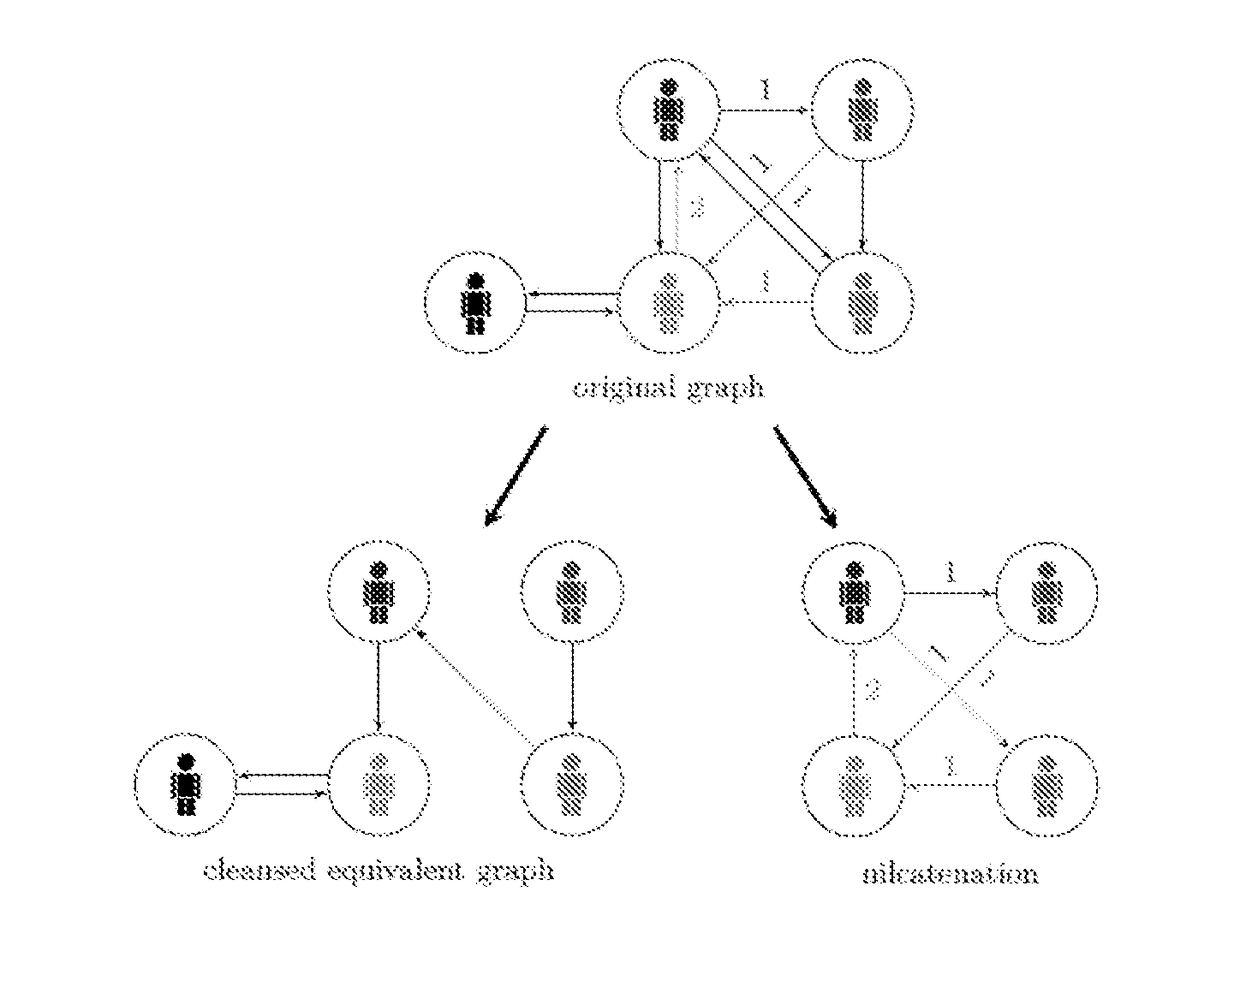
It is proposed a device and method for finding nilcatenations, and proposes nilcatenation detection techniques, which can be applied to blockchains, and even constitute a proof of useful work, as the periodic removal of nilcatenations keeps a ledger size as small as possible. Banks and blockchains need to keep track of an ever-increasing list of transactions between the accounts owned by their users. However, as time goes by, many of these transactions can be safely “forgotten”, in the sense that purging a set of transactions that compensate each other does not impact the network's semantic meaning i.e. the vector Bt of amounts representing the balances of users at a given point in time t. Nilcatenation refers to a collection of past transaction vectors having no effect on Bt. Removing these transactions yields a smaller, but equivalent set of transactions.
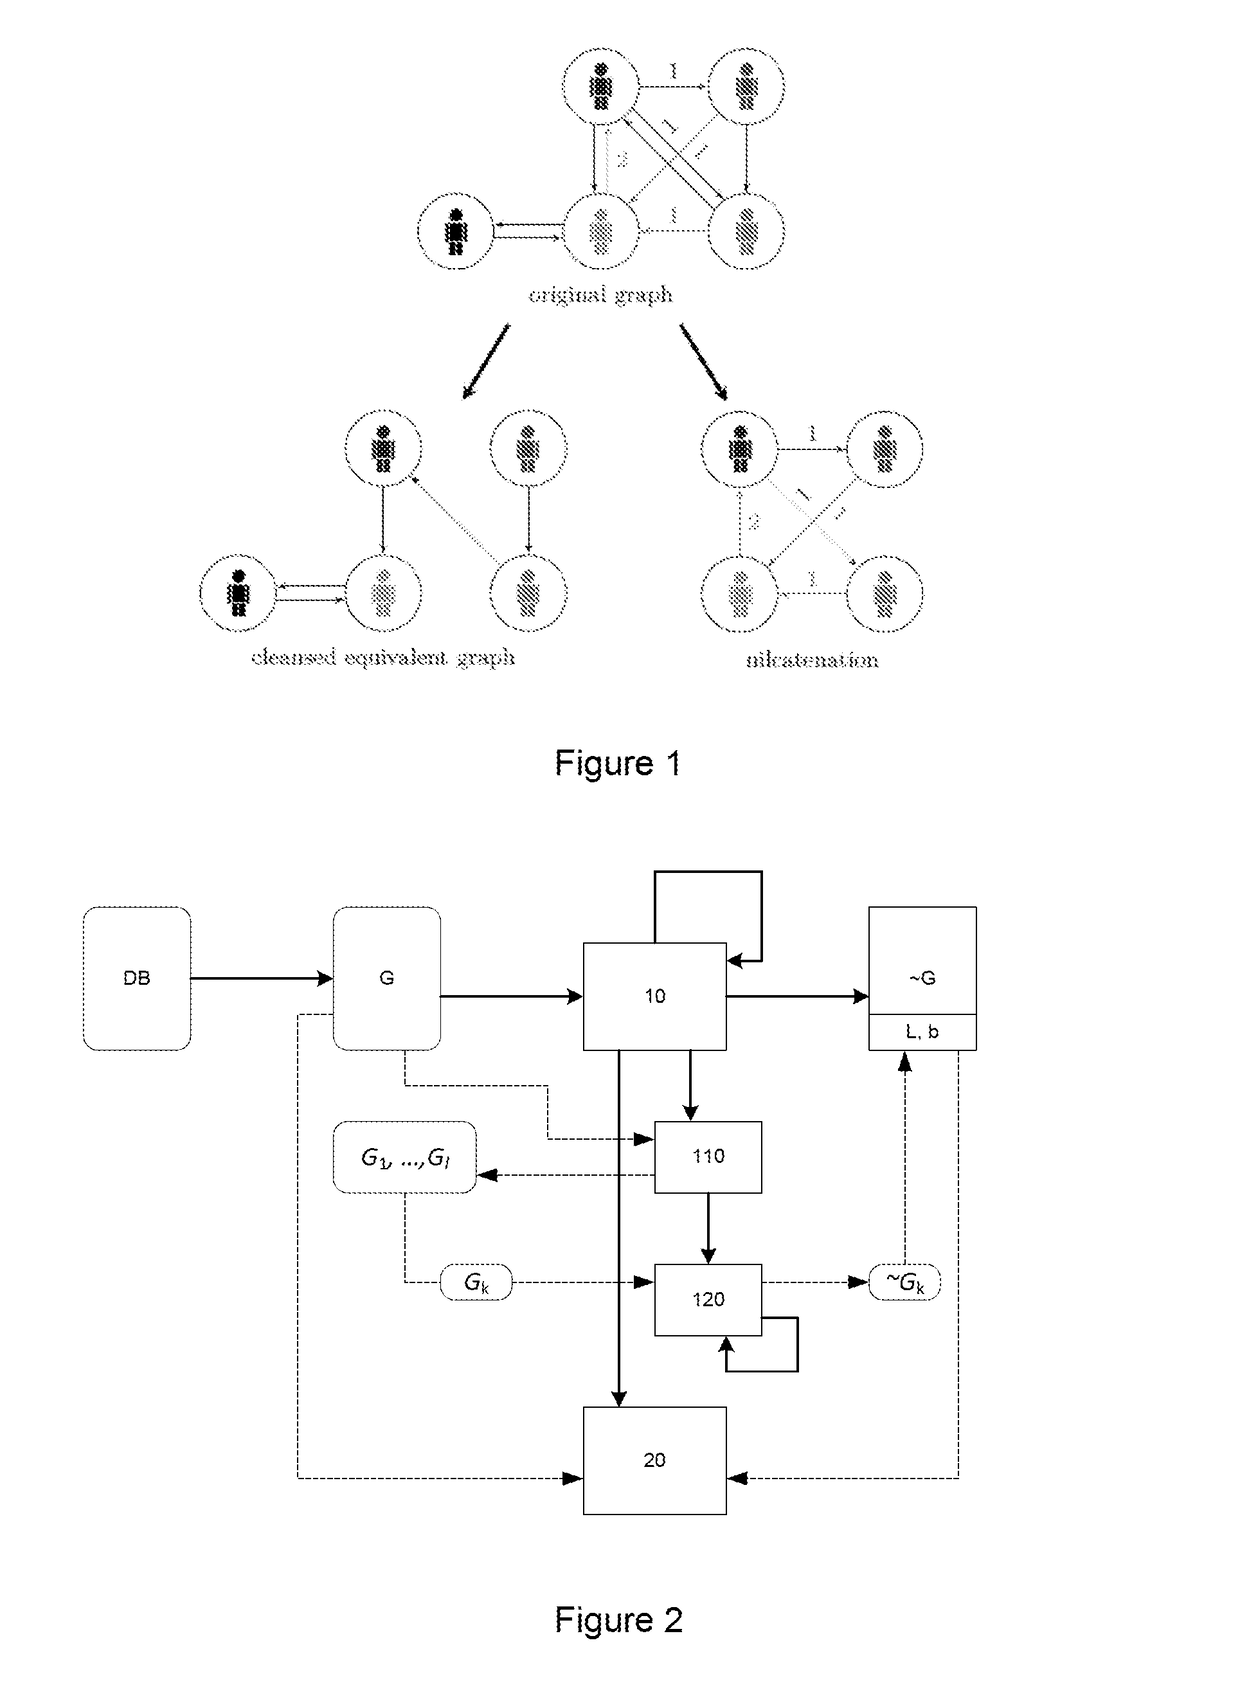
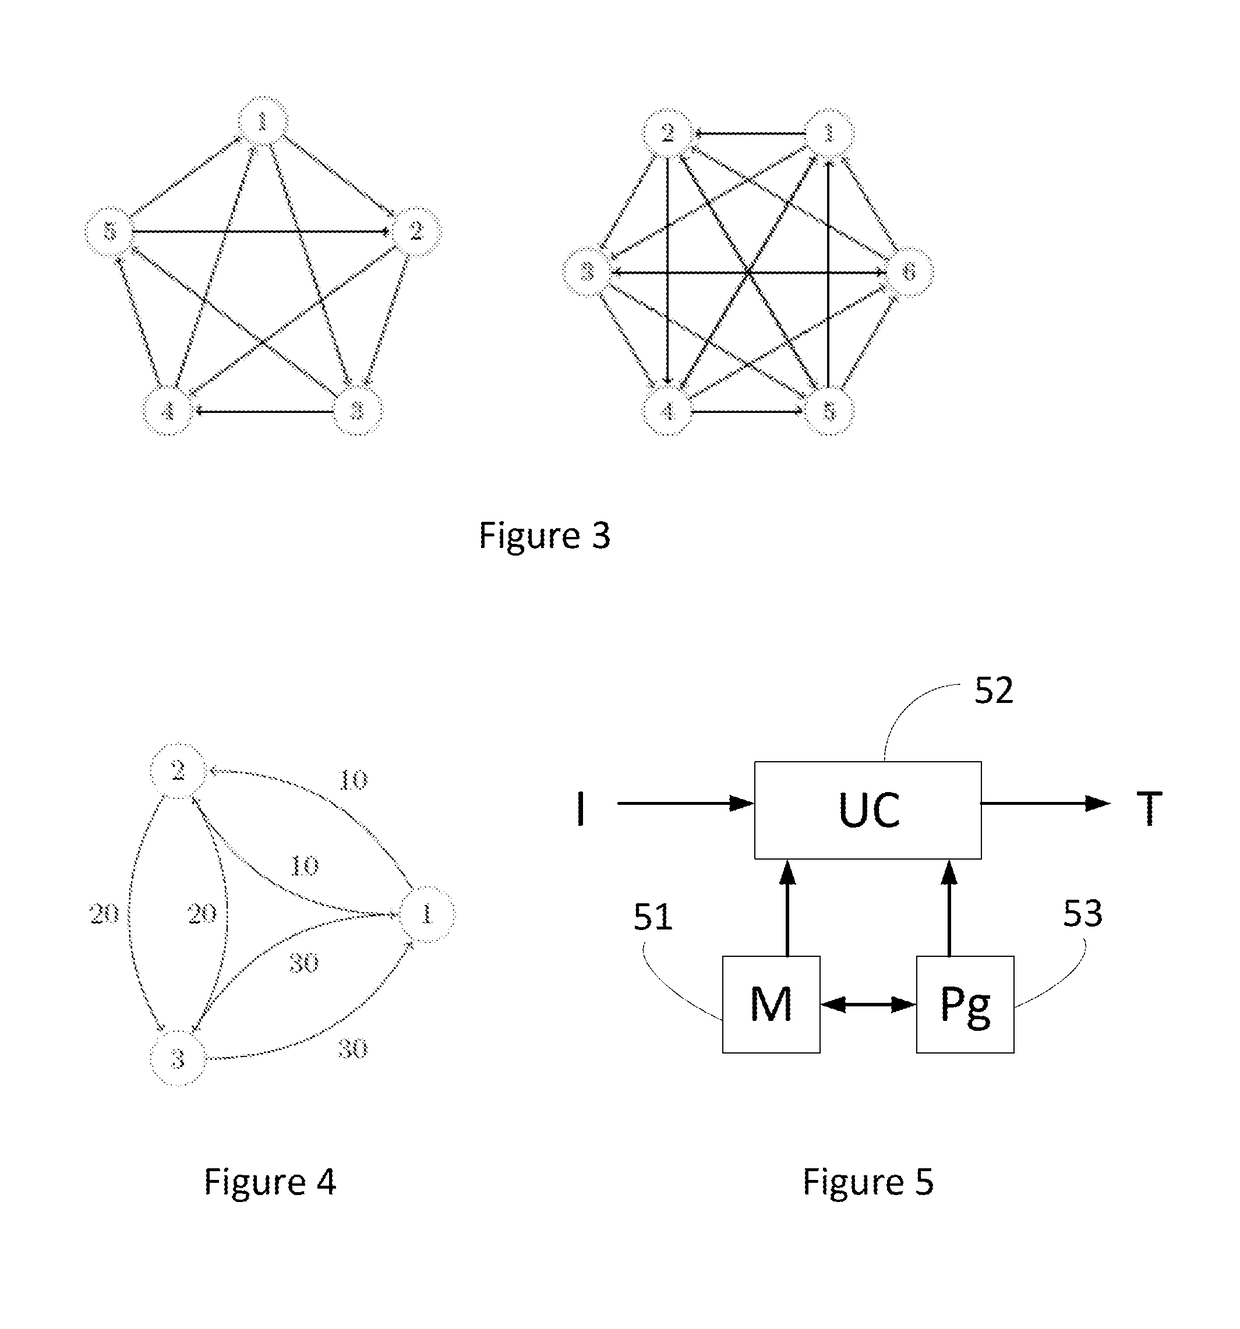
Owner:BANKS & ACQUIRERS INT HLDG
Public key cryptosystem based on goppa codes and puf based random generation
InactiveUS20130094649A1Small sizeImprove securityPublic key for secure communicationSecret communicationEncryption systemRandom number generation
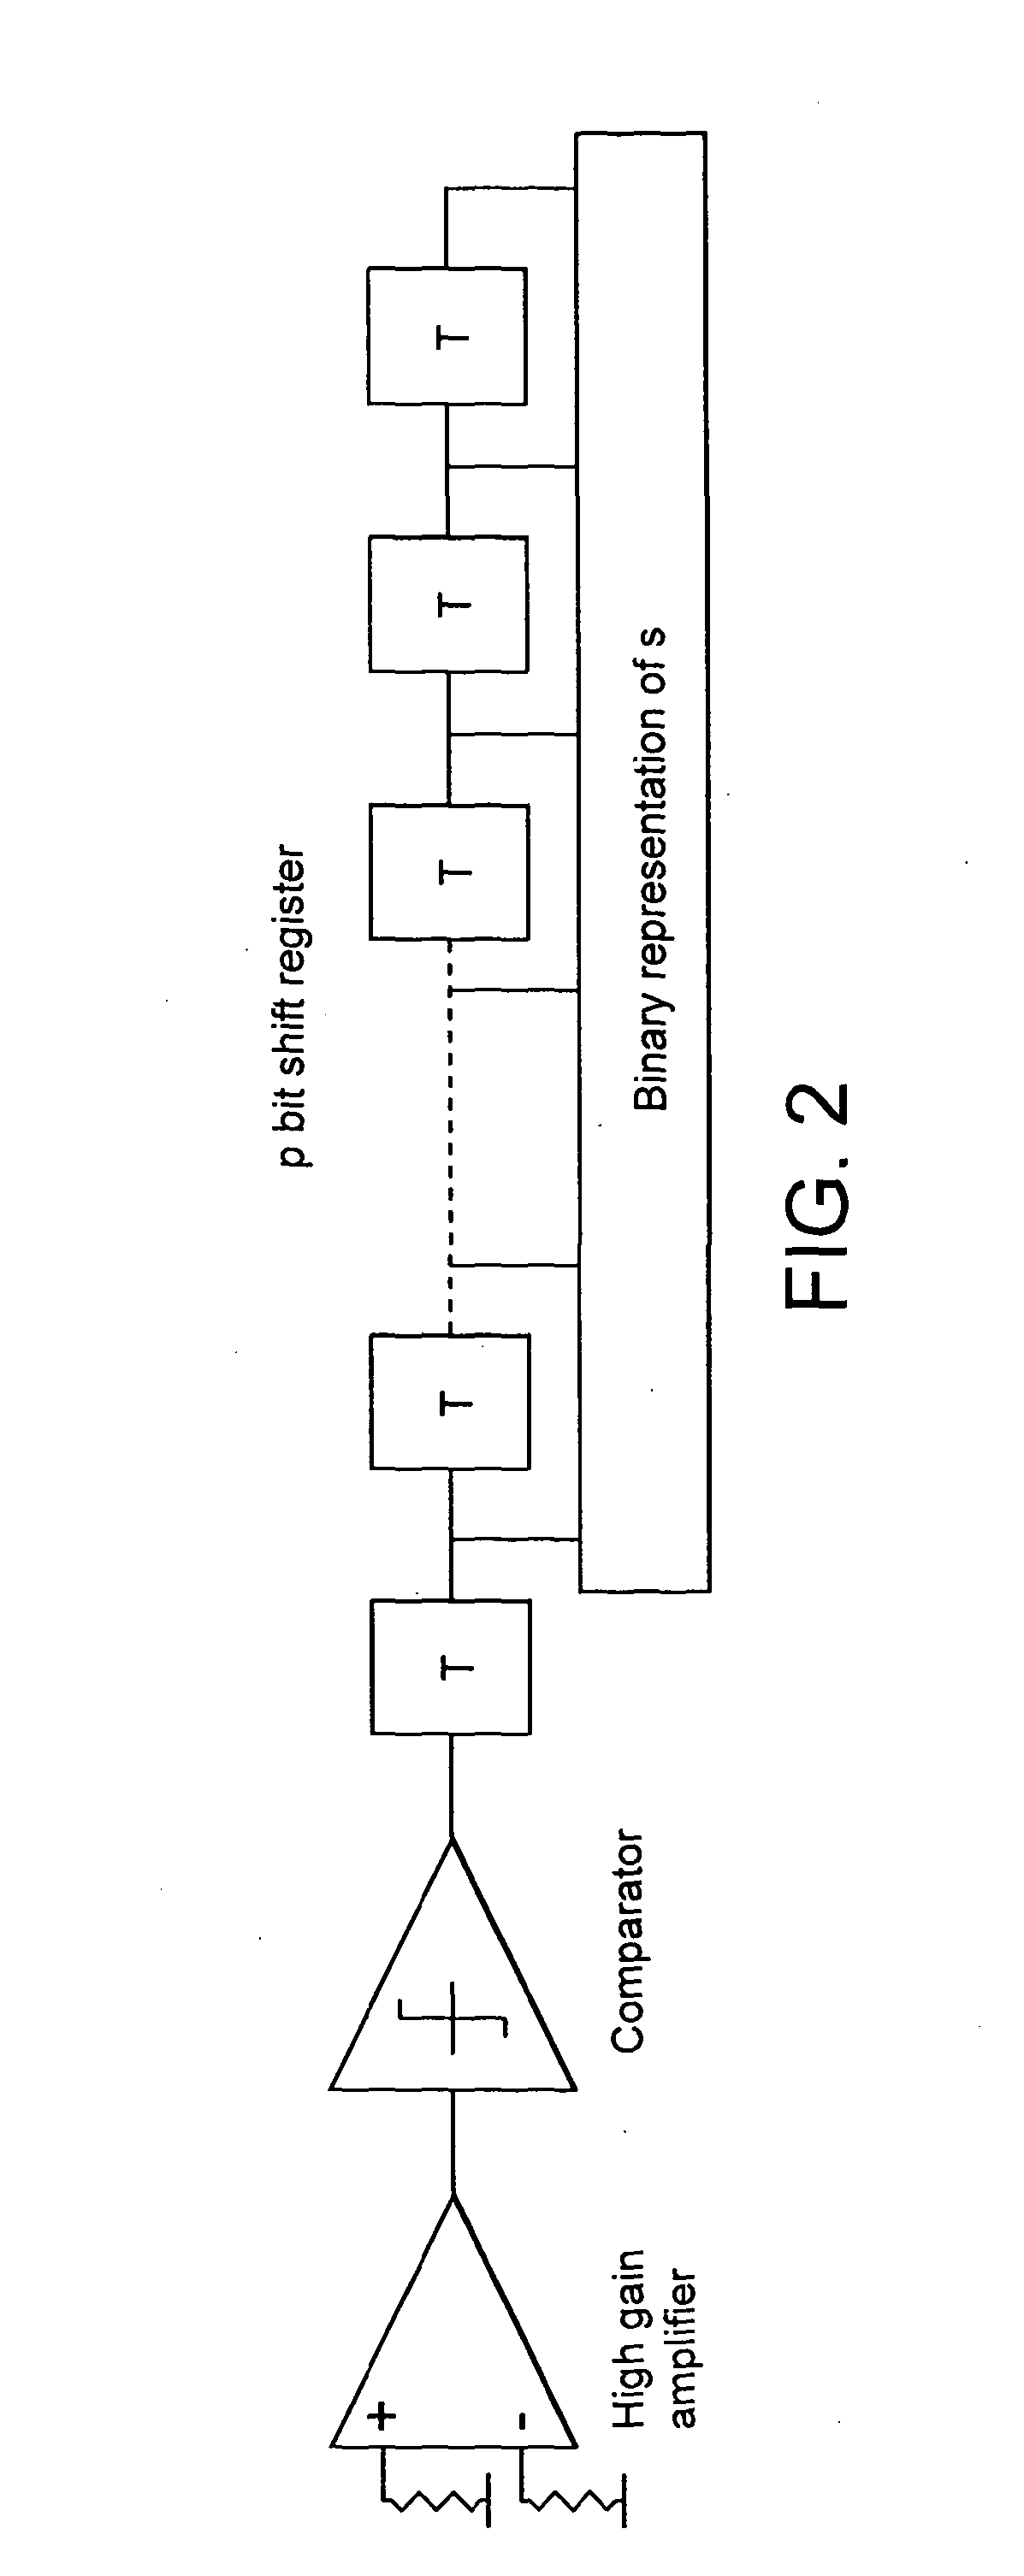
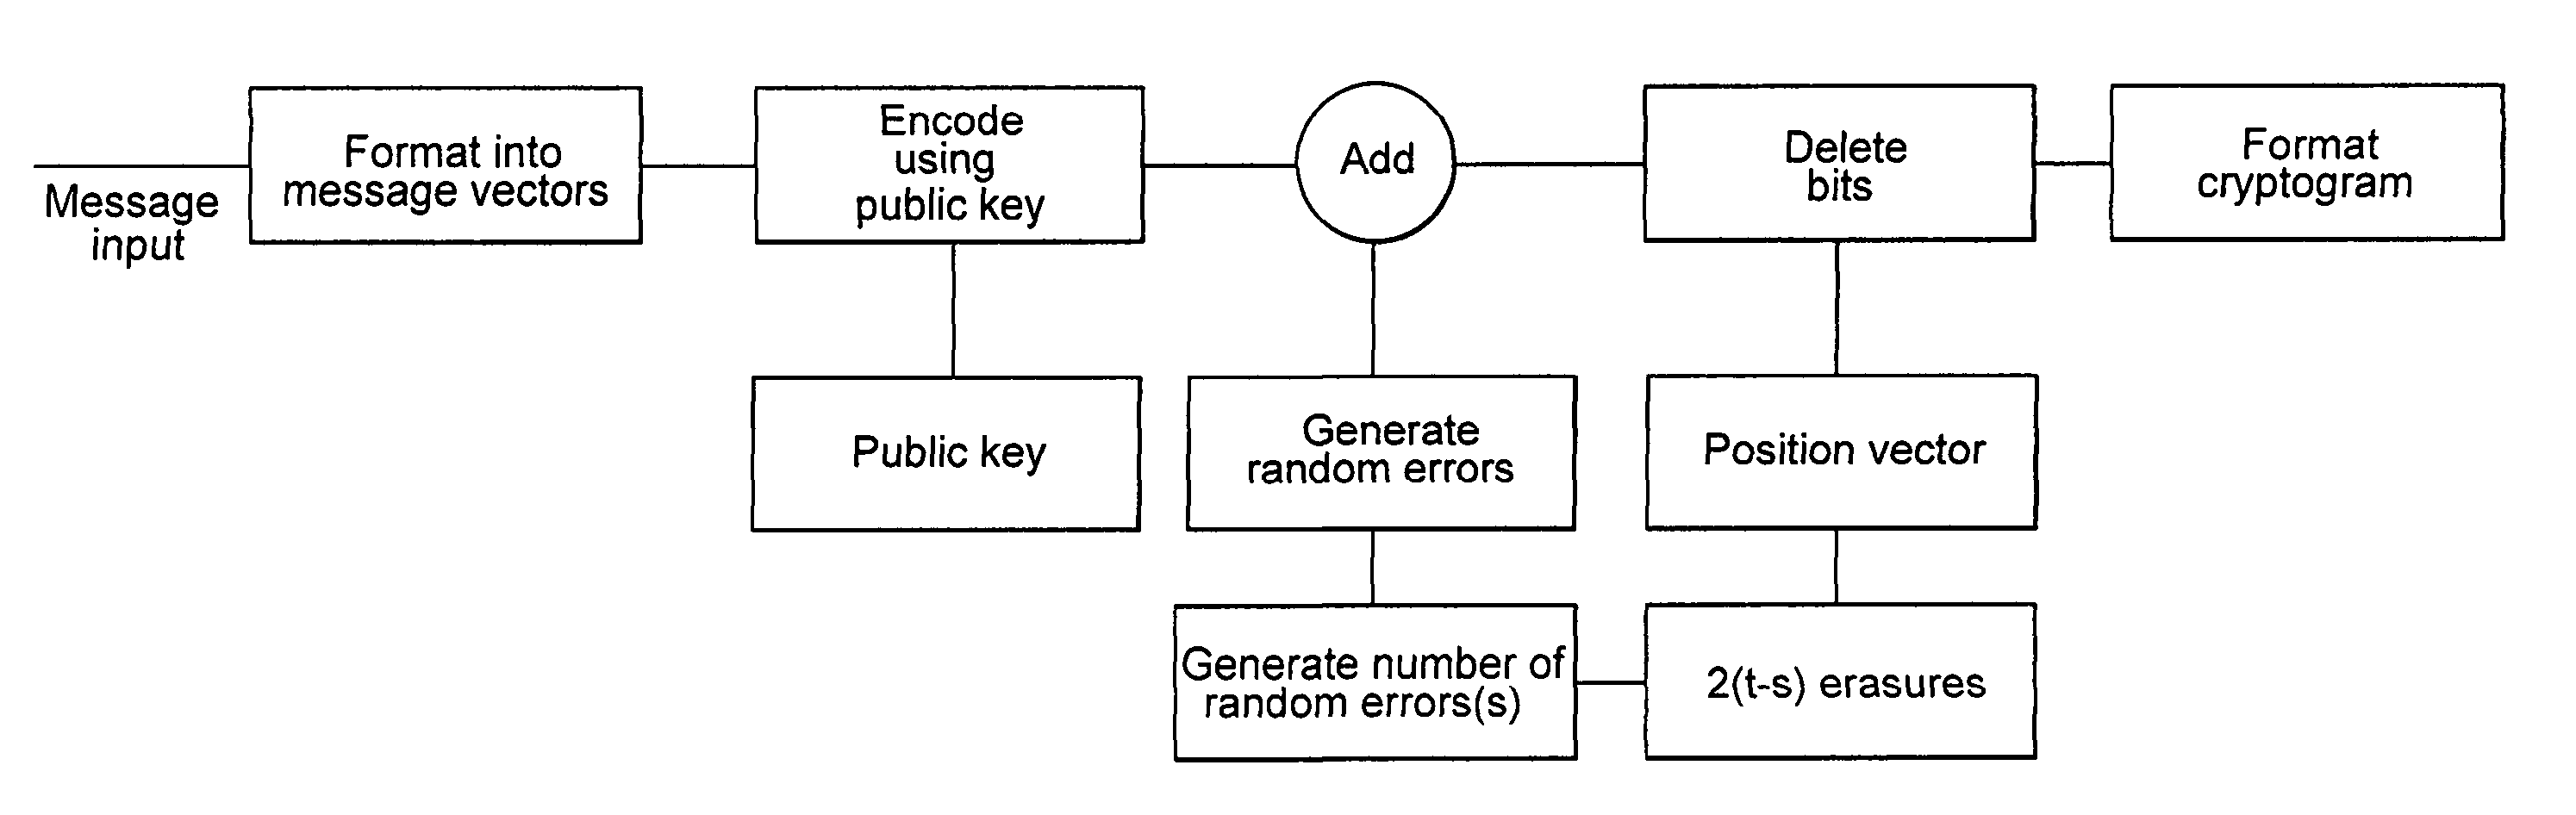
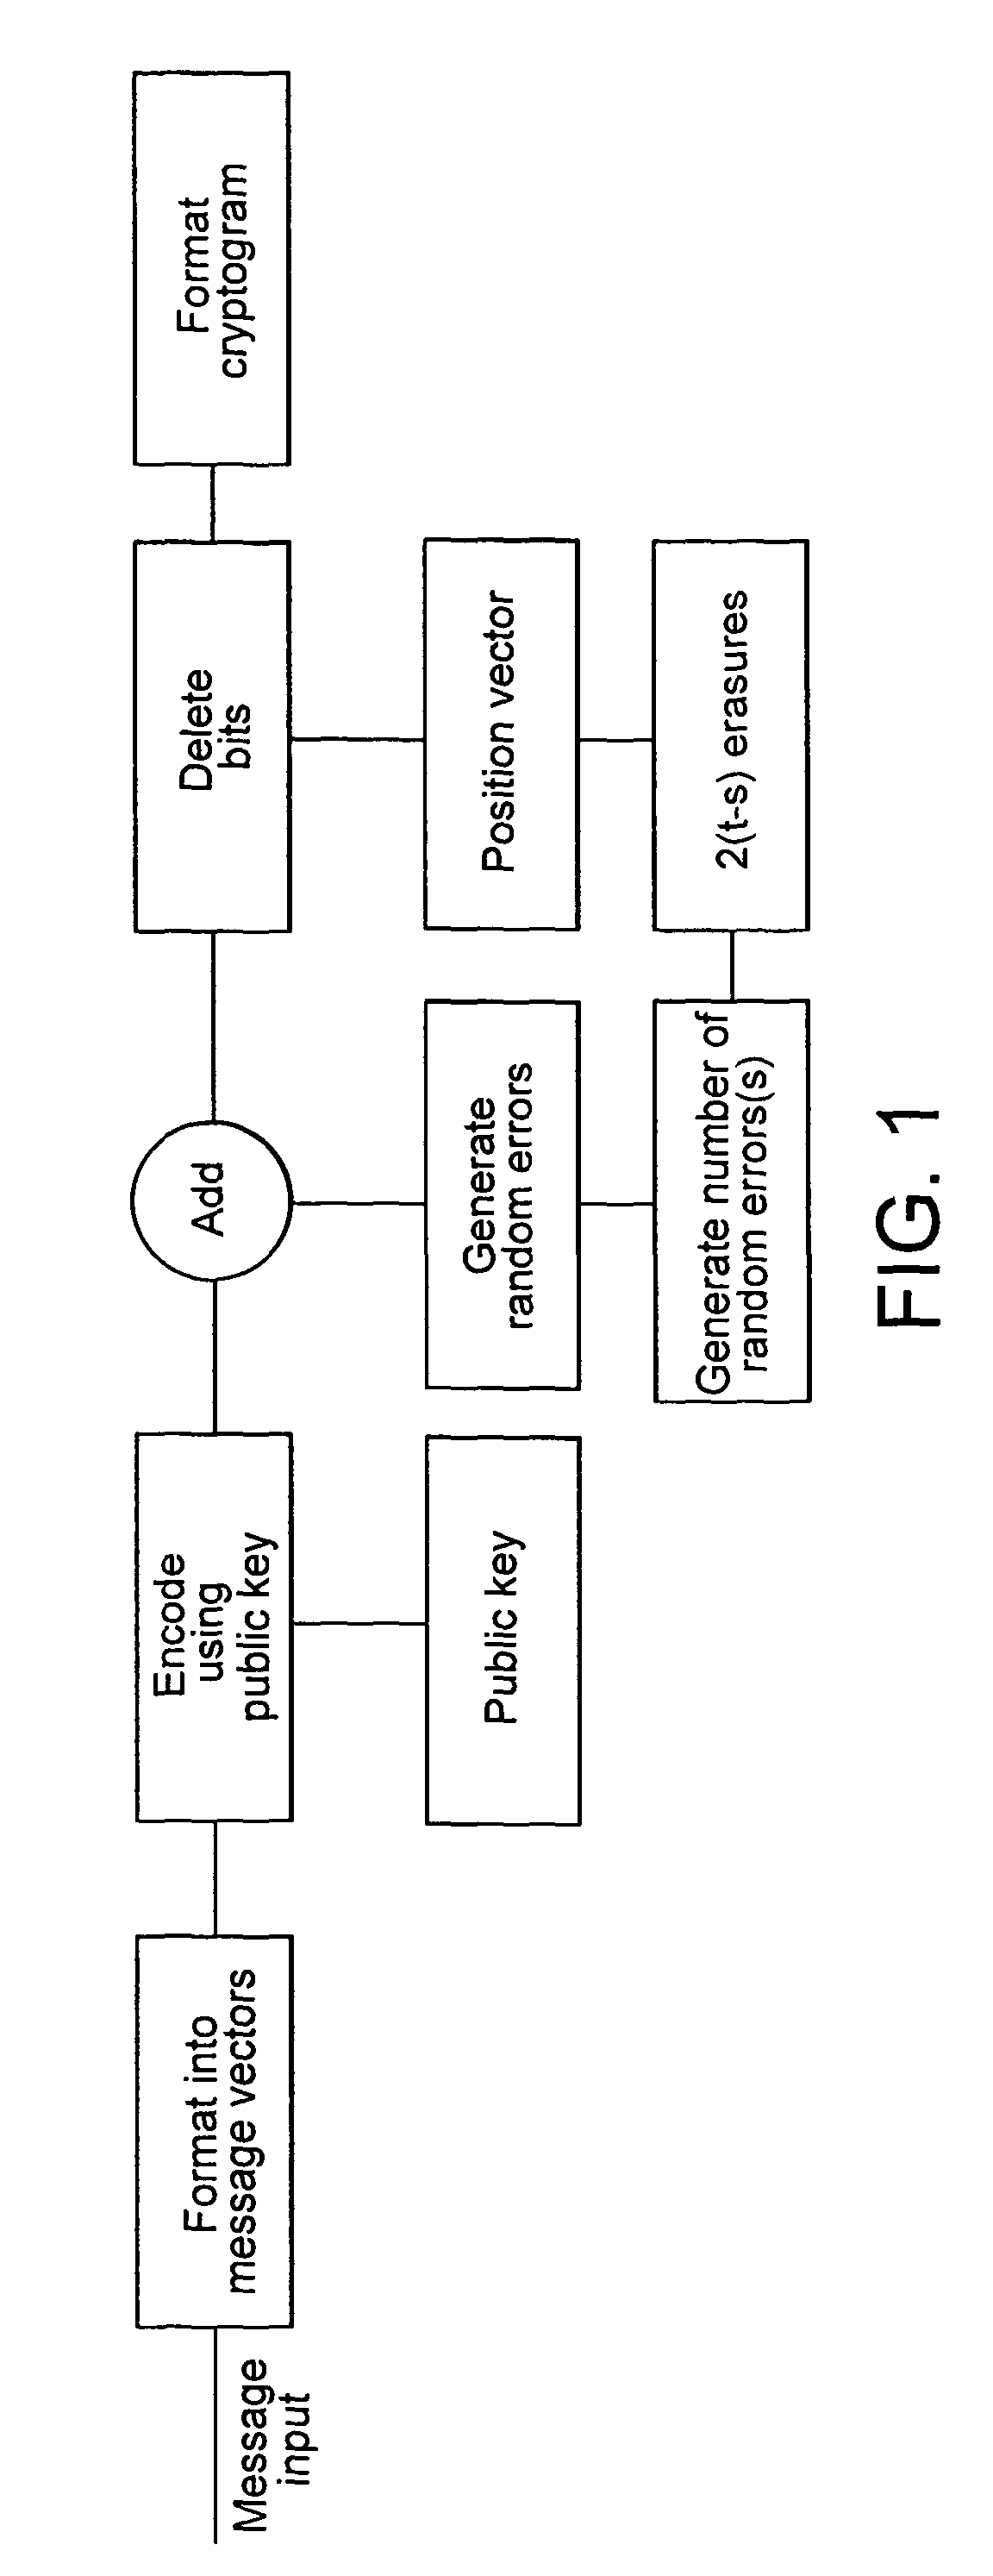
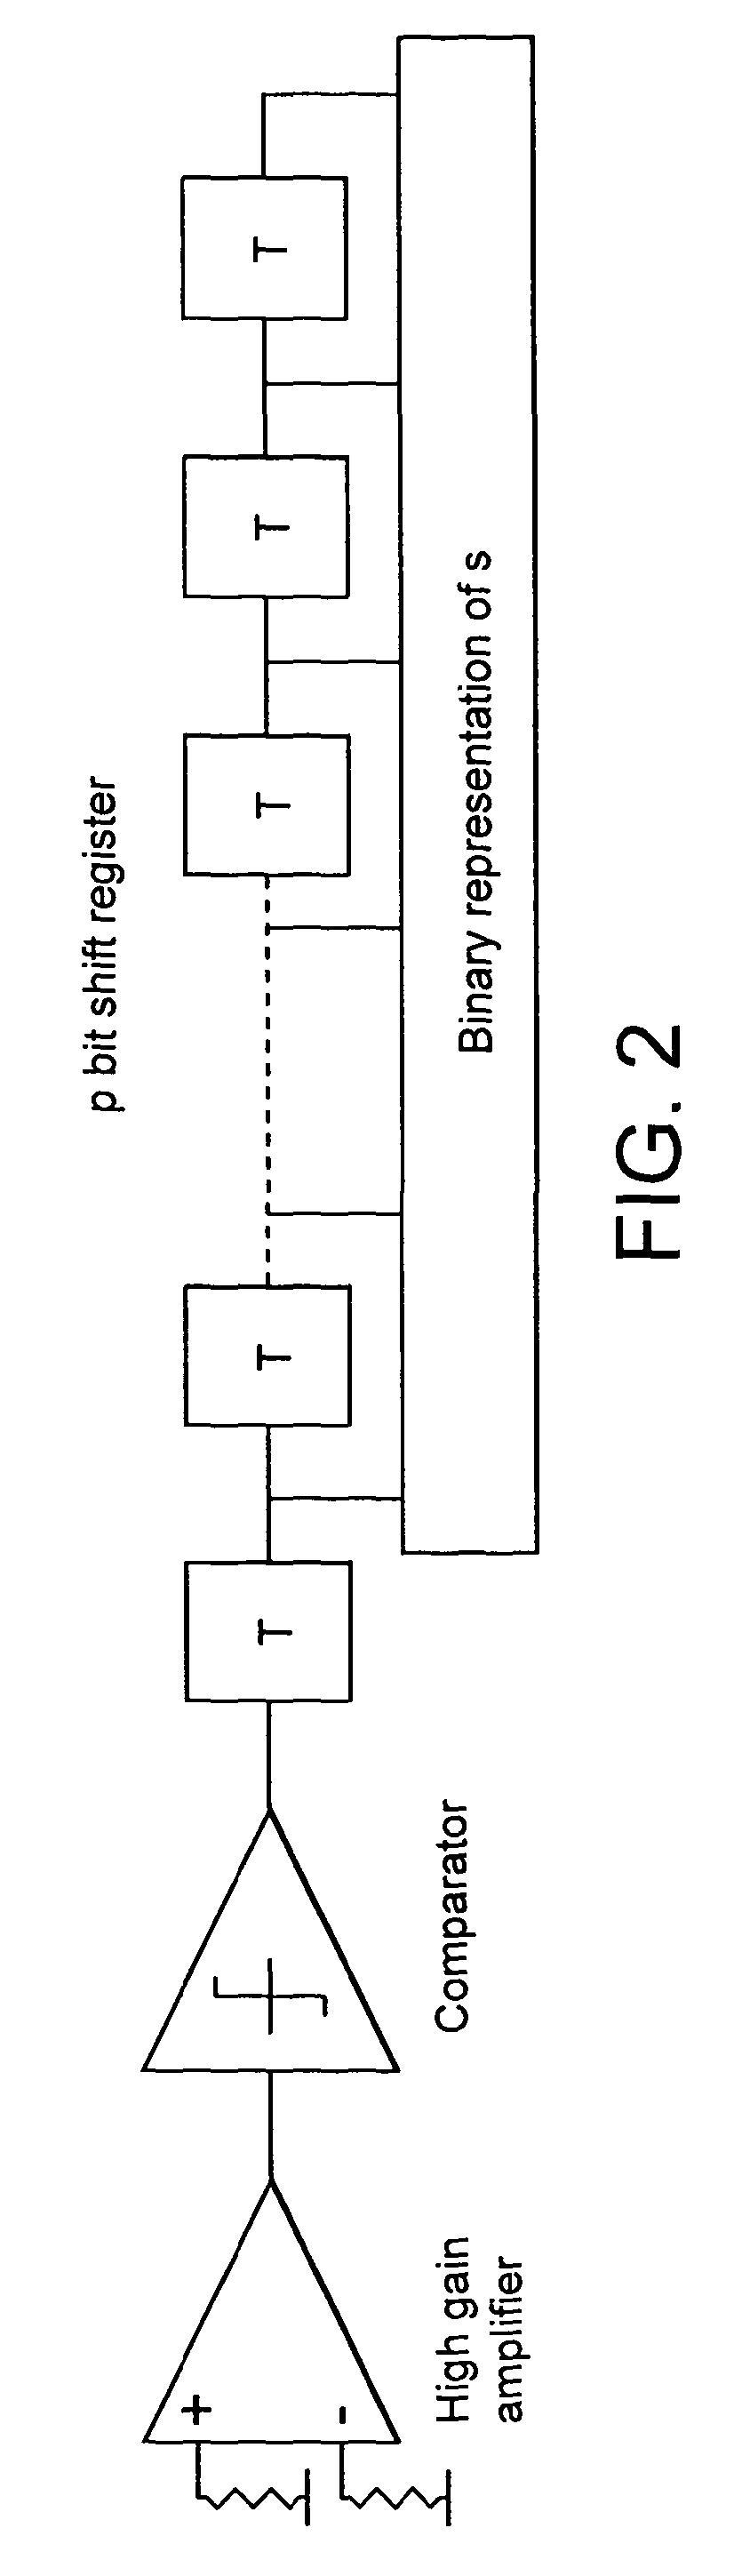
This invention provides improved security of the McEliece Public Key encryption system adding features which make full use of random number generation for given message and cryptogram parameters, using this invention the encrypted message (i.e. the cryptogram) is a truly random function, not a pseudo random function of the message so that even with the same message and the same public key, a different, unpredictable cryptogram is produced each time. With the knowledge of the private key, the random function may be determined from the cryptogram and the message decrypted. Different embodiments of the invention are described which enable the level of security to be traded-off against cryptogram size and complexity. A number of different applications are given.
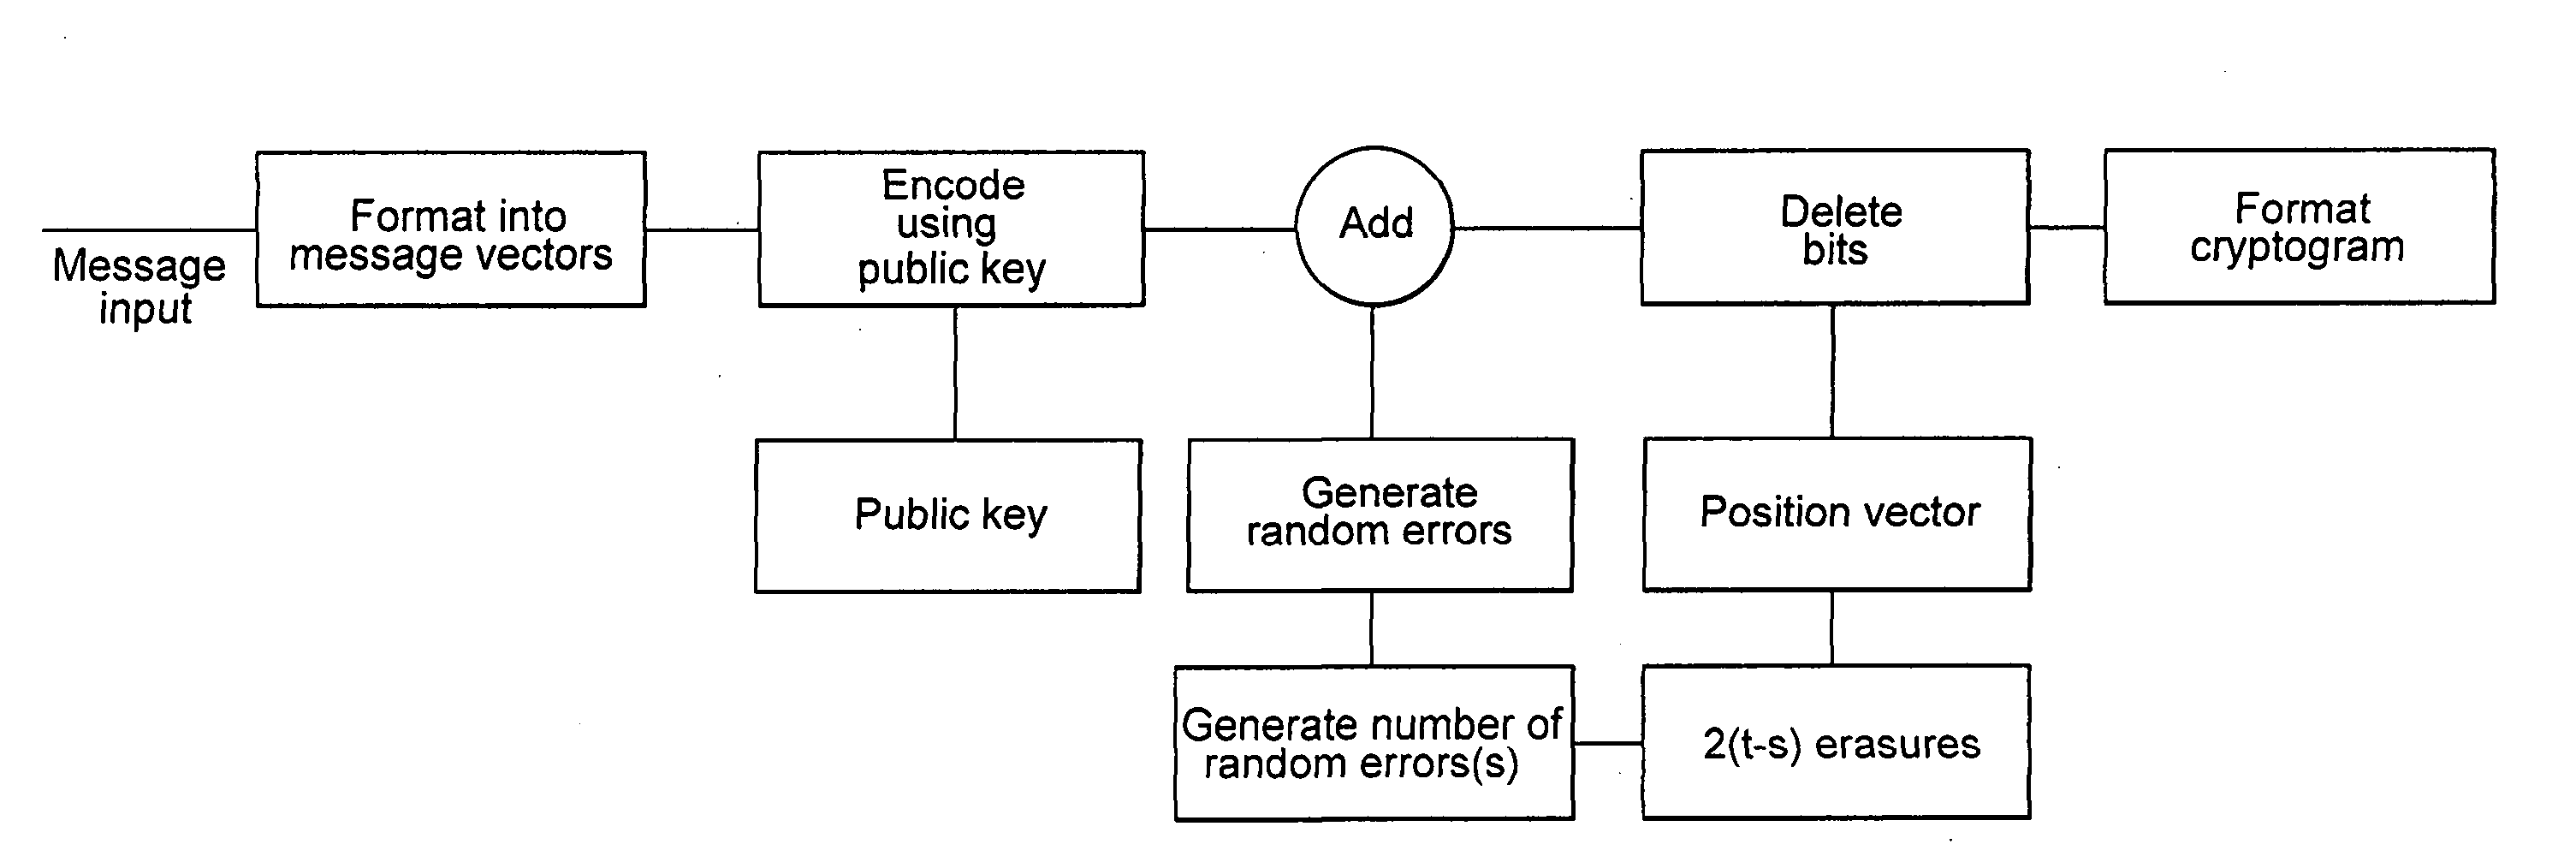
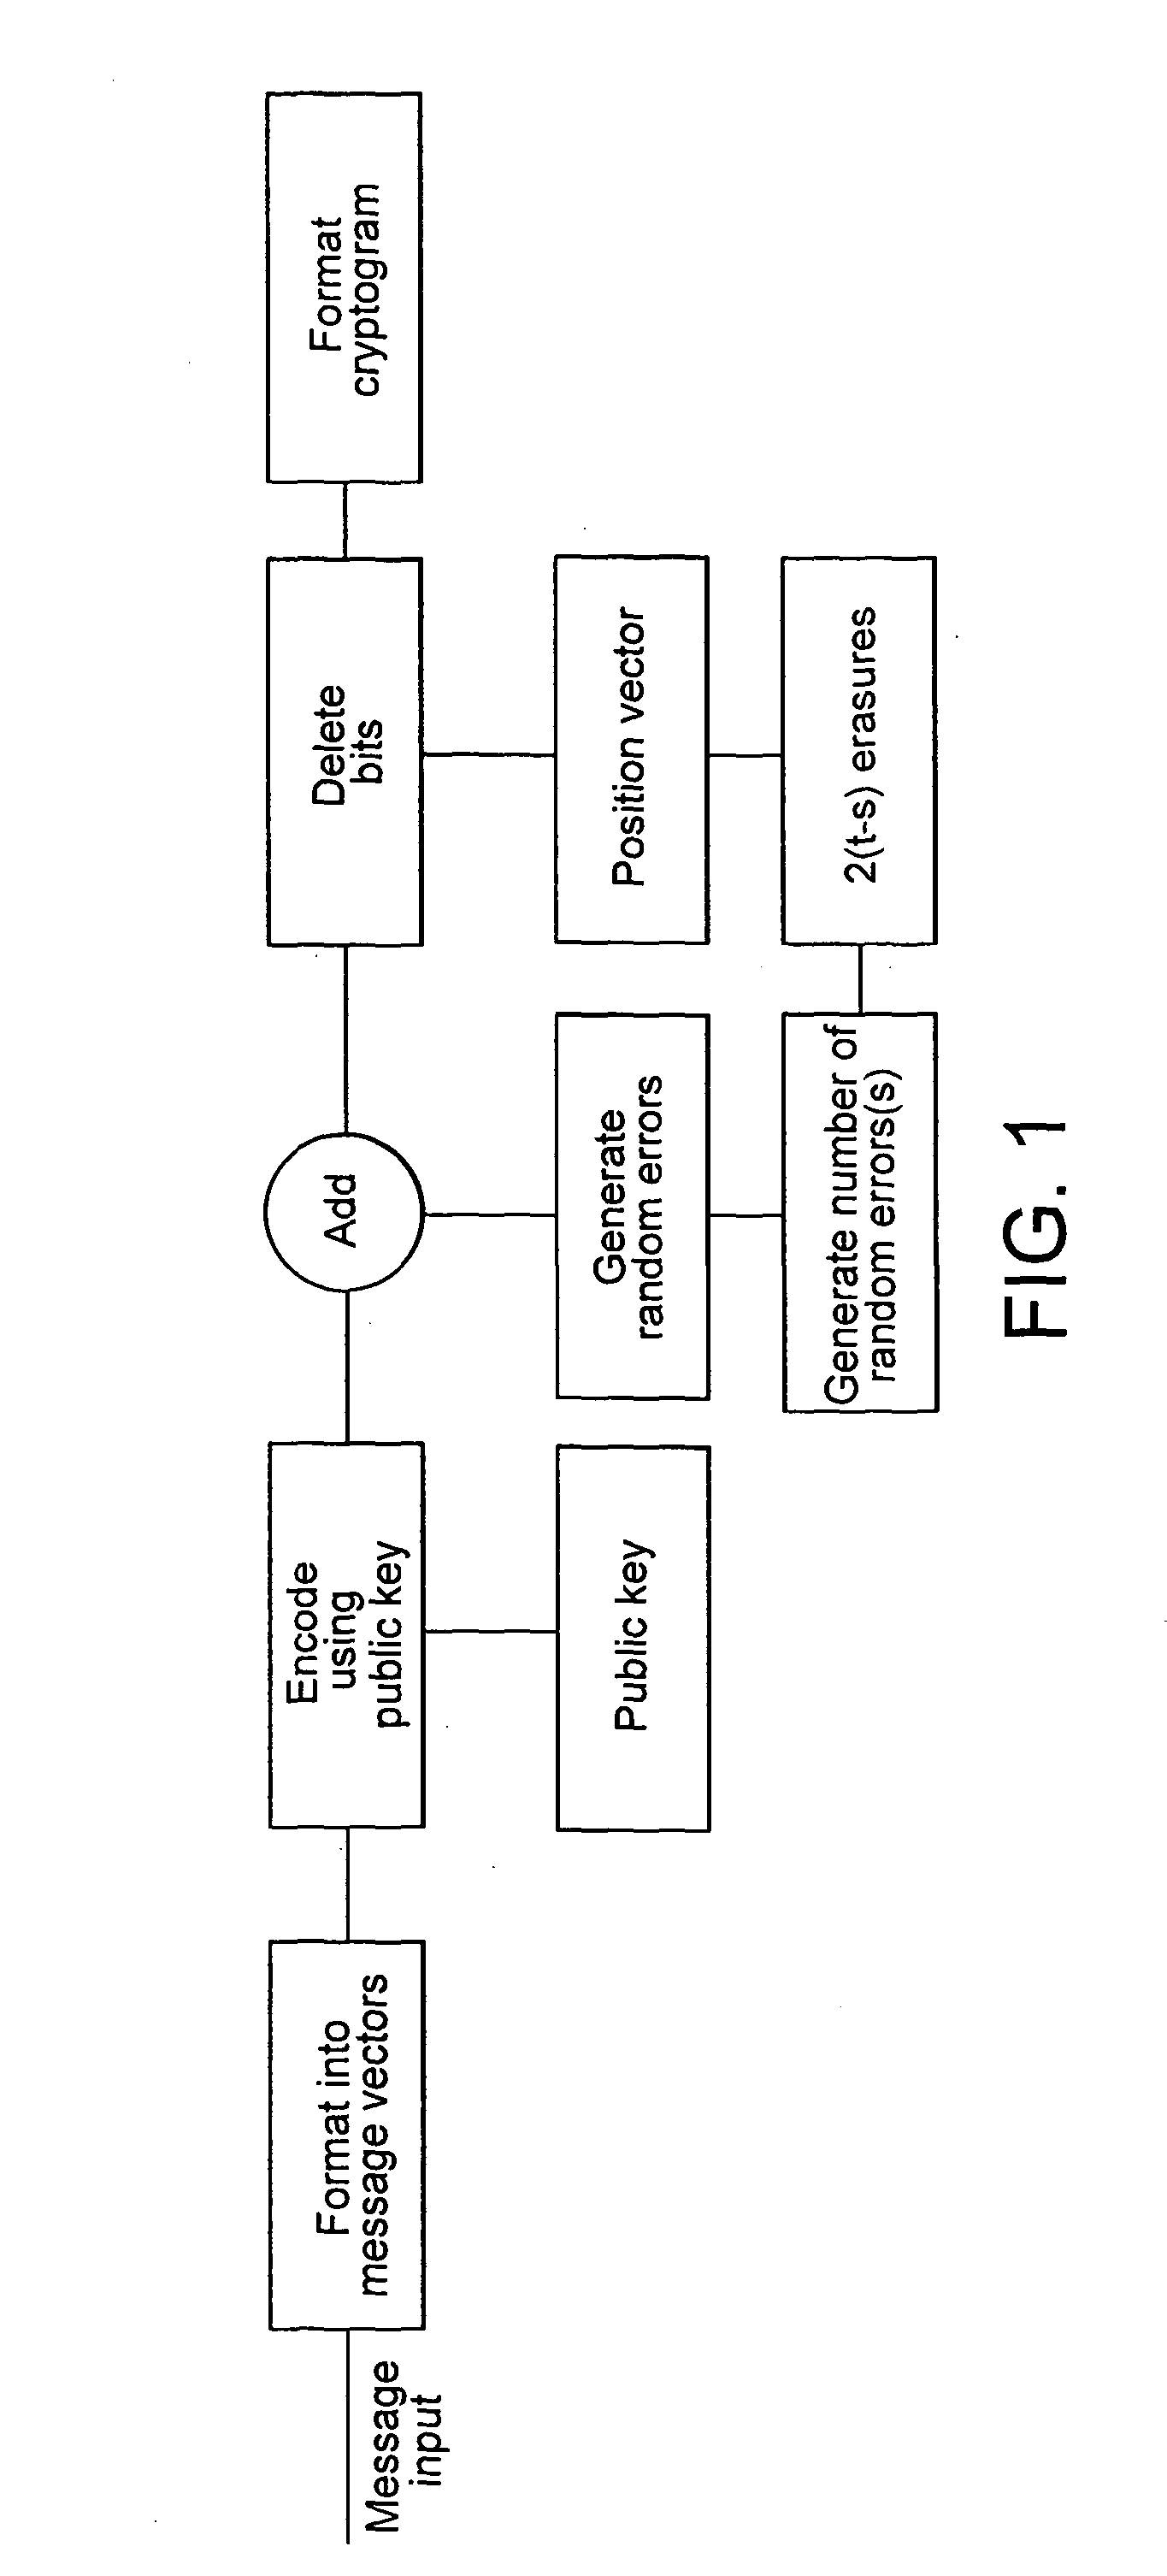
Owner:PQ SOLUTIONS LTD
Server-assisted device-to-device discovery and connection
ActiveUS9654960B2Efficiently setReduce power consumptionAssess restrictionNetwork topologiesIp addressService discovery


Owner:QUALCOMM INC
Method, device and system for network prepayment
ActiveCN101686289AReduce messagingSave resourcesMetering/charging/biilling arrangementsPrepayment telephone systemsAuthorizationBilling system
The invention discloses a method, a device and a system for network prepayment, which are used for solving the problem that too many interactions of corrected authorization messages exist between an access server and an authentification, authorization and charging server and occupy too many resources. The method mainly comprises the following step: the authentification, authorization and chargingserver responds an authentification response message indicating the maximum user on-line time length or available time length to the access server according to a credit control response primary message sent by an on-line charging system, and in each subsequent charging time length, only charges for the previous charging time length and pre-distributes the work for the next available time length. The method can reduce the message transmission between the access server and the authentification, authorization and charging server, thereby saving the resources.


Owner:HUAWEI TECH CO LTD
Method, device and system for processing instant messaging information, and storage medium
ActiveCN107154894ASave resourcesReduce messagingData switching networksInput/output processes for data processingMessage flowNetwork packet
The embodiments of the invention disclose a method, a device and a system for processing instant messaging information, and a storage medium. The method comprises the following steps: a navigation menu request carrying a target user identifier is sent to a server in an instant messaging dialog window with a target user; and after a navigation menu data packet returned by the server according to the target user identifier is received, a navigation operation interface is generated according to the navigation menu data packet, and the navigation operation interface is displayed in the instant messaging dialog window. Through the scheme, the number of process messages in the signaling process and message flow between users and a server can be reduced greatly, the operation efficiency can be improved, and network resources can be saved.


Owner:TENCENT TECH (SHENZHEN) CO LTD
Method for informing that the network supports the mobile IP enhancement capability
InactiveUS20090109878A1Improve abilitiesSave resourcesSpecial service provision for substationMultiplex system selection arrangementsPacket data serving nodeTelecommunications
A method for informing that the network supports the mobile Internet Protocol (IP) enhancement capability includes the network sending a message indicating the mobile IP enhancement capability of the network to a mobile station (MS). If the MS supports the mobile IP enhancement capability, the MS requests the enhanced mobile IP service according to the mobile IP enhancement specifications. If the MS does not support the mobile IP enhancement capability, the MS requests the mobile IP service according to the specifications which do not support mobile IP enhancement. The packet data access gateway may be a packet data serving node (PDSN) or a controlling access point (CAP) in a Code Division Multiple Access (CDMA) evolving network. Therefore, the method provided by the present disclosure enables the MS to learn the mobile IP enhancement capability of the network without having to resending requests, thus avoiding the waste of air interface resources.


Owner:HUAWEI TECH CO LTD
Public key cryptosystem based on goppa codes and puf based random generation
InactiveUS8958553B2Increase the number ofImprove securityPublic key for secure communicationSecret communicationTrade offsCryptogram
This invention provides improved security of the McEliece Public Key encryption system adding features which make full use of random number generation for given message and cryptogram parameters, using this invention the encrypted message (i.e. the cryptogram) is a truly random function, not a pseudo random function of the message so that even with the same message and the same public key, a different, unpredictable cryptogram is produced each time. With the knowledge of the private key, the random function may be determined from the cryptogram and the message decrypted. Different embodiments of the invention are described which enable the level of security to be traded-off against cryptogram size and complexity. A number of different applications are given.
Owner:PQ SOLUTIONS LTD
Data exchange method and device
ActiveCN109429180AImprove performanceRun fastConnection managementBroadcast service distributionTrunkingBroadband
The embodiment of the invention provides a data exchange method and device, applied to a broadband trunking communication (B-TrunC) system, the B-TrunC system comprises a trunking core network, a trunking base station and a trunking terminal, the trunking core network comprises an eMME, and the method comprises the following steps: the eMME judges whether the trunking terminal is in an ECM IDLE state or not; when the trunking terminal is in the ECM IDLE state, the eMME establishes a dedicated bearer and a default bearer between the eMME and the trunking base station at the same time; and the eMME performs data exchange with the trunking base station by virtue of the dedicated bearer and the default bearer. The embodiment of the invention solves the problem that call delay of voice group calling is long in a scene that the eMME releases a first context connection with the trunking base station, signaling interaction messages inside the trunking core network are also reduced by one pair,and a TCF at a trunking core network side establishes the original dedicated bearer and a shared trunking dedicated bearer at the same time, so that delay is greatly shortened.


Owner:DATANG MOBILE COMM EQUIP CO LTD
Method for realizing period position updating
InactiveCN101827440AReduce messagingSave vital resourcesHigh level techniquesWireless communicationComputer scienceUser equipment
The invention provides a method for realizing period position updating, which comprises the following steps that: when an user equipment UE access pack under the exchange domain access condition simulates the CS core network under a circuit exchange domain CSoPS structure, gateway equipment IWF requires that the UE is not necessary to execute the CS period position updating; network equipment or the UE obtains the position updating period; and when the time of the position updating period is reached, the IWF obtains the position information of the UE and carries out the period position updating on the CS core network. Through the method of the invention, the messages on the vent hole resources and the terminal electric power resources in the prior art can be effectively reduced, and the importance resources can be saved.
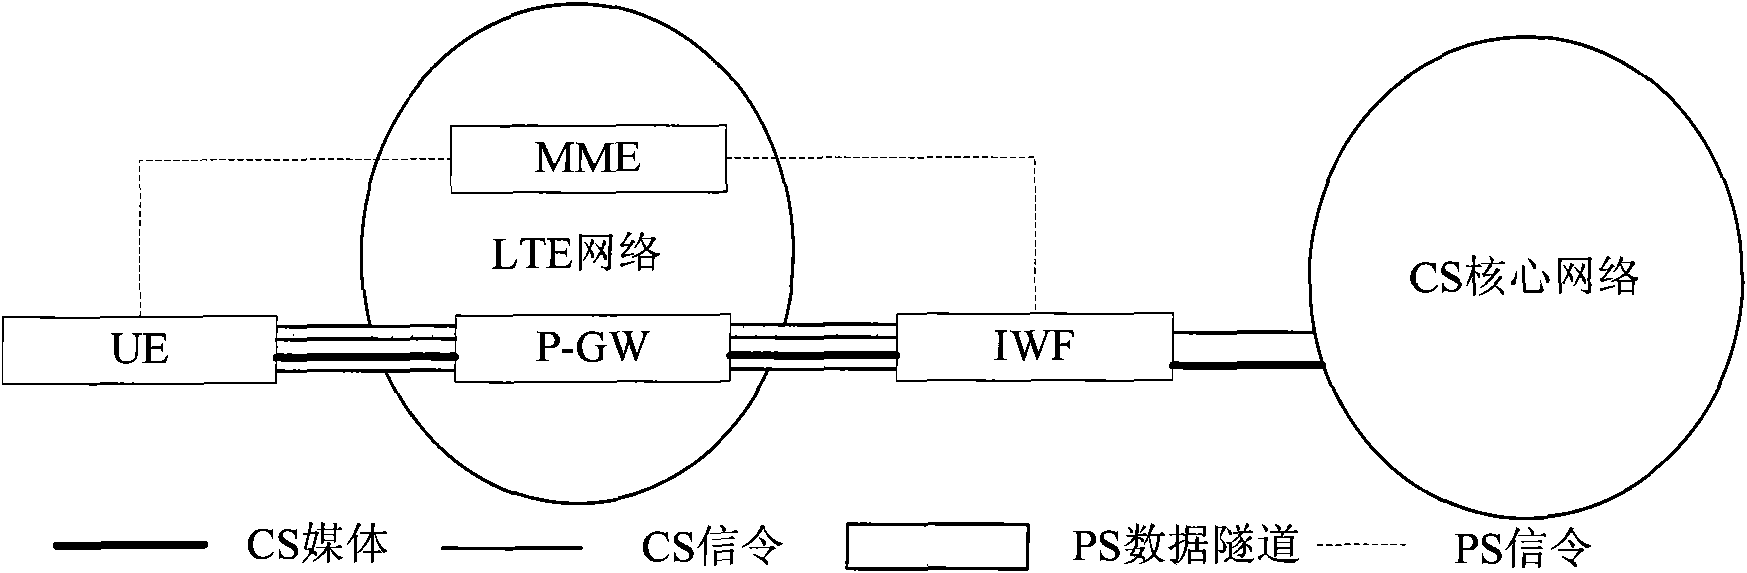
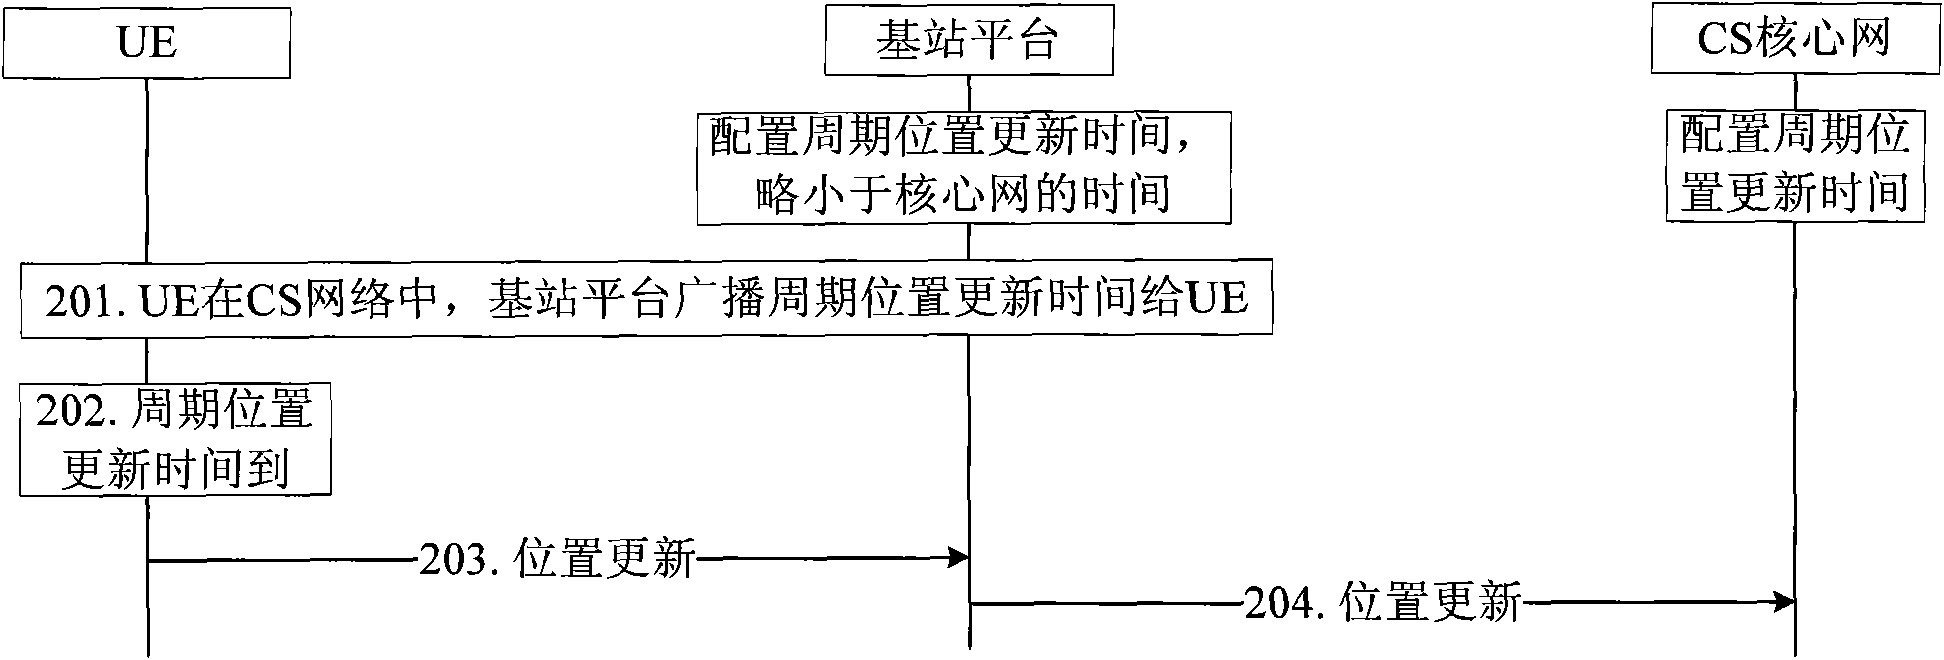
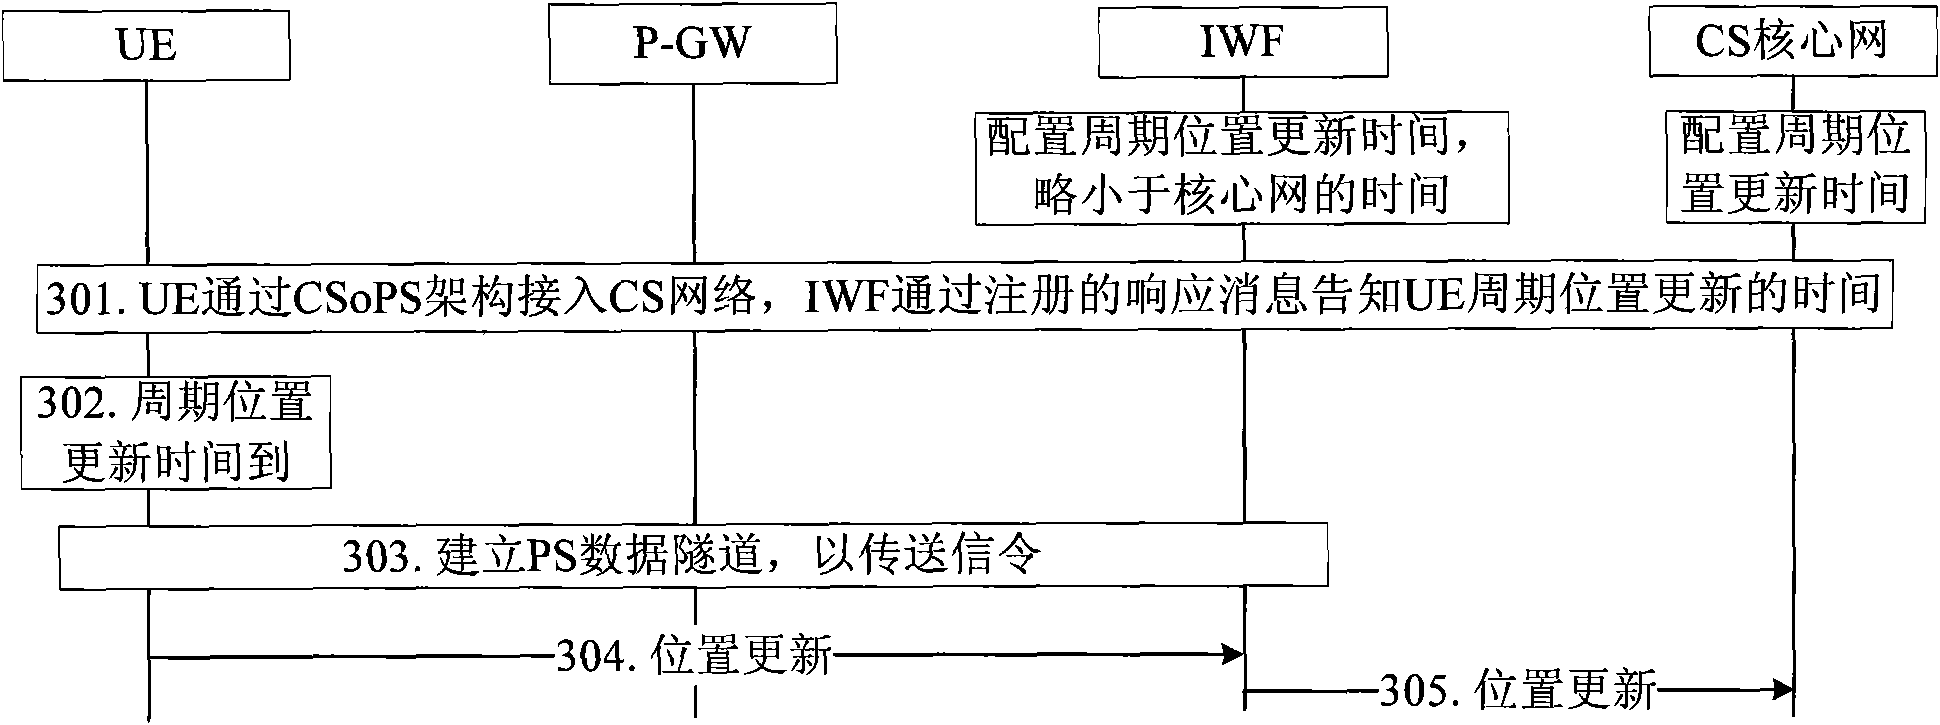
Owner:南通亘通智能设备有限公司
Intelligeat network control method of network exchange equipment
InactiveCN1514656AReduce workloadEasy to modifyRadio/inductive link selection arrangementsData switching networksProcess moduleProcessor register
The method includes following steps: location-updating procedure initiates user authentication and service node of GPRS service based on register of attributed location in order to determine whether the user is a intelligent control user. Following steps are carried out right along for an intelligent control user: entering intelligent processing status; calling macro functions provided by intelligent controlled auxiliary process module; the said macro functions carries out processing; building communication between intelligent controlled process module and service control point in intelligent network; waiting for signaling form signaling control point; the micro functions carries out processing according to message from intelligent controlled process module; based on the return from macro functions, processing flow is continuous for service course.


Owner:ZTE CORP
Global server load balance-based data synchronization time management method and apparatus
ActiveCN106131129AReduce frequencyReduce update frequencyTransmissionData synchronizationTime management
The present invention provides a global server load balance-based data synchronization time management method and apparatus that are applied to the site side. The method comprises the steps of analyzing a domain name system (DNS) request sent by a local user, creating a corresponding session holding entry according to the DNS request, and synchronizing the session holding entry to other sites, wherein the site and the other sites are pre-configured load balance sites; monitoring aging remaining time of the session holding entry in the site and the other sites; and dynamically adjusting, based on a preset algorithm, an updating check frequency of the session holding entry according to the aging remaining time of the session holding entry in the site and the other sites. Through adoption of the global server load balance-based data synchronization time management method and apparatus, while the session holding entry does not age, the check frequency of whether the session holding entry is updated is dynamically adjusted according to the aging remaining time of each site, and correspondingly, the updating frequency of the session holding entry in each site is lowered to the greatest extent.


Owner:杭州迪普信息技术有限公司
Information processing apparatus, information processing system, information processing method, and program
InactiveUS20080040778A1Reduce messagingDigital data processing detailsComputer security arrangementsInformation processingInformation handling system
An information processing apparatus includes an authentication unit configured to identify a user who uses a data processing apparatus, a storage unit configured to store user identification information for identifying the user who is identified by the authentication unit and is identified as not having ended using the data processing apparatus, and an acquisition unit configured to, in accordance with the user identification information stored in the storage unit, acquire from the data processing apparatus information about using of the data processing apparatus by the user identified with the user identification information that has not been acquired during the state in which communication with the data processing apparatus is unavailable.


Owner:CANON KK
Multi-module voice channel resource management method
InactiveCN1523816AImprove scalabilityImprove stabilityData switching networksSelection arrangementsRelay channelResource management
A multimodule channel resource management method is to divide the modules in an exchange system into a management module and a service process module, both of them store the information of attribute and state field of the local relay channel resources, and the relay channel resource stores the resource allocation. When a service call requests, the calling initiating module applies for management capability for the relay channel to the resource management module which assigns the relay channel to the call initiating module and marks the occupation till returns it back to the resource management module after finishing the service.


Owner:ZTE CORP
Method and system for deleting loads and serving gateway


Owner:HUAWEI TECH CO LTD
Control method of flywheel array energy storage system, energy storage system and power grid system
InactiveCN112821433AImprove stabilityIncrease capacityElectrical storage systemAc network load balancingPower compensationControl engineering
The invention discloses a control method of a flywheel array energy storage system, the flywheel array energy storage system and a power grid system. The method comprises: a master controller determining that the flywheel array energy storage system is not started for operation for the first time, and obtaining flywheel total compensation power according to obtained power grid information; obtaining single flywheel compensation power according to the number of online single flywheels and the total compensation power of the flywheels, and issuing the single flywheel compensation power to a corresponding single flywheel controller in a broadcast mode; the single flywheel controller receiving the single flywheel compensation power and sending the single flywheel compensation power to the corresponding single flywheel so as to control the corresponding single flywheel to execute the corresponding power compensation action, and recording the issuing time of the single flywheel compensation power and the corresponding flywheel rotating speed during issuing; and acquiring the reporting time and the reporting rotating speed when the single flywheel reports the rotating speed state, and performing action difference correction on the single flywheel according to the issuing time and the flywheel rotating speed, the reporting time and the reporting rotating speed corresponding to the issuing time. The method can improve the system stability, shorten the response time and increase the capacity expansion amount.
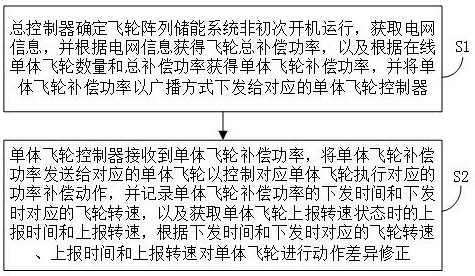
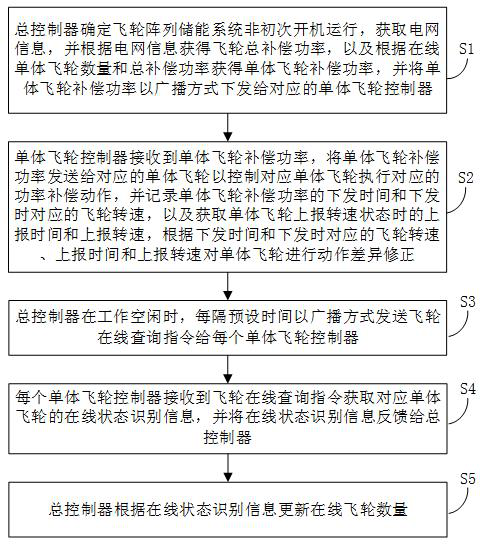
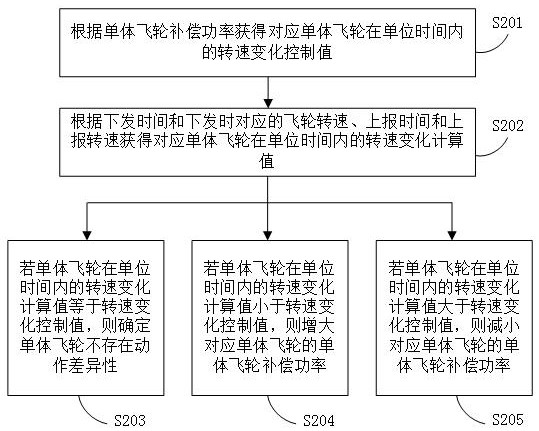
Owner:沈阳微控新能源技术有限公司
Lamp control system communication protocol encryption method
ActiveCN110086618AAvoid crackingImprove securityKey distribution for secure communicationControl systemPassword
The invention relates to a lamp control system communication protocol encryption method in the field of computers. The method adopts a method of dynamically generating secret key encryption at a receiving end and a sending end. The sending end extracts a secret key parameter I dynamically generated by sending end data frame information to ensure that the sending secret keys are different each time. A private password by a user is used as a key parameter II to participate in the generation of the key, so that security is higher. A key parameter III transmitted next time is contained in the dataframe transmitted this time, and the receiving end is informed to update the key parameter III. In the first transmission, the key parameter III generates a key by adopting a preset initial value, and after the sending and receiving processes are completed each time, the key parameter III is updated at the receiving end and the transmitting end. According to the invention, messages specially distributed by keys can be reduced. In addition, the private password set by each user is used as the key parameter to participate in the generation of the key, so that the security can be improved.

Owner:南京格兰斯贝网络科技有限公司
Mixed node multi-bit processing polarization code decoding method
InactiveCN109194338AImprove throughputReduce messagingError correction/detection using linear codesNODALComputer engineering
The present invention discloses a mixed node multi-bit processing polarization code decoding method. The method comprises the following steps of: 1) configuring decoding parameters; 2) determining themaximum order number required by decoding; 3) determining the type of each node in each decoding phase according a vector p; 4) preferentially performing hard decision of 0 rate node and 1 rate node;5) determining the type of the sub nodes of the mixed node and performing decoding; and 6) outputting a complete decoding result u:{u1, ...uN} according to decoding result of each node in the step 4)and the step 5). The method provided by the invention can improve the decoding speed of the polarization code on the premise without loss of the decoding error correction performance.


Owner:GUILIN UNIV OF ELECTRONIC TECH
Access network selection for a multi-access terminal, based on a pheromone signal
InactiveUS20180249395A1Reduce messagingSimple processAssess restrictionAccess networkConstant frequency
Provided are a method for updating at least two tables and a method for transmission of a pheromone signal. The pheromone signal carries a series of pheromone messages transmitted at a constant frequency to a first terminal from a second terminal across each of the access networks of a plurality of access networks. The first terminal and the second terminal are connected in parallel by the plurality of access networks. A pheromone message of the series includes a single packet, the packet having an address of the first terminal relative to one access network of the plurality, via which the message is passed, triggers, when it is received by the first terminal, an updating of a table corresponding to the access network. This table is determinant for selection of an access network from the plurality, by one of the first or second terminals.


Owner:ORANGE SA (FR)
Real-time target detection, tracking and motion prediction method for automatic driving
PendingCN119579862Areduce demandprocessing speedCharacter and pattern recognitionNeural learning methodsVoxelNetwork architecture
The invention discloses a real-time target detection, tracking and motion prediction method for automatic driving, and belongs to the technical field of automatic driving. The method mainly comprises the following steps: 1, receiving three-dimensional point cloud data and corresponding two-dimensional image data; 2, extracting feature representation of the point cloud and the image; 3, performing multi-modal information fusion on the image features and the point cloud features by adopting a step-by-step fusion mode to obtain self-adaptive fused voxel features; 4, according to the self-adaptive fused voxel features, a target detection output head, a behavior tracking output head and a behavior prediction output head are adopted for analysis, and a detection result, a tracking result and a prediction result of the moving objects around the vehicle are obtained. According to the method, a single convolutional neural network is utilized, and three-dimensional point cloud data and corresponding two-dimensional image information are combined, so that efficient and accurate three-dimensional object detection, tracking and motion prediction are realized. Through a unified network architecture, traditional multi-stage processes are integrated into one model, and the efficiency and performance of the system are improved.

Owner:ZHEJIANG UNIV +1
Session management method, entity, network device and storage medium
ActiveCN113207096BReduce difficultyEasy to handleAccounting/billing servicesConnection managementSession managementEngineering
The present application provides a session management method, entity, network device and storage medium. The method includes: sending a group-level session management request to a control plane entity based on service requirements; wherein, the group-level session management request carries group information, and the group The information is used to characterize the virtual network group that needs to perform group-level session management; receive the response message returned by the control plane entity in response to the group-level session management request; perform corresponding session service management on the virtual network group according to the content carried in the response message .


Owner:ZTE CORP
Method, device and system for network prepayment
ActiveCN101686289BReduce messagingSave resourcesMetering/charging/biilling arrangementsAuthorizationComputer science
The invention discloses a method, a device and a system for network prepayment, which are used for solving the problem that too many interactions of corrected authorization messages exist between an access server and an authentification, authorization and charging server and occupy too many resources. The method mainly comprises the following step: the authentification, authorization and chargingserver responds an authentification response message indicating the maximum user on-line time length or available time length to the access server according to a credit control response primary message sent by an on-line charging system, and in each subsequent charging time length, only charges for the previous charging time length and pre-distributes the work for the next available time length. The method can reduce the message transmission between the access server and the authentification, authorization and charging server, thereby saving the resources.


Owner:HUAWEI TECH CO LTD
A load sharing method and device
ActiveCN104363620BReduced Interoperability RequirementsReduce messagingNetwork traffic/resource managementInformation transmissionUser device
An embodiment of the invention provides a load sharing method and device, relates to the field of communication, and aims to reduce information transmission between a macro cell and a micro cell and lower the requirement on inter-communication capacity of micro cells at the premise of not affecting the macro cell to micro cell load-sharing process. The method includes the steps: after the macro cell receives a service request sent by a user device, the macro cell acquires a first message which is sent by the micro cell and which includes a first identifier used for indicating whether or not the micro cell is allowed to gain access to the user device; if yes, the macro cell judges whether or not the user device is allowed to share load to the micro cell; if yes and when the user device is in coverage of the micro cell, the macro cell shares the load of the macro cell to the micro cell. The load sharing method and device according to the embodiment is applicable to load sharing of macro and micro cells.


Owner:CHINA UNITED NETWORK COMM GRP CO LTD
Intelligeat network control method of network exchange equipment
InactiveCN100417236CReduce workloadEasy to modifyRadio/inductive link selection arrangementsData switching networksProcess moduleProcessor register
The method includes following steps: location-updating procedure initiates user authentication and service node of GPRS service based on register of attributed location in order to determine whether the user is a intelligent control user. Following steps are carried out right along for an intelligent control user: entering intelligent processing status; calling macro functions provided by intelligent controlled auxiliary process module; the said macro functions carries out processing; building communication between intelligent controlled process module and service control point in intelligent network; waiting for signaling form signaling control point; the micro functions carries out processing according to message from intelligent controlled process module; based on the return from macro functions, processing flow is continuous for service course.


Owner:ZTE CORP
Method and device for global load balancing data synchronization time management
ActiveCN106131129BReduce frequencyReduce update frequencyTransmissionData synchronizationTime management


Owner:杭州迪普信息技术有限公司
Encryption method of communication protocol of light control system
ActiveCN110086618BAvoid crackingImprove securityKey distribution for secure communicationPasswordEngineering
The invention relates to an encryption method for a communication protocol of a light control system, which belongs to the field of computers. This method adopts the method of dynamically generating key encryption at the sending and receiving ends; the sending end extracts the key parameter I dynamically generated by the data frame information of the sending end to ensure that the key is different each time; the private password set by the user is used as the key parameter II to participate in the encryption Key generation, higher security; the key parameter III for the next transmission is included in the data frame sent this time, and the receiving end is notified to update the key parameter III. For the first transmission, the key parameter III uses a preset initial value to generate a key, and each time the sending and receiving process is completed, both the sending and receiving ends update the key parameter III. The present invention can reduce special key distribution messages. In addition, using the private password set by each user as a key parameter to participate in key generation can improve security.

Owner:南京格兰斯贝网络科技有限公司
Method and device for data exchange
ActiveCN109429180BImprove performanceRun fastConnection managementBroadcast service distributionCommunications systemTrunking


Owner:DATANG MOBILE COMM EQUIP CO LTD
Multi-module voice channel resource management method
InactiveCN1260913CEasy to implementImprove scalabilityData switching networksSelection arrangementsResource informationCall origination
A multi-module voice channel resource management method, which divides the modules in the switch system into resource management modules and business processing modules: each resource management module and business processing module stores the attributes and status fields of the trunk voice channel resources of the office information, the trunk channel resources of the resource management module also store the resource allocation field; when a service call is requested, the call initiation module applies for the management right of the trunk channel to the resource management module; the resource management module allocates the trunk channel Give the call originating module a flag that is occupied by this module and cannot be allocated to other modules until the call originating module returns the trunk channel; after the service is completed, the trunk channel is returned to the resource management module. The invention improves the scalability of the system and increases the stability of the system.


Owner:ZTE CORP