

Patents
Literature
42results about How to "Flexible sorting" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Method and apparatus for ordering incidence relation search result
InactiveCN101140588AFlexible sortingAccurate acquisitionSpecial data processing applicationsAlgorithmCophenetic correlation


Owner:HUAWEI TECH CO LTD +1
Method for sequencing multi-index comprehensive weight video
InactiveCN101739416ATrue and objective reflection of inner characteristicsFlexible sortingSpecial data processing applicationsWeighted scoreComputer science
The invention provides a method for sequencing a multi-index comprehensive weight video which comprises a step of analyzing a video by a video database, a step of determining subjective weight, a step of determining objective weight in order to calculate an objective weight of a sequencing index determined by the step of determining subjective weight according to the data provided by the step of analyzing video, a step of optimizing decision for calculating a comprehensive weight of each sequencing index, a step of calculating a score of sequencing index in order to calculate the sequencing score of index of each video, and a step of calculating a comprehensive score in order to calculate a weighted score of the video. The invention regards for a plurality of characters of the video and the feedback of the video from customer, can intelligently and flexibly sequence the video and can search out the video result in the best mode and send to customer.


Owner:RESHUFFLE TECH SHANGHAI
Multi-payment channel selection method and system
ActiveCN106296142AGood choiceCombined with personal habitsPayment schemes/modelsPaymentComputer module
The invention provides a multi-payment channel selection method. The method comprises the following steps that S1, different users send payment requests to a payment channel selection module through APPs; and S2, the payment channel selection module selects payment channels according to the payment requests, generates a support list of the payment channels supporting the payment requests, and displays the support list to the users for selection. The invention furthermore provides a corresponding system. According to the multi-payment channel selection method and system, a multi-national payment situation is covered; universal payment request parameters are defined, so that the users can conveniently select the payment channels; the support list supporting the payment requests is flexibly sorted; the personal habits of the users are considered; and in addition, the sorted support list is displayed for the users to select, so that the payment processing of the APPs is simplified and the APPs can focus in own business logic processing.


Owner:深圳云游四海信息科技有限公司
Method and system for ordering linkman
InactiveCN101465752AMeet the diverse needs of sortingVarious sorting methodsSpecial service provision for substationCommunications systemComputer science
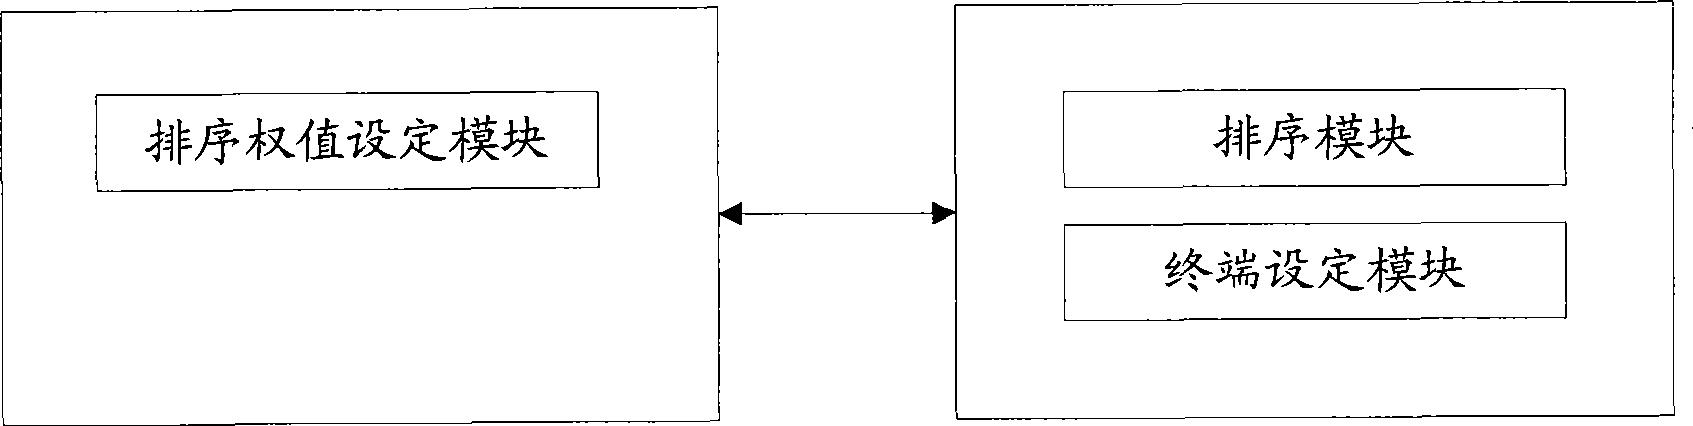
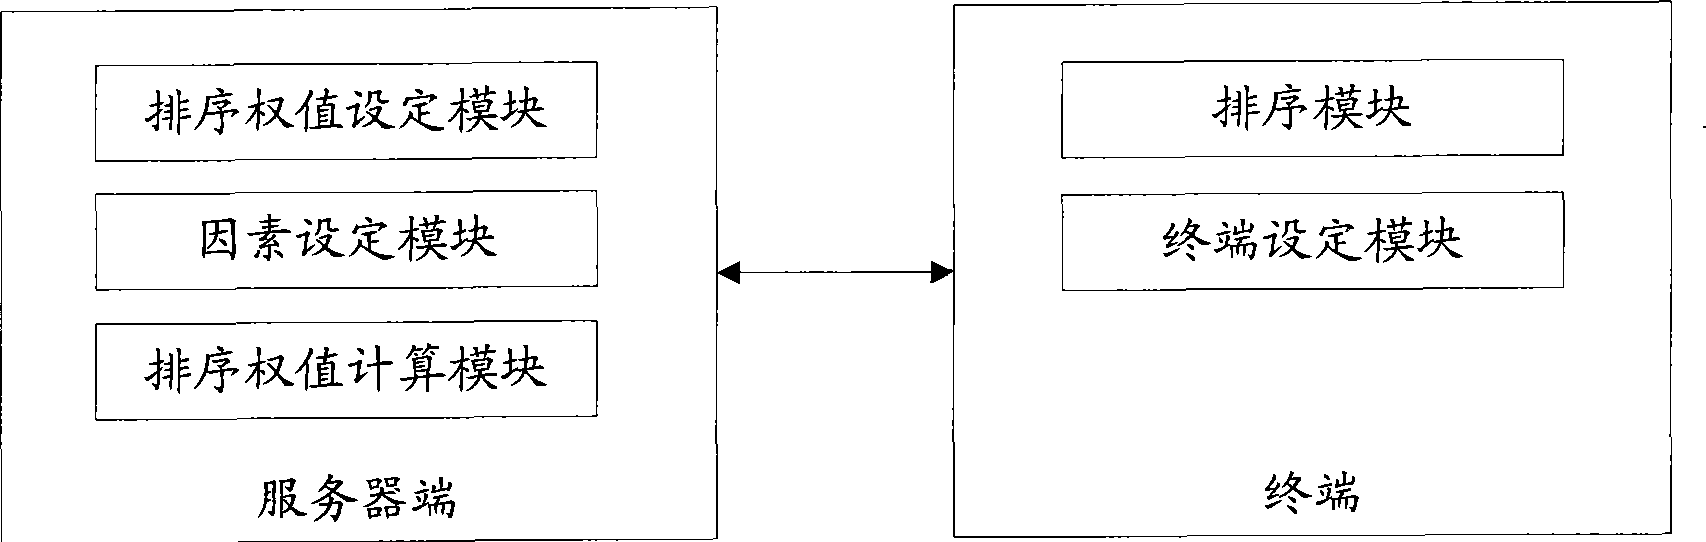
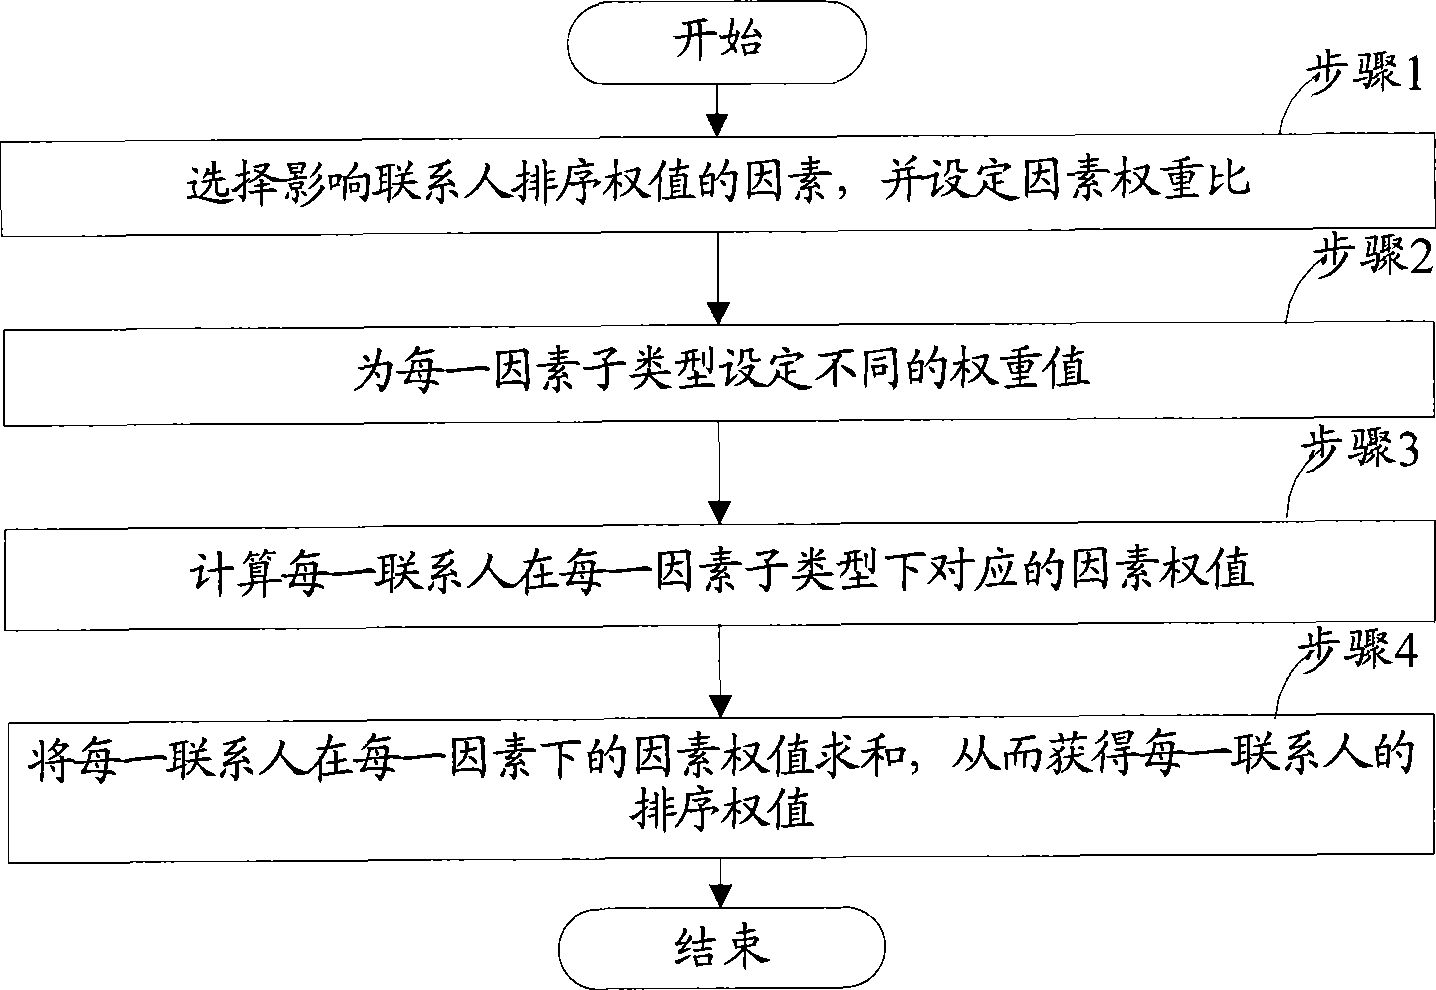
The invention relates to sorting technology and discloses a contact list sorting method and a system, aiming at solving the technical problems that contacts cannot be displayed in a sorted way according to special requirements including ranks and positions of contacts in constant messaging system. The invention sets sorting weights for contacts on server, and a terminal displays the contacts in a sorted way according to the sorting weights. As for a plurality of factors which affect the sorting sequence of contacts, the invention proposes a method of polynomial summation of the product of factor weight ratio and factor sub-type weight value to compute contact sorting weights. Besides, the contact sorting method based on sorting weight is combined with a sorting method based on state priority to provide various and flexible contact sorting modes for enterprise users, so the special requirements of enterprise users are satisfied, and the user satisfaction degree is improved.
Owner:TENCENT TECH (SHENZHEN) CO LTD
Contact person information displaying method, contact person information displaying device and mobile terminal
InactiveCN101546247AEasy to viewEasy to operate in groupsTelephone sets with user guidance/featuresSpecial data processing applicationsInformation networksComputer terminal
The invention relates to data processing, and provides a contact person information displaying method, a contact person information displaying device and a mobile terminal, aiming at the defect that the contact person sort display mode of the prior mobile communication terminal is too rigid. The contact person information display method comprises the steps of creating a contact person information network graph and displaying the contact person information through the network graph, wherein the network graph is created by the following steps: receiving inputted network graph structural information, generating root nodes and intermediate nodes according to the labels and the subordination relation information of the root nodes and the intermediate nodes; and receiving a packet commands and generating contact person nodes subordinate to the intermediate nodes according to the labels of contact persons and the labels of the intermediate nodes. The contact person information displaying proposal of the invention creates the network graph according to the network graph structural information, and organizes and sorts the contact person information according to the network graph, so the sorting mode is more flexible and the operation is more convenient.


Owner:YULONG COMPUTER TELECOMM SCI (SHENZHEN) CO LTD
Method for sequencing multi-index comprehensive weight audio-video album
InactiveCN101739418ATrue and objective reflection of inner characteristicsFlexible sortingSpecial data processing applicationsData miningWeighted score
The invention provides a method for sequencing a multi-index comprehensive weight audio-video album which comprises a step of analyzing an audio-video album by an audio-video album database, a step of determining subjective weight, a step of determining objective weight in order to calculate an objective weight of a sequencing index determined by the step of determining subjective weight according to the data provided by the step of analyzing an audio-video album, a step of optimizing decision for calculating a comprehensive weight of each sequencing index, a step of calculating a score of sequencing index in order to calculate the sequencing score of index of each audio-video album, and a step of calculating a comprehensive score in order to calculate a weighted score of the audio-video album. The invention regards for a plurality of characters of the audio-video album and the feedback of the audio-video album from customer, can intelligently and flexibly sequence the audio-video album and can search out the audio-video album result in the best mode and send to customer.


Owner:RESHUFFLE TECH SHANGHAI
Horizontal carton packaged cigarette sorter
ActiveCN101185927ANot suitable for damageRealize automatic sortingSortingLogistics managementControl system
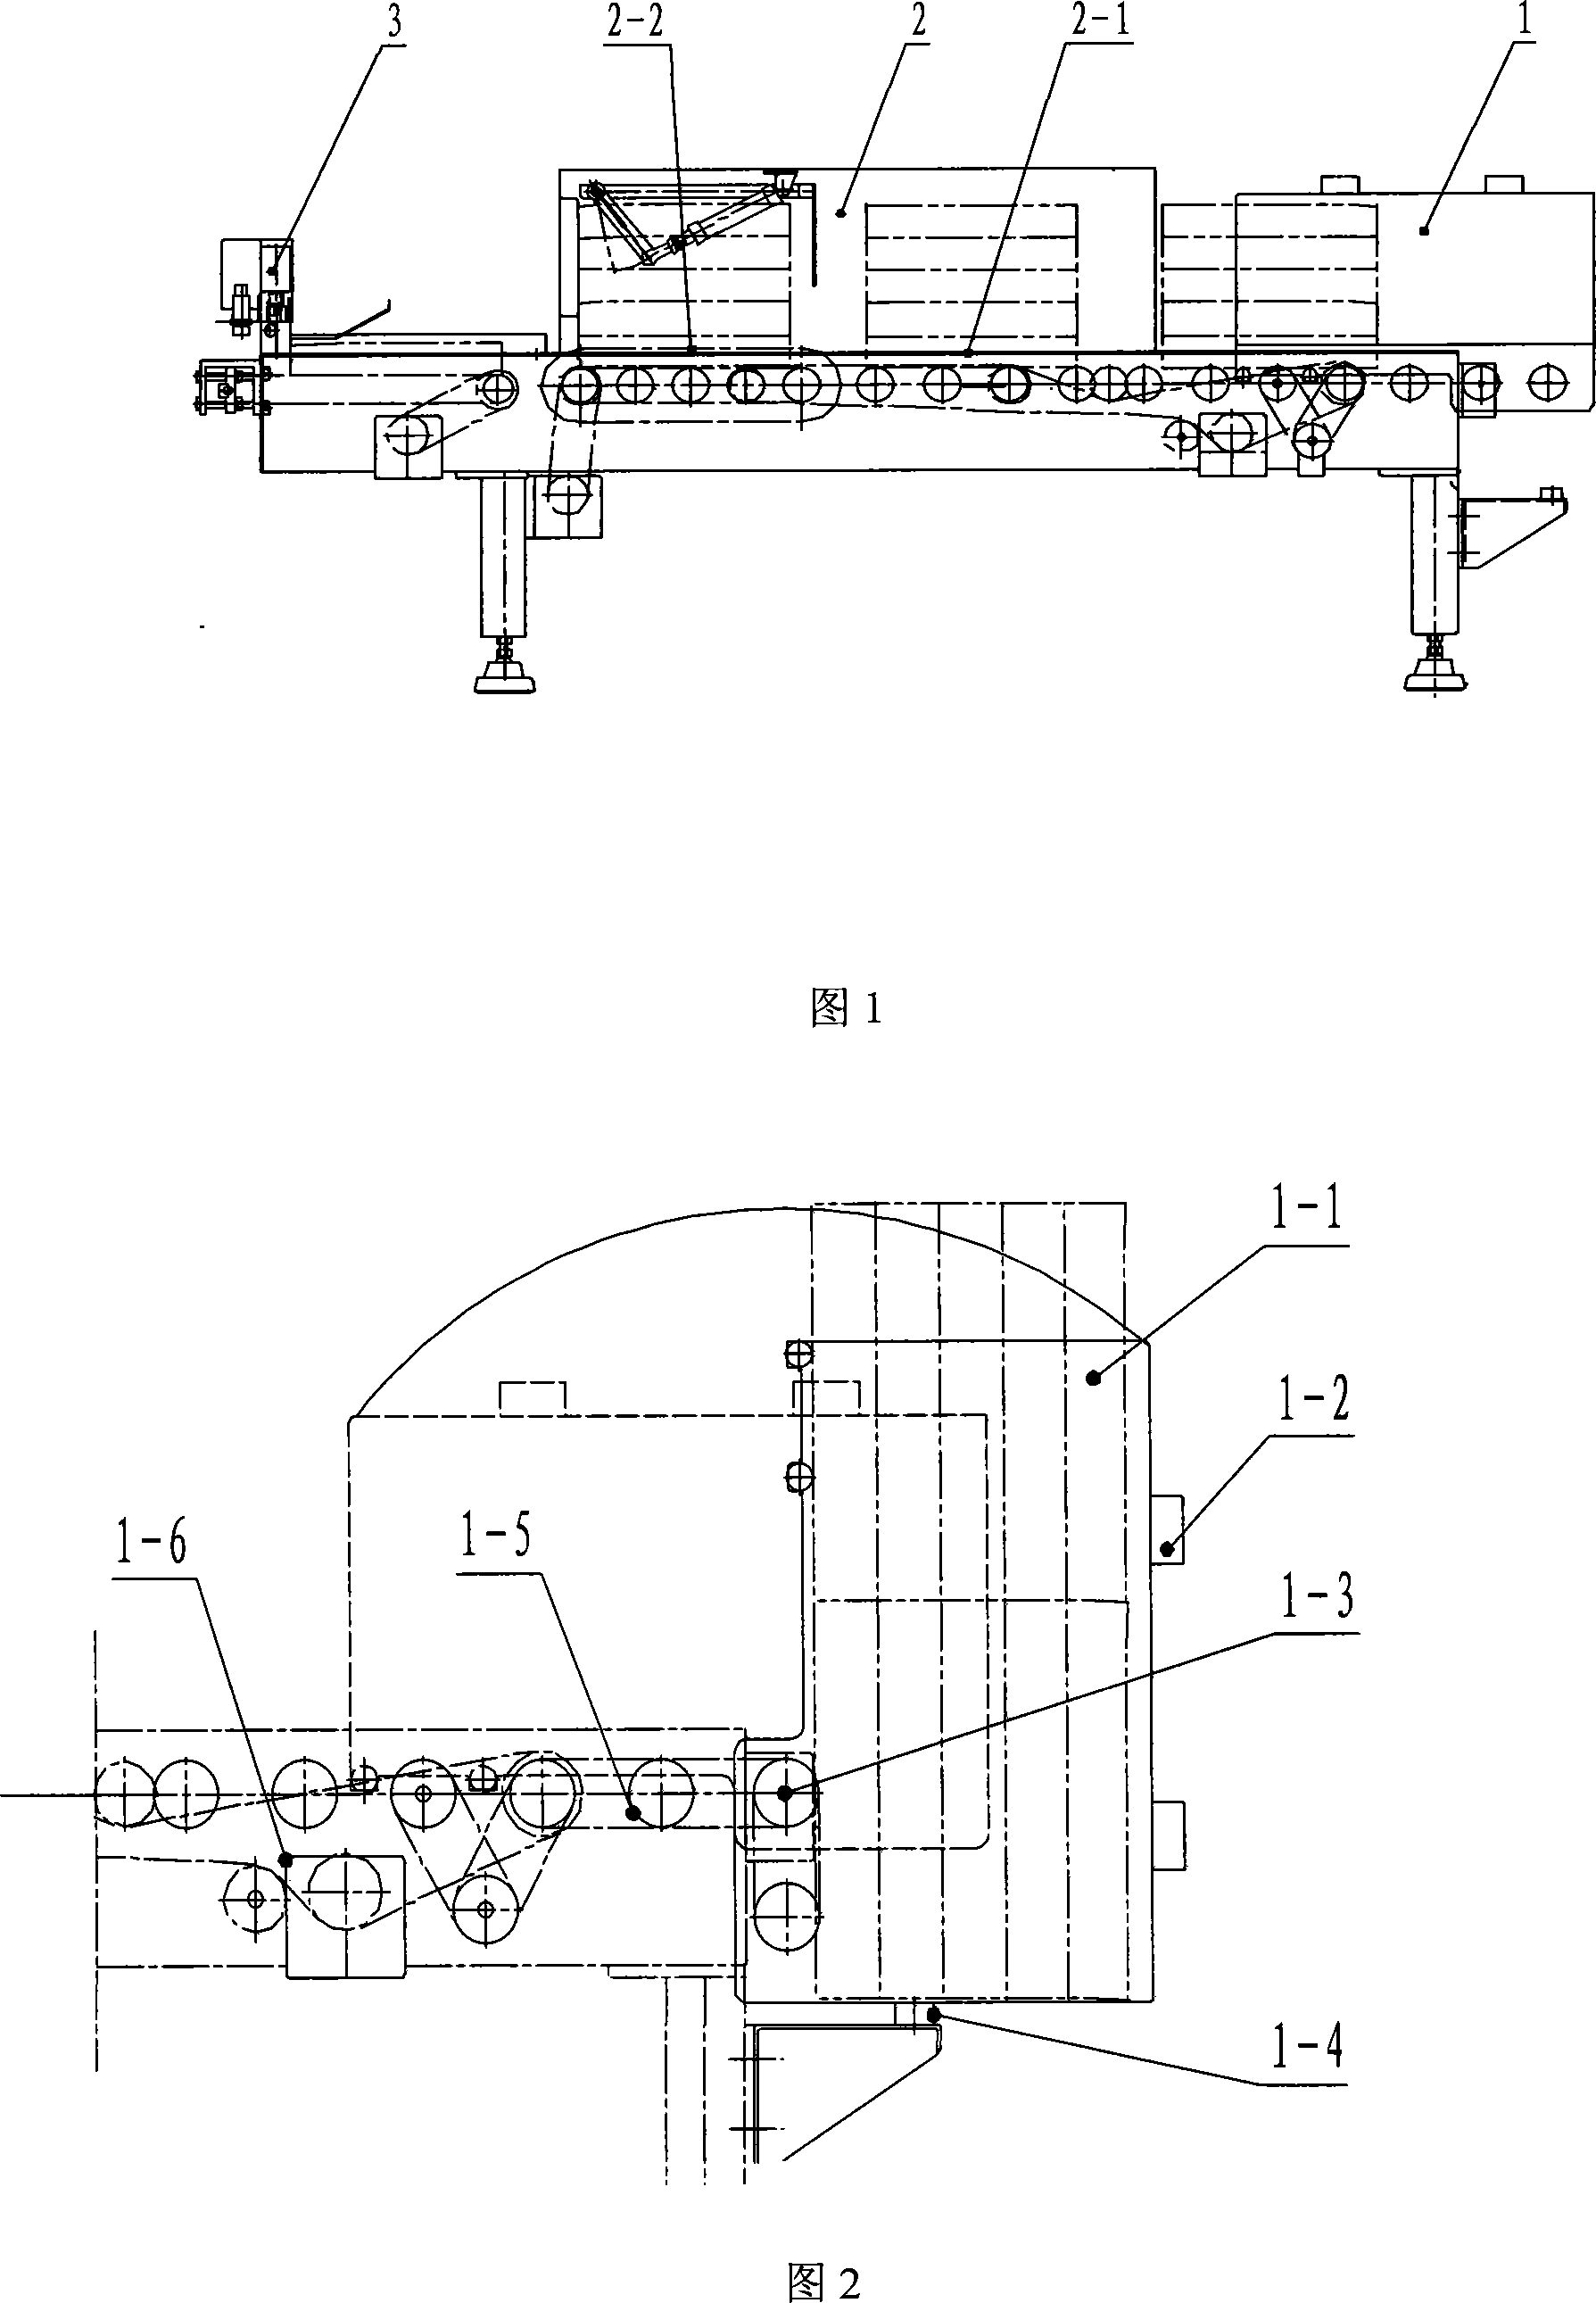
The invention which belongs to the field of logistics equipment technology relates to a horizontal tobacco carton sorting machine used in tobacco carton delivery operation, comprising a turn-over tobacco supplement device, a tobacco carton delivery mechanism which includes a conveying passage and a separated transportation mechanism, a tobacco carton sorting mechanism and a control system. The turn-over tobacco supplement device is arranged at the start end of the conveying passage of the tobacco carton delivery mechanism. The tobacco carton sorting mechanism is arranged at the terminal end of the separated transportation mechanism of the tobacco carton delivery mechanism. The whole structure of the machine is simple and reasonable. The style of tobacco supplement is simple, rapid and labor-saving, which reduces labor intensity and improves working efficiency. The sorting is flexible with a reliable precision, which seldom damages the tobacco carton and improves the sorting package quality. According to the requirements of the sorting business, the sorting system can be arbitrarily combined and installed by utilizing the horizontal tobacco carton sorting machine, so as to realize the automatic sorting of tobacco carton and high adaptability.
Owner:BLUESWORD INTELLIGENT TECH CO LTD
Page template replacing method and device
ActiveCN106339373AFlexible Template ReplacementFlexible Page LayoutSpecial data processing applicationsDatabase
The invention relates to the publication field, and especially relates to a page template replacing method and device; the method comprises the following steps: respectively classifying vessels in a to-be-replaced page template and a selected page template according to vessel attributes; ranking the vessels of the same type in the to-be-replaced page template according to set conditions, and thus obtaining a to-be-replaced vessel sequence; ranking the vessels of the same type in the selected page template according to set conditions, and thus obtaining a replacing vessel sequence, wherein the set conditions comprise positions and / or sizes of the vessels in the page template; aiming at vessels of the same type, and writing contents of each vessel of the to-be-replaced vessel sequence into corresponding vessels of the replacing vessel sequence. The novel method solves the problems that a conventional page template replacement rule is fixed and not flexible.


Owner:新方正控股发展有限责任公司 +1
System for sequencing multi-index comprehensive weight video
InactiveCN101739419ATrue and objective reflection of inner characteristicsFlexible sortingSpecial data processing applicationsData miningWeighted score
The invention provides a system for sequencing a multi-index comprehensive weight video which comprises a video database, a video analyzing module, a subjective weight determining module and an objective weight determining module which is connected with the video analyzing module and the subjective weight determining module and calculates an objective weight of a sequencing index determined by the subjective weight determining module according to the data provided by the video analyzing module. The system further comprises a decision optimizing module which is arranged for calculating a comprehensive weight of each sequencing index, an index sequencing score calculating module which is arranged for calculating a sequencing score of index of each video and a comprehensive score calculating module which is arranged for calculating a weighted score of the video. The invention regards for a plurality of characters of the video and the feedback of the video from customer, can intelligently and flexibly sequence the video and can search out the video result in the best mode and send to customer.


Owner:RESHUFFLE TECH SHANGHAI
Automatic dispense system of randomly assembled sorting unit
ActiveCN1803320AImprove replenishment efficiencyEasy replenishmentDe-stacking articlesSortingDistribution systemEngineering
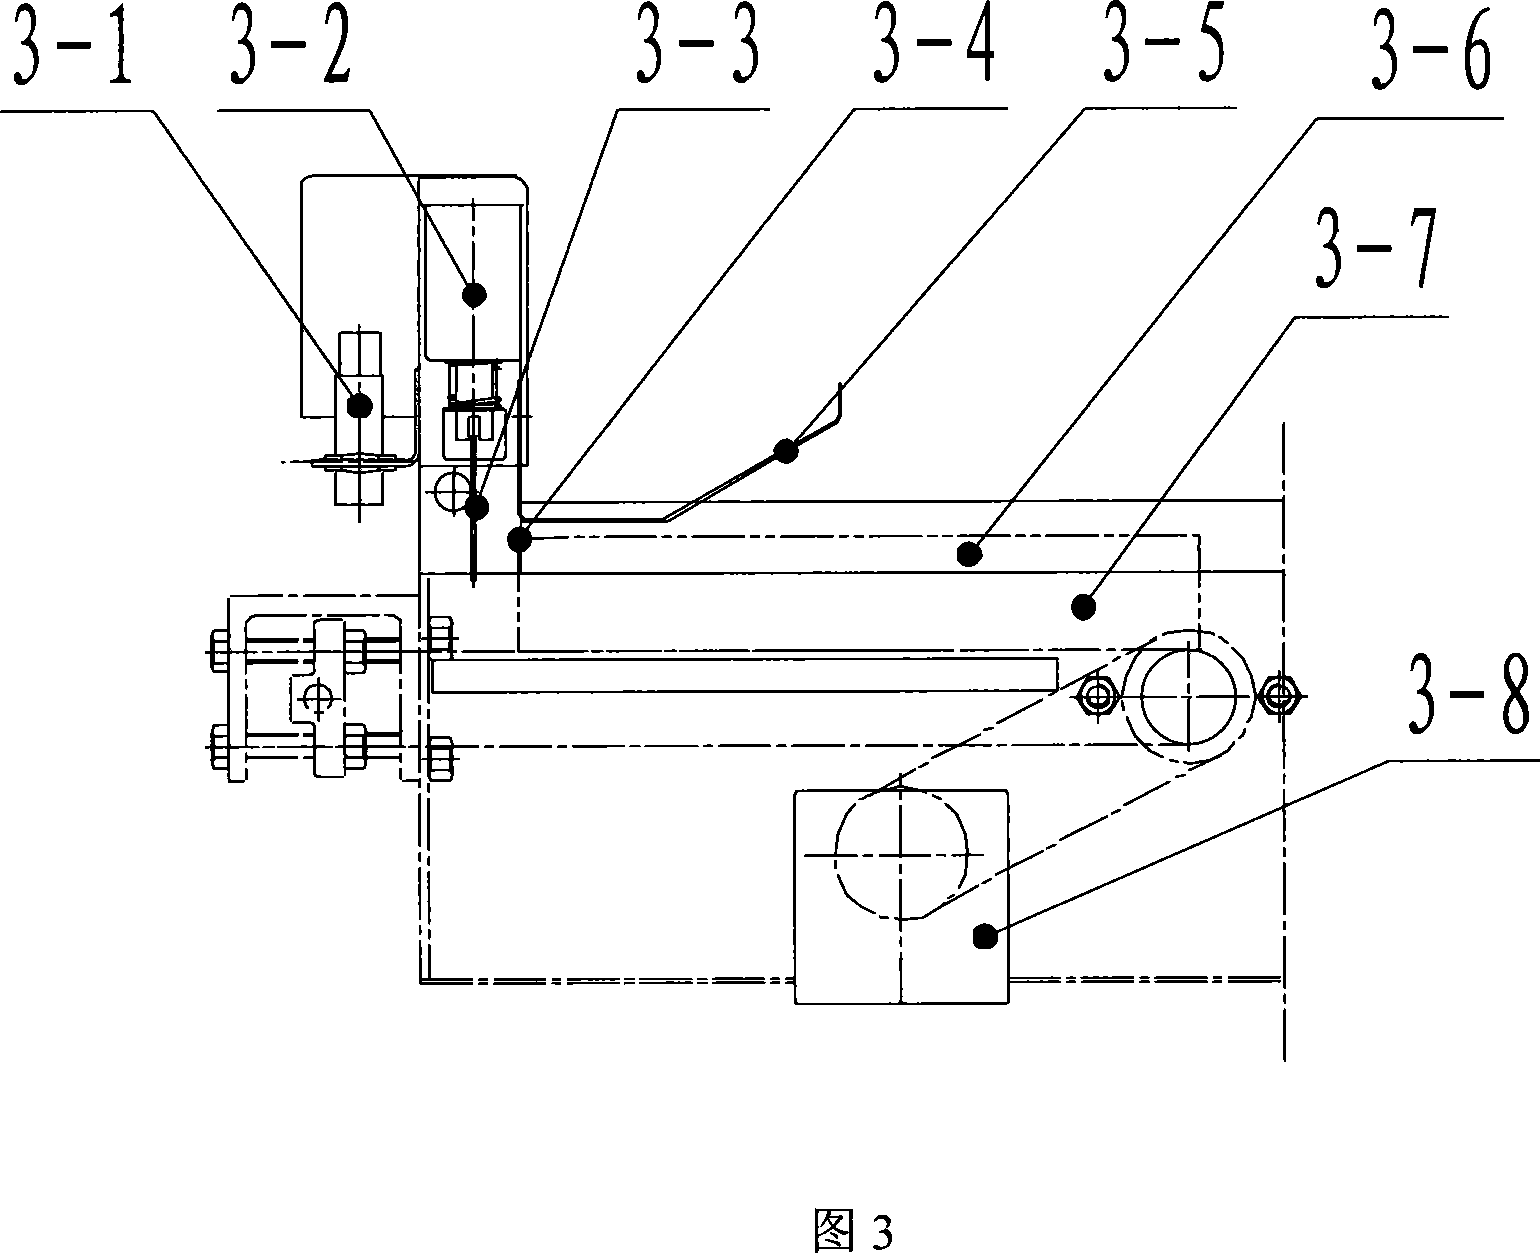
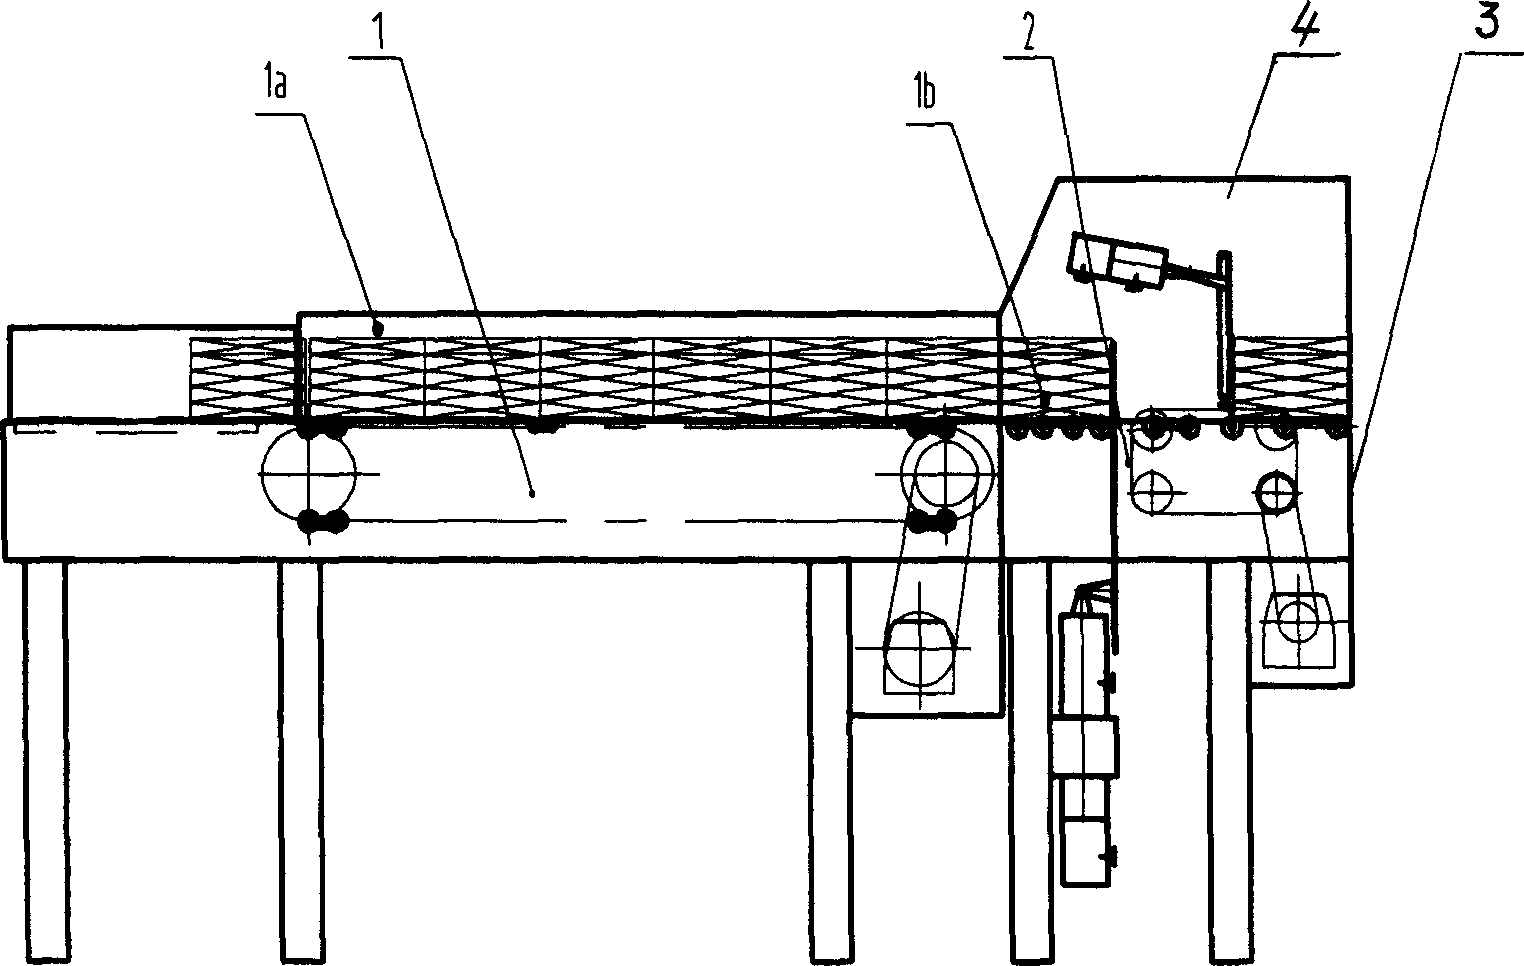
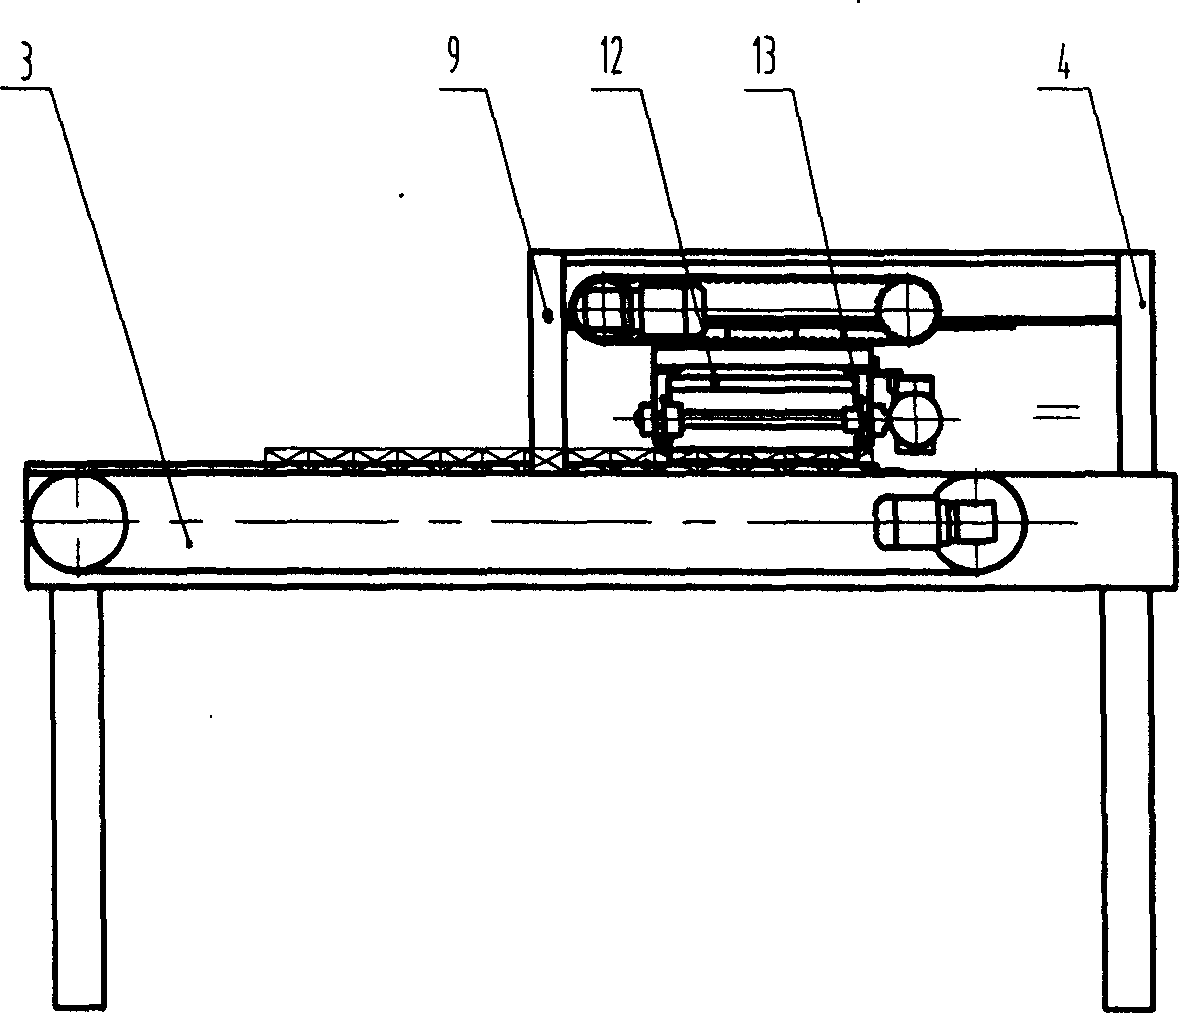
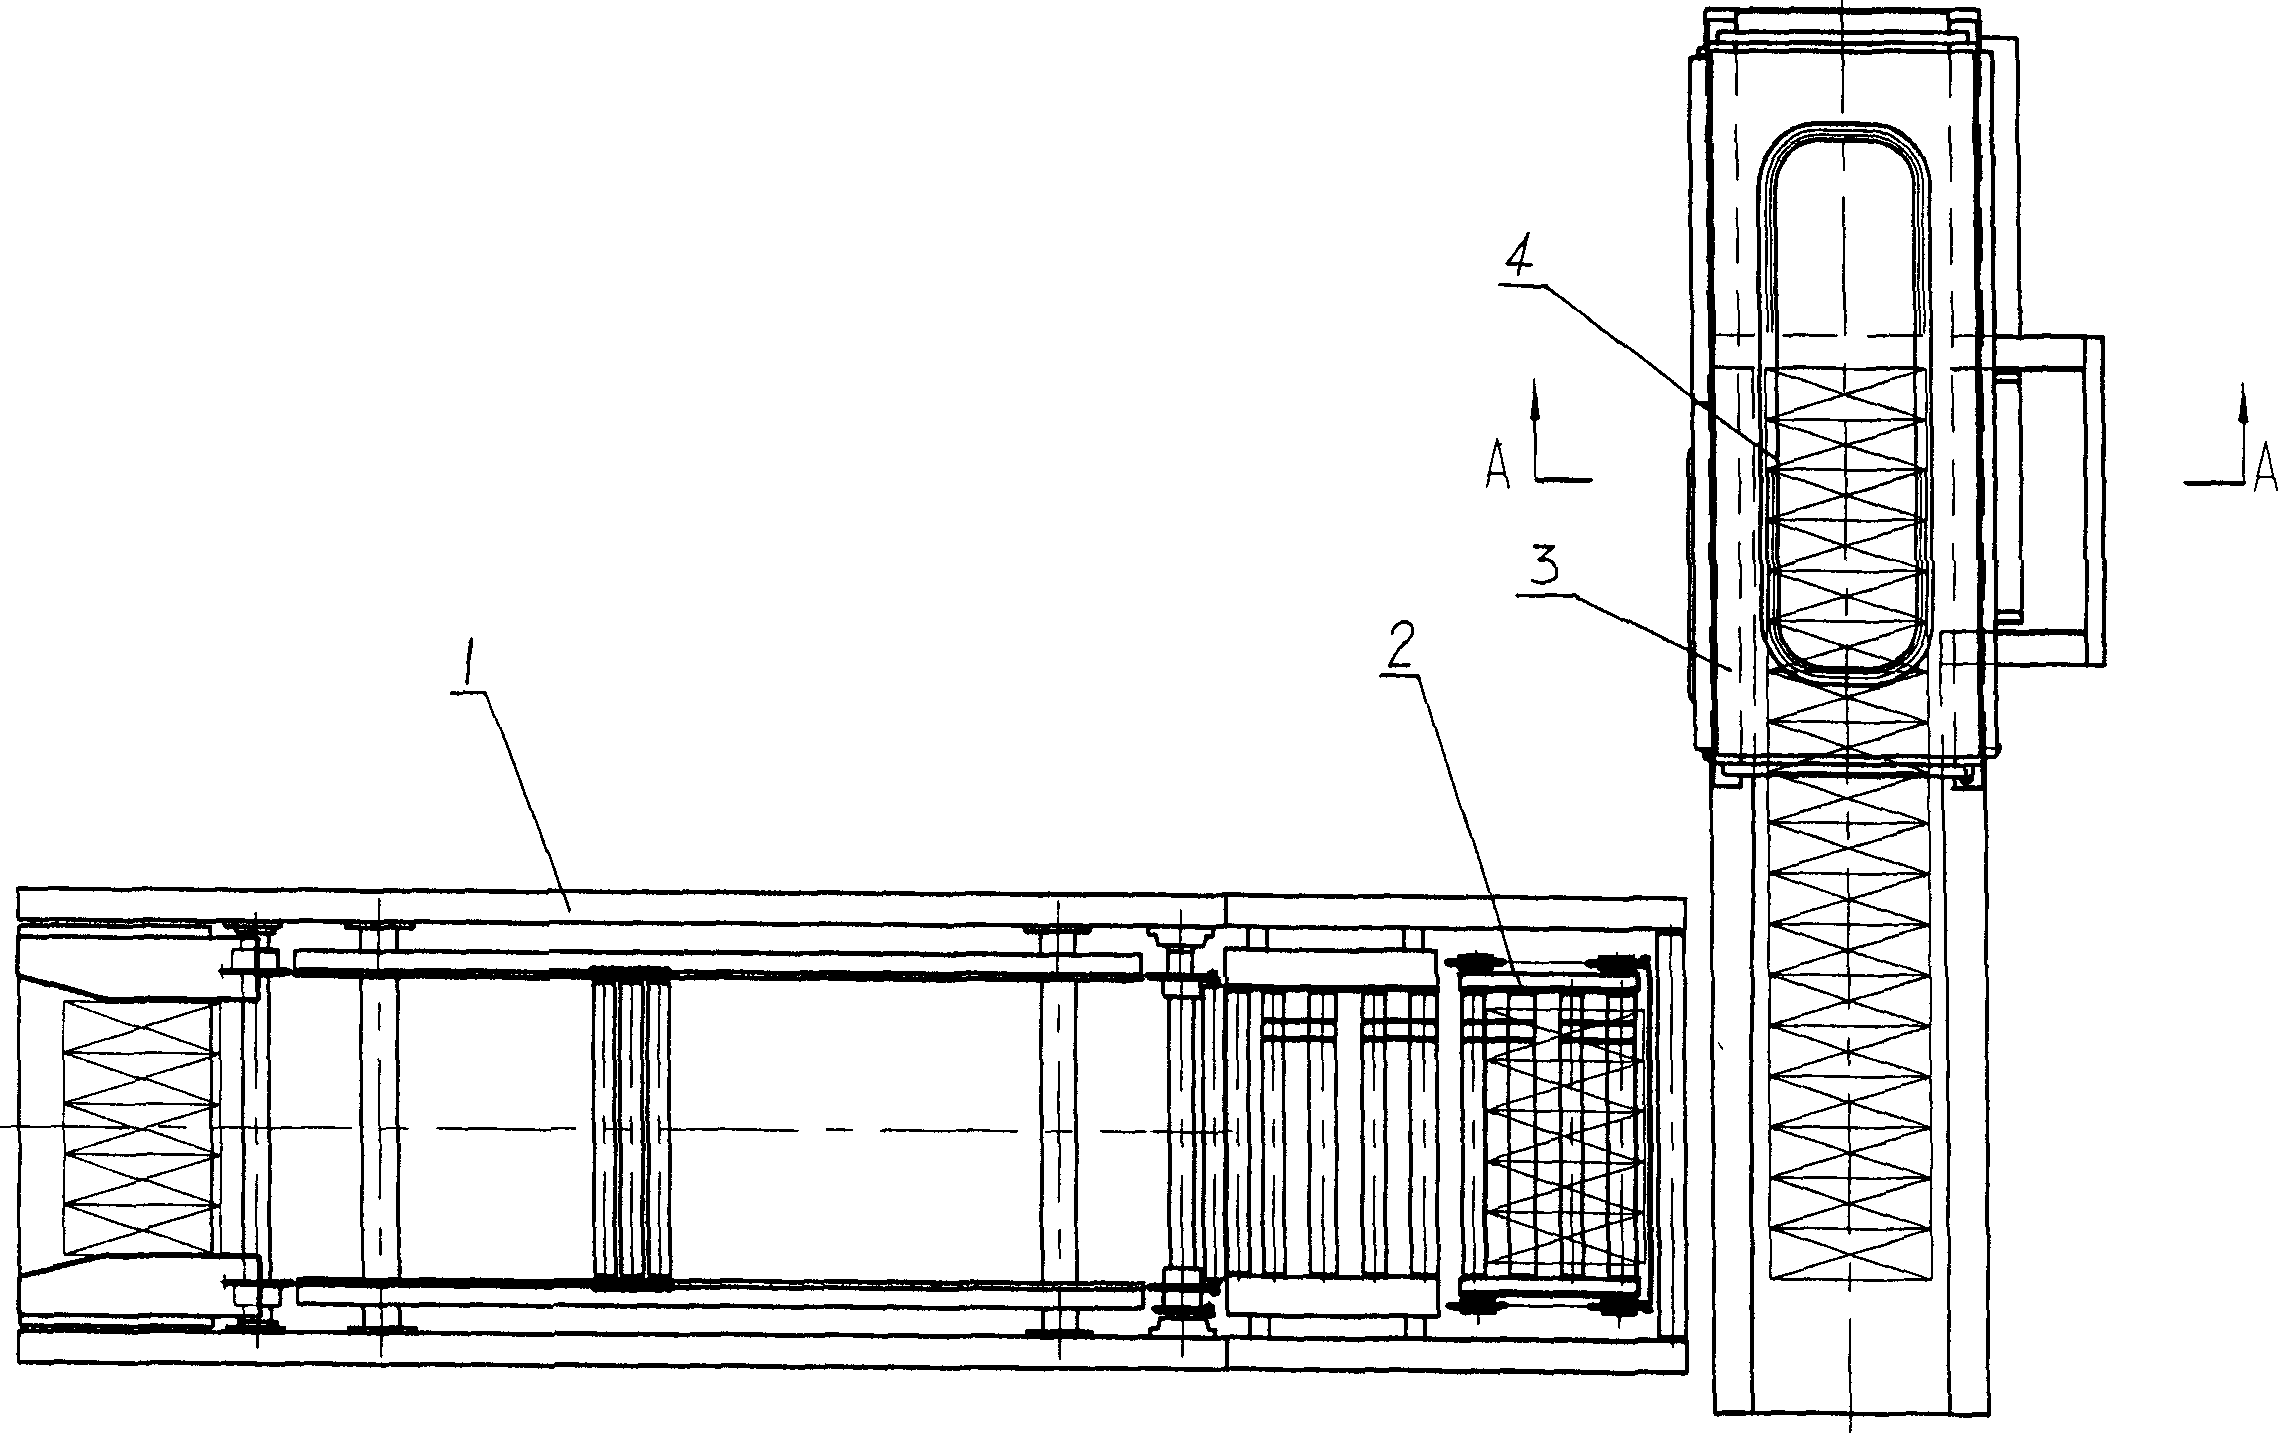
The invention discloses a self-distribution system to combine and pickup unit randomly, which consists of upstream distribution device and downstream interflow device along the material conveying line, wherein the distribution device contains pile-shaped material conveying structure (1) and distribution structure (2) in the output end of conveyer; the interflow device connects the output end of distribution structure, which contains distribution material conveying structure (3) and dialing structure (4) on the conveying structure. The invention can pick up and dispense random quantity of bar-shaped material, which replaces the worker to lessen the working strength greatly.
Owner:KUNMING KSEC LOGISTIC INFORMATION IND
Cross belt type sorting device
ActiveCN105752603ASimple structureFlexible sortingConveyorsSortingBidirectional transmissionMechanical engineering
The invention discloses a cross belt type sorting device. The cross belt type sorting device comprises sorting structures, a driving structure used for enabling the sorting structures to move along a main conveying line, and a bidirectional transmission structure used for enabling the sorting structures to work in the forward direction or the reverse direction. The cross belt type sorting device has the advantages of being simple in structure, capable of carrying out loading and unloading at any needed sorting position and capable of carrying out sorting on the two sides of the main conveying line.
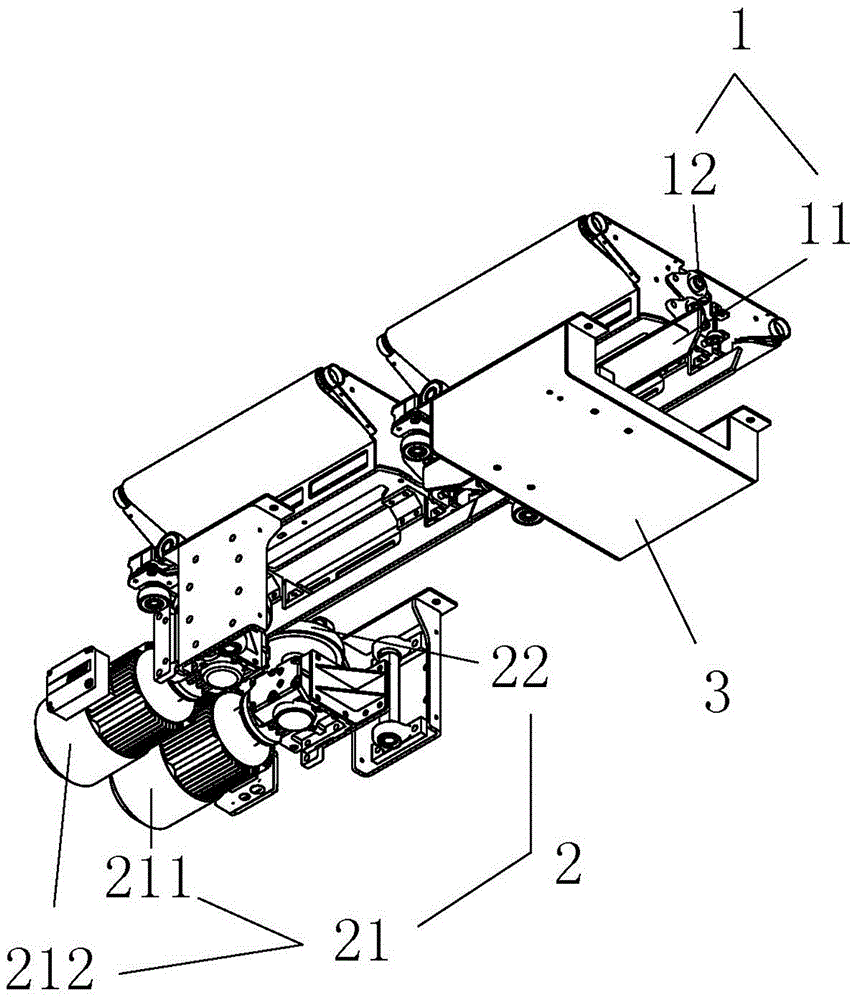
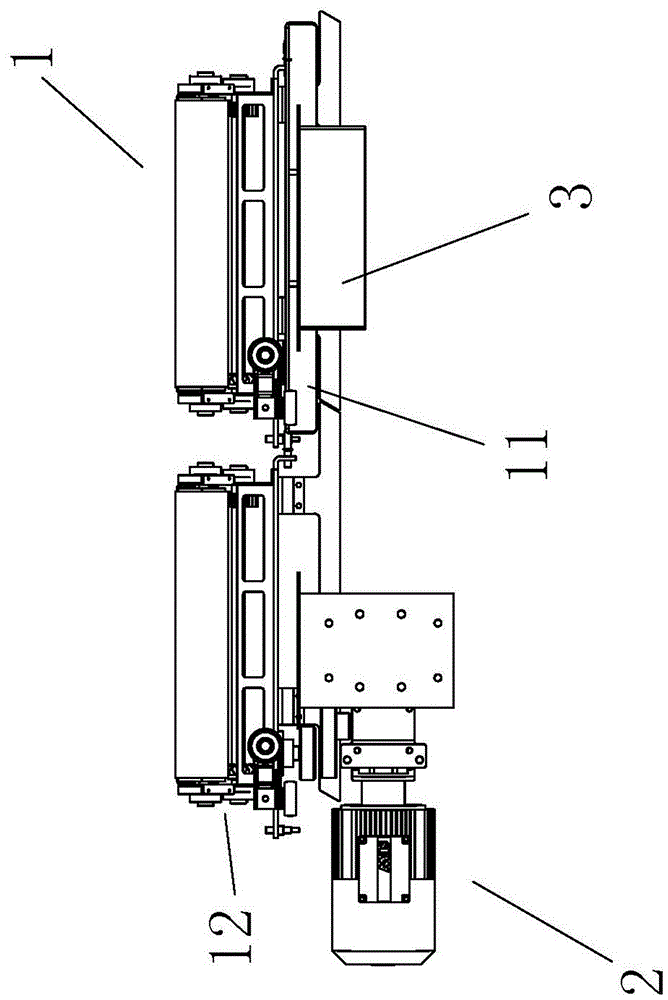
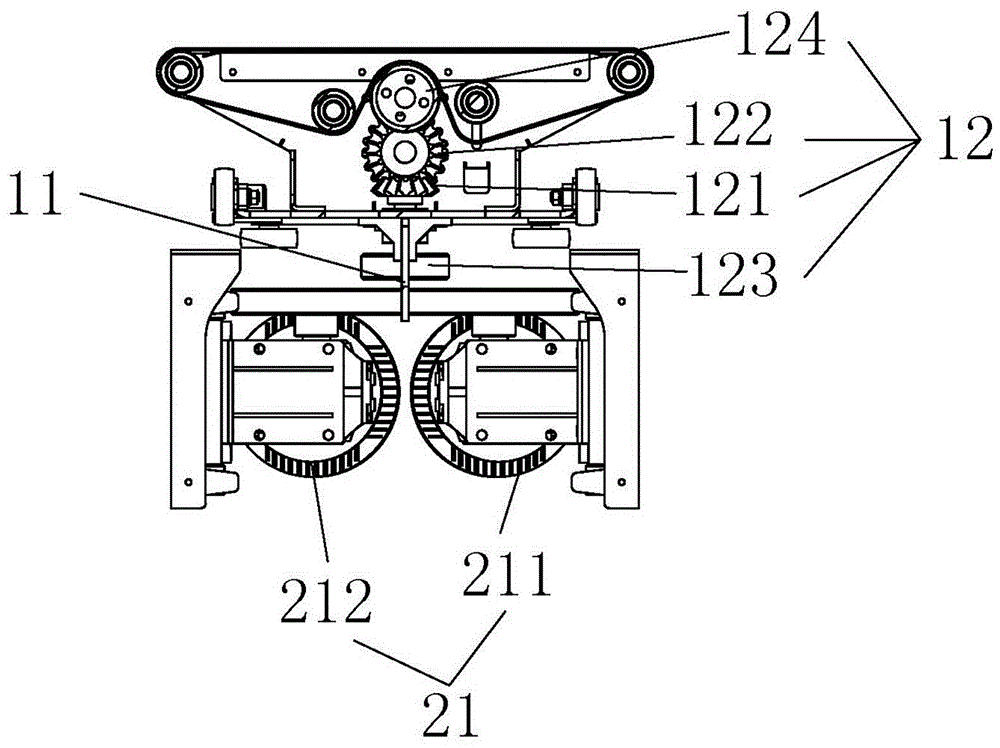
Owner:HUZHOU NANXUN DEAO MACHINERY EQUIP
File processing method based on flexible screen, mobile terminal and storage medium
ActiveCN109521916AFlexible sortingFile/folder operationsInput/output processes for data processingDocument handlingComputer engineering
The invention discloses a file processing method based on a flexible screen, a mobile terminal and a storage medium. When it is detected that the bending state of the flexible screen meets the set condition, the application icons of the set area in the flexible screen are sorted and sorted. The invention does not require a user to pre-determine an application icon to be edited, but only through the bending operation of the flexible screen of the mobile terminal automatically triggers the sorting and sorting function of putting the application icons of the set area into the corresponding folders, the utility model provides a function of batch sorting and sorting all application icons in any part of a two-part area divided by a bending line, or provide the user with the batch sorting function of a row of application icons covered by the bending line, and can flexibly sort and sort the individual application icons according to the bending points generated by the bending operation of an application icon.


Owner:NUBIA TECHNOLOGY CO LTD
Novel sorting device for storing
InactiveCN107934335AEasy to sortFlexible moving processStorage devicesConveyor partsManipulatorEngineering
The invention discloses a novel sorting device for storage, which belongs to the technical field of storage sorting equipment, and aims to solve the problem of unstable clamping of the existing sorting device. It includes a connected sorting manipulator and a universal moving mechanism. The sorting manipulator includes a frame on which a driving hydraulic cylinder is installed. Clamping frame 1 and clamping frame 2 are set in the hole. Sorting handle 1 and sorting handle 2 are connected to clamping frame 1 and clamping frame 2. Hollow sliders 1 and 2 are set on both sides of the connecting rod. Slider 2, the upper and lower surfaces of hollow slider 1 are hinged with connecting rod 1 and connecting rod 2, the other end of connecting rod 1 is hinged with the frame, the other end of connecting rod 2 is hinged with clamping frame 1, the upper and lower surfaces of hollow slider 2 Hinged with connecting rod three, connecting rod four, the other end of connecting rod three is hinged with frame, the other end of connecting rod four is hinged with clamping frame two. The invention is applicable to sorting devices for storage.
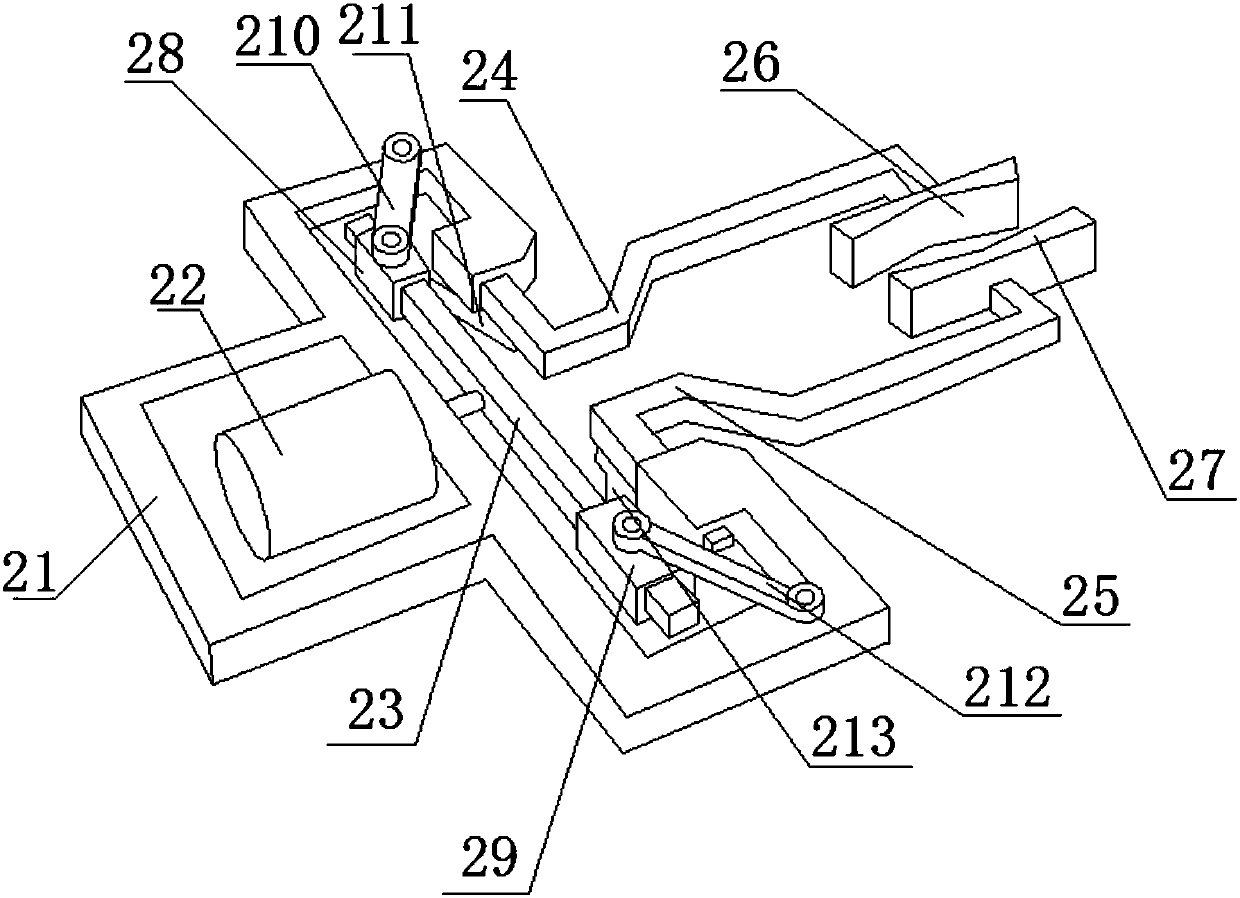
Owner:沈波
Controlling method of waypoint flow
ActiveCN103065506AImplement flow controlFlexible controlAircraft traffic controlTime rangeSorting algorithm
The invention relates to a controlling method of waypoint flow. The controlling method of the waypoint flow comprises establishing a time slice containing a plurality of time ranges according to a time sequence, initializing the time ranges, enabling each time range to be in an open and free state, setting the pass frequency of a waypoint in different time ranges according to the flow control information of the waypoint, adjusting width of different time ranges according to the passing frequency, and marking the opening-closing state of the time range corresponding to the pass frequency to be a closed state when the passing frequency is zero. The controlling method of the waypoint flow describes and controls the trafficability characteristic of an aircraft of the waypoint at a specific time through the width change, the opening-closing change, and the free-non-free change of the time slice, is suitable for different flight sort algorithms, namely, can carrying out flexible sorting according to the properties of different aircrafts, and is easy to control and high in precision, and therefore the flow control of the waypoint can be effectively achieved, and conflicts are prevented from occurring.
Owner:CICIL AVIATION HUADONG NAVIGATION MANAGEMENT EQUIP INSTALLATION DEPT
Sorting device for logistics
InactiveCN107891005ASolve the problem that cannot be sorted flexiblyFlexible sortingSortingLogistics managementEngineering
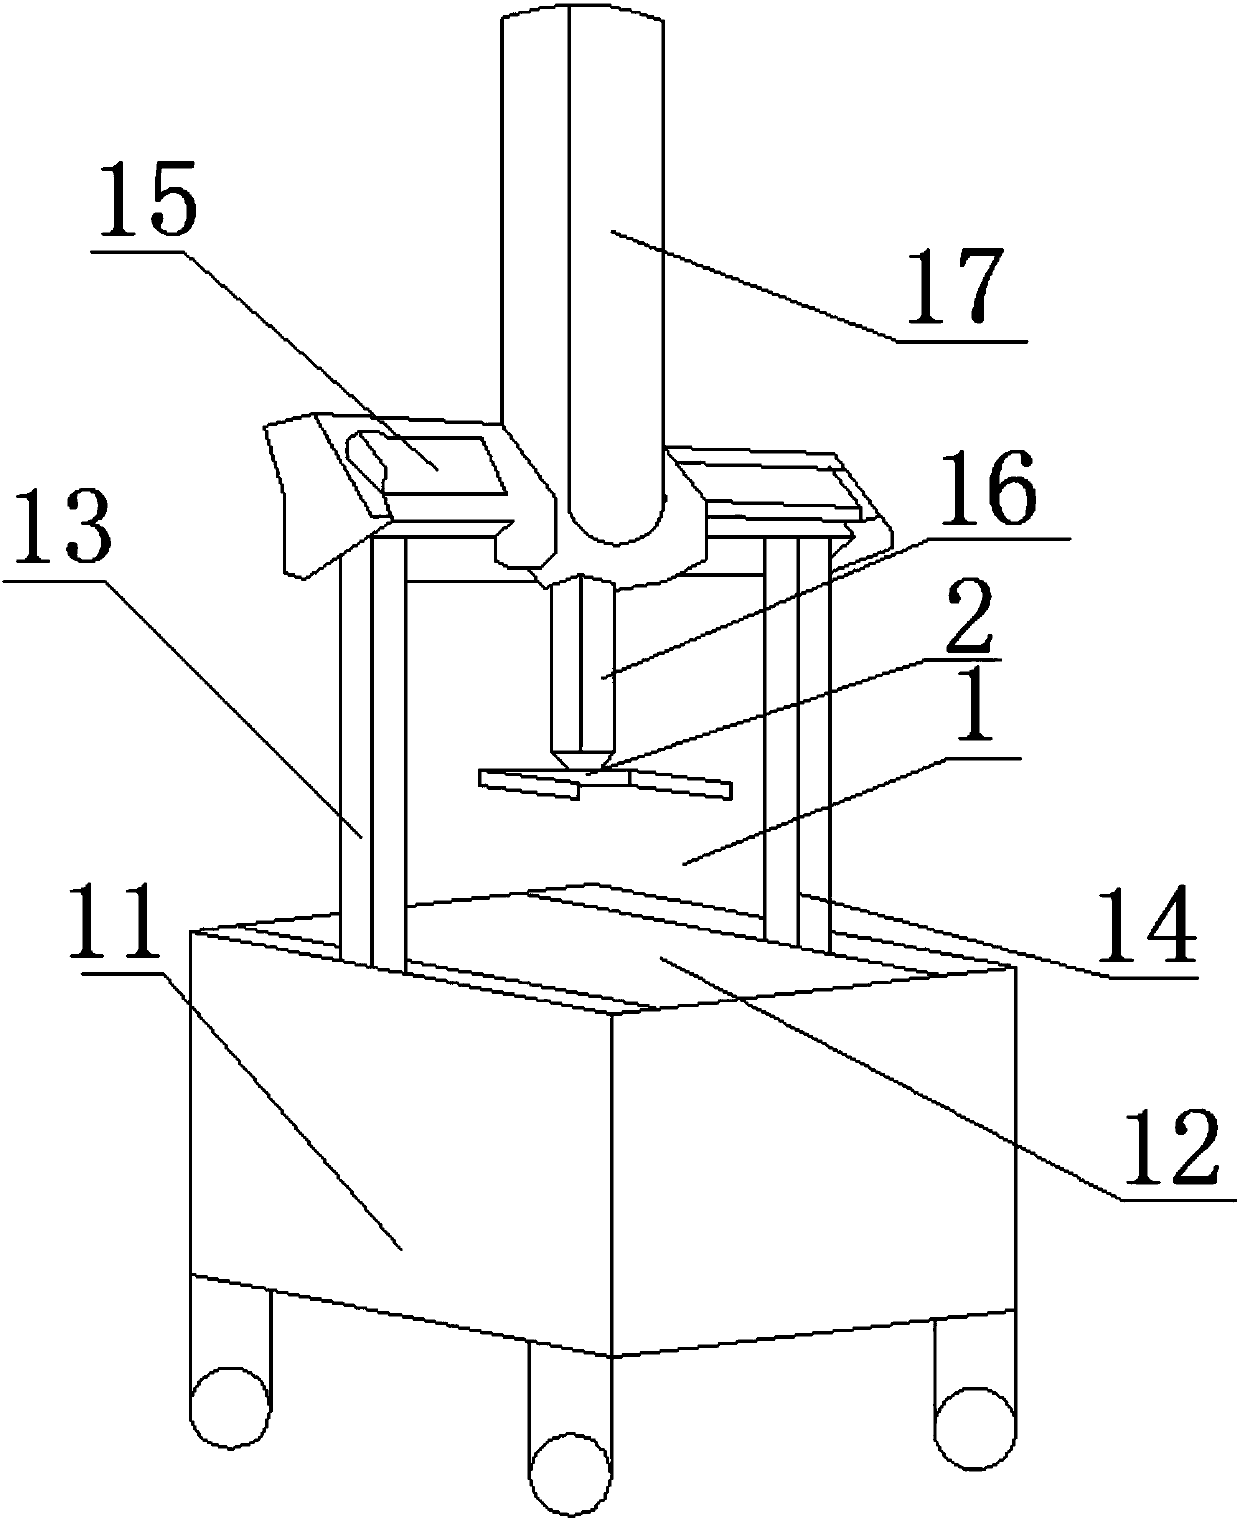
The invention discloses a sorting device for logistics, and belongs to the technical field of logistics sorting equipment. The sorting device aims at solving the problem that an existing sorting device cannot achieve flexible sorting. The sorting device comprises a sorting mechanical arm and a three-dimensional movement mechanism. The three-dimensional movement mechanism comprises a base. A movement assembly is arranged below the base. A carrier platform is arranged on the base. Sliding grooves are formed in the left side and the right side of the carrier platform correspondingly. A first movement column and a second movement column are arranged in the sliding grooves. A cross beam is arranged between the first movement column and the second movement column and provided with a guide rail.A movement arm is arranged on the guide rail in a sleeved manner. The movement arm is vertically arranged relative to the cross beam and can slide in the length direction of the guide rail. A drive air cylinder is arranged in the movement arm. The output end of the drive air cylinder can move in the vertical direction and is connected with the sorting mechanical arm. The sorting device is suitablefor sorting devices for logistics.


Owner:SICHUAN ZHONGYONG PHARMA CO LTD
Three-dimensional moving device for logistics
InactiveCN107915042AFlexible moving processSolve the problem of inability to move flexiblyConveyor partsLogistics managementEngineering
The invention discloses a three-dimensional moving device for logistics and belongs to the technical field of logistics sorting equipment. The three-dimensional moving device is used for solving the problem that an existing sorting mechanical hand cannot move flexibly. The three-dimensional moving device comprises a base. A moving assembly is arranged below the base. A carrying platform is arranged on the base. Sliding grooves are formed in the left side and the right side of the carrying platform. A first moving pillar and a second moving pillar are arranged in the sliding grooves. A cross beam is arranged between the first moving pillar and the second moving pillar, and a guide rail is arranged on the cross beam. A moving arm is arranged on the guide rail in a sleeving manner. The movingarm is perpendicular to the cross beam and can slide in the length direction of the guide rail. A driving air cylinder is arranged in the moving arm. The output end of the driving air cylinder can move in the vertical direction. The three-dimensional moving device is suitable for logistics.

Owner:SICHUAN ZHONGYONG PHARMA CO LTD
Sorting method, sorting device and user equipment
ActiveCN106371741AEasy to determineEasy to sortInput/output processes for data processingUser deviceTouchscreen
Embodiments of the invention provide a sorting method, a sorting device and user equipment. The sorting method comprises the following steps of: in response to a touch event on a touch screen, determining two touch positions and two touch pressures at the two touch positions; determining a plurality of contents pointed by the two touch positions; determining a sorting manner according to the two touch pressures at the two touch positions; and sorting the plurality of contents by adoption of a sorting manner. Embodiments of the invention provide a sorting scheme.


Owner:BEIJING ZHIGU RUI TUO TECH
Automatic dispense system of randomly assembled sorting unit
ActiveCN100460094CImprove replenishment efficiencyEasy replenishmentDe-stacking articlesSortingDistribution systemEngineering
The invention discloses a self-distribution system to combine and pickup unit randomly, which consists of upstream distribution device and downstream interflow device along the material conveying line, wherein the distribution device contains pile-shaped material conveying structure (1) and distribution structure (2) in the output end of conveyer; the interflow device connects the output end of distribution structure, which contains distribution material conveying structure (3) and dialing structure (4) on the conveying structure. The invention can pick up and dispense random quantity of bar-shaped material, which replaces the worker to lessen the working strength greatly.


Owner:KUNMING KSEC LOGISTIC INFORMATION IND
Method, equipment and system of node sorting and selection
InactiveCN102318288BFlexible sortingMeet the actual application needsData switching networksPathPingEngineering
Provided are a node ranking and selection method, device and system. The ranking method includes: receiving a node ranking request sent by a node selection device, with the node ranking request containing a source address, at least two destination node addresses and a direction parameter; determining path overhead values between the source address and the at least two destination node addresses in the direction indicated by the direction parameter; ranking the at least two destination node addresses according to the path overhead values, and generating a ranking result, with the ranking result containing the optimal destination node address; and feeding back the ranking result to the node selection device, so that a user terminal sends a service request to the optimal destination node address. According to the embodiments of the present invention, destination node addresses can be ranked flexibly according to the routing information in different directions, so that the selection of the optimal node can meet practical application demands.


Owner:HUAWEI TECH CO LTD
Logistics sorting system
InactiveCN107891007AFlexible sortingSolve the problem of inflexible sorting and low sorting efficiencySortingLogistics managementIdentification device
The invention discloses a logistics sorting system, and belongs to the technical field of logistics sorting. The logistics sorting system aims to solve the problem that an existing sorting system is low in sorting efficiency. The logistics sorting system comprises a recognition device, a conveying device, sorting devices and a controller, wherein the recognition device is electrically connected tothe controller, the conveying device is electrically connected to the controller, the sorting devices are electrically connected to the controller, the recognition device comprises a scanning assembly, the scanning assembly is electrically connected to a storage device, the storage device is electrically connected to the controller, the conveying device comprises a plurality of conveying belts which are arranged in parallel, the recognition device is arranged on the conveying belts, the multiple sorting devices are arranged among the conveying belts, each sorting device comprises a sorting mechanical arm and a three-dimensional moving mechanism. The logistics sorting system is high in applicability.


Owner:SICHUAN ZHONGYONG PHARMA CO LTD
Solid separating device
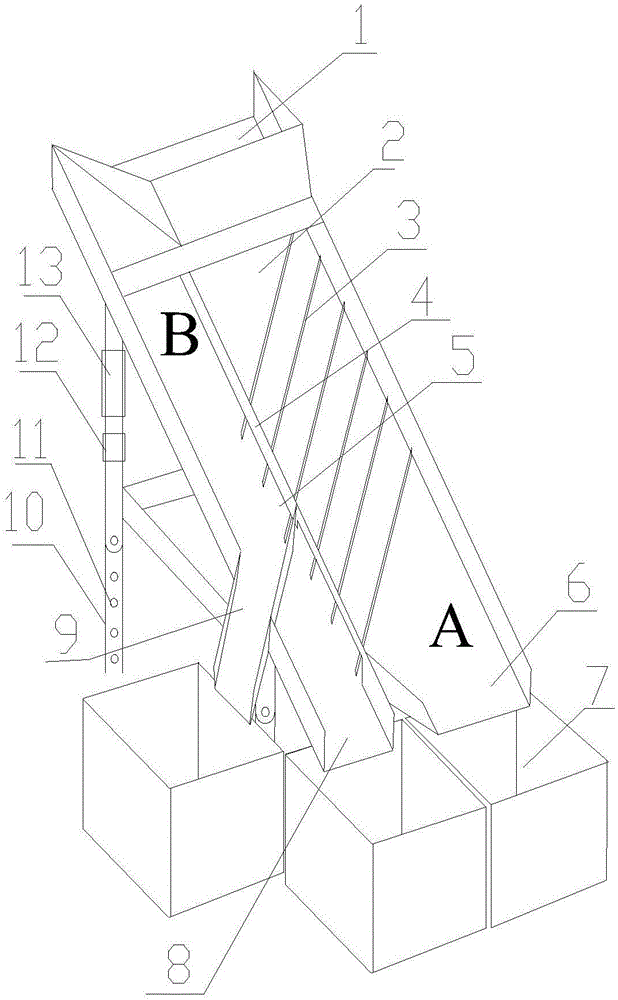
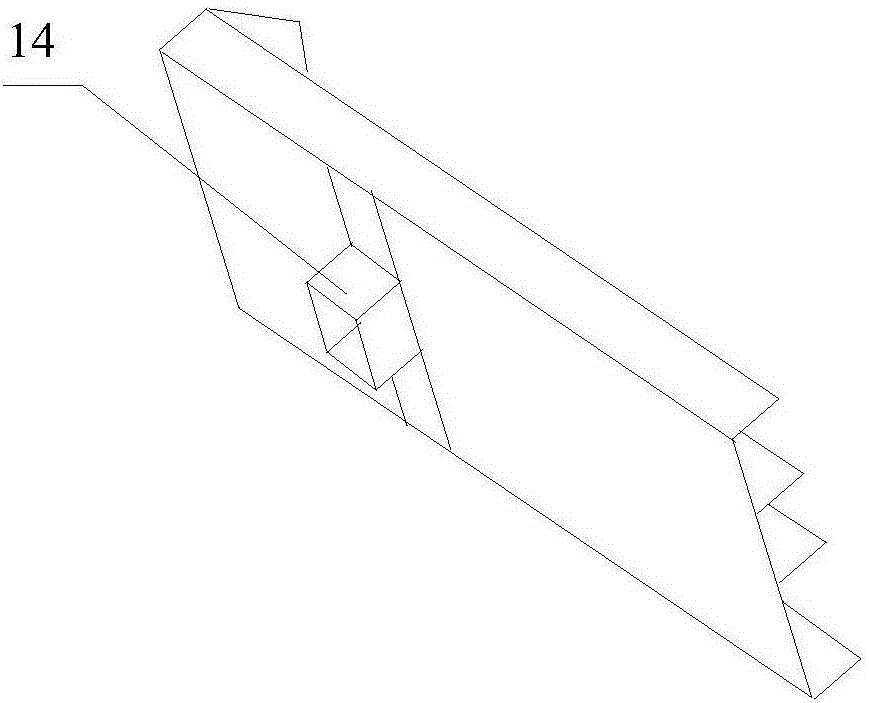
The invention discloses a solid separating device and belongs to the field of separating devices. The solid separating device comprises supporting racks which are obliquely fixed to a separating liner plate through a vibrator; the angle of inclination can be adjusted through a supporting adjusting rod, the separating liner plate is divided into two parallel grooves, a feed inlet is formed in the top end of the groove A, a first discharge port is formed in the bottom end of the groove A, and a plurality of separating edges are arranged obliquely downward in the groove A; a second discharge port is formed in the bottom end of the groove B, the groove A and the groove B are separated through a separating baffle plate, a third discharge port is further formed in the middle part of the groove B, the separating baffle plate is trapezoidal, the separating baffle plate, the separating edges and the separating liner plate form separating holes, the pore diameter of the separating hole leading to the second discharge port is greater than that of the separating hole leading to the third discharge port, and the gradients of the separating edges can be adjusted through bolts; an independent material collecting box is arranged at each of the discharge ports. The solid separating device disclosed by the invention is simple in structure and separates irregular solids quickly and efficiently with many requirements at one time as required.
Owner:ASIA SILICON QINGHAI
Test method and device of smart home equipment, program and electronic equipment
PendingCN119472608AImprove execution success rateavoid manual interventionProgramme controlElectric testing/monitoringTest efficiencyReliability engineering
The invention provides a test method and device of smart home equipment, a program and electronic equipment. The method comprises the following steps: acquiring a current equipment state of the smart home equipment; according to the current equipment state and the priority weights, the execution sequence of the multiple test cases in the test case library is determined, so that the smart home equipment executes the multiple test cases, and each test case in the test case library has a preset priority weight. According to the invention, the problem that the test efficiency is affected due to inflexible sorting of the test cases of the smart home equipment in the prior art is solved.

Owner:GREE ELECTRIC APPLIANCE INC OF ZHUHAI +1
Controlling method of waypoint flow
ActiveCN103065506BImplement flow controlFlexible controlAircraft traffic controlTime rangeSorting algorithm
The invention relates to a controlling method of waypoint flow. The controlling method of the waypoint flow comprises establishing a time slice containing a plurality of time ranges according to a time sequence, initializing the time ranges, enabling each time range to be in an open and free state, setting the pass frequency of a waypoint in different time ranges according to the flow control information of the waypoint, adjusting width of different time ranges according to the passing frequency, and marking the opening-closing state of the time range corresponding to the pass frequency to be a closed state when the passing frequency is zero. The controlling method of the waypoint flow describes and controls the trafficability characteristic of an aircraft of the waypoint at a specific time through the width change, the opening-closing change, and the free-non-free change of the time slice, is suitable for different flight sort algorithms, namely, can carrying out flexible sorting according to the properties of different aircrafts, and is easy to control and high in precision, and therefore the flow control of the waypoint can be effectively achieved, and conflicts are prevented from occurring.
Owner:CICIL AVIATION HUADONG NAVIGATION MANAGEMENT EQUIP INSTALLATION DEPT
Intelligent express transfer robot and use method
PendingCN113733108ASave space resourcesMeet the needs of sorting stationsProgramme-controlled manipulatorSortingControl engineeringMachine
The invention provides an intelligent express transfer robot and a use method. The robot comprises a base, a movable rotating disc, a carrying platform and a machine frame, the movable rotating disc is installed in an inner groove of the base, each of the base and the movable rotating disc is of a hollow shell structure, a control monitoring module and a storage battery module are arranged in the base, base moving mechanisms are arranged on the periphery in an upper-layer cavity of the movable rotating disc, a rotating shaft is arranged in the center, a charging mechanism is arranged in a lower-layer cavity, the rotating shaft is connected to the movable rotating disc and the base, the storage battery module is connected to the base moving mechanisms through cables, the charging mechanism is connected to the storage battery module through a base conductive mechanism, the machine frame is arranged at the four corners of the base, the four corners of the carrying platform are connected to the machine frame, the carrying platform ascends and descends along the machine frame through a lifting driving mechanism, and the storage battery module is connected to the lifting driving mechanism through a machine frame conductive mechanism. According to the robot and the use method, storage express sorting automation is achieved, the labor cost is lowered, and the storage efficiency is improved.


Owner:WUHAN UNIV OF TECH
Turbine blade intelligent identifying, sorting and sequencing control system based on collaborative robot
PendingCN119525159AReduce labor intensityimprove accuracyPrintingSortingSequence controlControl system
The invention relates to the field of detection, sorting and sequencing of turbine blades before installation, in particular to a control system for intelligent identification, sorting and sequencing of turbine blades based on a collaborative robot. The robot is installed on the robot stand column, a blade picking clamping jaw is carried at the tail end of the robot, and a camera, a balance and a code spraying machine are sequentially distributed on the inner side equipment. And the robot drives the clamping jaw at the tail end to move so as to complete operations such as detection before installation of all turbine blades. Blade picking of the blade feeding box is completed through the clamping jaw, blade code recognition is achieved through the camera system, automatic weighing of the blades is achieved through the balance, blade weight information jet printing is achieved through the ink-jet printer, and finally the jet-printed blades are placed in the blade discharging box. And the operations of picking up the blades, scanning and identifying the codes, weighing the blades, spraying the codes on the blades and placing the blades are repeatedly executed in sequence until all the operations of the blades in the whole box are completed. According to the invention, the installation efficiency of subsequent assembly is improved, and the risk of information acquisition or input errors caused by manual operation originally is reduced.

Owner:SHENYANG INST OF AUTOMATION - CHINESE ACAD OF SCI
Horizontal carton packaged cigarette sorter
ActiveCN101185927BNot suitable for damageRealize automatic sortingSortingLogistics managementControl system
The invention which belongs to the field of logistics equipment technology relates to a horizontal tobacco carton sorting machine used in tobacco carton delivery operation, comprising a turn-over tobacco supplement device, a tobacco carton delivery mechanism which includes a conveying passage and a separated transportation mechanism, a tobacco carton sorting mechanism and a control system. The turn-over tobacco supplement device is arranged at the start end of the conveying passage of the tobacco carton delivery mechanism. The tobacco carton sorting mechanism is arranged at the terminal end of the separated transportation mechanism of the tobacco carton delivery mechanism. The whole structure of the machine is simple and reasonable. The style of tobacco supplement is simple, rapid and labor-saving, which reduces labor intensity and improves working efficiency. The sorting is flexible with a reliable precision, which seldom damages the tobacco carton and improves the sorting package quality. According to the requirements of the sorting business, the sorting system can be arbitrarily combined and installed by utilizing the horizontal tobacco carton sorting machine, so as to realize the automatic sorting of tobacco carton and high adaptability.


Owner:BLUESWORD INTELLIGENT TECH CO LTD
uav sensor signal redundancy voting system
ActiveCN109976141BEnsure flight safetyImprove securitySafety arrangmentsData acquisitionAlgorithm Selection
The invention discloses a UAV sensor signal redundancy voting system, which aims to provide a more flexible, safe and reliable redundancy voting system. The present invention is realized through the following technical solutions: the UAV flight data is collected by the sensor data acquisition system and sent to the central controller, the redundancy management module in the management software configures the redundancy of the signal, and the voting device passes the signal voting algorithm Select the sensor signal input, the flight management control program dynamically adjusts the signal threshold according to the size of the sensor data, four-degree redundancy synchronously judges whether the sensor is faulty, the voting device detects the fault and isolates the corresponding sensor signal and performs signal voting; if the hardware circuit is normal, The fault is judged according to the data of each sensor; the sensor data whose data value is in the middle is selected as the final output; the voting device averages the remaining valid signals according to the sensor signal value and fault latch information to output a voting signal.


Owner:CHENGDU AIRCRAFT INDUSTRY GROUP
Terminal equipment access control system and led display system
ActiveCN105679231BPrecise positioningEasy to operateStatic indicating devicesLED displayControl system
The present invention relates to a terminal device access control system. The terminal device access control system comprises an upper computer and a plurality of terminal devices which are in cascade connection, the upper computer is connected with the first-stage terminal device of the plurality of terminal devices via a network, and the plurality of terminal devices are in the cascade connection via a serial bus. The present invention also provides an LED display system using the terminal device access control system. According to the present invention, the upper computer and the first stage terminal device are connected via the network, and the terminal devices are in the cascade connection via the serial bus, so that the system architecture can be simplified under the premise of guaranteeing the communication speed, the remote access and the long-distance transmission control can be supported, the browser operations can be simplified, and the cascade sort is flexible, and accordingly, the positioning and addressing to the terminal devices are convenient.


Owner:XIAN NOVASTAR TECH
Sorting method, sorting device and user equipment
ActiveCN106371741BEasy to determineEasy to sortInput/output processes for data processingTouchscreenUser equipment
Embodiments of the invention provide a sorting method, a sorting device and user equipment. The sorting method comprises the following steps of: in response to a touch event on a touch screen, determining two touch positions and two touch pressures at the two touch positions; determining a plurality of contents pointed by the two touch positions; determining a sorting manner according to the two touch pressures at the two touch positions; and sorting the plurality of contents by adoption of a sorting manner. Embodiments of the invention provide a sorting scheme.


Owner:BEIJING ZHIGU RUI TUO TECH
A cross-belt sorting device
ActiveCN105752603BSmooth feedingSimple structureConveyorsSortingBidirectional transmissionEngineering
The invention discloses a cross belt type sorting device. The cross belt type sorting device comprises sorting structures, a driving structure used for enabling the sorting structures to move along a main conveying line, and a bidirectional transmission structure used for enabling the sorting structures to work in the forward direction or the reverse direction. The cross belt type sorting device has the advantages of being simple in structure, capable of carrying out loading and unloading at any needed sorting position and capable of carrying out sorting on the two sides of the main conveying line.


Owner:HUZHOU NANXUN DEAO MACHINERY EQUIP