
Patents
Literature
52 results about "Gps spoofing" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
GPS spoofing. Definition. GPS spoofing is the use of a signal that is stronger than and mimics the attributes of a genuine GPS signal to take over a GPS receiver. The signal can cause the receiver to report a position chosen by the attacker that is somewhere other than where the receiver actually is.
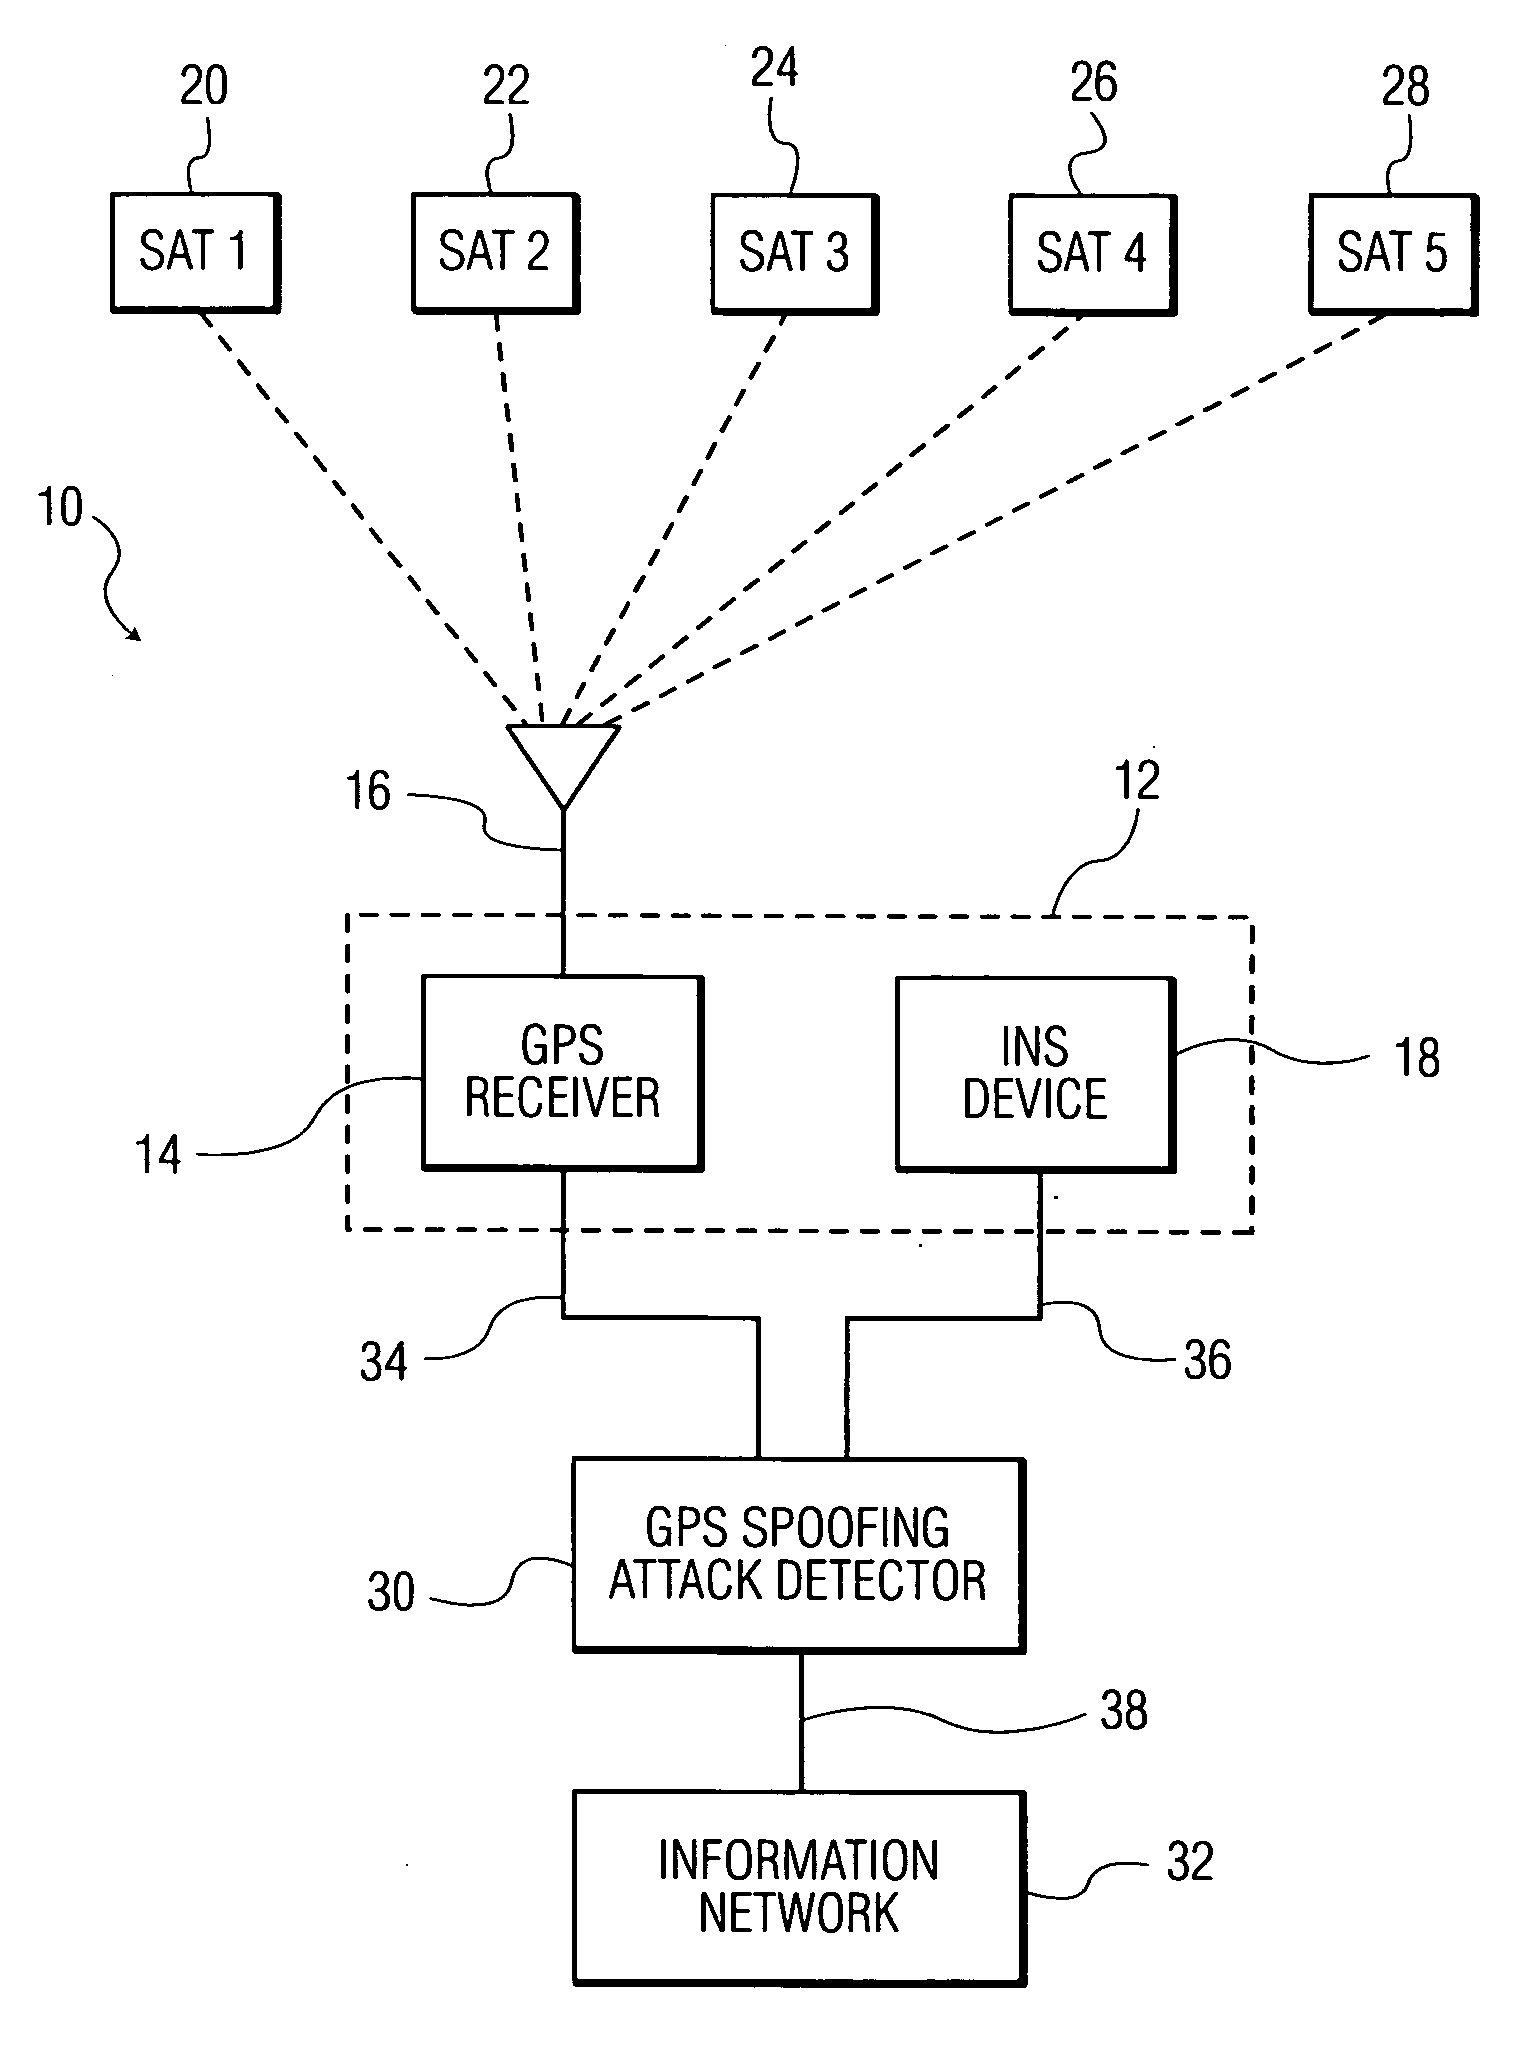
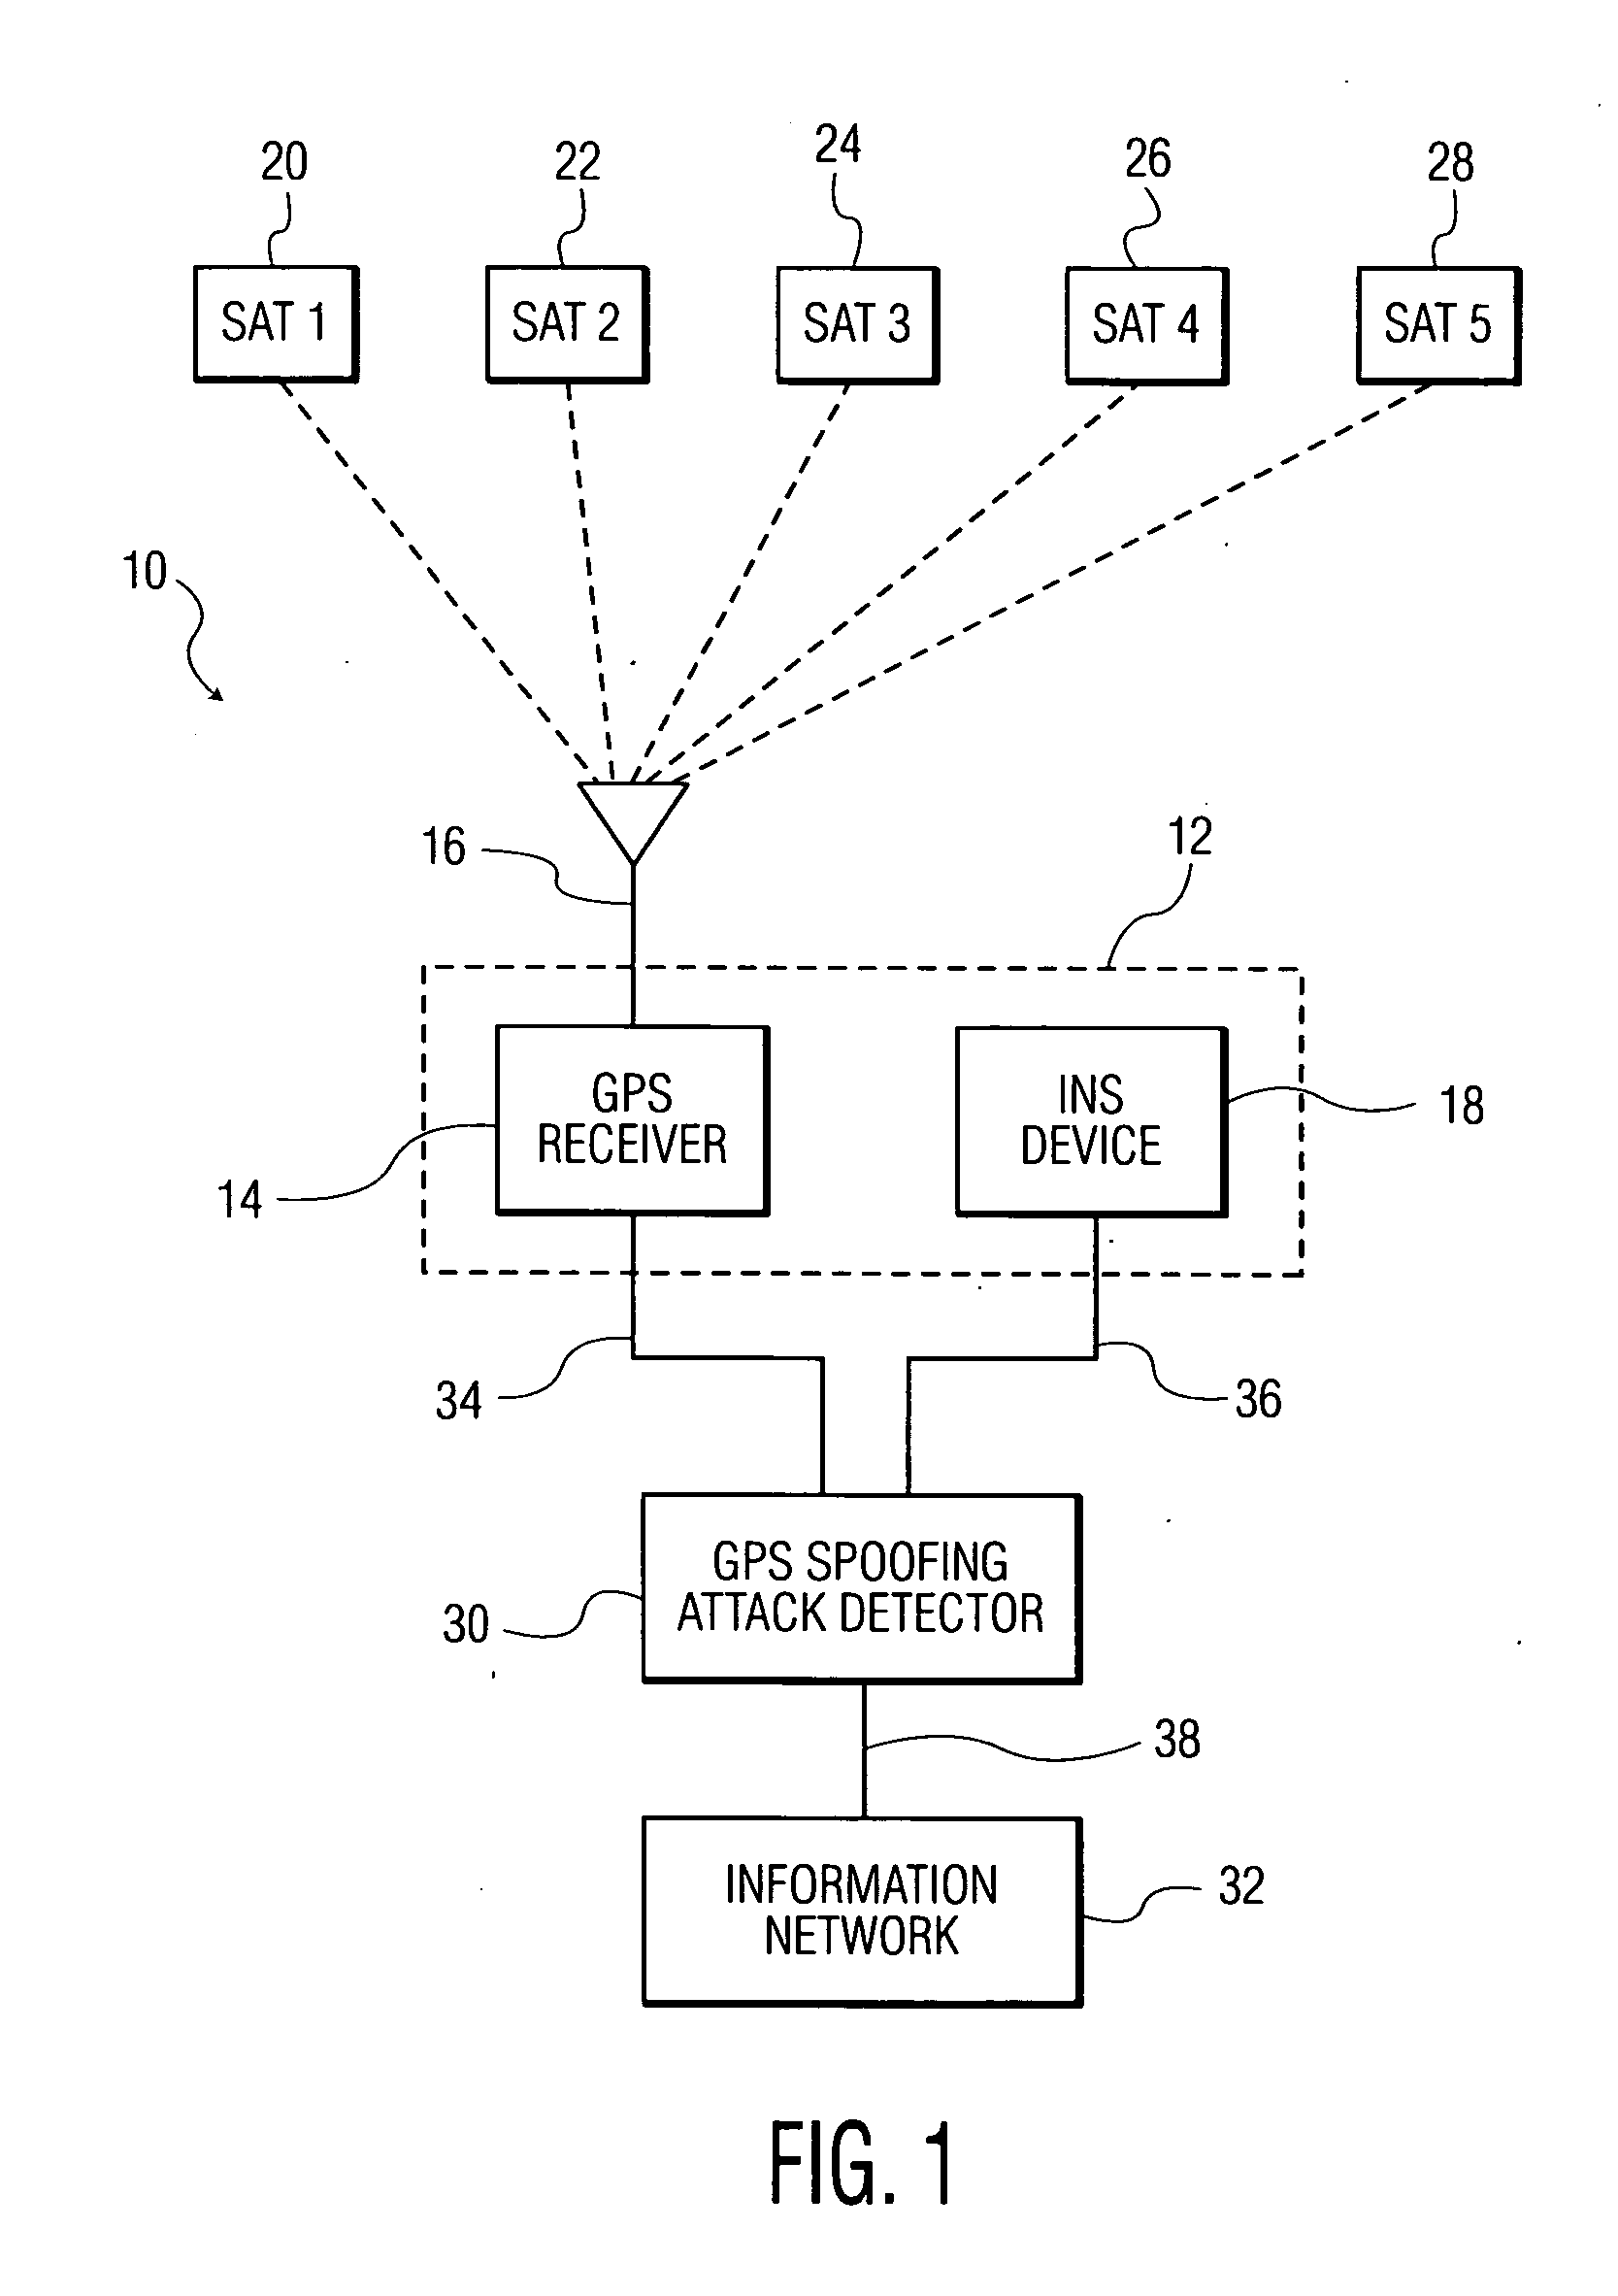
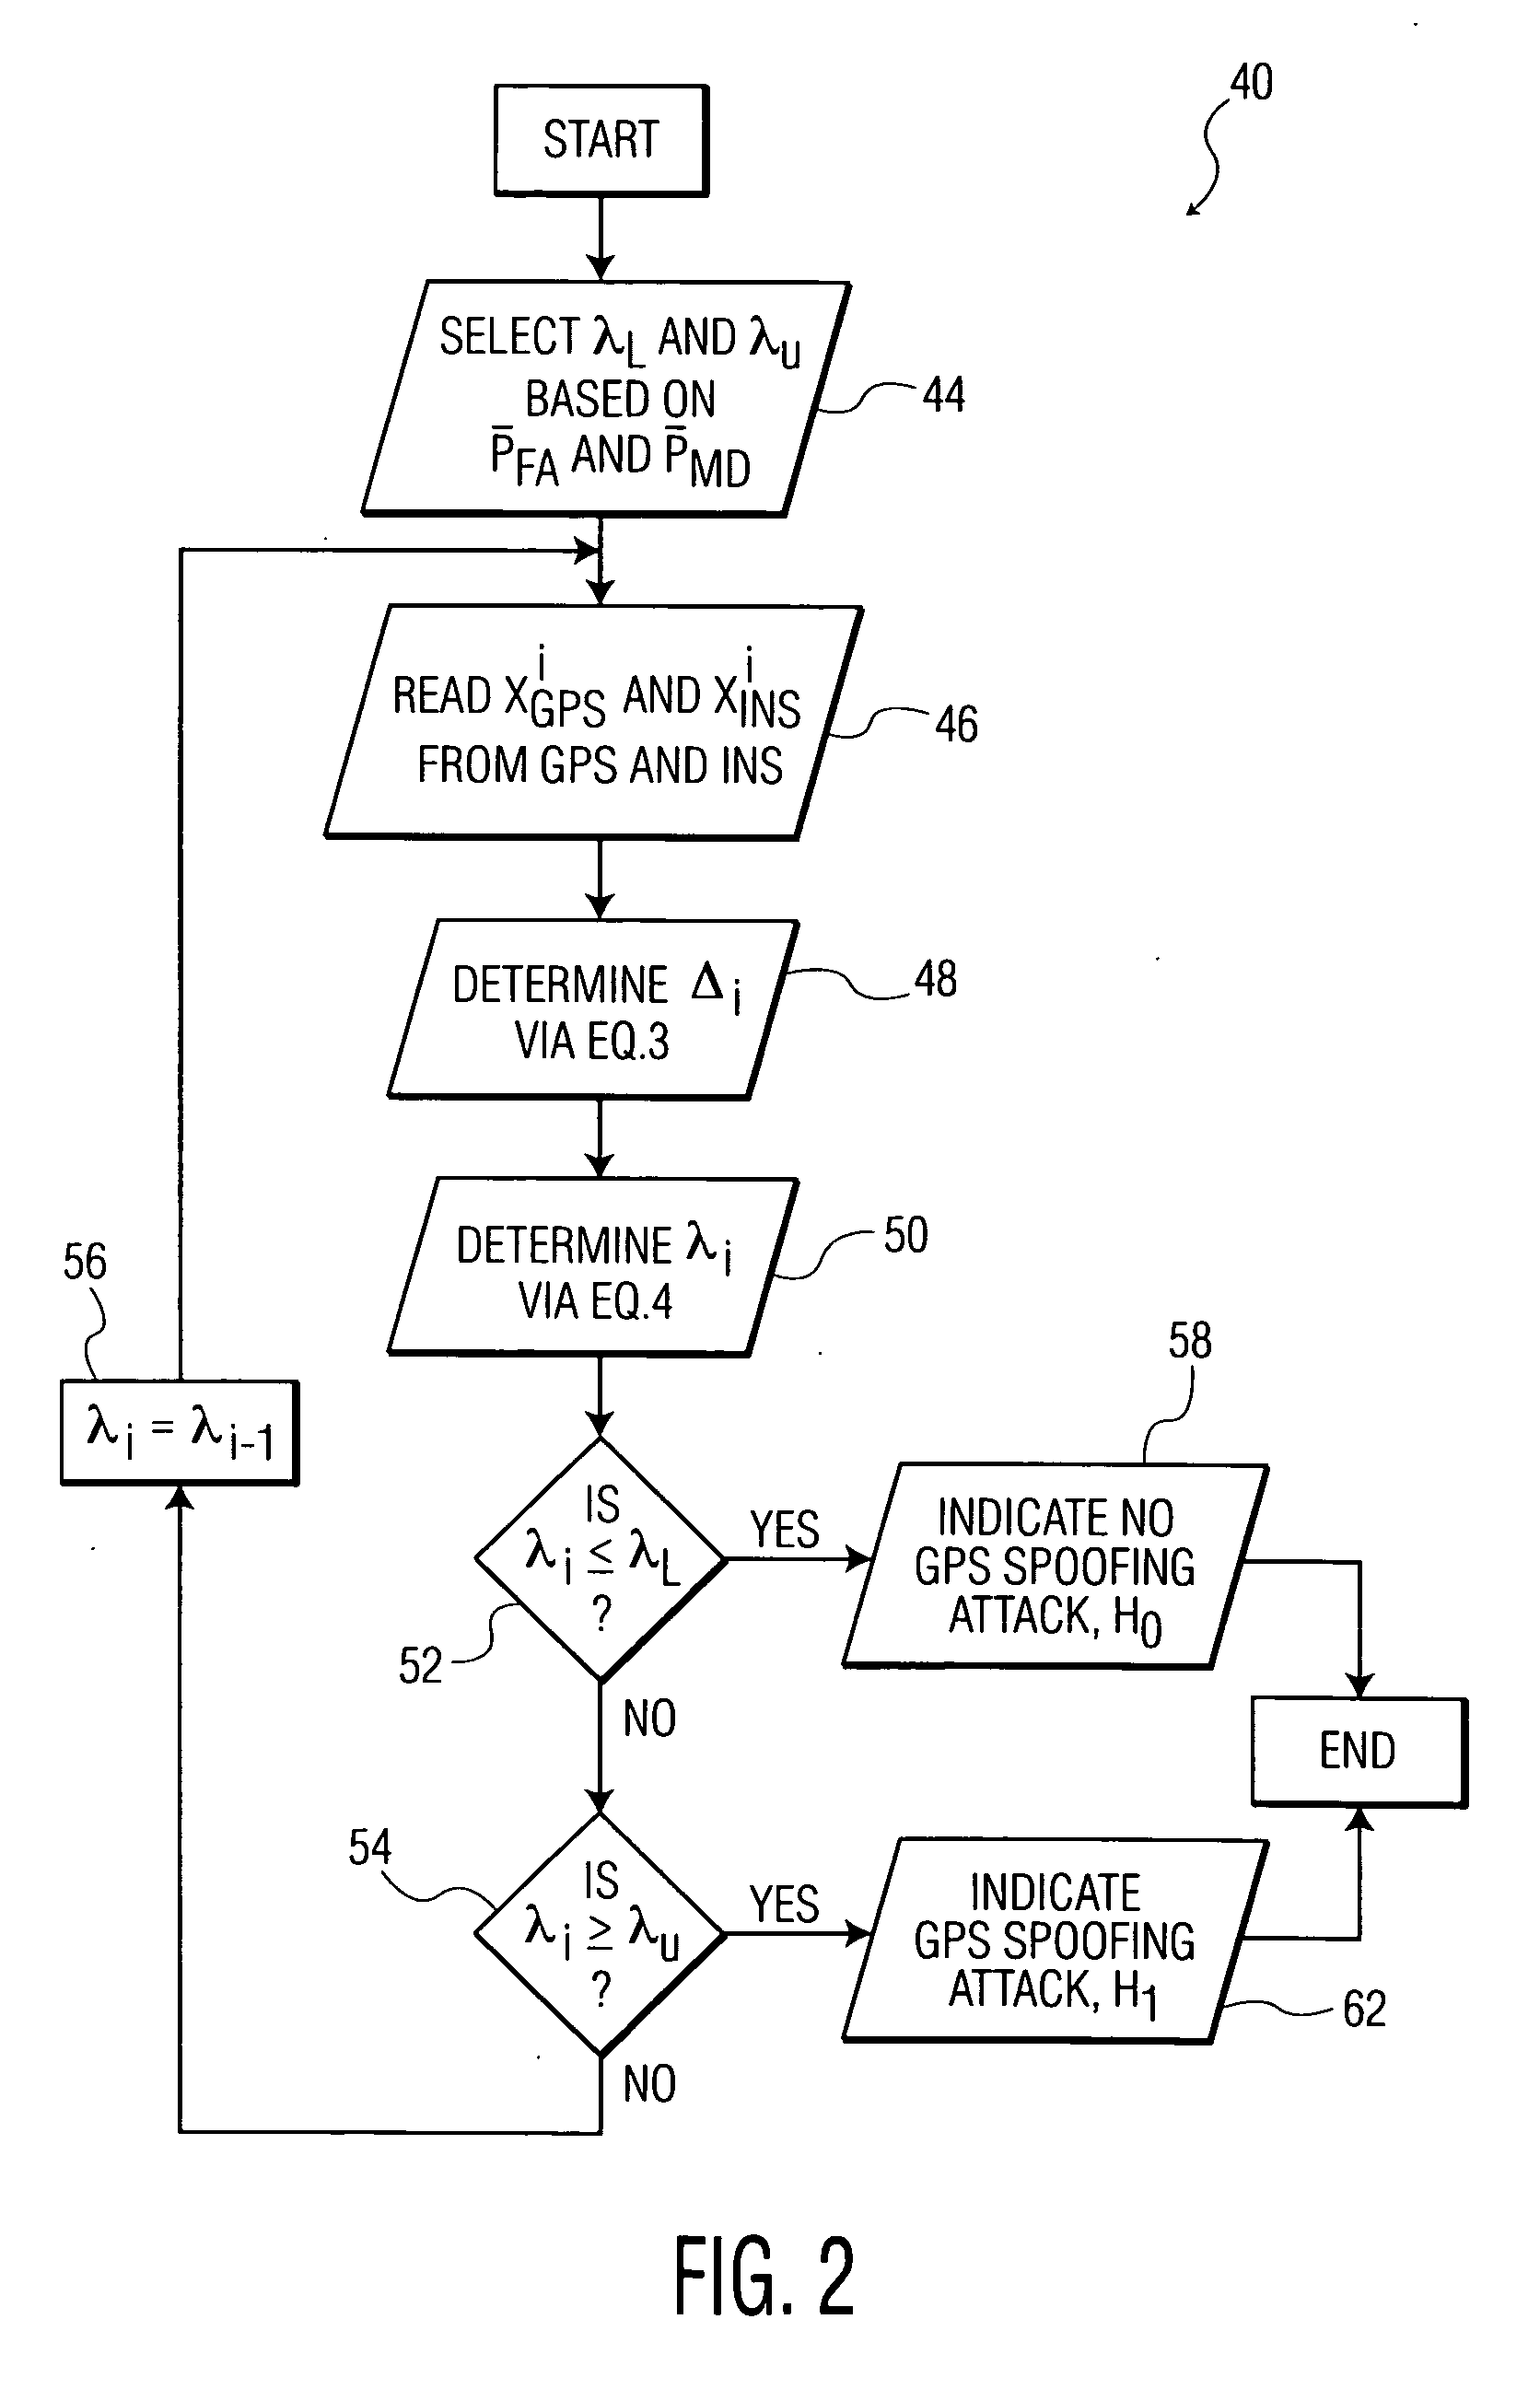
Methods and systems for detecting GPS spoofing attacks
ActiveUS20130002477A1Improve accuracyImprove efficiencySatellite radio beaconingGround truthNavigational system
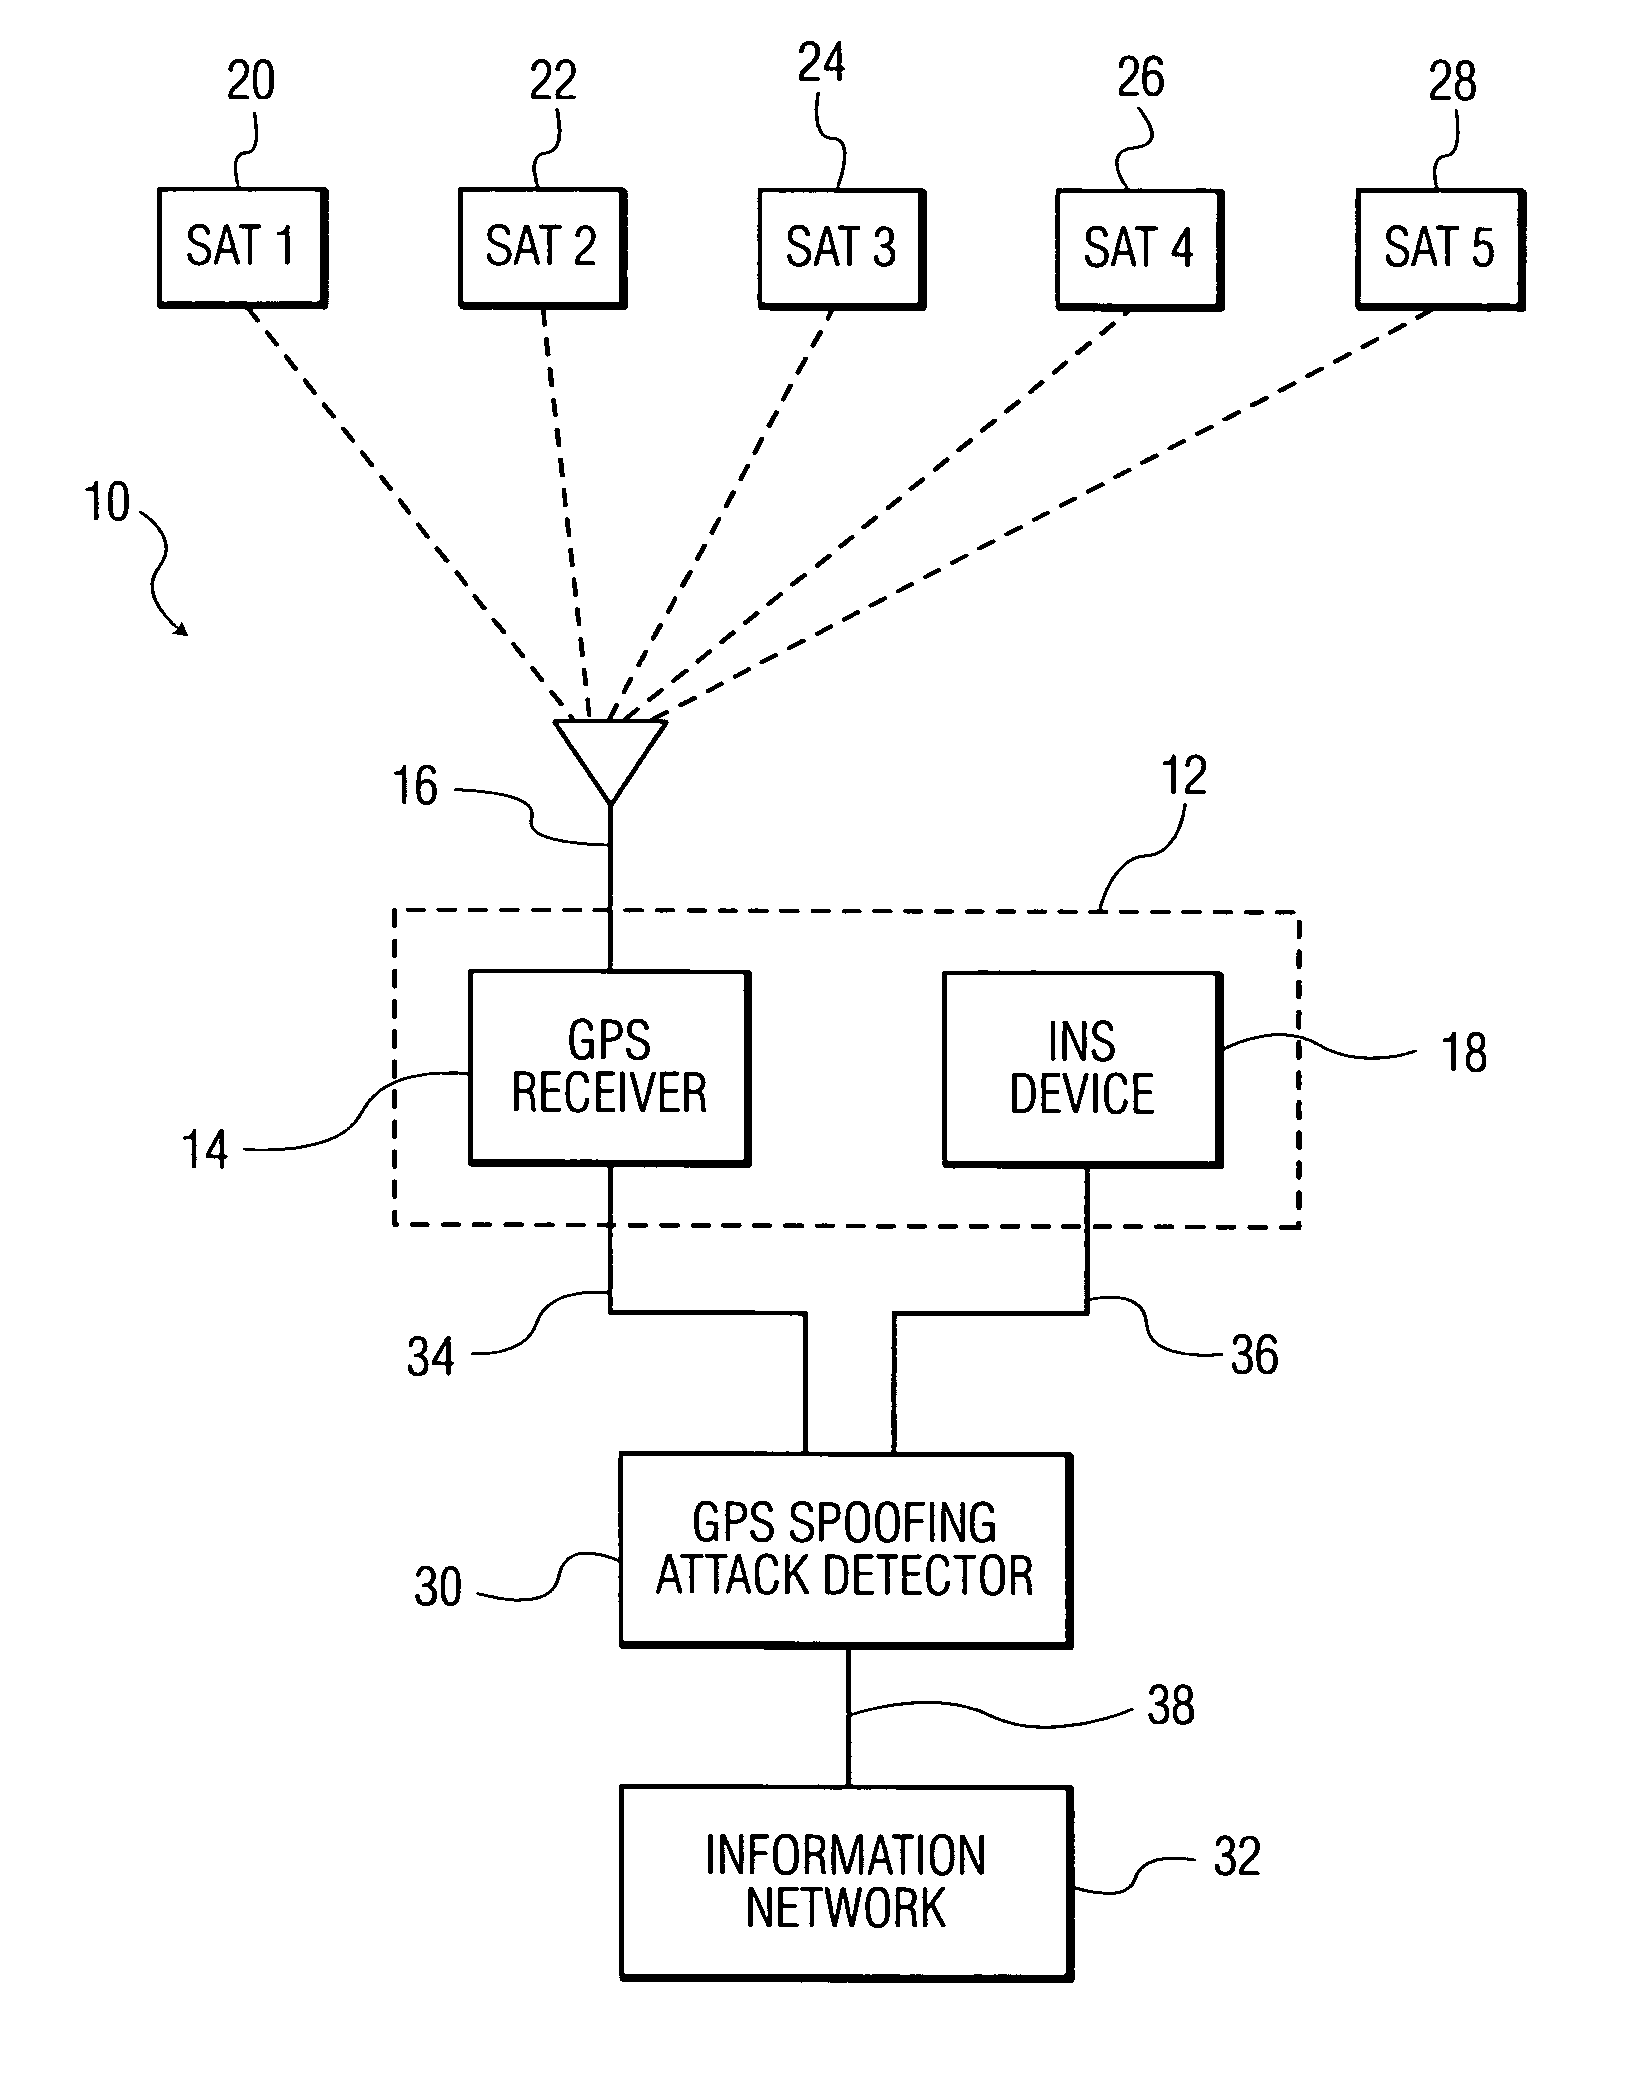
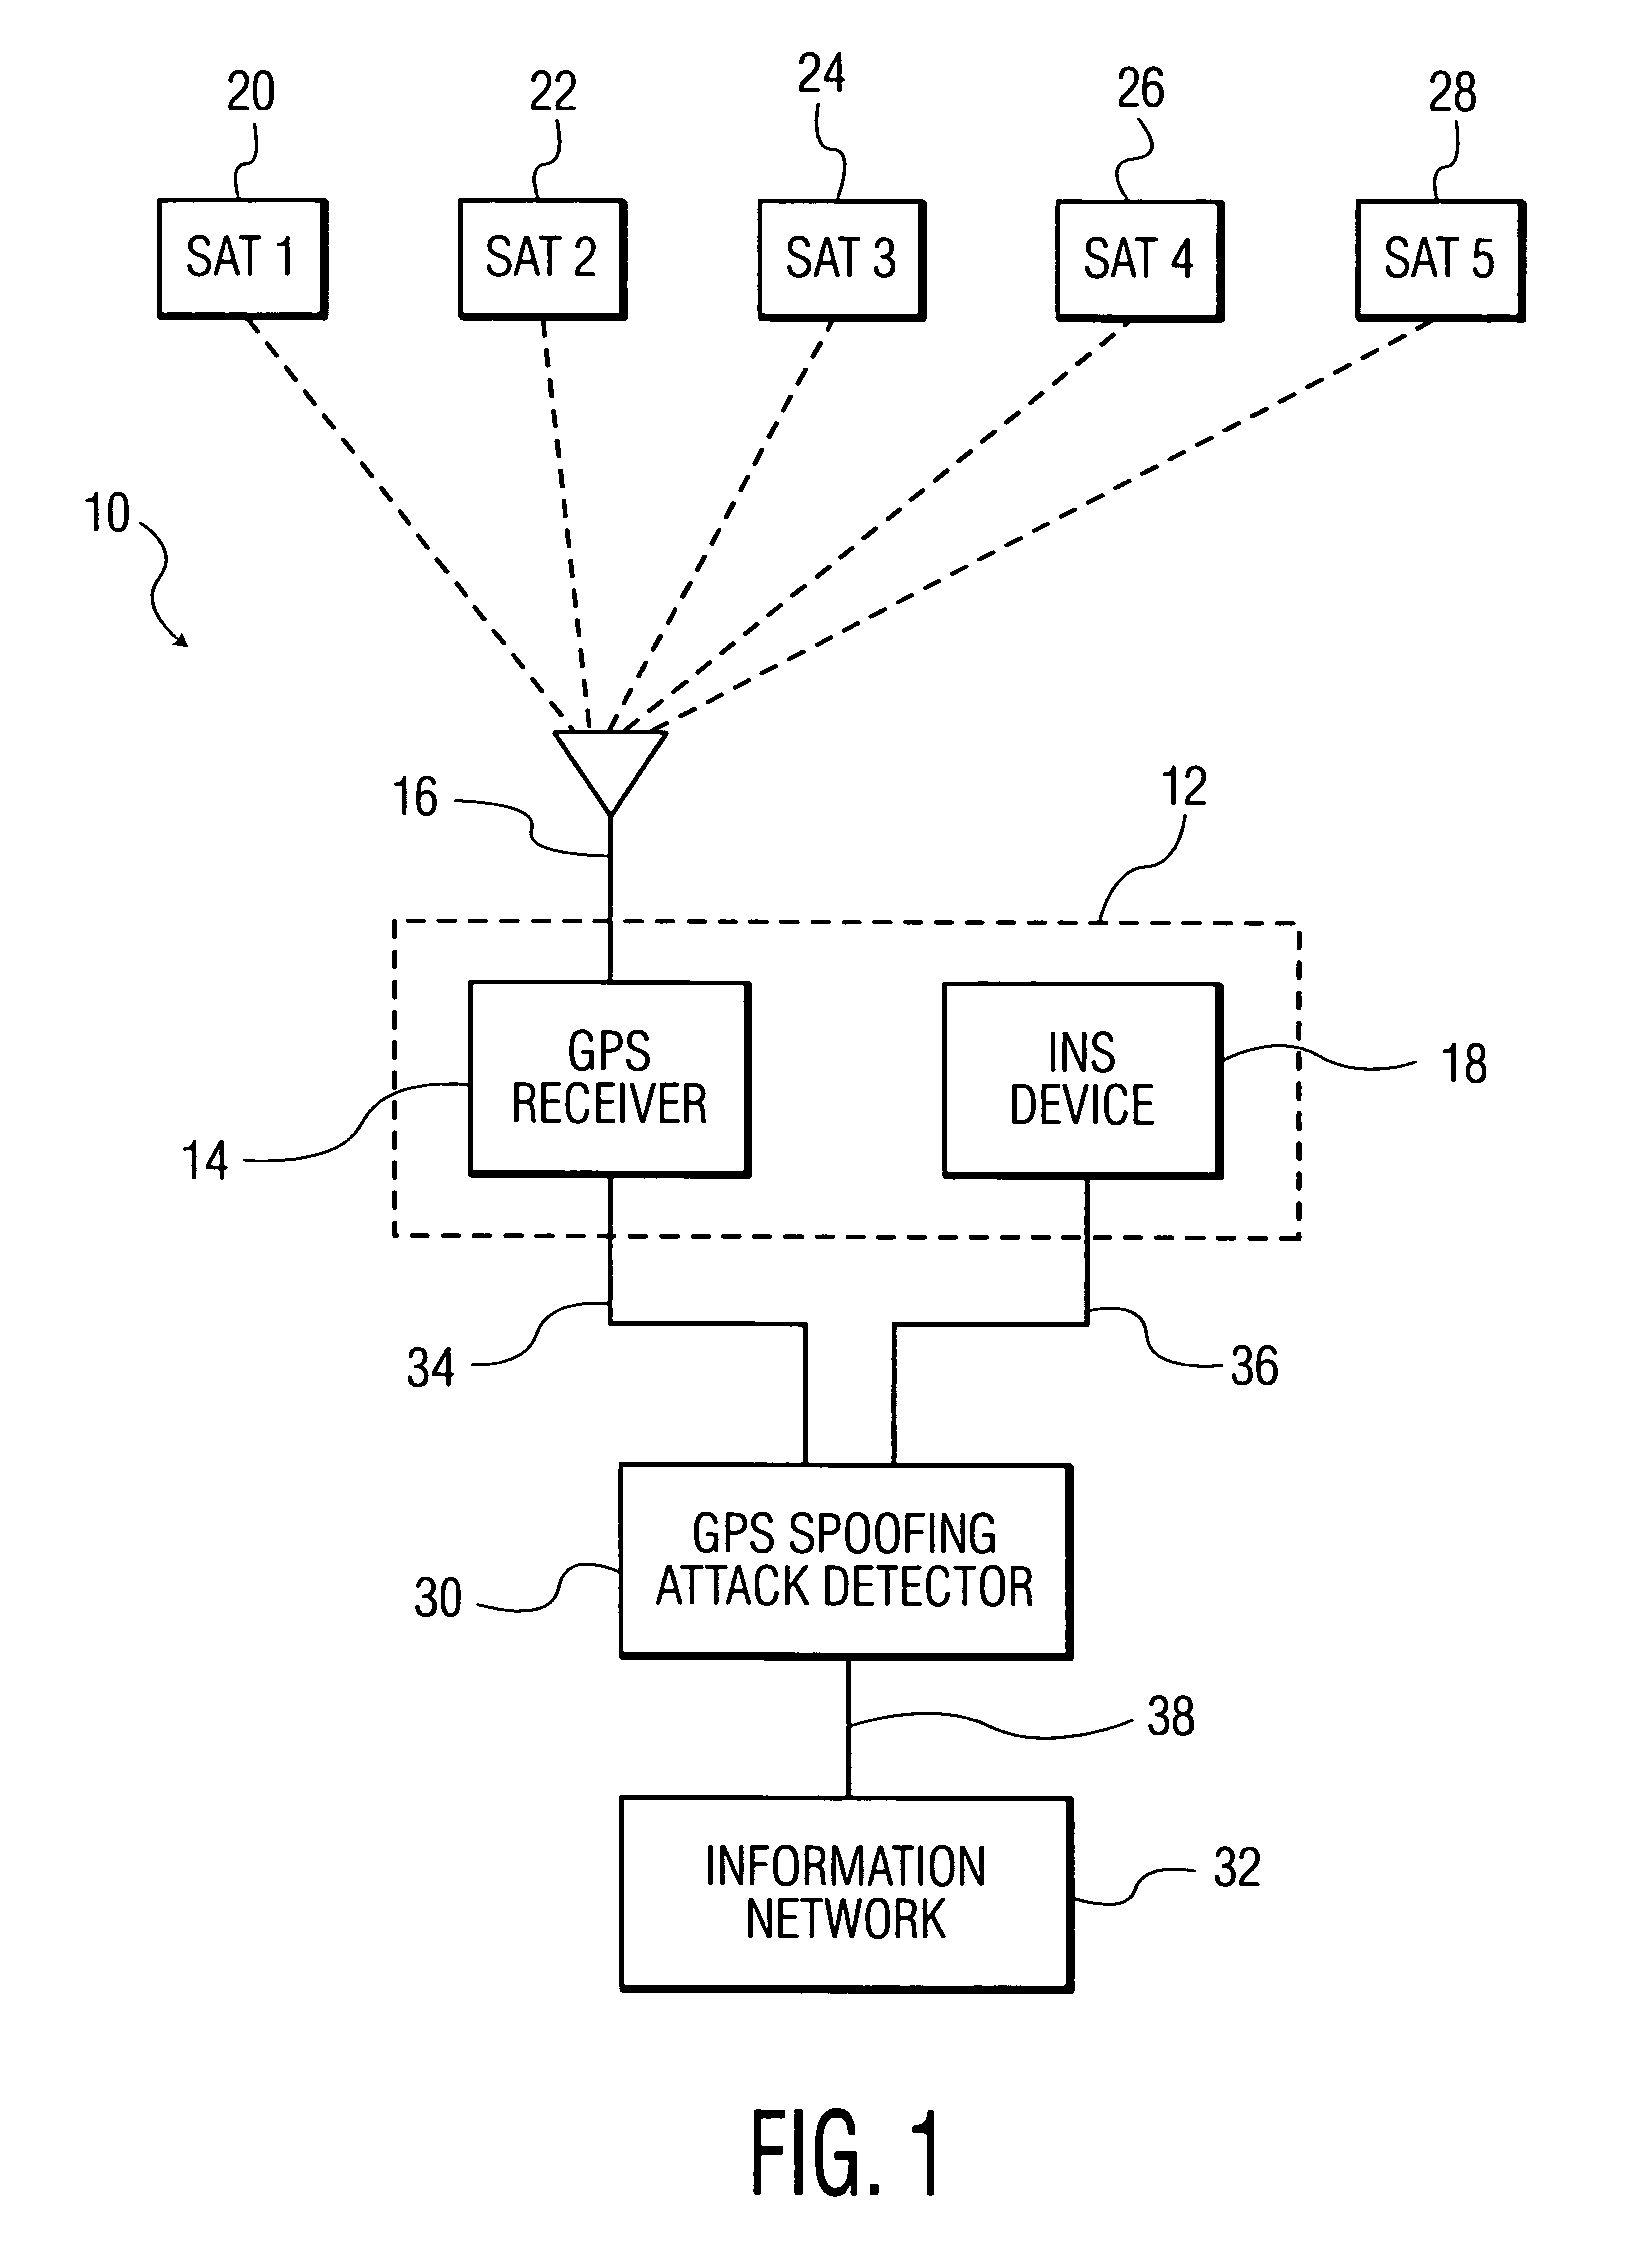
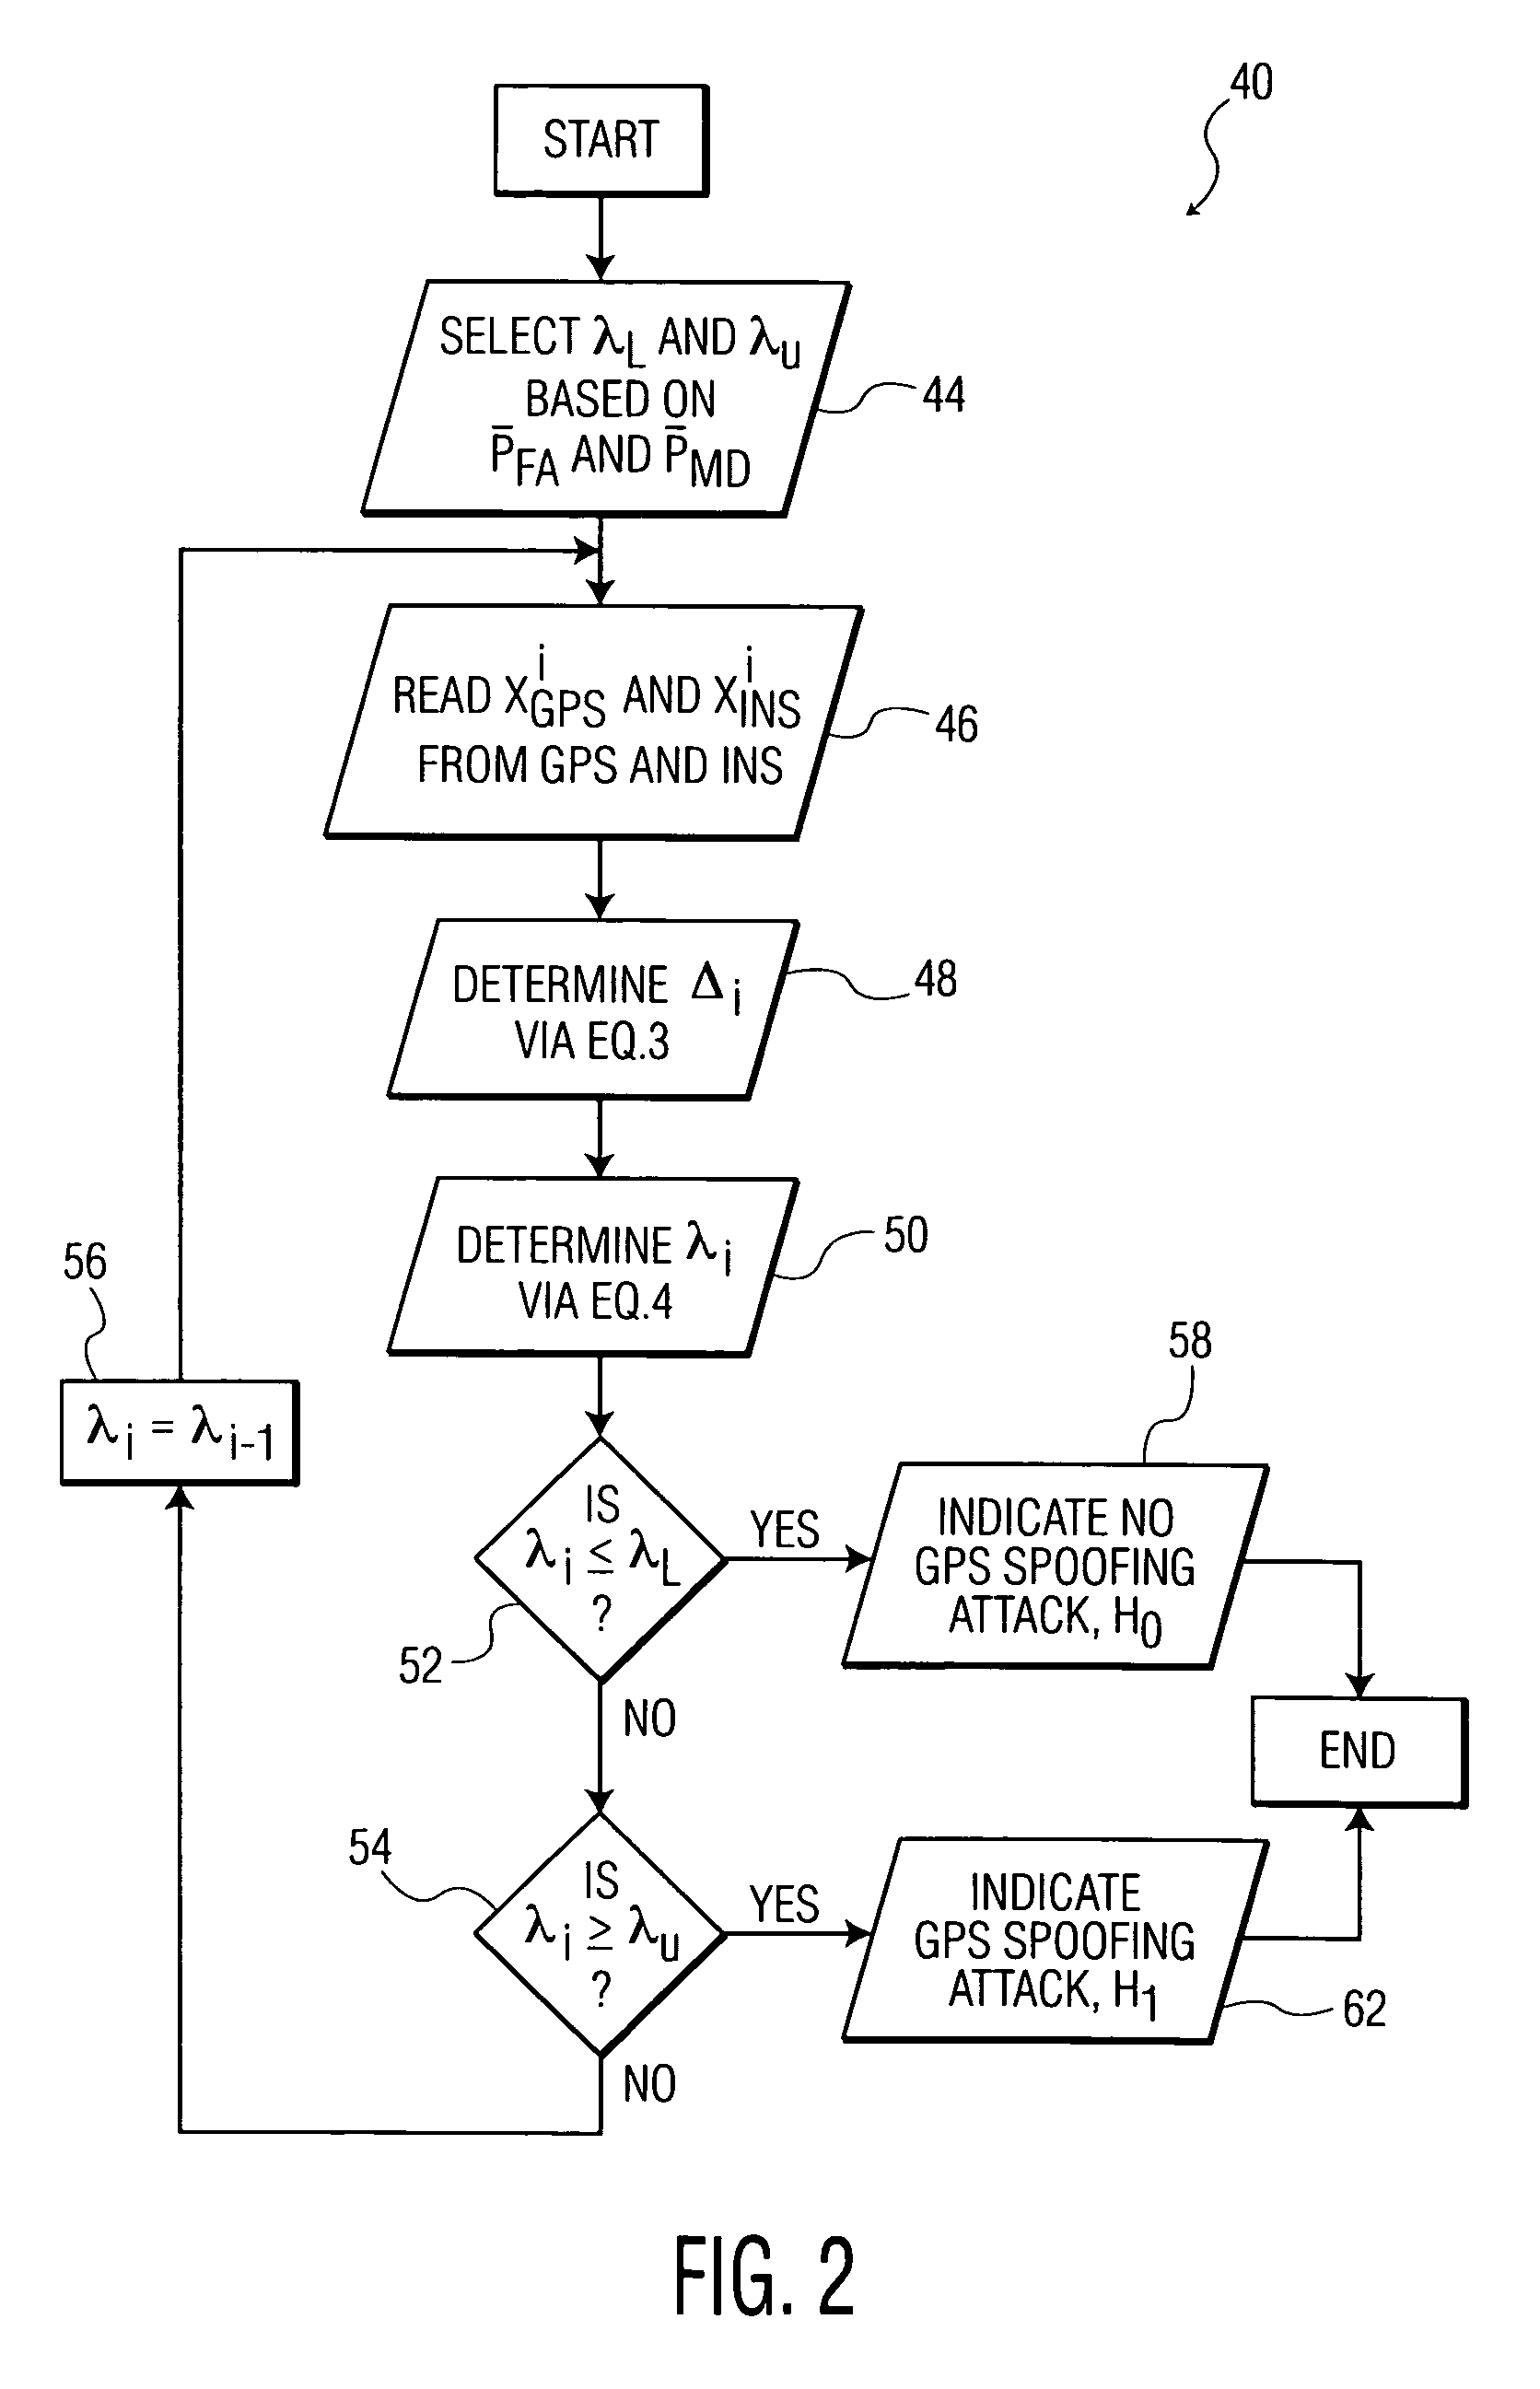
A system and method for detecting global positioning system (GPS) spoofing attacks includes collecting GPS readings along with inertial navigational system (INS) readings as a ground truth, and sequentially testing the GPS readings and INS readings through the use of a sequential probability ratio testing (SPRT) process.
Owner:BAE SYST INFORMATION & ELECTRONICS SYST INTERGRATION INC
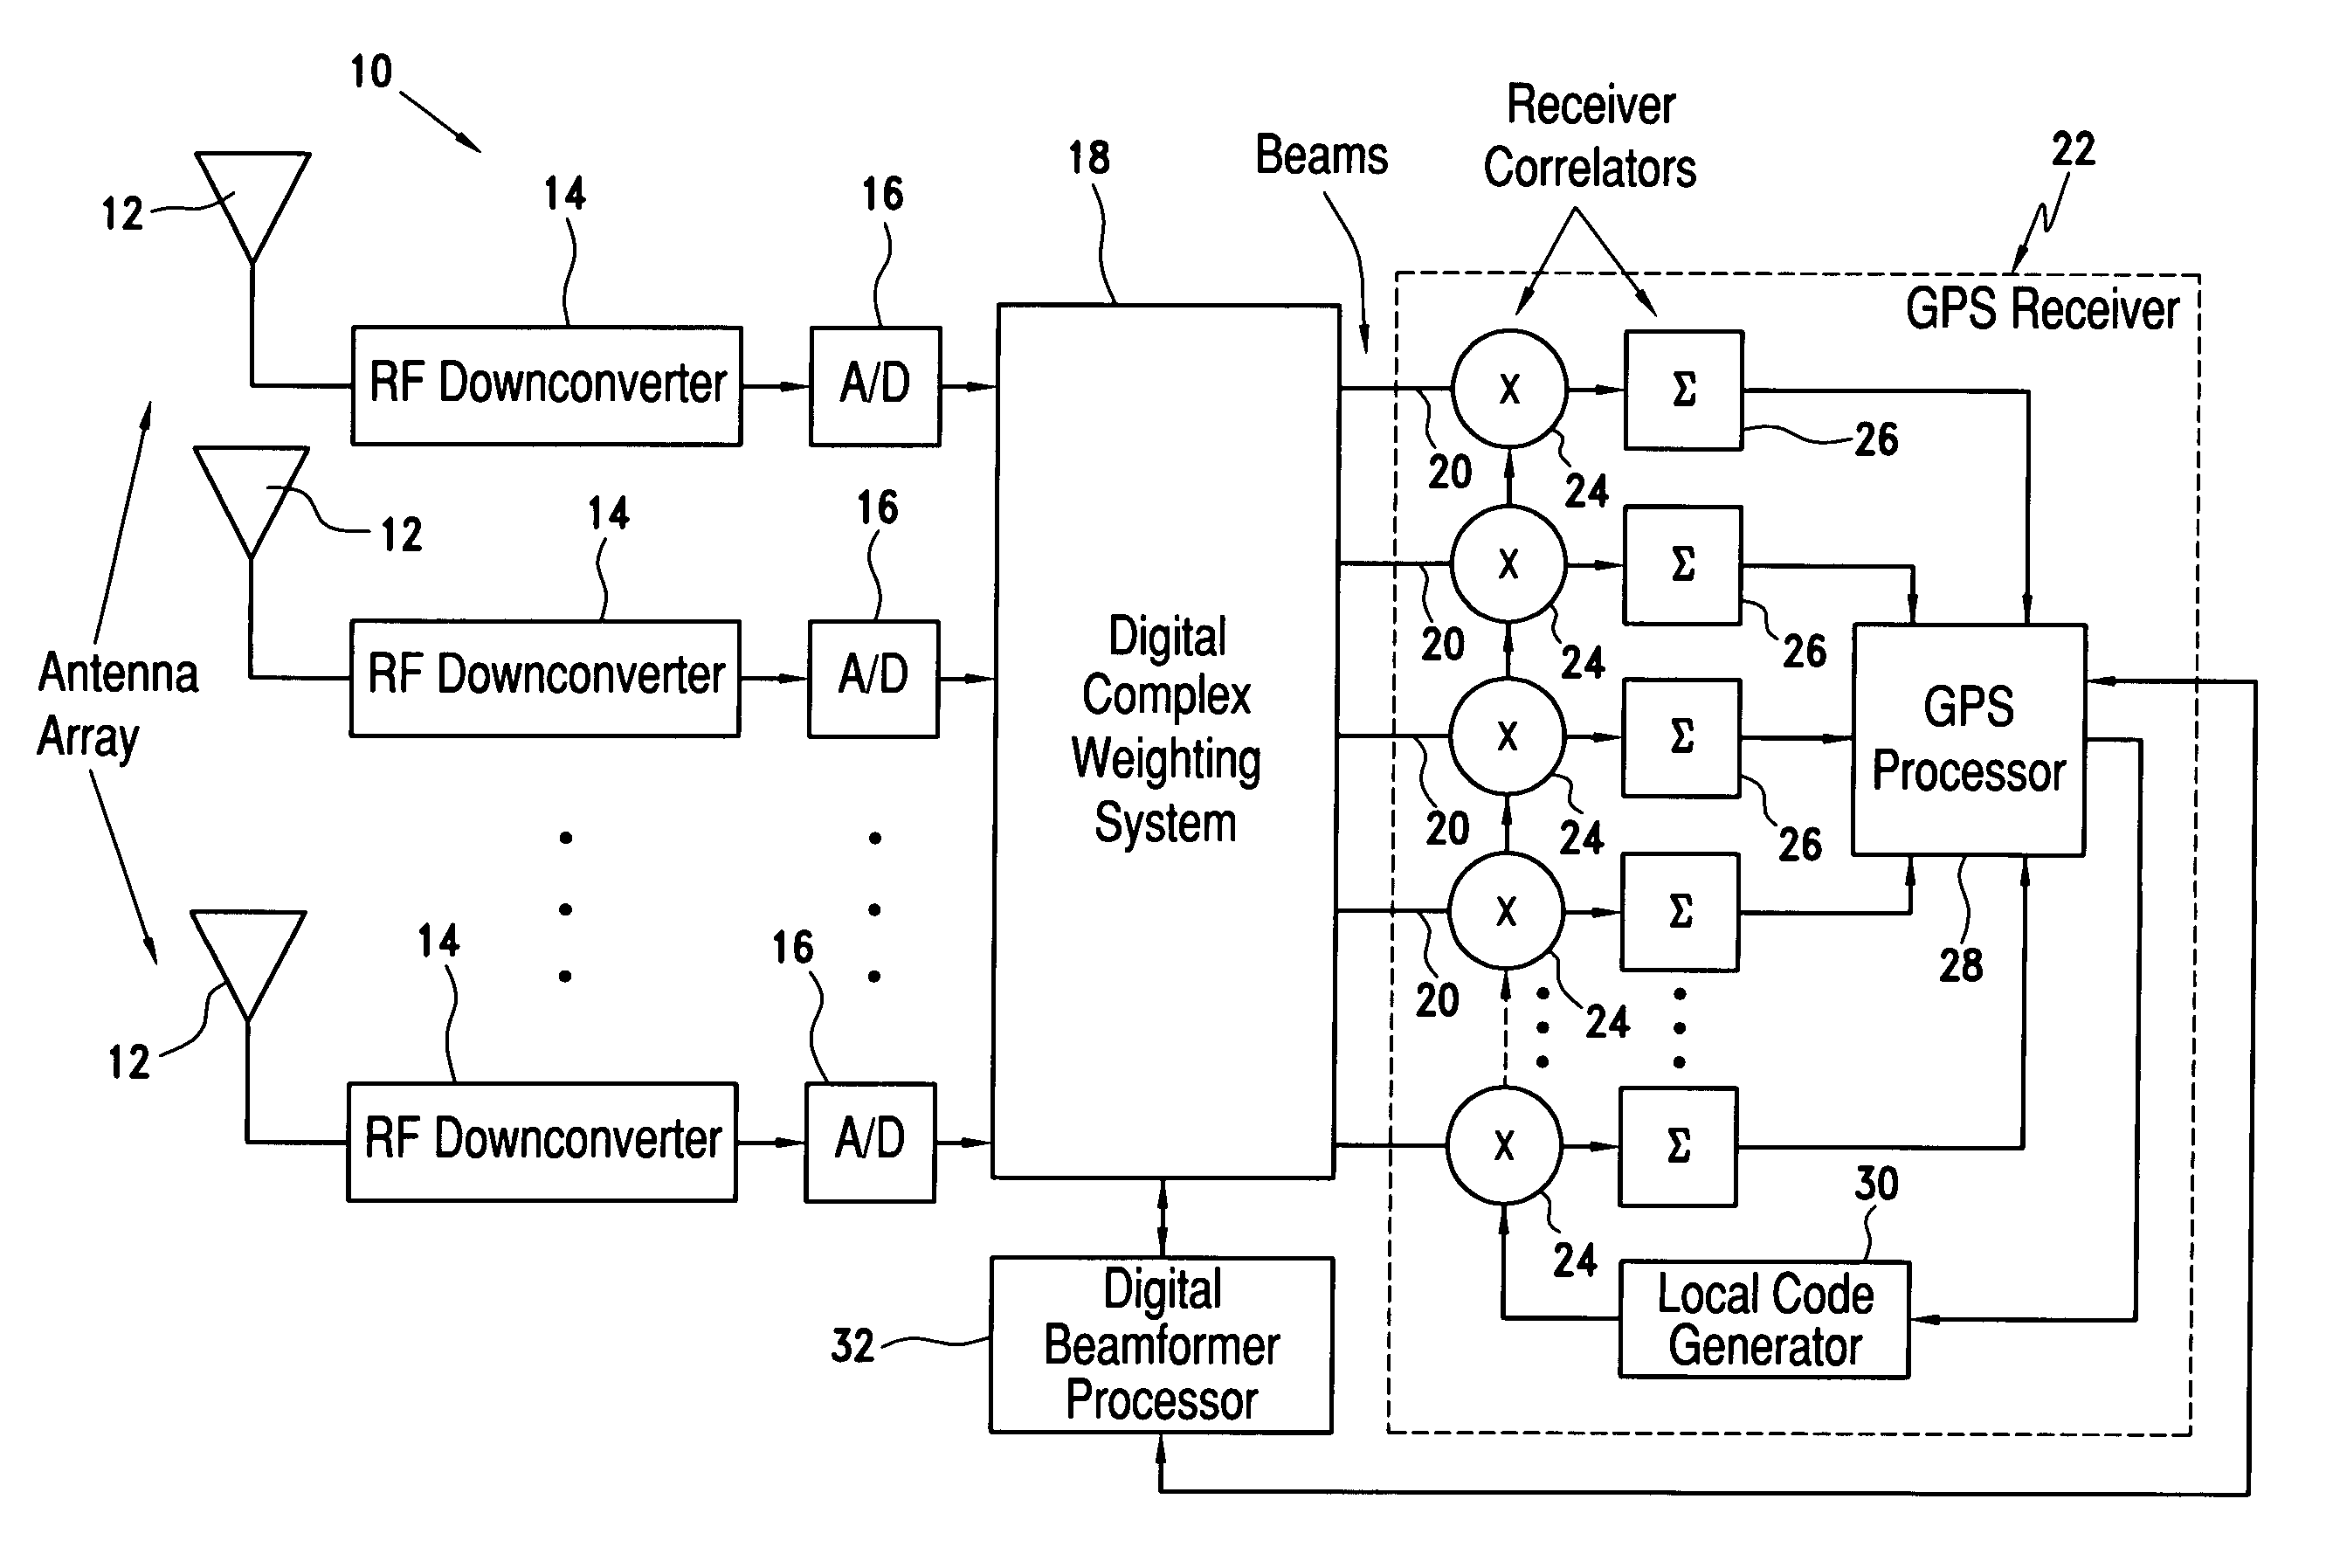
GPS spoofer and repeater mitigation system using digital spatial nulling
ActiveUS7250903B1Mitigate repeater threatMitigate GPS spoofer and repeater threatsPosition fixationRadio transmissionSignal-to-noise ratio (imaging)Gps receiver
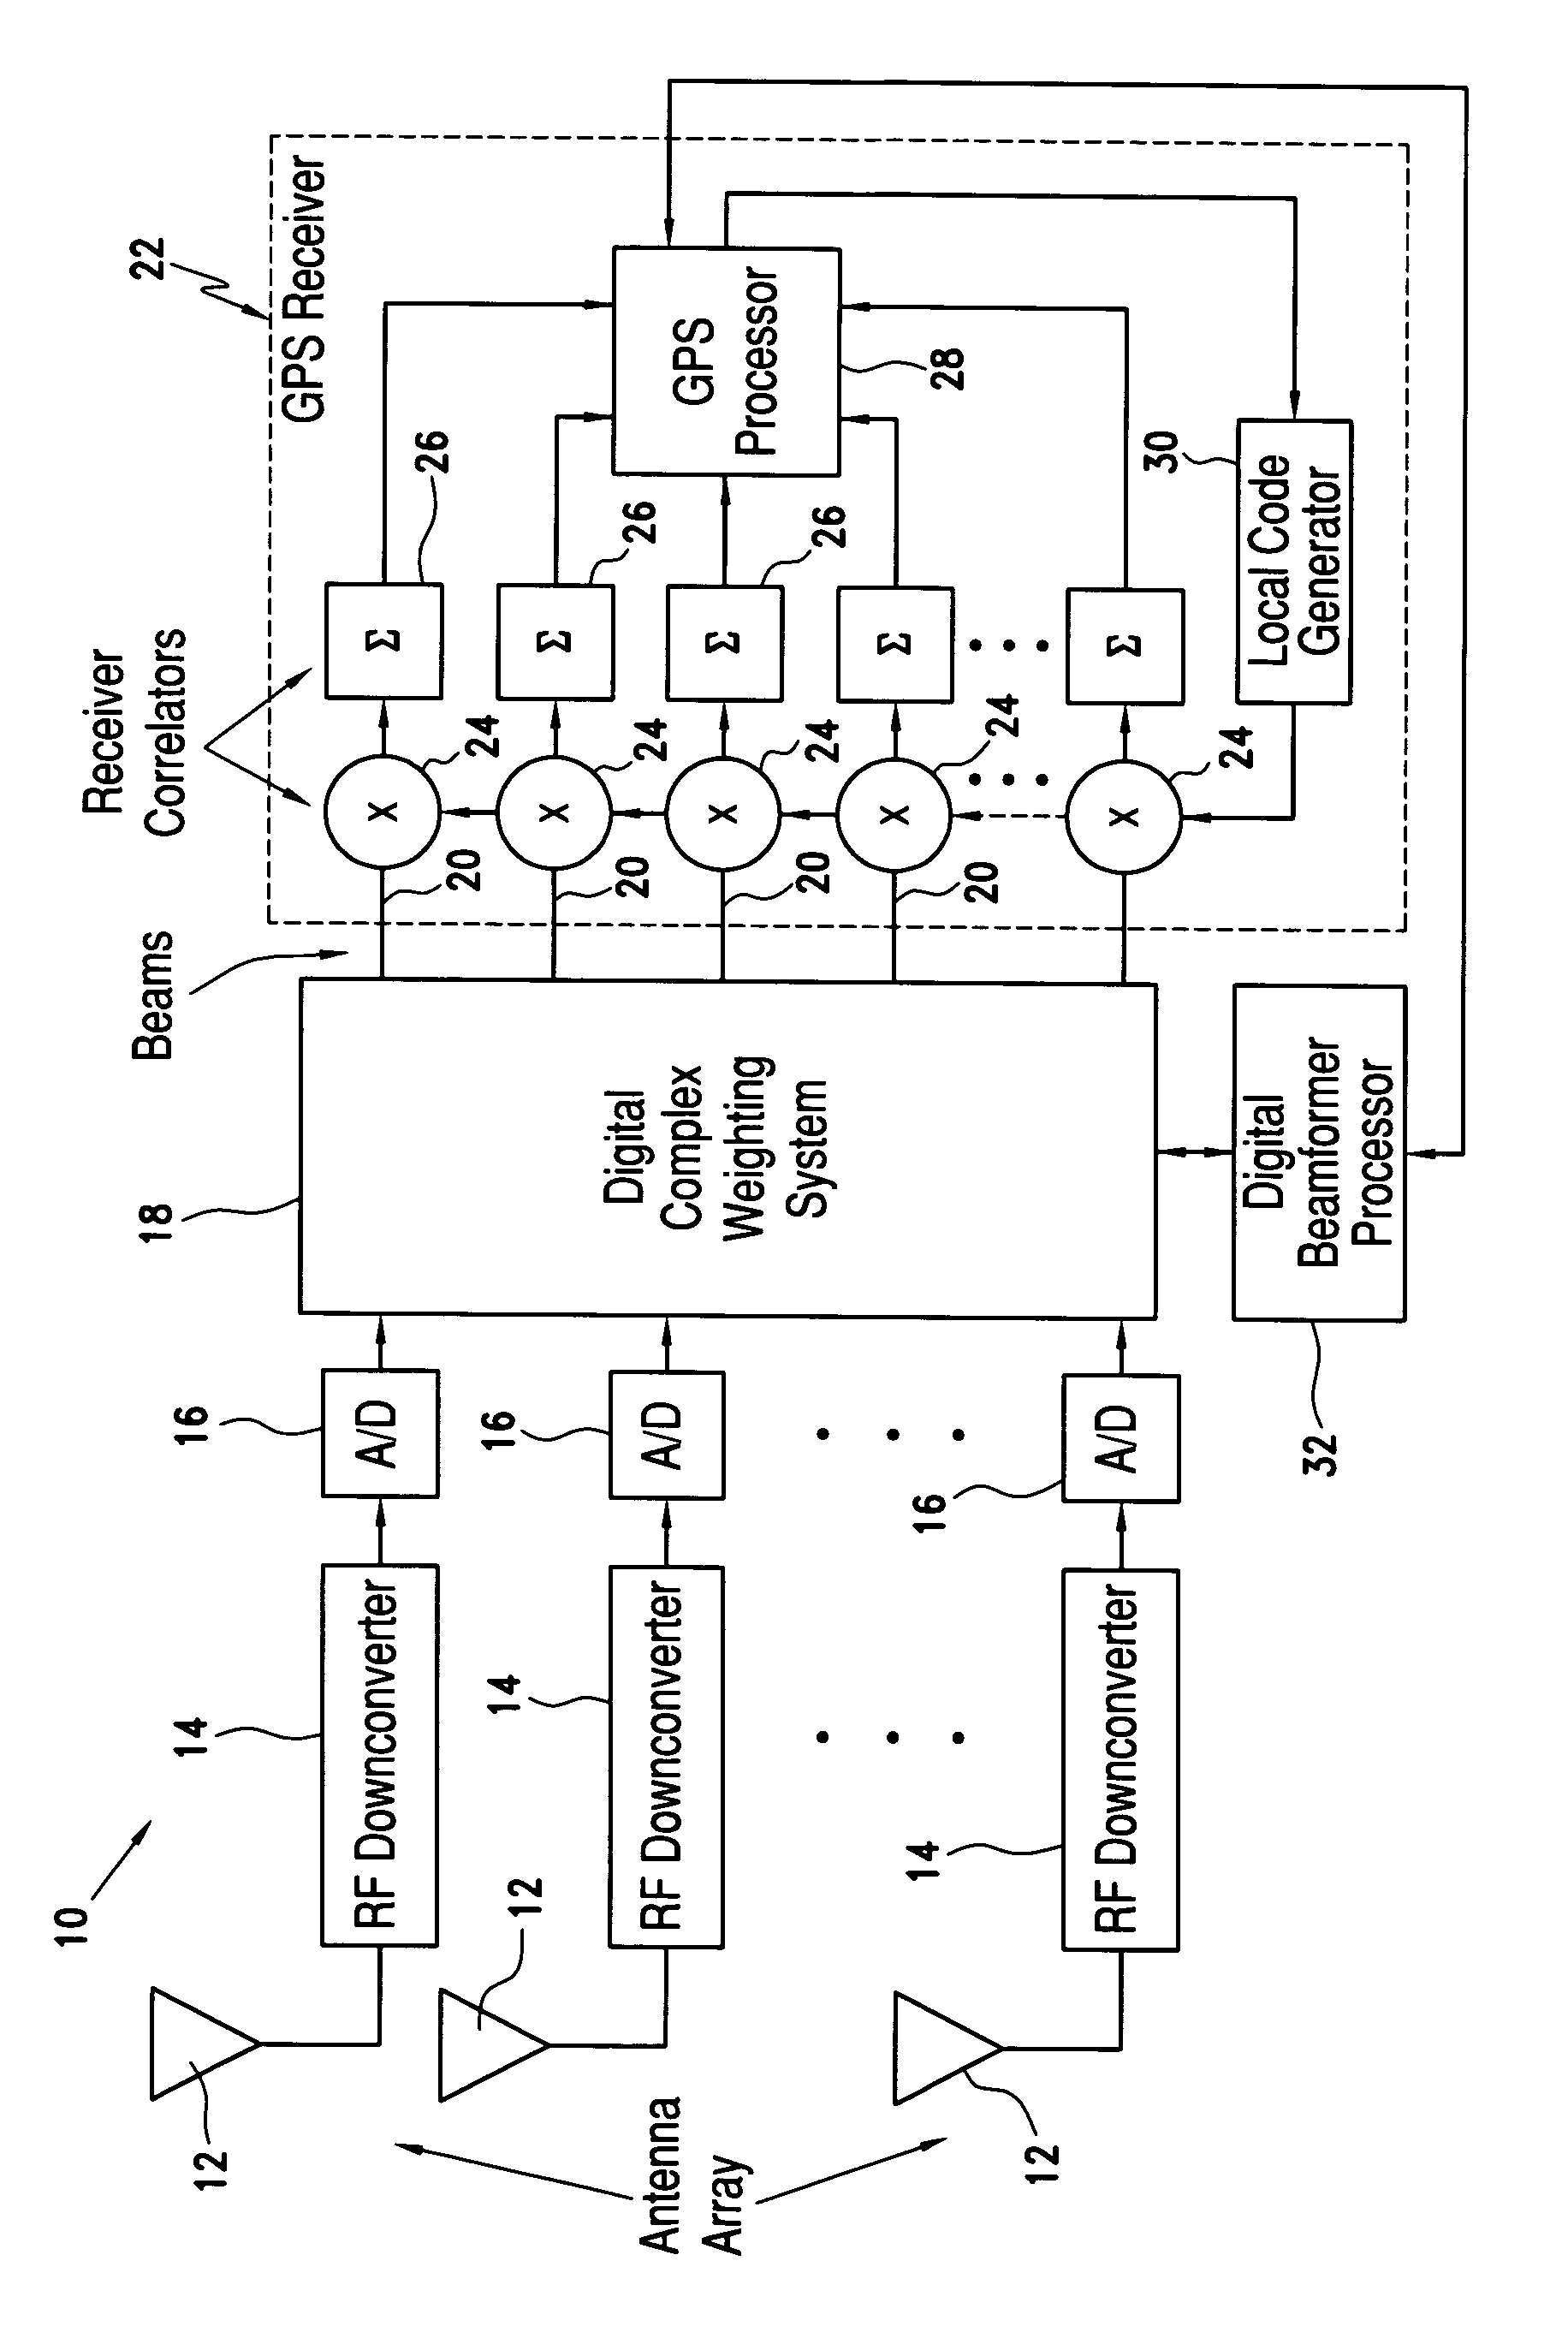
A system and method using a multi-element digital beamformer for detection and mitigation of spoofer and repeater threats to GPS that would not be addressed by baseline signal-to-noise (SNR) maximization algorithms is disclosed. GPS correlators and processing are applied to multiple beam outputs to detect and locate spoofer and repeater threats. In the beamformer processing, detected threats can be spatially nulled, even in the presence of traditional high power jamming, by modifying the normal sample covariance matrix to introduce synthetic nulls. A digital complex weighting system multiples each input channel by a complex (gain / phase) weight and adds the weighted channels together to form beams that the GPS receiver can use to reacquire the satellites in use without knowledge of platform attitude or the antenna manifold.
Owner:ROCKWELL COLLINS INC
Methods and systems for detecting GPS spoofing attacks
ActiveUS8922427B2Improve efficiencyDetect identifyNavigation by speed/acceleration measurementsSatellite radio beaconingGround truthNavigation system
A system and method for detecting global positioning system (GPS) spoofing attacks includes collecting GPS readings along with inertial navigational system (INS) readings as a ground truth, and sequentially testing the GPS readings and INS readings through the use of a sequential probability ratio testing (SPRT) process.
Owner:BAE SYST INFORMATION & ELECTRONICS SYST INTEGRATION INC
Global position system (GPS) deception jamming method and system
ActiveCN102866406AReduce transmit powerImprove concealmentSatellite radio beaconingTransducerGps receiver
The invention discloses a global position system (GPS) deception jamming method and a GPS deception jamming system. The GPS deception jamming system comprises a GPS signal digital generating module and a radio frequency emitting part. A GPS deception jamming signal generating part is mainly composed of a field programmable gata array(FPGA) digital platform and used for generating a digital GPS jamming signal. The radio frequency emitting part includes a plurality of transducers, wherein the traducers are used for changing the digital GPS jamming signal to a nominal frequency of the GPS satellite signal and a plurality of frequencies up and down the nominal frequency of the GPS satellite signal, and emitting the radio frequency signal through an antenna; possibility of receiving signals by the GPS receiver is largely increased, the deception jamming can be realized for the GPS receiver with certain airspace. Compared with the traditional GPS jamming system, the emitting power of the jamming system is much smaller, and own safety can be guaranteed. Furthermore, the goal GPS receiver is positioned to a wrong position, and thus, the GPS losses a fighting effect.
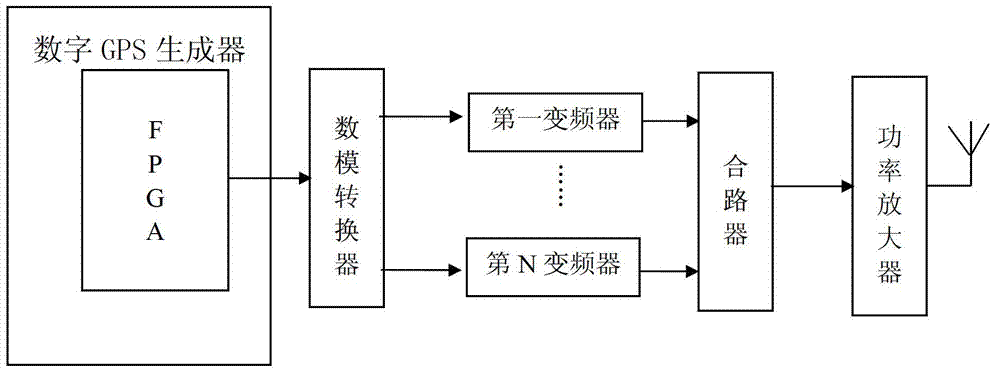
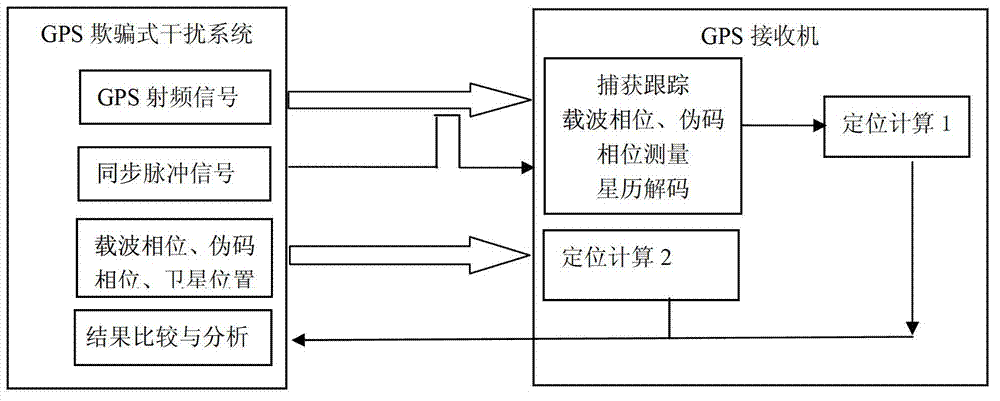
Owner:GUILIN UNIV OF ELECTRONIC TECH
Unmanned aerial vehicle anti-GPS spoofing system and method based on multisource information fusion
InactiveCN109358344AImprove accuracyAccurate detectionSatellite radio beaconingSystem usageGps spoofing
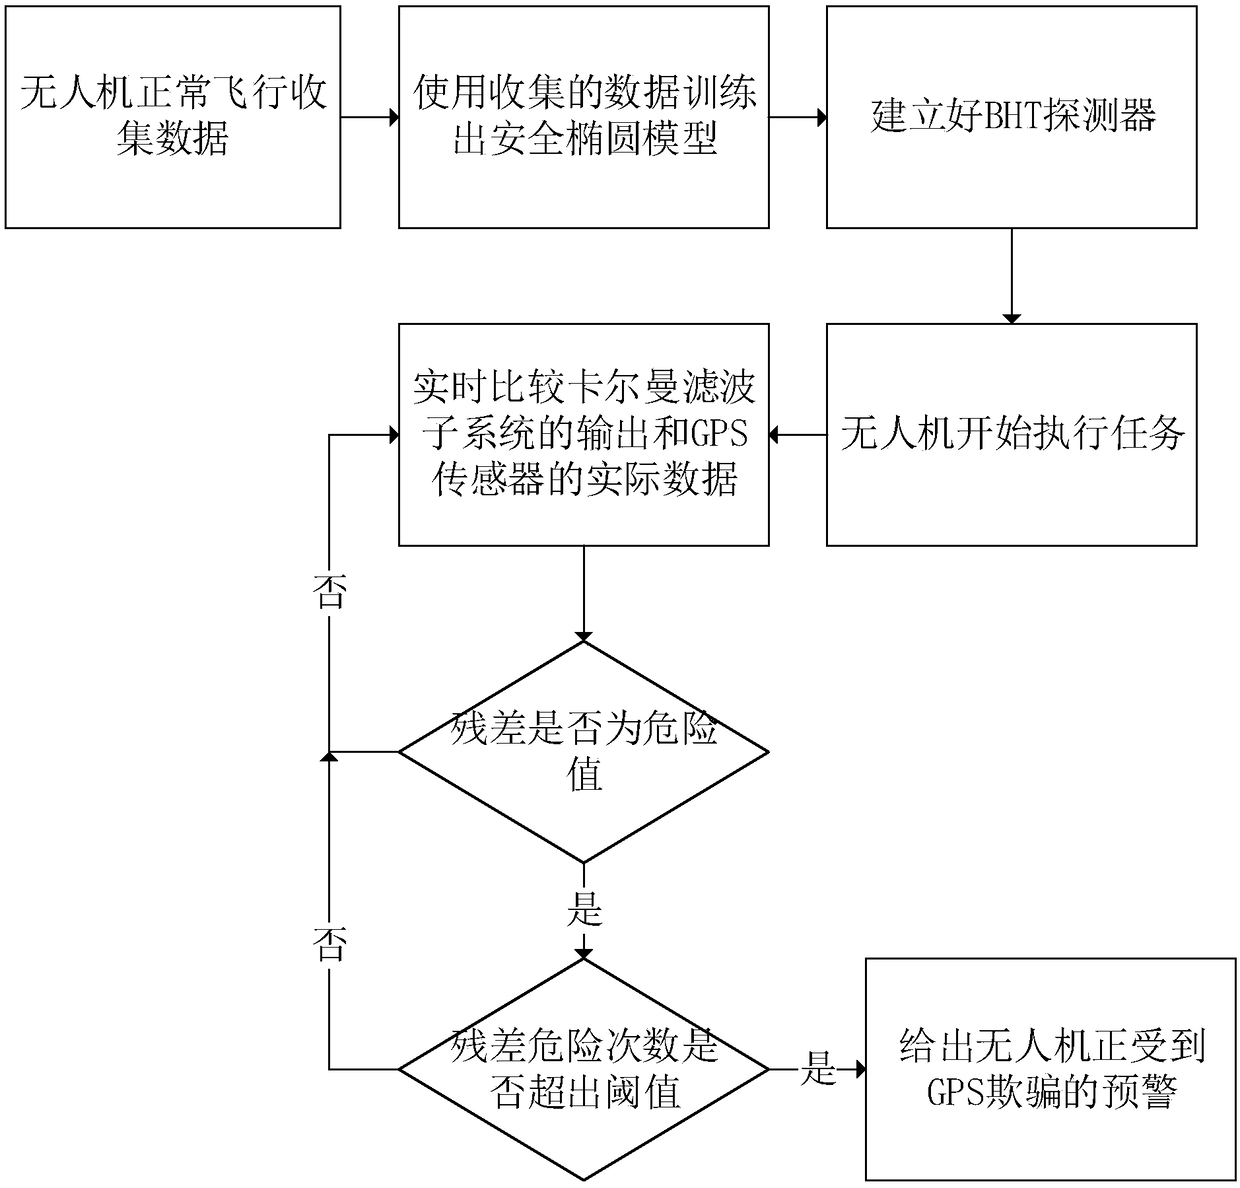
The invention discloses an unmanned aerial vehicle anti-GPS spoofing system and a method based on multisource information fusion. The method comprises the following steps of: the sensor subsystem collecting the data in real time and sending the data to a Kalman filtering subsystem and a GPS spoofing attack detection subsystem; the Kalman filtering subsystem carries out the filtering processing onthe data received by the sensor by using an extended Kalman filtering method, calculating a prediction value of the state of the unmanned aerial vehicle at the kth moment of the unmanned aerial vehicle, and obtaining a prediction value of the GPS sensor signal, then sending the prediction value to a spoofing detection subsystem; the GPS spoofing attack detection subsystem comparing the received GPS signal prediction value with the actual value received by the GPS sensor, calculating the residual error between the two, and recognizing whether the residual error is abnormal or not by using a BHTalgorithm, realizing the real-time detection of the GPS spoofing attack of the unmanned aerial vehicle. The unmanned aerial vehicle has relative high anti-interference performance, and can effectively improve the safety of the unmanned aerial vehicle in performing tasks in the complex airspace when the unmanned aerial vehicle is in an interfering more complicated environment.
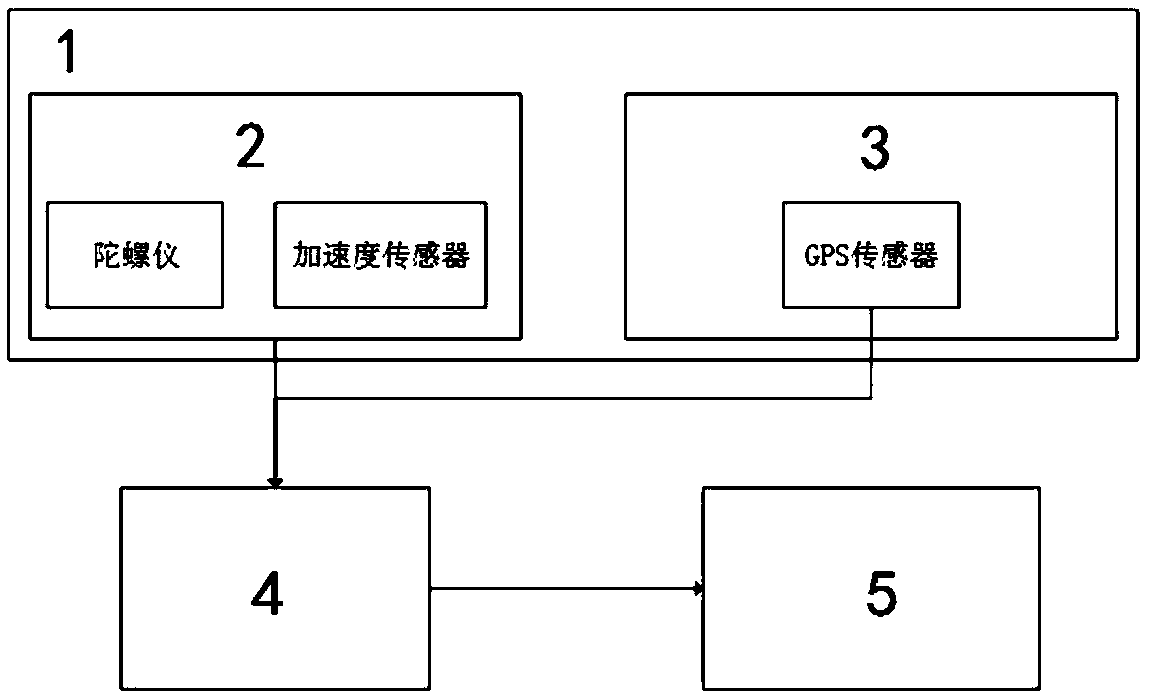
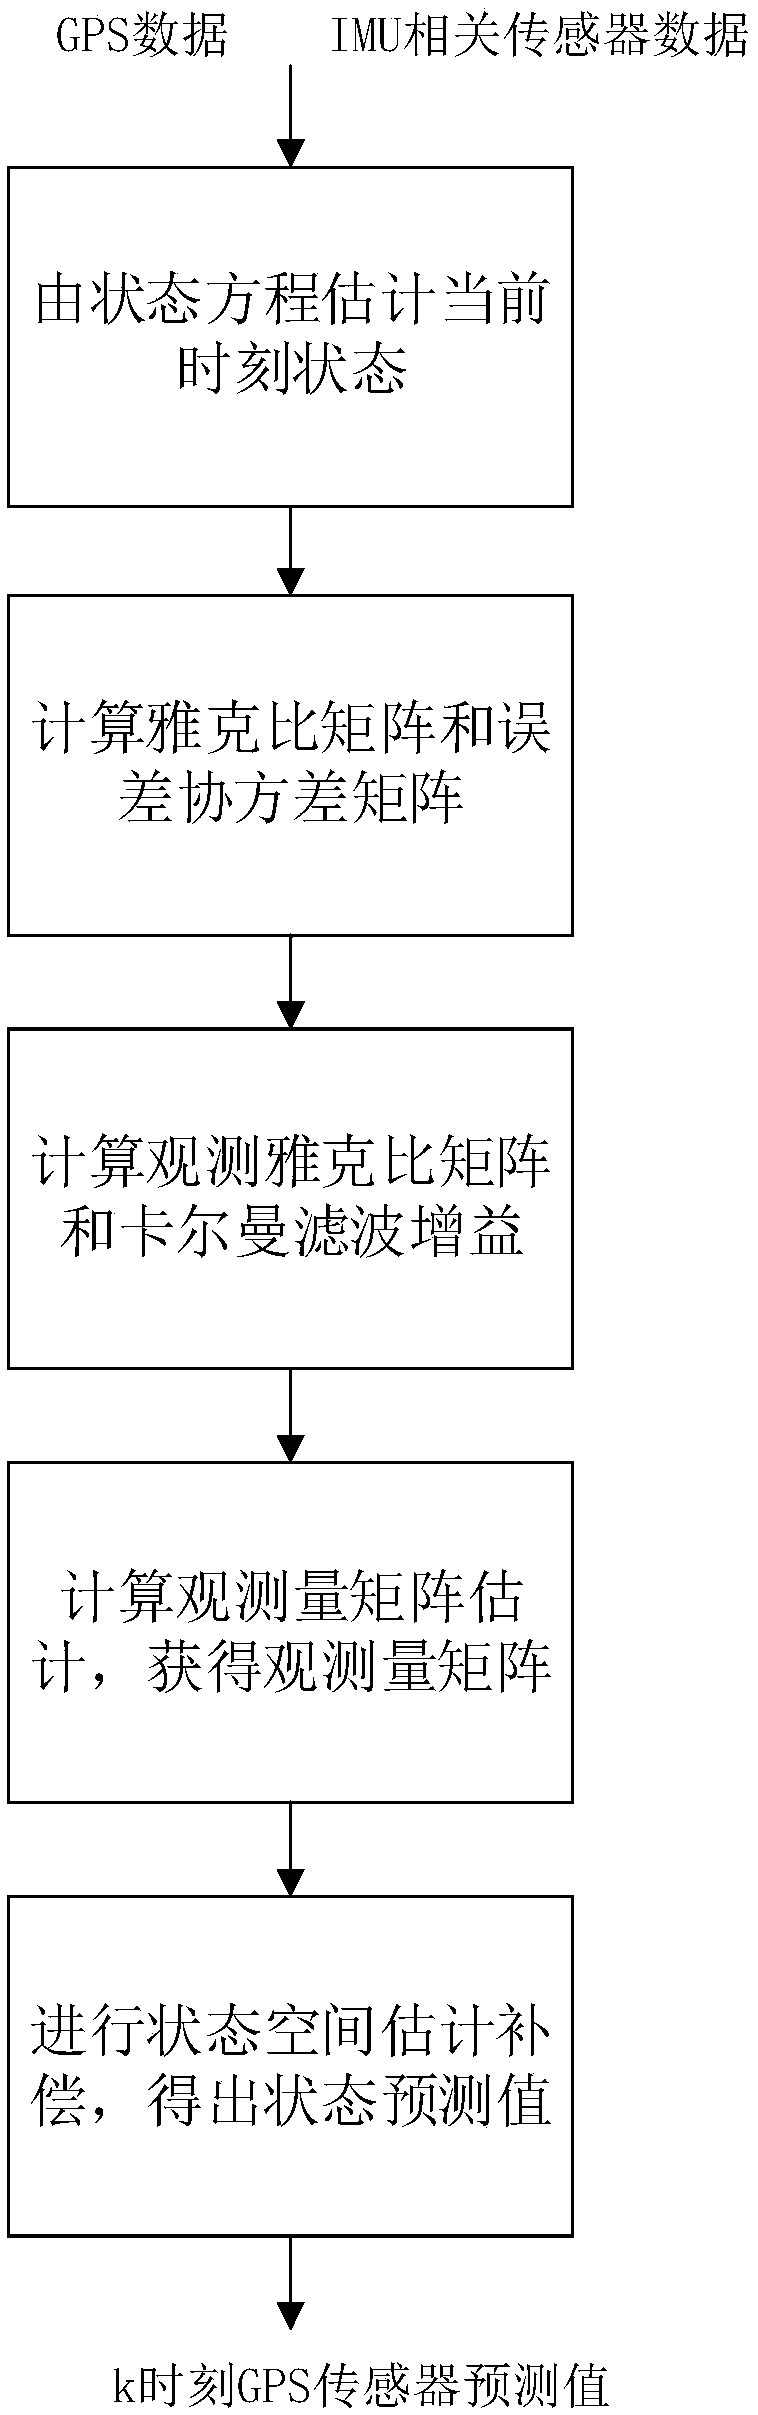
Owner:XIDIAN UNIV +1
Unmanned aerial vehicle interference deception system and unmanned aerial vehicle defense system
PendingCN110719136AHighly integratedEasy to useCommunication jammingSatellite radio beaconingUncrewed vehicleEmbedded system
The invention discloses an unmanned aerial vehicle interference deception system and an unmanned aerial vehicle defense system. The unmanned aerial vehicle interference deception system specifically comprises an unmanned aerial vehicle interference deception system body, a photoelectric tracking device, a radio interference device, a GPS deception all-in-one machine and an unmanned aerial vehicledefense system. The invention further provides an unmanned aerial vehicle GPS spoofing trapping method and an unmanned aerial vehicle pilot positioning method which are provided based on the unmannedaerial vehicle defense system.


Owner:ANHUI SUN CREATE ELECTRONICS
Autonomous navigation unmanned aerial vehicle GPS deception detection and defense method
The invention discloses an autonomous navigation unmanned aerial vehicle GPS (global positioning system) deception detection and defense method, belongs to the technical field of autonomous navigationunmanned aerial vehicle positioning safety, and particularly relates to a GPS deception attack detection and defense technology. GPS deception detection is mainly divided into two parts, namely a signal-to-noise ratio technology and a kalman filtering technology are adopted, an inertia navigation technology is adopted in GPS deception attack defense, simulation experiments show that the method supports detection and defense of GPS generation type attacks and forwarding attacks, can provide accurate positioning information for an autonomous navigation unmanned aerial vehicle, and can make flying safer.


Owner:BEIJING UNIV OF TECH
GPS deception detection method for electric patrol unmanned aerial vehicle
The present invention discloses a GPS deception detection method for an electric patrol unmanned aerial vehicle. The method comprises a step 1, a GPS module of the unmanned aerial vehicle obtains the signal intensity of a currently observed GPS satellite; a step 2, a distance between each GPS satellite and the unmanned aerial vehicle is calculated; a step 3, the observation angle of the present each GPS satellite relative to the horizontal plane wherein the unmanned aerial vehicle is located is calculated; a step 4, if the observation angle value is less than 0, there is a GPS attack in a preset area, and a GPS alarm is emitted, otherwise, according to the elevation mask angle, satellite signals that are not easily blocked are selected; a step 5, the maximum signal strength of the GPS signal is calculated according to the distance and position relation between each GPS satellite and the unmanned aerial vehicle; and a step 6, when the signal strength of the current GPS satellite is detected to exceed the maximum signal strength of the GPS satellite, a GPS attack exists in the preset area. The method can quickly detect GPS deception with low power consumption and low cost.

Owner:STATE GRID CORP OF CHINA +4
Multi-UAV anti-GPS-spoofing method in intelligent cooperative environment
ActiveCN107976690AEasy to operatePracticalSatellite radio beaconingPosition/course control in three dimensionsTriangulationUncrewed vehicle
The invention discloses a multi-UAV anti-GPS-spoofing method in an intelligent cooperative environment. The method comprises steps of: firstly, recording the GPS signal information of each UAV in a UAV fleet and exchanging information among the UAVs; causing the airborne cooperative control algorithm of each UAV to predict the position of the UAV at the next moment through the fleet GPS information; updating the GPS information by the predicted position and the next moment and determining whether the UAV has potential GPS spoofing; if it is determined that GPS spoofing may be encountered, performing triangulation by using infrared positioning to determine the exact position of the UAV and correcting the GPS signal, otherwise, repeating the above steps until the end of the flight. The method can ignore specific GPS spoofing details and directly detect whether GPS spoofing has occurred based on the cooperative control mechanism, can handle the situations where multiple UAVs simultaneously suffer GPS spoofing. is easy to operate and practical.


Owner:XIDIAN UNIV
Low, slow and small target navigation spoofing device and method
The invention discloses a low, slow and small target navigation spoofing device and method. The low, slow and small target navigation spoofing device and method solve the problem of potential safety hazards of low, slow and small target interception of an existing device and method. The device comprises a detection module, a GPS receiver, a navigation signal simulator and a navigation signal transmitter. The detection module is used for receiving a target echo in real time and outputting target information; the GPS receiver is used for receiving GPS signals, solving the output GPS time, a realsignal navigation telegraph text, signal amplitude, and GPS receiver location; the navigation signal simulator is used for receiving the GPS time, the real signal navigation telegraph text, the signal amplitude, and outputting a GPS spoofing signal with combination of trajectory requirements of the spoofing process; and the navigation signal transmitter is used for adjusting the power of the GPSspoofing signal according to the position of the GPS receiver to radiate into space. The method is used for generating the GPS spoofing signal by the device. The device and method achieves spoofing signal generation of a low, slow and small target with anti-interference measures.


Owner:BEIJING INST OF RADIO METROLOGY & MEASUREMENT
Unmanned aerial vehicle network system security posture awareness assessment method capable of preventing GPS deception
ActiveCN108259223AHierarchicalComprehensive Security Situation Quantitative AssessmentData switching networksAircraft traffic controlUncrewed vehicleNetwork security policy
The invention discloses an unmanned aerial vehicle network system security posture awareness assessment method capable of preventing GPS deception. The technical scheme of the method comprises the steps of firstly assessing security posture of a single task process on a single unmanned aerial vehicle, setting weights for different task processes, introducing an auxiliary control console to verifycredibility of a GPS signal of each unmanned aerial vehicle in an unmanned aerial vehicle group, and comprehensively considering the security posture of each unmanned aerial vehicle; and at last acquiring a security posture threat index of the whole unmanned aerial vehicle group network system via the security posture thread indexes of the different unmanned aerial vehicles in combination with theweights of the different unmanned aerial vehicles. Therefore, the network security posture of the whole unmanned aerial vehicle group can be accurately expressed. According to the method provided bythe invention, the problem that the existing methods cannot effectively assess the security posture of the unmanned aerial vehicle group network system is mainly solved.


Owner:XIAN AVIATION COMPUTING TECH RES INST OF AVIATION IND CORP OF CHINA
Analysis method for global positioning system
InactiveUS20190219398A1Navigational calculation instrumentsNavigation by speed/acceleration measurementsSupport vector machineAccelerometer
The present disclosure relates to an analysis method for a global positioning system. The analysis method includes steps of operating a mobile device including an accelerometer, a magnetometer and a GPS data receiver, and using the GPS data receiver to receive GPS data, and using the accelerometer to obtain acceleration data, and using the magnetometer to obtain magnetic data; combining and converting the GPS data, the acceleration data and the magnetic data into a direction error value, a position error value, and a movement distance error value; and executing a support vector machine system installed in a server, to compare the direction error value, the position error value and the movement distance error value with a predetermined threshold for classification. The technical solution of the present disclosure is able to detect GPS spoofing attacks and perform correction position data, so as to improve security in the user's personal safety.


Owner:NATIONAL TSING HUA UNIVERSITY
Method for determining GPS deception by single unmanned aerial vehicle based on Kalman filtering under wind field interference
ActiveCN110007318AReduce payloadReduce mistakesSatellite radio beaconingICT adaptationReal-time dataWind field
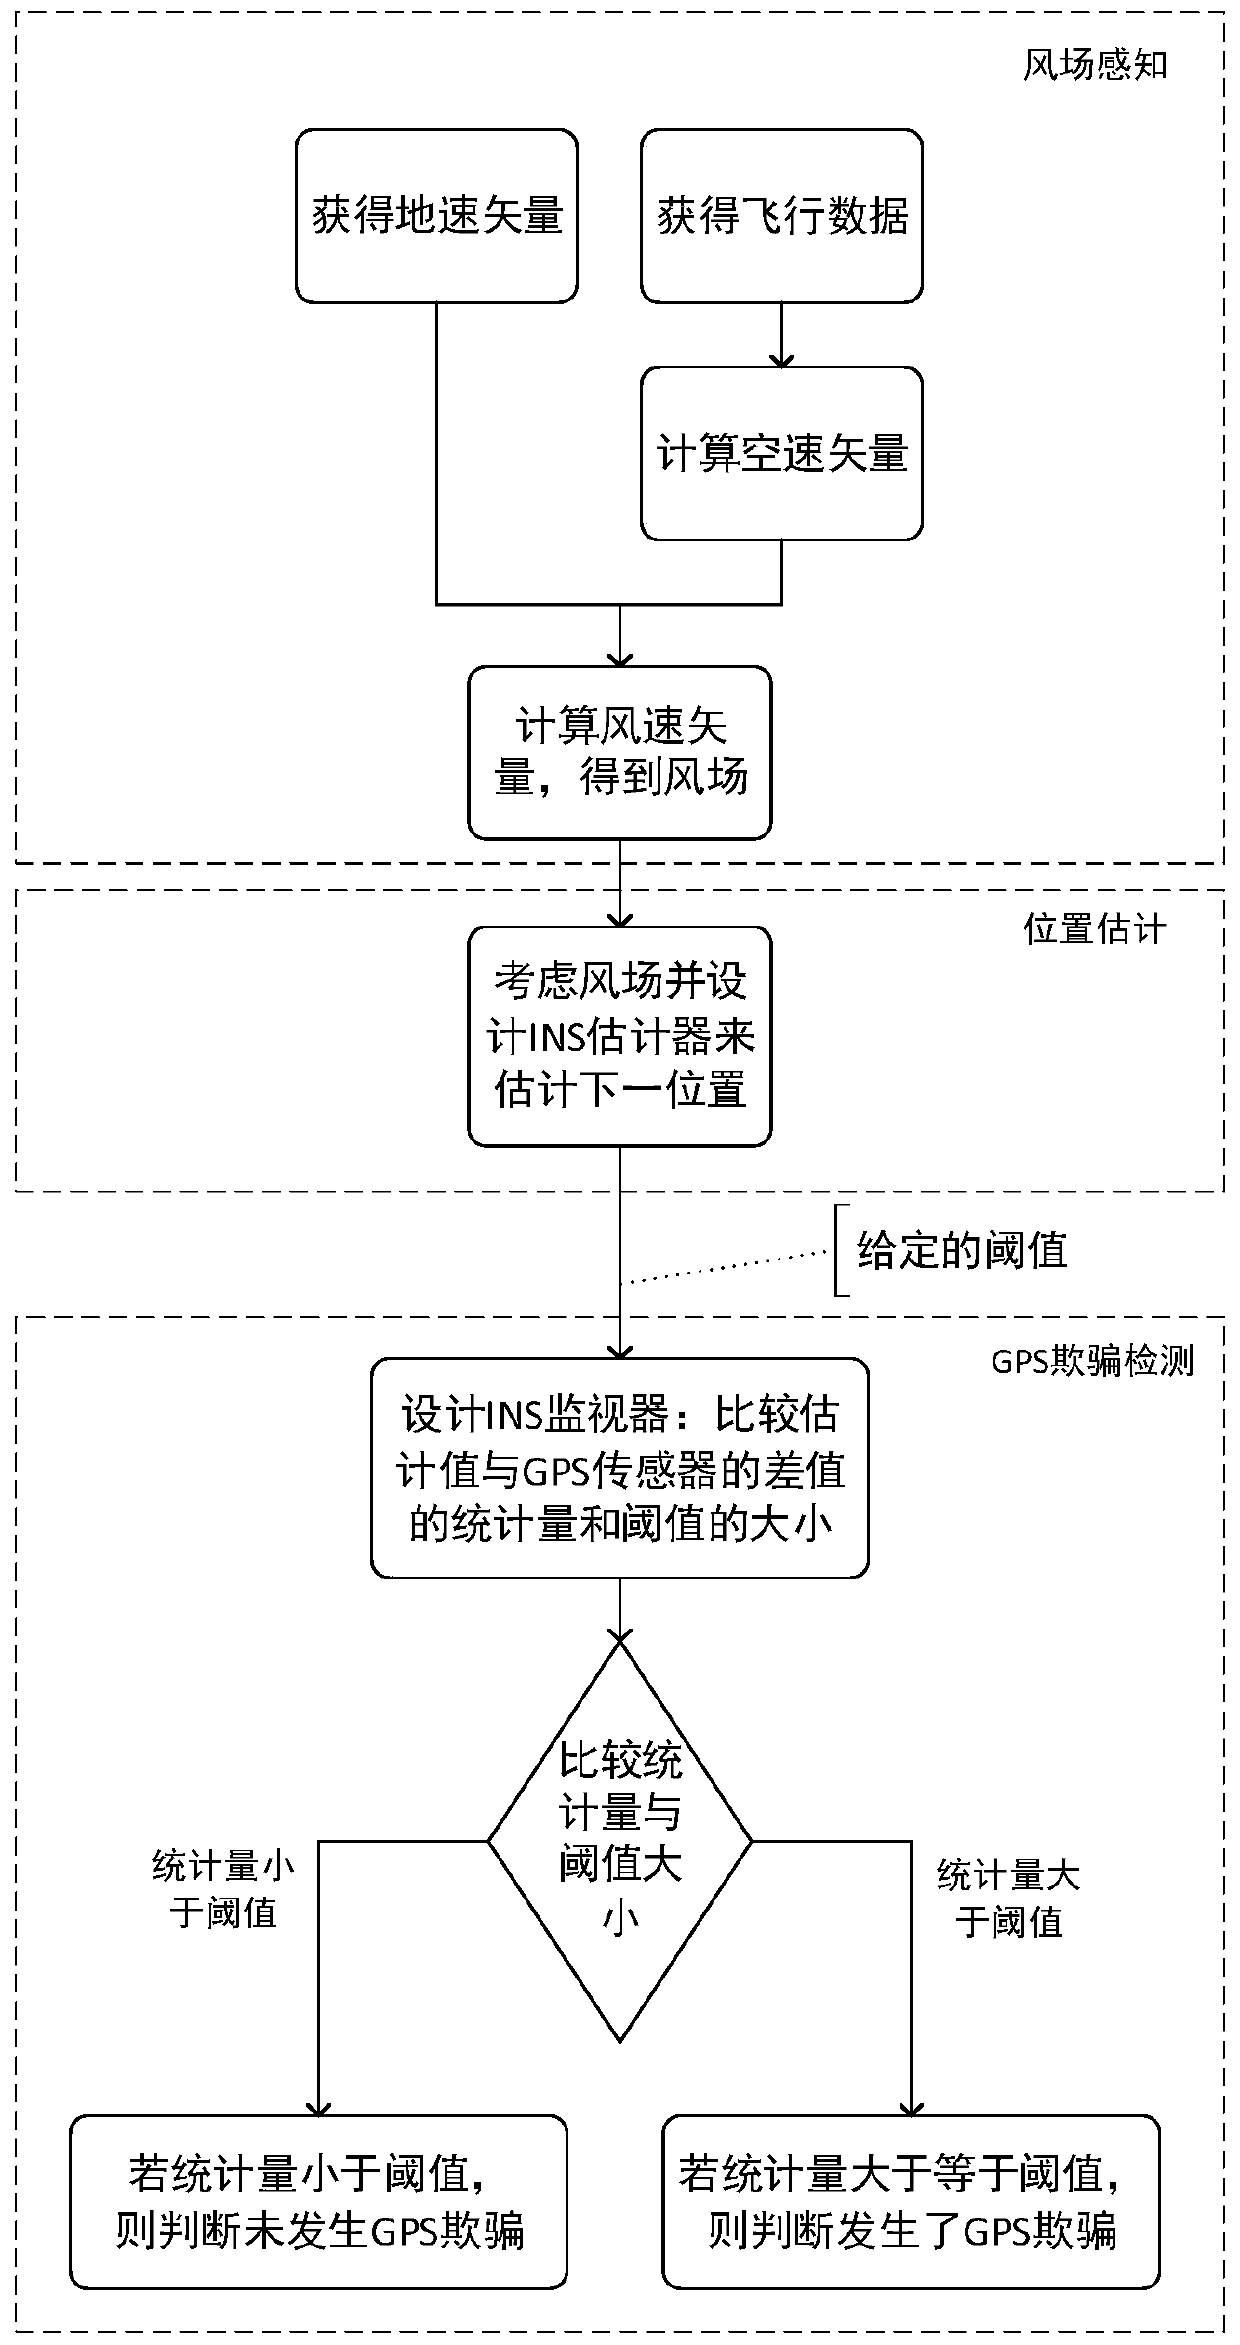
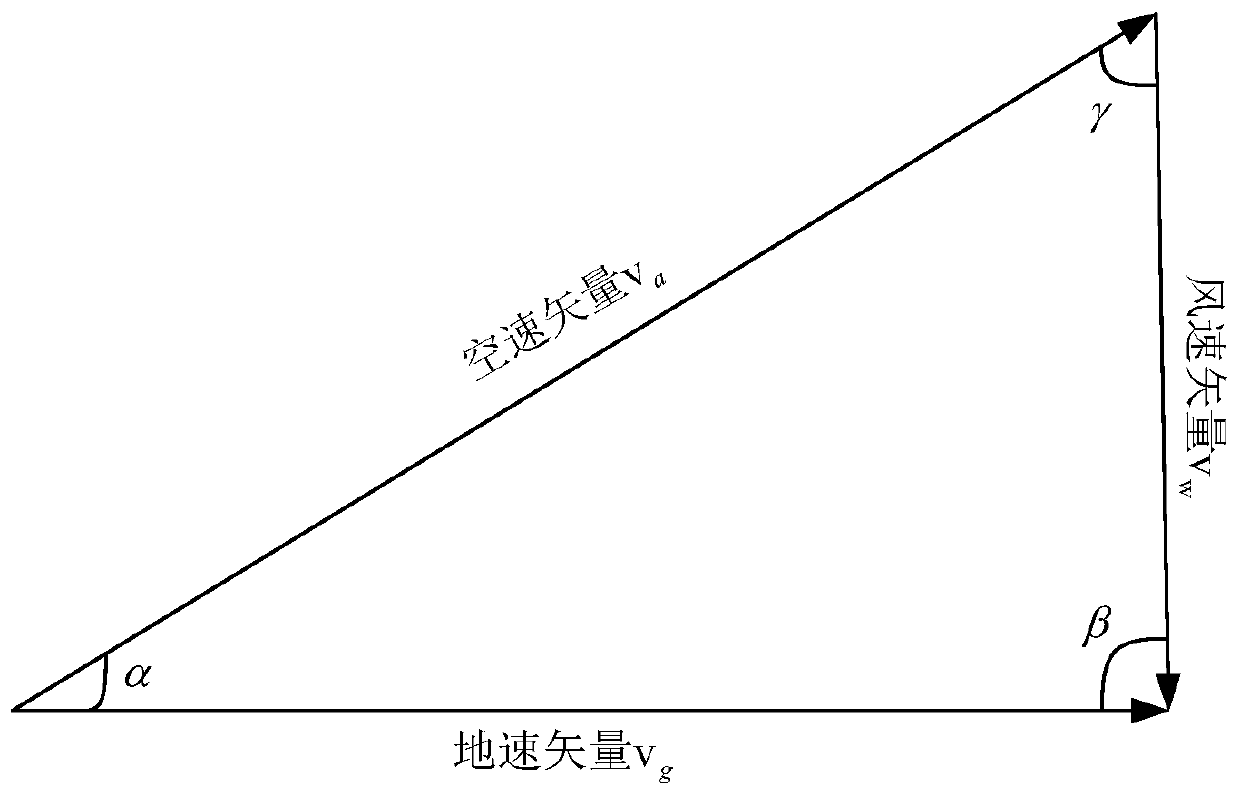
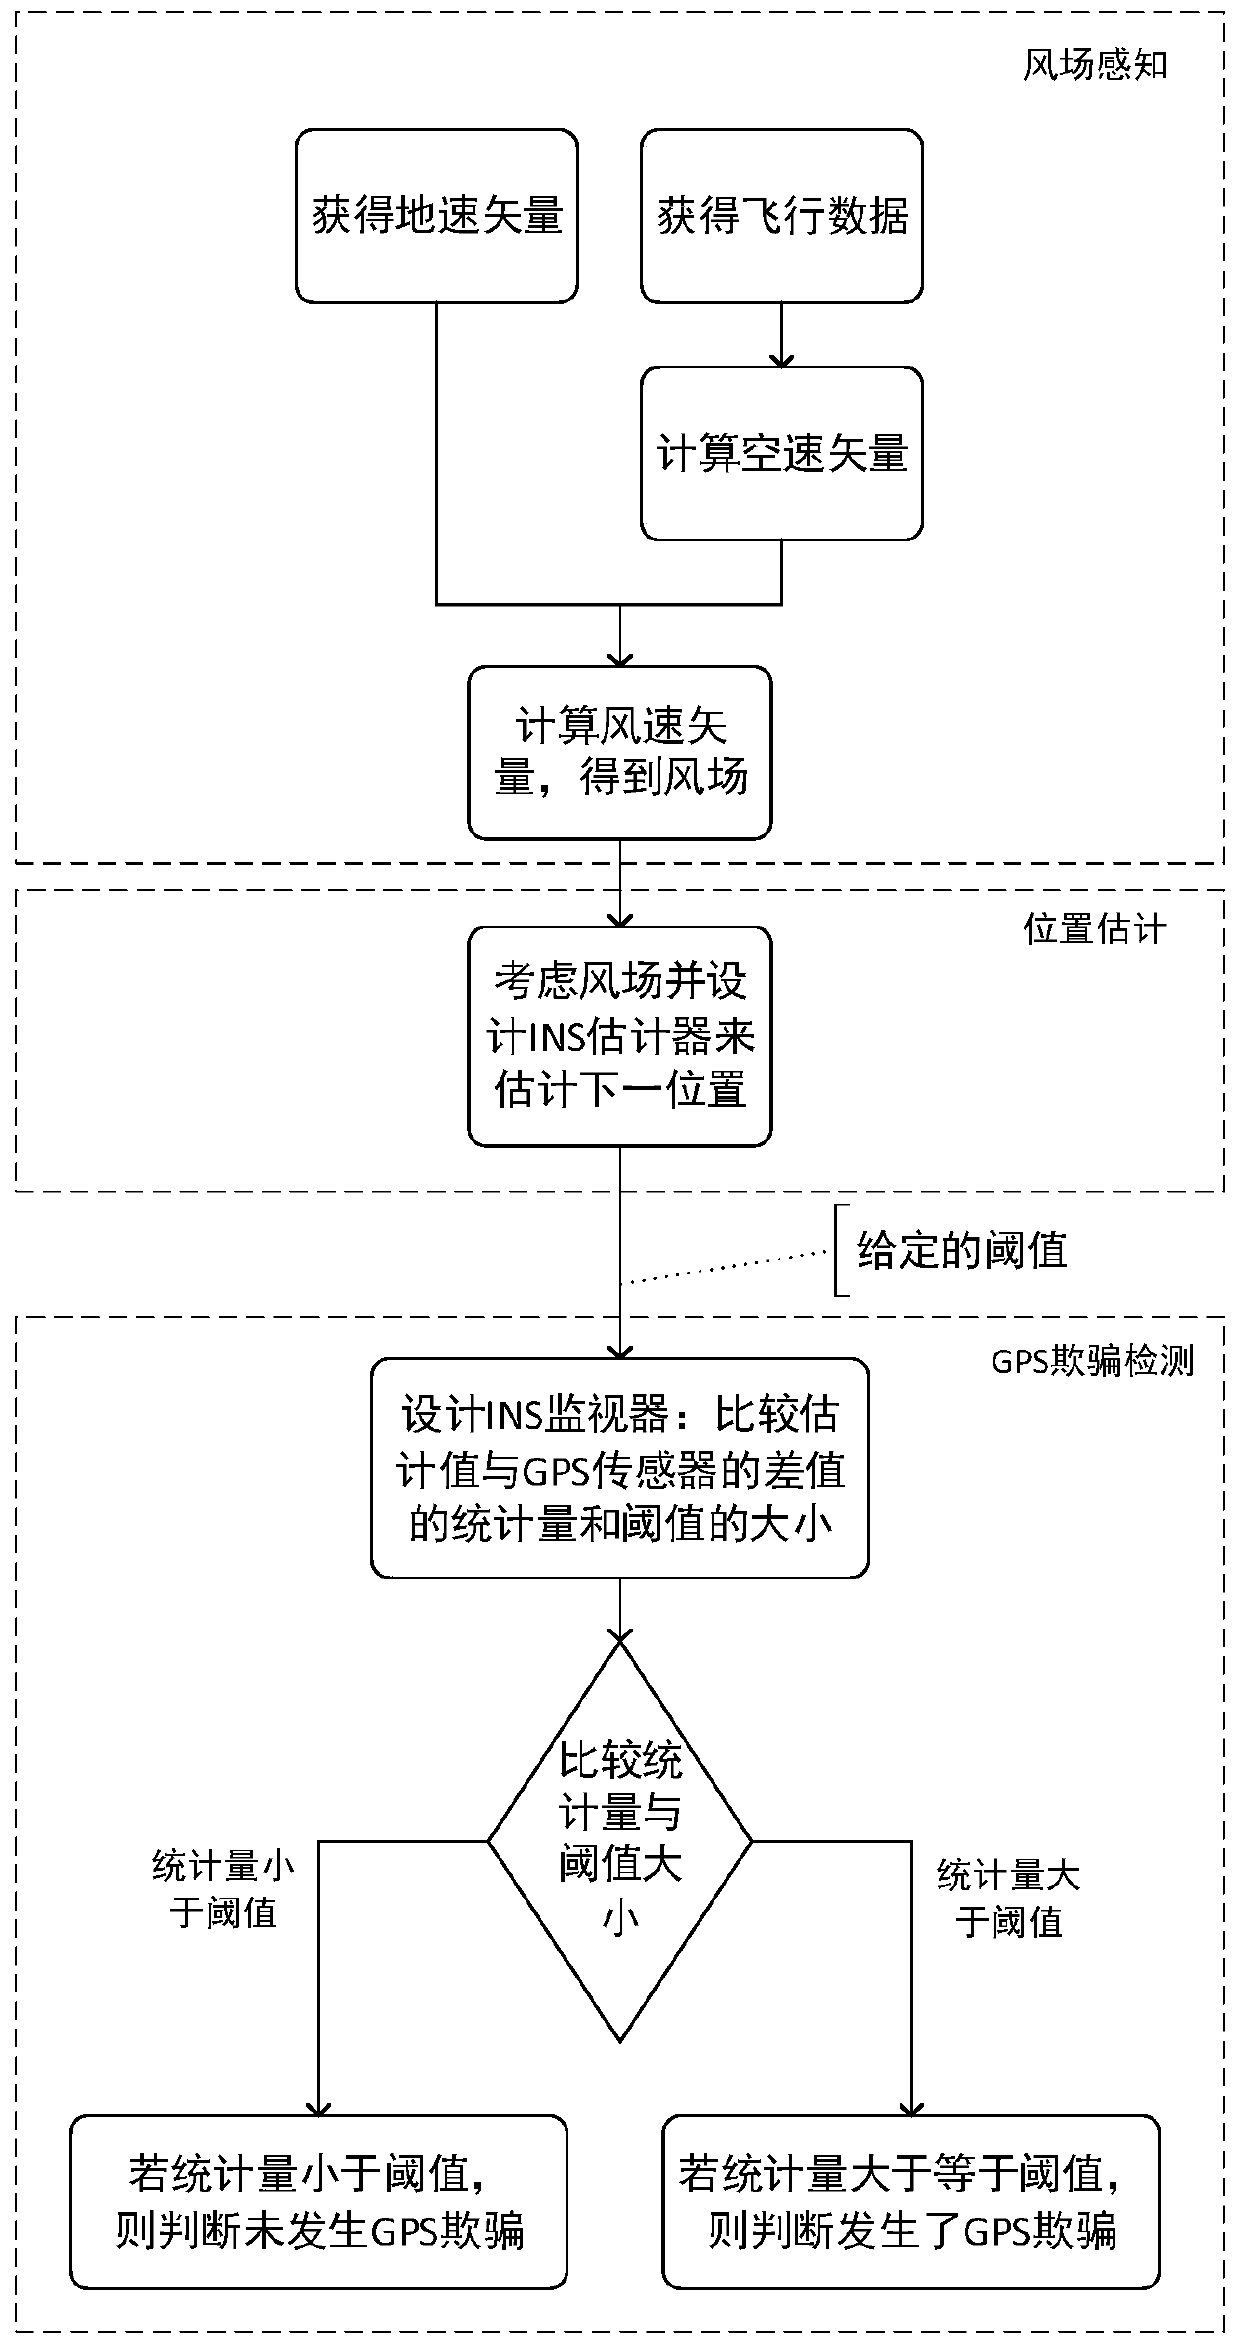
The invention discloses a method for determining GPS deception by a single unmanned aerial vehicle based on Kalman filtering under wind field interference. The method comprises the steps of: wind field perception, position estimation and GPS deception detection. The calculation idea is as follows: the wind field condition can be obtained according to the real-time data of the sensor, the wind field condition can influence the position speculating based on an inertial navigation module, and after the wind field condition is known, the influence of wind on the position speculating can be eliminated, so that the reliability of the finally obtained determination result about whether GPS cheating occurs or not is higher.
Owner:XIDIAN UNIV
Self-adaptive generalized accumulation and GPS spoofing attack detection method
ActiveCN113534199AIncrease widthReduce widthDigital technique networkSatellite radio beaconingSelf adaptiveLog likelihood
The invention relates to a self-adaptive generalized accumulation and GPS spoofing attack detection method. The method comprises the following steps: initializing the system; collecting measurement data zm, t of a PMU by using an adaptive sliding window; carrying out an improved Kalman filtering prediction step; solving a ratio gamma t by using a generalized log-likelihood ratio, and updating an accumulative statistic beta t; carrying out an improved Kalman filtering measurement updating step; if the cumulative statistic betat is equal to 0, judging that the system is not subjected to GPS spoofing attack; and if the cumulative statistic betat is greater than a preset threshold Thr, judging that the system suffers from the GPS spoofing attack. According to the GSA detection method, the most suitable width of the sliding window is automatically adjusted according to different conditions, all PMU measurement data subjected to GPS spoofing attacks can be detected more quickly, accordingly, corresponding damaged data are repaired, the operation time of an algorithm can be effectively shortened, and normal operation of a power system is ensured. Besides, the GSA detection method also provides a method for detecting the GSA attack type, which is more beneficial for the system to make a corresponding attack defense strategy.


Owner:CHANGSHA UNIVERSITY OF SCIENCE AND TECHNOLOGY
Cross-regional positioning data anti-spoofing system based on network structure detection
The invention discloses a cross-regional positioning data anti-fraud system based on network structure detection, which comprises the following steps: acquiring a routing path of a current positioningdata transmission terminal based on an ICMP protocol, and judging whether positioning fraud is carried out by judging whether the routing path is consistent with transmitted positioning data or not.According to the cross-region positioning data anti-spoofing system based on network structure detection, based on the principle of equipment network detection, a user is prevented from carrying out positioning data position tampering in a cross-region mode through GPS spoofing and other means. The system can effectively verify whether the position of the user is reasonable or not to a certain extent (across regions).


Owner:SICHUAN CHANGHONG ELECTRIC CO LTD
V2X security communication and identity authentication system based on lightweight block chain
PendingCN120602940AParticular environment based servicesVehicle wireless communication serviceSecure communicationDigital signature
The invention relates to the technical field of Internet of Vehicles, and discloses a V2X security communication and identity authentication system based on a lightweight block chain, the system comprises a projection early warning end, an angle detection end and a hierarchical color difference end, and the projection early warning end, the angle detection end and the hierarchical color difference end are jointly connected with a voice alarm module; through a distributed verification mechanism of a projection early warning end, a single-point fault risk of a traditional CA centralized architecture is eliminated, through multi-node parallel verification of a digital signature, a malicious instruction is intercepted when a signature abnormity is detected, the problem of malicious certificate propagation caused by paralysis of an authentication center is solved, safety and reliability of an identity authentication system are ensured, and the security and reliability of the system are improved. Through the dynamic positioning correction of the angle detection end, the adaptability to complex road conditions is enhanced, the vehicle communication orientation and the standard position stored in the block chain are compared in real time, when the angle deviation is detected, a deviation correction mechanism is automatically triggered, GPS spoofing attack vulnerabilities in tunnels and elevated scenes are overcome, and the risk of instruction mistaken execution caused by the position deviation is solved.

Owner:BEIJING AUTOMOBILE WORKS CO LTD
Unmanned aerial vehicle GPS spoofing attack detection method and device based on comparative learning and Mama
The invention provides an unmanned aerial vehicle GPS spoofing attack detection method and device based on comparative learning and Mama, and relates to the technical field of unmanned aerial vehicle navigation safety monitoring. The method comprises the following steps: acquiring navigation data of a GPS (Global Positioning System) of an unmanned aerial vehicle, preprocessing the navigation data to generate a plurality of track subsequences with fixed window lengths, obtaining initial time domain data, and performing frequency domain conversion processing on the navigation data to obtain initial frequency domain data; inputting the initial time domain data and the initial frequency domain data into a trained double-branch Mama model for feature extraction, and outputting time domain features and frequency domain features; calculating a spoofing score according to the time domain feature and the frequency domain feature, and determining a spoofing attack behavior detection result according to the spoofing score; wherein two branches in the double-branch Mama model share a weight; the spoofing attack detection model is obtained based on comparative learning strategy training. According to the method, the modeling efficiency and the detection accuracy of the long-sequence navigation data can be considered while the dependence on manual labels is reduced.

Owner:HEBEI XIANGTUO AVIATION TECH CO LTD
GPS deception jamming detection method based on magnetic heading of unmanned aerial vehicle
ActiveCN110376613AGuaranteed credibilityReduce the effect of course deviationSatellite radio beaconingFlight timeGps spoofing
The invention relates to a GPS deception jamming detection method based on the magnetic heading of an unmanned aerial vehicle. An AB segment, a BC segment, a CD segment and a DA segment of a virtual route are built by using a current position of an unmanned aerial vehicle as a starting point A and a current heading as the direction; the unmanned aerial vehicle is guided to fly along the AB segmentand consumed flight time Tf is recorded; if a distance Dd of deviation of the unmanned aerial vehicle to the virtual route is less than or equal to a threshold Kd, a difference between the current magnetic heading and the angle of the unmanned aerial vehicle is calculated every one second and the difference is marked as gamma; after the unmanned aerial vehicle arrives at a B point, average filtering is performed on the angle difference within the period of time to obtain an average deviation and the unmanned aerial vehicle is guided to enter the BC segment; if the Dd is larger than Kd, counting is started; if the lasting time exceeds five seconds, the GPS of the unmanned aerial vehicle is determined to be affected and detection is stopped; and if the consumed flight time Tf is larger than2t and the unmanned aerial vehicle is determined not to arrive at the B point, the GPS of the unmanned aerial vehicle is determined to be affected and detection is stopped; and determination of the BC segment, the CD segment and the DA segment is performed successively.


Owner:XIAN AISHENG TECH GRP +1
Unmanned aerial vehicle navigation decoy defense method based on visual map matching
PendingCN121049937AImage analysisInternal combustion piston enginesPattern recognitionVisual perception
The invention relates to an unmanned aerial vehicle navigation decoy defense method based on visual map matching, and solves the technical problems that a traditional relative positioning mode is easy to cause positioning drift and an unmanned aerial vehicle is easy to decoy and interfere under long-term and large-scene conditions. The absolute positioning method based on the scene coordinate regression network is adopted, positioning drift is avoided in mechanism, and the scene coordinate regression network based on deep learning is used for performing positioning information mapping on the visual image and the scene coordinates. And inputting a visual image shot by the unmanned aerial vehicle into the optimized scene coordinate regression network to obtain a scene coordinate predicted value, and calculating the scene coordinate predicted value by using an RANSAC algorithm to obtain a pose estimation result. And comparing the pose estimation result with global navigation satellite system (GPS) positioning information received by the unmanned aerial vehicle to complete positioning signal decoy recognition, so that the unmanned aerial vehicle can effectively defend against GPS decoy signals.

Owner:XIAN INST OF OPTICS & PRECISION MECHANICS CHINESE ACAD OF SCI
Unmanned aerial vehicle GPS deception detection method based on dynamic threshold generation
The invention relates to the technical field of spoofing detection, in particular to an unmanned aerial vehicle GPS spoofing detection method based on dynamic threshold generation, and the method comprises the steps: collecting multi-source sensor data of an unmanned aerial vehicle, and carrying out the preprocessing of the data, so as to obtain a current state vector; based on the attack frequency model, determining the attack frequency of the unmanned aerial vehicle, performing risk level grading on the attack frequency to obtain a risk level grading result, and further determining a sensitivity factor corresponding to the attack frequency; and generating a current feature weight vector corresponding to the target unmanned aerial vehicle based on the current state vector, the sensitivity factor and an online reinforcement learning driving strategy, and dynamically calculating a current deception judgment threshold by combining the current state vector and the sensitivity factor, thereby obtaining a corresponding GPS deception detection result. Therefore, the problems that an existing GPS deception detection technology is poor in adaptability, low in deployment efficiency, high in response delay, disjointed in software and hardware, incapable of meeting the real-time requirement of an edge platform and the like are solved.

Owner:BEIJING INST OF TECH
Analysis method for global Positioning System (GPS)
InactiveCN110058265AProtect location information securityNavigational calculation instrumentsNavigation by speed/acceleration measurementsAccelerometerGait
The invention provides an analysis method for a global Positioning System (GPS). The method comprises steps of operating a mobile device containing an accelerometer, a magnetometer and a GPS data receiver, receiving GPS data through the GPS data receiver and acquiring acceleration data through the accelerometer; acquiring magnetic data through the magnetometer; combining the GPS data, the acceleration data and the magnetic data and converting into a heading error value, a position error value and a shift distance error value; running a support vector machine (SVM) system installed in a server,comparing the heading error value, the position error value, the shift distance error value with the predetermined threshold values and conducting classification, and adjusting the predetermined threshold values according to the height and gait of a user. The analysis method of the invention utilizes the detection and correction means for the GPS spoofing attack to further improve the personal safety guarantee of a user.


Owner:孙宏民
Oil tank truck primary and secondary lock safety monitoring system based on LoRa communication
The invention relates to the technical field of oil tank truck safety monitoring, in particular to an oil tank truck primary and secondary lock safety monitoring system based on LoRa communication, which comprises a monitoring center server, a vehicle-mounted terminal and a primary and secondary lock device. The surrounding radio environment of each physical position is complex and difficult to copy, when an attacker carries out GPS spoofing, although GPS coordinates reported by a vehicle are forged, a radio frequency signal set collected by a vehicle-mounted terminal in real time is a real reflection of an illegal position where the vehicle-mounted terminal is located. The radio frequency signal set is obviously different from a pre-stored radio frequency signal set of a legal position stored in a monitoring center database; by comparing the two, the system can immediately identify deception behaviors with mismatched positions and reject an unlocking request; according to the field investigation mechanism based on the physical environment, the problem of vulnerability caused by purely depending on digital coordinates in the prior art is fundamentally solved.

Owner:FUZHOU ZHENGCHENG SECURITY SEALS CO LTD
Unmanned aerial vehicle GPS deception detection method based on adaptive orthogonal guidance particle swarm optimization
ActiveCN121091320AInternal combustion piston enginesBiological modelsUncrewed vehicleComposite adaptation
The invention discloses an unmanned aerial vehicle GPS deception detection method based on adaptive orthogonal guidance particle swarm optimization, and relates to the technical field of unmanned aerial vehicle navigation. According to the method, a standardized residual error and a residual error energy index are constructed based on internal physical constraints of navigation data, deception type priori knowledge is not needed, abnormal disturbance can be stably perceived and quantitatively represented, and the adaptability and generalization ability to an unknown deception mode are improved; a fitness-driven adaptive orthogonal guide disturbance particle swarm optimization algorithm is combined with fitness evaluation and a population diversity coefficient to adjust an inertia weight and control disturbance switching, dynamic balance parameter space global exploration and local fine search are performed, premature convergence is inhibited, hyper-parameter optimization precision and stability are improved, and the robustness of the system is improved. Robustness and accuracy of the classification model under complex interference are enhanced; the composite fitness function gives consideration to classification performance and stability, and is matched with training optimization of an XGBoost model to establish a GPS deception detection model with high accuracy and strong generalization.

Owner:CIVIL AVIATION FLIGHT UNIV OF CHINA
Systems and methods to detect GPS spoofing attacks
A method for detecting GPS spoofing attacks includes providing a trained deep learning (DL) model based on neural networks, feeding GPS signals into the trained DL model, using asymmetric Shapley values (ASVs) to calculate feature contributions, using the ASVs to assign a non-uniform distribution over an ordering of features, obtaining causal structures among the features, applying the ASVs to causal Shapley additive explanation to obtain Shapley attributions, incorporating the Shapley attributions and the causal structures, and detecting GPS spoofing attacks by running the trained DL model and using the causal structures, non-uniform distribution, feature contributions, and Shapley attributions.

Owner:INTELLIGENT FUSION TECHNOLOGY INC
GPS spoofing detection method and device based on RSSI, and storage medium
PendingCN111948677AHigh cost of solutionSolve the shortcomings of limited application rangeCharacter and pattern recognitionSatellite radio beaconingElectronic communicationEmbedded system
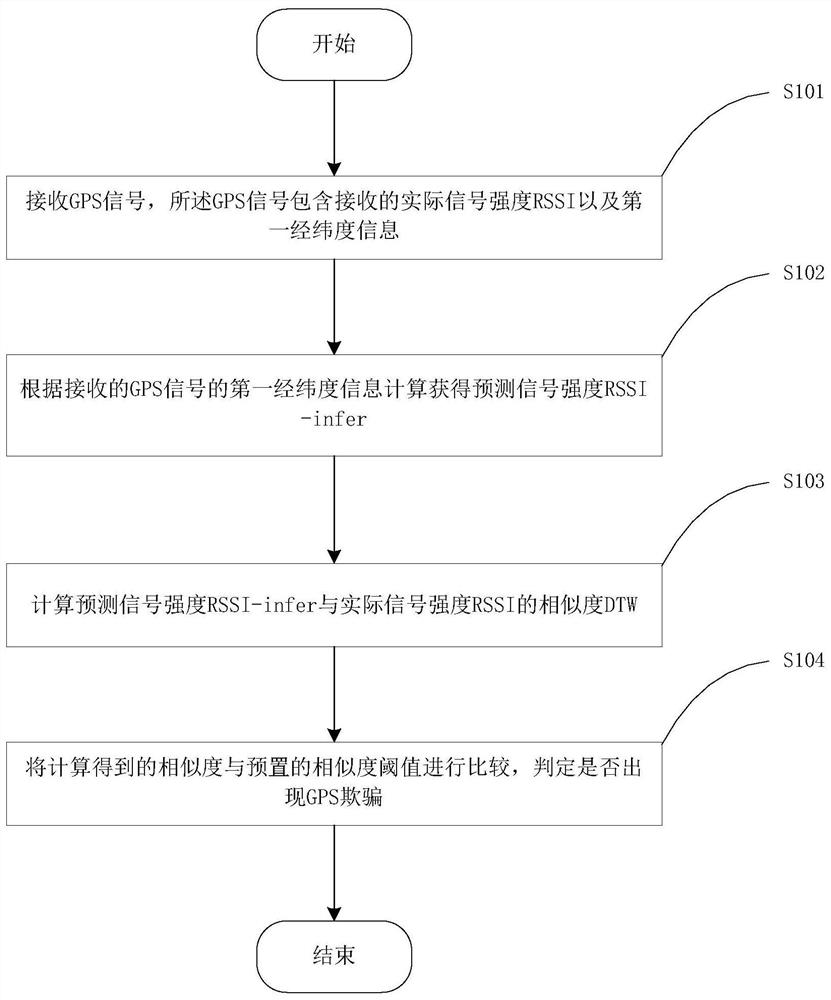
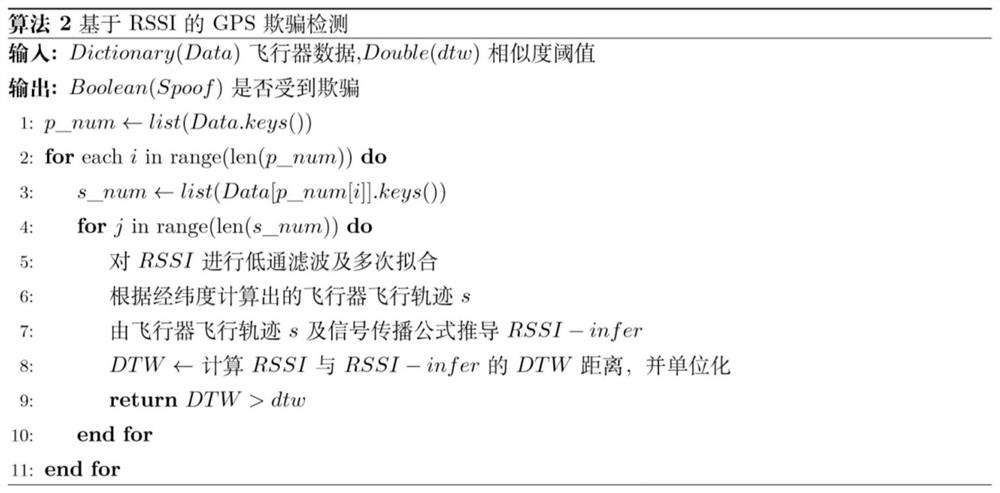
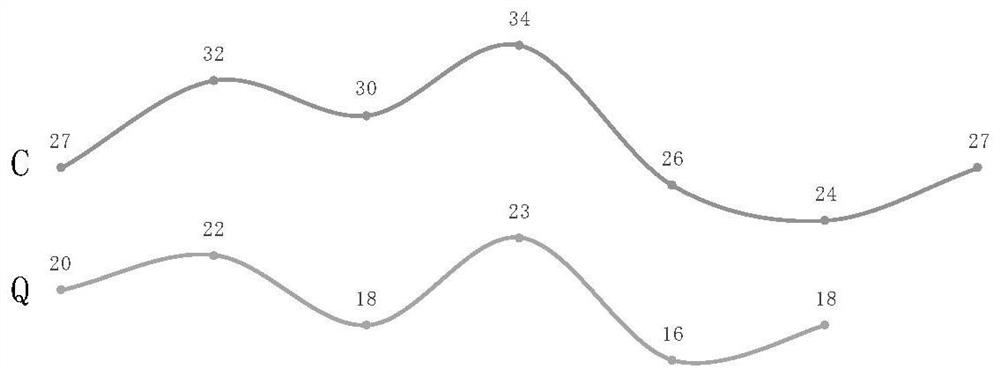
The invention relates to the technical field of electronic communication, in particular to a GPS spoofing detection method and device based on RSSI and a storage medium. The method comprises the stepsthat a GPS signal is received, and the GPS signal comprises received actual signal strength RSSI and first longitude and latitude information; calculating according to the first longitude and latitude information of the received GPS signal to obtain predicted signal strength RSSIinfer; calculating the similarity DTW between the predicted signal strength RSSI-infer and the actual signal strength RSSI; and comparing the calculated similarity with a preset similarity threshold, and judging whether GPS spoofing occurs or not. The method can effectively solve the problem that an existing GPS spoofing detection method needs to upgrade hardware equipment to cause huge cost, and the defect that a part of defense methods have limitation in application range, so that a GPS receiving end can discover the occurrence of GPS spoofing conditions in time and take corresponding defense measures.
Owner:武汉众腾智创信息技术有限公司
Spoofing detection using terrain avoidance and warning system
PendingUS20250244483A1External condition input parametersSatellite radio beaconingTerrain awareness and warning systemEmbedded system
A vehicle comprising: an user interface (UI); a global positioning system (GPS); an inertial reference system (IRS); and a terrain awareness and warning system (TAWS), the TAWS comprising processing circuitry configured to: receive at least one of: GPS data from the GPS or IRS data from the IRS; determine, based at least in part on the received at least one of the GPS data or the IRS data, whether the vehicle is receiving one or more of a GPS spoofing signal or a GPS jamming signal; and in response to a determination that the vehicle is receiving the GPS spoofing signal or the GPS jamming signal, cause the UI to output a notification indicating that the vehicle is receiving the GPS spoofing signal or the GPS jamming signal.

Owner:HONEYWELL INTERNATIONAL INC
Unmanned aerial vehicle GPS deception detection method based on federal learning
The invention relates to the technical field of unmanned aerial vehicles, in particular to an unmanned aerial vehicle GPS spoofing detection method based on federated learning, and the method comprises the steps: obtaining a first spoofing probability generated by a target unmanned aerial vehicle according to multi-source heterogeneous data, the first spoofing probability being generated by a dual-branch lightweight detection model carried by the target unmanned aerial vehicle; fusing the spoofing probabilities corresponding to the plurality of unmanned aerial vehicles by using a space-time perception dynamic aggregation algorithm to generate a second spoofing probability; and correcting the first spoofing probability of the target unmanned aerial vehicle by using the second spoofing probability, and determining a spoofing detection result of the target unmanned aerial vehicle based on the corrected first spoofing probability. Therefore, the problems of high false alarm rate, missing report rate and the like caused by the fact that a single unmanned aerial vehicle cannot distinguish real deception and environmental interference only by analyzing a single data source in the related technology are solved.

Owner:BEIJING INST OF TECH
Position location for navigation without GPS
ActiveUS12504545B2Radio wave direction/deviation determination systemsPosition fixationSignal sourceRemote sensing
An apparatus and method of determining the position location of a moving platform without using any GPS signals such as in the GPS-denial environment is disclosed. A direction finding system is employed to receive signals from a source of known position location and to compute the look angles. The look angles include the azimuth and the elevation information. The position location (e.g., latitude and longitude) of the moving platform is determined from the computed azimuth and elevation and the known position location of a remote signal source. There is no interactive communications required between the moving platform and the remote signal source. Consequently, the disclosed method is a passive approach employing a direction finding system to determine the position location of the moving platform from the received non-GPS signals. The position location obtained via this method is also applicable to GPS spoofing detection when the GPS is considered available.

Owner:COMMACCESS LLC
Global positioning system spoofing detection and positioning recovery method based on pseudo-range residual error
The application discloses a global positioning system spoofing detection and positioning recovery method based on pseudo-range residual error, and comprises the following steps: S1, initializing system parameters, determining initial position information of a receiver and clock error of the receiver, and acquiring latest navigation ephemeris information; S2, using measurement information of an inertial sensor to perform prior estimation on the current position of the receiver; S3, acquiring global positioning system measurement information, and calibrating satellite pseudo-range information; S4, acquiring an estimated value of the satellite pseudo-range by using the navigation ephemeris information and the estimated position of the receiver; S5, using the residual error of the satellite pseudo-range measurement value and the estimated value to judge whether the currently received satellite data is spoofing data; and S6, using real satellite information and measurement information of the inertial sensor to realize positioning recovery. The method can detect GPS spoofing behavior, fully utilize effective information in GPS data, and comprehensively optimize positioning error.

Owner:SOUTHEAST UNIV
Intelligent research and judgment method for safety of inspection data of electric power unmanned aerial vehicle
The invention discloses an intelligent research and judgment method for power unmanned aerial vehicle inspection data security, and relates to the technical field of power unmanned aerial vehicle security, and the method comprises the steps: carrying out the vulnerability mining and risk identification of a power unmanned aerial vehicle system communication protocol, firmware and a mobile terminal SDK, and building a power unmanned aerial vehicle communication protocol security quantitative index model; analyzing the binary code of the electric unmanned aerial vehicle APP by using a deep learning model, extracting a time sequence feature and a semantic feature, and identifying unauthorized access, key hard coding and abnormal calling behaviors; simulating GPS spoofing, data link interference and data tampering attack scenes, and performing risk assessment by dynamically deducing an attack chain of the power unmanned aerial vehicle; identifying potential security threats through multi-modal data association analysis; and constructing a comprehensive safety situation assessment system of the electric unmanned aerial vehicle, and performing intelligent safety research and judgment and risk grading on the inspection data. According to the method, security threat intelligent study and judgment are carried out from multiple levels, and the comprehensiveness and accuracy of data anomaly detection are improved.

Owner:STATE GRID SHANGHAI MUNICIPAL ELECTRIC POWER CO +1