

Patents
Literature
52 results about "Germ free isolator" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Aseptic cultivating technology for cavy and feed formula
InactiveCN1748493AComprehensive and balanced nutritionImprove palatabilityAnimal feeding stuffAccessory food factorsMicroorganismGerm free isolator
The present invention discloses the cultivating technology of aseptic cavy and the feed formula. The cultivating technology includes abdominal incision to take out cavy embryo, raising and propagating in aseptic isolating apparatus, and providing delicious feed comprising protein, carbohydrate, fat, vitamins and minerals and Co-60 ray irradiated. The cavy thus raised has high survival rate and no microbe and parasite infection, and makes it possible to obtain correct and reliable experiment result. The present invention may be used widely in various research and production fields.
Owner:INST OF LAB ANIMAL SCI CHINESE ACAD OF MEDICAL SCI
Aseptic isolator for fixed automatic feeding and discharging on vacuum freeze drier
InactiveCN102032770AAchieve isolationNo harmDrying solid materials without heatFreeze-dryingGerm free isolator


Owner:SHANGHAI TOFFLON SCI & TECH CO LTD
Drug sterile freeze-drying isolator system for laboratory
InactiveCN106016978ASimple structureImprove cleanlinessMechanical apparatusDrying solid materials without heatSterile environmentFreeze-drying
The invention discloses a drug sterile freeze-drying isolator system for a laboratory, and belongs to the field of drug making equipment. The system comprises a dry heat sterilizer system, a freeze dryer system and a sterile isolator system. The dry heat sterilizer system is connected with the sterile isolator system through a dry heat sterilizer seal connection system; the freeze dryer system is connected with the sterile isolator system through a freeze dryer seal connection system; and the drug sterile freeze-drying isolator system is simple in structure, high in cleanliness, good in sealing performance, capable of providing safe and reliable sterile environment for a freeze-drying experiment of novel sterile drugs and also capable of effectively avoiding the harm of toxic drugs to experimenters during toxic drug experimenting, and provides the effective safe protection for health of the experimenters, and meanwhile the system reduces the requirement of the equipment background environment, the running cost is saved, and the higher practicability is achieved.
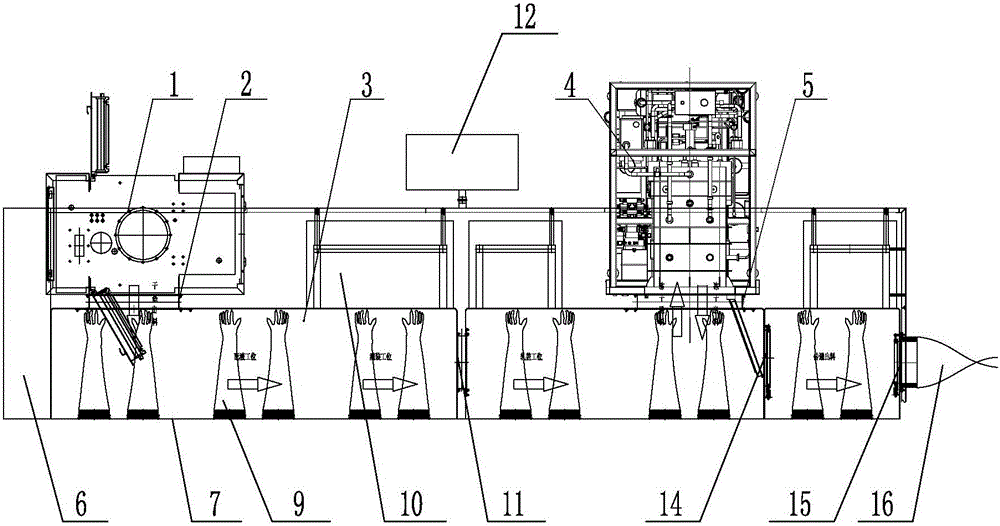
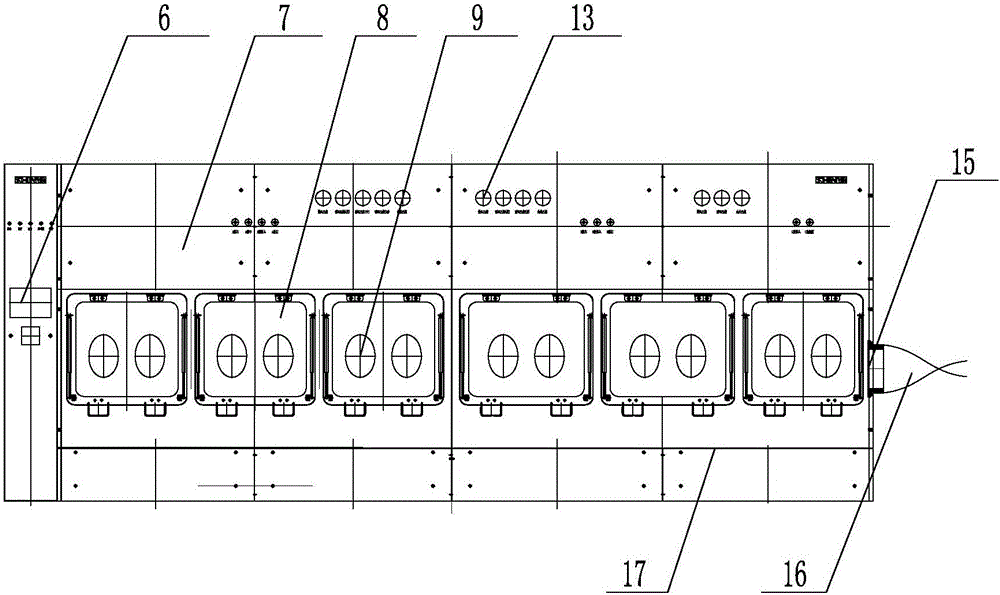
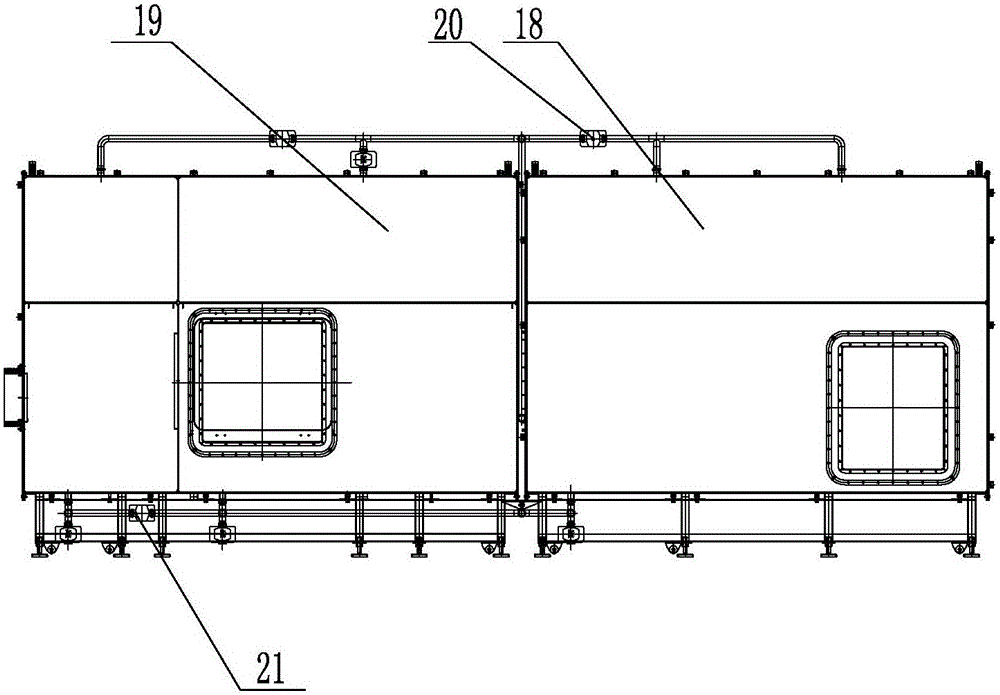
Owner:SHINVA MEDICAL INSTR CO LTD
Sterile isolator for lyopilization preparation core area
InactiveCN101961294AAchieve isolationNo harmPharmaceutical product form changeHermetic sealBiochemical engineering
The invention provides a sterile isolator for a lyopilization preparation core area, which is characterized by comprising a framework assembly provided with a visible operation window assembly and a sterile transmission interface assembly, wherein the visible operation window assembly is sealed by a hermetic seal assembly arranged on the framework assembly, one end of a blast pipe extends into the framework assembly, and the other end of the blast pipe is connected with an air processing unit which is connected with an exhaust fan through a pipeline. The invention has the advantages that the risk on artificial contamination is reduced, the pollution of the products on operators and outside environment is simultaneously reduced, a production clean area is reduced, the controllability of a production area is greatly increased, and the cost on operation and maintenance is further reduced.


Owner:SHANGHAI TOFFLON SCI & TECH CO LTD
Parallel flow sterile isolator
The invention discloses a parallel flow sterile isolator. The parallel flow sterile isolator comprises a sterile isolator main body, a pore plate, a high efficiency filter, a static pressure box, a forced draft fan, an IVC (individually ventilated cage) cage air supply system and an IVC cage air exhausting system, wherein the sterile isolator main body, the pore plate, the high efficiency filter, the static pressure box and the forced draft fan are sequentially communicated, a pair of gloves and a transmission system are arranged on the sterile isolator main body, and a supporting structure is arranged at the bottom of the sterile isolator main body. The parallel flow sterile isolator has the advantages that positions of supplying air and exhausting the air are changed, an up-supply and up-exhaust mode is designed, and the IVC cage air supply system and air exhausting systems are additionally arranged inside, so that the interior of an existing sterile isolator forms two functional areas; meanwhile, the IVC system at the rear half of the isolator further guarantees cleanliness of the air, and operation space of the front half of the isolator is changed into a parallel flow from a non-parallel flow, so that the parallel flow sterile isolator has positive significance in maintenance of the air cleanliness when impurities appear in an operation of changing a cage for animals, reduction of dust particulate matters as well as stable air exchange, temperature and humidity.


Owner:傅江南
Integrated microsphere preparation device
InactiveCN105726313AEasy Aseptic ProductionEasy to operateSemi-permeable membranesMembranesBiochemical engineeringFreeze-drying
The invention provides an integrated microsphere preparation device. The integrated microsphere preparation device is characterized by comprising a microsphere forming line, a microsphere post-processing tank, a connecting and transferring device and a refrigerating device, wherein the microsphere forming line is used for processing liquid materials into primary cured microspheres, the microsphere post-processing tank is used for subjecting the primary cured microspheres to further curing, temperature reversion and washing, the connecting and transferring device is used for conveying the microspheres produced by the microsphere forming line into the microsphere post-processing tank, the refrigerating device is used for subjecting the microspheres treated by the microsphere post-processing tank to filling and freeze drying, and the microsphere forming line, the microsphere post-processing tank, the connecting and transferring device and the refrigerating device are arranged in a sterile isolation hood. The integrated microsphere preparation device integrates microsphere preparation steps of forming, curing, collecting, washing and sieving previously operated by five units, so that the whole technological process can be conducted in a sterile isolator, and simplicity and convenience in sterile production are achieved; the integrated microsphere preparation device is simple and convenient to operate, safe and environment friendly, thereby meeting industrial demands.


Owner:SHANGHAI TOFFLON SCI & TECH CO LTD +1
Method for cultivating sterile silkworm insect grass
ActiveCN105379562AReduce the amount of solutionCultivating equipmentsMushroom cultivationCordycepsSterile environment
The invention provides a method for cultivating sterile silkworm insect grass. The method comprises the steps that silkworm eggs in the head pigmentation stage or before the head pigmentation stage are disinfected and sterilized; the disinfected and sterilized silkworm eggs are placed in a sterile isolator to be hatched; sterile newly-hatched silkworms which are hatched in the sterile isolator are fed with sterile artificial feed; cordyceps militaris bacterium liquid is prepared; the cordyceps militaris bacterium liquid is injected into abdominal cavities of the sterile silkworms of the third to fifth day of five ages; died and stiff sterile silkworms which grow a small amount of hyphae are taken out from a raising plate and then transferred into a sterile environment alternating illumination at 25 DEG C in the daytime with dark at 20 DEG C at night to be cultivated for 38-42 days, the environment humidity is kept 95% or above in the cultivating process, and then the sterile silkworm insect grass of which the whole body completely grows the hyphae and sporophores of different lengths is obtained.

Owner:王荫槐 +3
Temperature-adjustable and humidity-adjustable sterile isolator
The invention discloses a temperature-adjustable and humidity-adjustable sterile isolator which comprises a box body, a high-efficiency filter, a control box, a delivery window and an air outlet, wherein an isolator body is arranged at the upper half part of the box body, and a rack is arranged at the lower half part of the box body; the delivery window is arranged at one side of the isolator body; the high-efficiency filter is arranged on the upper surface of the isolator body and comprises an outer barrel, an inner container and filter materials; the outer barrel is made of stainless steel and takes the shape of a sealed cylinder, and the inner container is made of stainless steel and takes the shape of a grid; the filter materials are of F17 and are in wheel type cylindrical structures; a clearance of 2-4 centimeters is arranged between the interior of the outer barrel and the filter materials; fresh air enters into the clearance between the inner barrel and the outer barrel through an air supply port and passes through the F17 filter materials, then enters into the cavity of the inner container, and finally enters into the isolator body through an air hole connected with the isolator body; and the control box is arranged inside the rack, and the air outlet is arranged at one side of the rack. In the scheme of the invention, the temperature and the humidity in the isolator body can be adjusted according to needs.


Owner:徐平 +1
Novel aseptic processing system for crude drugs
PendingCN107875407AConditions affecting stabilityQuality assuranceLavatory sanitoryHeatBiochemical engineeringGerm free isolator
The invention relates to a novel aseptic processing system for crude drugs. The system comprises a poor solvent aseptic processing module, a crude drug aseptic processing module, a sterile crude drugoutput module, an online temperature monitoring system, a pure steam sterilizing system and a compressed air delivery system (comprising an air sterilizing filter), wherein the poor solvent aseptic processing module is composed of sequentially connecting a poor solvent storage tank No. 1, a 0.22mu m filter, a poor solvent storage tank No. 2, a 0.22mu m security filter, and conveying pipelines between all the tanks and the filters; the crude drug aseptic processing module is composed of sequentially connecting a crude drug heating reflux dissolving tank, a first stage 0.45mu m filter, a secondstage 0.22mu m filter, and conveying pipelines between all the tanks and the filters; the sterile crude drug output module comprises a cooling crystallization tank, a sterile isolator, conveying pipelines respectively arranged between the cooling crystallization tank and the sterile isolator as well as between the poor solvent aseptic processing module and the crude drug aseptic processing module,and an output pipeline of the sterile isolator.

Owner:天津梅花生物医药科技有限公司
Improved sterile artificial feeding milk for rats
ActiveCN102293334APromote digestion and absorptionFast gastric emptyingAnimal feeding stuffAccessory food factorsAdditive ingredientHigh pressure
The invention relates to a milk product for artificial animal feeding, which aims at providing improved sterile artificial rat feeding milk, which is divided into three stages according to the growth and development requirements of suckling rats and respectively consists of rabbit milk, newborn calf serum, infant formula milk powder and water. During the preparation, the rabbit milk and the infant formula milk powder are transmitted into a sterile isolator after the radiation sterilization through cobalt 60, the water and the newborn calf serum are transmitted into the same sterile isolator after high-pressure sterilization, and the materials are uniformly and proportionally mixed. Because the recipe ingredients are simpler, only four preparation ingredients are adopted, the preparation operation is simpler, and in addition, the nutrition is overall. After the radiation sterilization, the nutrition loss is minimum, the newborn suckling rats have good digestive absorption, the gastic emptying is fast, the growth and the development are good, and in addition, the survival rate is higher. The sterile artificial rat feeding milk is economic and effective and is applicable to various suckling methods.


Owner:ZHEJIANG UNIV
Sterile isolator
PendingCN112190740AEffective isolationImproved ability to withstand positive and negative pressureLavatory sanitoryChemicalsGerm free isolatorMechanical engineering
The invention provides a sterile isolator. The sterile isolator comprises a cabin body, a visual operation part, a sterilization system and an air circulation system, wherein the cabin body is of a horizontal cylindrical structure; a detachable operation platform is arranged in the cabin body; the visual operation part comprises a visual window and an operation opening; the visual window is formedin the annular face of the cabin body; the visual window is detachably connected with the cabin body in a sealed mode; the operation opening is formed in the visual window; a detachable glove is arranged in the operation opening in a sealed mode; the air circulation system provides one-way air flow from top to bottom for the cabin body; and the sterilization system generates a sterilization substance to sterilize the cabin body along with the one-way air flow. The sterile isolator is of a horizontal cylinder structure, the positive and negative pressure tolerance capacity is effectively improved, the cabin body has no dead angle, the sterilization effect is good, the bacterial contamination possibility is greatly reduced, and a closed effective partition is formed inside and outside the cabin body.


Owner:杭州精合医药科技有限公司
Sterile isolator for experimental animals
ActiveCN113207717AAvoid pollutionNo human intervention requiredLavatory sanitoryAnimal housingAnimal scienceGerm free isolator
The invention discloses a sterile isolator for experimental animals. The sterile isolator comprises an isolation bag used for isolating the external environment, an air supply device used for providing clean air for the isolation bag and a feeding and discharging disinfection device used for automatically disinfecting materials entering and exiting the isolation bag; wherein the feeding and discharging disinfection device performs dynamic partitioned sealing on a shell through a rotor rotationally installed on the shell, a carrier body is arranged in a sealed space, the carrier body is driven to rotate through the rotor, and materials are transferred between a feeding port and a discharging port; and the rotor is matched with a disinfectant nozzle for linkage operation in the rotating process, so that automatic transfer and disinfection of the materials entering and exiting from the isolation bag are realized. The shell is sealed in a partitioned mode through the rotor, the materials are transferred and disinfected in the sealed area, automation of material transferring and disinfecting is achieved, the material transferring and disinfecting efficiency is improved, meanwhile, leakage pollution of the isolation bag caused by misoperation in the manual operation process is avoided, and the disinfecting reliability is improved.


Owner:深圳净拓生物科技有限公司
Sterile isolator for sterilizing and unpacking disposable freeze-drying disc
The utility model relates to the technical field of pharmaceutical appliances, and provides a sterile isolator for sterilization and unpacking of disposable freeze-drying trays, the sterile isolator comprises a sterilization box, the sterilization box is provided with a feed inlet, and the feed inlet is communicated with the interior of the sterilization box; the suspension support is rotationally arranged in the sterilization box, the suspension support is provided with a plurality of suspension hooks used for suspending packaging bags, freeze-drying discs are arranged in the packaging bags, and after the suspension support is arranged to rotate, the suspension hooks are sequentially close to the feeding port. According to the technical scheme, the technical problems that in the prior art, when materials are stacked in the isolator, the materials are not prone to being stacked, and time and labor are wasted are solved.

Owner:AUSTAR PHARM EQUIP (SHIJIAZHUANG) CO LTD
Microsphere emulsification equipment used in sterile isolator
The invention relates to the technical field of material mixing and emulsifying equipment, and discloses microsphere emulsifying equipment used in a sterile isolator, the microsphere emulsifying equipment comprises a bottom frame, the top of the bottom frame is fixedly connected with an emulsifying tank, the top of the emulsifying tank is fixedly connected with a sealing cover, and the right side of the outer wall of the emulsifying tank is communicated with a transmission pipe; the bottom of the sealing cover is fixedly connected with an emulsification functional layer, a self-adaptive mechanism is arranged on the outer wall of the conveying pipe and used for conducting self-adaptive adjustment on the pressure at the joint of the conveying pipe, flow sterile emulsification operation is achieved through a PLC, after the conveying pipe is in butt joint, an annular air bag at the joint of the conveying pipe is inflated and expands to form tight sealing, and the conveying pipe is in butt joint with the annular air bag. The sealing structure has the pressure self-adaptive adjusting capacity, the inflation amount is automatically adjusted when pressure fluctuation is caused by operation, the ultraviolet plate on the outer side of the air bag irradiates a gap area and inactivates microorganisms, and the whole mechanism achieves sterile sealing of a connector and self-adaptive pressure adjustment of the pipe end.

Owner:韩立营
Sterile isolator
The utility model relates to the technical field of sterile isolators, and discloses a sterile isolator which comprises a sterile isolator body, a glove fixing inlet and outlet pipe is fixedly connected to the front side of the sterile isolator body, fixing pipes are fixedly connected to the left side and the right side of the sterile isolator body, and threaded rings are fixedly connected to the sides, away from the sterile isolator body, of the fixing pipes. A threaded rod is meshed with an inner cavity of the threaded ring, a telescopic rod is movably connected to an inner cavity of the fixing pipe in a sleeved mode, a limiting groove is formed in the side, close to the threaded ring, of the telescopic rod, a supporting rod is fixedly connected to the front side of the telescopic rod, and a supporting frame is fixedly connected to the top end of the supporting rod. The arm of a worker is supported through the soft cushion at the top end of the supporting frame, the labor intensity of the worker during working is reduced, the position of the supporting frame can be adjusted according to the needs of the worker by adjusting the position of the supporting frame, and the use convenience of the worker is further improved.

Owner:济南市食品药品检验检测中心
Improved sterile artificial rat feeding milk
ActiveCN102293334BPromote digestion and absorptionFast gastric emptyingAnimal feeding stuffAccessory food factorsAdditive ingredientHigh pressure
The invention relates to a milk product for artificial animal feeding, which aims at providing improved sterile artificial rat feeding milk, which is divided into three stages according to the growth and development requirements of suckling rats and respectively consists of rabbit milk, newborn calf serum, infant formula milk powder and water. During the preparation, the rabbit milk and the infant formula milk powder are transmitted into a sterile isolator after the radiation sterilization through cobalt 60, the water and the newborn calf serum are transmitted into the same sterile isolator after high-pressure sterilization, and the materials are uniformly and proportionally mixed. Because the recipe ingredients are simpler, only four preparation ingredients are adopted, the preparation operation is simpler, and in addition, the nutrition is overall. After the radiation sterilization, the nutrition loss is minimum, the newborn suckling rats have good digestive absorption, the gastic emptying is fast, the growth and the development are good, and in addition, the survival rate is higher. The sterile artificial rat feeding milk is economic and effective and is applicable to various suckling methods.


Owner:ZHEJIANG UNIV
A kind of method of cultivating sterile silkworm cordyceps
ActiveCN105379562BReduce the amount of solutionFungiCultivating equipmentsSterile environmentWhole body
The invention provides a method for cultivating sterile silkworm insect grass. The method comprises the steps that silkworm eggs in the head pigmentation stage or before the head pigmentation stage are disinfected and sterilized; the disinfected and sterilized silkworm eggs are placed in a sterile isolator to be hatched; sterile newly-hatched silkworms which are hatched in the sterile isolator are fed with sterile artificial feed; cordyceps militaris bacterium liquid is prepared; the cordyceps militaris bacterium liquid is injected into abdominal cavities of the sterile silkworms of the third to fifth day of five ages; died and stiff sterile silkworms which grow a small amount of hyphae are taken out from a raising plate and then transferred into a sterile environment alternating illumination at 25 DEG C in the daytime with dark at 20 DEG C at night to be cultivated for 38-42 days, the environment humidity is kept 95% or above in the cultivating process, and then the sterile silkworm insect grass of which the whole body completely grows the hyphae and sporophores of different lengths is obtained.

Owner:王荫槐 +3
Object taking mechanism for sterile isolator and sterile isolator
ActiveCN222540771Ureduce depthavoid damageBioreactor/fermenter combinationsBiological substance pretreatmentsGerm free isolatorMechanical engineering
The object taking mechanism comprises a sleeve and a piston capable of moving in the axial direction of the sleeve, the sleeve is arranged on the wall of the isolator and extends towards the outer side of the isolator, the outer diameter of the piston is matched with the inner diameter of the sleeve, a containing groove is formed in the piston, and the containing groove is communicated with the sleeve. The isolator is provided with an opening matched with the containing groove, the opening is located on the outer side of the isolator, the length of the piston is larger than that of the sleeve, and at least part of the containing groove can extend out of the sleeve and is located in the isolator. According to the object taking mechanism for the sterile isolator, the fixed sleeve and the movable piston are matched, and the opening in the sleeve is matched with the containing groove in the piston, so that a biological indicator in the isolator is transferred out of the isolator, and the damage to the internal integrity of the isolator is effectively reduced.

Owner:王晓明
Material sterile connection adding system
The utility model relates to the technical field of material sterile equipment, and provides a material sterile connecting and adding system, which is used for adding materials into a main pipeline and comprises a movable sterile tank connected with a discharge pipeline. The system is provided with a discharging station, when the system is located at the discharging station, the system has a discharging state, in the discharging state, a discharging pipeline is connected with a sterile transfer valve, the sterile transfer valve is connected with a sterile isolator, a conveying hose with a needle head is arranged in the sterile transfer valve, a main pipeline penetrates through the sterile isolator, one end of the conveying hose is connected with the sterile transfer valve, and the other end of the conveying hose is connected with the sterile isolator. One end, with a needle head, of the conveying hose is inserted into an adding point of the main pipeline; materials in the movable sterile tank can be added into the main pipeline through the discharging pipeline and the conveying hose. According to the utility model, the heat-sensitive material can be added into the pipeline in a sterile manner through the movable tank, so that the use of a sterile material bag is avoided; and a sterile isolator is adopted to carry out sterile isolation on the adding point, so that thermal damage of the heat-sensitive material is avoided.

Owner:INNER MONGOLIA YILI IND GROUP CO LTD
Self-control type sterile isolator
PendingCN107940555AImprove controllabilityReduce pollutionMechanical apparatusLighting and heating apparatusElectricityBiochemical engineering
The invention discloses a self-control type sterile isolator. The self-control type sterile isolator comprises a moving frame, an isolator body is arranged at the upper end of the moving frame, an airinlet assembly is arranged at the upper end of the isolator body, a sterile delivery window connected with a purification chamber is arranged on the side face of the isolator body, a control box is arranged on the moving frame, an electrostatic precipitator, a temperature sensor, a humidity sensor and a sterilization lamp are arranged in the isolator body, and are electrically connected with a control box, internal production environment is completely isolated from an operator and exterior environment, manual pollution risks are reduced, meanwhile, the pollution of products to the operator and the exterior environment can be reduced, the production cleaning area is reduced, controllability of the production area is greatly increased, running cost and maintaining cost are reduced, and meanwhile, the control box, the temperature sensor, the humidity sensor, a sterilizer and the air inlet assembly are used for finishing adjusting of internal air parameters.


Owner:京华建设科技有限公司
A sterile isolator for experimental animals
ActiveCN113207717BAvoid pollutionNo human intervention requiredLavatory sanitoryAnimal housingAnimal scienceMedicine


Owner:深圳净拓生物科技有限公司
Ampoule breaker for aseptic isolator
ActiveCN103407950ASave spaceExtended service lifeOpening closed containersBottle/container closureGlass chipGerm free isolator
The invention provides an ampoule breaker for an aseptic isolator, which comprises a rotor, a baffle and a breaking rod, wherein one or more first through holes are formed in the rotor, and a rotating handle is arranged on the side wall of the rotor; a groove, which is matched with the rotor, is formed in the baffle, a second through hole, which corresponds to the first through hole, is formed in the baffle, two bulges are formed on the surface of the baffle facing the rotor, and a positioning groove is formed between the two bulges; a limited rod, which is clamped inside the positioning groove, is arranged at the lower edge of the side wall of the rotor, the limited rod is in contact with the bulge on one edge of the positioning groove, the first through hole and the second through hole are formed in a staggered manner; the limited rod is in contact with the other edge of the positioning groove, the axle line of the first through hole is overlapped with that of the second through hole; a sleeving head, which is matched with the upper end of the ampoule, is arranged at the head part of the break rod. The ampoule breaker provided by the invention has the advantages that labor is saved; an experimenter is not required to stop midway to treat rubbish; table board space of the isolator is saved; the service life of a glove is prolonged; the experimenter's hand is protected from being cut by glass chips; glass chips and medicine liquor can not be scattered in the cabin of the insulator.


Owner:CHIATAI QINGCHUNBAO PHARMA
Apparatus and method for conducting PAO test on air return efficient filter of aseptic isolator
InactiveCN105973536AConvenient and effective testingImprove product qualityFluid-tightness measurement using lightFluid-tightness measurement using fluid/vacuumGerm free isolatorIndustrial engineering
The invention relates to a device and method suitable for the PAO test of the return air high-efficiency filter of the aseptic isolator, which belongs to the technical field of PAO testing, and comprises an isolator operation cabin and a return air box which are sealed and connected, and the lower part of the isolator operation cabin and the return air box passes through The vents are connected, and the return air high-efficiency filter fixing frame is installed in the return air box, and the return air high-efficiency filter is fixed on the return air high-efficiency filter fixing frame. The PAO concentration detection connection and the PAO smoke connection are sealed and connected to the fixed frame of the device. The high-efficiency filter scanning port is set on the return air box corresponding to the air outlet surface of the return air high-efficiency filter, and the return air box cover is set at the high-efficiency filter scanning port. The present invention can accurately judge whether the return air high-efficiency filter leaks, effectively avoids the safety risk caused by the return air high-efficiency filter leakage, can ensure the safety of the aseptic isolator during normal operation, and contributes to Improve the production quality of sterile drugs.


Owner:SHINVA MEDICAL INSTR CO LTD
RTP aseptic valve tank discharge temporary storage automatic transfer and discharging device and method
The application discloses a kind of RTP sterile valve tank discharging temporary storage automatic transfer discharging device and method, including horizontal cleaning machine, be set in the sterile isolator of horizontal cleaning machine side portion and material tank, the main valve mouth of sterile isolator is inclined downward and is set, material tank is equipped with auxiliary valve, still include fixed hoist, transfer trolley, transport mechanism and rotary turnover hoist, transfer trolley is used to send material tank to rotary turnover hoist or carry away material tank, fixed hoist is set below sterile isolator, transport mechanism is set between rotary turnover hoist and fixed hoist and is used to transport material tank set on rotary turnover hoist to fixed hoist, main valve mouth of sterile isolator is equipped with sterile adjustable butt joint mechanism for the butt joint of auxiliary valve on material tank and main valve mouth on sterile isolator.The application can realize the closed transfer of rubber plug, ensure the sterility of transfer process, avoid cross infection, meet the more stringent requirements of new version GMP to sterility.

Owner:浙江亚光科技股份有限公司
Method for transferring at least one filling needle of a number of filling needles into an aseptic isolator
ActiveUS12552053B2Gripping headsAir-pressure/air-lock chambersGerm free isolatorMechanical engineering
A method for transferring at least one filling needle of a number of filling needles into an isolator which has a transfer lock, the method having the following steps: providing a first needle carrier within the transfer lock, said needle carrier carrying the number of filling needles; providing a second needle carrier in a first position within the isolator; robot-assisted transferring of the at least one filling needle of the number of filling needles from the first needle carrier to the second needle carrier; and robot-assisted placing of the at least one filling needle of the number of filling needles in the second needle carrier, wherein the at least one filling needle of the number of filling needles is held directly during the robot-assisted placing. A transfer system, in which such a method can be conducted, is also disclosed.

Owner:GRONINGER GMBH & CO KG
Adaptive device and surgical robot
The utility model relates to an adaptive device and a surgical robotic.The adaptive device comprises a cannula, a sterile isolator and a base, the cannula comprises a cannula body and a cannula base, the cannula body is arranged on the cannula base and provided with a cannula cavity allowing a surgical instrument to penetrate through, the sterile isolator comprises a flexible sleeve, the flexible sleeve is arranged between the base and the cannula base, the cannula base is connected with the base in a clamped mode through the flexible sleeve, and the sterile isolator is arranged in the cannula cavity. The sleeve and the base are isolated in a sterile mode. The tube body is used for penetrating through surgical instruments such as an endoscope, the tube body is arranged on the tube base, the tube base is connected with the base in a clamped mode, the sleeve and the base can be disassembled and assembled more conveniently through the clamping mode, and rapid adaptive disassembly and assembly of the sleeve and the base are achieved; the sterile isolator comprises a flexible sleeve, the flexible sleeve is arranged between the base and the tube seat, the tube seat is connected with the base in a clamped mode through the flexible sleeve, the flexible sleeve can achieve sterile isolation between the base and the sleeve and reduce infection, meanwhile, friction force among the tube seat, the flexible sleeve and the base can be increased through flexible deformation, and the clamping fixing effect is better.

Owner:CORE MOTION MEDICAL ROBOT (SHENZHEN) CO LTD
Sterile isolator for cell product culture
ActiveCN222119265Uavoid sorenessincrease flexibilityBioreactor/fermenter combinationsBiological substance pretreatmentsGerm free isolatorMechanical engineering
The utility model discloses a cell product culture sterile isolator which comprises a sterile isolator body, a plurality of supporting plates are installed on the two sides of the sterile isolator body, a first groove is formed in one side of each supporting plate, a second groove is formed in one side of each first groove, a sliding disc is installed in each second groove in a sliding mode, and the sliding discs are connected with the supporting plates in a sliding mode. An adjusting assembly used for driving the sliding disc to move is arranged on one side of the supporting plate, a first limiting block is fixedly installed on one side of the sliding disc, a connecting plate is installed on the outer side of the first limiting block, a second limiting block is fixedly installed at one end of the connecting plate, and the second limiting block and the first limiting block penetrate through the first groove. The sliding disc can be driven to move through the adjusting assembly, the vertical height of the arm supporting piece can be adjusted conveniently, when the second limiting block corresponds to the arc-shaped disengaging hole in position, the second limiting block can be rotated to leave the first groove, and the supporting rod and the arc-shaped clamping plate can be controlled to face downwards.

Owner:CHENGDU MEDGENCELL CO LTD
Method for transferring at least one filling needle of a number of filling needles into an aseptic isolator
PendingUS20250236029A1Gripping headsAir-pressure/air-lock chambersGerm free isolatorMechanical engineering
A method for transferring at least one filling needle of a number of filling needles into an isolator which has a transfer lock, the method having the following steps: providing a first needle carrier within the transfer lock, said needle carrier carrying the number of filling needles; providing a second needle carrier in a first position within the isolator; robot-assisted transferring of the at least one filling needle of the number of filling needles from the first needle carrier to the second needle carrier; and robot-assisted placing of the at least one filling needle of the number of filling needles in the second needle carrier, wherein the at least one filling needle of the number of filling needles is held directly during the robot-assisted placing. A transfer system, in which such a method can be conducted, is also disclosed.

Owner:GRONINGER GMBH & CO KG
Ampoule breaker for aseptic isolator
ActiveCN103407950BSave spaceExtended service lifeOpening closed containersBottle/container closureGlass chipGerm free isolator
The invention provides an ampoule breaker for an aseptic isolator, which comprises a rotor, a baffle and a breaking rod, wherein one or more first through holes are formed in the rotor, and a rotating handle is arranged on the side wall of the rotor; a groove, which is matched with the rotor, is formed in the baffle, a second through hole, which corresponds to the first through hole, is formed in the baffle, two bulges are formed on the surface of the baffle facing the rotor, and a positioning groove is formed between the two bulges; a limited rod, which is clamped inside the positioning groove, is arranged at the lower edge of the side wall of the rotor, the limited rod is in contact with the bulge on one edge of the positioning groove, the first through hole and the second through hole are formed in a staggered manner; the limited rod is in contact with the other edge of the positioning groove, the axle line of the first through hole is overlapped with that of the second through hole; a sleeving head, which is matched with the upper end of the ampoule, is arranged at the head part of the break rod. The ampoule breaker provided by the invention has the advantages that labor is saved; an experimenter is not required to stop midway to treat rubbish; table board space of the isolator is saved; the service life of a glove is prolonged; the experimenter's hand is protected from being cut by glass chips; glass chips and medicine liquor can not be scattered in the cabin of the insulator.


Owner:CHIATAI QINGCHUNBAO PHARMA
Sterile isolator with ventilation filtration function
The application discloses a sterile isolator with a ventilation filtering function, relates to the technical field of sterile isolators, and comprises an isolator body, a ventilation box fixedly installed at the middle position of the surface of the isolator body, a box door installed at the position of the surface of the isolator body, perspective glass fixedly installed at the position of the surface of the box door, rubber gloves fixedly installed at the surface of the perspective glass and a transmission frame installed at the inner position of the isolator body. The isolator body is reasonable in structure, the object inside the isolator body can be fixed through the cooperation of the sliding assembly and the limiting assembly, sterilization and disinfection can be performed on the inside of the isolator body through the ventilation assembly, the inside of the isolator body is isolated from the outside air through the rotation of the air collecting plate, and the pollution caused by the entry of the outside air into the inside of the isolator body is avoided.

Owner:JIANGSU KANGHE BIOLOGICAL PHARMA