
Patents
Literature
51 results about "Propeller aeroplane" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Engine Control System For An Aircraft Diesel Engine
InactiveUS20110239992A1Reliable functionElectrical controlFuel injection apparatusCommon railControl system
In an engine control system for an aircraft diesel engine for a propeller aircraft for controlling the injection valves, charge pressure valves, common rail pressure valves and propeller control valves actuated by non-redundant actuators, comprising a plurality of sensors and a regulating device connected thereto and to the actuators, two engine control units—first and second—which are each connected to a first and a second power supply and are each connected to the sensors, are provided and are interconnected by way of a serial bus and can be connected selectively to the actuators by way of relays that are supplied with power together with the first engine control unit. The two engine control units each have a diagnostic function for calculating the respective health levels (A and B), which are determined by the defects detected, can be exchanged by way of the serial bus and are compared to one another. If the health level (A) of the first engine control unit is below the health level (B) of the second engine control unit, the power supply to the relay is interrupted, so that the second engine control unit is automatically connected to the actuators by way of the relays that have released, and consequently a redundant engine control system for an aircraft diesel engine is created. The core of the invention is the automatically switchable connection of the two engine control units communicating with one another via relays depending on the calculated health level.


Owner:TECHNIFY MOTORS
Anti-icing and deicing device and method for wings and emages of turbo-prop aircraft
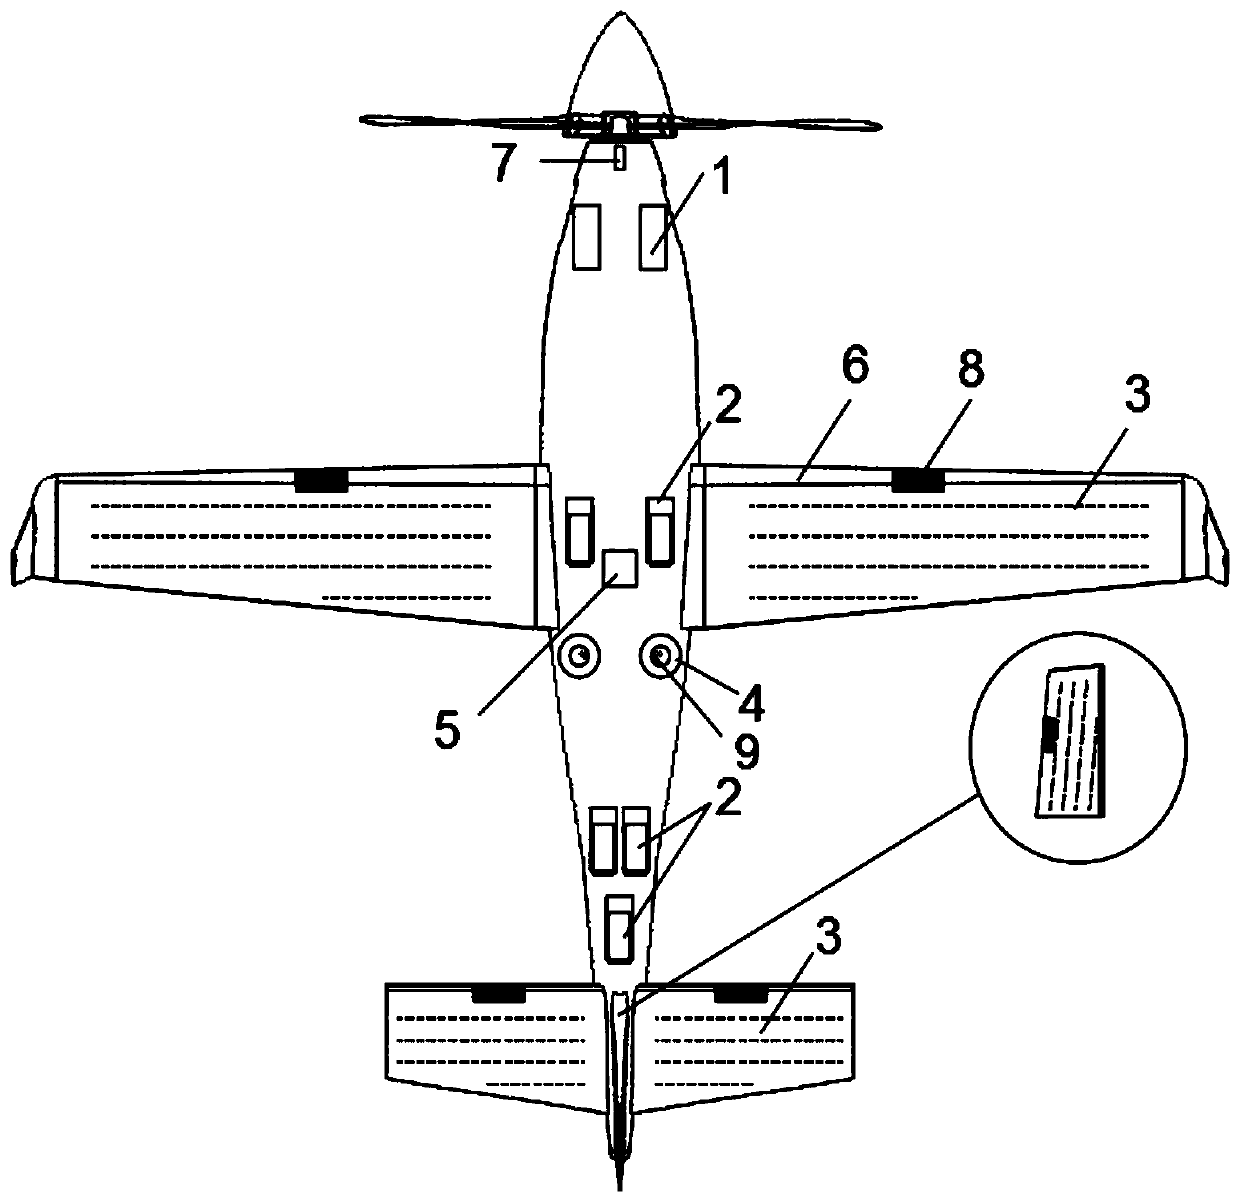
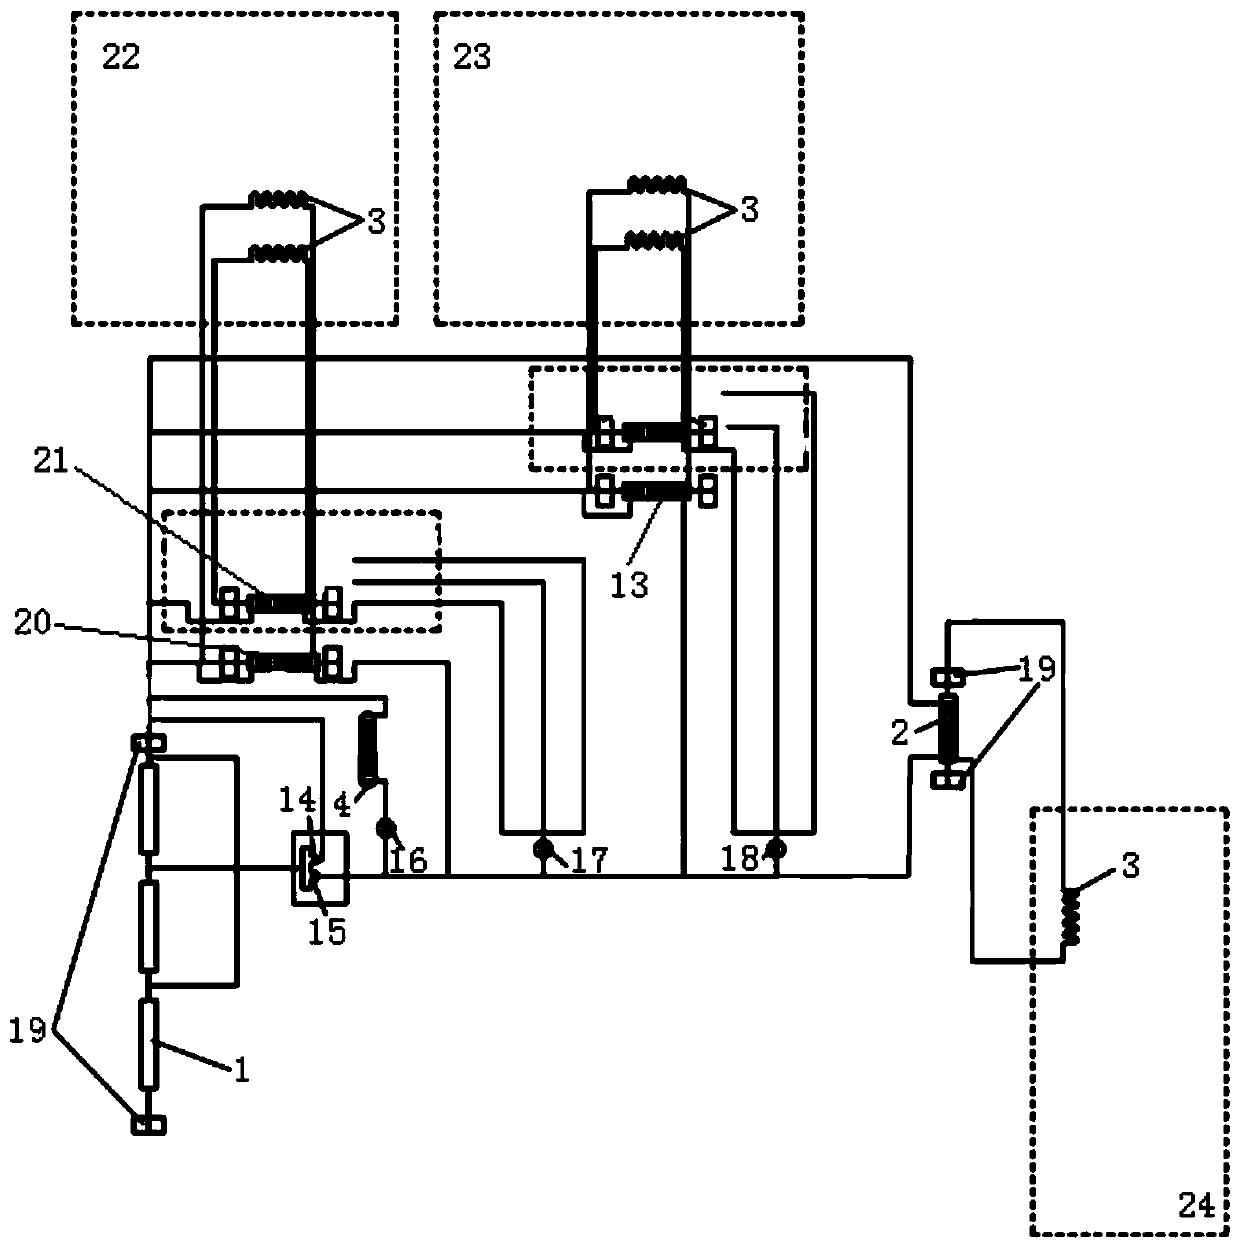
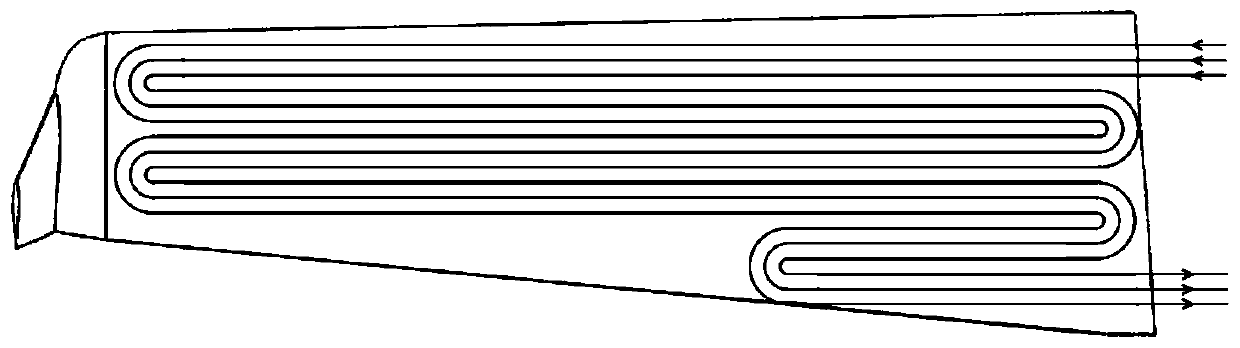
The invention relates to an anti-icing and deicing device and method for wings and emages of a turbo-prop aircraft, the device comprises a system close loop, a TKS fluid reservoir heating loop, an anti-icing and deicing heat transfer loop heat pipe, a distributed loop heat pipe and a TKS deicing mechanism, wherein the system close loop, the TKS fluid reservoir heating loop and a heat transfer loopshare a set of heat transfer evaporator (1), in an anti-icing state, the TKS fluid reservoir heating loop, the anti-icing and deicing heat transfer loop heat pipe and the distributed loop heat pipe work; in a deicing state, the TKS deicing mechanism works. Compared with the prior art, the TKS system deicing efficiency is improved greatly, the icing phenomena of the wings and the emages are reduced, the flight stability of the aircraft is ensured, and the system safety is reliable; waste heat of an exhaust pipe is taken as a heat source, and the energy comprehensive utilization ratio of a single turbo-prop aircraft is improved.
Owner:SHANGHAI UNIV OF ENG SCI
Propeller-driven aircraft cabin noise control design method
ActiveCN111591458AImprove driving comfortSustainable transportationAircraft components testingAviationClassical mechanics
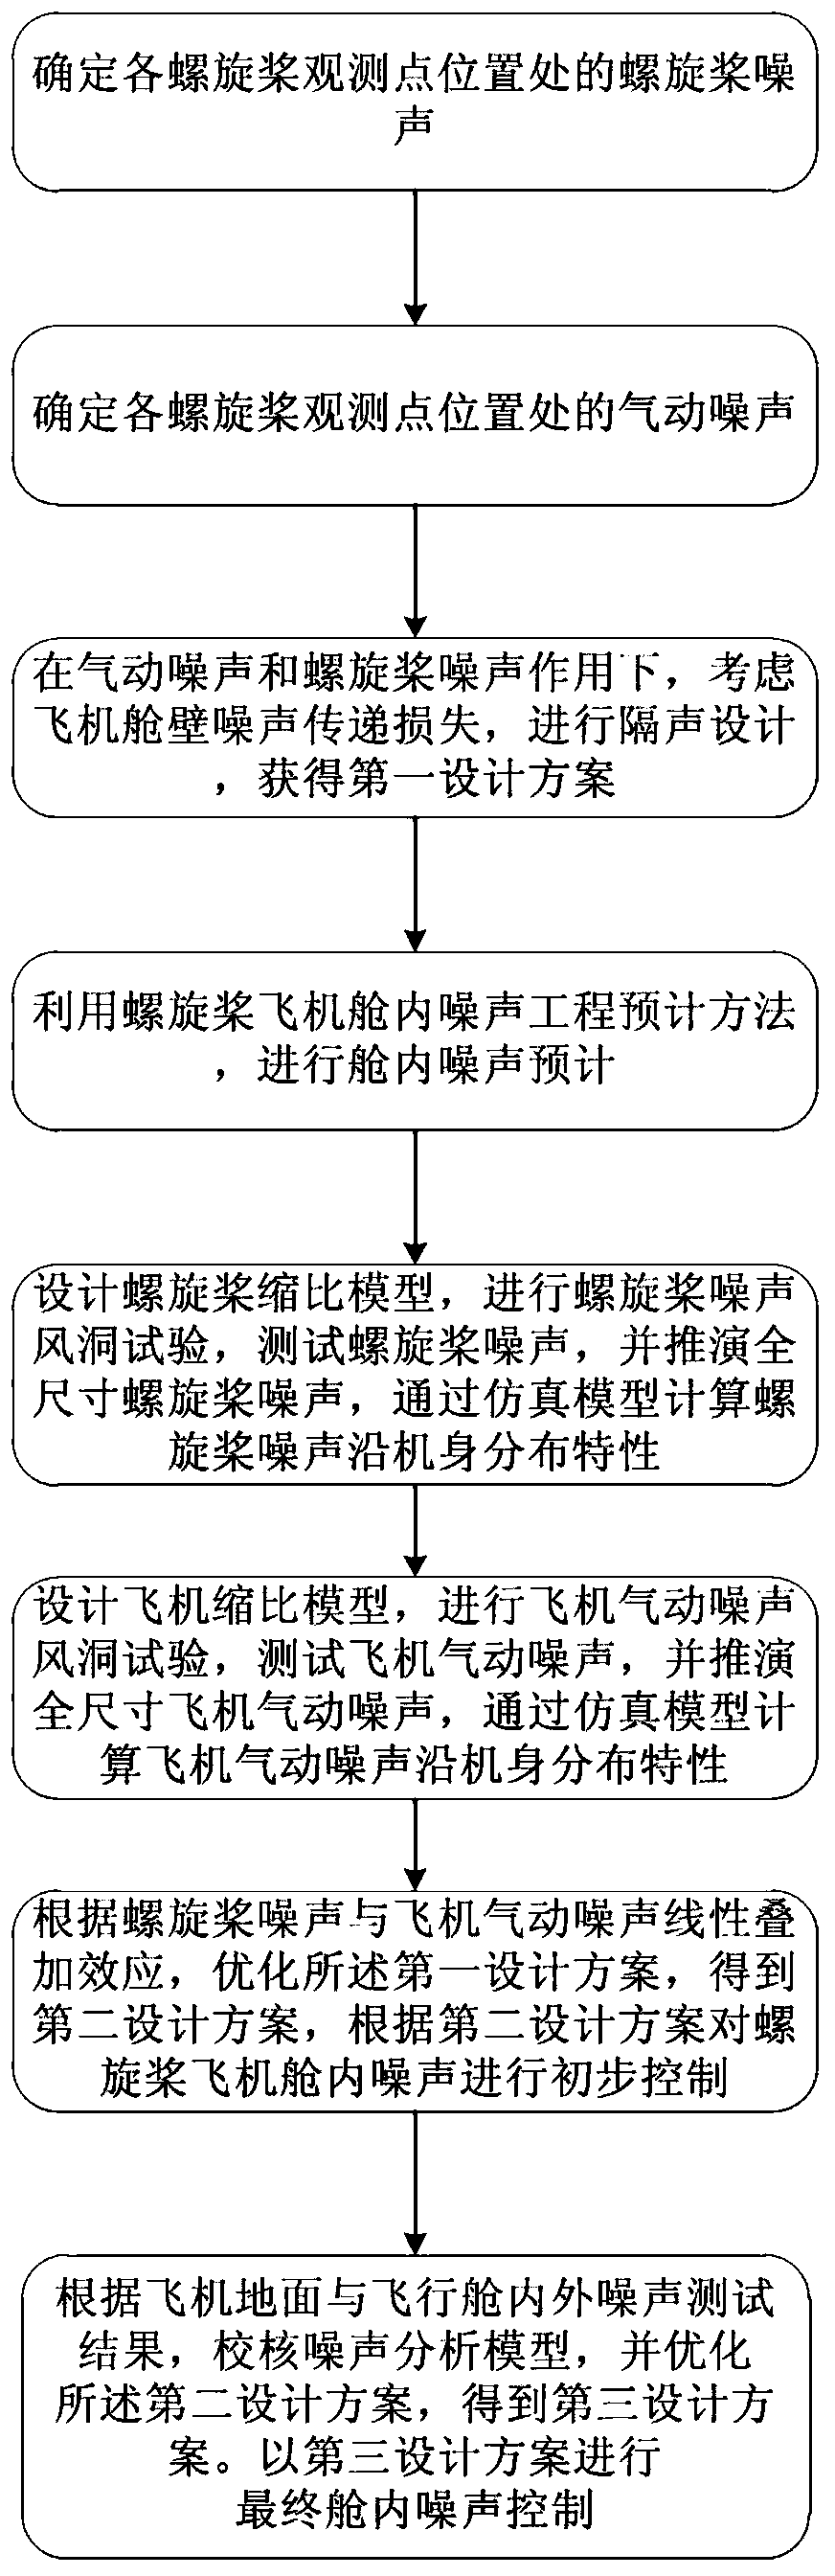
The invention belongs to the technical field of aviation acoustics, and particularly relates to a propeller-driven aircraft cabin noise control design method. The method starts from an aircraft designprocess, propeller noise and aircraft aerodynamic noise are predicted, a noise index in the cabin is demonstrated and preliminary design is carried out; a propeller noise wind tunnel test and an airplane aerodynamic noise wind tunnel test are then carried out, a detailed prediction model is established, simulation calculation is carried out on distribution of propeller noise and aircraft aerodynamic noise along an aircraft body, and on the basis, an aircraft cabin noise detailed model is established, evaluation and optimization design are carried out on a detailed design scheme, ground and flight noise test is carried out on an actual aircraft, the detailed design scheme is further optimized, propeller aircraft cabin noise control design is completed, and the driving and riding comfort ofan aircraft cabin is improved.
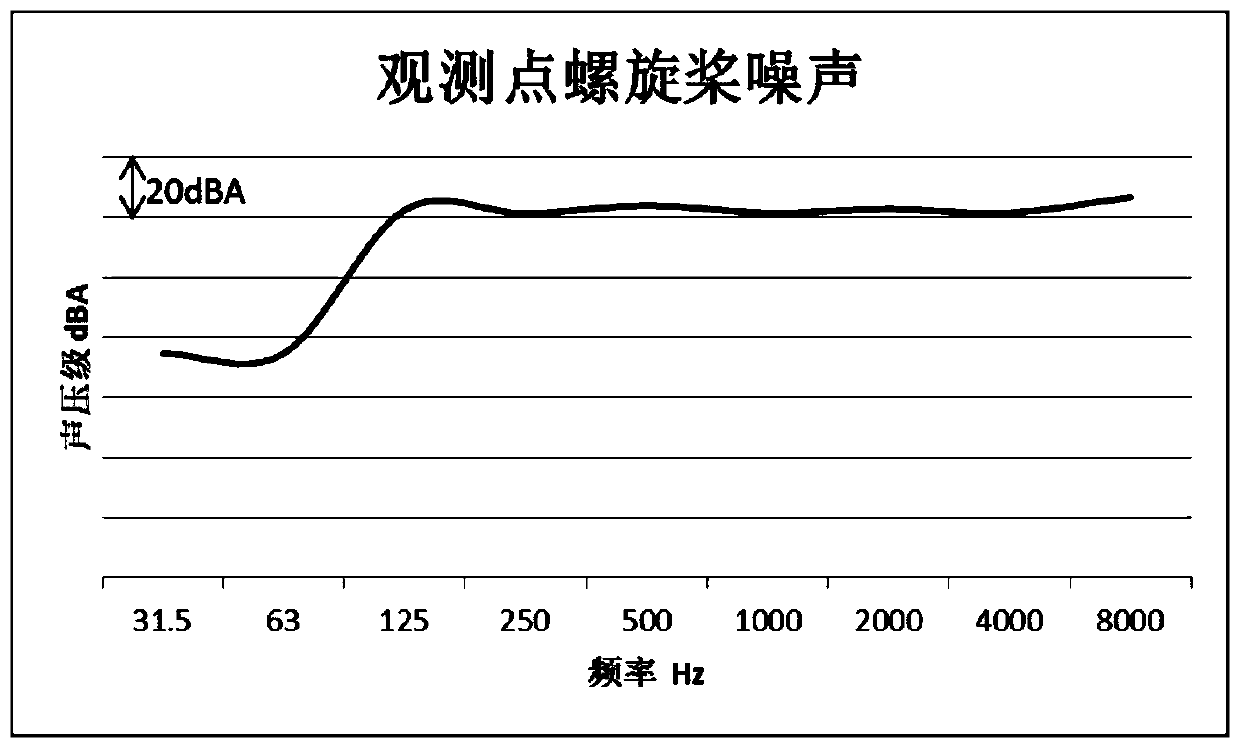
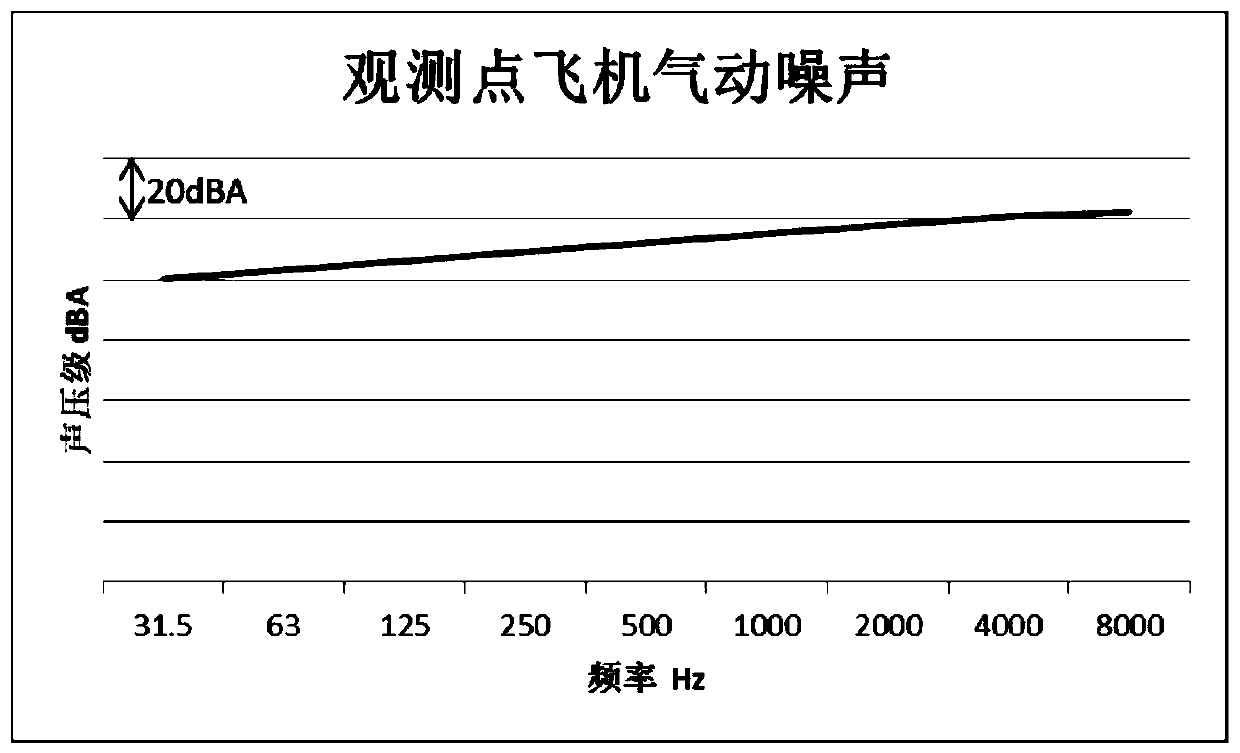
Owner:XIAN AIRCRAFT DESIGN INST OF AVIATION IND OF CHINA +1
Turbo-propeller aircraft power control method
PendingCN110816824ASimplify power control methodOptimize power handlingAircraft power plantsRotocraftPropellerControl theory
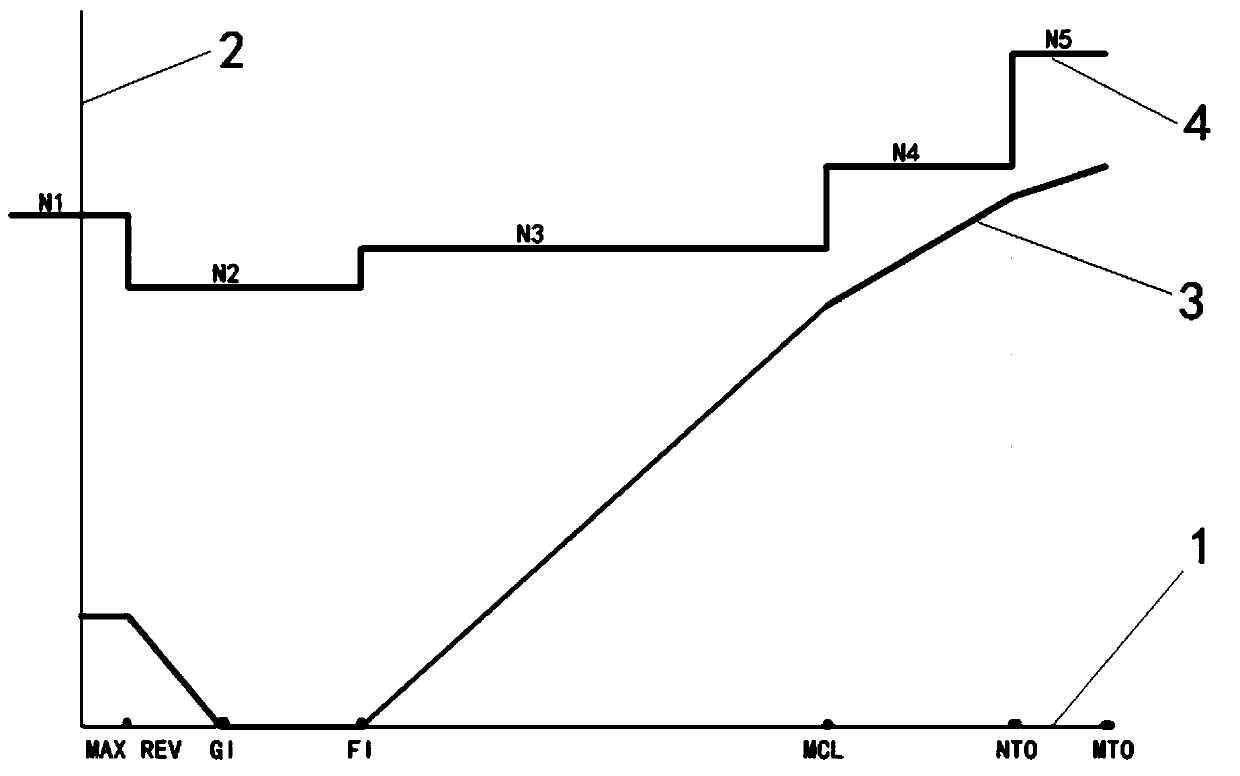
The invention discloses a turbo-propeller aircraft power control method. The turbo-propeller aircraft power control method involves a power rod, a throttle table, an engine controller, a propeller controller, an electromechanical data computer and an atmospheric data computer, wherein the engine power rod is provided with a plurality of control gears in an engine maximum propeller reversing power-to-maximum take off power full-activity stroke, the engine controller controls the working state of an engine, the propeller controller controls the working state of a propeller, the power rod performs control over the engine controller through the throttle table, and the engine controller is in linkage with the propeller controller.
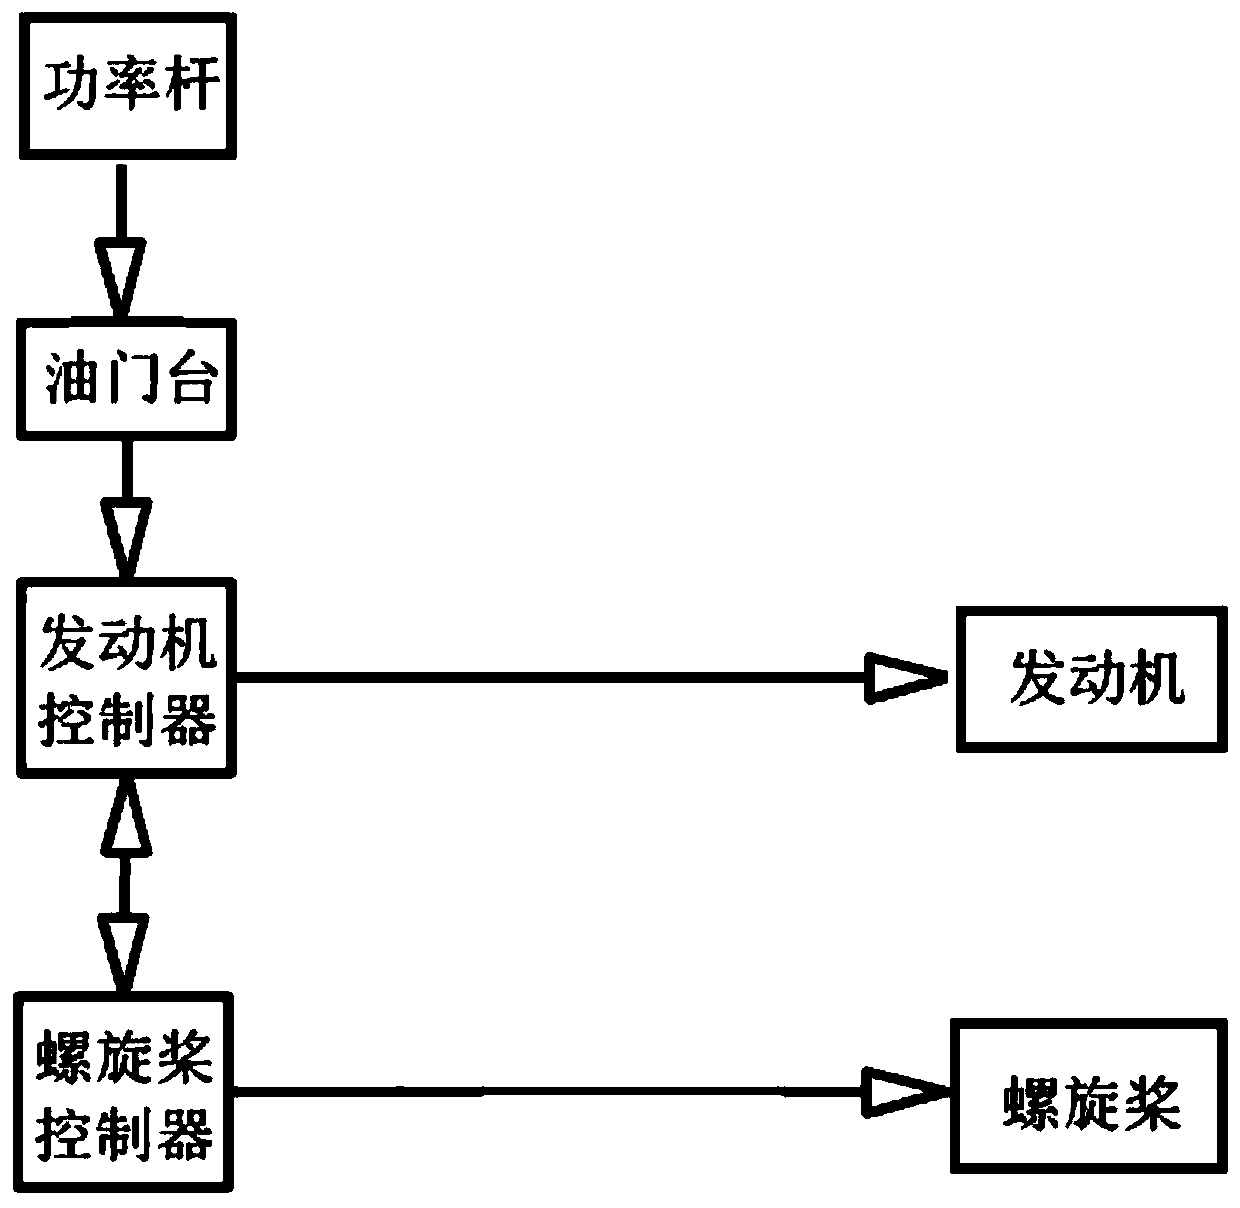
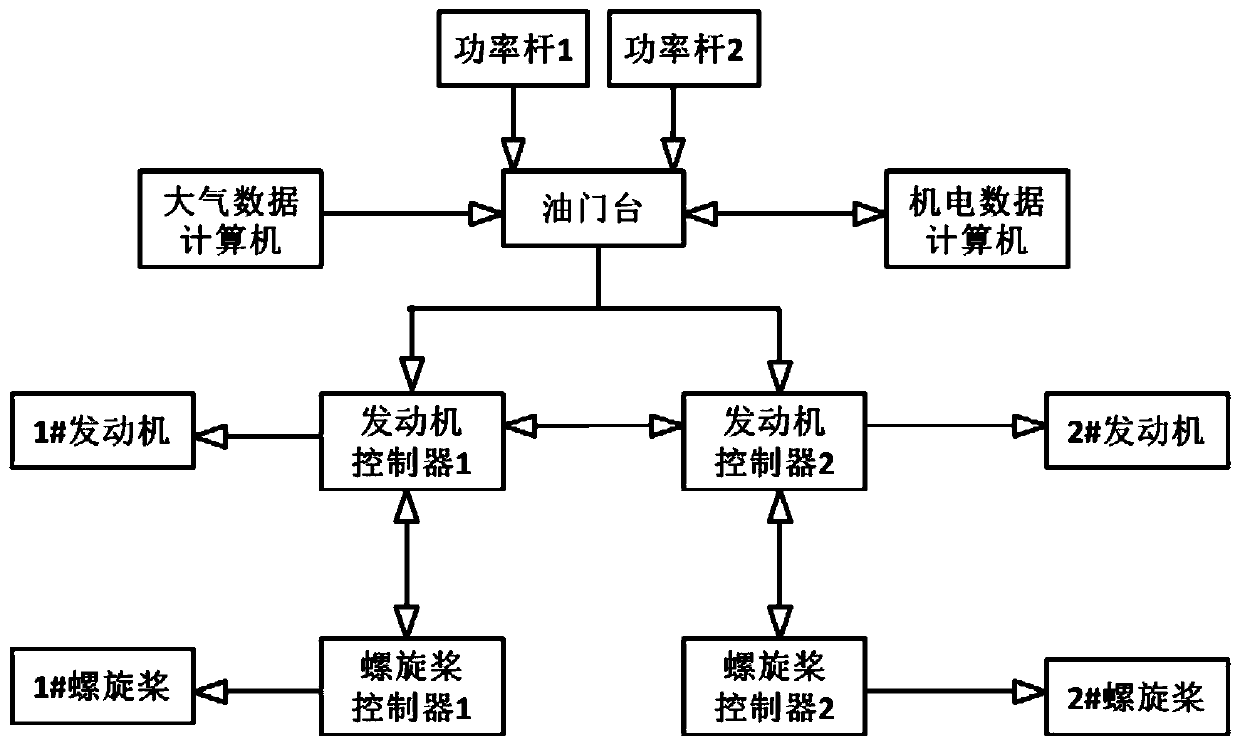
Owner:中航西飞民用飞机有限责任公司
Tilt-prop aircraft
A tilt-prop aircraft is configured to operate in a vertical take-off and landing (VTOL) mode or a forward flight mode by adjusting a tilt angle of a rotor connected to a wing. The tilt-prop aircraft includes: a blade included in the rotor and configured to rotate to produce lift and thrust; and a tilt center shaft configured to connect the rotor and the wing to each other and adjust the tilt angle of the rotor with respect to a flight plane of the tilt-prop aircraft, wherein when the tilt angle of the rotor is adjusted, a pitch angle of the blade is varied by a power transmission unit mechanically interlocked with the tilt center shaft.


Owner:KOREA AEROSPACE RES INST
Propeller aircraft slip flow pre-sensing rudder deflection control method and system
PendingCN114560073AOvercome or mitigate technical deficienciesAircraft controlSustainable transportationControl signalControl system
The invention relates to a propeller aircraft slip flow pre-sensing rudder deflection control method. The method comprises the steps that an interpolation table of rudder deflection control angles of dynamic pressure, attack angles and axial overload under different flap skewness is constructed; obtaining a rudder deflection control angle according to the interpolation table, and generating a corresponding rudder deflection control signal; and connecting the rudder deflection control signal to a rudder control system to control the rudder to deflect. In addition, the invention relates to a propeller-driven aircraft slip flow pre-sensing rudder deflection control system, which comprises a rudder deflection balancing unit, which is internally provided with an interpolation table of rudder deflection control angles of dynamic pressure, attack angle and axial overload under different flap skewness, is connected with flap skewness signals, dynamic pressure signals, attack angle signals and axial overload signals, and is used for controlling the slip flow of a propeller-driven aircraft according to the interpolation table. And a rudder deflection control angle is obtained, a corresponding rudder deflection control signal is output, the rudder deflection control signal is input into a rudder control system, and the rudder is controlled to deflect.


Owner:XIAN AIRCRAFT DESIGN INST OF AVIATION IND OF CHINA
A method for calculating the aerodynamic performance of an aircraft propeller under a wing and nacelle configuration
The present invention discloses a method for calculating the aerodynamic performance of an aircraft propeller in a wing and nacelle configuration, belonging to the field of propeller aerodynamic performance calculation. First, a mathematical model for calculating the aerodynamic performance of the propeller in the wing and nacelle configuration is established; the flow at the propeller tip and root of the established mathematical model is corrected, and the interference effect of the wing and nacelle on the aerodynamic performance of the propeller is considered, and the angle of attack of the blade element is corrected. According to the corrected mathematical model, program development is carried out using Matlab software. This program can quickly and accurately predict the aerodynamic performance of the propeller under the aerodynamic interference of the wing and nacelle, and can provide certain guiding functions for evaluating the structural strength, overall design and performance optimization of the propeller aircraft. The present invention improves the calculation efficiency, saves the calculation cost, and increases the convenience of calculating the aerodynamic performance of the propeller in the installed state.

Owner:NORTH CHINA UNIVERSITY OF TECHNOLOGY +1
Propeller aircraft engine test system and test method
PendingCN114563190ASimple structureReasonable designInternal-combustion engine testingSustainable transportationDrive shaftPropeller
The invention discloses a propeller aircraft engine test system and test method.The system comprises a base, a propeller aircraft engine, a transmission mechanism, a rotating speed and torque measuring mechanism and a sliding mechanism, the sliding mechanism comprises a sliding rail, a base and an electric push rod, and the rotating speed and torque measuring mechanism is a rotating speed and torque sensor; the transmission mechanism comprises a first transmission part and a second transmission part, the first transmission part comprises a first bearing box and a first transmission shaft, and the second transmission part comprises a second bearing box and a second transmission shaft; the method comprises the following steps: 1, mounting a first transmission part; 2, mounting a rotating speed and torque sensor; 3, mounting a second transmission part; 4, propeller installation; and 5, testing the propeller aircraft engine. According to the invention, the performance test of the propeller aircraft engine under the condition of taking the propeller as the load is realized, and the actual working condition of the propeller aircraft engine is simulated more accurately.


Owner:中检西部检测有限公司
Simulation method and device for automatic deceleration of spoiler of medium-sized propeller-driven aircraft, computer equipment and medium
PendingCN121859517AVerify validityGeometric CADDesign optimisation/simulationClassical mechanicsPropeller
The embodiment of the invention provides a simulation method and device for automatic deceleration of a spoiler of a medium-sized propeller-driven aircraft, computer equipment and a medium, and the method comprises the following steps: determining a use scene in which the spoiler of the aircraft needs to be automatically decelerated, according to the use scene of automatic deceleration, flight data needing to be introduced into the simulation system is determined, and the flight data comprises a ground signal, a speed signal, an engine power signal and a spoiler normal working signal; according to the flight data, judging whether an entry condition for starting to use an automatic deceleration function is met, and if yes, unfolding the spoilers on the two sides to the maximum through a simulation system to automatically decelerate the aircraft; and continuously monitoring the flight data until the quit condition of quitting the automatic deceleration function is met, quitting the automatic deceleration, and resetting the double-side spoilers through the simulation system. According to the scheme, a method for automatically decelerating the ground through the spoiler is designed, and the effectiveness of the scheme is verified through simulation.

Owner:SHAANXI AIRCRAFT CORPORATION
Aircraft maneuvering system for single propeller aircraft and single propeller aircraft
A jet aircraft maneuvering characteristic simulation system for a single propeller aircraft includes a power lever, speed brakes, and a controller. The power lever is configured to change a thrust of the single propeller aircraft. The speed brakes are provided on respective right and left sides of the single propeller aircraft. The controller is configured to, in response to an operation of the power lever to raise the thrust of the single propeller aircraft, deploy both the right and the left speed brakes to cause an increase in speed of the single propeller aircraft to be moderate, and control the speed brakes to cause a force in a yaw direction and a force in a roll direction to be generated that act against a turning tendency of the single propeller aircraft by making amounts of the deployment of the right and the left speed brakes different from each other.

Owner:SUBARU CORP
Propeller matching design method and device, electronic equipment and storage medium
The invention provides a propeller matching design method and device, electronic equipment and a storage medium, and relates to the technical field of aviation aircrafts. The method comprises the following steps: acquiring a first design parameter of the distributed electric propulsion propeller-driven aircraft; according to the first design parameter, determining the design resistance of the distributed electric propulsion propeller-driven aircraft and the design thrust of a single propeller corresponding to the design resistance; and determining a third design parameter of the single propeller according to the design thrust of the single propeller and the second design parameter. According to the method, the propeller parameter design efficiency of the distributed electric propulsion propeller aircraft is improved.

Owner:GUILIN UNIV OF AEROSPACE TECH
A method for calculating large-angle glide performance of a fixed-wing turboprop aircraft
The application belongs to the field of aviation medium-sized aircraft design, and relates to a large-angle glide performance calculation method of a fixed-wing turboprop aircraft. The method comprises the following steps: determining the combination characteristics of the power device of the turboprop aircraft according to the characteristics of the turboprop engine and the propeller; increasing the resistance and reducing the lift by using the double-open state of the spoiler, so as to realize large-angle glide; and obtaining the required large-angle glide performance of the aircraft by modeling and adjusting calculation.

Owner:SHAANXI AIRCRAFT CORPORATION
Method for calculating air-slip performance of fixed-wing turboprop aircraft
The invention belongs to the field of flight performance design, and relates to a method for calculating the air-slip performance of a fixed-wing turboprop aircraft. The method comprises the steps that according to the characteristics of a turbine engine and a propeller, the combined characteristics of a propeller aircraft power device are determined, the influence of feathering of the propeller on the aerodynamic characteristics of an aircraft is considered, and the needed aircraft air-slip performance is obtained through modeling and adjustment calculation according to aerodynamic characteristic parameters and weight characteristic parameters of the aircraft.

Owner:SHAANXI AIRCRAFT CORPORATION
Composite material rotor with electrostatic discharge function, preparation method and discharge method
This invention discloses a method for preparing a composite material rotor with electrostatic discharge (ESD) function: 1. Fabricating a composite material rotor, applying adhesive to the surface of the composite material rotor, and attaching ESD material, followed by high-temperature curing, polishing, cleaning, and drying of the ESD material, and then spraying a primer onto the rotor surface; 2. Installing semiconductor protective devices and metal discharge needles on the rotor obtained in step 1, followed by spraying a topcoat onto the rotor surface, and finally drying, polishing, and grinding. This invention also discloses the prepared composite material rotor with ESD function, and a method for performing ESD using the composite material rotor with ESD function. The method for preparing a composite material rotor with ESD function provided by this invention effectively releases the static charge generated by the rotor of a propeller aircraft during high-speed operation, solving the problem of electrostatic discharge damage to aircraft electrical equipment caused by accumulated static charge.

Owner:XIAN AIRBORNE ELECTROMAGNETIC TECH
1. Stand fan; 2. Table fan; 3. Floor fan
1. Pedestal fan made of metal, featuring dark anthracite and smoky gold tones; the design is inspired by vintage propeller airplanes; the base, vertical rod, and outer frame of the fan head are finished in anthracite; the front grid with propeller-style center knob, motor housing, and digital display housing, which also functions as a speed control wheel - are in smoky gold; a single-button digital interface is integrated; the motor housing includes a dedicated area for the “Stylies” brand logo; the fan head has a diameter of 35 cm.; 2. Table fan made of metal, combining dark anthracite and smoky gold finishes; inspired by vintage propeller airplane design; the base, support rod, and outer fan head frame are in anthracite; the front grid features a central propeller-style knob in smoky gold, matching the motor housing and the circular digital control unit, which is integrated into the base plate; the control wheel allows speed adjustment via a single-button interface; the motor housing provides space for the “Stylies” brand logo.; 3. Compact floor fan made of metal in dark anthracite and smoky gold finishes, with a design inspired by vintage propeller airplanes; the fan rests directly on a wide, stable base without a vertical pole; the base features an engraved “Stylies” logo; the outer fan head frame is anthracite, while the front grid with central propeller-style knob and motor housing are smoky gold; speed levels are controlled by a simple rotating knob on the side; manual up-and-down oscillation allows directional airflow adjustment.


Owner:COPLAX
Flight control structure of propeller aircraft mode of electric tilting six-rotor unmanned aerial vehicle
PendingCN121785359AVehicle position/course/altitude controlPosition/direction controlLoop controlClassical mechanics
The invention discloses a flight control system structure of an electric tilting six-rotor unmanned aerial vehicle in a propeller aircraft mode. The flight control system structure is composed of a layered closed-loop architecture composed of outer ring attitude / height (or climbing rate) control and inner ring attitude angular rate control, and an airspeed single-loop control, trajectory guidance and actuator distribution / constraint management module. The flight control system structure of the electric tilting six-rotor unmanned aerial vehicle in the propeller aircraft mode has the remarkable advantages that under the influence of the control surface efficiency changing along with the air speed / attack angle, external disturbance and coupling, the rolling and pitching channel adjusting time is remarkably shortened, and overshoot and steady-state errors can be neglected; the airspeed is kept without overshoot, and the steady-state error is small; the yaw rate response is fast, and the coupling inhibition effect is good; the system structure calculation load is low, parameter calibration is friendly, and robustness is high; the method is suitable for attitude, airspeed and height / climbing rate cooperative control and route autonomous tracking of the electric tilt six-rotor unmanned aerial vehicle in a propeller aircraft mode.

Owner:NANJING YILONG AVIATION IND CO LTD
Aircraft with pusher propeller
Embodiments provide an electric aircraft with a plurality of lift fan assemblies that are configured to provide vertical lift, and one or more pusher propellers that are configured to provide forward thrust. The lift fan assemblies may be coupled to the wings of the aircraft via one or more support structures, and the wings may be coupled to an upper region of the fuselage. The pusher propeller(s) may be coupled to a tailing end of the fuselage. The lift fan assemblies and the pusher propeller(s) may provide thrust and movement in directions that are orthogonal to one another. A control system coupled to the aircraft may control the lift fan assemblies and the one or more pusher propellers to activate, increase in power, and decrease in power. The lift fan assemblies and the one or more pusher propellers may be operated separately, and may be active at different times.

Owner:WISK AERO LLC
Simulation method and device for fault of horizontal stabilizer of medium-sized propeller-driven aircraft, computer equipment and medium
The embodiment of the invention provides a simulation method and device for a fault of a horizontal stabilizer of a medium-sized propeller-driven aircraft, computer equipment and a medium, and the method comprises the following steps: setting a fault mode of the horizontal stabilizer, and setting a deflection rate proportion and control surface target skewness; the control surface skewness of each horizontal stabilizer is output through a control surface actuator model; estimating six-component aerodynamic parameters of the single horizontal stabilizer; when the fault mode is trim rudder shifting, the lift coefficient and the pitching moment coefficient of the six-component aerodynamic parameters are corrected; according to the control surface skewness and the six-component aerodynamic parameters of each horizontal stabilizer, the state parameters of the airplane at the next moment are obtained through simulation calculation of the state parameters of the airplane at the previous moment by means of the airplane six-degree-of-freedom simulation calculation model. According to the scheme, through the fault simulation of the horizontal stabilizer, the authenticity of the command response of the horizontal stabilizer of the airplane is improved.

Owner:SHAANXI AIRCRAFT CORPORATION
Propeller-driven aircraft wing and propeller-driven aircraft
The invention belongs to the field of aircraft aerodynamic design, and particularly relates to a propeller-driven aircraft wing and a propeller-driven aircraft. In a first aspect, for a propeller-driven aircraft wing, a droop is provided at a leading edge portion of the wing at its wash-up zone; in the second aspect, the aircraft with the propellers rotating in the same direction comprises wings on the left side and the right side, and drooping parts of front edge parts of the wings on the left side and the right side are asymmetrically distributed. According to the propeller-driven aircraft wing and the propeller-driven aircraft, a left wing flow field and a right wing flow field generated by homodromous rotation of propellers on two sides are asymmetric; the leading edge of the wing within a certain range on one side of the propeller-driven aircraft washing area is drooped linearly, so that the standing point line of the leading edge of the wing moves downwards, the surface speeds ofthe leading edge wing and the nacelle are reduced, the whole aircraft resistance of the aircraft is reduced, the lift-drag ratio of the propeller-driven aircraft is increased, and the performance ofthe propeller-driven aircraft is improved.


Owner:XIAN AIRCRAFT DESIGN INST OF AVIATION IND OF CHINA
Composite material rotor wing with electrostatic discharge function, preparation method and discharge method
The invention discloses a preparation method of a composite rotor wing with an electrostatic discharge function, which comprises the following steps of: 1, manufacturing the composite rotor wing, coating glue on the surface of the composite rotor wing, pasting an electrostatic discharge material, curing the electrostatic discharge material at high temperature, polishing, cleaning and drying, and spraying primer on the surface of the rotor wing; and 2, a semiconductor protection device and a metal spray point are installed on the rotor wing obtained in the step 1, then finish paint is sprayed to the surface of the rotor wing, and finally drying, polishing and grinding treatment are conducted. The invention further discloses the prepared composite material rotor wing with the electrostatic discharge function and a method for conducting electrostatic discharge by means of the composite material rotor wing with the electrostatic discharge function. According to the preparation method of the composite material rotor wing with the electrostatic discharge function, electrostatic charges generated by the rotor wing of a propeller aircraft in high-speed work are well released, and the problem that electrical equipment of the aircraft is damaged by deposition electrostatic discharge caused by electrostatic charge accumulation is solved.

Owner:XIAN AIRBORNE ELECTROMAGNETIC TECH
Method and device for calculating noise in cabin of electric propeller aircraft
PendingCN114282300AEasy to compareEasy to optimizeGeometric CADDesign optimisation/simulationSound sourcesNacelle
The invention discloses a method and a device for calculating noise in a cabin of an electric propeller aircraft. According to the method, a cabin three-dimensional geometric model is established according to structural parameters of the electric propeller aircraft, grid division is carried out on the cabin three-dimensional geometric model, and grids are divided into structural grids, acoustic grids and acoustic envelope surface grids; propeller noise is equivalent to a fan sound source, corresponding material and physical property parameters are set as boundary conditions for calculating in-cabin noise, a sound-vibration coupling surface is established, data between a structural grid and an acoustic grid are mutually mapped, the in-cabin noise is calculated, field points are arranged in an aircraft in-cabin model, and the in-cabin noise is calculated. According to the method, the total sound pressure levels of the frequency doubling time field points of the propellers at different rotating speeds are calculated respectively, the sound pressure cloud atlas of the sound field in the cabin is obtained, the noise in the aircraft cabin can be calculated quickly, simply and conveniently, comparison and optimization of various noise reduction schemes are facilitated, the design period is greatly shortened, and the cost is reduced.


Owner:SHENYANG AEROSPACE UNIVERSITY
Flight control structure of electric tilting six-rotor unmanned aerial vehicle in helicopter mode
PendingCN121785360AVehicle position/course/altitude controlPosition/direction controlProportional integral differentialAttitude control
The electric tilting rotorcraft has three flight modes including a helicopter mode, a tilting transition mode and a propeller aircraft mode, and flight of the three modes is achieved through a flight control system. The invention discloses a special flight control system structure of an electric tilting six-rotor unmanned aerial vehicle in a helicopter mode, and solves the problems of insufficient robustness, low attitude control precision, response lag and the like of traditional PID control (proportional-integral-derivative control) under ground effect interference. The structure adopts an instruction input-double loop control-control distribution-feedback correction closed loop architecture, an outer loop dynamically optimizes parameters through a fuzzy-PID controller, an inner loop ensures rate response through traditional PID control, and control distribution is realized based on an electric tilt rotor configuration. The flight control system structure is suitable for vertical take-off and landing, hovering, low-speed flight, attitude control and the like of the electric tilting six-rotor unmanned aerial vehicle in a helicopter mode.

Owner:NANJING YILONG AVIATION IND CO LTD
Simulation method and device for aileron fault of medium-sized propeller-driven aircraft, computer equipment and medium
PendingCN121859522AGeometric CADAircraft health monitoring devicesComputational modelMechanical engineering
The embodiment of the invention provides a simulation method and device for aileron faults of a medium-sized propeller aircraft, computer equipment and a medium, and the method comprises the following steps: setting fault modes of ailerons, and setting a deflection rate proportion and control surface target skewness for each fault mode of the ailerons; the control surface skewness of each aileron is output through a control surface actuator model; estimating six-component aerodynamic parameters of a single aileron through the three-component aerodynamic parameters of the whole aileron; performing propeller slip flow asymmetric correction on the six-component aerodynamic parameters to generate asymmetric six-component aerodynamic parameters; according to the control surface skewness and the asymmetric six-component aerodynamic parameters of each aileron, the state parameters of the airplane at the next moment are obtained through simulation calculation of the state parameters of the airplane at the previous moment by means of the six-degree-of-freedom simulation calculation model of the airplane. According to the scheme, through analog simulation of the aileron fault, the problems that an existing aileron fault model is rough, and consistency of theoretical simulation and a real airplane model is poor are solved.

Owner:SHAANXI AIRCRAFT CORPORATION
Tilt prop aircraft
A tilt prop aircraft is provided, including a first longitudinal support member and a second longitudinal support member capable of tilting relatively to each other, a tilt actuator disposed on the second longitudinal support member, a first power transmission member rotated by the tilt actuator, a second power transmission member fixed to the first longitudinal support member and coupled to the first power transmission member to transmit a rotational movement of the first power transmission member by turning 90 degrees in different planes, a crank fixed to the second longitudinal support member and extending through a slot in the first longitudinal support member and protruding inwardly from the first longitudinal support member, and a connecting rod connected to the crank so as to be relatively rotatable to the crank, and connected to the pitch control rod.

Owner:KOREA AEROSPACE RES INST
A method for determining the parameters of a single-layer wallboard noise index of a propeller aircraft
The application relates to a propeller airplane single-layer wallboard noise index parameter decomposition determination method, which comprises the following steps: step one, calculating the critical frequency of the single-layer wallboard; step two, calculating the sound transmission loss based on the critical frequency of the single-layer wallboard; step three, calculating the single-layer wallboard surface turbulent boundary layer noise; step four, calculating the near-field noise of the propeller distributed along the single-layer wallboard; step five, calculating the propeller airplane cabin noise by using the sound transmission loss of the single-layer wallboard, the single-layer wallboard surface turbulent boundary layer noise and the near-field noise of the propeller distributed along the single-layer wallboard; and step six, if the propeller airplane cabin noise cannot meet the cabin noise index requirement, adjusting the single-layer wallboard structure and material parameters, optimizing the single-layer wallboard structure and material parameters, and then performing steps one to five again until the propeller airplane cabin noise meets the cabin noise index requirement, so as to obtain the sound transmission loss of the single-layer wallboard and the structure and material parameters.

Owner:XIAN AIRCRAFT DESIGN INST OF AVIATION IND OF CHINA
Aircraft aerodynamic characteristic calculation method
The invention provides an aircraft aerodynamic characteristic calculation method, and the method comprises the steps: building an isolated rotary wing CFD calculation model and an isolated rotary wing volume force source item database, and determining an isolated rotary wing volume force source item reduced-order model; an agent model of the modal coefficient of the isolated rotor volume force source item reduced-order model is established, isolated rotor volume force source items are reconstructed, the reconstructed isolated rotor volume force source items serve as source items of CFD calculation models of other aircraft components, the aerodynamic characteristics of the aircraft are obtained through calculation, and the isolated rotor is a propeller or a rotor. Through the method, the aerodynamic characteristic calculation speed of the propeller aircraft and the tilting rotor aircraft under the consideration of aerodynamic interference can be improved, the calculation time can be shortened, and the calculation precision is high.

Owner:CHINA HELICOPTER RES & DEV INST
a propeller plane
ActiveCN107697269BReduce weightImprove stabilityPower plant cooling arrangmentsAircraft power plant componentsNacelleClassical mechanics
The invention relates to the technical field of aerodynamic layout of a twin-engine propeller aircraft, in particular to a propeller aircraft. It includes: two engine nacelles (1), two main landing gear compartments (7) and two main landing gears (8). The wing (2) adopts an upper monoplane layout, which increases the ground clearance of the propeller tip and facilitates the arrangement of the engine nacelle (1). The environmental control liquid cooling inlet (4) is the combination of the environmental control liquid cooling and the engine lubricating oil air inlet into one, so as to improve the aerodynamic efficiency. The main landing gear compartments (7) are respectively arranged at the lower ends of the two engine nacelles (1), which solves the difficulty in storing the main landing gear (8) and the loss of the structural strength of the fuselage caused by the large occupation of space. The deflection nozzle (9) rear portion that is installed in the propeller engine (5) afterbody deflects 5 ° to 20 ° downwards along the axis, effectively avoiding the jet flow of the engine from hitting the flap (10). The structure of the invention has good bearing characteristics, light weight and good overall rigidity characteristics.


Owner:XIAN AIRCRAFT DESIGN INST OF AVIATION IND OF CHINA
Reverse thrust in multi-engine propeller aircraft
Herein provided are methods and systems for producing reverse thrust in a multi-engine propeller aircraft, comprising: obtaining, at a first engine controller of a first engine of the aircraft, a first power request for the first engine for producing reverse thrust; determining, at the first engine controller, a first blade angle for a first propeller coupled to the first engine; obtaining, at thefirst engine controller and from a second engine controller of a second engine of the aircraft, a second power request for the second engine and a second blade angle for a second propeller coupled tothe second engine; and when the second power request is indicative of a request for producing reverse thrust and when the first and second blade angles are beyond a predetermined threshold, commanding, via the first engine controller, the first engine to produce reverse thrust based on the first power request.


Owner:PRATT & WHITNEY CANADA CORP
Design method and device of fully movable horizontal tail for ultra-low-speed tail-wheel propeller aircraft
The present invention discloses a method and device for designing a fully movable horizontal tail for an ultra-low-speed tail-type propeller aircraft. The method comprises: S1, formulating a criterion for determining longitudinal control characteristics; S2, selecting an initial design base airfoil based on a low-speed symmetrical airfoil and trade-off factors; S3, designing a fully movable horizontal tail based on the initial design base airfoil; S4, determining the deflection angle range of the fully movable horizontal tail, calculating the trim angle of the horizontal tail at different cruise angles of attack, and determining whether sufficient control margin remains after trimming. If not, execute S2; if so, execute S5; S5, calculating the longitudinal control characteristics of the aircraft based on the fully movable horizontal tail, determining whether the longitudinal control characteristics meet the longitudinal control characteristics determination criterion; if not, execute S2; if so, terminate the design and determine the parameters of the fully movable horizontal tail. The present invention minimizes the structural weight of the aircraft while ensuring that the aircraft has good longitudinal maneuverability and stability.

Owner:CHINA ACAD OF AEROSPACE AERODYNAMICS
A high Reynolds number single propeller aerodynamic force measurement test device and its measurement method
The present invention discloses a high Reynolds number single propeller aerodynamic force measurement test device and its measurement method, belonging to the field of wind tunnel tests. It includes a rotating shaft balance, an extension shaft body, a torque sensor, a turbine air motor, a motor mounting seat and a strut. The propeller model is connected to the rotating shaft balance, the rotating shaft balance is connected to the torque sensor through the extension shaft body, the torque sensor is connected to the turbine air motor, the strain gauge measures the blade bending moment of the propeller model, the rotating shaft balance measures the aerodynamic force of the propeller model, and the torque sensor monitors the output shaft torque of the turbine air motor. The measurement method: Install the test device of the present invention into the test section of the pressurized wind tunnel, utilize the pressurized wind tunnel, by increasing the internal pressure of the wind tunnel, increase the density of the test flow field, thereby increasing the test Reynolds number, so as to realize the slipstream test of the high Reynolds number propeller aircraft. The present invention improves the accuracy of the propeller model wind tunnel test while reducing the test cost.

Owner:CHINA AVIATION IND CORP HARBIN AERODYNAMICS RESEARCH INSTITUTE