
Patents
Literature
62results about How to "Reduce search volume" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
System and method for locating a target and guiding a vehicle toward the target
InactiveUS6910657B2Reduce search volumeExact referenceDirection controllersRoad vehicles traffic controlEngineeringVehicle guidance


Owner:RAYTHEON CO
Method and device for splicing strip of airborne laser scanning system
InactiveCN104992074ARealize splicingAvoid mismatchSpecial data processing applicationsPattern recognitionPoint cloud
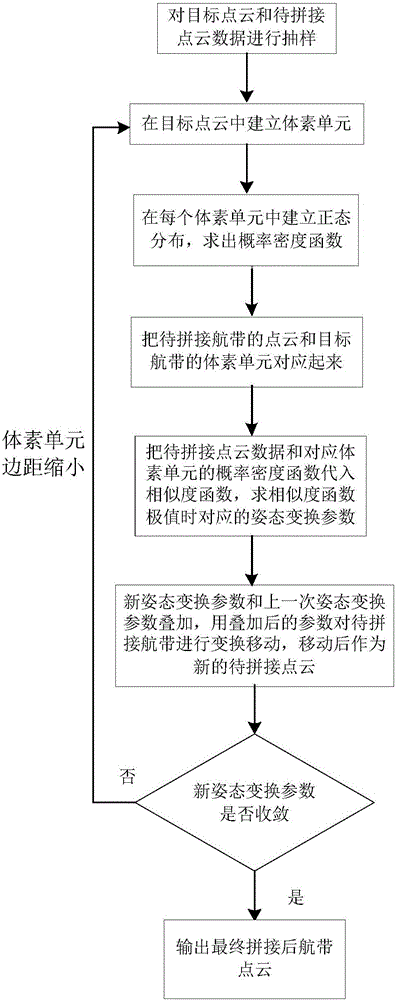
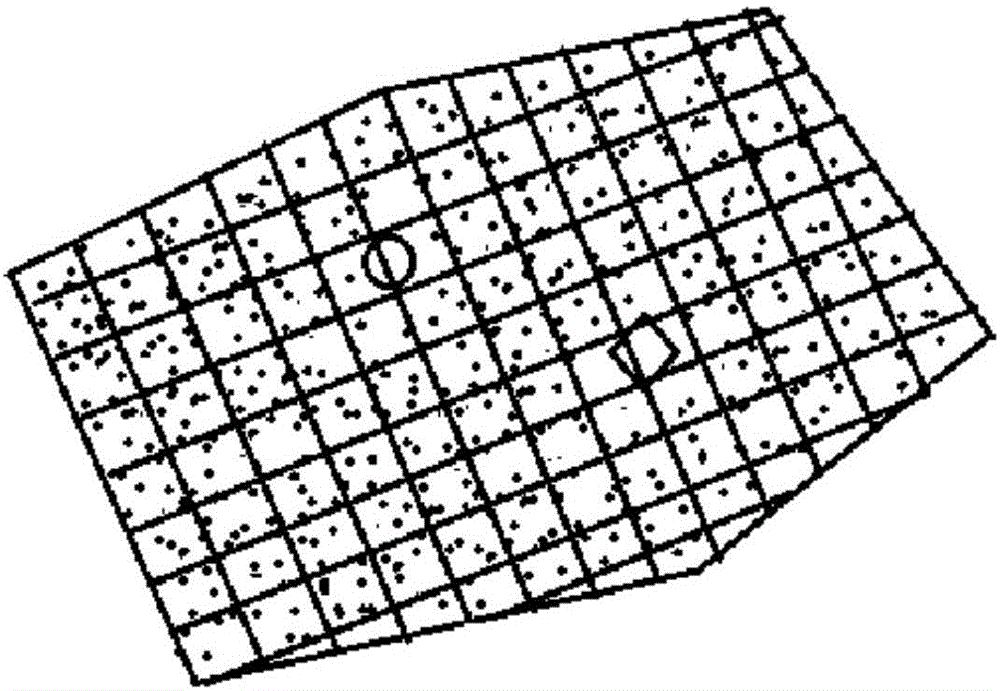
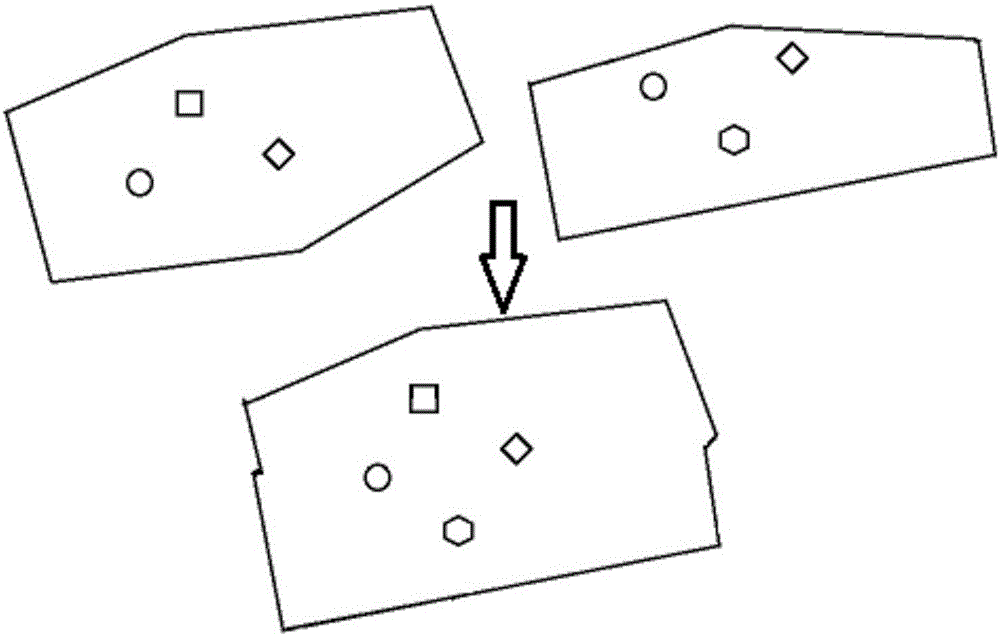
The invention discloses a method and a device for splicing strips of an airborne laser scanning system. The method comprises: using a three-dimensional normal distribution transformation algorithm as a splicing algorithm in strip splicing, dividing voxel units in point cloud data of the airborne laser scanning system, establishing normal distribution in the voxel units, mean values and variance of the normal distribution representing characteristics of the voxel units; and then establishing a similarity function, and obtaining offset of strips when value of the similarity function is maximum; and adjusting adjacent strips according to the offset, to finally splice a plurality of strips together. In addition, through contrast experiment analysis, methods and parameters on three aspects of sample rate before strip splicing, data organization method in a strip splicing process, and discretization are selected to be more proper. The method has higher robustness, shorter splicing time, and better splicing precision, and memory utilization rate of a computer is lower.
Owner:SOUTH CHINA UNIV OF TECH
Method, device and server for obtaining user behavior
InactiveCN106599107AGet behaviorEasy to implementSpecial data processing applicationsWeb data retrieval using information identifiersData miningServer-side
The present disclosure relates to a method, device and server for obtaining a user behavior. The method for obtaining a user behavior comprises: receiving a trigger request from a client, and generating identification information for the trigger request, the identification information being associated with user information; recording and storing logs associated with all trigger requests; and analyzing the logs according to the identification information to obtain a user behavior. In embodiments of the present disclosure, a user behavior can be obtained by generating, by a server side, identification information for a trigger request and analyzing logs associated with all trigger requests according to the identification information, so the user behavior can be still tracked when a user deletes cookie.


Owner:BEIJING XIAOMI MOBILE SOFTWARE CO LTD
Timeliness and face quality considered filtering selection method and system
ActiveCN106295585AReduce invalid storageReduce search volumeImage enhancementImage analysisFeature extractionImaging quality
The invention provides a timeliness and face quality considered filtering selection method and system. The filtering selection method comprises a receiving step, a feature extracting step, a quality scoring step, a quality rating step, a judging step, a storing step and a returning step. The timeliness and face quality considered filtering selection method provided by the invention has the beneficial effects that the filtering selection method adopts a supervised machine learning method based on real mass data to obtain a fuzzy evaluation standard of face image quality which is convenient for a machine to effectively retrieve, and in a certain period of time, a method to quickly decide and select high quality images is provided, which can reduce the invalid storage and search volume under the mass data; and a cascade configuration method is provided for rapid filter selection, which considers both the timeliness and image quality, and also improves the flexibility.

Owner:SHENZHEN INTELLIFUSION TECHNOLOGIES CO LTD
Video shooting anti-shaking method based on mobile apparatus GPU and angular velocity sensor
InactiveCN104869310ANarrow searchReduce the burden onTelevision system detailsColor television detailsComputer graphics (images)Angular velocity
The invention discloses a video shooting anti-shaking method based on a mobile apparatus GPU and an angular velocity sensor. The method comprises following steps: collecting and acquiring angular velocity data through the angular velocity sensor; integrating the collected angular velocity data so as to obtain preliminary prediction information of inter-frame and intra-frame motion directions and angles; further predicting inter-frame motions according to the preliminary prediction information of the inter-frame motion directions and angles so as to obtain final prediction information of the inter-frame motion directions and angles, and giving correction terms back; performing filtering processes according to the preliminary prediction information and the correction terms of the inter-frame motion directions and angles, and giving inter-frame motion compensation items back; and performing rotation transformation on each pixel of each frame image according to the compensation terms and the preliminary prediction information of the inter-frame motion directions and angles, removing rolling shutter effects and performing motion compensation so as to obtain final frame images. By employing the method, the rolling shutter effects can be removed, motion compensation is achieved, burdens of the GPU are reduced, and excellent video anti-shaking effects are achieved.


Owner:成都平行视野科技有限公司
Natural language search results for intent queries
ActiveCN105359144AQuality improvementSearch result reductionNatural language data processingSpecial data processing applicationsDocumentationData store
Systems and methods provide natural language search results to clearintent queries. To provide the natural language search results, a system may parse a document from an authoritative source to generate at least one headingtext pair, the text appearing under the heading in the document. The system may assign a topic and a question category to the heading-text pair and store the heading-text pair in a data store keyed by the topic and the question category. The system determines that a query corresponds to the topic and the question category, and provides the heading-text pair as a natural language search result for the query. In some implementations, the text portion of the heading-text pair may be a paragraph or a list of items and the natural language search result may be provided with conventional snippet-based search results in response to the query.


Owner:GOOGLE LLC
Method for downloading software by cell phone
InactiveCN101076164AReduce search volumeImprove search speedRadio/inductive link selection arrangementsMessaging/mailboxes/announcementsShort Message ServiceSoftware engineering
The method comprises: mobile phone user edits the keyword of software name or keyword of mobile phone brand or model and sends the edited keyword to a short message special service number; according to the received keyword, the inquiry system of short message service returns the download address of the Wap Push custom software or the serial numbers of several hot software programs capable of being supported by the user's mobile phone to the user's mobile phone; the mobile phone user can selects one from said several hot software programs to download.

Owner:CHINA MOBILE GRP FUJIAN CO LTD
Intelligent inquiry and dialup software system used for embedded equipment and implementation method thereof
InactiveCN102184252AEasy to understandReduce the burden onSubstation equipmentCommerceSoftware systemEmbedded system
The invention provides an intelligent inquiry and dialup software system used for embedded equipment and an implementation method thereof. The method comprises the following steps of: establishing a database which contains the business information of a plurality of cities at a server end; and loading and storing the business information of a region selected by a user by networking the embedded equipment to the server end. The inquiry method comprises the following steps of: inputting a numeric string representing a specific character on a dialup interface of an embedded server; and automatically searching and displaying the business information partially or completely matching with the character on the dialup interface so that the user can directly select and call to contact a required business on the dialup interface. The implementation method provided by the invention has convenience and rapidness, and is applied widely.


Owner:GUANGZHOU JIUBANG DIGITAL TECH
Face recognition method and device capable of protecting privacy
ActiveCN112200133AEnsure safetyReduce search volumeCharacter and pattern recognitionDigital data protectionPattern recognitionCiphertext
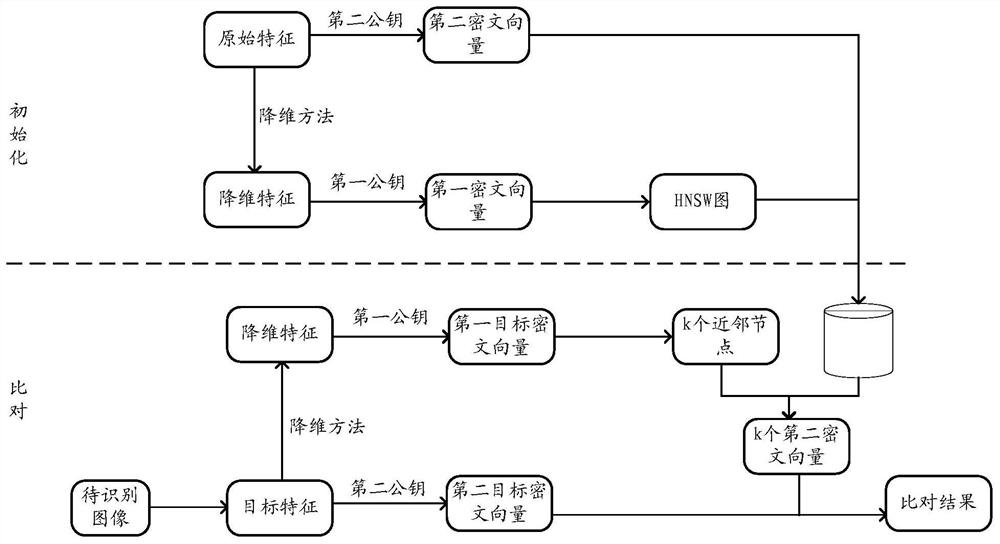
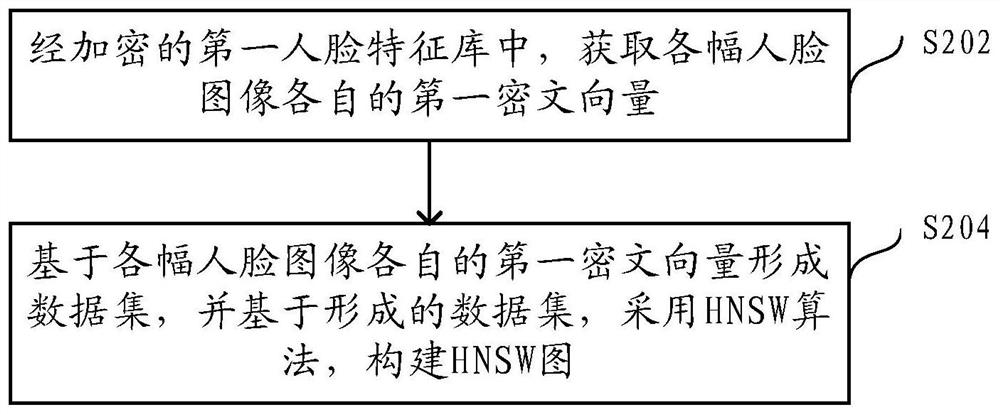
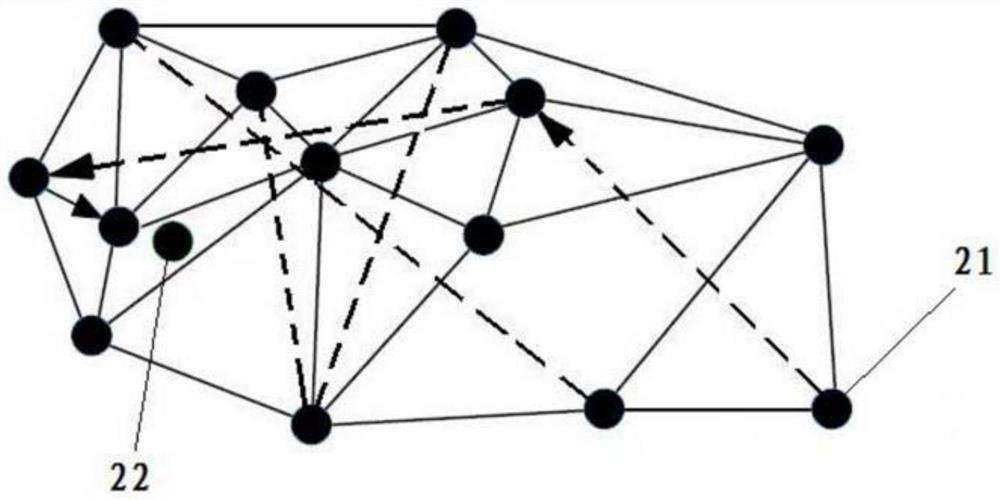
The embodiment of the invention provides a privacy-protecting face recognition method and device, and the method comprises the steps: obtaining a layered navigable small-world HNSW graph; and obtaining target features of a to-be-recognized face image, and performing the first dimension reduction on the target features to obtain dimension reduction features; performing homomorphic encryption on thedimension reduction feature by adopting the first public key to obtain a first target ciphertext vector; performing homomorphic encryption on the target feature by using a second public key to obtaina second target ciphertext vector; starting from the topmost NSW of the multi-layer NSW, performing layer search on each layer of NSW according to a sequence from top to bottom until k neighbor nodesof the first target ciphertext vector are searched from the N nodes in the bottommost NSW; obtaining respective second ciphertext vectors of the k face images represented by the k neighbor nodes froman encrypted second face feature library; and comparing the second target ciphertext vector with respective second ciphertext vectors of the k face images to determine a comparison result of the to-be-recognized face image.
Owner:ALIPAY (HANGZHOU) INFORMATION TECH CO LTD
Operation and maintenance monitoring and solution integrated management system and method
ActiveCN105119761ARealize precise monitoringAbility to quickly process and solve problemsData switching networksMessage queueOpen source
The invention discloses an operation and maintenance monitoring and solution integrated management system and a method. The system comprises an open source monitoring system, a message queue, a background server and a database. The open source monitoring system is used for monitoring a server in real time and judging whether to give a warning and the type of the warning. The open source monitoring system calls a warning medium and sends warning information to the message queue. The background server judges the type of the message ordered from the message queue. When the type of the ordered message is problem triggering, the background server records manual operation to be performed on the server where a problem occurs and stores the manual operation which has been performed, and informs technical staff that there is a problem to be solved at the same time; when the type of the ordered message is problem solving, the background server stops the recording and stores the manual operation which has been stored into the database, and informs the technical staff that the problem has been solved. According to the invention, problems of the server can be rapidly positioned and resolved. The operation and maintenance cost is low, the efficiency is high and the abilities of technical staff to resolve problems are rapidly increased.


Owner:CHENGDU STARCOR INFORMATION TECH
Digital signal transmission method and system based on multi-carrier pseudorandom sequence
ActiveCN101827059AExcellent search volumeReduce search volumeBaseband system detailsMulti-frequency code systemsData aidedRadio frequency
The invention relates to digital signal transmission method and system based on a multi-carrier pseudorandom sequence. The method comprises the steps of: carrying out coding and modulation treatment on data to be transmitted to generate a data block to be transmitted; carrying out framing on the data block to be transmitted and a selected multi-carrier pseudorandom sequence to obtain a data frameto be transmitted; and carrying out digital-to-analogue conversion and RF (Radio Frequency) modulation treatment on the data frame to be transmitted and sending. The method and system can obtain the needed multi-carrier pseudorandom sequence used as data assistance with the least time and provides more accurate and reliable parameter estimation for digital signal transmission.


Owner:TSINGHUA UNIV
Analysis preprocessing method and device for data quality, storage medium and terminal
InactiveCN108038131AImprove accuracyReduce search volumeSpecial data processing applicationsPretreatment methodAssessment data
The invention relates to an analysis preprocessing method and device for the data quality, a storage medium and a terminal. The analysis preprocessing method for the data quality comprises the steps that label value sources of data provided by multiple suppliers are extracted; the label value sources and corresponding label values are used as nodes of a network, and association relations between every two nodes are determined according to a preset association relation among the label value sources, wherein the association relations comprise set membership and association intensity; a likelihood grade and a complexity grade of a subnetwork of the network are calculated, wherein the subnetwork is a directed loop-free network; based on the likelihood grade and the complexity grade, the corresponding subnetwork is selected as a Bayesian network and used for evaluating the accuracy rate of to-be-evaluated data. According to the technical scheme, the Bayesian network for analyzing the data quality can be established, so that the accuracy for analyzing the data quality is improved.


Owner:上海数据发展科技有限责任公司
Semantic analysis based poetry retrieval method and system
InactiveCN108845987AReduce search volumeAvoid the problem that poetry resources cannot be retrievedSemantic analysisSpecial data processing applicationsUser needsUser input
The present invention provides a semantic analysis based poetry retrieval method and system. The method includes: determining whether a conversation text contains necessary attribute information afterthe conversation text input by a user is acquired, and determining a retrieval range according to a word corresponding to the necessary attribute information if the conversation text contains the necessary attribute information; and prompting the user to perform re-inputting and acquiring a supplementary text re-input by the user by displaying a prompt message if the conversation text does not contain the necessary attribute information, acquiring the text content containing the necessary attribute information in the form of multiple rounds of conversation, and determining a retrieval resultmeeting the conversation text and feeding the retrieval result back. The retrieval method prompts the user to input the supplementary text in the form of multiple rounds of conversation, thereby avoiding the problem that the poetry resources cannot be retrieved because the conversation text input by the user lacks the necessary attribute information. The problem that the traditional retrieval methods have high requirements on the input text, and cannot satisfy the requirement of the users for the poetry resources can be solved.


Owner:北京玄一科技有限公司
Information searching method
InactiveCN108897861AReduce search volumeImprove search efficiencySpecial data processing applicationsCompositional dataInformation searching
The invention provides an information searching method. The method includes the steps of extracting key information from text in a database to obtain key sentences corresponding to each piece of textin the database; according to the key sentences corresponding to each piece of text in the database, constituting a database key sentence set; when a user conducts text searching, obtaining keywords which the user is searching for; according to the keywords, searching the database key sentence set to determine target key sentences matched with the keywords; according to the target key sentences, searching the database for corresponding text and displaying a text searching result. According to the method, since all text in the database has corresponding key sentences, when the user carries outsearching based on the keywords, the key sentences matched with the keywords are searched for at first, then the text corresponding to the key sentences is searched for, the amount of the searched text is greatly reduced, and the efficiency and accuracy of searching for the text are improved.


Owner:DONGGUAN HUARUI ELECTRONICS TECH CO LTD
Database read-write method for mass performance data of network management system
ActiveCN106599113AImprove the efficiency of writing to the databaseReduce search volumeSpecial data processing applicationsGranularityNetwork management
The invention provides a database read-write method for mass performance data of a network management system. The method is characterized in that when a database is established, a partition data table is defined for storage of the data, partitioning is performed by date with days being granularity, and a partition table maintenance component is used for increasing a new partition and deleting an overdue partition; when the data is written in, the database allocates the data into different partitions according to a defined partition range, and the data is subjected to format compression first and then written into the database; when the data is read, the data is filtered from multiple partitions in parallel, and after format decompression is performed, a result is returned to the network management system. According to the technical scheme, the database read-write efficiency can be improved under the mass performance data by scattering data storage, lowering the data reading size and increasing the data reading parallelism degree.


Owner:WUHAN HONGXIN TELECOMM TECH CO LTD
Method and device for integrating a plurality of databases
InactiveCN104424190AAchieve accessReduce search volumeSpecial data processing applicationsData mining


Owner:FUJITSU LTD
Audio retrieval method and device and medium
ActiveCN113268630AReduce search volumeShort timeSpecial data processing applicationsAudio data clustering/classificationAudio frequencyRetrieval result
The invention discloses an audio retrieval method and device and a medium, and the method comprises the steps: obtaining a to-be-retrieved audio, and extracting the voiceprint features of the to-be-retrieved audio; matching a target voiceprint feature from a preset voiceprint feature library based on the voiceprint feature; determining a target singer corresponding to the target voiceprint feature; screening retrieval audio features of each song of the target singer from a preset retrieval audio feature library to obtain a retrieval audio feature set corresponding to all songs of the target singer; and based on the retrieval audio feature set, retrieving a target song corresponding to the to-be-retrieved audio to obtain a retrieval result. Therefore, the voiceprint features of the to-be-retrieved audio are firstly extracted, then the target singer corresponding to the voiceprint features is matched, and then the retrieval audio feature range is narrowed in the retrieval audio feature set corresponding to all songs of the target singer, so that the retrieval amount is reduced, the features of other singers are excluded, the time consumption and resource overhead of audio retrieval can be reduced, and the retrieval accuracy is improved.


Owner:TENCENT MUSIC ENTERTAINMENT TECH SHENZHEN CO LTD
Processing method and device for alarm information
ActiveCN109510718AReduce search volumeReduce search timeData switching networksNetwork managementReal-time computing
Embodiments of the invention provide a processing method and device for alarm information. The alarm is assigned to a FKS (family key set) through network equipment. Network management equipment determines the FKS of a root alarm according to the FKS carried by the alarm. The same correlation family to which the FKS of the alarm and the FKS of the root alarm belong is determined according to the alarm information of the alarm. The method of adding the alarm information to the same correlation family avoids that the network management device needs to traverse all alarms when the number of the alarms is large, and the network device needs to update sub-alarm information when derived alarms are reported to the network management device before the root alarms, or all sub-alarms must be carriedwhile the root alarms are reported, thereby reducing search volume and saving search time.


Owner:HUAWEI TECH CO LTD
Query optimization method and query optimization device of search engine and electronic equipment
PendingCN113407807AReduce search volumeReduce search consumptionSpecial data processing applicationsWeb data queryingSyntaxQuery optimization
The invention provides a query optimization method and a query optimization device of a search engine, electronic equipment and a computer readable storage medium. The method comprises the following steps: obtaining a historical query record of a search engine, wherein the historical query record comprises a plurality of query statements, and generating a syntax tree based on words included in the query statements; based on the amount of information included in an inverted list corresponding to each word in the syntax tree, adjusting the execution sequence of the words in the syntax tree; searching based on the syntax tree after the execution sequence is adjusted, and determining the execution sequence of each word in the syntax tree according to a search result, wherein the execution sequence minimizes the overall search cost, and the syntax tree is used for searching when the search engine receives the query statements. Through the invention, search consumption can be reduced.


Owner:TENCENT TECH (SHENZHEN) CO LTD
Target matching method, integrated circuit, radio device and equipment
PendingCN112578351AReduce search volumeReduce data volumeWave based measurement systemsIntegrated circuitEngineering
The invention discloses a target matching method, an integrated circuit, a radio device and equipment. The target matching method comprises the steps of obtaining a plurality of first target data anda plurality of second target data; selecting at most K pieces of second target data to construct a first candidate matching queue of each piece of first target data, wherein a first matching object ofthe queue is a candidate matching object with the smallest difference degree with the first target data; selecting at most K pieces of first target data to construct a second candidate matching queueof each piece of second target data, wherein the first matching object of the queue is a candidate matching object with the smallest difference degree with the second target data; and determining thefirst target data and the second target data which are the first matching objects as target data pairs adaptive to the same target until each piece of first target data is matched or the first candidate matching queue is empty. The target matching method can reduce the power consumption of the radio device and improve the operation speed.


Owner:CALTERAH SEMICON TECH SHANGHAI CO LTD
Poem retrieval method and system based on semantic analysis
ActiveCN109635295AReduce search volumeAvoid the problem that poetry resources cannot be retrievedSemantic analysisSpecial data processing applicationsUser inputRetrieval result
The invention provides a poem retrieval method and system based on semantic analysis. The method comprises: obtaining a session text input by a user, judging whether the session text contains necessary attribute information, and determining a retrieval range according to vocabularies corresponding to the necessary attribute information if the session text contains necessary attribute information;and if the session text does not contain necessary attribute information, prompting the user to re-input and obtain a supplementary text re-input by the user by displaying prompt information, obtaining text content containing necessary attribute information in a multi-round session form, determining a retrieval result conforming to the session text, and feeding back the retrieval result. Accordingto the retrieval method provided by the invention, the user is prompted to input the supplementary text in a multi-round session form, so that the problem that poem resources cannot be retrieved dueto the fact that the session text input by the user lacks necessary attribute information is avoided. The problems that a traditional retrieval method has high requirements for input texts and poem resources meeting the requirements of users cannot be retrieved are solved.


Owner:安徽省泰岳祥升软件有限公司
Method and system for identity verification by using iris features and action features
PendingCN112036894AImprove retrieval speedReduce search volumeDigital data information retrievalSpecial data processing applicationsComputer visionReal time acquisition
The invention provides a method and system for identity verification by using iris features and action features. The method comprises the following steps: acquiring user information, iris image features and authorized payment action features; establishing an iris recognition total database according to a user file; performing library separating processing, and establishing an iris sub-library corresponding to each preset action feature; when a payment request initiated by a user is received, collecting an iris image and a hand action of the user in real time; determining whether the hand action matches a preset action feature or not; if so, retrieving the user file in an iris sub-library corresponding to the preset action feature; if not, or the hand action is not acquired, retrieving theuser file in an iris recognition total database; comparing the iris image of the user with iris image features in the user file; if the comparison is successful, determining that the user identity issuccessfully verified, processing the payment request and recording the payment request to a transaction log; and if the comparison is not successful, returning to a user side to prompt re-acquisitionof the iris image.


Owner:BANK OF CHINA
Laser filling method and device for multilayer contour pattern based on contour lines
ActiveCN113793351AReduce search volumeSave time and costImage analysisManufacturing computing systemsGrid patternComputer graphics (images)
The invention relates to a laser filling method and device for a multilayer contour pattern based on contour lines, computer equipment and a storage medium. The method comprises the following steps: performing outer contour inner offset operation on a to-be-filled pattern according to an equidistant offset algorithm to obtain a contour offset pattern; performing grid method environment modeling on the contour offset pattern to obtain a preprocessed grid pattern; performing inner and outer contour discrimination on the grid pattern to obtain a to-be-filled grid; for the to-be-filled grid, constructing a shortest path problem set; and solving the shortest path problem set by using an A* algorithm to obtain an optimal filling path of the to-be-filled grid. By adopting the method, the laser filling efficiency of the pattern can be improved.
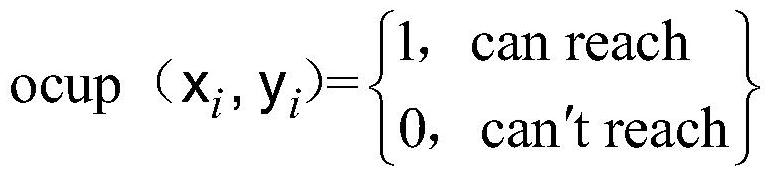
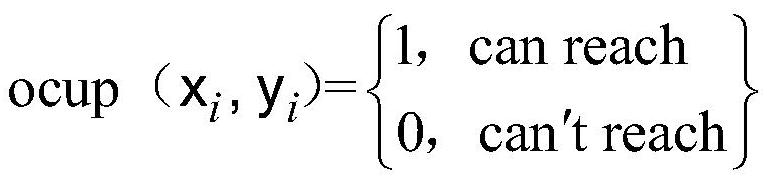
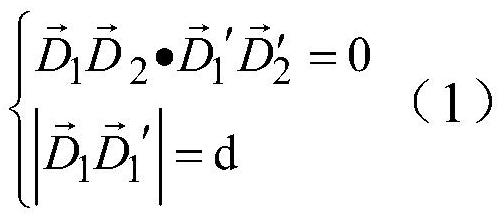
Owner:NAT UNIV OF DEFENSE TECH
Method and system for processing telecommunications access network data
InactiveCN108063684AReduce search volumeImprove user experienceData switching networksSpecial data processing applicationsInformation retrievalData query
The invention is applicable to the field of data processing, and provides a method and system for processing telecommunications access network data. The processing method comprises the following steps: obtaining a corresponding relationship between upper and lower levels of devices in to-be-processed data and IDs of the devices; and storing the IDs in a log according to the corresponding relationship in a tree structure. In the embodiment of the invention, by obtaining the corresponding relationship between upper and lower levels devices in to-be-processed data and IDs of the devices, and storing the IDs in the log according to the corresponding relationship in the tree structure, so that in a subsequent data query process, the information of the device can be quickly queried through the tree structure, the upper and lower level relationship of the devices is achieved through the lightweight IDs, thereby reducing the search amount during the query, improving the user experience and accelerating the processing speed.


Owner:FENGHUO COMM SCI & TECH CO LTD
Wheelchair path planning method based on grid map and eye-controlled wheelchair navigation system
PendingCN119573740AImprove search speedImprove path qualityNavigational calculation instrumentsForecastingWheelchairSimulation
The invention discloses a wheelchair path planning method based on a grid map and an eye-controlled wheelchair navigation system. Belongs to the technical field of intelligent path planning and particularly relates to the technical field of wheelchair path planning based on a grid map. The method overcomes the defects that according to an existing common path planning method, when the road condition is complex, the path planning quality is low, and the path is too close to an obstacle. An original cost function is formed by respectively weighting existing path cost, heuristic cost and safety cost, the method provides a dynamic weighting strategy, and comprises the following steps: firstly, weighting a w2 heuristic cost weight according to a current distance; specifically, in the initial stage of searching, we hope to converge to the position of a target point as quickly as possible, namely, increase the weight value of w2, and decrease the value of w2 as the w2 approaches to the target point, and at the moment, better path quality is required to reach the target point. In addition, the value of w3 is dynamically adjusted according to the number of obstacles in a certain range where the current node is located, so that a safer path is exchanged in a complex environment.

Owner:CHANGCHUN UNIV
Method for processing and rapidly retrieving inland ship videos based on RFID
InactiveCN102693292BQuick searchImprove retrieval efficiencyCo-operative working arrangementsClosed circuit television systemsTime segmentSurveillance camera
The invention discloses a method for processing and rapidly retrieving inland ship videos based on RFID. In the method, first, a RFID reader reads RFID electronic tag information on ships passing a monitoring area, and time that the ships get in and out of the area is recorded. Simultaneously, a monitoring camera collects videos of ships passing the filming area and the videos are sent back to a server. For every frame of image, the server judges whether the operation conditions of the ships in the frame raise an exception, and then the videos are compressed and saved, and bytes the frame of image information occupying are obtained. At the same time of saving the monitoring video data, a position of videos with a rated time interval in a whole video stream file is recorded in an index file, and whether an exceptional case occurred in the period of time is also recorded in the index file. The method can establish index files of videos generated by multipoint uninterruptible monitoring in maritime affairs, and can rapidly display the videos of specified time, target ships, and exceptional scenes.


Owner:WUHAN UNIV OF TECH
Character conversion method and device, system and storage medium
InactiveCN108121692AImprove editabilityImprove matchNatural language data processingSpecial data processing applicationsAlgorithmOperations research
An embodiment of the invention discloses a character conversion method and device, a system and a storage medium. The method comprises: determining a conversion relation to determine a pre-conversionconverted character under conversion and a converted target character; determining a relation comparison table according to the conversion relation, wherein the relation comparison table is used for representing a direct correspondence between the character under conversion and the target character; acquiring the character under conversion, and determining the target character according to the relation comparison table and the character under conversion. The problem is solved that character data of the prior art are of poor editability and have low conversion speed, and both character conversion speed and data editability are increased.


Owner:SUZHOU MEHDI HOUSTTON MEDICALSYST TECH
E-commerce site promotion configuration method and device, equipment, medium and product
PendingCN114663164AImprove efficiencyHigh trafficNatural language data processingBuying/selling/leasing transactionsEngineeringData mining
The invention discloses an e-commerce site promotion configuration method and device, equipment, a medium and a product. The method comprises the steps that a search text is constructed according to product words and attribute words of a commodity title in a commodity display page; obtaining statistical data matched with the search text, wherein the statistical data comprises a plurality of candidate long-tail words and historical search statistical indexes thereof; according to the statistical index, determining a unique candidate long-tail word which is semantically matched with the commodity title as a target long-tail word; and configuring the target long tail word into a page title of the commodity display page. According to the method, the long-tail keywords can be determined based on the commodity titles corresponding to the commodity display pages, the long-tail keywords are automatically configured as the page titles of the commodity display pages, search engine keyword optimization is achieved, the effect that search ranking is in the top is exerted through massive long-tail keywords of single commodity display pages by means of the long-tail effect, and the search efficiency is improved. And the effect of improving the search engine drainage capability of the whole station of the independent station of the e-commerce platform is achieved.


Owner:广州欢聚时代信息科技有限公司
System and method for monitoring intelligent video combining wireless radio frequency recognition technique
InactiveCN101325694BReduce search volumeEasy to handleProgramme controlComputer controlVideo monitoringSmart surveillance
The invention discloses an intelligent video monitor system combined with radio frequency technique and a method thereof. The system is composed by a data collection unit, a storage unit, a control unit and an application unit. The method comprises the steps of: mounting the data collection unit on a monitor scene as required by the monitor scene, enabling a monitored object to carry an electroniclabel including an exclusive identification coding, recording in the storage unit the distribution situation of the electronic labels, probability grammar describing motion rules of the object on themonitor scene and a variety of other information on the scene, ceaselessly capturing information of videos and electronic labels by the data collection unit, and transmitting the information upwardsandcontinuously to the application unit via a network to realize the monitor to the monitored object. The invention effectively shortens the time as required by retrieving a video stream comprising part icular objects and integrates merit about the radio frequency identification to batch-identify the objects at high speed, thereby the invention is convenient to track and monitor the monitored objectson condition of high density and improve system intelligence, as well as suitable for online application, expedient intelligent monitor system.


Owner:INST OF AUTOMATION CHINESE ACAD OF SCI
CIM model power flow data conversion method and device based on java platform
ActiveCN107017639BFast conversionReduce search volumeSemi-structured data mapping/conversionSoftware designStreaming dataData matching
The invention discloses a CIM model stream data conversion method and apparatus based on a JAVA platform. Firstly, the CIM model stream data conversion method and apparatus of invention are developed based on the JAVA platform, and adopt an object-oriented CIM model modeling thought. Compared with apparatuses and methods developed through adoption of the non-object-oriented language programs, the development of the method and apparatus of the invention have simple idea and meet the requirements. Secondly, in the process of the conversion, the data structure of the bottom layer of HashMap is used to reduce the search amount when the data is matched, and the speed of CIM model conversion is accelerated. Finally, in dealing with non-switch-type equipment, assessment of whether the equipment is in on-line operation is conducted according to states of switches to ensure the correctness of the conversion results.


Owner:POWER DISPATCHING CONTROL CENT OF GUANGDONG POWER GRID CO LTD