

Patents
Literature
44results about How to "Improve planning ability" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Taxi guiding and dispatching system
ActiveCN105006145AImprove operational efficiencyAvoid grabbing ordersRoad vehicles traffic controlComputer terminalPredictability
The invention provides a taxi guiding and dispatching system, which belongs to the field of taxi dispatching system. The taxi guiding and dispatching system provided by the invention comprises a vehicle-mounted terminal, a passenger terminal and a server, and is characterized in that: the vehicle-mounted terminal, the passenger terminal and the server communicate with one another through a network; and the server collects online information of the passenger terminal and the vehicle-mounted terminal, establishes and maintains a supply-demand link relation between taxis and passengers through an intelligent dispatching mechanism, sends travel information of a dispatched taxi to the passenger terminal according to the supply-demand link relation, and sends passenger requirement information dispatched to the vehicle-mounted terminal and an optimal driving route planned for the same to the vehicle-mounted terminal. The taxi guiding and dispatching system can recommend the optimal driving route, improves operating efficiency, reduces operating cost, protects the environment, minimizes the participation of the driver in the whole link so that the driver can concentrate on driving, ensures the safe driving of the driver, reports passenger travel information in real time, and has a certain predictability in passenger riding arrangement.
Owner:山东睿达电子科技有限责任公司
Artificial intelligence operation method and device applied to game
ActiveCN106422332AImprove planning abilityTroubleshoot technical issues with poor planning skillsArtificial lifeVideo gamesSimulationArtificial intelligence
The invention discloses an artificial intelligence operation method and device applied to games; the method comprises the following steps: receiving status information sent by a client end, wherein the status information is used for indicating present game status of the client end; using a built model to obtain motion indication information, wherein the motion indication information is used for indicating the next motion of the present game status, the model is obtained by training a plurality of motion combinations in the client end, and each motion combination comprises a plurality of motions executed in sequence; sending the motion indication information to the client end. The method and device can solve the technical problems that an artificial intelligence operation algorithm in the prior art is poor in game operation strategy programming capability.


Owner:TENCENT TECH (SHENZHEN) CO LTD
Method and device of implementing test
ActiveCN101159742AImprove planning abilityImprove accuracyData switching networksIntegration testingDistributed computing
The invention discloses a method and a device for achieving test. The method comprises receiving a test signal and the planning parameters of an IP supporting network of internet protocol; initiating a test service on the IP supporting network according to the test signal the planning parameters of the IP supporting network; and acquiring the performance indicators of the IP supporting network according the operation condition of the test service. The method and the device of the invention can integrate test function on the nodes of control network elements of the IP supporting network. According to the planning parameters of the IP supporting network, the test service is initiated on the IP supporting network, and the performance indicators of the IP supporting network is acquired according to the operation condition of the test service so as to accurately determine whether the IP supporting network satisfies the performance requirement of a communication network programming model, thereby improving the test accuracy and reliability.


Owner:HUAWEI TECH CO LTD
Activity based resource management system
ActiveUS20180188051A1Improve planning abilityIncrease awarenessAircraft componentsSpeed controllerResource Management SystemSimulation
The invention discloses a vehicle management system which is energy centric. The system may be configured to operate on a terrestrial vehicle, a nautical or on an aerial vehicle. It is configured to allow a user input a route comprising legs, each leg associated with an activity and an energy consumption mode. The system captures parameters from sensors or sensor emulators to compute a position of the vehicle and a predicted energy consumption per leg. The system comprises a display unit which associates graphically the activities, their energy consumptions and their duration. It allows the user to simulate what-if scenarios, to continuously visualize the impact of modifications of some of the parameters of energy consumption on an energy / time / range budget. The invention discloses a vehicle energy management system wherein the simulation capability is configured to display the time spent on each activity in a scale which is commensurate to the energy consumption. The invention also discloses a vehicle energy management system wherein estimated variables which impact the energy consumption may be acquired by the system to validate the conditions under which the mission performed by the vehicle will be feasible. The invention may be adapted to other applications than vehicle energy management like project planning and electronic devices energy management, among other result oriented / resource constrained activities.


Owner:FRENCH CIVIL AVIATION UNIVERSITY
Method for performing network relationship discovery and automatically realizing layered TOPO display by means of LLDP
InactiveCN105791014AGuarantee high-efficiency operationImprove network planning capabilitiesData switching networksHigh level techniquesLogical relationsNetwork structure
The invention discloses a method for performing network relationship discovery and automatically realizing layered TOPO display by means of LLDP. The method comprises the following steps of 1), configuring busy time and idle time for discovered equipment; 2) selecting the idle time, and starting LLDP enabling on the equipment; 3) acquiring neighboring information on each port which is discovered on the equipment; 4) performing LLDP disenabling on the equipment for ensuring high-efficiency operation of the equipment; 5) performing duplicate elimination and combination on connecting relations on ports of the equipment, obtaining connecting relation among the equipment and the duplicate number of connections, generating a logical relation among the equipment; and 6) traversing and analyzing the whole logical TOPO, automatically combining the independent parts, thereby displaying a network structure in a layered manner. The method of the invention has advantages of automatically finding equipment and connecting relationship and automatically performing TOPO presentation in the layered manner; selecting the idle time of the equipment for performing automatic discovery operation, utilizing equipment in maximal efficiency, quickly finding network design problems, improving network planning capability, and supplying a reasonable plan for capacity expanding and upgrading.

Owner:INSPUR TIANYUAN COMM INFORMATION SYST CO LTD
Intelligent route recommendation method and system based on global historical ship tracks
PendingCN114066354AImprove retrieval efficiencyQuality improvementForecastingGeographical information databasesPathPingPrediction algorithms
The invention provides an intelligent route recommendation method and system based on global historical ship tracks, and the method comprises the steps: firstly collecting AIS data, carrying out the preprocessing of the collected AIS data, obtaining ports and key nodes based on the preprocessed AIS data, constructing network nodes, dividing segments generated in the preprocessing process according to key nodes to obtain node segments, calculating the node segments based on a kernel density estimation method to obtain recommended segments, and taking the navigation distance of the recommended segments as the weight of the edge between the starting node and the ending node of the recommended segments to construct the route network; and finally, based on the constructed route network, performing calculating through a recommendation or prediction algorithm to obtain an optimal route path, and displaying a calculation result of the optimal route path to a user. According to the method and system, the global route segment network is constructed and stored by utilizing the high-quality route data screened after massive AIS data is processed, so that the planning capability of a dynamic route can be effectively improved, and a more diversified route query function is provided.


Owner:CHINA SHIPPING NETWORK TECH
Model construction method for GUI intelligent agent, program product and storage medium
ActiveCN119576470AImprove adaptabilityImprove targetingArtificial lifeMachine learningPersonalizationData set
The invention relates to the technical field of artificial intelligence, in particular to a model construction method for a GUI agent, a program product and a storage medium, and the model construction method for the GUI agent provided by the invention comprises the following steps: performing pre-training based on a general data set in the GUI field to obtain a base model; a user demonstration operation track is collected online, and a personalized task execution track is obtained; automatically labeling the task execution track to obtain a labeled track; performing task planning training on the base model based on the marked track to obtain a scene planner, and combining the base model and the scene planner to obtain a personalized model; based on the plug-in scene knowledge base, corresponding scene knowledge is retrieved as context supplement during personalized task action planning. The task execution track is automatically labeled, a large model is guided to actively label and understand thinking in human execution operation, the next behavior is further planned, and the adaptive capacity of a GUI intelligent agent to the personalized use environment of a user is greatly improved.

Owner:BEIJING LANZHOU TECH CO LTD
Robot optimal path planning method based on improved angle exendin optimization algorithm
PendingCN119223280Aevenly distributedFlexible direction adjustmentNavigational calculation instrumentsArtificial lifeSimulationPath plan
The invention discloses a robot optimal path planning method based on an improved angle skid optimization algorithm, and the method comprises the steps: designing a single-target optimization problem under a constraint condition based on the angle skid optimization algorithm, setting a target function as the shortest distance between a starting point and an end point, and determining the constraint condition; a good point set strategy is adopted to replace random node initialization distribution, and an adaptive dynamic weight, a dynamic weight, an adaptive coefficient, a Brownian motion random disturbance parameter and a random walk and adaptive t distribution disturbance strategy of step length adjustment are introduced. A hiding behavior, a blood jetting behavior, an escape behavior, a skin blackening and brightening behavior and a melanocyte stimulating hormone (MSH) rate formula of the algorithm are optimized respectively, and a planned path is optimized through the improved HLOA algorithm. Compared with the prior art, the method has the advantages that the convergence speed, the optimization precision and the global search capability of the angle exid optimization algorithm in robot path planning are improved, and the method is suitable for optimal path planning in a complex environment.

Owner:HUAIYIN INSTITUTE OF TECHNOLOGY
Fire-fighting reconnaissance robot path generating method, device and system and robot
InactiveCN109910009AImprove cruise efficiencyRealize autonomous cruiseProgramme-controlled manipulatorMeasurement devicesRadarPath generation
The invention relates to a fire-fighting reconnaissance robot path generating method and device, computer equipment and a storage medium. The method comprises the steps that the front path is detectedthrough an ultrasonic radar on the front side of a chassis, information of a barrier in front of the fire-fighting reconnaissance robot is obtained, if the information of the barrier in front of thefire-fighting reconnaissance robot meets a steering triggering model, the steering state of the fire-fighting reconnaissance robot is triggered, in the steering state, left barrier information detected by an ultrasonic radar on the left side of the chassis and right barrier information detected by an ultrasonic radar on the right side of the chassis are received, the turning direction of the fire-fighting reconnaissance robot is determined according to the left barrier information and the right barrier information, and a turning path of the fire-fighting reconnaissance robot is generated according to the turning direction. By adopting the method, the robot can effectively avoid the barriers on the advancing path, and the cruising efficiency of the fire-fighting reconnaissance robot in thefire scene environment is improved.
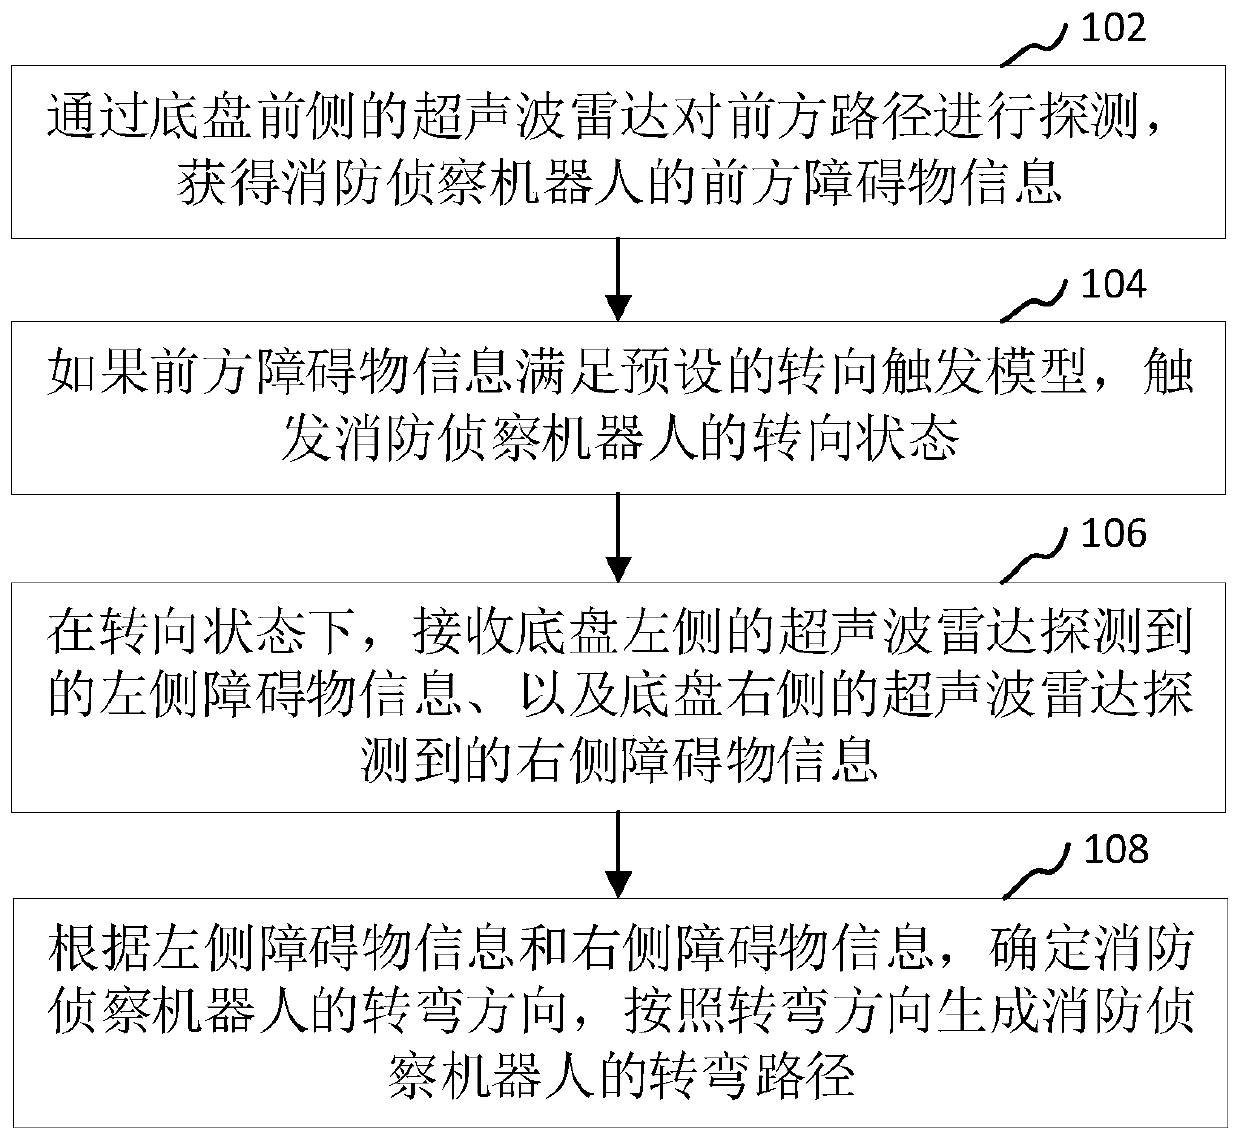
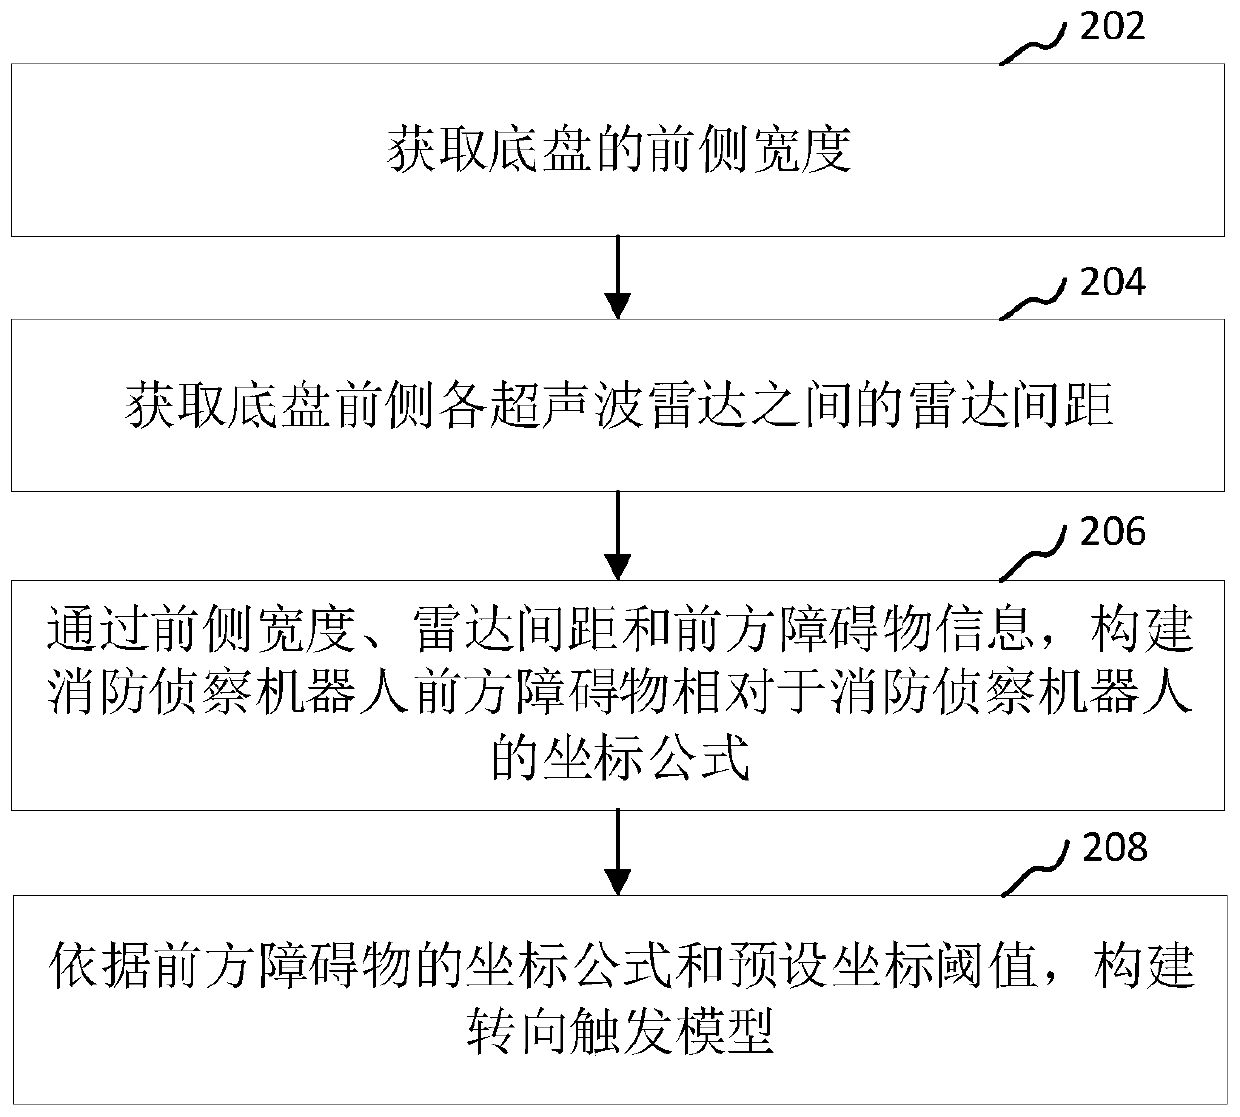
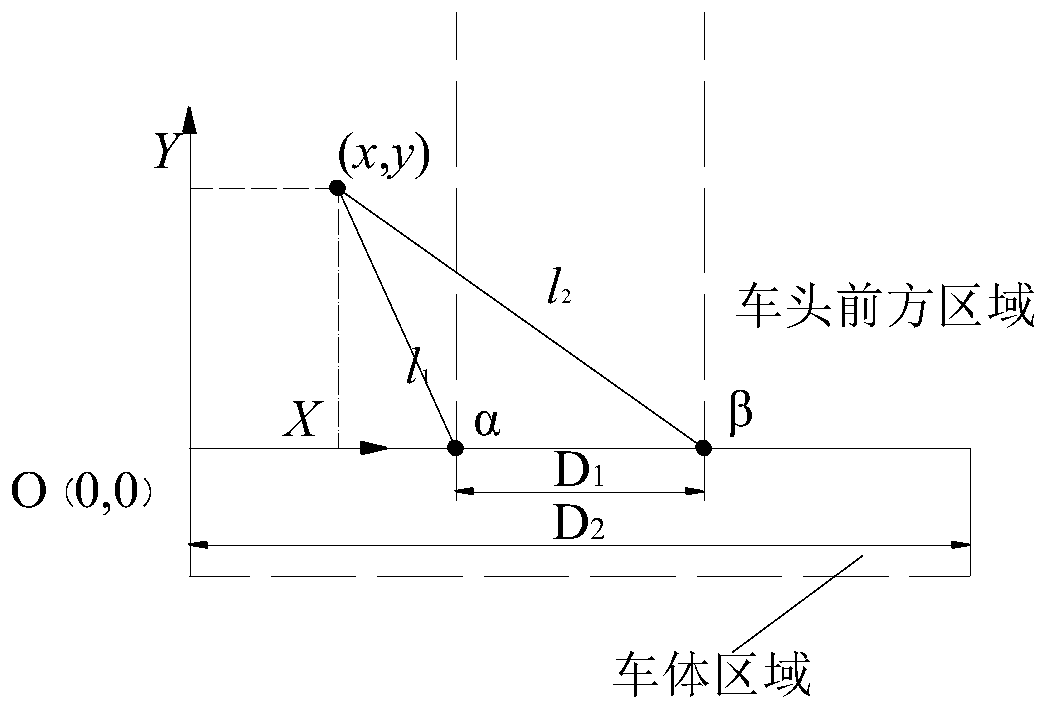
Owner:浙江华消科技有限公司
Smart city traffic information system based on 5G network
ActiveCN119229656AImprove traffic efficiencyspread widelyInput/output for user-computer interactionDetection of traffic movementTraffic signalTraffic violation
The invention provides a smart city traffic information system based on a 5G network, and relates to the technical field of data processing, and the system comprises a digital traffic processing module which is used for collecting and analyzing the operation data of various traffic facilities and vehicles in real time so as to recognize a traffic flow mode, predict a traffic state, obtain an analysis result, and according to the analysis result, determine the traffic flow mode; traffic signals are automatically adjusted, and traffic flow is optimized; and the digital government affair cooperation module is used for automatically acquiring and distributing update information of traffic policies and laws and regulations, automatically processing traffic violation behaviors, and collecting and analyzing feedback information of the public for the traffic policies to obtain an analysis report. According to the system, a plurality of digital modules are integrated, real-time collection, intelligent analysis and efficient management of traffic information are realized, the traffic operation efficiency and safety are improved, the public participation degree and satisfaction degree are enhanced, and intelligent, collaborative and sustainable development of urban traffic is effectively promoted.

Owner:XIAMEN ZHIXIANG INTELLIGENT TECH CO LTD
Artificial intelligence operating method and device applied to games
ActiveCN106422332BImprove planning abilityTroubleshoot technical issues with poor planning skillsArtificial lifeVideo gamesSimulationArtificial intelligence
The invention discloses an artificial intelligence operation method and device applied to games; the method comprises the following steps: receiving status information sent by a client end, wherein the status information is used for indicating present game status of the client end; using a built model to obtain motion indication information, wherein the motion indication information is used for indicating the next motion of the present game status, the model is obtained by training a plurality of motion combinations in the client end, and each motion combination comprises a plurality of motions executed in sequence; sending the motion indication information to the client end. The method and device can solve the technical problems that an artificial intelligence operation algorithm in the prior art is poor in game operation strategy programming capability.


Owner:TENCENT TECH (SHENZHEN) CO LTD
A Method for Automatic Partitioning of Urban Floor Area Ratio
ActiveCN103336894BImprove planning abilityImprove engineering efficiencySpecial data processing applicationsInformation processingFloor area ratio
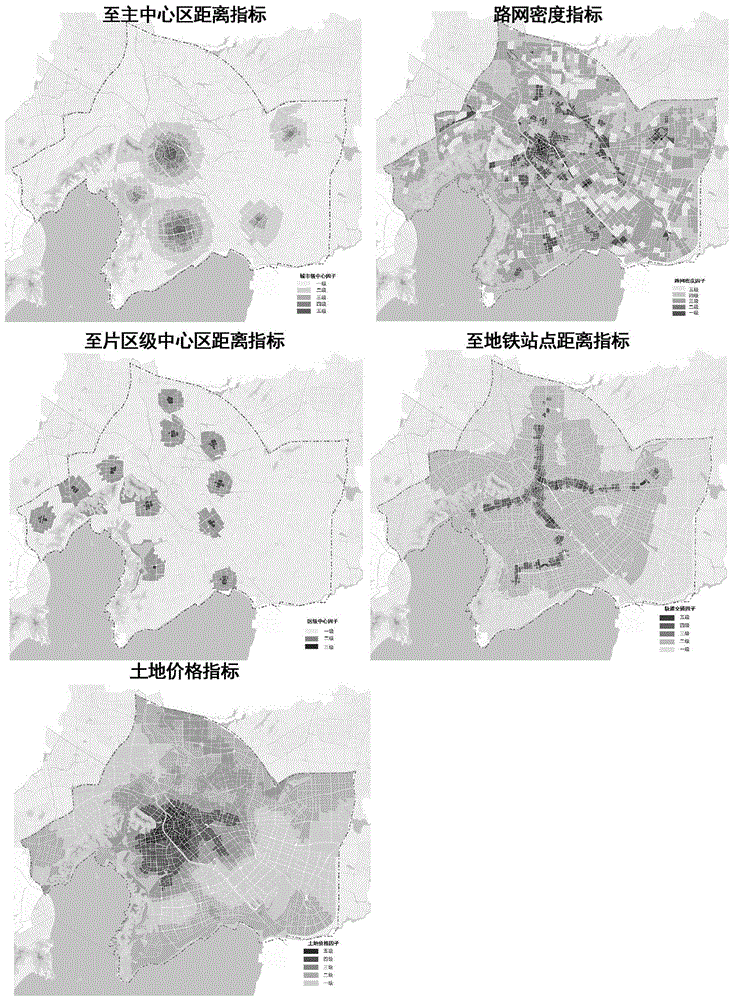
The invention discloses an automatic dividing method of a city plot ratio, which comprises the following steps: utilizing an information-processing system taking a high performance computer as a core, taking geography data of a city downtown as model input data, taking city blocks as model process evaluation base maps, building a city plot ratio evaluation model, carrying out standardized revise through a Saaty method, determining the plot ratio numerical value of each block, and automatically outputting engineering drawings that can be directly used in the city overall planning through drawing equipment. The method overcomes the insufficiency that the subjectivity and the randomness exist when the city plot ratio division is carried out by utilizing the human brain intellectual activity to make a decision in a city construction project, and greatly improves the working efficiency.
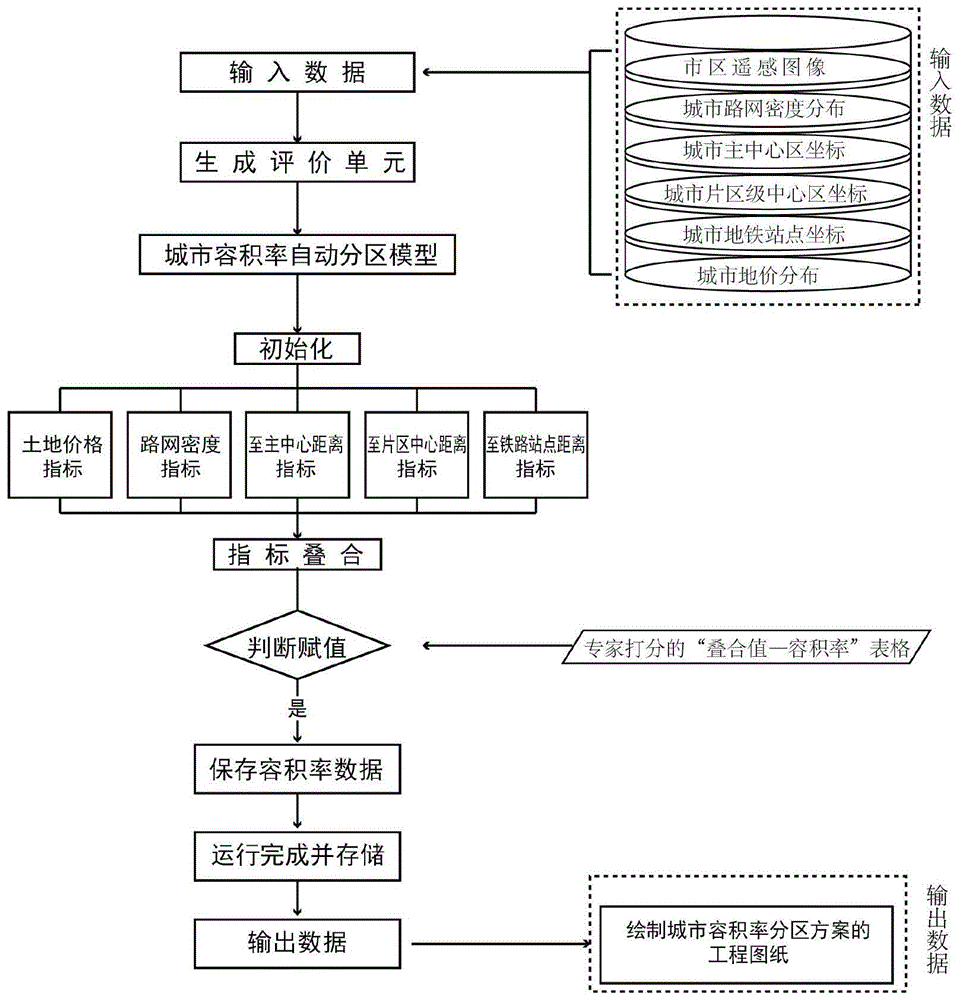
Owner:SOUTHEAST UNIV
Probability analysis method for distributed generation planning based on area grey relational decision
ActiveCN108964134AImprove planning efficiencyImprove planning abilitySingle network parallel feeding arrangementsWind energy generationIntelligent planningSystem stability
The invention relates to a probability analysis method for distributed generation planning based on area grey relational decision. The method is characterized in that a problem of conflicts of analysis on the same node caused by utilizing different methods to analyze sensitivity of a distribution network node is solved. The method is advantaged in that planning efficiency and the planning effect of the distributed generation of the distribution network can be effectively improved, influence of access of a high-sensitivity node to the distributed generation having output fluctuation characteristics on stability of the distribution network system can be effectively analyzed, and the method is scientific and reasonable, has strong applicability and good effect, can improve intelligent planning efficiency of the distribution network and balances the DC optimal mounting position.


Owner:NORTHEAST DIANLI UNIVERSITY
Construction method of oil content index model for predicting oil content of reservoir and prediction method of oil content of reservoir
PendingCN110765606ATake sensitivity into accountConsider sensitivityForecastingDesign optimisation/simulationCorrelation coefficientWell drilling
The invention relates to a construction method of an oil content index model for predicting the oil content of a reservoir and a prediction method of the oil content of the reservoir, and belongs to the field of prediction of the oil content of the reservoir. The method comprises the following steps: 1) according to historical drilling data in a research area, acquiring logging parameters and initial oil production data which change along with depth; 2) assigning values to the qualitative parameters, and digitizing the qualitative parameters; 3) performing normalization processing on the digitized qualitative parameters and the digitized quantitative parameters; 4) setting initial weights of qualitative parameters and quantitative parameters, and calculating an oil content index; 5) fitting the preliminarily calculated oil content index with the initial oil yield, and determining a correlation coefficient; adjusting the weight of each logging parameter according to the correlation coefficient. According to the method, the sensitivity of different descriptive parameters to oil and gas is fully considered, the accuracy of oil content evaluation is improved, and effective data supportcan be provided for subsequent yield prediction and reservoir reconstruction.


Owner:中石化石油工程技术服务有限公司 +1
Big data-based academic and career planning system
InactiveCN111179134AImprove connectivitySmooth entryForecastingResourcesCareer planningKnowledge management
The invention provides a big data-based academic vocational planning system, which comprises an academic planning module and a career planning module, and the academic planning module comprises a course setting module, a postgraduate entrance exam taking and planning module and an employment planning module, and the course setting module displays course key points and a course question bank; thepostgraduate entrance exam taking and planning module displays postgraduate entrance exam taking and planning contents, and displays postgraduate entrance exam taking related directions and subjectsrequired to be prepared of various colleges and universities; the employment planning module displays enterprise recruitment information and recruitment requirements; the career planning module comprises an intention display module, a comparison analysis module, a comprehensive analysis module and a development status module; the comparison analysis module is used for solving the degree that the job meets the requirement of the job seeker by adopting a corresponding algorithm according to the working attribute information input by the user; the comprehensive analysis module is used for solvingthe degree of the job seeker meeting the job requirement by adopting a corresponding algorithm according to the personal attribute information input by the user; and the development state module analyzes the position development prospect of the position according to the position salary level in recent years.


Owner:SHANGHAI DIANJI UNIV
Multi-satellite joint planning method and system considering task splitting
ActiveCN114781851BImprove planning abilityImprove observation efficiencyComplex mathematical operationsSatellite observationDistributed computing
The multi-satellite joint planning method and system considering task splitting provided by the present invention construct a task planning model. The model covers the planning of both splittable observation tasks and inseparable observation tasks, and designs phased algorithms for inseparable and splittable task planning respectively, taking into full account various constraints such as satellite resource capability level and task timeliness requirements. A large number of numerical experiments have proved that by splitting the tasks, the possibility of collaboration between multiple satellites is provided, the task completion rate is improved, the benefits of multi-satellite joint observation are significantly improved, and ultimately the observation efficiency of satellites is greatly improved.

Owner:NAT UNIV OF DEFENSE TECH
A Circular Trajectory Planning Method for Robots Based on Sinusoidal Curves
ActiveCN111872943BImprove planning abilityProgramme-controlled manipulatorRobot end effectorComputer vision
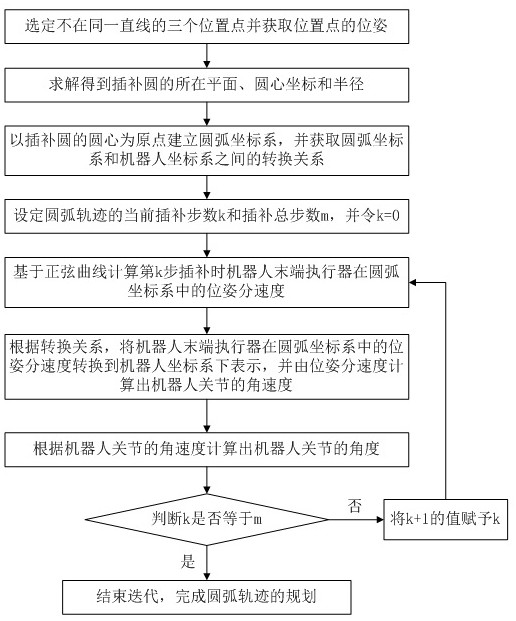
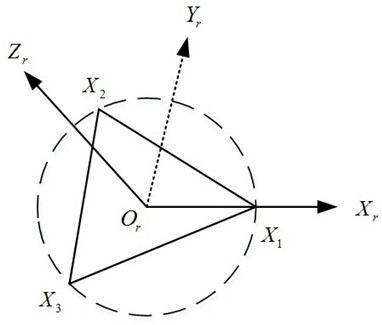
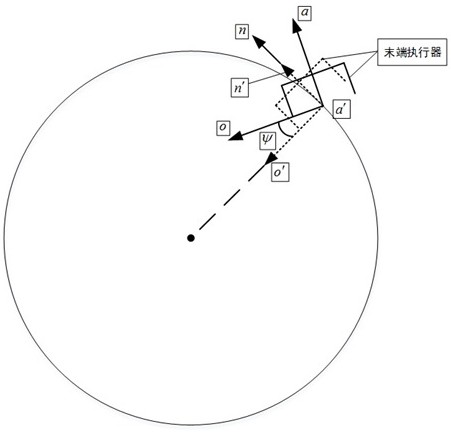
The present invention provides a robot arc trajectory planning method based on a sinusoidal curve, which includes the following steps: S1: select three position points and obtain the pose of the position points; S2: obtain the interpolation circle passing through the three position points The plane, the coordinates of the center of the circle and the radius; S3: establish the arc coordinate system; S4: set the current interpolation step k and the total interpolation step m of the arc trajectory, and set k=0; S5: calculate based on the sine curve The pose and velocity of the end effector of the robot during interpolation in the kth step; S6: Calculate the angular velocity of the robot joint; S7: Calculate the angle of the robot joint; S8: Determine whether k is equal to m; if not, set k+ Give k a value of 1, and return to step S5; if it is equal, then end the iteration and complete the planning of the arc trajectory. The invention provides a robot arc trajectory planning method based on a sinusoidal curve, which solves the problem that the change of the joint angle of the robot is mostly not considered when planning the trajectory of the robot at present.
Owner:FOSHAN LONGSHEN ROBOT
Unmanned aerial vehicle adaptive repulsion coefficient path planning method based on deep learning
ActiveCN114779821AImprove planning abilityExcellent pathInternal combustion piston enginesPosition/course control in three dimensionsSimulationResidual neural network
The invention discloses an unmanned aerial vehicle adaptive repulsion coefficient path planning method based on deep learning. The method comprises the following steps: firstly, finding out a most suitable repulsion coefficient sample set in a specific environment through a fusion genetic algorithm and an artificial potential field method; secondly, training a residual neural network by using the sample set; and finally, a repulsive force coefficient adapting to the environment is calculated through the residual neural network, and path planning is performed by using an artificial potential field method. The problems that a traditional artificial potential field method cannot adjust the repulsive force coefficient according to specific environment information, and an existing improvement method cannot give consideration to the planning effect and the planning duration while adaptively adjusting the repulsive force coefficient are solved. Simulation experiments show that the method has excellent performance in the aspects of planning effect and planning duration, and can well meet the self-adaption requirement and the rapid planning requirement for the current environment in practical application.


Owner:SICHUAN UNIV
Method and device of implementing test
ActiveCN101159742BImprove planning abilityImprove accuracyData switching networksControl networkReliability engineering
A method for realizing a test is provided. The method includes receiving a test signaling and a planning parameter of an internet protocol, IP, bearer network; initiating a test service on the IP bearer network according to the test signaling and the planning parameter of the IP bearer network; and obtaining a performance indicator of the IP bearer network according to the running situation of the test service. An apparatus for realizing a test is also provided. The testing functionality may be integrated in a control network element node of the IP bearer network, without connecting to any test device. Thus, the test performance is not limited to or affected by the performance of the test device. A test service is initiated on the IP bearer network according to the planning parameter of the IP bearer network; and a performance indicator of the IP bearer network is obtained according to a running situation of the test service. According to the performance indicator, it is determined whether the current IP bearer network satisfies the performance requirements of the communication network planning model. Thus, the planning capability of the communication network is enhanced, and the test accuracy and the test reliability are improved.


Owner:HUAWEI TECH CO LTD
Power distribution cabinet convenient for wire outgoing
ActiveCN222620411UImprove tidinessImprove cooling effectBus-bar/wiring layoutsTransportation and packagingStructural engineeringMechanical engineering

Owner:JIANGSU SUNAI ELECTRIC CO LTD
Multifunctional mounting bracket for security camera
ActiveCN112325132BImprove planning abilityEasy to installStands/trestlesEngineeringStructural engineering


Owner:陕西众智鹏成信息科技有限公司
Multi-welding robot path optimization method and system based on B-APF
ActiveCN114043475AStrengthen information exchangeImprove collaborationProgramme-controlled manipulatorInternal combustion piston enginesVirtual targetSimulation
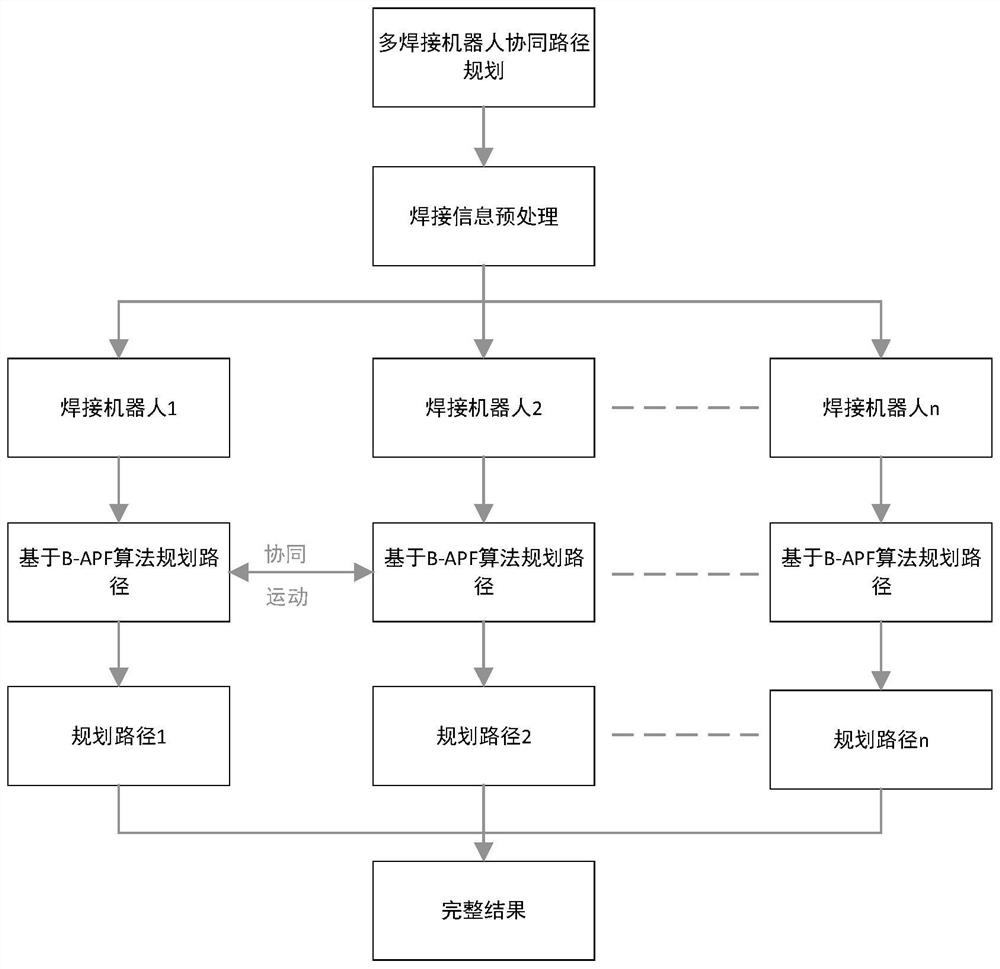
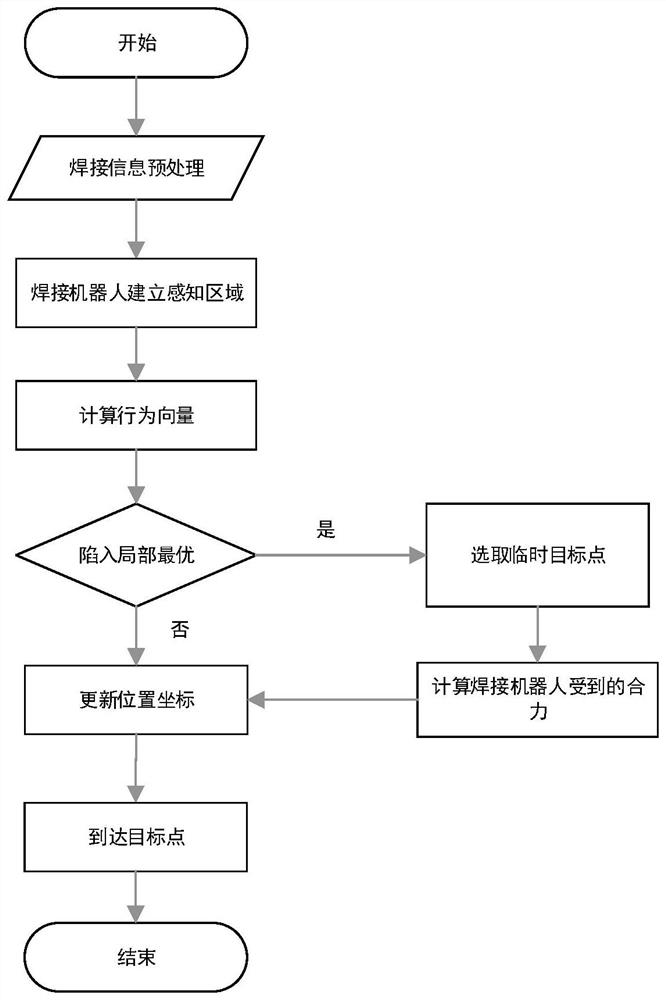
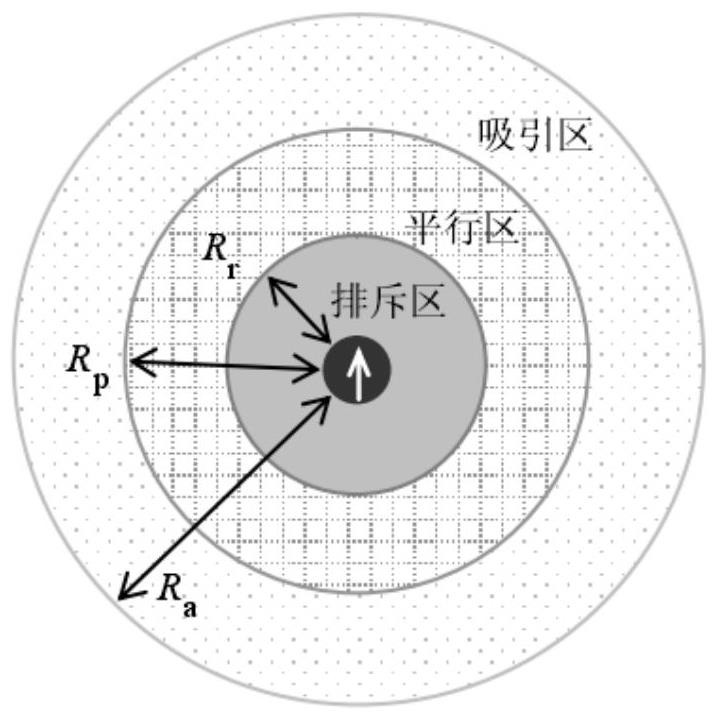
The invention discloses a multi-welding robot path optimization method and system based on a B-APF, and provides a B-APF algorithm. The multi-welding robot path optimization method comprises the steps that: a sensing area of a welding robot is introduced on the basis of a BOID model principle, and when a robot falling into a local minimum value point exists in multiple robots, the robot is stagnated, and meanwhile position coordinates of other robots are sensed; when other robots arrive at the target point, a path of the other robots closest to the stagnant robot is searched, and the closest point is selected as a virtual target point of the stagnant robot; after the stagnant robot reaches the virtual target point, the target point of the stagnant robot is changed back to an initial target point of the stagnant robot; and meanwhile, the B-APF algorithm is adopted to perform formation structure control optimization when the multiple welding robots work cooperatively, so that the overall path planning effect is improved. According to the multi-welding robot path optimization method, the multiple welding robots can better cooperatively weld large precise complex parts in the ship construction project, and optimal path optimization of the multiple welding robots in cooperative work can be obtained.
Owner:716TH RES INST OF CHINA SHIPBUILDING INDAL CORP
A three-layer architecture-based path planning method for unmanned vehicles
ActiveCN111596664BImprove planning abilityImprove driverless technologyPosition/course control in two dimensionsVehiclesRoad networksLocal planning
The invention discloses a path planning method for unmanned vehicles based on a three-layer architecture, which includes the following steps: step 1: building a map, abstracting and mathematically describing the road in the application scene, expressing and storing the road; step 2 : Application, use the road network map that has been built in this specific scene, and realize the planned route on the road network map according to the task requirements. The beneficial effects of the present invention are as follows: (1) The global path planning and the local path planning are taken into consideration by using the three-layer architecture, so that the two are closely connected with the physical platform, and more useful information is provided for the road local path planning, which improves the Planning performance; the third layer of planning execution layer introduces an improved A-star search method based on guidelines, using guidelines and key points, which not only preserves the expected local planning path as much as possible, but also maintains the characteristics of flexible obstacle avoidance.
Owner:NAT INNOVATION INST OF DEFENSE TECH PLA ACAD OF MILITARY SCI +1
Road network generation method, navigation method and device, equipment and storage medium
ActiveCN111121795AImprove road network coverageImprove the effect of road network planningInstruments for road network navigationComputer equipmentReal-time computing
The invention relates to the technical field of artificial intelligence, and provides a road network generation method, a navigation method and device, computer equipment and a storage medium. A roadnetwork can be intelligently generated according to a passing area for passing of a passing object in the area; a plurality of coverage units are arranged by fully utilizing the space of the passing area, so that a coverage area formed by the plurality of coverage units on the passing area is maximized, the road network of the area is generated based on the geometric centers of the plurality of coverage units enabling the coverage areas to be maximized, the coverage degree of the road network is improved, a more accurate navigation route can be generated by fully utilizing the space of the passing area based on the road network with high coverage degree, and the planning effect of the road network is improved.


Owner:TENCENT TECH (SHENZHEN) CO LTD
A smart city traffic information system based on 5G network
ActiveCN119229656BImprove traffic efficiencyspread widelyInput/output for user-computer interactionDetection of traffic movement
The present invention provides a smart city traffic information system based on 5G network, which relates to the field of data processing technology. The method includes: a digital traffic processing module, which is used to collect and analyze the operation data of various traffic facilities and vehicles in real time, so as to identify traffic flow patterns, predict traffic status, obtain analysis results, and automatically adjust traffic signals and optimize traffic flow according to the analysis results; a digital government affairs collaboration module, which is used to automatically obtain and distribute updated information on traffic policies and regulations, automatically handle traffic violations, and collect and analyze public feedback on traffic policies to obtain analysis reports. The present invention integrates multiple digital modules, realizes real-time collection, intelligent analysis and efficient management of traffic information, not only improves traffic operation efficiency and safety, but also enhances public participation and satisfaction, and effectively promotes the intelligence, collaboration and sustainable development of urban transportation.

Owner:XIAMEN ZHIXIANG INTELLIGENT TECH CO LTD
Robot circular arc trajectory planning method based on sine curve
ActiveCN111872943AImprove planning abilityProgramme-controlled manipulatorRobot end effectorComputer vision
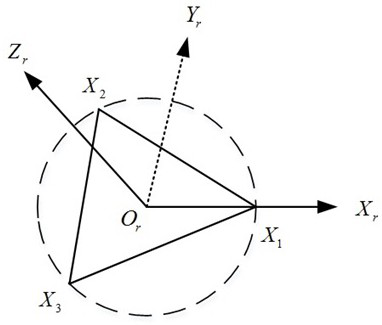
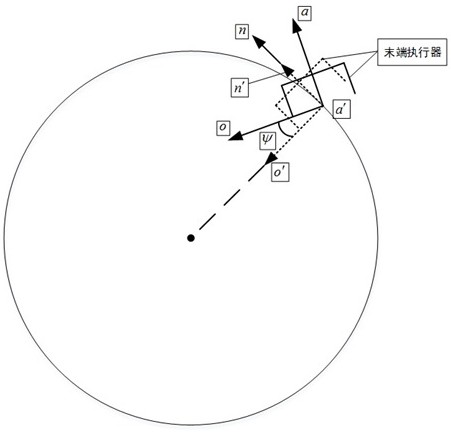
The invention provides a robot circular arc trajectory planning method based on a sine curve. The method comprises the following steps that S1, three position points are selected, and poses of the position points are obtained; S2, solving is carried out to obtain a plane, a circle center coordinate and a radius of an interpolation circle passing through the three position points; S3, a circular arc coordinate system is established; S4, the current interpolation step number k and the total interpolation step number m of a circular arc trajectory are set, and the k is enabled to be equal to 0; S5, the pose component velocity of a robot end effector during the kth interpolation is calculated based on the sine curve; S6, the angular velocities of joints of a robot are calculated; S7, the angles of the joints of the robot are calculated; S8, whether the k is equal to the m or not is judged; if not, the k is endowed with the value of k+1, and the step S5 is returned and if yes, iteration isended, and planning of the circular arc trajectory is completed. The robot circular arc trajectory planning method based on the sine curve solves the problem that the joint angle change of the robot is mostly not considered when the motion trajectory of the robot is planned at present.
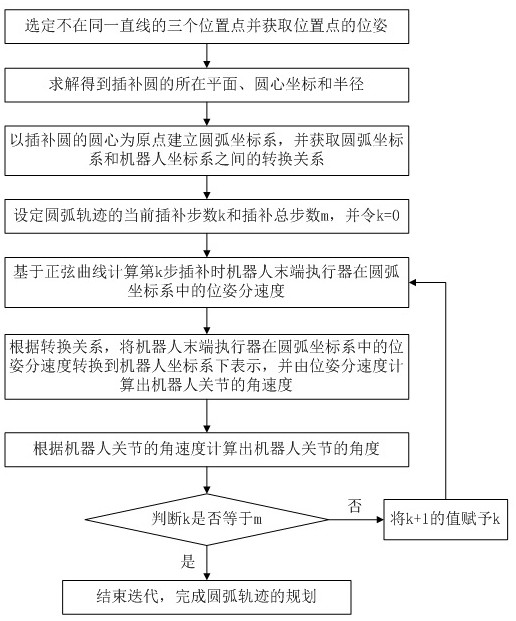
Owner:FOSHAN LONGSHEN ROBOT
Method and device for acquiring motion route and storage medium
ActiveCN109718530AImprove planning abilityMeets requirementsPhysical therapies and activitiesSport apparatusSimulationMotion correlation
The embodiment of the invention discloses a method and device for acquiring a motion route and a storage medium. The method includes the steps of determining motion association data corresponding to an outdoor motion request when an outdoor motion request of a user is received, wherein the motion association data includes at least one piece of travel data, social activity data and consumption dataof the user within a specified time period; determining the motion preference of the user according to the motion association data; determining the motion route of the user based on the motion preference, wherein the motion route is composed of at least one motion path.


Owner:MIGU INTERACTIVE ENTERTAINMENT CO LTD +1
Robot path planning method based on improved RRT algorithm
ActiveCN119245645AImprove production efficiencyReduce the number of samplesNavigational calculation instrumentsPathPingPath length
The invention discloses a robot path planning method based on an improved RRT algorithm, and the method comprises the steps: limiting a sampling region through a maximum sampling radius and a newly-added node at a previous moment, and enabling an obtained sampling point to be deviated to a target point with a large probability; meanwhile, by limiting the sampling points, the method can be close to the target point to the maximum extent under the condition that the number of obstacles is small, and can be close to the target point to the minimum extent under the condition that the number of obstacles is large, so that the sampling frequency of the sampling points when the newly added nodes of the random tree are obtained is reduced, and the path generation efficiency is improved. In addition, redundant nodes in the path are removed after the path is generated, and pruning operation is performed on the nodes in the path, so that optimization of the path nodes is realized, the number of corners of the generated path is reduced, the path planning performance is improved, and compared with RRTstar and Astar algorithms, the path length can be effectively shortened, and the search efficiency is improved.

Owner:BEIJING LINGSHENG TECHNOLOGY CO LTD
Venue seat information planning method, device and system
ActiveCN111489042AMeet planning needsImprove matchRelational databasesResourcesPlanning approachInformation planning
The invention discloses a venue seat information planning method, device and system, and the method comprises the steps: receiving a seat planning request of a target venue, and determining the planning target parameter information of seat planning; determining planning input data of the target venue seat information and a planning method model used for seat planning; inputting the planning inputdata and the planning target parameter information into the planning method model; and determining a planning result that the planning method model plans the seat information of the target venue according to the planning target parameter information. Through the method, planning of venue seat information can be automatically and efficiently realized, the obtained planning result is more scientificand reasonable, the satisfaction degree of audiences is improved, and seat planning and activity expectation are better considered.


Owner:ALIBABA GRP HLDG LTD
Micro-grid optical exchange planning method, device, equipment and medium
ActiveCN117474970BImprove planning abilityLight traffic planning science
The application provides a micro-grid optical exchange planning method, device, equipment and medium, and the method comprises the following steps: acquiring a to-be-constructed micro-grid of a micro-grid resource map; determining an effective coverage area of the to-be-constructed micro-grid based on the number of pixel points of the to-be-constructed micro-grid; if the proportion of the effective coverage area in the total area of the micro-grid is less than a preset proportion threshold, determining the number of optical exchange constructions of the to-be-constructed micro-grid based on the effective coverage area and the total area of the micro-grid; and determining the optical exchange construction point of the to-be-constructed micro-grid based on the number of optical exchange constructions. The application realizes more scientific and accurate optical exchange planning and improves the planning effect of micro-grid optical exchange construction.

Owner:CHINA MOBILE GRP GUANGDONG CO LTD +1