

Patents
Literature
53 results about "Fuzzy pi controller" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
PI (Proportional Integral) parameter mixed setting method
ActiveCN102426417AVerify validityImprove dynamic performanceControllers with particular characteristicsControl vectorMathematical model
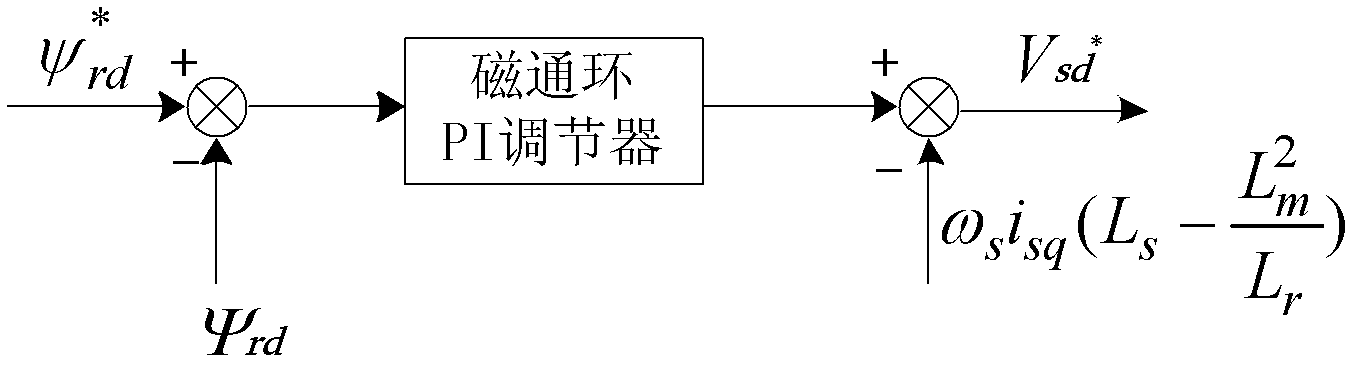
The invention relates to a PI (Proportional Integral) parameter mixed setting method, which is a model-based mixed setting method combining off-line setting and fuzzy PI on-line setting for ensuring that a closed loop vector control system works in an optimal state. The PI parameter mixed setting method comprises the following steps of: firstly deducing a mathematic model of a system according toa vector control principle, calculating rotational inertia by a method of constant torque start and machine free stop, and calculating PI parameters and inner ring compensation dosage according to the mathematic model; proposing a new PI control rule table by a fuzzy PI controller; and finally verifying the exactness of the PI parameters by a comparison test. According to the PI parameter mixed setting method disclosed by the invention, the dynamic property and the steady state precision of the system are improved and are better than those of a system utilizing a single setting method, and the validity of the method is verified.
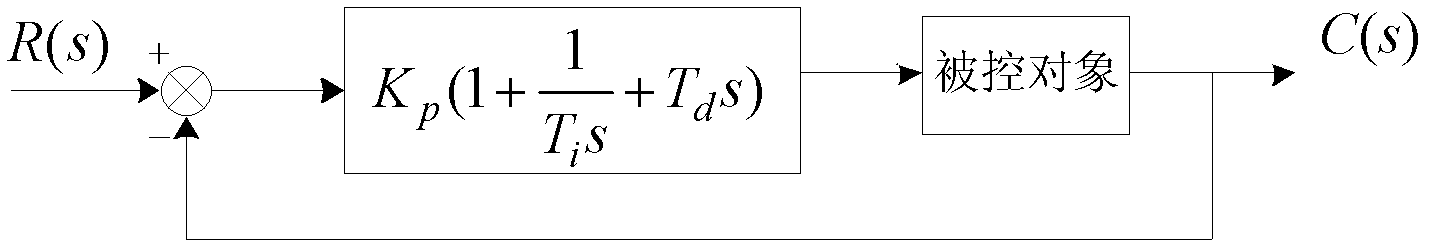
Owner:WISDRI WUHAN AUTOMATION
Novel fuzzy and deadbeat algorithm vector control system of permanent magnet synchronous motor
InactiveCN103904972ASpeed loopEliminate current loopElectronic commutation motor controlVector control systemsControl systemPermanent magnet synchronous motor
The invention provides a novel fuzzy and deadbeat algorithm vector control system of a permanent magnet synchronous motor. The novel fuzzy and deadbeat algorithm vector control system comprises a fuzzy PI controller, a deadbeat current predictive control module, a space pulse width vector modulation module, a three-phase two-level inverter, a permanent magnet synchronous motor module and a 3s / 2r changing module. The novel fuzzy and deadbeat algorithm vector control system can be well applied to a digital control system, and has good application prospects.


Owner:杨飏
Brushless direct-current motor fuzzy PI controller based on FPGA
InactiveCN104201946AEasy to controlReal-time online controlSingle motor speed/torque controlElectronic commutatorsMotor speedFuzzy pi
The invention discloses a brushless direct-current motor fuzzy PI controller based on FPGA, belongs to the technical field of motor control and aims to solve the problems that according to the existing brushless direct-current motor adopts a fuzzy adaptive PID algorithm to control the motor, and the control of the motor is delayed since the executing speed is low. A filter module filters and transmits Holzer position signals to a speed calculation module; the speed calculation module calculates to acquire the motor speed feedback signals in real time; a speed fuzzy PI adjusting module calculates to acquire current adjusting determined signals; a current PI adjusting module adopts the traditional PI algorithm to modulate the current of the motor to acquire and transmit PWM modulation signals to a PWM modulation and commutation module; the PWM modulation and commutation module transmits commutation signals and PWM modulation signals to a power drive module to drive a brushless direct-current motor. The controller is applied to control of the brushless direct-current motor.


Owner:HARBIN UNIV OF SCI & TECH
Drive control method and device for electric fork truck, and electric fork truck
ActiveCN106817058AGood speed regulation performanceImprove integrityElectronic commutation motor controlVector control systemsPower inverterStator voltage
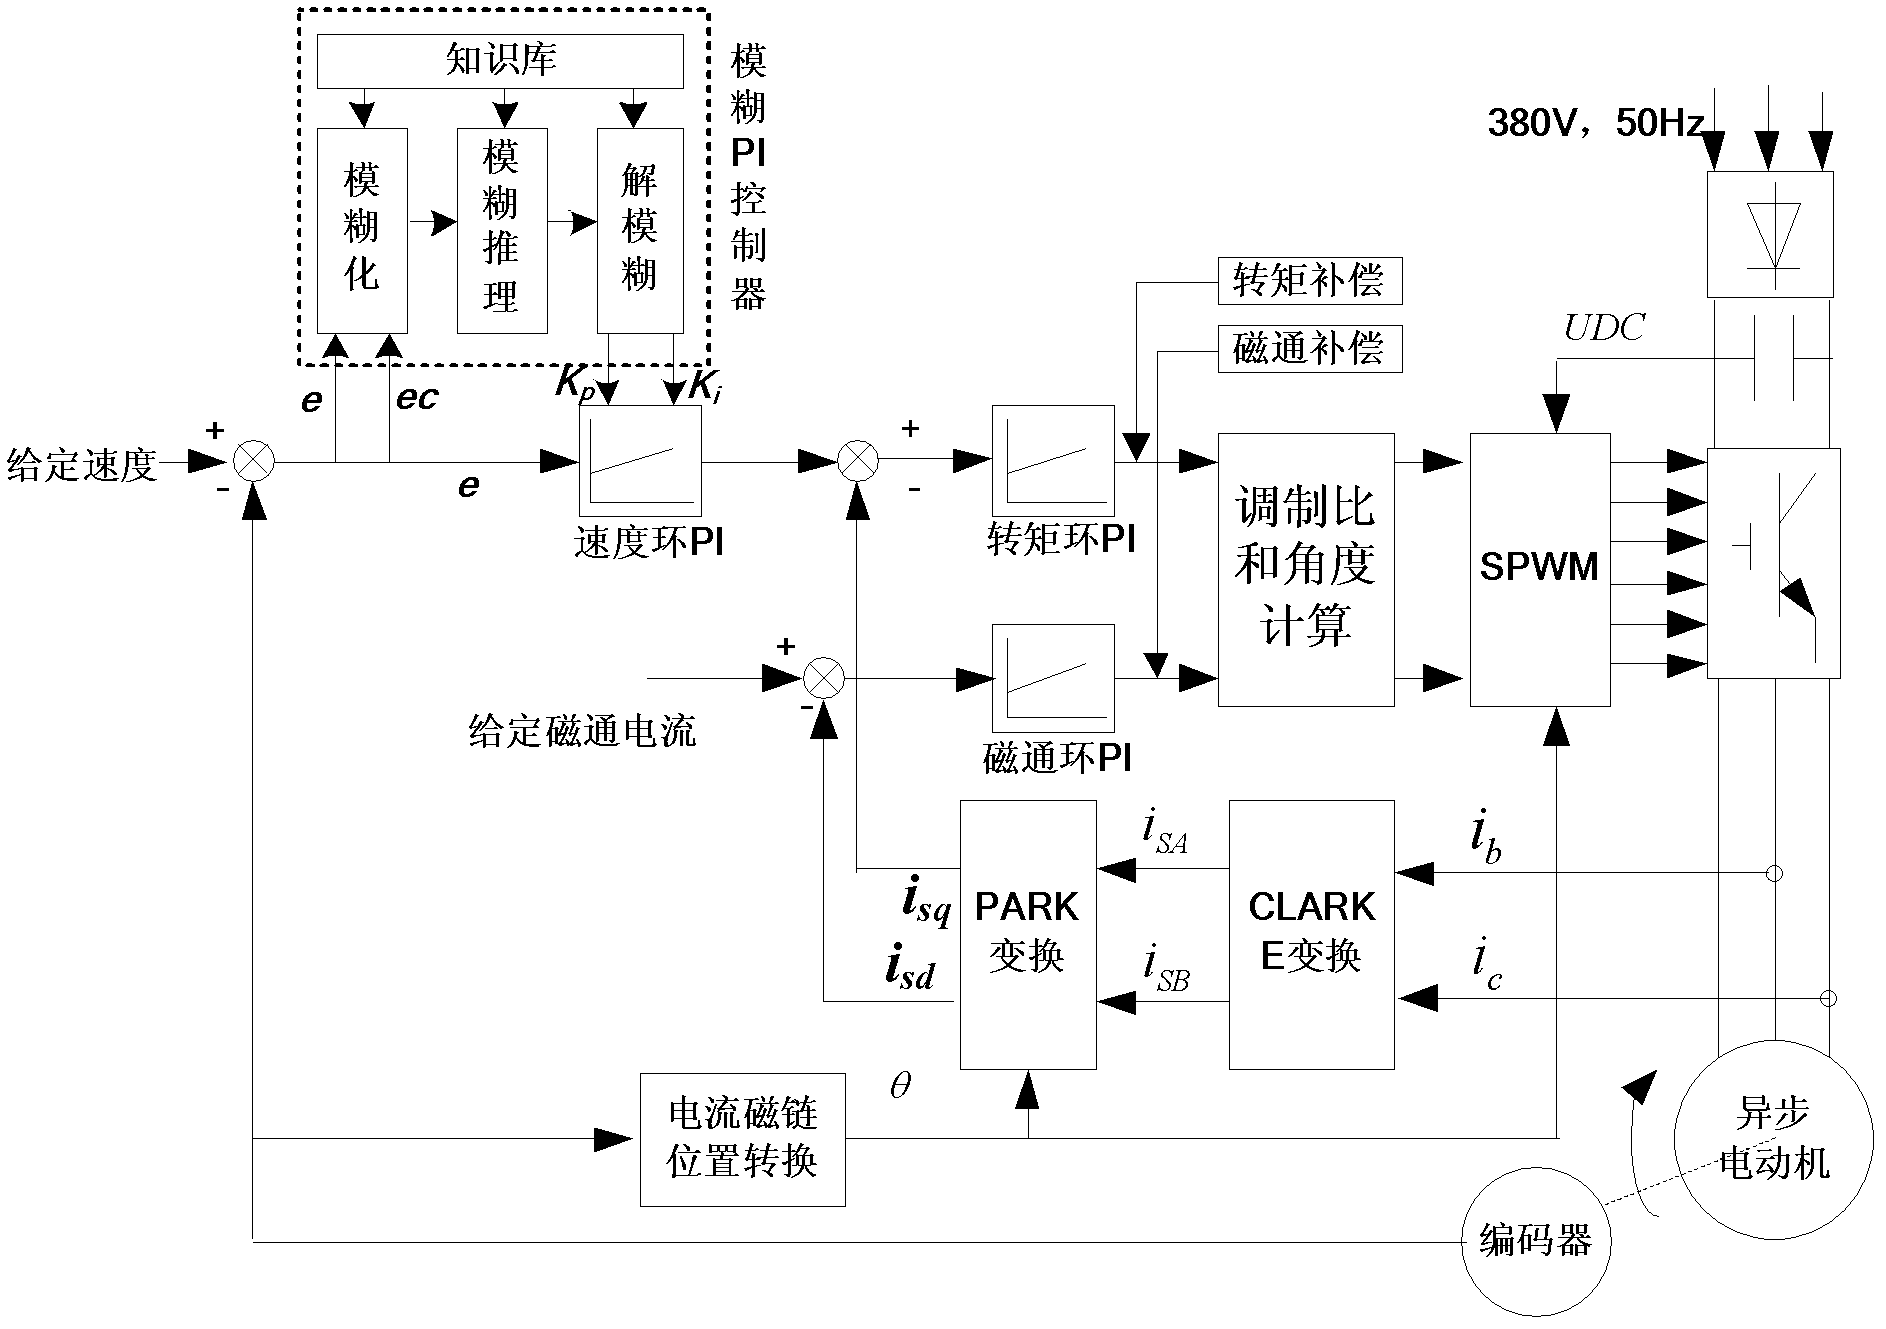
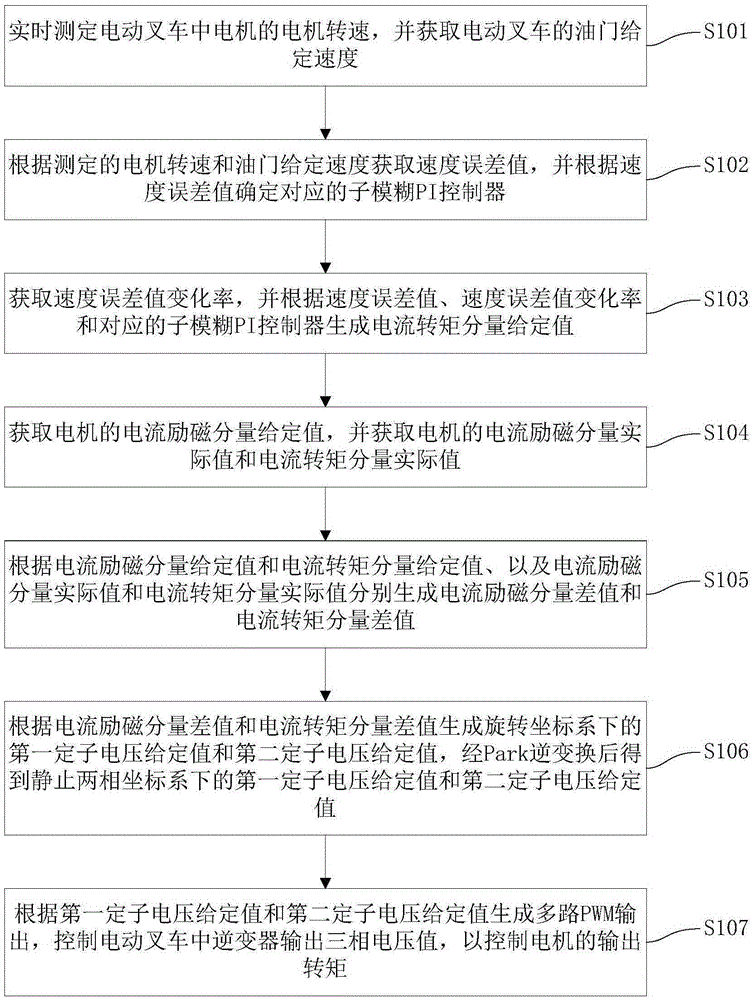
The invention discloses a drive control method and device for an electric fork truck, and the electric fork truck. The method comprises the steps: measuring the rotating speed of a motor of the electric fork truck, obtaining a speed error value according to the rotating speed of the motor and a given speed of an accelerator, and determining a corresponding child fuzzy PI controller according to the speed error value; generating a current torque component given value according to the speed error value, the change rate of the speed error value and the corresponding child fuzzy PI controller; respectively generating a current excitation component difference value and a current torque component difference value according to a current excitation component given value, a current torque component given value, a current excitation component actual value and a current torque component actual value; generating a first stator voltage given value and a second stator voltage given value in a stationary two-phase coordinate system according to the two component difference values; generating multipath PWM output according to the two given values in the stationary two-phase coordinate system, and controlling an inverter to output a three-phase voltage value, so as to control the output torque of the motor.
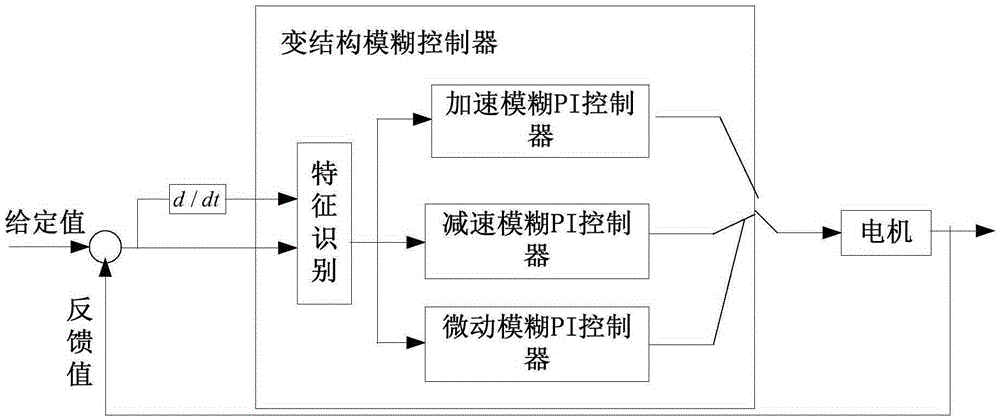
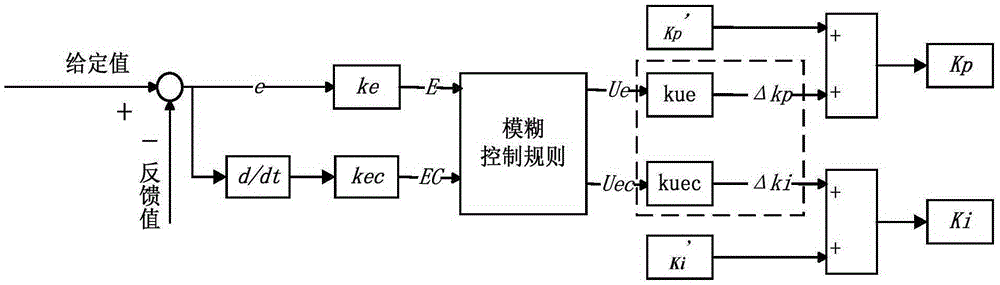
Owner:BYD CO LTD
Aeroengine steady-state loop proportional integral controller and design method and device thereof
The invention discloses an aeroengine steady-state loop proportional integral controller and a design method and device thereof. The method comprises steps that an aeroengine T-S fuzzy model is established for an aeroengine steady-state loop, the aeroengine T-S fuzzy model is composed of at least one fuzzy sub model, and each fuzzy submodel is a linear system model near a steady-state linear operating point of an aeroengine; a steady-state loop proportional-integral controller is designed for the aeroengine based on the aeroengine T-S fuzzy model. The method is advantaged in that through combining the T-S fuzzy model with PI control, the method is more practical than combining with state feedback control and is more suitable for the aeroengine engineering, based on the T-S fuzzy theory, the aeroengine T-S fuzzy model is established, the steady-state loop PI controller is designed based on the model, and steady state performance control of the full speed range of an engine rotor can berealized through the fuzzy PI controller designed.


Owner:AECC COMML AIRCRAFT ENGINE CO LTD
Balance car control method employing fuzzy algorithm
In order to solve the problem that the speed following performance of an upright vehicle is not good due to solving the conflict between speed control and upright control of the upright vehicle, the invention provides a method for controlling an upright vehicle based on fuzzy PI. In the design of a fuzzy PI controller, the states of the upright vehicle under different working conditions are analyzed. A setting principle of fuzzy PI control parameters capable of enabling the system to obtain optimal response performance is formulated, software simulation is carried out on the upright vehicle adopting fuzzy PI control, and a real vehicle test is carried out. Test simulation results show that the upright vehicle speed following performance based on the fuzzy algorithm is good, the stability and the robustness of the system are high.


Owner:CHANGCHUN UNIV OF TECH
Active filter control method based on fuzzy PI and repetitive control
InactiveCN104979830AStrong robustnessQuick responseHarmonic reduction arrangementAc network to reduce harmonics/ripplesFuzzy piFuzzy adaptive
The invention discloses an active filter control method based on fuzzy PI and repetitive control. On the basis of parallel cooperative operation of a fuzzy adaptive PI controller and a repetitive controller, a dynamic response speed and steady state response precision of the active filter can be effectively guaranteed. The fuzzy adaptive PI controller uses a fuzzy control principle to carry out on-line adaptive setting on a PI parameter and characteristics of high fuzzy control robustness and fast PI control response speed are fully combined, thereby realizing the rapid shock-free response function of the controller. According to the internal model principle of the repetitive controller, internal model construction of the periodic harmonic current reference signal and amplitude phase compensation of the control object are carried out, thereby realizing the no-steady-state-error tracking function of the controller. According to the invention, with integration of advantages of the fuzzy PI controller and the repetitive controller, the active filter can be operated safely, stably, and effectively.


Owner:SHENG YE ELECTRIC CO LTD
Space vector pulse width modulation (SVPWM) and fuzzy proportion integral (PI)-based grid-connected control method of Z-source inverter
InactiveCN106786738AReduce volumeLow costSingle network parallel feeding arrangementsZ-source inverterVoltage vector
The invention relates to a space vector pulse width modulation (SVPWM) and fuzzy proportion integral (PI)-based grid-connected control method of a Z-source inverter. An equivalent space rotation voltage vector is synthesized by selecting two adjacent effective vectors in the same section, an appropriate traditional zero vector and a direct-connection zero vector, the action times of the effective vectors are the same as that of a traditional voltage type inverter, and a part or all of action times of the traditional zero vector are substituted by direct-connection zero vectors. The SVPWM-based grid-connected inverter has the characteristics of high DC voltage utilization ratio, low harmonic distortion rate of a power grid current and no floating control, and decoupling control of direct-axis and quadrature-axis currents can be achieved; and a large output voltage range of the Z-source inverter, low harmonic distortion rate of the SVPWM grid-connection current and the advantage that a PI parameter can be adjusted on line by the fuzzy PI controller with regard to an error size are integrated, so that the system has the advantages of high control accuracy, good dynamic and static performance, high grid-connected power factor, high reliability and the like.


Owner:SHANGHAI UNIVERSITY OF ELECTRIC POWER
Method for designing fuzzy PI controller of Delta robot movement mechanism
InactiveCN104267598AOvercome the shortcomings of not being able to establish a definite mathematical modelFast dynamic responseAdaptive controlActuatorControl theory
The invention provides a method for designing a controller of a Delta robot movement mechanism based on LabVIEW graphical programming software and belongs to the technical field of robot control. The method is used for improving the dynamic response performance of a system and improving the tracking precision. The method for designing the controller of the Delta robot movement mechanism comprises the steps that the kinematic relation of a Delta robot is solved based on the structure of the Delta robot, and the inverse kinematical equations of an end effector moving to all shafts are established; the movement paths of all the shafts are fitted by means of a quintic polynomial curve; information obtained through feedback of an encoder of a servo motor and positional deviation e obtained through processing of an FPGA module are input to the fuzzy PI controller, and a speed pulse signal is output by the controller; a servo motor driver is driven through the FPGA module on a PCI-7842 board card of an NI, so that the motor is made to rotate to a specific position accurately and rapidly.
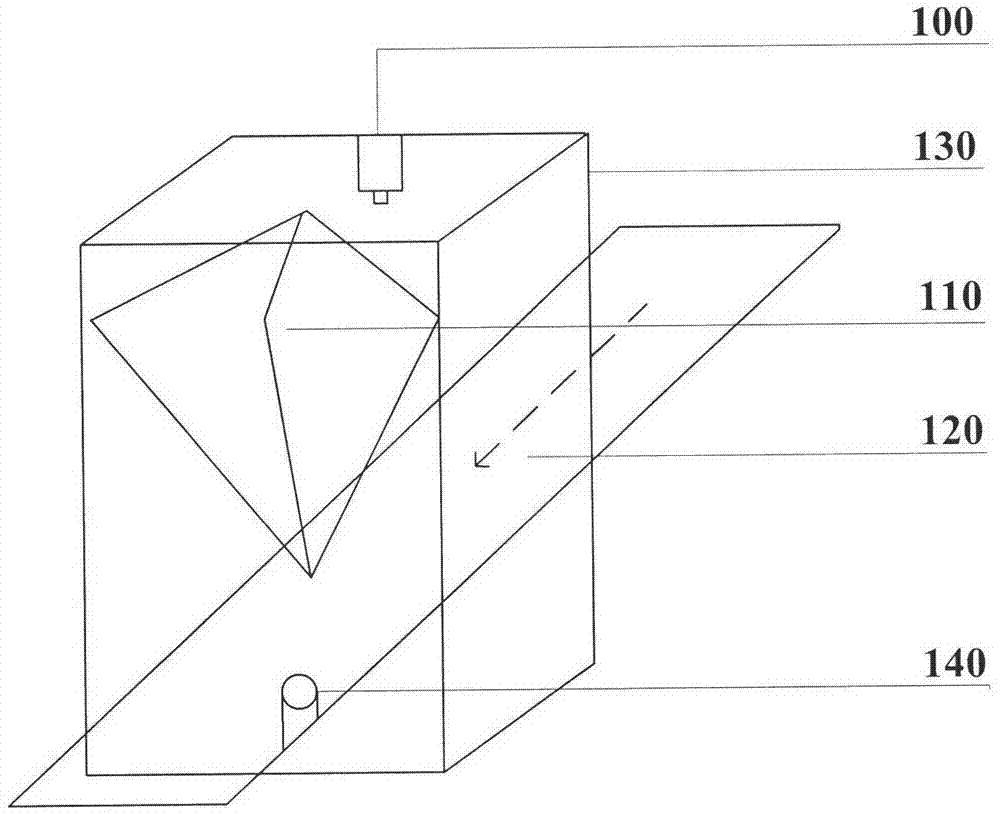
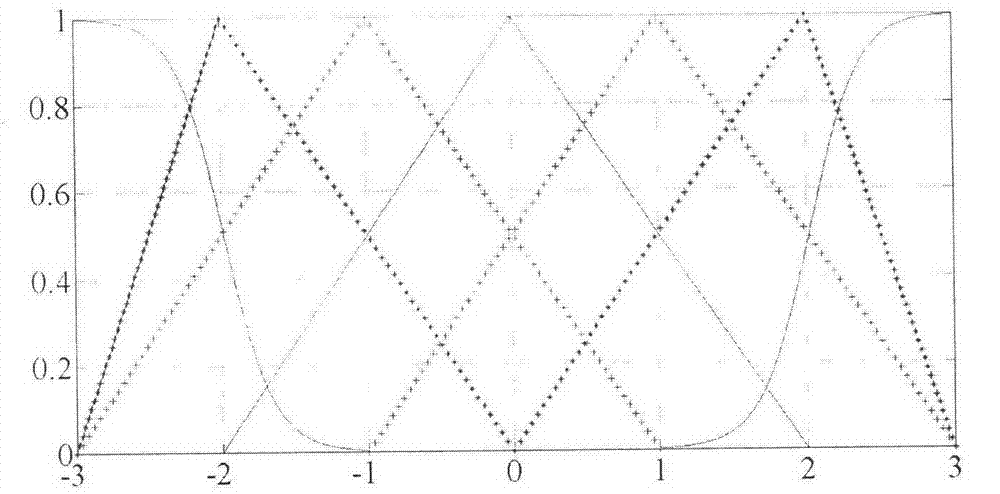
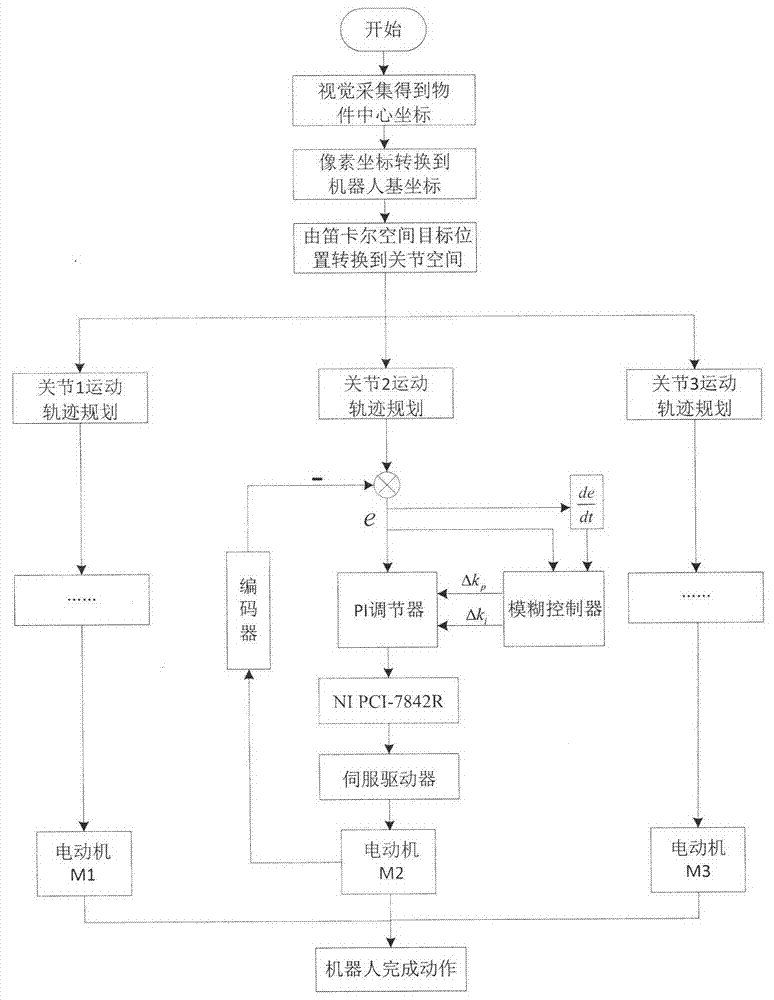
Owner:JIANGNAN UNIV
A fuzzy PI control method of boots circuit simulating load cell
ActiveCN109217664AAccurate trackingReduce overshootDc-dc conversionElectric variable regulationElectronic loadPeak value
The invention relates to the technical field of energy-fed direct current electronic load control, in particular to a fuzzy PI control method of a boots circuit simulating load cell, Normalization ofcontrol variables and selection of the same control variable, that is, input current average value IIN_Ref, are used to control multiple analog load modes. In addition, the feedback control loop and fuzzy PI controller are designed to track the input current more accurately in the nonlinear boost circuit, so as to meet the requirements of better dynamic response speed and static error, reduce current overshoot and protect the circuit system.


Owner:DONGGUAN LARGE ELECTRONICS CO LTD
Method for improving voltage sag endurance capacity of frequency converter without participation of energy storage equipment
ActiveCN111769773AImprove voltage sag toleranceImprove robustnessElectronic commutation motor controlElectric motor controlFrequency changerExternal energy
The invention discloses a method for improving the voltage sag endurance capacity of a frequency converter without participation of energy storage equipment. On the basis of the mode of improving thevoltage sag endurance capability of the frequency converter, a structure adopting external energy storage equipment or extra equipment is abandoned and a fuzzy flux weakening-vector control strategy is provided, so that the voltage sag endurance capability of the frequency converter is enhanced and the cost for improving the voltage sag endurance capability is reduced; in order to solve the technical problem, the invention provides a method for improving the voltage sag endurance capacity of a frequency converter without participation of energy storage equipment; a fuzzy flux weakening-vectorcontrol strategy is employed to control a frequency converter; and a fuzzy PI controller is used to replace an original PI controller so as to enhance the robustness of a control system to system parameter changes; and flux-weakening control is adopted, and a flux linkage reference value is changed under the condition of sag, so that the energy of the magnetic field is maintained to be transferredto torque current. The combination of the two improves the voltage sag endurance capability of the frequency converter.


Owner:ELECTRIC POWER RES INST STATE GRID SHANXI ELECTRIC POWER
Multi-loop voltage regulation control method for three-stage brushless synchronous motor
ActiveCN111030528AImprove dynamic characteristicsOpen loop gain unchangedSynchronous generator controlGenerator control by field variationMOSFETSynchronous motor
The embodiment of the invention discloses a multi-loop voltage regulation control method for a three-stage brushless synchronous motor, relates to the technical field of synchronous motors, and realizes that the motor does not need to be accurately modeled and an additional DC-DC converter is not needed. The method comprises the following steps: updating Kp value initial gain of a fuzzy PI controller of a voltage loop by utilizing the rotating speed signal of a three-stage brushless synchronous motor; using the sum of the current signal outputted by the fuzzy PI controller and the current signal fed forward by the load current as the reference value of the excitation current loop, and then obtaining the error of the excitation current of the alternating-current exciter; inputting the errorinto the PI controller of the excitation current loop, and outputing a PWM signal in a digital generator controller (GCU) to control on or off of the MOSFET in the excitation power circuit of the three-stage brushless synchronous motor so that the magnitude of excitation current of the alternating-current exciter is controlled, and voltage stability is maintained. The method is applicable to theaircraft variable-frequency alternating-current power generation system.


Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Permanent magnet synchronous motor speed regulation system variable universe fuzzy PI control method and system
PendingCN119582669AImprove adaptabilityquick responseElectronic commutation motor controlElectric motor controlMotor speedPhase currents
The invention provides a permanent magnet synchronous motor speed regulation system variable universe fuzzy PI control method and system, and relates to the technical field of motor speed regulation system control. The motor rotating speed deviation is determined; current controller parameters are adjusted based on the rotating speed deviation, and a q-axis current given value is obtained; converting the three-phase current into a two-phase static coordinate system; converting the static coordinate system current into a rotating coordinate system; d-axis current and q-axis current are adjusted respectively, and d-axis reference voltage and q-axis reference voltage are obtained; converting the d-axis reference voltage and the q-axis reference voltage into a static coordinate system; modulating the voltage of the static coordinate system to obtain an inverter control signal; and outputting an inverter control signal to the three-phase voltage inverter to drive the permanent magnet synchronous motor to operate. Compared with a traditional fuzzy PI controller, the method has the advantages of being rapid in speed response, small in torque pulsation, high in control precision and high in disturbance rejection capacity.


Owner:STATE GRID HEBEI ELECTRIC POWER COMPANY TRAINING CENT +1
High-power photovoltaic array simulator control method based on fuzzy PI control
ActiveCN106647284ASmall steady state errorSmall overshootAdaptive controlStable stateReference current
The present invention discloses a high-power photovoltaic array simulator control method based on fuzzy PI control. The method employs a three-phase PWM rectifying circuit, and a control structure comprises: a V-I characteristic curve module, a fuzzy controller, a PI controller, a Park conversion module, a Clark conversion module and an SVPWM controller. The control method comprises: a rated open-circuit voltage Voc is compared to a virtual voltage Vdc to obtain error signals when opening a circuit, a reference current Idc_ref is compared to an actual current Idc to obtain error signals when load, the fuzzy PI controller is operated to obtain control reference signals, and the control signals are outputted through the SVPWM. The high-power photovoltaic array simulator control method based on the fuzzy PI control introduces the simulator open circuit voltage to individually control the loop so as to ensure the safely and stably operate the system; and moreover, the high-power photovoltaic array simulator control method is connected in series with the fuzzy PI controller to effectively combine the advantages so as to ensure the good dynamic performance of high stable state precision of the system.


Owner:GUANGZHOU INST OF ENERGY CONVERSION - CHINESE ACAD OF SCI
Three-phase current tracking type inverter control method based on fuzzy PI control
InactiveCN113014132AThe self-recovery process is faster than pure PI controlEasy to controlAc-dc conversionDefuzzificationCurrent sensor
The invention relates to a three-phase current tracking type inverter control method based on fuzzy PI control, and the method comprises the steps of obtaining a load side current of a three-phase inverter through a current sensor, obtaining the difference of the load side current and a given tracking current, carrying out fuzzification processing on a difference value and a difference value change rate, and carrying out fuzzy setting, fuzzy reasoning and defuzzification so as to realize the real-time adjustment of the parameters of a PI controller; and comparing the output of the fuzzy PI controller with a triangular wave to generate a required PWM waveform, so that the three-phase inverter is controlled. According to the method, the fuzzy control and the PI control are utilized, the proportion and integral coefficients can be adjusted in real time, the problem that the parameters of a traditional PI controller are fixed is solved, and the robustness, adaptability and anti-jamming capability of the three-phase current tracking type inverter can be improved.


Owner:FUZHOU UNIV
Electric load simulator control method based on negative feedback correction
InactiveCN111399377ANoise reduction effectImprove stabilityAdaptive controlNegative feedbackSelf-tuning
The invention discloses an electric load simulator control method based on negative feedback correction. The electric load simulator control method comprises the steps of: firstly, establishing a mathematical model of an electric load simulator system; secondly, performing stability analysis on the established electric load simulator system; thirdly, if the system is unstable, correcting the system as needs; if the system is stable but a loading bandwidth does not meet the loading requirement, correcting the system as needs; fourthly, correcting the electric load simulator system; and finally,introducing fuzzy control, designing a self-adaptive fuzzy PI controller, and improving control precision and robustness of the system by self-tuning a proportionality coefficient KP and an integralcoefficient KI of the PI controller and further adjusting the value of a time constant Kfd of torque differential negative feedback. The electric load simulator control method is simple in algorithm,easy to implement and smooth in output, and can effectively improve the stability and robustness of the system.


Owner:NANJING UNIV OF SCI & TECH
PI (Proportional Integral) parameter mixed setting method
ActiveCN102426417BVerify validityImprove dynamic performanceControllers with particular characteristicsControl vectorControl system
The invention relates to a PI (Proportional Integral) parameter mixed setting method, which is a model-based mixed setting method combining off-line setting and fuzzy PI on-line setting for ensuring that a closed loop vector control system works in an optimal state. The PI parameter mixed setting method comprises the following steps of: firstly deducing a mathematic model of a system according to a vector control principle, calculating rotational inertia by a method of constant torque start and machine free stop, and calculating PI parameters and inner ring compensation dosage according to the mathematic model; proposing a new PI control rule table by a fuzzy PI controller; and finally verifying the exactness of the PI parameters by a comparison test. According to the PI parameter mixed setting method disclosed by the invention, the dynamic property and the steady state precision of the system are improved and are better than those of a system utilizing a single setting method, and the validity of the method is verified.


Owner:WISDRI WUHAN AUTOMATION
Permanent magnet synchronous motor servo control system based on fuzzy PI control
InactiveCN111934585AAdaptableImprove anti-interference abilityElectronic commutation motor controlVector control systemsPermanent magnet synchronous motorFuzzy pi
The invention relates to a permanent magnet synchronous motor servo control system based on fuzzy PI control. The system comprises a current loop structure, a speed loop structure and a position loopstructure which are arranged from inside to outside, the speed loop structure and the position loop structure perform parameter control based on a fuzzy PI controller, and the data processing processof the fuzzy PI controller comprises the following steps: 1) obtaining an error and an error change rate in real time; 2) performing fuzzification, fuzzy reasoning, defuzzification and parameter correction on the error and the error change rate in sequence to obtain a parameter adjustment amount; and 3) based on the error, the error change rate and the parameter adjustment amount, performing parameter control through a PI controller. Compared with the prior art, PI control and fuzzy control are combined to form fuzzy PI control, the anti-interference capability of the system is well improved,the steady state and dynamic performance of the system are improved, the dynamic error of the system can be effectively eliminated, and the control precision is improved.


Owner:TONGJI UNIV
Design method of fuzzy PI controller for EMU rectifier
ActiveCN110445132AImprove stabilityReduce DC voltage overshootAc-dc conversionPower oscillations reduction/preventionIntegratorVoltage overshoot
The invention discloses a design method of a fuzzy PI controller for an EMU rectifier, and the method comprises the following steps of constructing a dynamic characteristic relationship of AC side voltage and current of an EMU network side rectifier; decoupling by a two-phase generalized integrator to obtain a d-q two-phase rotating coordinate system current predictive model; considering a methodof combining fuzzy control and PI control to compensate for the shortcomings such as poor robustness of the PI control itself, controlling and correcting the input quantity through the processes suchas fuzzification, fuzzy inference and clearing in the controller; and controlling the voltage to be subjected to SPWM modulation to obtain the control pulse. The design method provided by the invention does not depend on the accurate mathematical model of the system, and has strong adaptability. The fuzzy PI control has the characteristics of small total harmonic distortion, small current distortion, small voltage overshoot on the DC side, fast dynamic response, etc. The problem of low frequency oscillation of the electric quantity of the traction network-EMU can be effectively restrained.


Owner:SOUTHWEST JIAOTONG UNIV
Ultra-high precision pneumatic force servo system and intelligent control parameter optimization method therefor
The present invention provides an ultra-high precision pneumatic force servo system and an intelligent control parameter optimization method therefor. The pneumatic force servo system is mainly composed of a double-acting air-floating frictionless cylinder and a pressure control system; the effect of friction on the control accuracy can be removed by using the air-floating frictionless cylinder; the pressure control system achieves ultra-high precision control of pressure by means of a fuzzy PI controller optimized on the basis of a novel improved particle swarm algorithm; a Gaussian variation strategy and a fuzzy control theory are integrated in the novel improved particle swarm algorithm; optimized fuzzy PI control parameters are obtained using the novel improved particle swarm algorithm and ultra-high precision pressure control of a chamber of the air-floating frictionless cylinder is performed on the basis of the parameters, such that ultra-high precision force output of the system can be achieved; the pneumatic servo system provided by the present invention can be applied to occasions where high control accuracy of force is required, expanding the application range of the pneumatic servo system.

Owner:ZHEJIANG LINIX MOTOR CO LTD +1
PMSM fuzzy PI controller optimization method based on improved artificial bee colony algorithm
The invention discloses a PMSM fuzzy PI controller optimization method based on an improved artificial bee colony algorithm. The method comprises the following steps: constructing a fuzzy PI controller to output a control quantity in real time; and an improved artificial bee colony algorithm is adopted to optimize six-dimensional parameters. In the algorithm, all individuals are initialized as worker bees, the first half iteration period is explored by using a traditional formula, and the second half iteration period is searched by using an improved formula integrated with global optimal information; screening 30% of worker bees by combining fitness sorting with a roulette method, and converting the worker bees into observation bees for local exploration; the forgetting threshold Limit is dynamically adjusted along with the number of iterations and is adjusted along with the change of the population fitness value, when the number of individual forgetting times exceeds the Limit, a reconnaissance bee is converted into a reconnaissance bee, and an improved formula integrated with global optimal information is adopted for searching again. And calculating an individual fitness value through an improved fitness function, transmitting the individual fitness value back to the algorithm to perform advantage and disadvantage comparison of a solution, and outputting a global optimal parameter after iterating to the maximum number of times. By improving the search strategy, the selection mechanism and the fitness function of the algorithm, efficient parameter optimization is realized, the control precision, the response speed and the robustness of the PMSM fuzzy PI controller are remarkably improved, and the application prospect is good.

Owner:GUANGXI NORMAL UNIV
Island power grid optimization power distribution method based on fuzzy PI-PD droop control
PendingCN111682590AImprove anti-interference abilityReduce voltageSingle network parallel feeding arrangementsPower oscillations reduction/preventionIslandingFuzzy rule
The invention discloses an island power grid optimization operation method based on fuzzy PI-PD droop control. The method comprises: building a droop control model added with a fuzzy PI-PD controller,wherein the fuzzy PI controller is composed of a fuzzy controller and a traditional PI controller; setting an input set and a fuzzy rule table required by fuzzy control; transmitting the deviation ofvoltage and frequency and the deviation change rate to the fuzzy controller, outputting the set KP and KI to the traditional PI controller, processing the KP and KI through a PD controller, and outputting a result; adding a new voltage parameter into a reactive droop control link, enabling a frequency parameter to pass through a unit integral link for 1 / s (s is a pull operator), and adding into an active droop control loop; and performing voltage synthesis on the parameters obtained in the two links to obtain a reference voltage. According to the invention, system output is adjusted in real time according to changes of voltage and frequency, so that voltage and frequency deviation is reduced, the anti-interference capability of the microgrid during operation is improved, the robustness ofthe system is enhanced, and the stability and reliability of the system are improved.


Owner:SICHUAN UNIV
Ultra-high-precision aerodynamic force servo system and intelligent control parameter optimization method therefor
An ultra-high-precision aerodynamic force servo system and an intelligent control parameter optimization method therefor. The aerodynamic servo system is mainly composed of a double-acting air-floatin

Owner:ZHEJIANG LINIX MOTOR CO LTD +1
Motor control method and device, motor, storage medium and processor
ActiveCN113489407AImprove robustnessSmooth switchingElectronic commutation motor controlAC motor controlElectric machineControl engineering
The invention discloses a motor control method and device, a motor, a storage medium and a processor. The method comprises the steps of: using an FOC control strategy as a control strategy for controlling the motor under the condition that the motor is started; under the condition that the motor operates after being started, acquiring operation parameters of the motor; and according to the operation parameters of the motor, controlling the motor to switch from the FOC control strategy to use any one of a DTC control strategy, an FOC-DTC hybrid control strategy and a set magnetic field intensity control strategy, wherein a fuzzy PI controller is used in the process of controlling the switching to use any one of the DTC control strategy, the FOC-DTC hybrid control strategy and the set magnetic field intensity control strategy, and the switching of the operation parameters of the motor is controlled. According to the motor control method and device, two or more control strategies are switched for use in different control strategies of the motor (such as a permanent magnet synchronous motor), so that the robustness of the motor in the operation process can be improved.


Owner:GREE ELECTRIC APPLIANCES INC
Double-fuzzy PI controller of three-phase full-bridge circuit voltage outer loop and control method thereof
PendingCN111756267AEasy to controlStable jobElectronic commutation motor controlVector control systemsDifferentiatorFull bridge
The invention discloses a double-fuzzy PI controller of a three-phase full-bridge circuit voltage outer loop. The double-fuzzy PI controller is connected to a three-phase full-bridge circuit, and is used for collecting parameter signals on the three-phase full-bridge circuit, and realizing control over the three-phase full-bridge circuit. The double-fuzzy PI controller comprises a sub-fuzzy controller, a main fuzzy controller, a differentiator and a PI regulator, and solves the problem that a system cannot well adapt to changes of two parameters to work normally when the three-phase full-bridge circuit is under the working conditions of wide-network-side alternating-current voltage and wide-direct-current-side voltage.


Owner:YANGZHOU UNIV
Self-adaptive control method for electrically-controlled electric gear shifting executing mechanism
PendingCN119244738Asolve precise controlresolve uncertaintyGearing controlGenetic algorithmsActuatorFuzzy pi controller
The invention relates to a self-adaptive control method for an electrically-controlled electric gear shifting executing mechanism, and aims to overcome the influence of uncertain problems such as parameter perturbation and external interference in the gear shifting process and quickly and accurately complete the gear shifting action. The method comprises the following steps: firstly, modeling a gear shifting execution mechanism according to a working principle of the gear shifting execution mechanism; secondly, considering the uncertainty of external interference and the parameters of the gear-shifting direct current motor, adding a sliding mode control algorithm, optimizing a membership function of fuzzy sliding mode control through a genetic algorithm, and realizing the self-adaptive adjustment of sliding mode control gain and following the actual response characteristics of the gear-shifting direct current motor; and finally, a fuzzy PI controller is designed to carry out adaptive adjustment on the duty ratio of the gear-shifting direct current motor, and accurate tracking of the displacement of the gear-shifting execution mechanism is completed. According to the method, the tracking precision, the response speed, the anti-interference capability and the like of the control of the gear shifting execution mechanism are improved through the online self-adaptive adjustment of the control parameters.

Owner:ZHENGZHOU UNIVERSITY OF LIGHT INDUSTRY
Surface-mounted permanent magnet synchronous motorized spindle vector control method based on id = 0 control
PendingCN113437911AEasy to controlGood global control effectElectronic commutation motor controlElectric motor controlStator voltageRegulator
The invention discloses a surface-mounted permanent magnet synchronous motorized spindle vector control method based on id = 0 control. The method comprises the steps of 1) taking the difference value between the actual rotating speed and the given rotating speed of a permanent magnet synchronous motorized spindle as the input of a fuzzy PI regulator, screening the input current through the fuzzy PI regulator, and calculating the q-axis current iq of the motorized spindle; 2) taking q-axis current iq and d-axis current id = 0 output by the fuzzy PI controller as input, subtracting the input from the closed-loop current, and obtaining direct-axis stator voltage ud and quadrature-axis stator voltage uq through a linear active-disturbance-rejection current controller; and 3) performing SVPWM conversion according to the voltage ualpha and the voltage ubeta, and acting on a power switch device on a main circuit inverter to realize id = 0 control of the permanent magnet synchronous motorized spindle. According to the method, the difficulty of manual parameter adjustment is reduced, the control can be more efficient by combining an intelligent control mode with linear active disturbance rejection control, the overshoot is greatly reduced, and the method is very stable under a high-speed operation condition.


Owner:JIANGSU UNIV OF TECH
Ultra-high-precision aerodynamic force servo system and intelligent control parameter optimization method therefor
An ultra-high-precision aerodynamic force servo system and an intelligent control parameter optimization method therefor. The aerodynamic servo system is mainly composed of a double-acting air-floating friction-free cylinder (10) and a pressure control system. The effect of friction on the output force control precision can be removed by using the air-floating friction-free cylinder (10); in the pressure control system, ultra-high-precision control over the pressure is realized by means of a fuzzy PI controller optimized on the basis of a new improved particle swarm algorithm; a Gaussian mutation policy and a fuzzy control theory are fused in the new improved particle swarm algorithm; and optimized fuzzy PI control parameters are obtained by using the new improved particle swarm algorithm, ultra-high-precision pressure control over a cavity of the air-floating friction-free cylinder (10) is executed on the basis of the parameters, and an ultra-high-precision force output of the system can be realized. The aerodynamic force servo system can be applied to occasions with very high requirements for force control precision, and expands the application range of the aerodynamic force servo system.

Owner:ZHEJIANG LINIX MOTOR CO LTD +1
Characteristic harmonic compensation method based on improved STATCOM
PendingCN121863459AExcellent dynamic reactive power compensation performanceimprove performanceFlexible AC transmissionReactive power adjustment/elimination/compensationReference currentHemt circuits
The method comprises the following steps: extracting frequency information of power grid voltage based on a characteristic harmonic compensation method of an improved STATCOM to obtain a reference phase and frequency of h-order harmonic; the load current is converted into a d-q coordinate system through a Cabc-dqh change matrix module and decomposed into a load active current component and a load reactive current component, and then a reference current instruction value is obtained through low-pass filtering; performing low-pass filtering on the active current component and the reactive current component to obtain a system side current component as a reference value; comparing each separated harmonic current component with a reference value, and inputting the current components to a fuzzy PI controller to obtain voltage compensation instructions of the characteristic harmonic waves under a d axis and a q axis respectively; and superposing each compensation instruction and the original reactive compensation and direct-current voltage control instruction of the STATCOM, and then inputting PWM (Pulse Width Modulation) to enable the STATCOM to output current containing a characteristic harmonic compensation component. According to the method, multi-synchronous rotating coordinate system detection and fuzzy PI adaptive control are introduced, and dynamic and accurate compensation of multiple characteristic harmonics is realized on the premise of not changing the main circuit topology of the STATCOM.

Owner:CHINA THREE GORGES UNIV
Fuzzy PI control method for BP neural network optimized totem pole PFC circuit
PendingCN120085529AEfficient power electronics conversionControllers with particular characteristicsReference currentClosed loop
The invention provides a fuzzy PI control method of a totem-pole PFC circuit optimized by a BP neural network. The method comprises the following steps: constructing the totem-pole PFC circuit; and constructing a voltage and current sampling circuit. A voltage loop and current loop double closed loop controller is constructed, the voltage loop controller adopts a fuzzy PI controller optimized by a BP neural network, and the integral rate of the fuzzy PI controller is optimized through the BP neural network. In a current loop controller, output of a voltage loop controller is multiplied by output of a phase-locked loop, obtained reference current iref is subtracted from inductive current iL, a duty ratio is obtained through a current loop PI controller, a duty ratio signal is sent into a PWM generator to generate a PWM signal, the PWM signal is used for controlling on and off of two GaN switching tubes, input current tracks an input voltage phase, and the phase-locked loop is switched off. Therefore, the purpose of power factor correction is achieved. According to the invention, the stability and response speed of the totem-pole bridgeless PFC circuit are improved.

Owner:DALIAN UNIV OF TECH