
Patents
Literature
69 results about "Geopotential model" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
In geophysics, a geopotential model is the theoretical analysis of measuring and calculating the effects of Earth's gravitational field.
GNSS-CCD-integrated zenith telescope high-precision vertical deflection fast measurement method
ActiveCN104913780AShorten the timeMeasurement accuracyNavigational calculation instrumentsInformaticsFixed starsStar catalogue
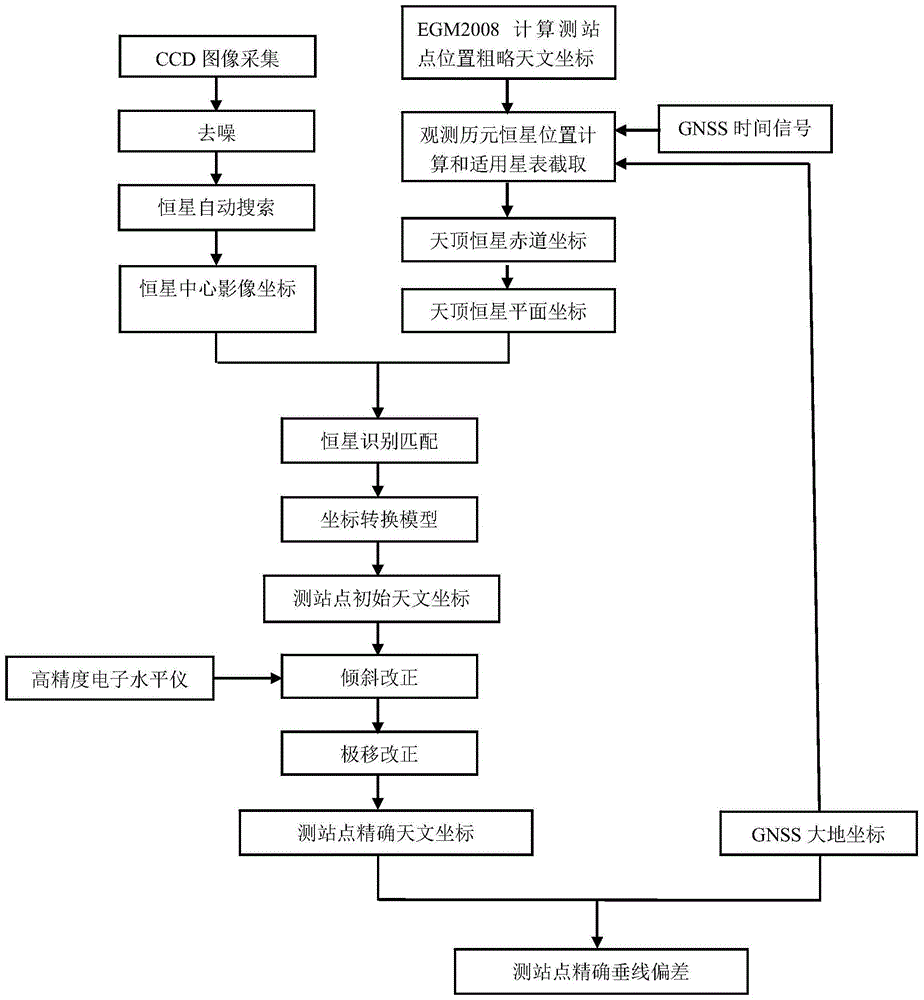
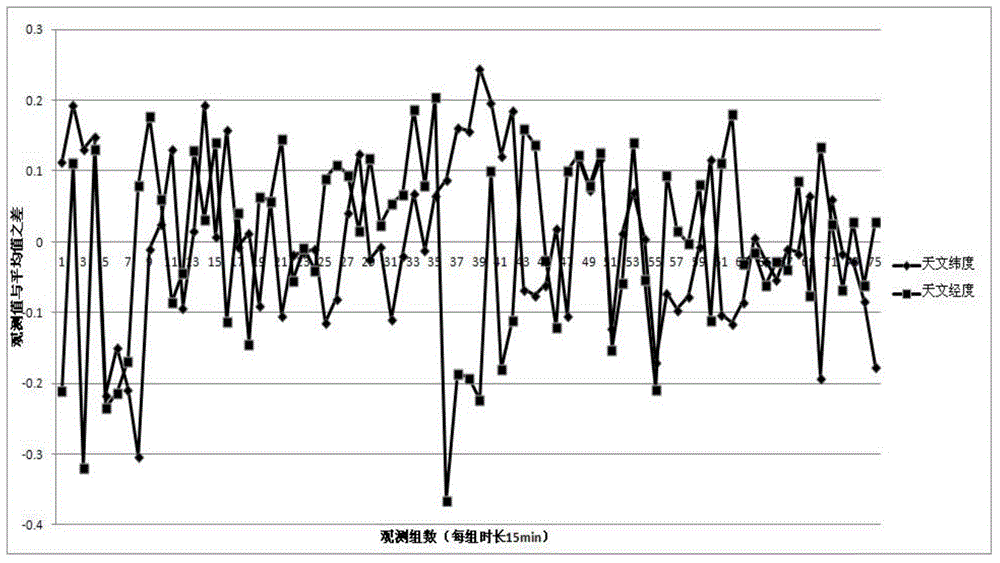
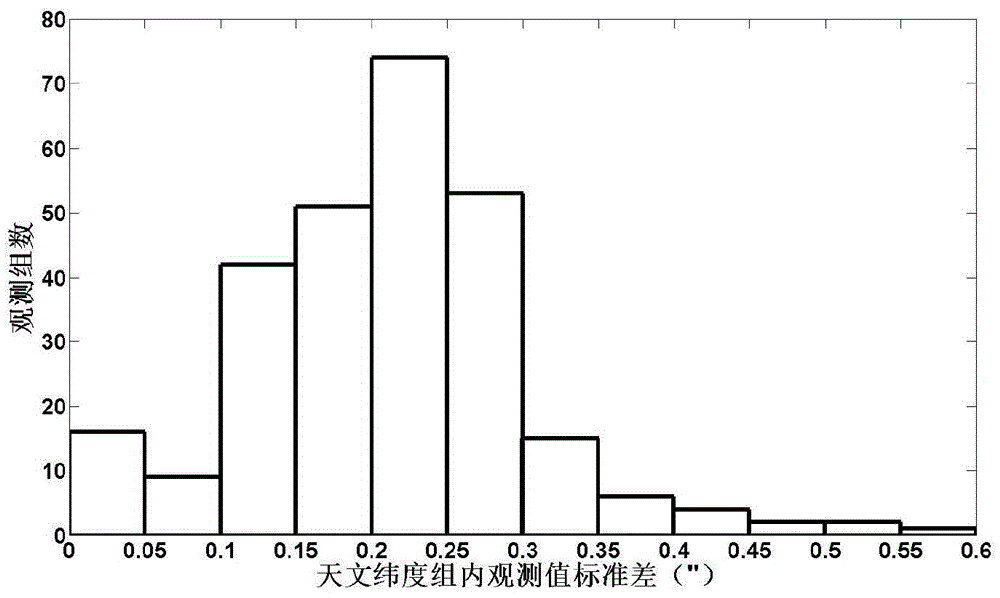
The invention discloses a GNSS-CCD-integrated zenith telescope high-precision vertical deflection fast measurement method. At a measurement station, the optical axis of a zenith telescope faces to the zenith and takes a picture of a zenith zone so that a CCD fixed star image is obtained, fixed star image coordinates are calculated, exposure epoch is controlled by geodetic coordinates and a GNSS time signal measured by GNSS, fixed star information in the zenith zone is acquired in an appropriate star catalogue according to the measurement station vertical deflection calculated by an EGM2008 geopotential model, coupling identification of fixed stars in a zenith tangent plane zone of a celestial sphere in the star catalogue and in the CCD fixed star image is realized, zenith astronomical coordinates are calculated by least spuare iterative computation, and vertical deflection of the observed point is calculated according to geodetic coordinates. Compared with the prior art, the method provided by the invention has the characteristics of simple operation, time and labor saving and high measurement precision and is suitable for high-precision vertical deflection fast measurement.
Owner:SHANDONG UNIV OF SCI & TECH
Method for improving ocean gravity field interpolation precision based on submarine topography three-dimensional optimization principle
PendingCN112229404ALower underwater navigationReduce mistakesNavigational calculation instrumentsGravitational wave measurementHigh spatial resolutionGravity anomaly
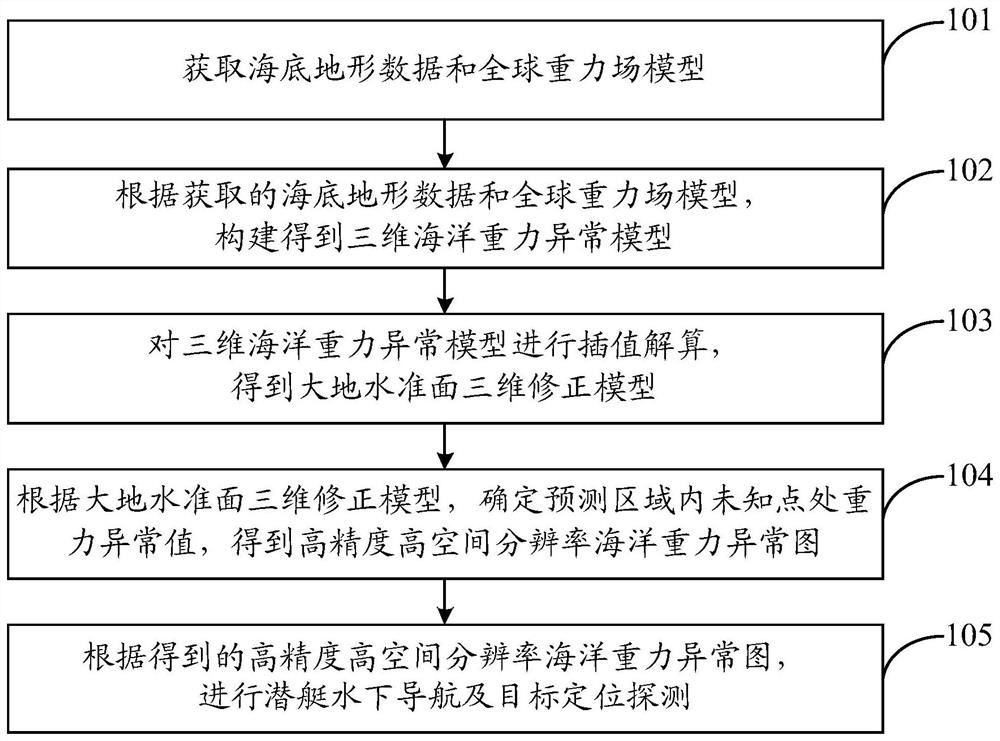
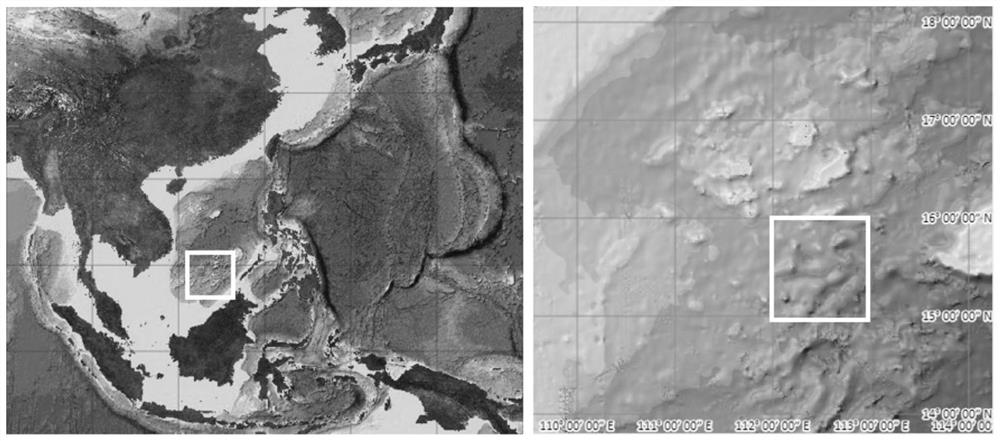
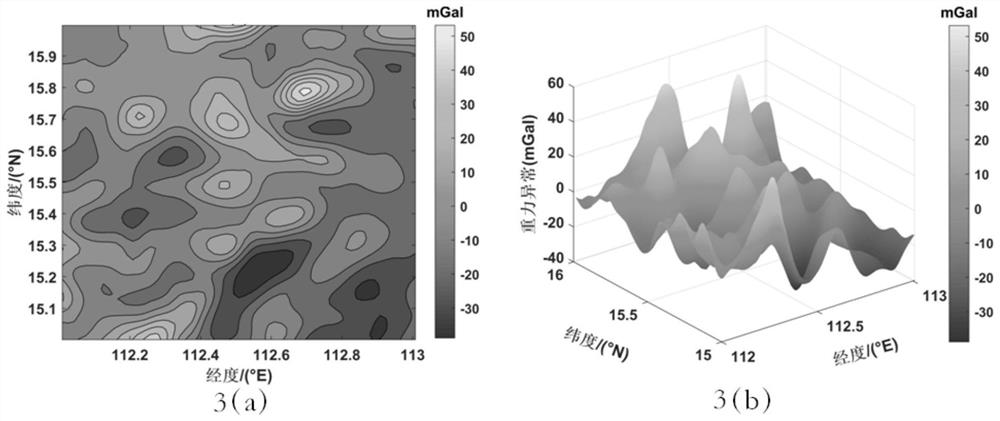
The invention discloses a method for improving ocean gravity field interpolation precision based on a submarine topography three-dimensional optimization principle. The method comprises steps of submarine topography data and a global gravity field model being acquired; constructing a three-dimensional ocean gravity anomaly model according to the acquired submarine topographic data and the global gravity field model; performing interpolation calculation on the three-dimensional ocean gravity anomaly model to obtain a geoid three-dimensional correction model; and according to the geoid three-dimensional correction model, determining a gravity anomaly value at an unknown point in the prediction area to obtain a high-precision and high-spatial-resolution marine gravity anomaly map. According to the method, the submarine topography is introduced into a common two-dimensional Kriging formula, a novel submarine topography three-dimensional optimization method is constructed, the precision loss is minimized while the spatial resolution of the global marine gravity anomaly map is improved, the interpolation precision is high, the calculation speed is high, and an effective basis is providedfor improving the submarine gravity matching navigation precision.
Owner:CHINA ACADEMY OF SPACE TECHNOLOGY
Submarine navigation method and system based on multi-dimensional gravity gradient lighthouse
ActiveCN111595345AImprove securityImprove accuracyNavigational calculation instrumentsClassical mechanicsSubmarine navigation
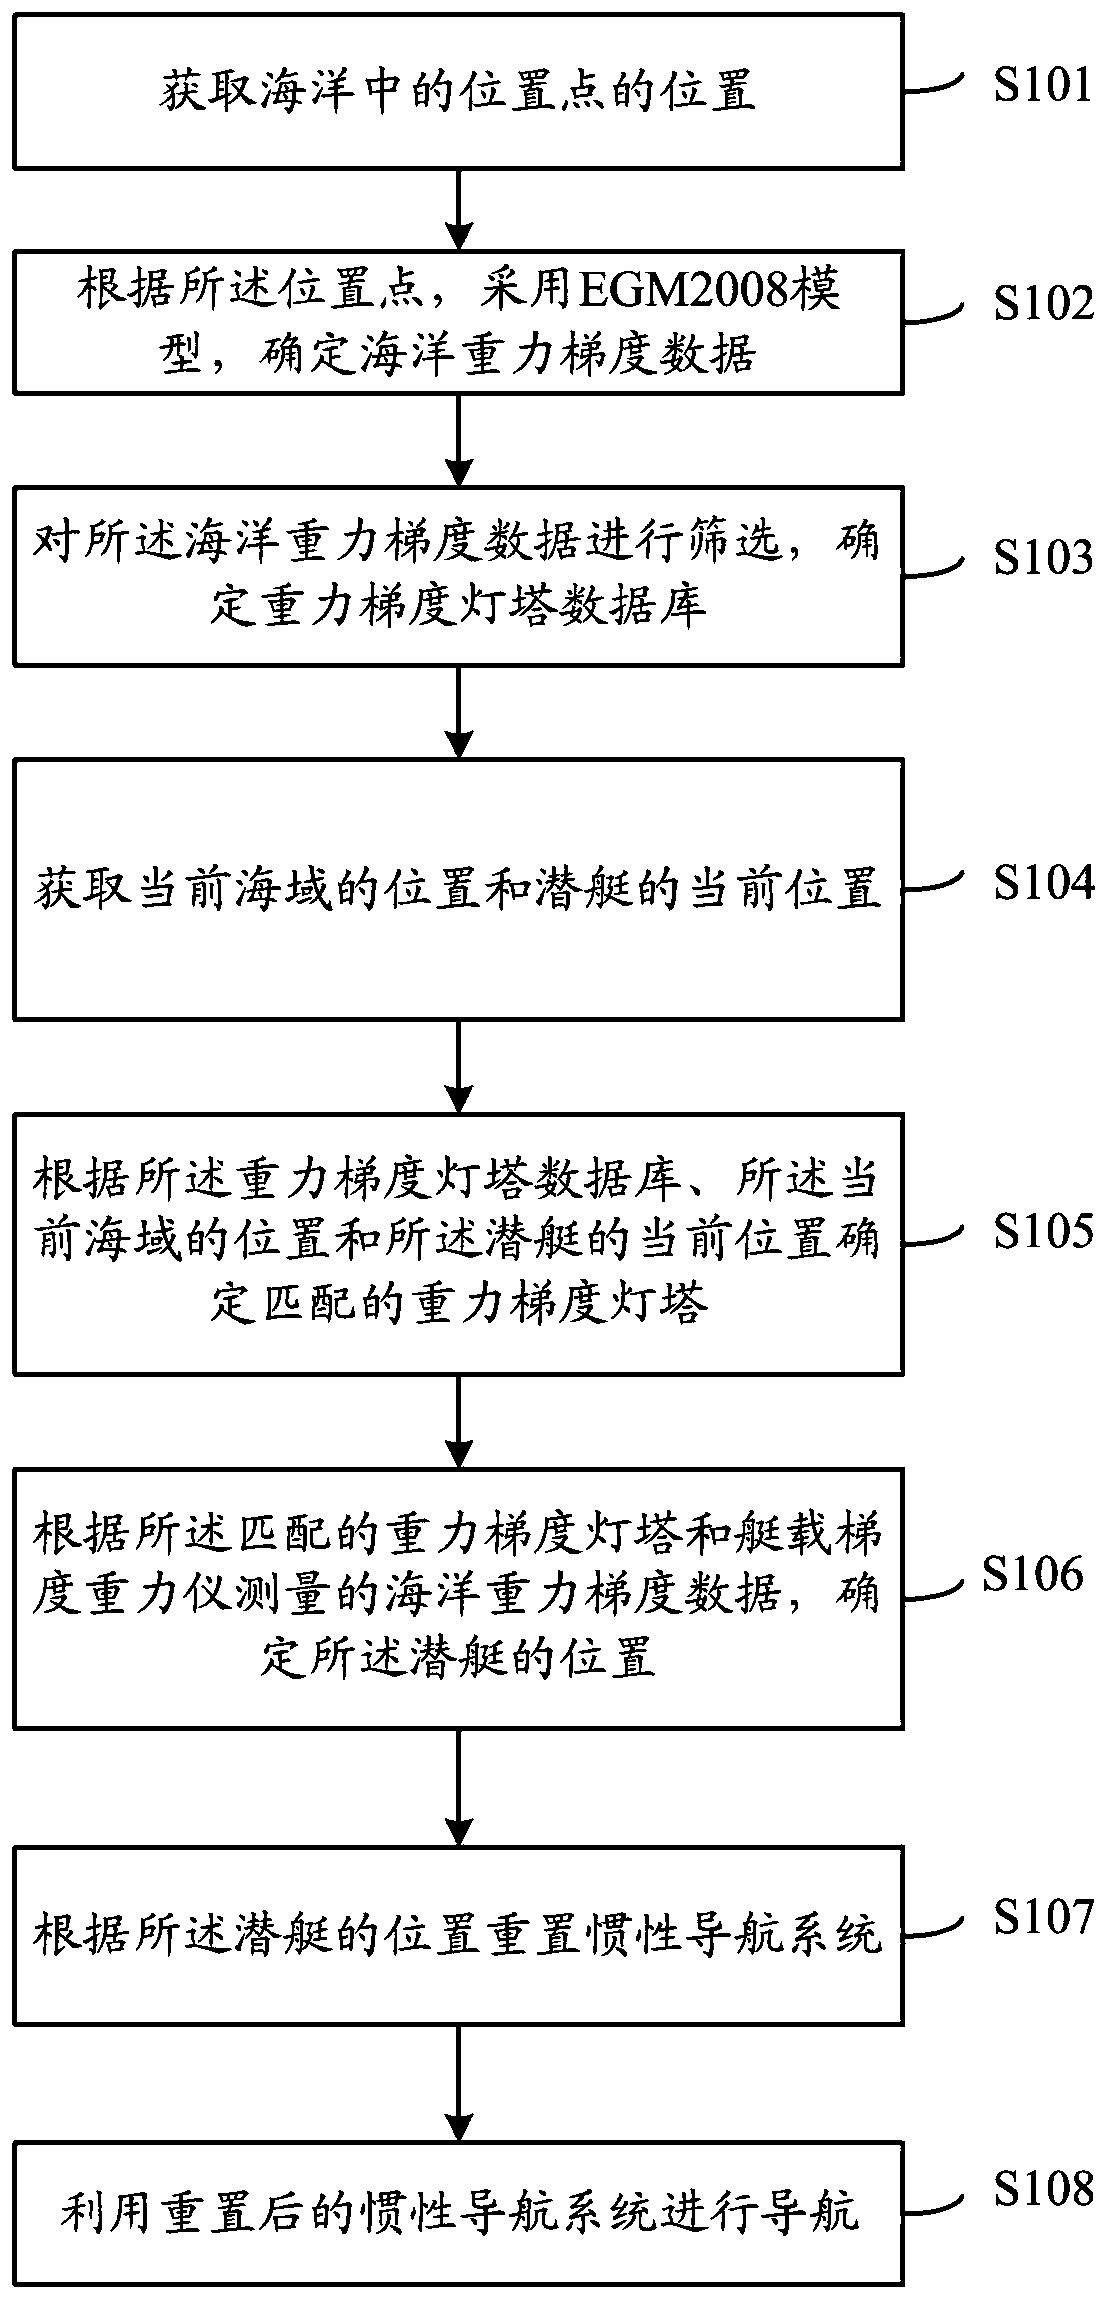
The invention relates to a submarine navigation method and a submarine navigation system based on a multi-dimensional gravity gradient lighthouse. The submarine navigation method comprises the following steps of: acquiring the position of a position point in the ocean; according to the position point, adopting a high-precision gravity field model to determine ocean gravity gradient data; screeningthe ocean gravity gradient data, and determining gravity gradient lighthouses; acquiring the position of the current sea region and the current position of a submarine; determining a matched gravitygradient lighthouse according to a gravity gradient lighthouse database, the position of the current sea region and the current position of the submarine; determining the position of the submarine according to the matched gravity gradient lighthouse and marine gravity gradient data measured by a ship-borne gradient gravimeter; and resetting an inertial navigation system according to the position of the submarine. According to the submarine navigation method and the submarine navigation system based on the multi-dimensional gravity gradient lighthouse, the safety and accuracy of navigation of the gravity lighthouse in a gravity gentle region can be improved.
Owner:中国人民解放军61540部队 +1
Method for improving ocean gravity reconstruction precision based on geoid three-dimensional correction principle
PendingCN112229403AImprove forecast accuracyImprove spatial resolutionNavigational calculation instrumentsForecastingReference mapGravity anomaly
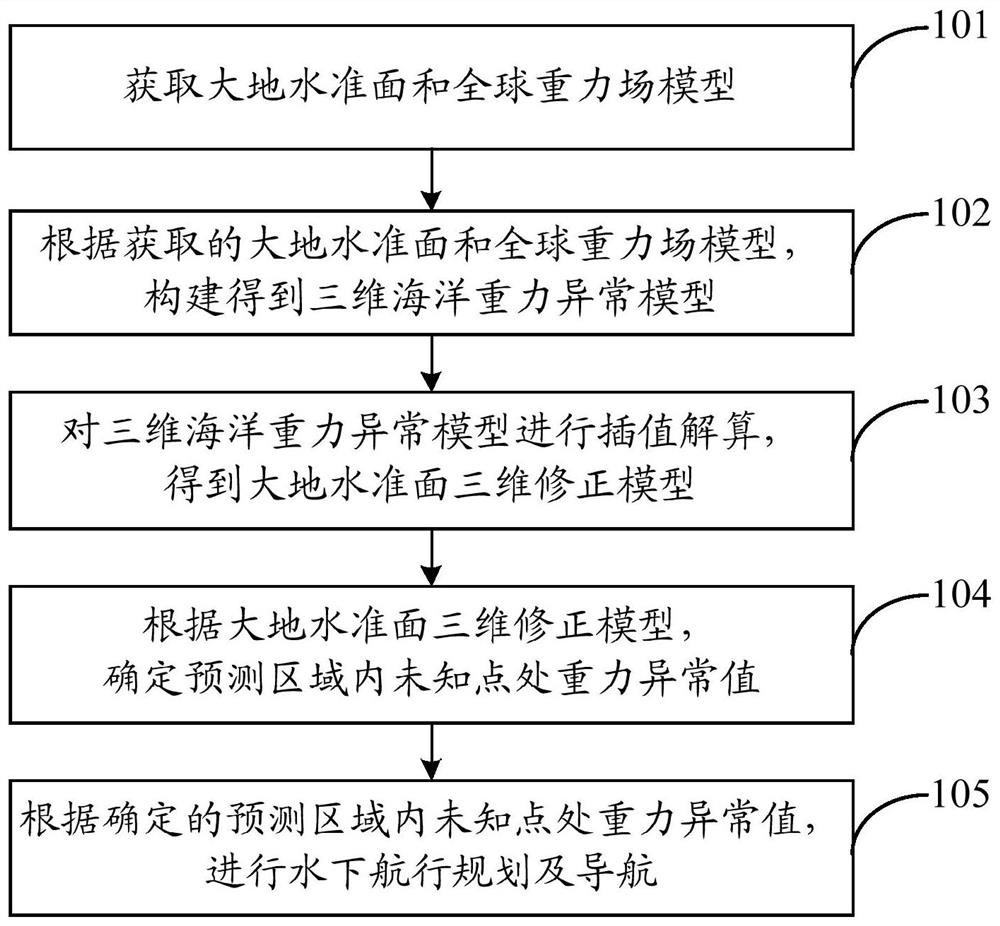
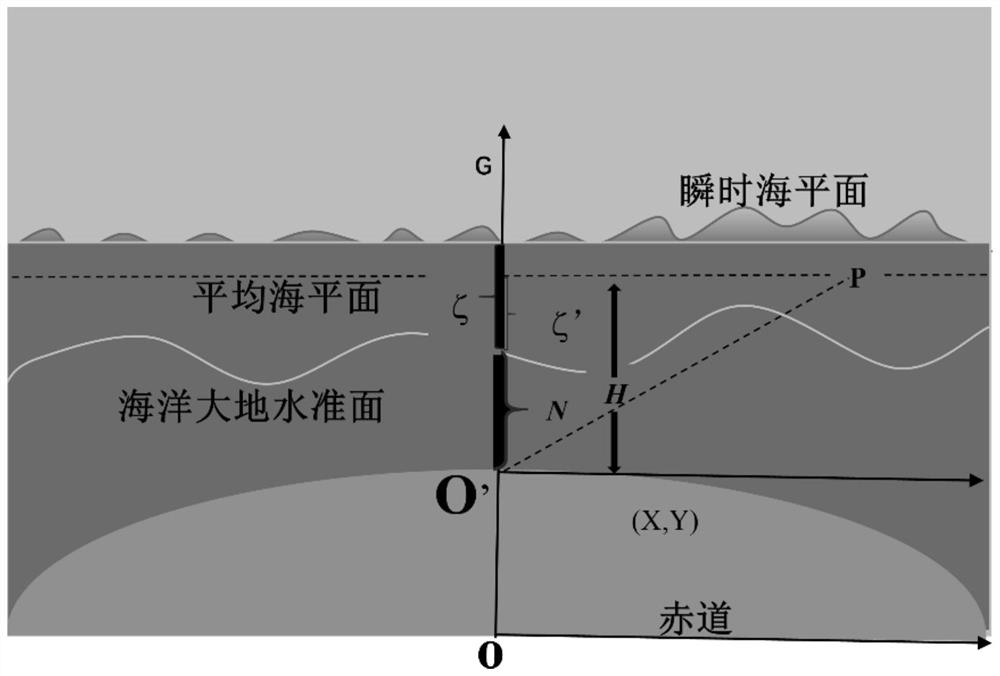
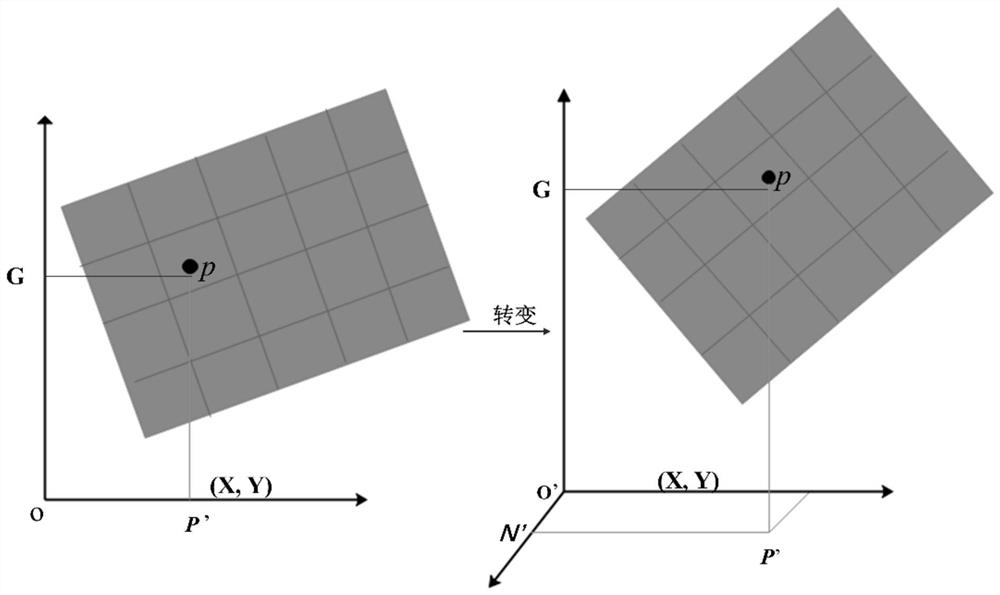
The invention discloses a method for improving ocean gravity reconstruction precision based on a geoid three-dimensional correction principle. The method comprises steps of a geoid and a global gravity field model being acquired; constructing a three-dimensional ocean gravity anomaly model according to the obtained geoid and global gravity field model; performing interpolation calculation on the three-dimensional ocean gravity anomaly model to obtain a geoid three-dimensional correction model; and according to the geoid three-dimensional correction model, determining a gravity abnormal value at an unknown point in the prediction area so as to improve the ocean gravity reconstruction precision. According to the statistical principle, prediction precision of the unknown point is improved byincreasing the amount of related information to optimize the estimated weight value, and precision loss is reduced to a large extent while the spatial resolution of the marine gravity reference map isimproved.
Owner:CHINA ACADEMY OF SPACE TECHNOLOGY
Method and device for determining seal level elevation by extracting GPS (Global Position System) signal gravity frequency shift
ActiveCN102147247ASave human and material resourcesShort test periodHeight/levelling measurementSatellite radio beaconingMaterial resourcesFrequency shift
The invention discloses a method and device for determining seal level elevation, in particular relates to a method and device for determining seal level elevation by extracting GPS (Global Position System) signal gravity frequency shift. In the method, gravity frequency shift can be extracted based on GPS observation data (obs documents and sp3 documents) provided by an IGS (International GNSS (Global Navigation Satellite System) Service), and the gravity potential and the elevation of a single station are further determined based on gravity frequency shift signals. In addition, by means of a gravity field model, a theoretical value of the gravity frequency shift can be calculated and the effectiveness of the extracted gravity frequency shift signals can be verified. Accordingly, the invention has the following advantages: 1, because leveling measurement between two points with longer distance can be carried out without uninterrupted transmission by a plurality (or multiple) intermediate instrument stations, manpower and material resources are saved, a measurement period is short and the measurement is precise; 2, the measurement on a seal level elevation difference can be carried out between two points in a mountainous area or a place with higher near-distance elevation difference; and 3, a globally unified elevation datum can be realized.
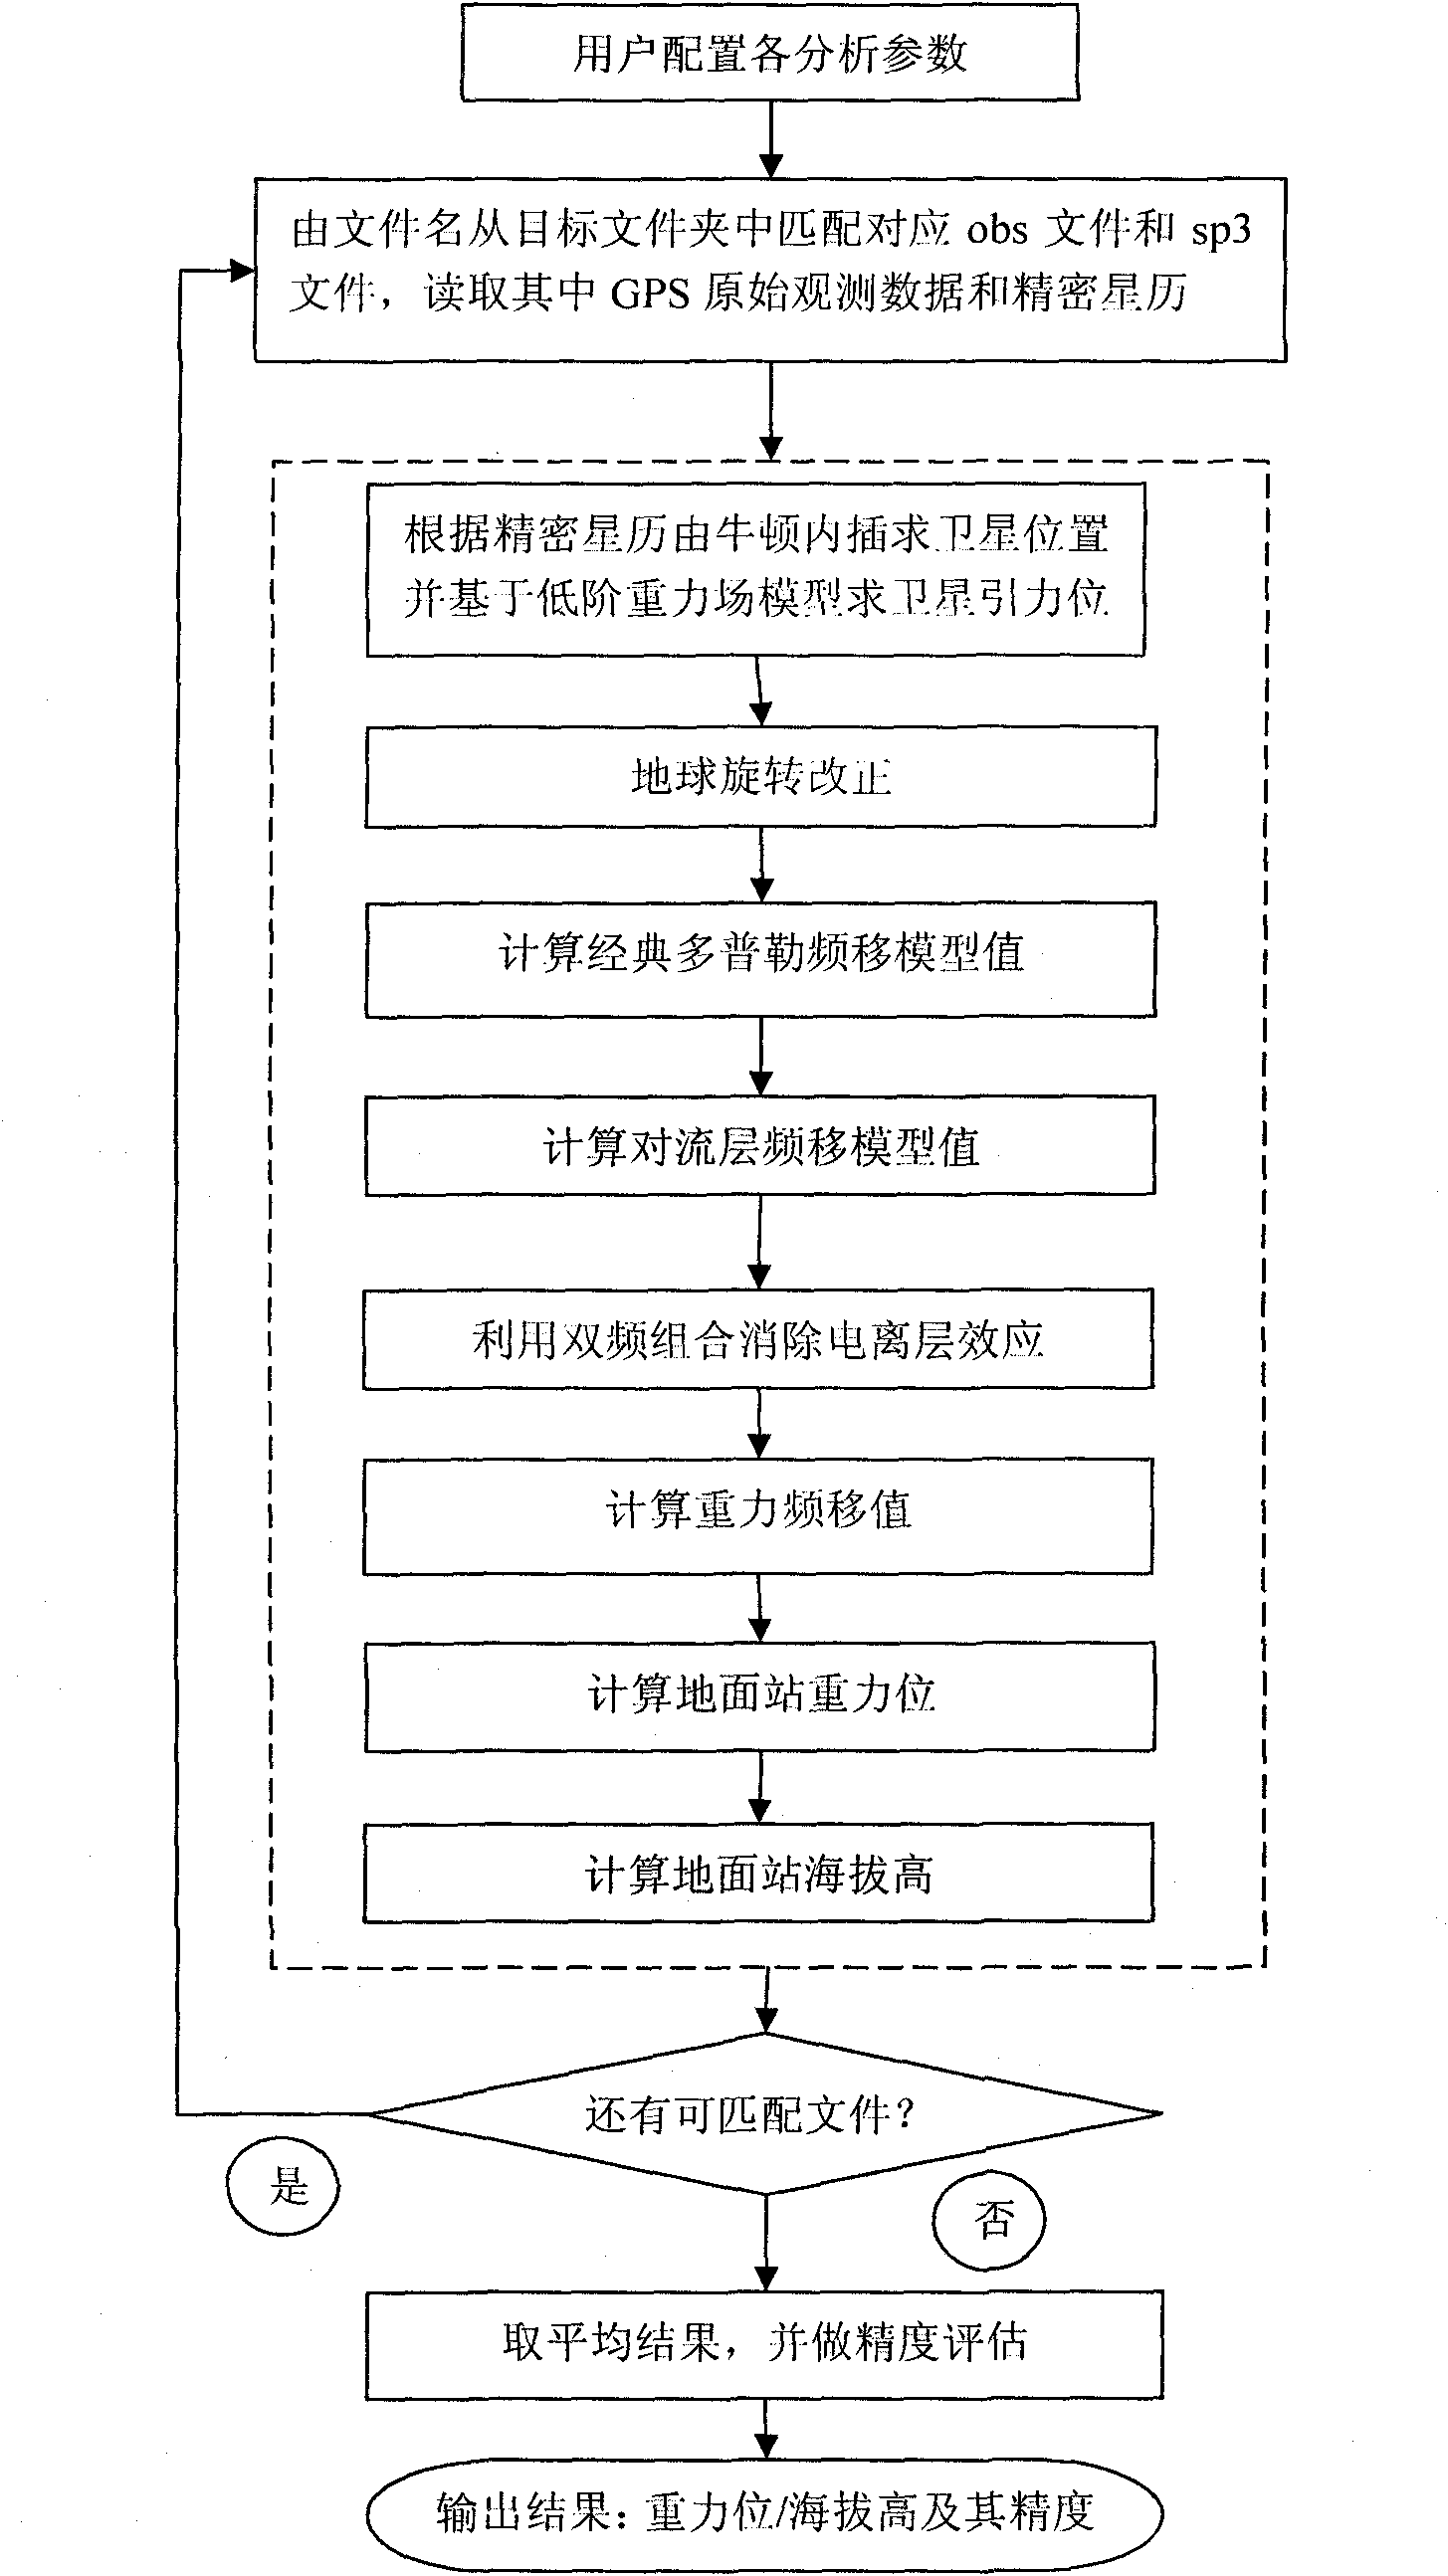
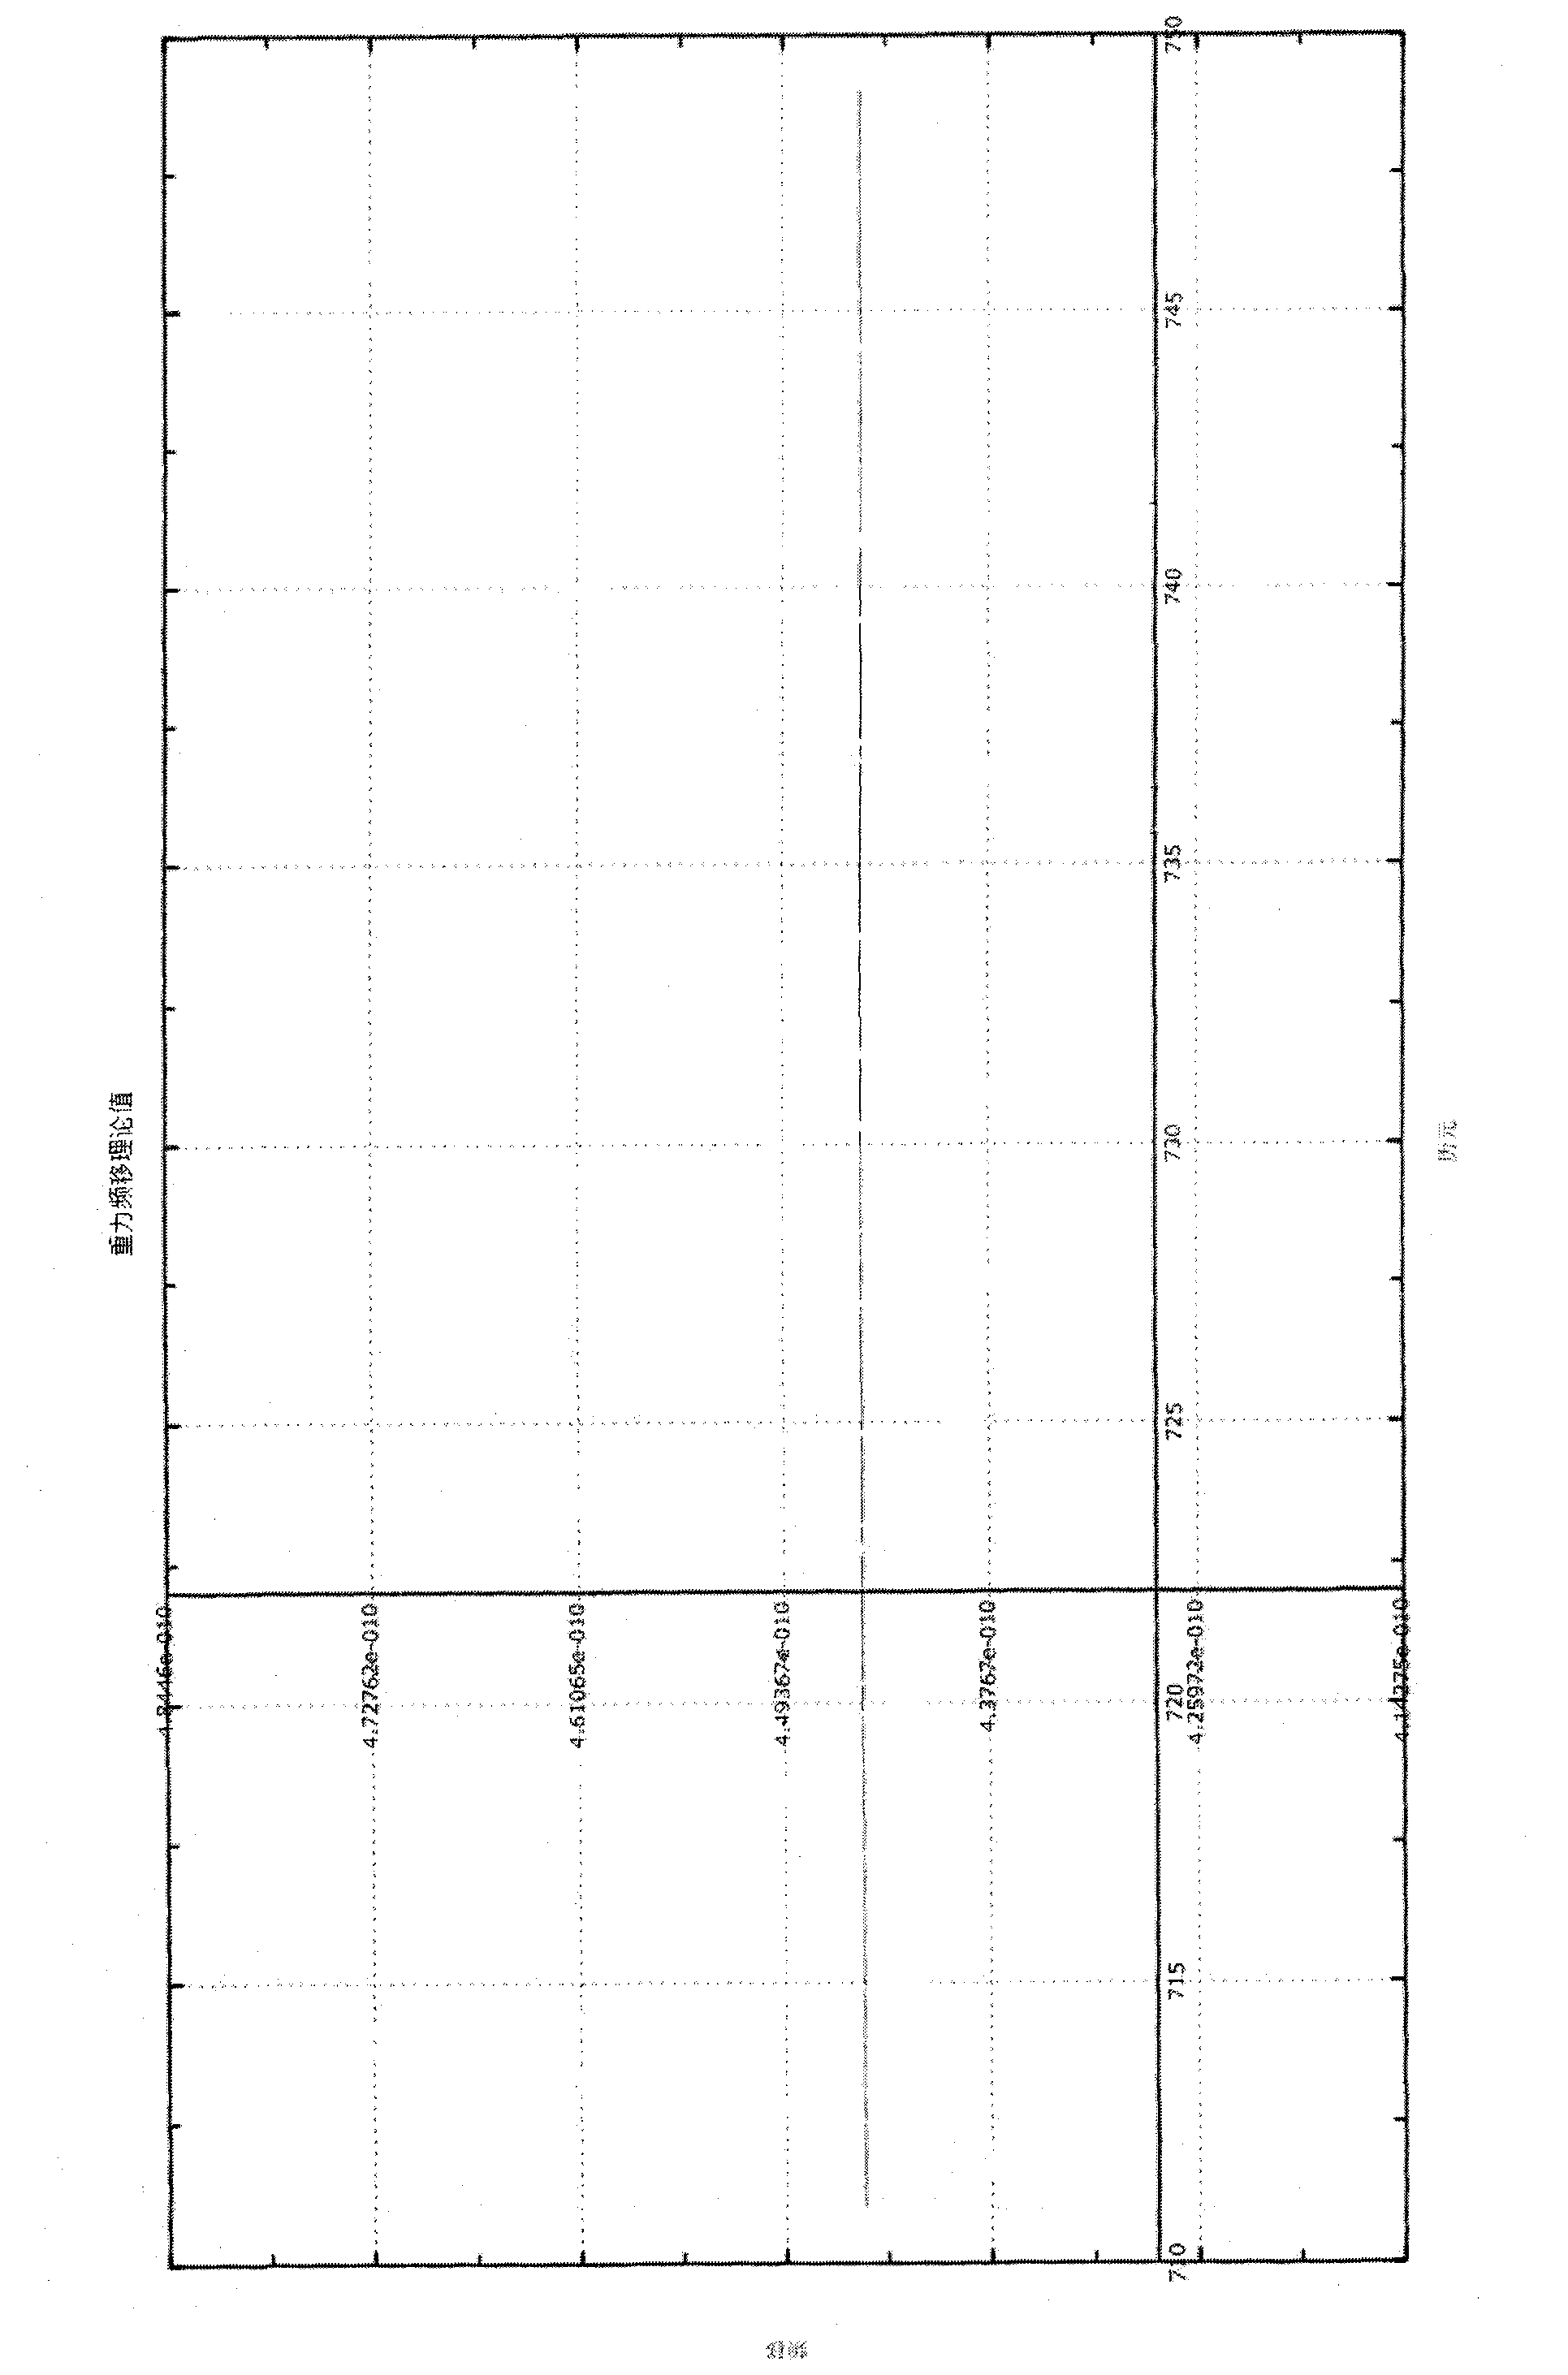
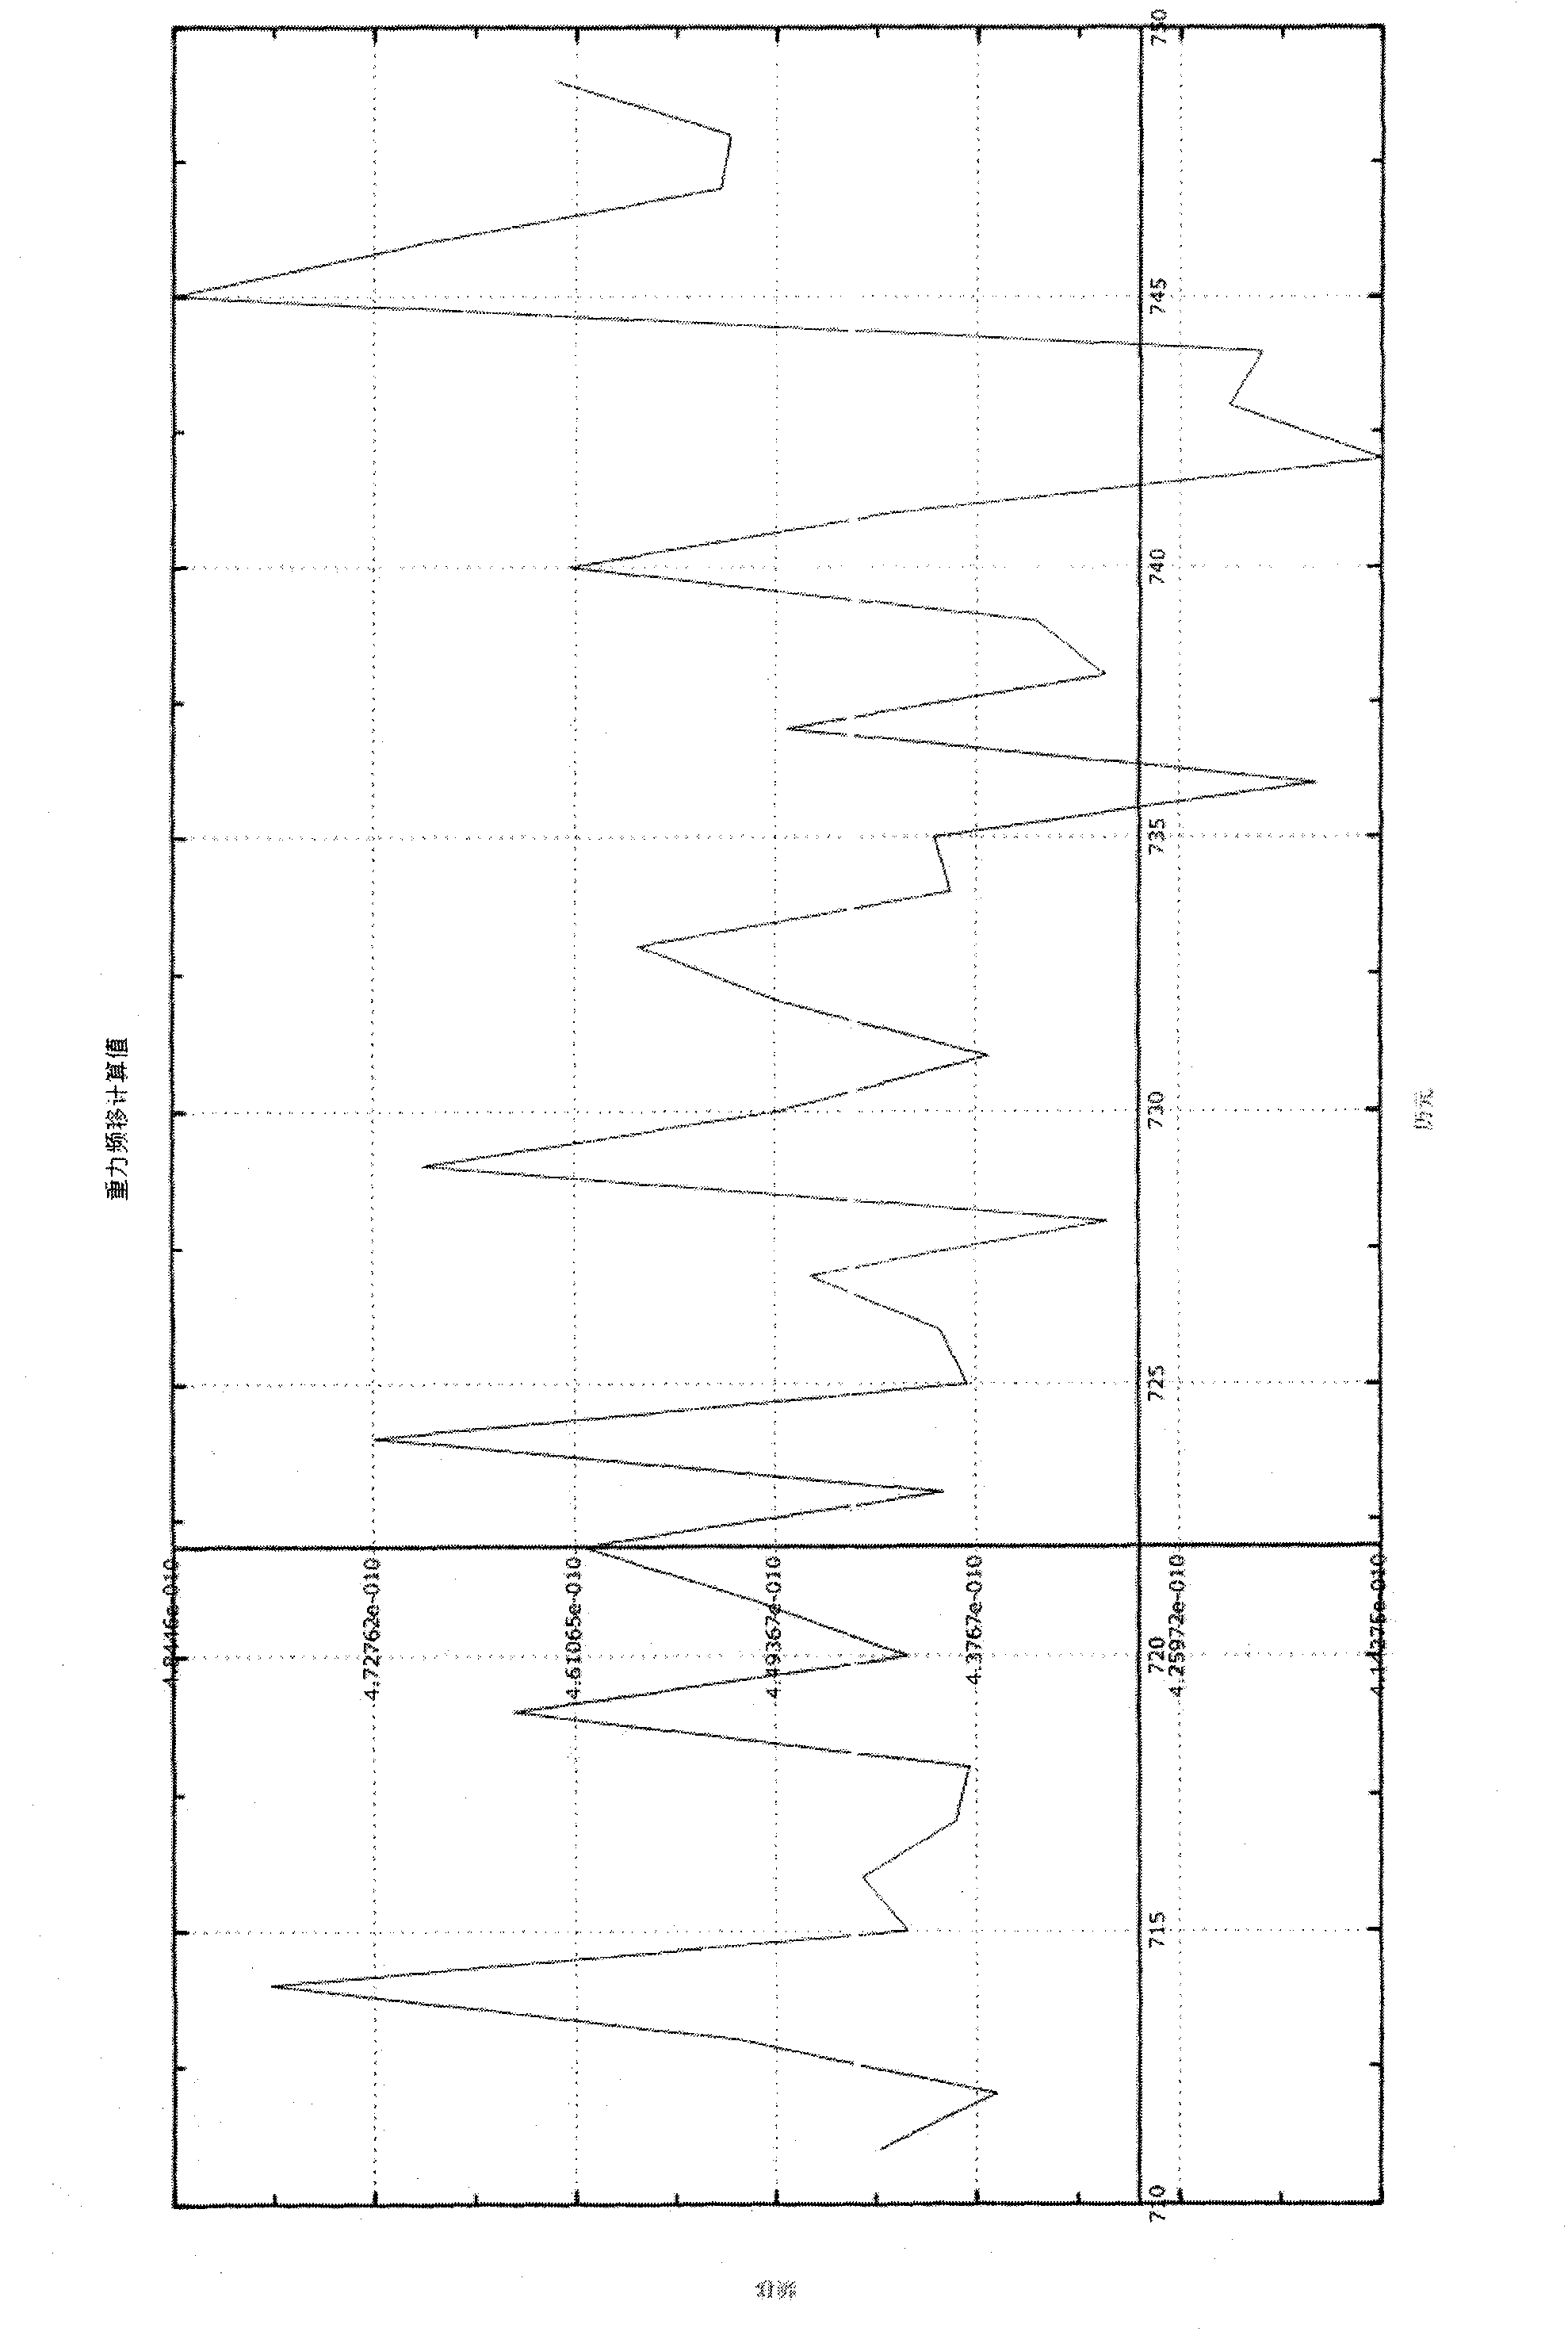
Owner:WUHAN UNIV
Sea area gravity anomaly inversion method and system based on satellite height measurement data
ActiveCN112556660AAbnormally accurate sea gravityAvoid introducingOpen water surveyGravitational wave measurementGrid basedGravity anomaly
The invention provides a sea area gravity anomaly inversion method and a system based on satellite height measurement data, and the method comprises the steps: calculating the sea surface height gradient of a sub-satellite point according to the sea surface height data collected by a satellite altimeter at the sub-satellite point in a preset sea area, and calculating the model vertical line deviation gradient of the sub-satellite point according to the position of the sub-satellite point, subtracting the sea surface height gradient of the sub-satellite point from the model vertical line deviation gradient to obtain the residual gradient of the sub-satellite point; converting the residual gradient of the sub-satellite point into a vertical line deviation grid based on a weighted least square method, and obtaining the residual vertical line deviation of the grid; and calculating the residual gravity anomaly of the grid according to the residual vertical line deviation of the grid, calculating the model gravity anomaly of the grid based on the gravity field model, and adding the model gravity anomaly of the grid and the residual gravity anomaly to obtain the sea area gravity anomaly value of the grid. According to the method, the accurate sea area gravity abnormal value is obtained after strict theoretical derivation.
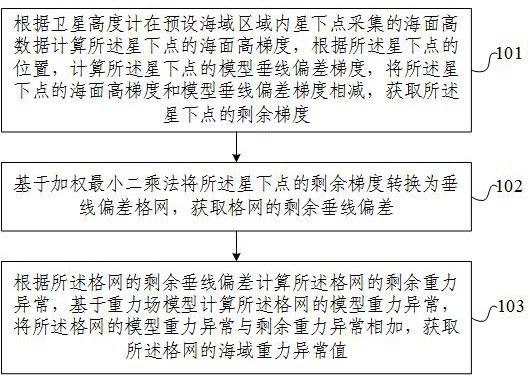
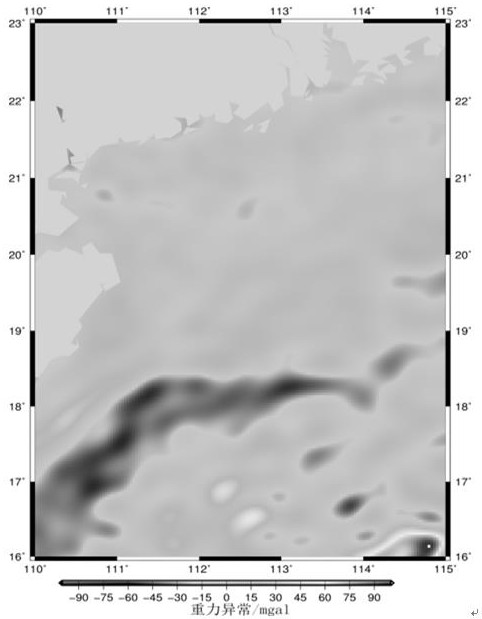
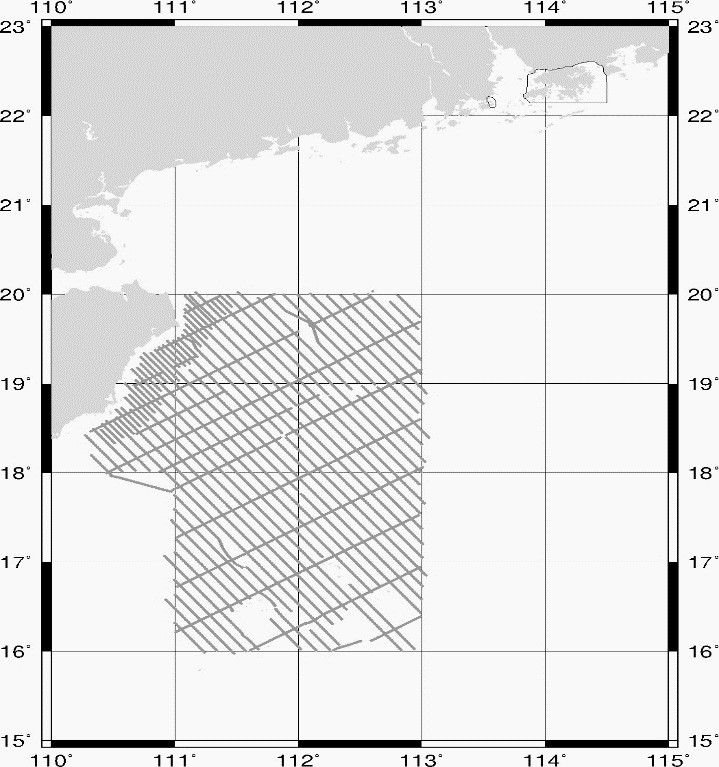
Owner:CHINESE ACAD OF SURVEYING & MAPPING
Gravitational field model-assisted inverse distance weighted geoid-like grid interpolation method
PendingCN113239567AHigh precisionSimple calculationHeight/levelling measurementDesign optimisation/simulationComputational physicsNumerical models
The invention belongs to the field of surveying and mapping science and technology, and discloses a gravitational field model-assisted inverse distance weighted geoid-like grid interpolation method, which comprises the following steps of: searching four grid nodes closest to an interpolation point in a geoid-like grid numerical model; setting the geodetic coordinates of four grid nodes and geoid-like elevation anomaly according to the geoid-like grid numerical model; calculating model elevation anomalies of the grid nodes and the interpolation points according to the geodetic coordinates of the interpolation points and the searched grid nodes by using a reference gravity field model bit coefficient; substracting the model elevation anomaly from the geoid elevation anomaly of the grid points to obtain the residual elevation anomaly of the four grid nodes; according to the residual elevation anomaly of the grid node, calculating the residual elevation anomaly of the interpolation point by adopting an inverse distance weighting method; and adding the residual elevation anomaly of the interpolation point to the model elevation anomaly of the point to obtain a final elevation anomaly interpolation result of the interpolation point. The method can greatly improve the precision of the elevation anomaly interpolation result.
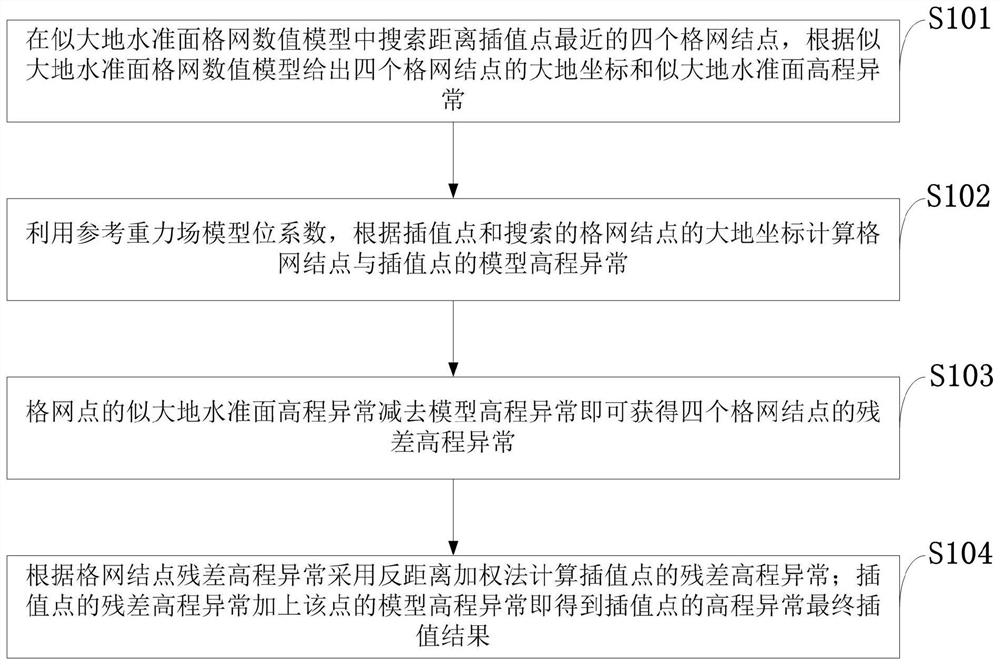
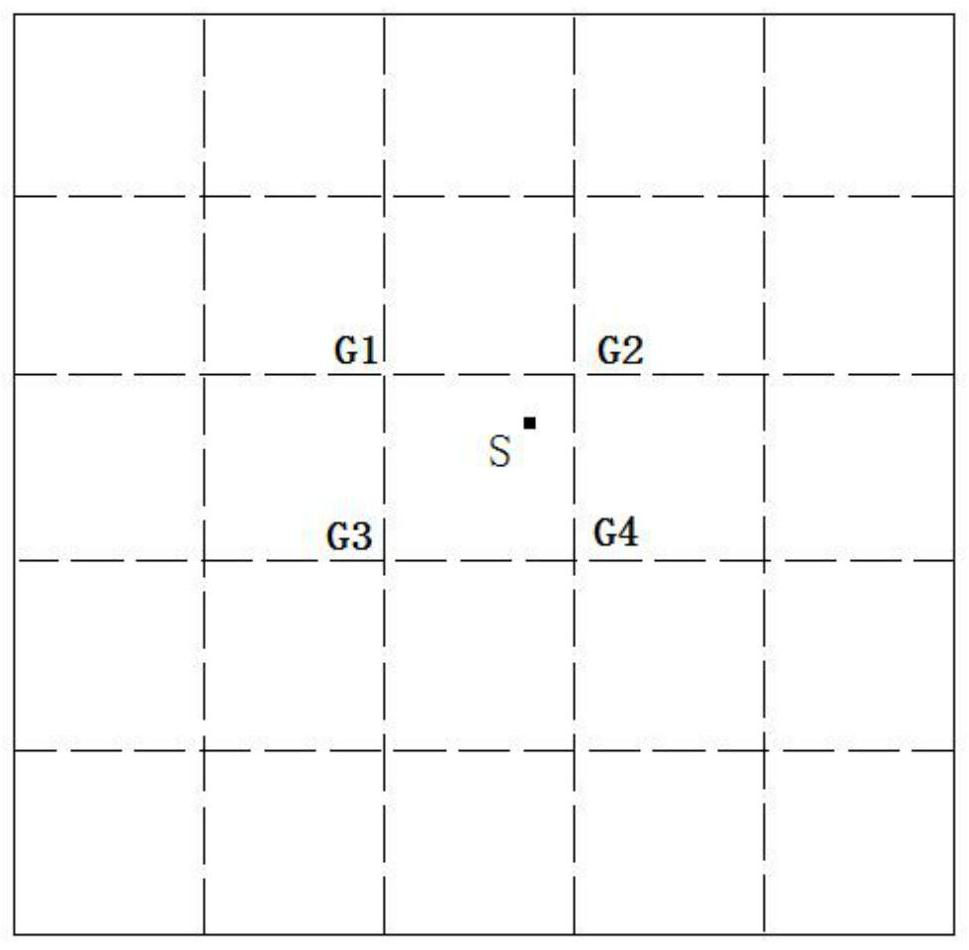
Owner:SHANDONG JIAOTONG UNIV
Satellite time-varying gravity field inversion method based on adaptive de-mixing
ActiveCN120831725AGravitational wave measurementComplex mathematical operationsGravitational forceAtmospheric sciences
The invention discloses a satellite time-varying gravity field inversion method based on adaptive de-mixing, and belongs to the technical field of satellite gravity measurement. Constructing a normal equation; accumulating the normal equations and solving parameter initial values through a weighted least square method; calculating a post-test residual error of the observation value and recovering a pre-elimination parameter; applying zero mean constraint to the daily time-varying gravity field parameters; establishing an autoregressive model to describe time correlation of the day solution sequence, applying autoregressive model constraint, updating a normal equation and jointly solving a time-varying gravity field model; outputting a daily time-varying gravity field model and a monthly time-varying gravity field model according to a parameter estimation result; evaluating the time-varying gravity field model through spectral domain analysis; according to the satellite time-varying gravity field inversion method based on self-adaptive de-mixing, self-adaptive de-mixing errors can be achieved, the stability and precision of time-varying gravity field inversion are improved, and the influence of background model mixing errors in satellite time-varying gravity field inversion is effectively weakened.

Owner:HUAZHONG UNIV OF SCI & TECH
EMD filtering method and system for time-varying gravity field
InactiveCN112800831AHigh SNR valueStrong ability to remove noiseCharacter and pattern recognitionNoise removalComputational physics
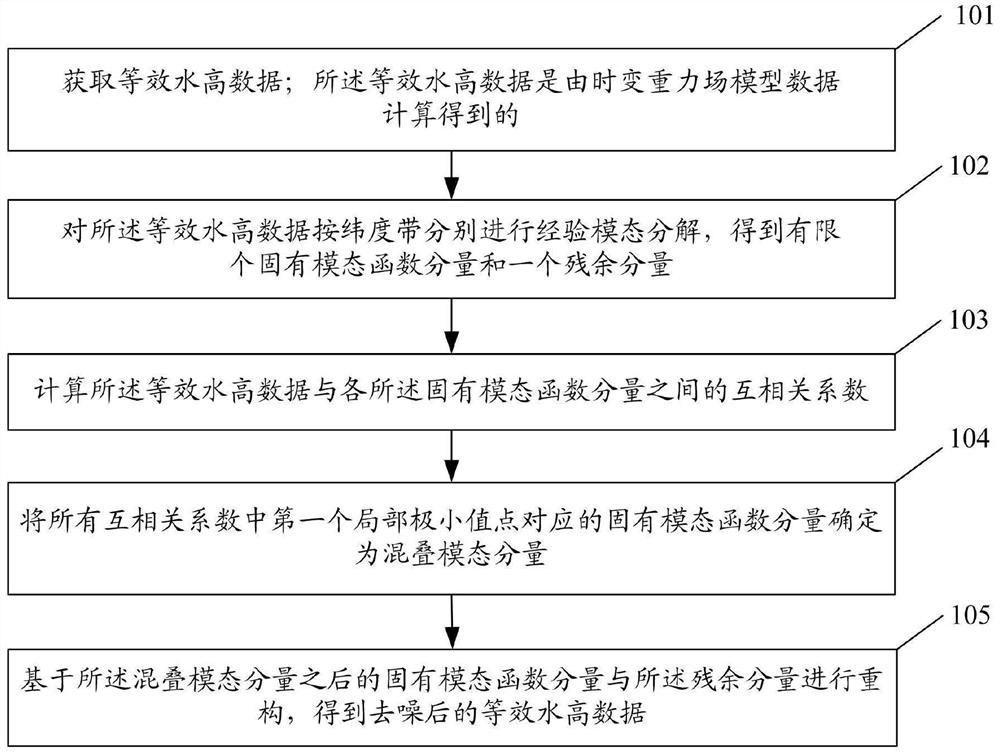
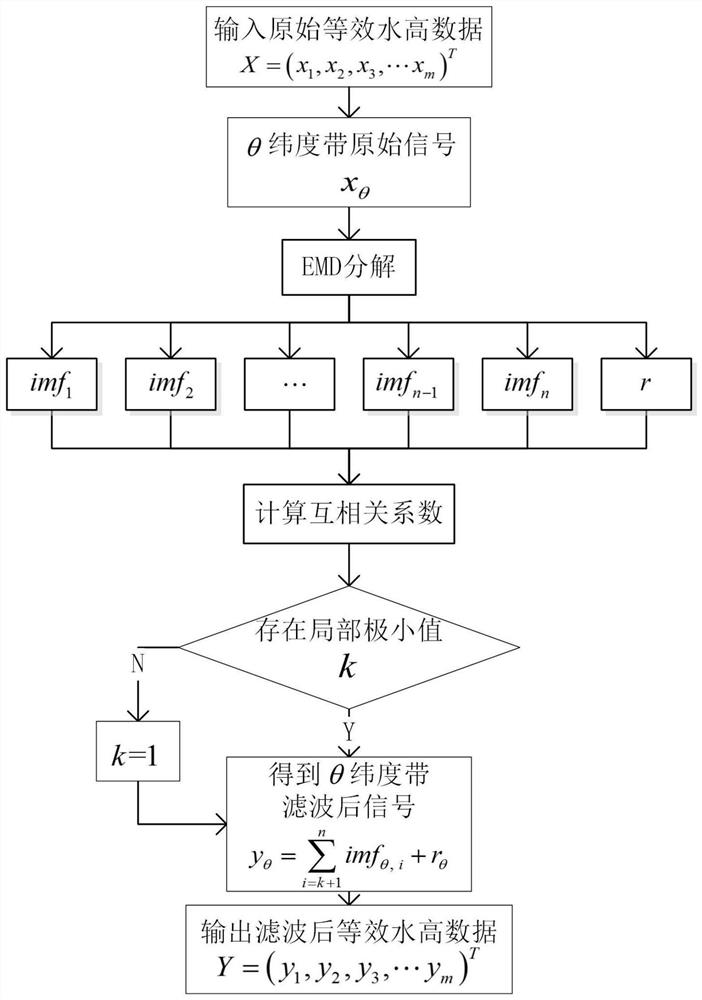
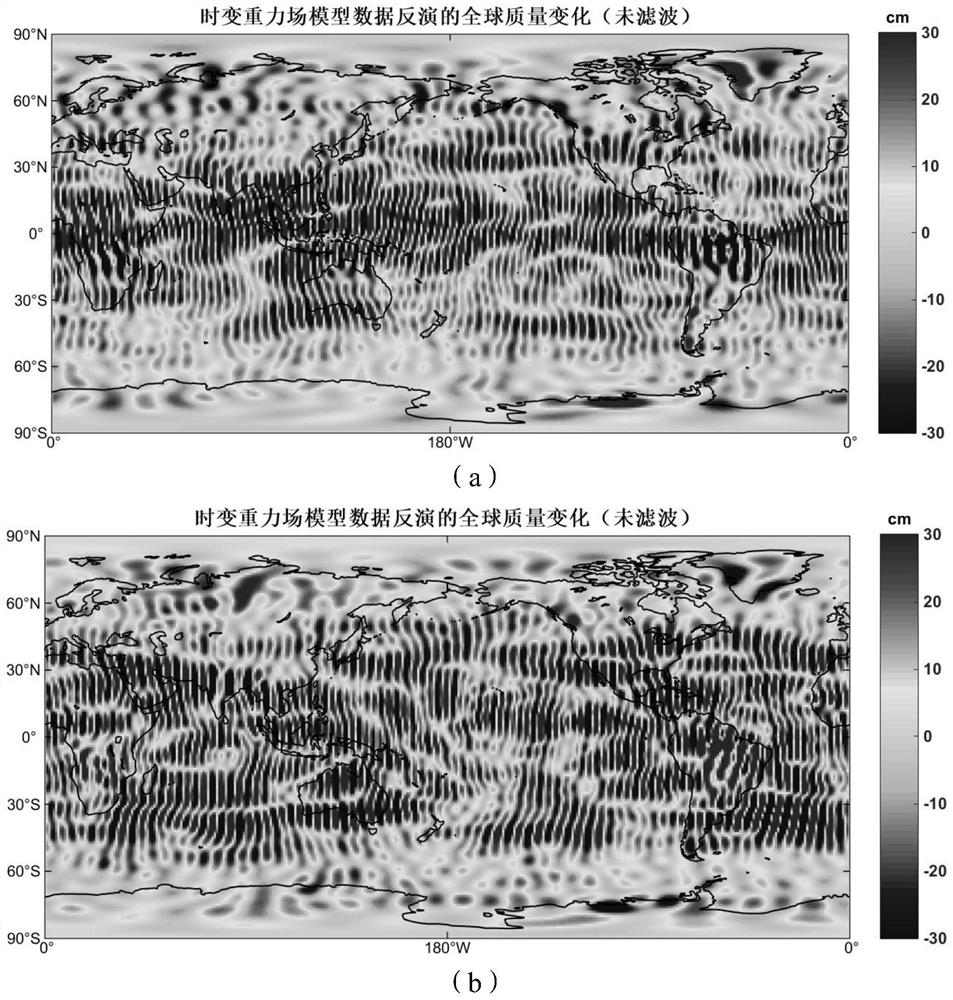
The invention discloses an EMD filtering method and system for a time-varying gravity field. The EMD filtering method for the time-varying gravity field comprises the following steps: acquiring equivalent water height data; the equivalent water height data is obtained by calculating the time-varying gravity field model data; respectively performing empirical mode decomposition on the equivalent water height data according to latitude zones to obtain a limited number of intrinsic mode function parts and a residual part; calculating a cross correlation coefficient between the equivalent water height data and each intrinsic mode function part; determining an intrinsic mode function part corresponding to a first local minimum point in all cross correlation coefficients as an aliasing mode part; and performing reconstruction based on the intrinsic mode function part and the residual part after the aliasing mode part to obtain denoised equivalent water height data. According to the invention, the noise removal capability can be enhanced, and the signal-to-noise ratio of the filtered signal is improved.
Owner:CHANGAN UNIV +2
Radial basis function grid method for constructing sea area vertical line deviation model based on frequency domain characteristics
InactiveCN111506871AHigh precisionHigh resolutionOpen water surveyComplex mathematical operationsFrequency spectrumObservation point
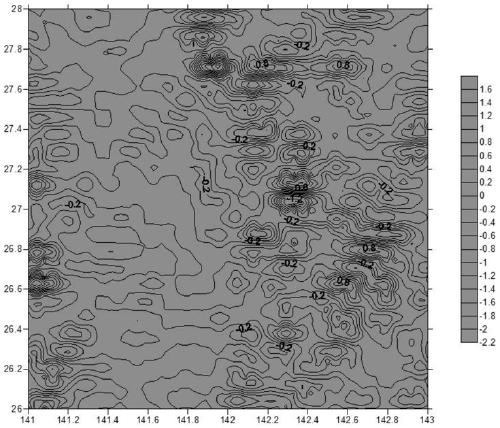
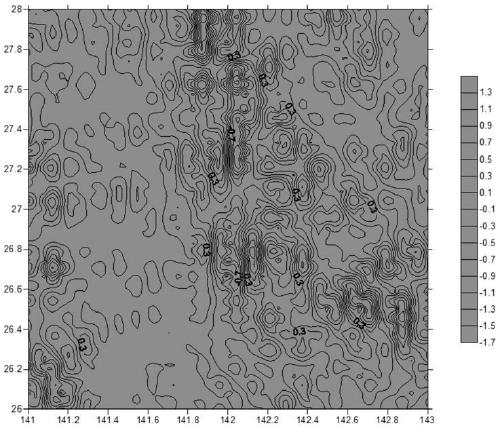
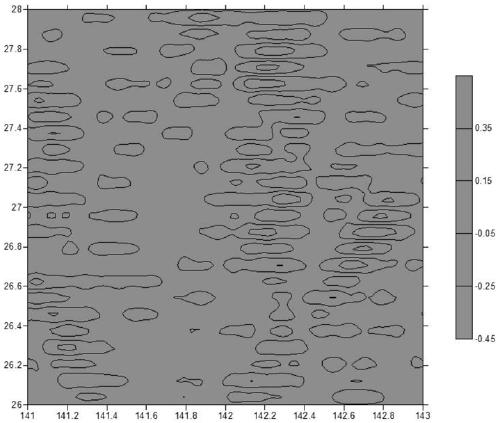
The invention relates to a radial basis function grid method for constructing a sea area plumb line deviation model based on frequency domain characteristics, which is technically characterized by comprising the following steps of: removing plumb line deviation in a sea plumb line deviation observation value by utilizing medium-long wave frequency spectrum information provided by a global gravityfield model to obtain residual plumb line deviation at an observation point; based on the residual vertical line deviation at the observation point, applying a radial basis function interpolation algorithm to obtain the residual vertical line deviation at the point to be estimated; recovering the model values of the meridian component and the mortise unitary component residual error of the vertical line deviation of the to-be-estimated point to obtain the calculation values of the meridian component and the mortise unitary component residual error of the vertical line deviation of the to-be-estimated point at the to-be-estimated point. The method is reasonable in design, the ocean plumb line deviation observed value serves as basic data, the global gravity field spherical harmonic model iscombined, a radial basis function interpolation method based on frequency domain characteristics is adopted, and the high-precision and high-resolution sea area plumb line deviation model can be constructed.
Owner:THE CHINESE PEOPLES LIBERATION ARMY 92859 TROOPS
Gravitational field inversion method considering unsteady noise of satellite gravity observation value
The invention discloses a gravitational field inversion method considering unsteady noise of a satellite gravity observation value. The gravitational field inversion method comprises the following steps: A, acquiring original observation data of a gravity satellite; b, setting observation value noise as white noise, and constructing a random model considering non-stationary noise; c, performing parameter estimation to obtain a post-test residual error of an observation value; d, estimating the noise auto-covariance and precision factor matrix of the observation value based on the post-test residual error of the observation value; e, repeating the steps C and D for iteration to realize refinement of the gravitational field parameter and observation value random model; and F, evaluating the time-varying gravity field model in the spectral domain. According to the invention, the defects in the prior art can be improved, and the precision and stability of gravitational field inversion are improved.

Owner:HUAZHONG UNIV OF SCI & TECH
Earth gravity field model modeling method based on orbital mask differential operator
ActiveCN111198402AImproved level of precisionSuppression of high frequency errorsGravitational wave measurementAccelerometerComputational physics
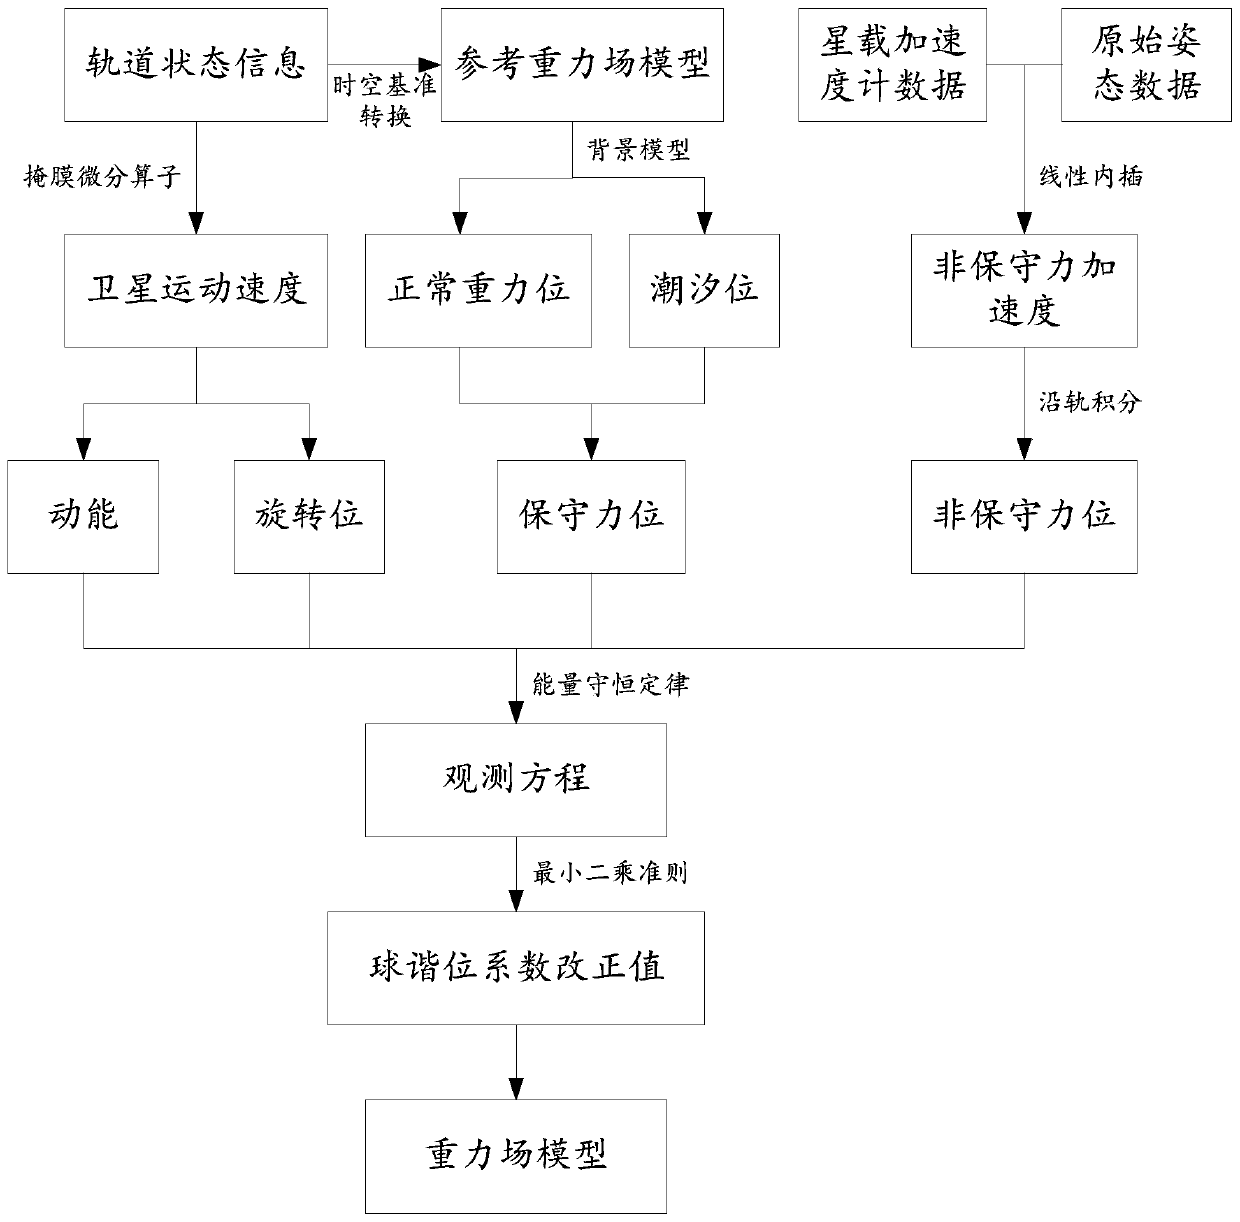
The invention discloses an earth gravity field model modeling method based on an orbit mask differential operator, which relates to the technical field of satellite gravity detection. The method comprises the steps of: carrying out the data preprocessing of orbit state information, a satellite-borne accelerometer and satellite attitude data, calculating the movement speed of the satellite by usingan orbit mask differential operator so as to obtain the kinetic energy and the rotation position of the satellite, establishing an observation equation meeting the law of conservation of energy through satellite kinetic energy, a rotation position, a conservative force position and a non-conservative force position, estimating a position coefficient correction value under the least square criterion, and determining a final earth gravity field model by adding a reference gravity field model position coefficient. Compared with a traditional method for determining the earth gravity field model by utilizing the orbit Newton polynomial differential speed, the method provided by the invention effectively suppresses high-frequency error amplification to realize noise reduction, is high in flexibility and calculation efficiency, obtains a high-precision satellite speed observation value, and further improves the precision level of the earth gravity field model.
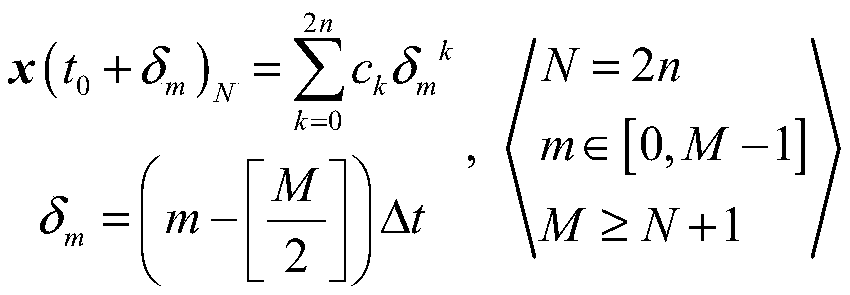
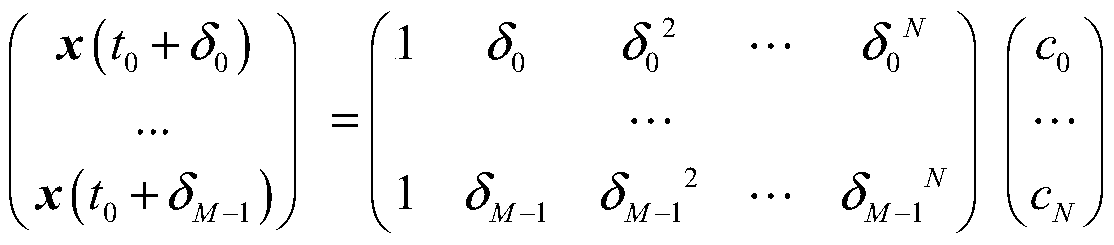
Owner:EAST CHINA UNIV OF TECH
Method for establishing high-precision gravity field model
PendingCN120493111AGeographical information databasesGravitational wave measurementObservation dataAtmospheric sciences
A high-precision gravity field model establishing method comprises the steps of firstly obtaining gravity observation data of a plurality of stations, then carrying out downsampling processing on the data, then carrying out theoretical earth tide correction on the data, and then carrying out wrong data, kick data and continuous grid-dropping data identification on the data, then error data, kick data and continuous grid-dropping data in the data are corrected, theoretical earth tide correction, tide correction, air pressure correction, sea tide correction and extreme tide correction are carried out on the data, and then a high-precision gravity field model is obtained; the gravity observation data is actually measured and generated in the region of China, so that a large amount of assignment calculation is not needed, and the generation efficiency of the gravity field model is relatively high. Therefore, according to the design, all nodes do not need to be calculated, and the gravity field model generation efficiency is high.

Owner:HUBEI EARTHQUAKE ADMINISTRATION (SEISMOLOGY RES INST OF CHINA EARTHQUAKE ADMINISTRATION)
Geological fracture identification method based on multi-source geophysical data and computer system
The invention relates to a geological fracture recognition method based on multi-source geophysical data and a computer system, and solves the problem of high-precision recognition of tiny fractures and complex fracture zones. The method comprises the following steps: acquiring gravitational field model data, full-tensor gravity gradient data and aeromagnetic data of a target area, and carrying out gridding processing, pole conversion processing and edge expansion preprocessing on the data; performing boundary identification calculation on the preprocessed data by adopting a traditional physical field multi-derivative algorithm to generate a first group of boundary information A; carrying out boundary recognition calculation on the preprocessed data by adopting a gravity and full-tensor gravity gradient combined derivative algorithm (an enhanced total horizontal gradient derivative algorithm, a combined derivative algorithm and a combined oblique derivative algorithm) to generate a second group of boundary information B, and carrying out boundary recognition calculation on the preprocessed data by adopting an image edge detection algorithm to generate a second group of boundary information B; generating a third group of boundary information C; and carrying out weighted fusion on the three groups of boundary information to obtain a final fracture identification result.

Owner:HUANGGANG NORMAL UNIV
Satellite gravitational gradient data precision verification method based on tensor invariant theory
The invention discloses a satellite gravitational gradient data precision verification method based on a tensor invariant theory. The method comprises the following steps: verifying the overall precision of a satellite gravitational gradient tensor and verifying the component independent precision of the satellite gravitational gradient tensor, wherein the component independent precision verification of the satellite gravitational gradient tensor comprises independent precision verification of each component of the satellite gravitational gradient tensor before and after calibration. Accordingto the satellite gravitational gradient data precision verification method based on a tensor invariant theory provided by the invention, on the basis of the tensor invariant theory, the tensor invariant characteristic of a satellite gravitational gradient observation value is applied to precision verification before and after calibration of a gravitational gradient measurement satellite gravimeter, and overall precision verification of the six components of the gravitational gradient tensor is achieved. By introducing a priori gravitational field model for calibration, precision independent verification of the six components of the main diagonal line and an off-diagonal line of the gravitational gradient tensor can be realized.

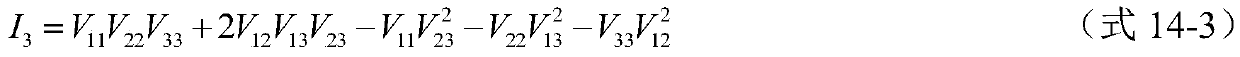
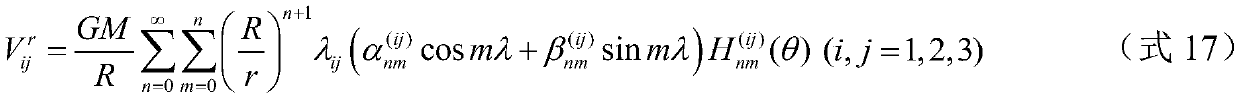
Owner:自然资源部国土卫星遥感应用中心
Method for realizing elevation measurement by using gravity, GNSS-RTK and gravity field model
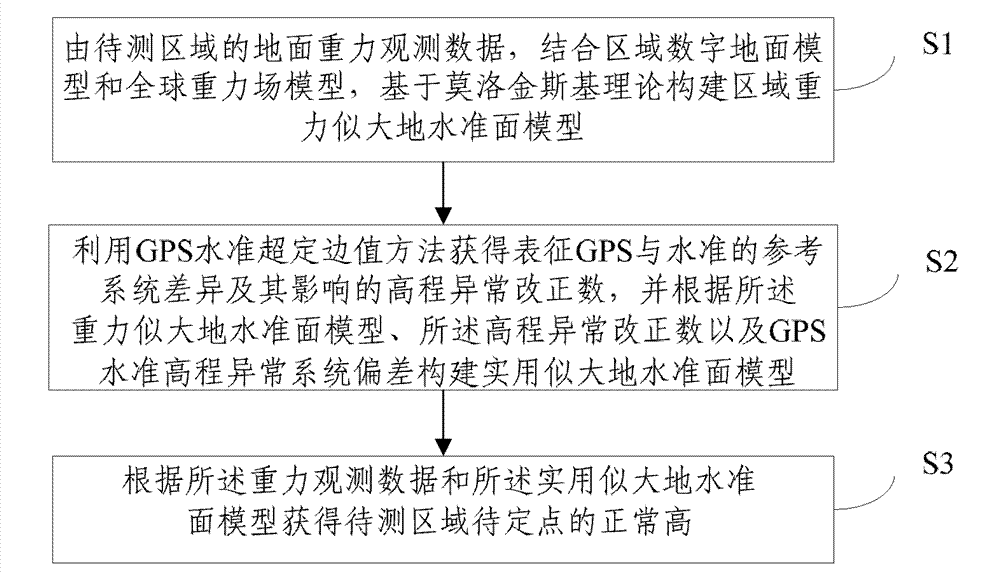
ActiveCN112985348AThe method steps are simpleReasonable designHeight/levelling measurementGravitational forceAtmospheric sciences
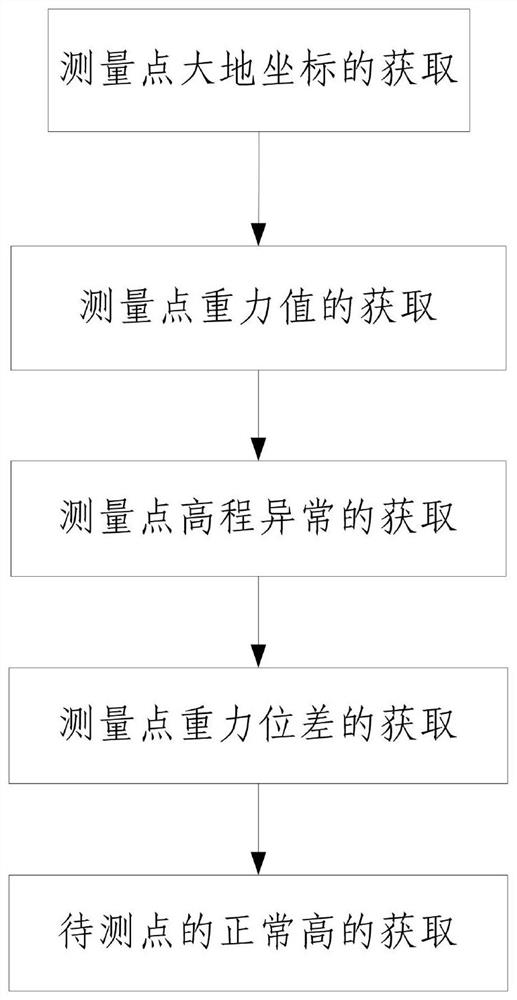
The invention discloses a method for realizing elevation measurement by utilizing gravity, GNSS-RTK and a gravity field model. The method comprises the following steps of: 1, acquiring geodetic coordinates of a measurement point; 2, obtaining a gravity value of the measurement point; 3, acquiring elevation anomaly of the measurement point; 4, obtaining the gravitational potential difference of the measurement point; and 5, obtaining the normal height of a point to be measured. The method is simple in step and reasonable in design, the geodetic height of the measurement points is obtained through the GNSS-RTK measurement technology, the gravity potential difference between the measurement points is obtained through flowing gravity observation, the height anomaly of the measurement points is calculated through the gravity field model, and finally the normal height of the point to be measured is calculated, so that high-precision height measurement is achieved.
Owner:雷军珍
A time-domain simulation method and related device for wave energy float model
ActiveCN119249963BSustainable transportationDesign optimisation/simulationTime domainComputational model
This application discloses a time-domain simulation method for a wave energy float model and related devices. The method includes: decomposing the wave energy float model to obtain a gravity field model, a wave energy float system model, a wave force calculation model, a buoyancy calculation model, an added mass calculation model, a damping force calculation model, a hydrostatic restoring force calculation model, and a viscous force calculation model; modeling each decomposed sub-model using OpenModelica and establishing a connection relationship between each sub-model, and solving the model using a solver. This application decomposes the wave energy float model into multiple sub-models according to potential flow theory for modeling. After physically connecting the sub-models, equations can be established. The equations are solved using a solver, greatly reducing the steps in the physical modeling process and the difficulty of solving the equations, thereby improving the reusability, reconfigurability, and scalability of the time-domain simulation method for the wave energy float model.

Owner:SUN YAT SEN UNIV
Elevation datum plane construction method and system based on low-order cosine correction Stokes kernel function, medium and product
ActiveCN119737914AHeight/levelling measurementDesign optimisation/simulationGravity anomalyCombination algorithm
The invention discloses an elevation datum plane construction method and system based on a low-order cosine correction Stokes kernel function, a medium and a product, and relates to the technical field of physical geodetic survey. The method comprises the following steps: calculating by utilizing an earth gravitational field model, topographic data and a high-frequency topographic influence combined algorithm to obtain model data, direct influence of topographic compression on ground gravity anomaly and indirect influence of topographic compression on an elevation datum plane; determining an empirical value and a test value of a correction order of the low-order cosine correction Stokes kernel function based on the accumulative error of the model gravity anomaly and the test frequency bandwidth; calculating an empirical elevation datum plane and a test elevation datum plane based on the empirical value and the test value of the correction order by adopting a low-order cosine correction Stokes kernel function; and determining a final elevation datum based on the empirical elevation datum and the test elevation datum. The construction precision of the elevation datum plane can be improved.

Owner:CHINESE PEOPLES LIBERATION ARMY UNIT 61540
Gravity satellite east-west direction differential observation data construction and inversion method and system
PendingCN112526624AEasy to implementEliminate common errorsGravitational wave measurementICT adaptationAccelerometerObservation data
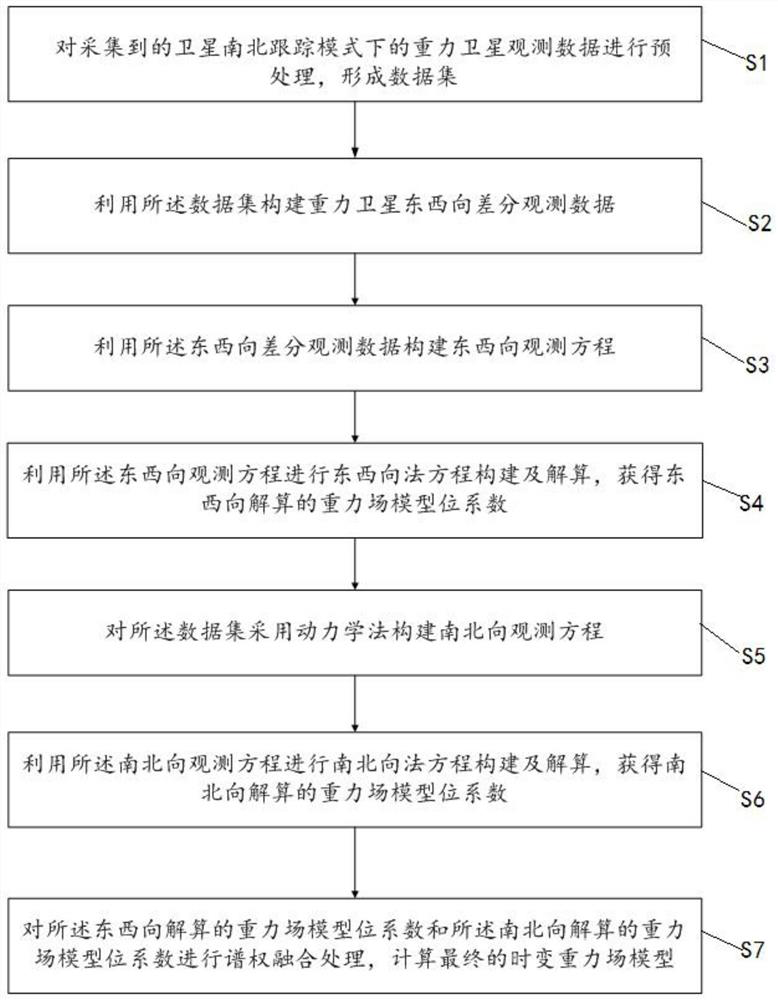
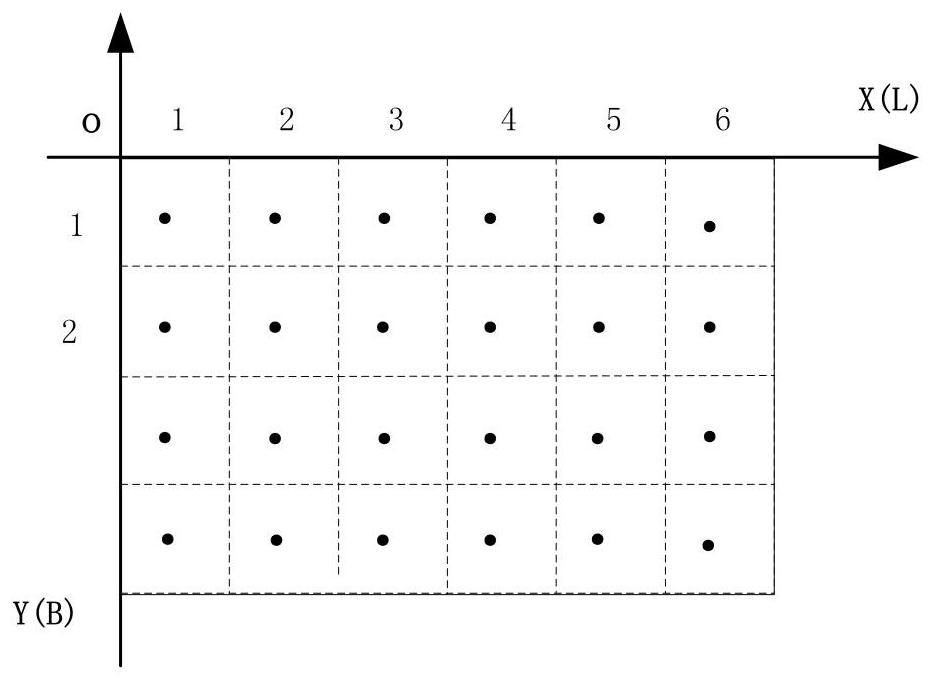
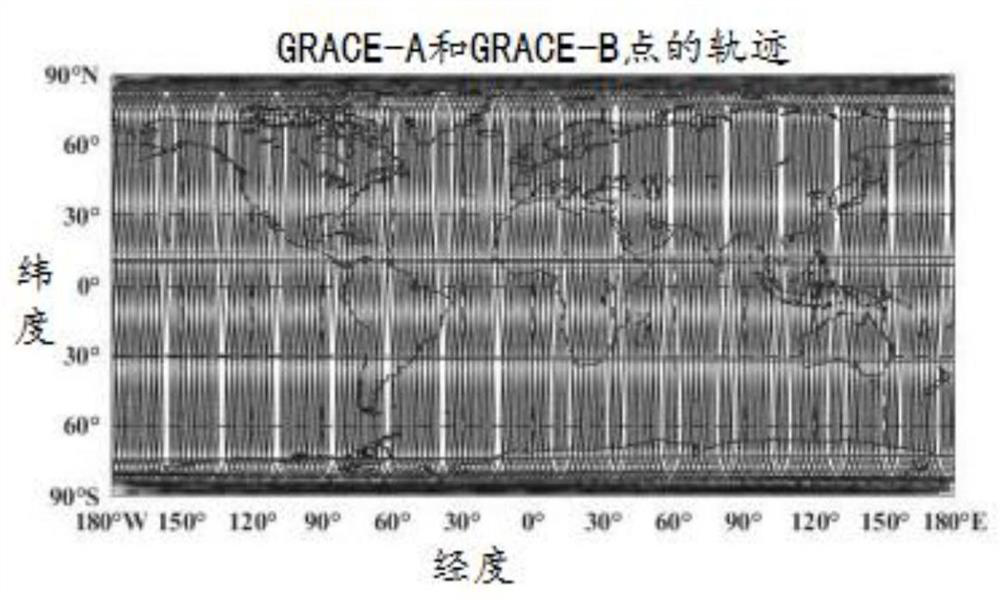
The invention relates to a gravity satellite east-west direction differential observation data construction and inversion method and system. The method comprises the following steps: carrying out datainterpolation and gridding processing on the basis of the observation data measured by a GNSS and the observation data of an accelerometer, carrying out difference processing on the positions, speedsand accelerations of a plurality of adjacent grid points in the east-west direction to obtain east-west differential observation data, further constructing an observation equation based on the east-west differential observation data, performing respective time-varying field calculation on north-south and east-west observation equations, finally performing spectral combination calculation on north-south and east-west gravitational field models, and calculating a final time-varying gravitational field model. The east-west observation data construction and inversion technology can effectively solve the problem of south-north stripes of a satellite inversion gravity field, thereby improving the gravitational field calculation precision. Compared with other methods, the algorithm provided by the invention is simple to implement, and the stability and reliability of the gravitational field calculation result can be ensured on the whole.
Owner:中国人民解放军61540部队
Method for constructing global gravity field based on carrier phase differential velocity
ActiveCN111308570AHigh solution accuracyReduce systematic bias between epochsGravitational wave measurementAccelerometerCarrier signal
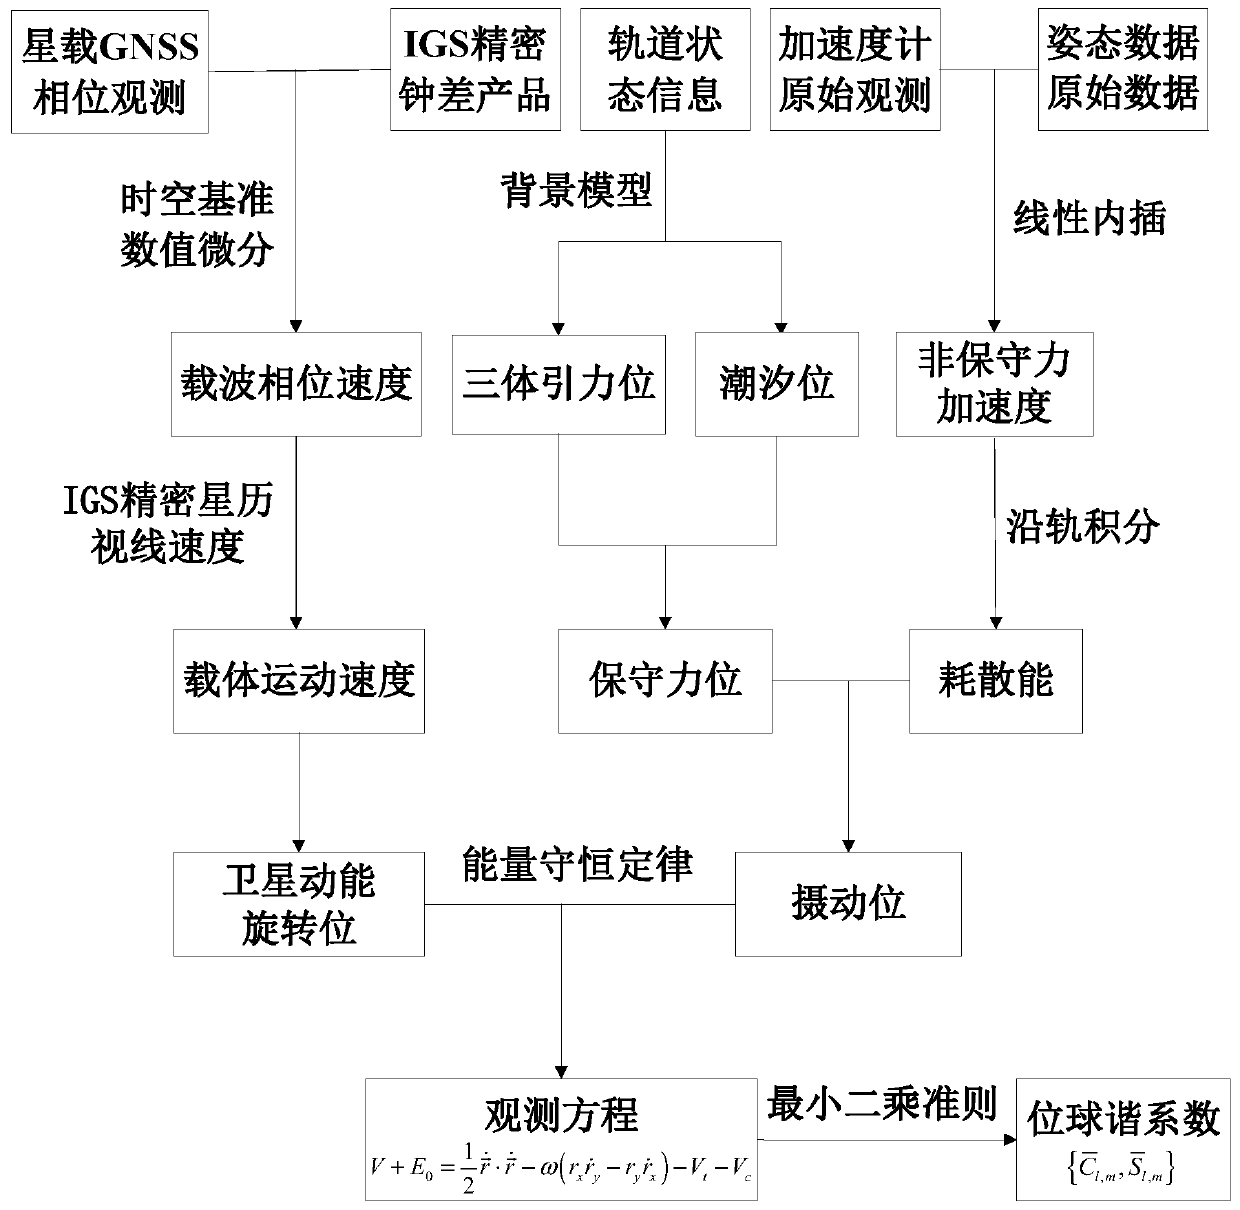
The invention discloses a method for constructing a global gravity field based on carrier phase differential velocity, which relates to the technical field of satellite gravity detection. The method comprises the following steps: S1, carrying out data preprocessing on a carrier phase, orbit state information, an accelerometer, satellite attitude and other original observation values; S2, obtainingsatellite kinetic energy and a rotation position by utilizing a carrier phase differential speed; and S3, establishing an observation equation through the satellite kinetic energy, the rotation position and various perturbation positions, and estimating a global gravity field potential coefficient under a least square criterion based on the energy conservation law. Compared with the traditional energy conservation method for inverting the gravity field model by using the orbit differential velocity, the algorithm provided by the invention does not need to estimate the phase ambiguity, reducesthe system deviation between epochs, is convenient to implement quality control on the motion velocity of the carrier, so that the resolving precision of the global gravity field model is improved.
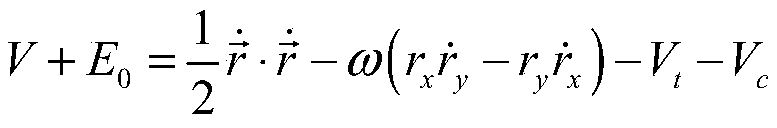
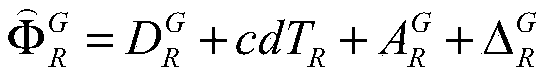
Owner:EAST CHINA UNIV OF TECH
Beidou-based Antarctic ice dome elevation measurement method
PendingCN120252636AHeight/levelling measurementSatellite radio beaconingObservation dataReference ellipsoid
The invention provides a Beidou-based antarctic ice dome elevation measurement method, and solves the problem that the traditional method cannot obtain the high-precision altitude of the antarctic ice dome. The method comprises the following steps: firstly, erecting a Beidou base station at a South Pole ice dome test point, collecting original observation data of a Beidou satellite, and calculating accurate coordinates and geodetic height of the test point through a post-event precise point positioning technology; then, determining a gravity value of a test point by using ground gravity measurement equipment, reducing the gravity value of the test point to a geoid through various corrections such as instrument null drift, earth tide and atmospheric pressure, obtaining gravity anomaly of the test point in combination with a known normal gravity value of a reference ellipsoid surface, and converting the gravity anomaly into elevation anomaly through a formula; and finally, converting the geodetic height calculated by the test point into the altitude through the conversion relation between the geodetic height and the altitude, and checking and checking the initial altitude calculated by the global gravitational field model. The method can be widely applied to the fields of South Pole scientific research, resource development and the like.

Owner:CHINA NORTH IND CORP +1
Aircraft collaborative gravity navigation system and method
PendingCN120313589ANavigational calculation instrumentsNavigation by speed/acceleration measurementsFlight vehicleUncrewed vehicle
The invention provides an aircraft collaborative gravity navigation system and method, and belongs to the technical field of navigation. The navigation system is composed of a high-precision distance and direction finding unit, an inertial navigation unit, a global gravity field model database unit, a positioning calculation unit and a filtering estimation unit. The specific implementation process of the navigation method comprises the steps of obtaining the relative position between the aircrafts by using distance and direction finding data between the aircrafts, extracting the relative gravitational acceleration by using polynomial fitting, carrying out positioning calculation based on the relative gravitational acceleration and the relative position, carrying out Kalman filtering correction by fusing a positioning calculation value and inertial navigation information, and finally obtaining the navigation result. And high-precision autonomous navigation is realized. According to the navigation system and method, autonomous navigation is achieved only through inertial navigation data and distance and direction finding data between the aircrafts, dependence on satellite navigation is completely eliminated, and the navigation system and method are suitable for autonomous navigation of aircrafts such as middle-high altitude long-endurance unmanned aerial vehicles.

Owner:BEIHANG UNIV
A submarine navigation method and system based on a multi-dimensional gravity gradient lighthouse
ActiveCN111595345BImprove securityImprove accuracyNavigational calculation instrumentsClassical mechanicsSubmarine navigation
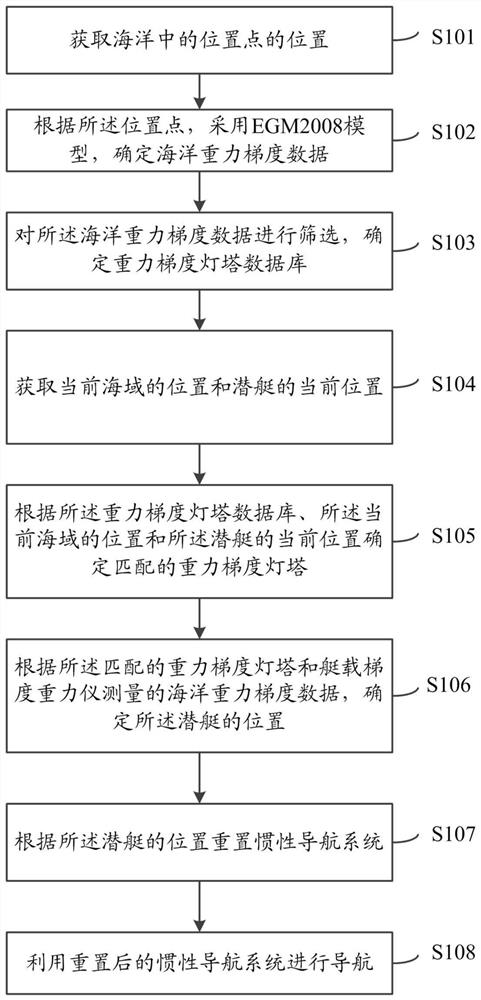
The invention relates to a submarine navigation method and system based on a multi-dimensional gravity gradient lighthouse. The method includes obtaining the position of a position point in the ocean; according to the position point, using a high-precision gravity field model to determine the ocean gravity gradient data; screening the ocean gravity gradient data to determine the gravity gradient lighthouse; acquiring the position of the current sea area and the submarine Determine the matching gravity gradient lighthouse according to the gravity gradient lighthouse database, the position of the current sea area and the current position of the submarine; determine the position of the submarine according to the ocean gravity gradient data measured by the matching gravity gradient lighthouse and the on-board gradient gravimeter; Reset the inertial navigation system based on the submarine's position. The invention provides a submarine navigation method and system based on a multi-dimensional gravity gradient lighthouse, which can improve the safety and accuracy of gravity lighthouse navigation in a gentle gravity area.
Owner:中国人民解放军61540部队 +1
A time-varying gravity field model inversion method, system, electronic equipment and medium
The present invention discloses a time-varying gravity field model inversion method, system, electronic equipment and medium, and relates to the field of gravity field inversion. The method comprises acquiring satellite gravity observation data; inverting the satellite gravity observation data according to the time-varying gravity field model, constructing an orbit observation equation and a corresponding satellite spacing rate variation observation equation for each arc segment with an integration time of one day as an arc segment; inverting the orbit observation equation and the corresponding satellite spacing rate variation observation equation according to the time-varying gravity field model of each arc segment, and obtaining a normal equation for each arc segment by using a weighted least squares method; performing Gaussian elimination on the normal equation of each arc segment to obtain a time-varying gravity field model potential coefficient. The present invention suppresses high-frequency mass change noise in the time-varying gravity field inversion process, and improves the accuracy of the inverted time-varying gravity field model.

Owner:CHINESE PEOPLES LIBERATION ARMY UNIT 61540 +2
Satellite orbit prediction method, system, device and medium based on gravity field vectorization calculation model
ActiveCN121328122BDesign optimisation/simulationComplex mathematical operationsComputational modelComputational physics
The application discloses a satellite orbit prediction method, system, device and medium based on a gravity field vectorization calculation model, and the method comprises the following steps: establishing a motion equation of a satellite in an inertial system; constructing a gravity field fast calculation model; dividing a gradient formula of a gravity field potential position into a sum of a harmonic part and a non-harmonic part, and performing vectorization reconstruction to obtain a gravity field vectorization calculation model; obtaining a position and a velocity vector of the satellite at an initial moment, inputting the position and the velocity vector into the motion equation of the satellite in the inertial system, combining the gravity field vectorization calculation model, and solving the satellite orbit by using a numerical integration method. The gravity field vectorization calculation model is numerically equivalent to a traditional loop algorithm, the accuracy of the gravity field model is ensured without loss, the traditional double loop structure is replaced by matrix operation, the calculation efficiency of a high-order gravity field is significantly improved, and therefore, the satellite orbit prediction calculation efficiency is improved on the basis of ensuring the accuracy.

Owner:SHANGHAI ASTRONOMICAL OBSERVATORY CHINESE ACAD OF SCI
Satellite orbit forecasting method, system and equipment based on gravitational field vectorization calculation model and medium
ActiveCN121328122ADesign optimisation/simulationComplex mathematical operationsComputational modelComputational physics
The invention discloses a satellite orbit forecasting method, system and equipment based on a gravitational field vectorization calculation model and a medium. The method comprises the following steps: establishing a motion equation of a satellite under an inertial system; constructing a gravitational field rapid calculation model: writing a gravitational field gravitational potential-to-position gradient formula into the sum of a harmonic part and a field harmonic part, and performing vectorization reconstruction on the sum to obtain a gravitational field vectorization calculation model; and acquiring the position and velocity vector of the satellite at the initial moment, inputting the position and velocity vector into a motion equation of the satellite under an inertial system, and solving by adopting a numerical integration method in combination with a gravitational field vectorization calculation model to obtain a satellite orbit. The gravitational field vectorization calculation model provided by the invention is equivalent to the numerical value of a traditional loop algorithm, so that the precision of the gravitational field model is ensured to be lossless; and matrix operation is used for replacing a traditional dual-cycle structure, so that the high-order gravity field calculation efficiency is remarkably improved, and the satellite orbit forecasting calculation efficiency is improved on the basis of ensuring the precision.

Owner:SHANGHAI ASTRONOMICAL OBSERVATORY CHINESE ACAD OF SCI
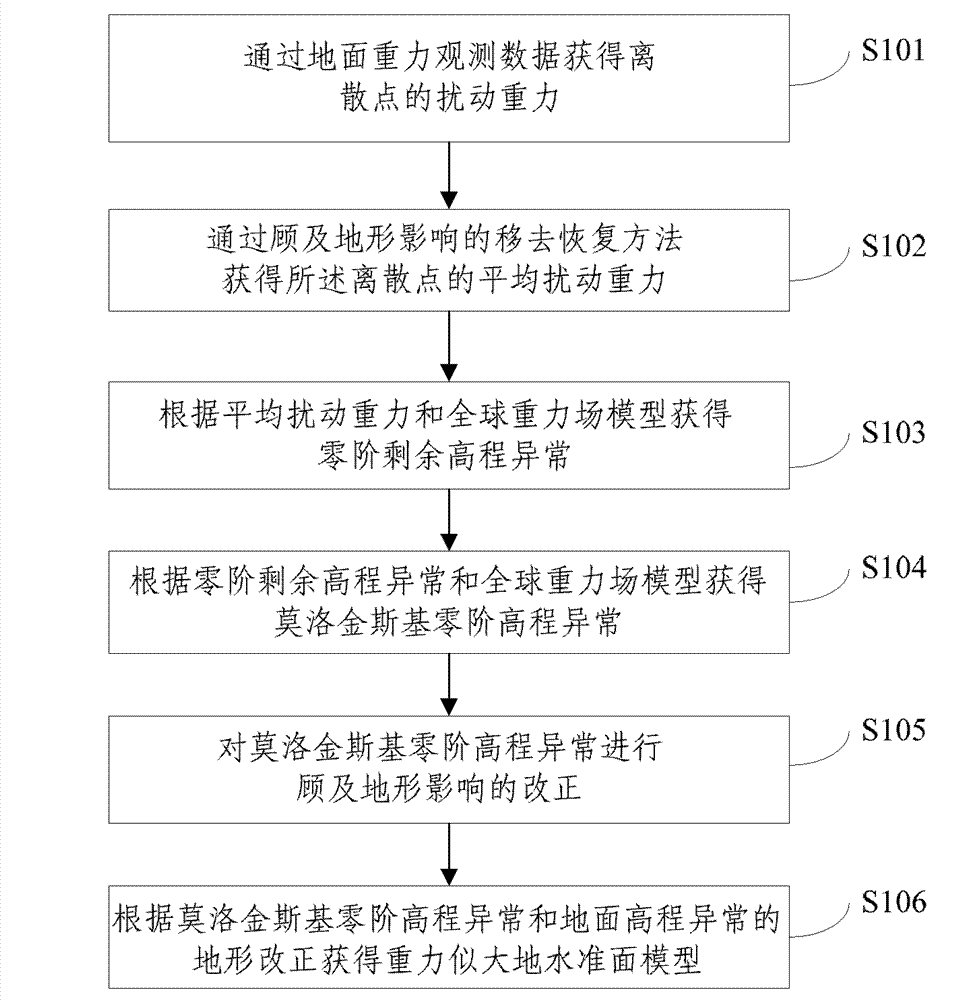
GPS leveling height transfer method
ActiveCN102175213BHigh precisionHeight/levelling measurementIncline measurementObservation dataHeight difference
Owner:CHINESE ACAD OF SURVEYING & MAPPING
A method and system for calibrating an accelerometer using a satellite tracking satellite device
ActiveCN109581523BSolve problems that cannot meet better accuracy requirementsAvoid problems with terrain constraints, etc.Gravitational wave measurementAccelerometerSatellite tracking
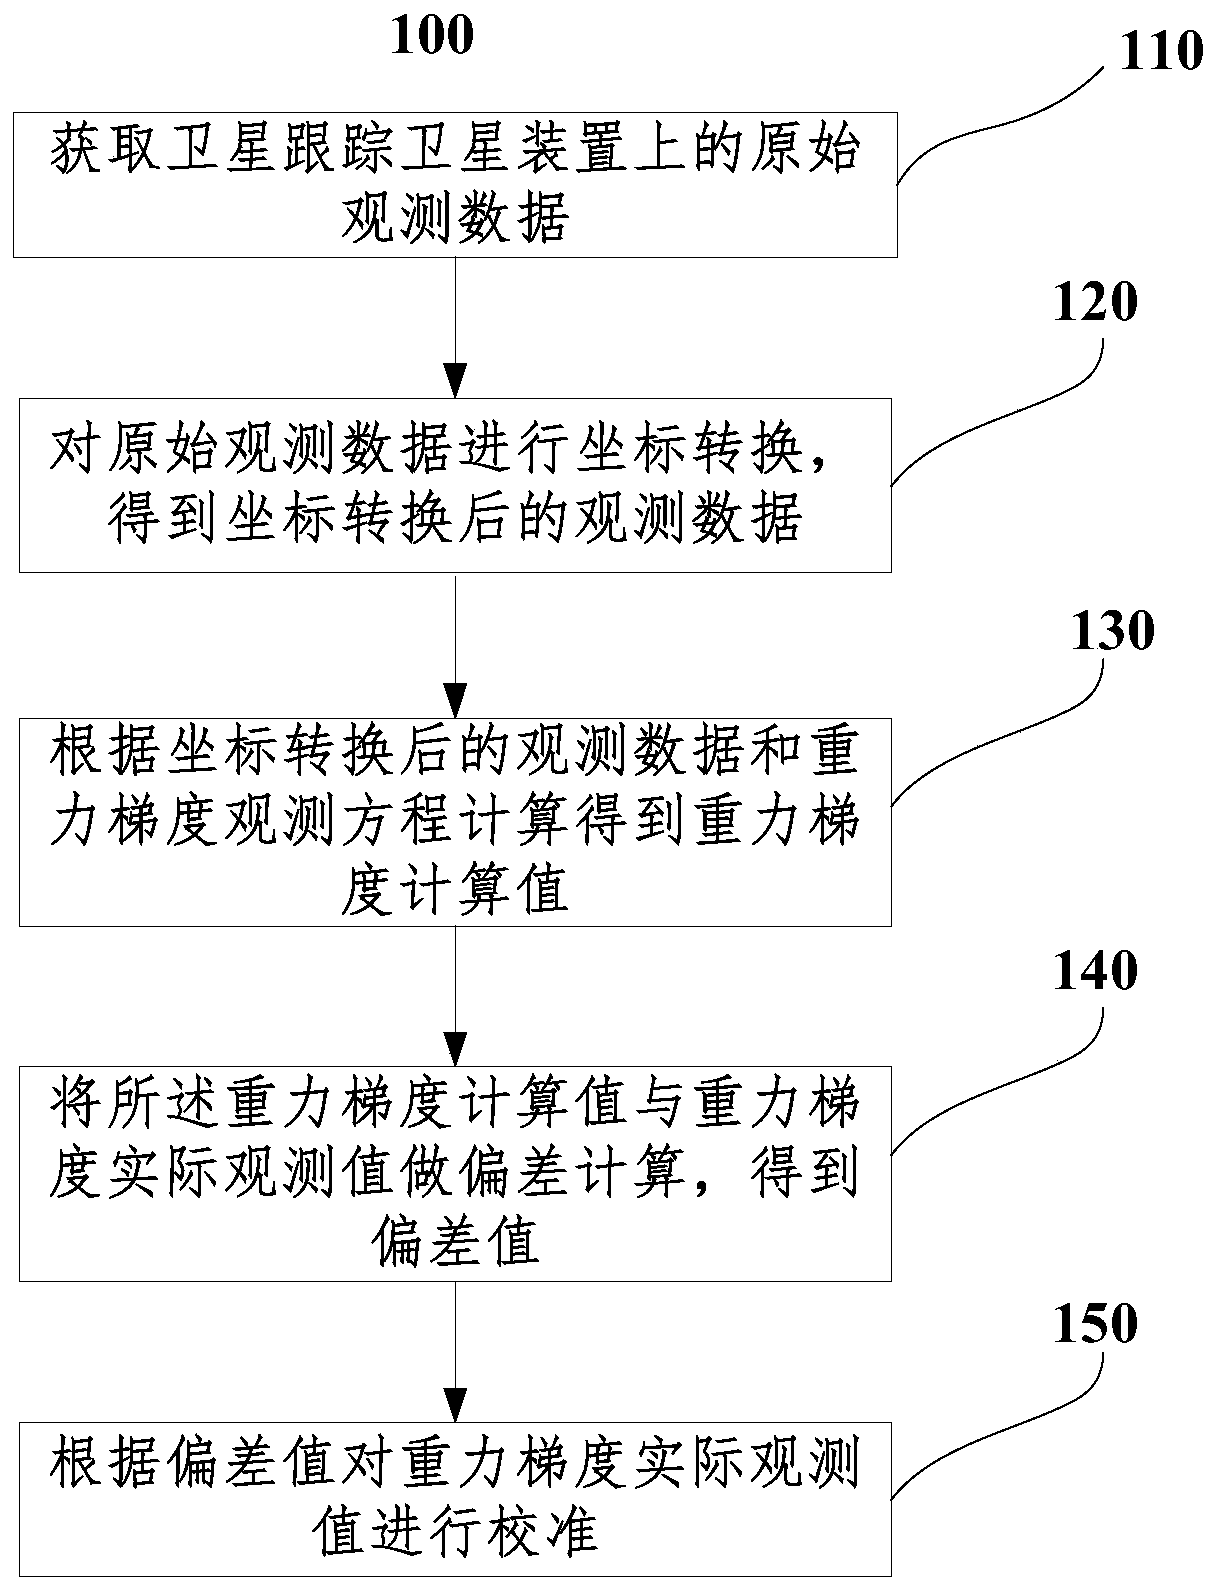
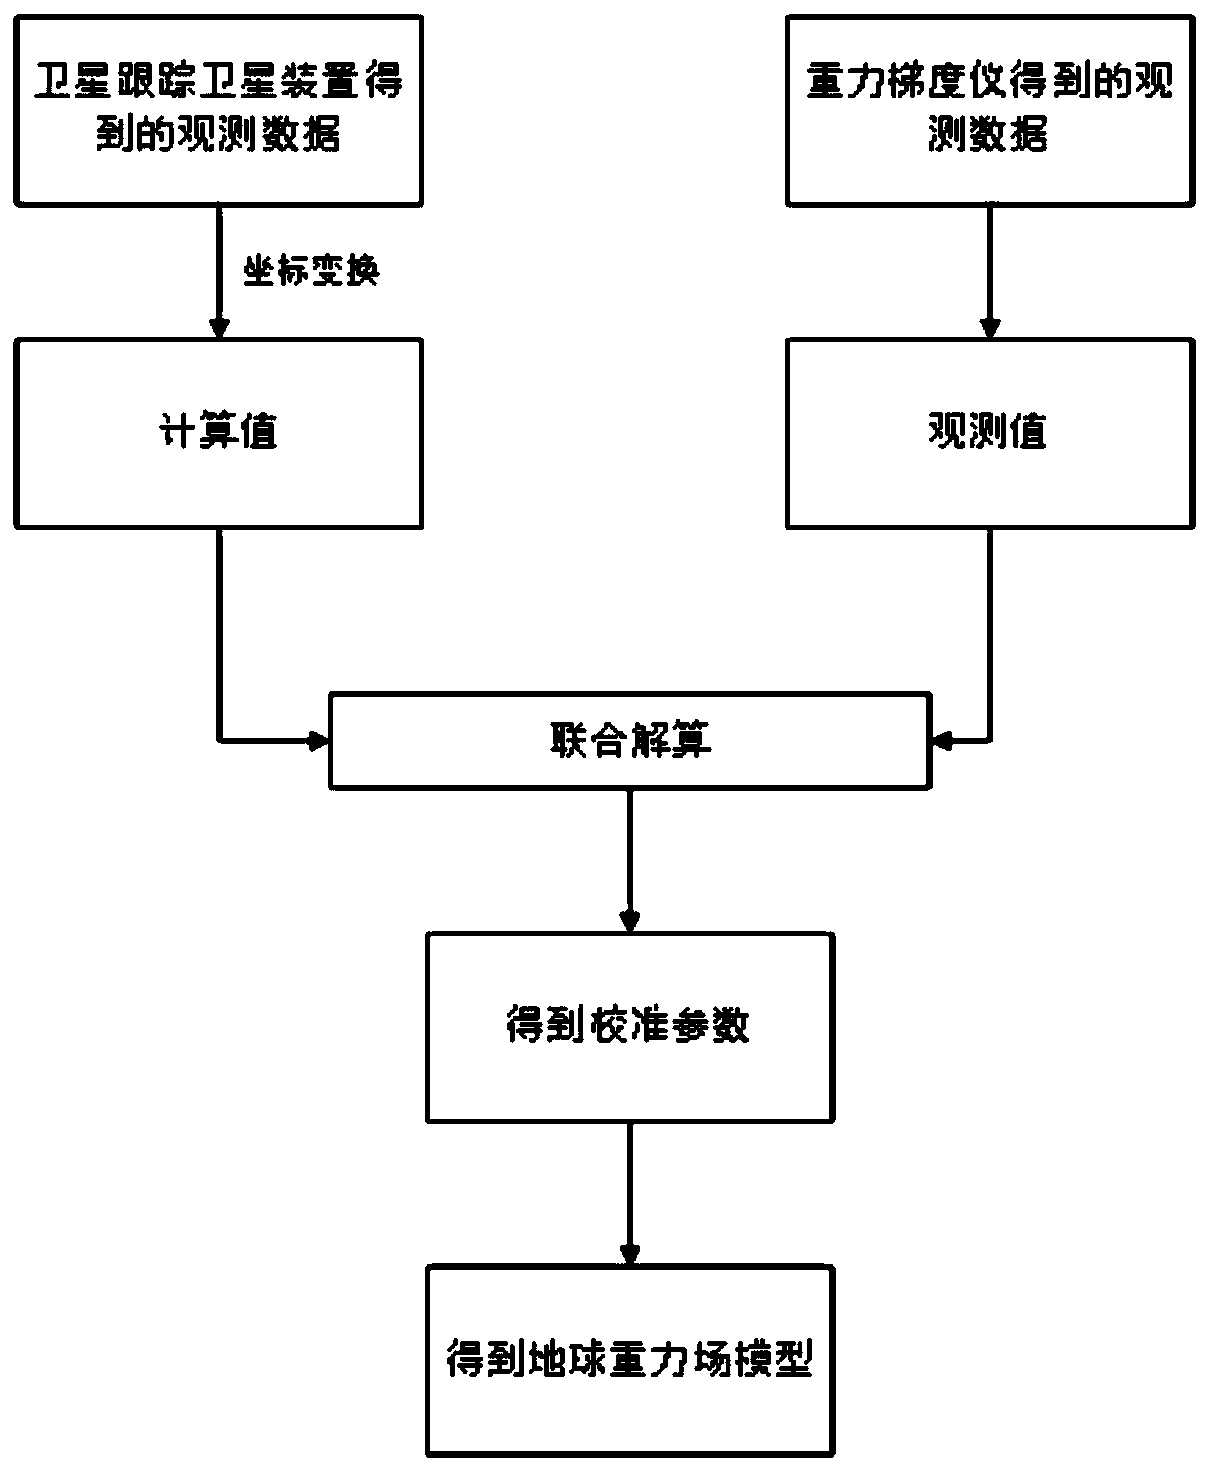
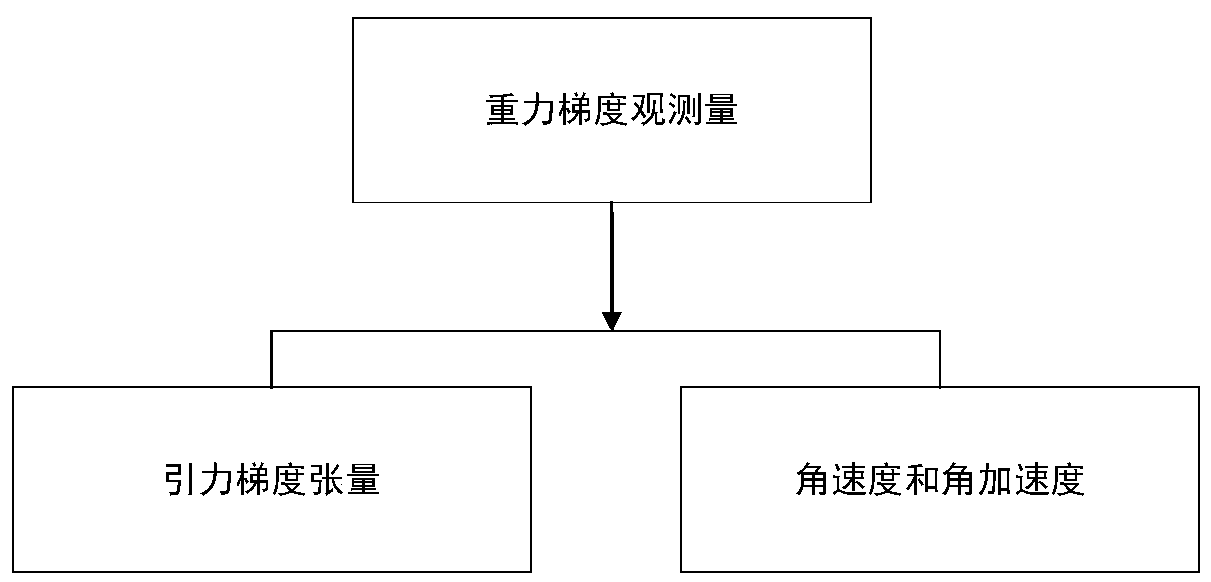
The invention discloses a method and system for calibrating an accelerometer using a satellite-to-satellite tracking device. The method comprises the steps that original observation data on the satellite-to-satellite tracking device is acquired; coordinate transformation is performed on the original observation data to obtain observation data after the coordinate transformation; a gravity gradientcalculated value is calculated and obtained according to the observation data after the coordinate transformation and a gravity gradient observation equation; deviation calculation is performed on the gravity gradient calculated value and an actual gravity gradient observation value to obtain a deviation value; and the actual gravity gradient observation value is calibrated according to the deviation value. The method and system adopt the satellite-to-satellite tracking device to acquire the observation value, and calculate and obtain the gravity gradient calculated value, thereby effectivelysolving the problem that data generated simply by a gravity field model cannot meet better precision requirements, solving the problems such as terrain constraints, and achieving the purpose of high-precision calibration of the gravity accelerometer.
Owner:湖北省地震局
A method and system for real-time regional gravity field modeling based on deep neural networks
This invention relates to the field of deep learning technology and discloses a real-time regional gravity field modeling method and system based on deep neural networks. The method includes the following steps: acquiring ground gravity measurement data and calculating the original ground gravity anomaly at discrete ground points; introducing a global gravity field model to obtain the long-wave gravity anomaly component of the discrete ground points in real time; introducing a deep fully connected neural network (FC-DNN); calculating the short-wave gravity anomaly component of the discrete ground points in real time; introducing a convolutional neural network (CNN); predicting the residual gravity anomaly component of the discrete ground points in real time; and fusing the residual gravity anomaly component, short-wave gravity anomaly component, and long-wave gravity anomaly component of the discrete ground points to complete the modeling of the regional ground gravity field. This invention features high training efficiency and fast inference speed, solving the problem of insufficient computational efficiency in existing gravity field modeling methods.

Owner:SUN YAT SEN UNIV
A gravity inversion accuracy evaluation system and method considering the self-noise of shipborne measurements
ActiveCN120214720BGravitational wave measurementRadio wave reradiation/reflectionSatellite altimetryAtmospheric sciences
The present application provides a gravity inversion accuracy evaluation system and method considering the self-noise of shipborne measurements. The system includes: a shipborne gravity data verification module, which is used to refine the shipborne gravity data, then use the shipborne gravity data to verify the altimetry gravity inversion product to obtain the shipborne verification accuracy of the altimetry gravity inversion product, and use the shipborne gravity data to verify the gravity field model to obtain the shipborne verification accuracy of the gravity field model; a global gravity field model comparison module, which is used to intercept the global gravity field model for comparison to obtain the gravity field model comparison accuracy of the altimetry gravity inversion product; a gravity inversion accuracy evaluation module, which is used to jointly calculate the self-noise of the shipborne verification data and deduct the shipborne self-noise to obtain the accurate satellite altimetry gravity inversion accuracy. The advantages of the present application are: it can effectively remove the influence of the self-noise of shipborne gravity data on the altimetry gravity inversion accuracy and evaluate the accurate altimetry gravity inversion accuracy.

Owner:NAT SPACE SCI CENT CAS